[AAAI 2026 Oral] LiDARCrafter: Dynamic 4D World Modeling from LiDAR Sequences
See the codeEnglish | 简体中文
Ao Liang
Youquan Liu
Yu Yang
Dongyue Lu
Linfeng Li
Lingdong Kong
Huaici Zhao
Wei Tsang Ooi


 |
|---|
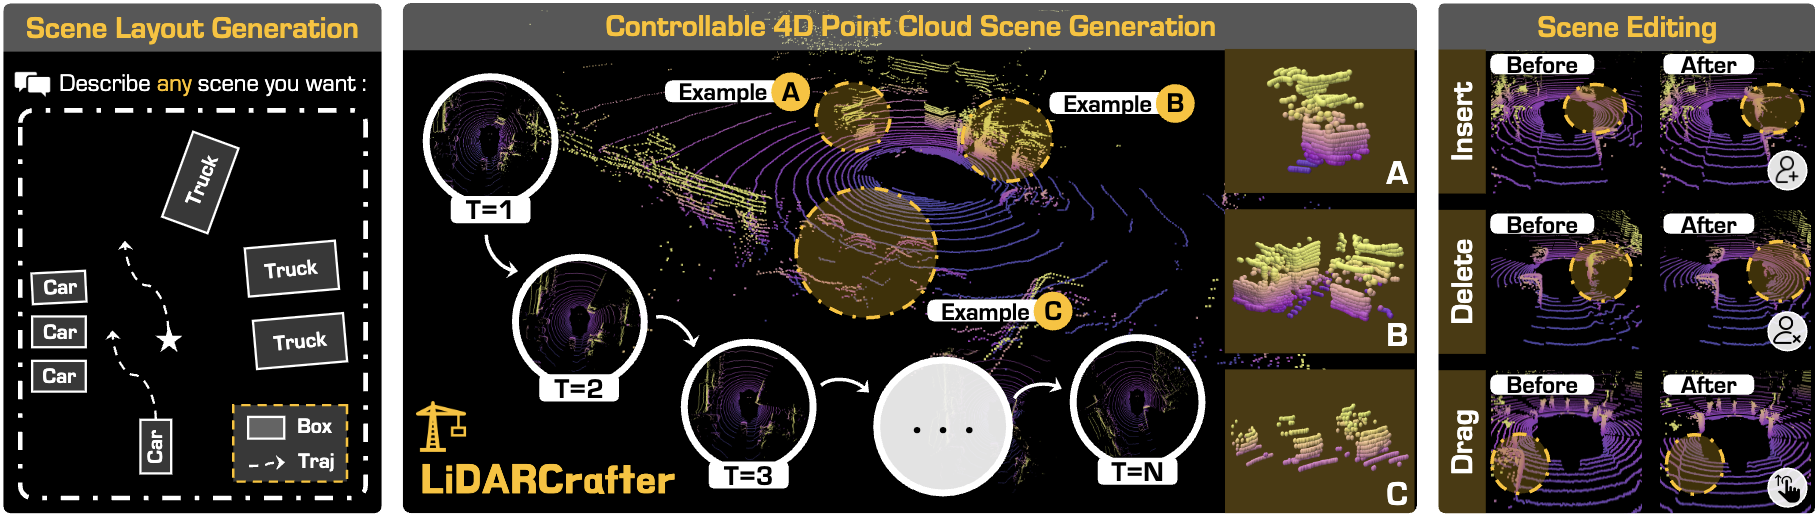
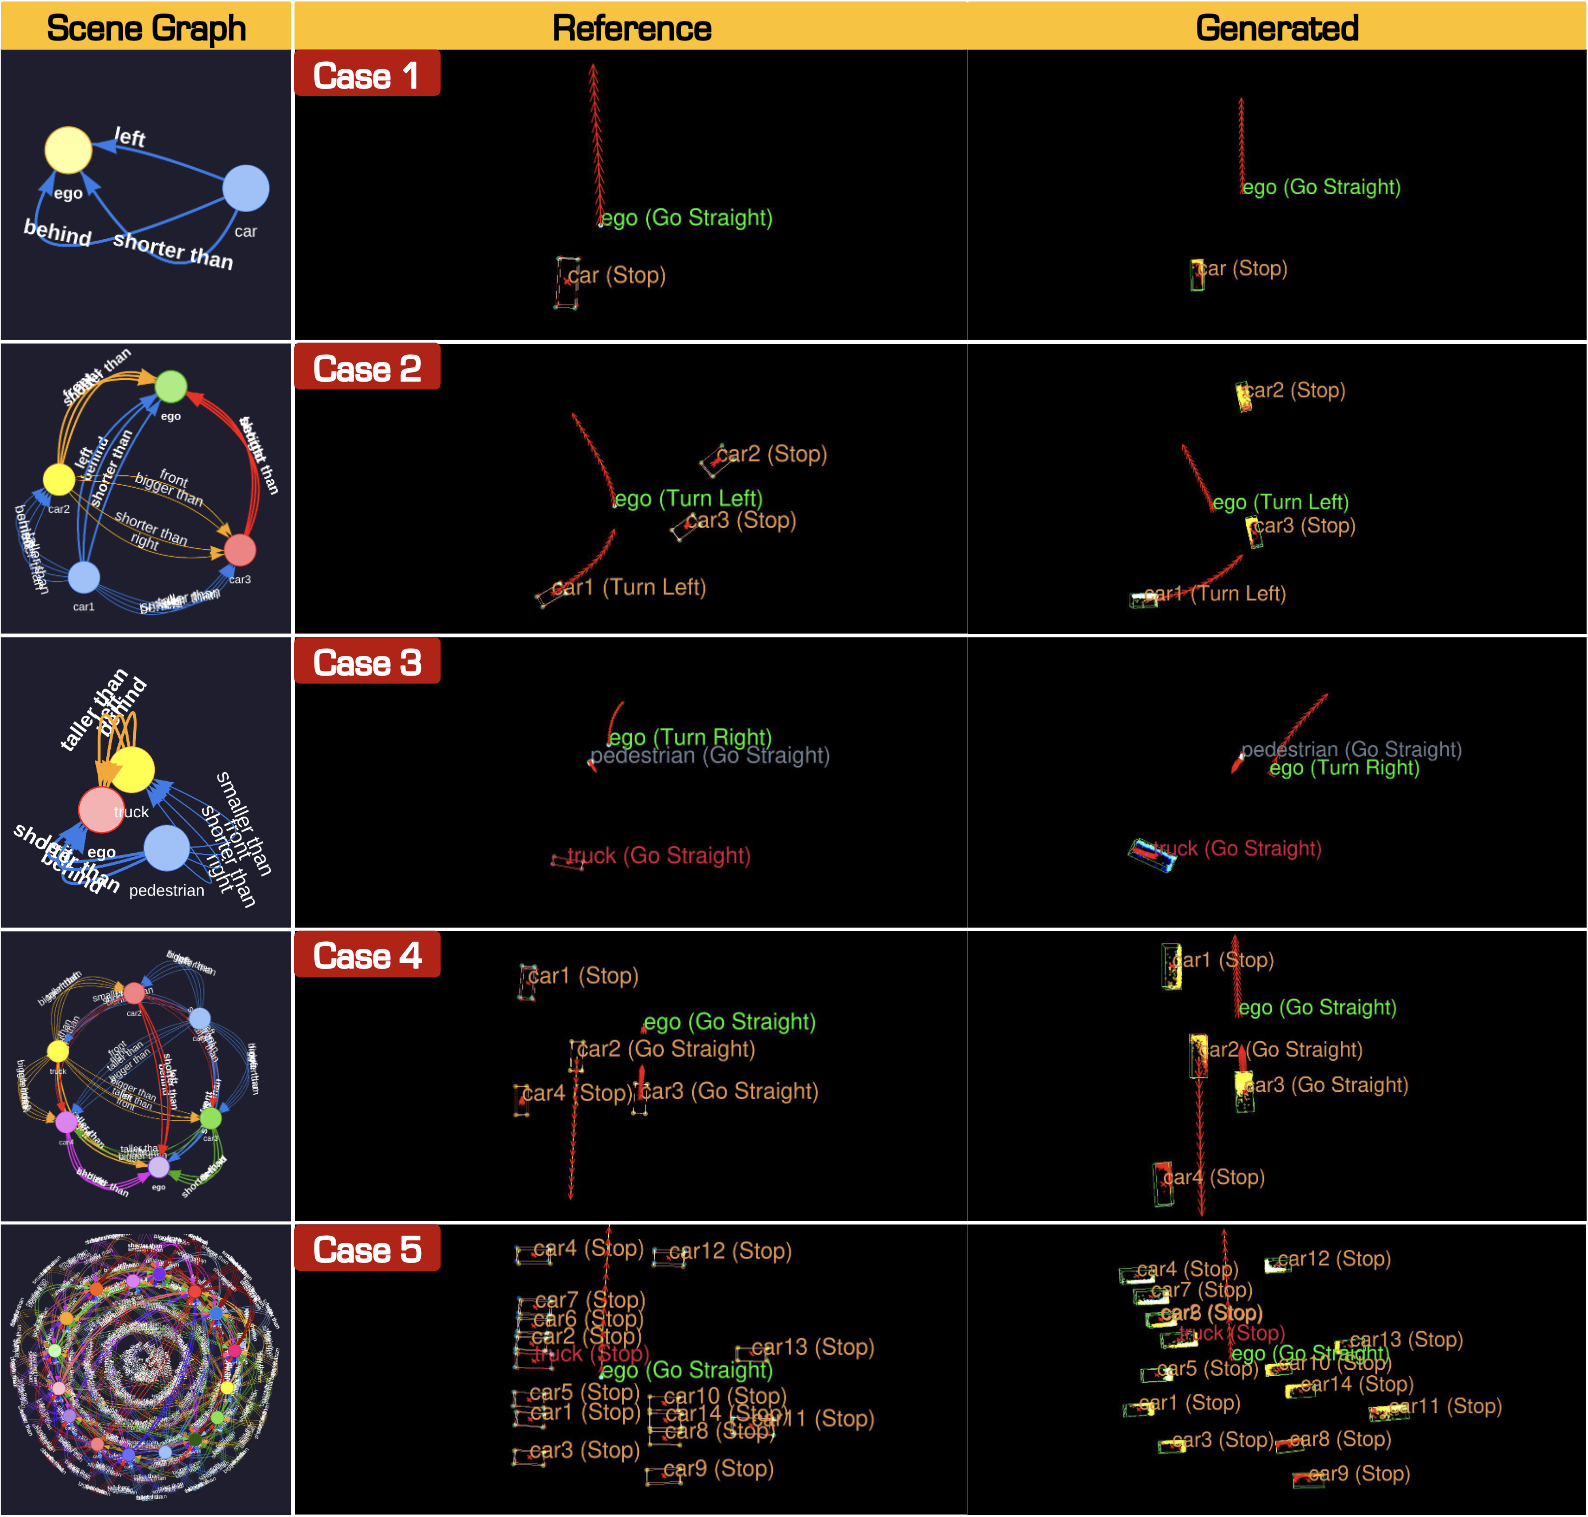
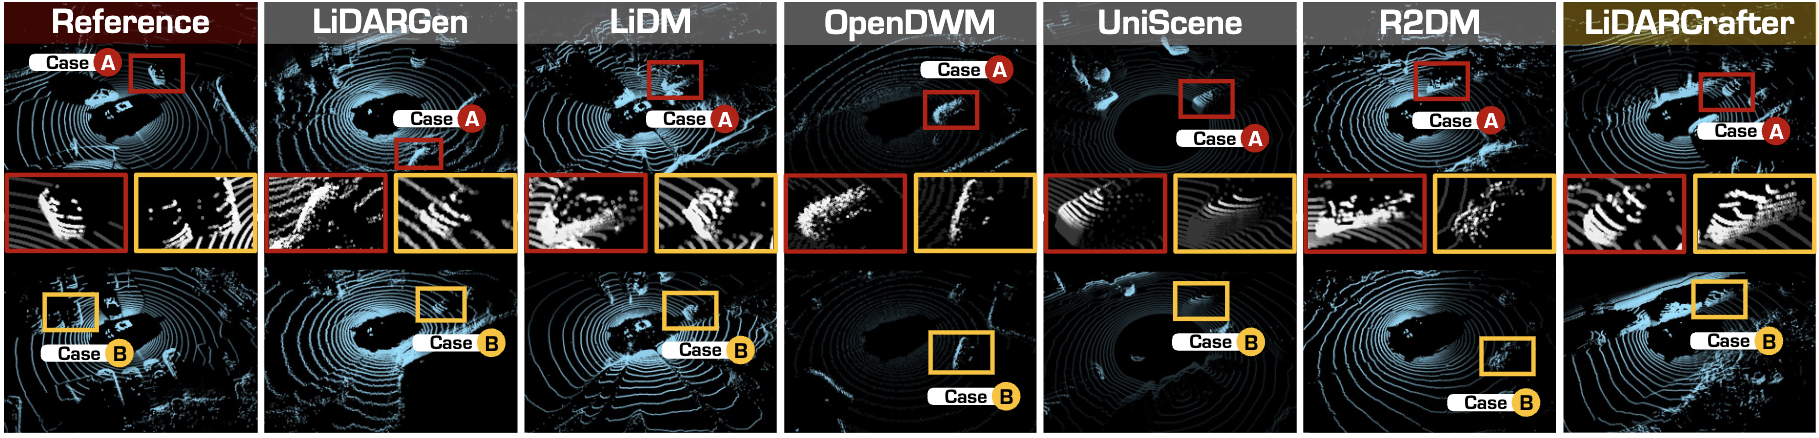
In this work, we introduce LiDARCrafter, a unified framework for 4D LiDAR generation and editing. We contribute:
If you find this work helpful for your research, please kindly consider citing our paper:
@inproceedings{liang2026lidarcrafter,
    title     = {{LiDARCrafter}: Dynamic {4D} World Modeling from {LiDAR} Sequences},
    author    = {Ao Liang and Youquan Liu and Yu Yang and Dongyue Lu and Linfeng Li and Lingdong Kong and Huaici Zhao and Wei Tsang Ooi},
    booktitle = {Proceedings of the AAAI Conference on Artificial Intelligence (AAAI)},
    volume    = {40},
    year      = {2026},
}
Please configure your environment according to the version information in environment.yml.
ln -s ${ROOT_DATA_PATH} ./data/nuscenes
Run bash scripts/create_data.sh for generate:
info with track and state
Updated pkl with scene graph
CLIP feature of scene graph
The file-tree of data is like:
data
├── clips
│   └── nuscenes
│       ├── obj_text_feat.pkl
│       ├── train
│       └── val
├── infos
│   ├── needed_5_framed_token.pkl
│   ├── nuscenes_dbinfos_10sweeps_withvelo.pkl
│   ├── nuscenes_infos_10sweeps_train.pkl
│   ├── nuscenes_infos_10sweeps_val.pkl
│   ├── nuscenes_infos_lidargen_train.pkl
│   ├── nuscenes_infos_lidargen_val.pkl
│   ├── nuscenes_infos_train.pkl
│   ├── nuscenes_infos_val.pkl
│   ├── nuscenes_object_classification_train.pkl
│   └── nuscenes_object_classification_val.pkl
└── nuscenes
python train/train_classification_pointmlp.pypython train/train_uncertainty_glenet.pyFor each generated 1w model
python evaluation/extract_foreground_samples.py --model ori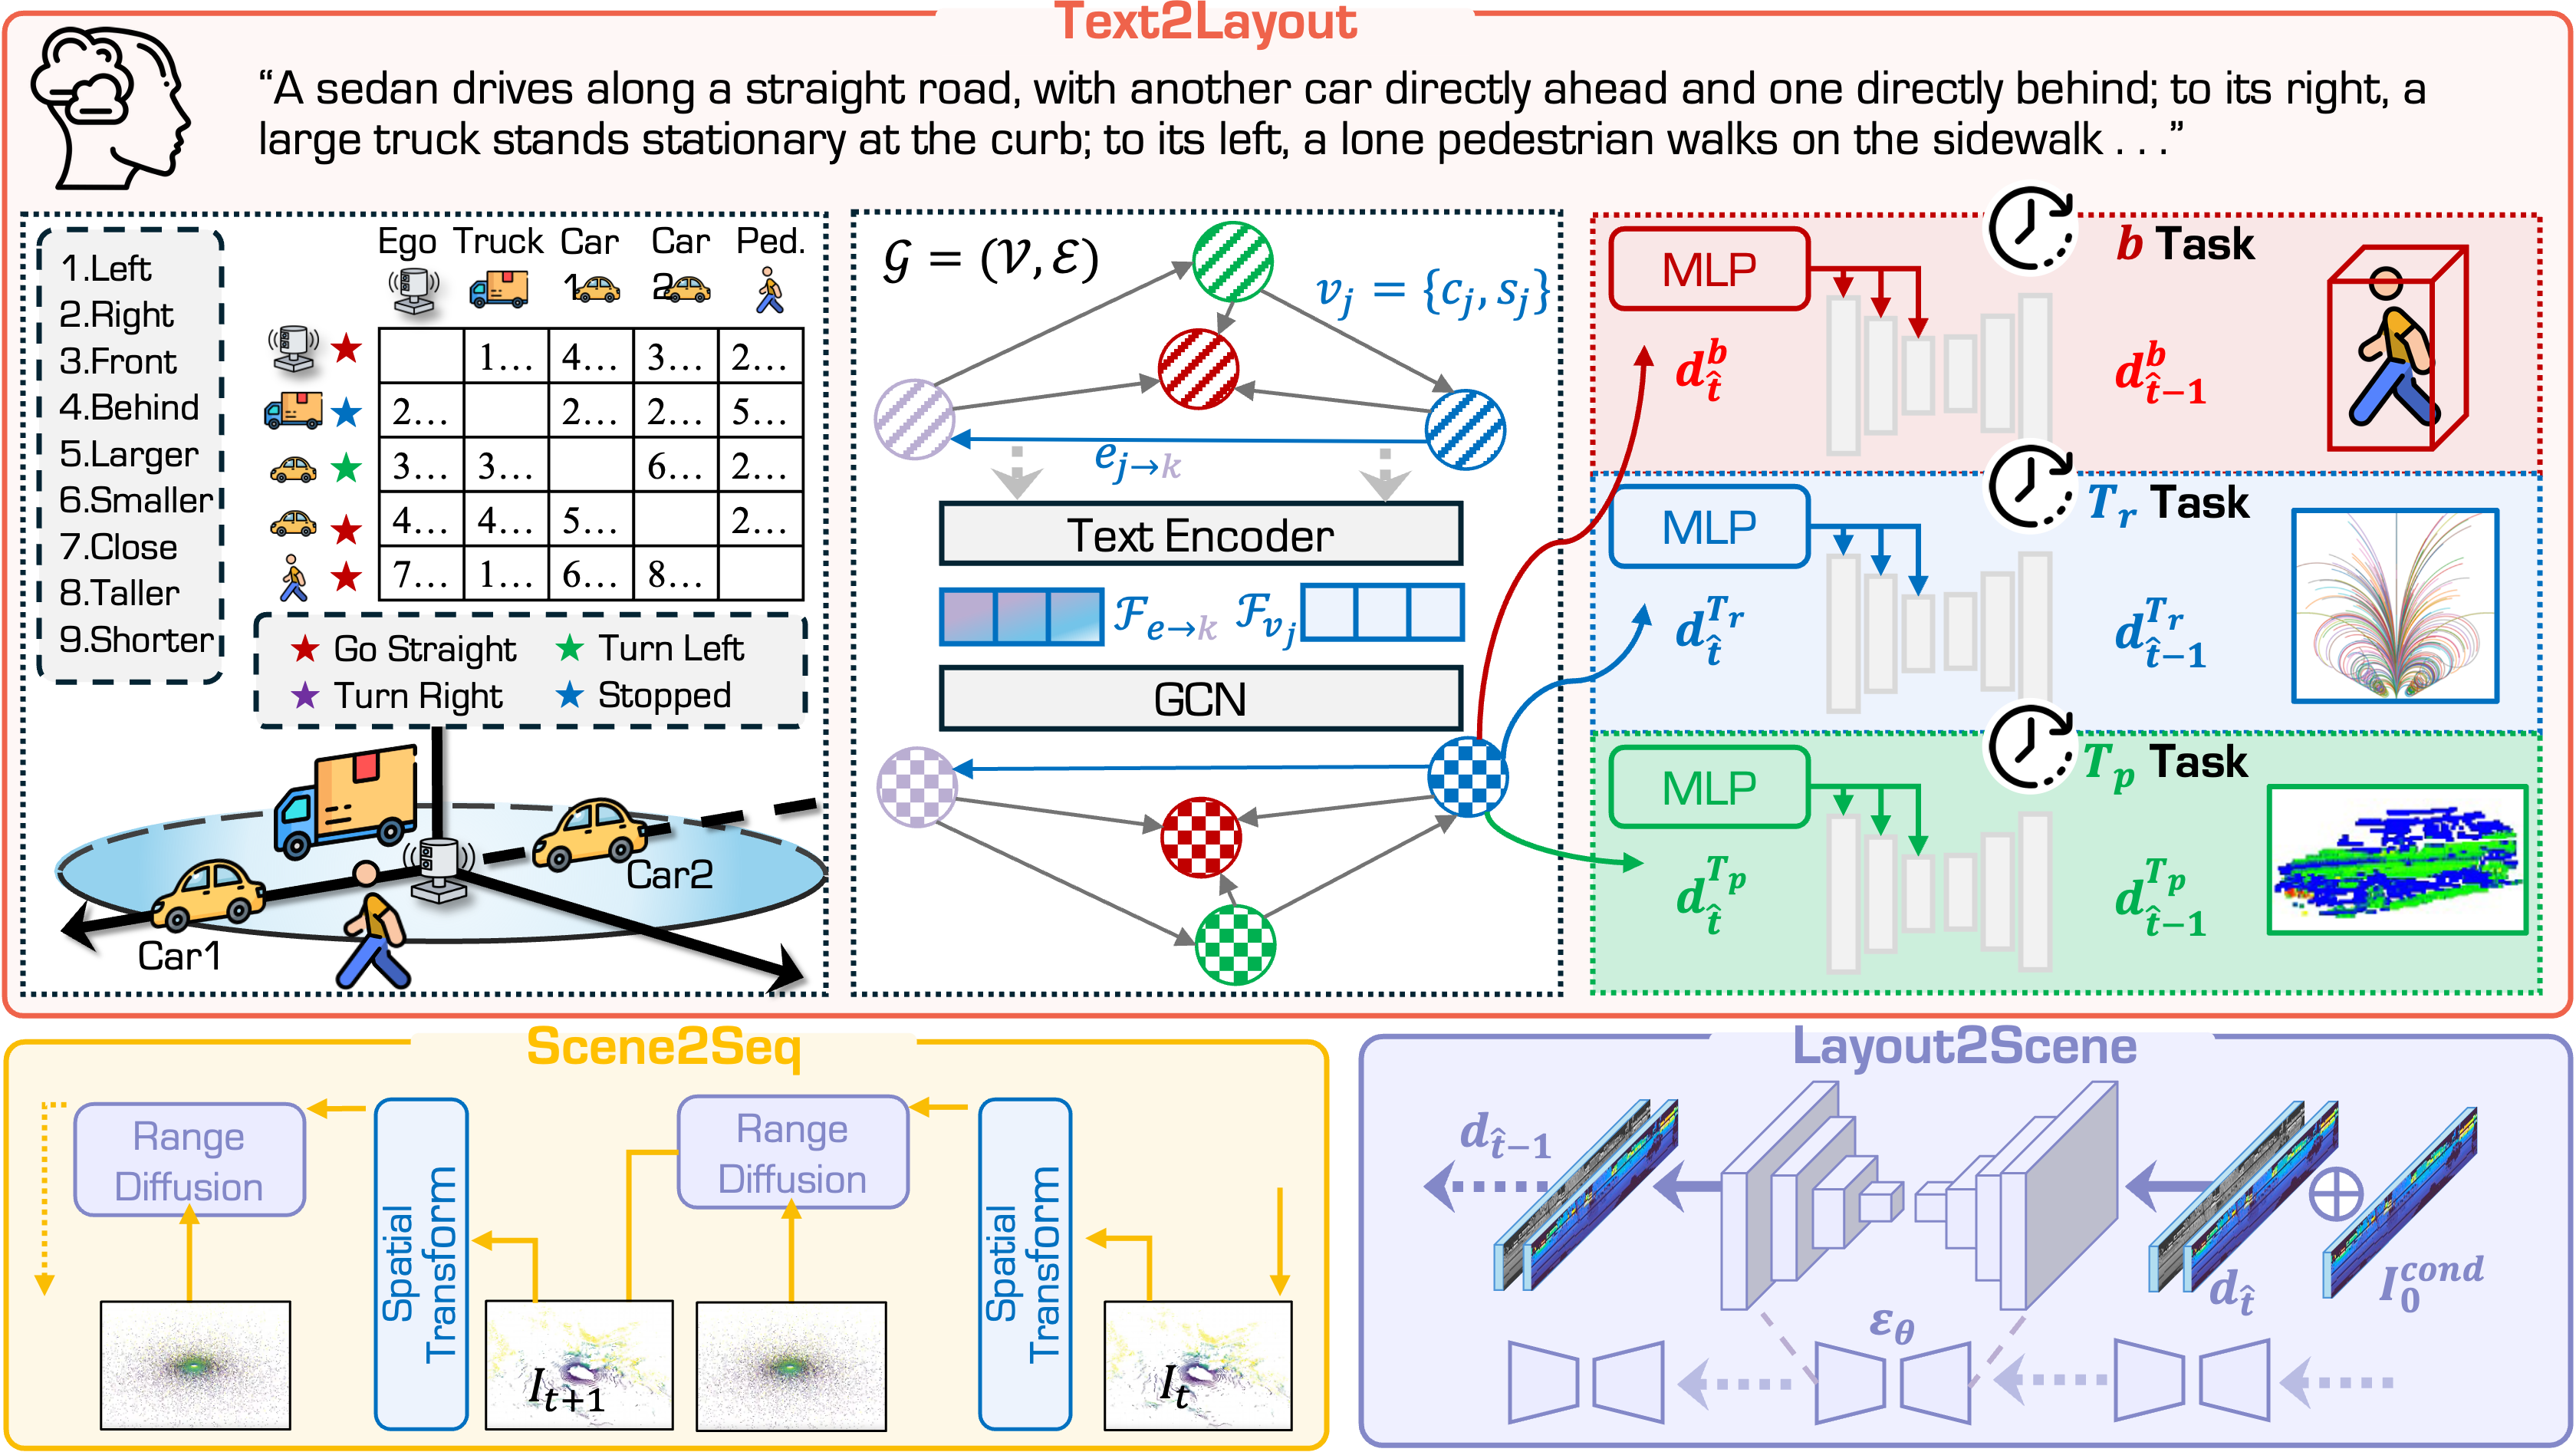 |
|---|
 |
|---|
 |
|---|
To be updated.
This work is under the Apache License Version 2.0, while some specific implementations in this codebase might be under other licenses. Kindly refer to LICENSE.md for a more careful check, if you are using our code for commercial matters.
This work is developed based on the MMDetection3D codebase.
MMDetection3D is an open-source toolbox based on PyTorch, towards the next-generation platform for general 3D perception. It is a part of the OpenMMLab project developed by MMLab.
Part of the benchmarked models are from the OpenPCDet and 3DTrans projects.
| 😎 Awesome | Projects |
|---|---|
 | 3D and 4D World Modeling: A Survey [GitHub Repo] - [Project Page] - [Paper] |
 | WorldLens: Full-Spectrum Evaluations of Driving World Models in Real World [GitHub Repo] - [Project Page] - [Paper] |
 | 3EED: Ground Everything Everywhere in 3D [GitHub Repo] - [Project Page] - [Paper] |
 | Are VLMs Ready for Autonomous Driving? A Study from Reliability, Data & Metric Perspectives [GitHub Repo] - [Project Page] - [Paper] |
 | Perspective-Invariant 3D Object Detection [GitHub Repo] - [Project Page] - [Paper] |
 | DynamicCity: Large-Scale 4D Occupancy Generation from Dynamic Scenes [GitHub Repo] - [Project Page] - [Paper] |
114 followers · starred Aug 2025
[AAAI 2026 Oral] LiDARCrafter: Dynamic 4D World Modeling from LiDAR Sequences
See the codeEnglish | 简体中文
Ao Liang
Youquan Liu
Yu Yang
Dongyue Lu
Linfeng Li
Lingdong Kong
Huaici Zhao
Wei Tsang Ooi
|
|---|
In this work, we introduce LiDARCrafter, a unified framework for 4D LiDAR generation and editing. We contribute:
If you find this work helpful for your research, please kindly consider citing our paper:
@inproceedings{liang2026lidarcrafter,
    title     = {{LiDARCrafter}: Dynamic {4D} World Modeling from {LiDAR} Sequences},
    author    = {Ao Liang and Youquan Liu and Yu Yang and Dongyue Lu and Linfeng Li and Lingdong Kong and Huaici Zhao and Wei Tsang Ooi},
    booktitle = {Proceedings of the AAAI Conference on Artificial Intelligence (AAAI)},
    volume    = {40},
    year      = {2026},
}
Please configure your environment according to the version information in environment.yml.
ln -s ${ROOT_DATA_PATH} ./data/nuscenes
Run bash scripts/create_data.sh for generate:
info with track and state
Updated pkl with scene graph
CLIP feature of scene graph
The file-tree of data is like:
data
├── clips
│   └── nuscenes
│       ├── obj_text_feat.pkl
│       ├── train
│       └── val
├── infos
│   ├── needed_5_framed_token.pkl
│   ├── nuscenes_dbinfos_10sweeps_withvelo.pkl
│   ├── nuscenes_infos_10sweeps_train.pkl
│   ├── nuscenes_infos_10sweeps_val.pkl
│   ├── nuscenes_infos_lidargen_train.pkl
│   ├── nuscenes_infos_lidargen_val.pkl
│   ├── nuscenes_infos_train.pkl
│   ├── nuscenes_infos_val.pkl
│   ├── nuscenes_object_classification_train.pkl
│   └── nuscenes_object_classification_val.pkl
└── nuscenes
python train/train_classification_pointmlp.pypython train/train_uncertainty_glenet.pyFor each generated 1w model
python evaluation/extract_foreground_samples.py --model ori |
|---|
|
|---|
|
|---|
To be updated.
This work is under the Apache License Version 2.0, while some specific implementations in this codebase might be under other licenses. Kindly refer to LICENSE.md for a more careful check, if you are using our code for commercial matters.
This work is developed based on the MMDetection3D codebase.
MMDetection3D is an open-source toolbox based on PyTorch, towards the next-generation platform for general 3D perception. It is a part of the OpenMMLab project developed by MMLab.
Part of the benchmarked models are from the OpenPCDet and 3DTrans projects.
| 😎 Awesome | Projects |
|---|---|
| 3D and 4D World Modeling: A Survey [GitHub Repo] - [Project Page] - [Paper] |
| WorldLens: Full-Spectrum Evaluations of Driving World Models in Real World [GitHub Repo] - [Project Page] - [Paper] |
| 3EED: Ground Everything Everywhere in 3D [GitHub Repo] - [Project Page] - [Paper] |
| Are VLMs Ready for Autonomous Driving? A Study from Reliability, Data & Metric Perspectives [GitHub Repo] - [Project Page] - [Paper] |
| Perspective-Invariant 3D Object Detection [GitHub Repo] - [Project Page] - [Paper] |
| DynamicCity: Large-Scale 4D Occupancy Generation from Dynamic Scenes [GitHub Repo] - [Project Page] - [Paper] |
114 followers · starred Aug 2025



