[ICLR 2025 Spotlight] Official implementation for "DynamicCity: Large-Scale 4D Occupancy Generation from Dynamic Scenes"
See the code
Hengwei Bian1,2,*
Lingdong Kong1,3
Haozhe Xie4
Liang Pan1,†,‡
Yu Qiao1
Ziwei Liu4
1Shanghai AI Laboratory
2Carnegie Mellon University
3National University of Singapore
4S-Lab, Nanyang Technological University
*Work done during an internship at Shanghai AI Laboratory
†Corresponding author
‡Project lead


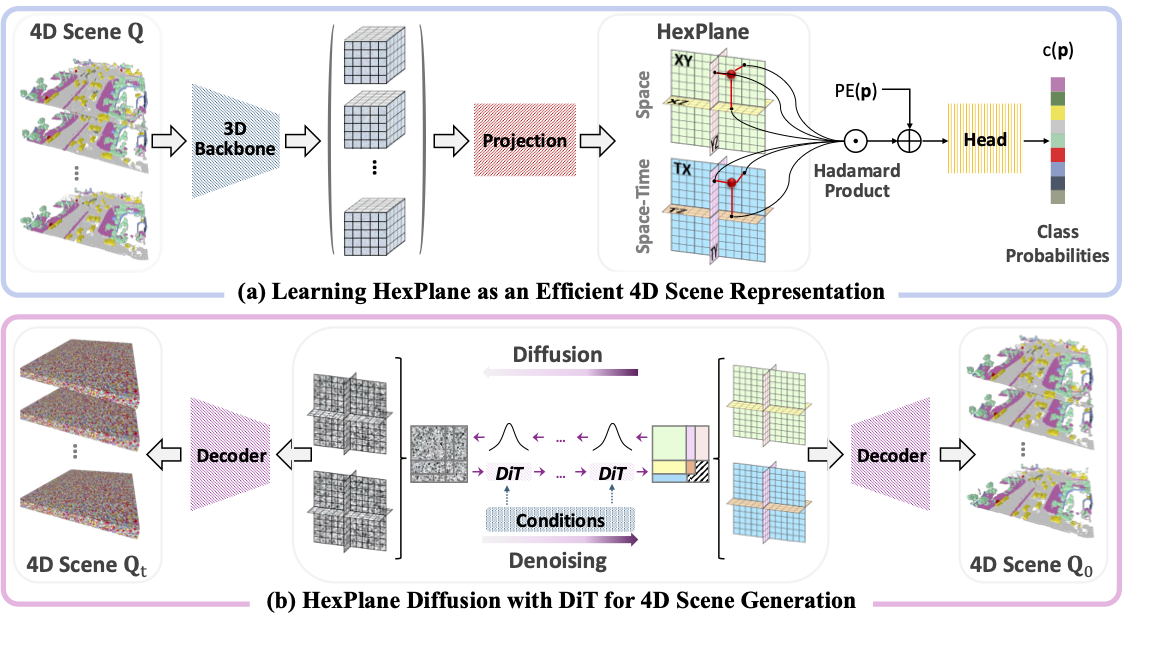
Our DynamicCity framework consists of two key procedures: (a) Encoding HexPlane with an VAE architecture, and (b) 4D Scene Generation with HexPlane DiT.
conda create -n dyncity python=3.10 -y
conda activate dyncity
conda install pytorch==2.4.0 pytorch-cuda=11.8 -c pytorch -c nvidia
conda install einops hydra-core matplotlib numpy omegaconf timm tqdm wandb -c conda-forge -y
pip install flash-attn --no-build-isolation
Download the CarlaSC dataset from here and extract it into
the ./carlasc directory.
Your repository should look like this:
DynamicCity
├── carlasc/
│   ├── Cartesian/
│   │   ├── Train/
│   │   │   ├── Town01_Heavy
│   │   │   ├── ...
│   │   ├── Test/
├── ...
You can obtain our checkpoints from here.
To use the pretrained models, simply unzip ckpts.zip as ./ckpts and run infer_dit.py.
To train VAE on CarlaSC dataset, run the following command:
torchrun --nproc-per-node 8 train.py VAE carlasc name=DYNAMIC_CITY_VAE
After VAE is trained, save hexplane rollouts using:
torchrun --nproc-per-node 8 infer_vae.py -n DYNAMIC_CITY_VAE --save_rollout --best
Then, you can train your DiT using this command:
torchrun --nproc-per-node 8 train.py DiT carlasc name=DYNAMIC_CITY_DIT vae_name=DYNAMIC_CITY_VAE
Finally, use DiT to sample novel city scenes:
torchrun --nproc-per-node 8 infer_dit.py -d DYNAMIC_CITY_DIT --best_vae
 |  |  |
 |  |  |
 |  |  |
 |  |
 |  |
If you find this work helpful for your research, please kindly consider citing our papers:
@inproceedings{bian2025dynamiccity,
  title={DynamicCity: Large-Scale 4D Occupancy Generation from Dynamic Scenes},
  author={Bian, Hengwei and Kong, Lingdong and Xie, Haozhe and Pan, Liang and Qiao, Yu and Liu, Ziwei},
  booktitle={Proceedings of the International Conference on Learning Representations (ICLR)},
  year={2025},
}
484 followers · starred Oct 2024
78 followers · starred Nov 2024
271 followers · starred Oct 2024
38 followers · starred Jan 2025
[ICLR 2025 Spotlight] Official implementation for "DynamicCity: Large-Scale 4D Occupancy Generation from Dynamic Scenes"
See the code
Hengwei Bian1,2,*
Lingdong Kong1,3
Haozhe Xie4
Liang Pan1,†,‡
Yu Qiao1
Ziwei Liu4
1Shanghai AI Laboratory
2Carnegie Mellon University
3National University of Singapore
4S-Lab, Nanyang Technological University
*Work done during an internship at Shanghai AI Laboratory
†Corresponding author
‡Project lead
Our DynamicCity framework consists of two key procedures: (a) Encoding HexPlane with an VAE architecture, and (b) 4D Scene Generation with HexPlane DiT.
conda create -n dyncity python=3.10 -y
conda activate dyncity
conda install pytorch==2.4.0 pytorch-cuda=11.8 -c pytorch -c nvidia
conda install einops hydra-core matplotlib numpy omegaconf timm tqdm wandb -c conda-forge -y
pip install flash-attn --no-build-isolation
Download the CarlaSC dataset from here and extract it into
the ./carlasc directory.
Your repository should look like this:
DynamicCity
├── carlasc/
│   ├── Cartesian/
│   │   ├── Train/
│   │   │   ├── Town01_Heavy
│   │   │   ├── ...
│   │   ├── Test/
├── ...
You can obtain our checkpoints from here.
To use the pretrained models, simply unzip ckpts.zip as ./ckpts and run infer_dit.py.
To train VAE on CarlaSC dataset, run the following command:
torchrun --nproc-per-node 8 train.py VAE carlasc name=DYNAMIC_CITY_VAE
After VAE is trained, save hexplane rollouts using:
torchrun --nproc-per-node 8 infer_vae.py -n DYNAMIC_CITY_VAE --save_rollout --best
Then, you can train your DiT using this command:
torchrun --nproc-per-node 8 train.py DiT carlasc name=DYNAMIC_CITY_DIT vae_name=DYNAMIC_CITY_VAE
Finally, use DiT to sample novel city scenes:
torchrun --nproc-per-node 8 infer_dit.py -d DYNAMIC_CITY_DIT --best_vae
| | |
| | |
| | |
| |
| |
If you find this work helpful for your research, please kindly consider citing our papers:
@inproceedings{bian2025dynamiccity,
  title={DynamicCity: Large-Scale 4D Occupancy Generation from Dynamic Scenes},
  author={Bian, Hengwei and Kong, Lingdong and Xie, Haozhe and Pan, Liang and Qiao, Yu and Liu, Ziwei},
  booktitle={Proceedings of the International Conference on Learning Representations (ICLR)},
  year={2025},
}
484 followers · starred Oct 2024
78 followers · starred Nov 2024
271 followers · starred Oct 2024
38 followers · starred Jan 2025



