Open-source leader + follower robot arm kit: 5 DOF + gripper, PET-CF frame, parallel gripper, LeRobot-compatible. STEP/STL, BOM, print and assembly guide.
See the codeEnglish · Русский · Español · Français · Deutsch · Português (Brasil) · 简体中文 · 日本語 · हिन्दी · العربية
🎥 Watch the preview video · 🛒 Buy the kit
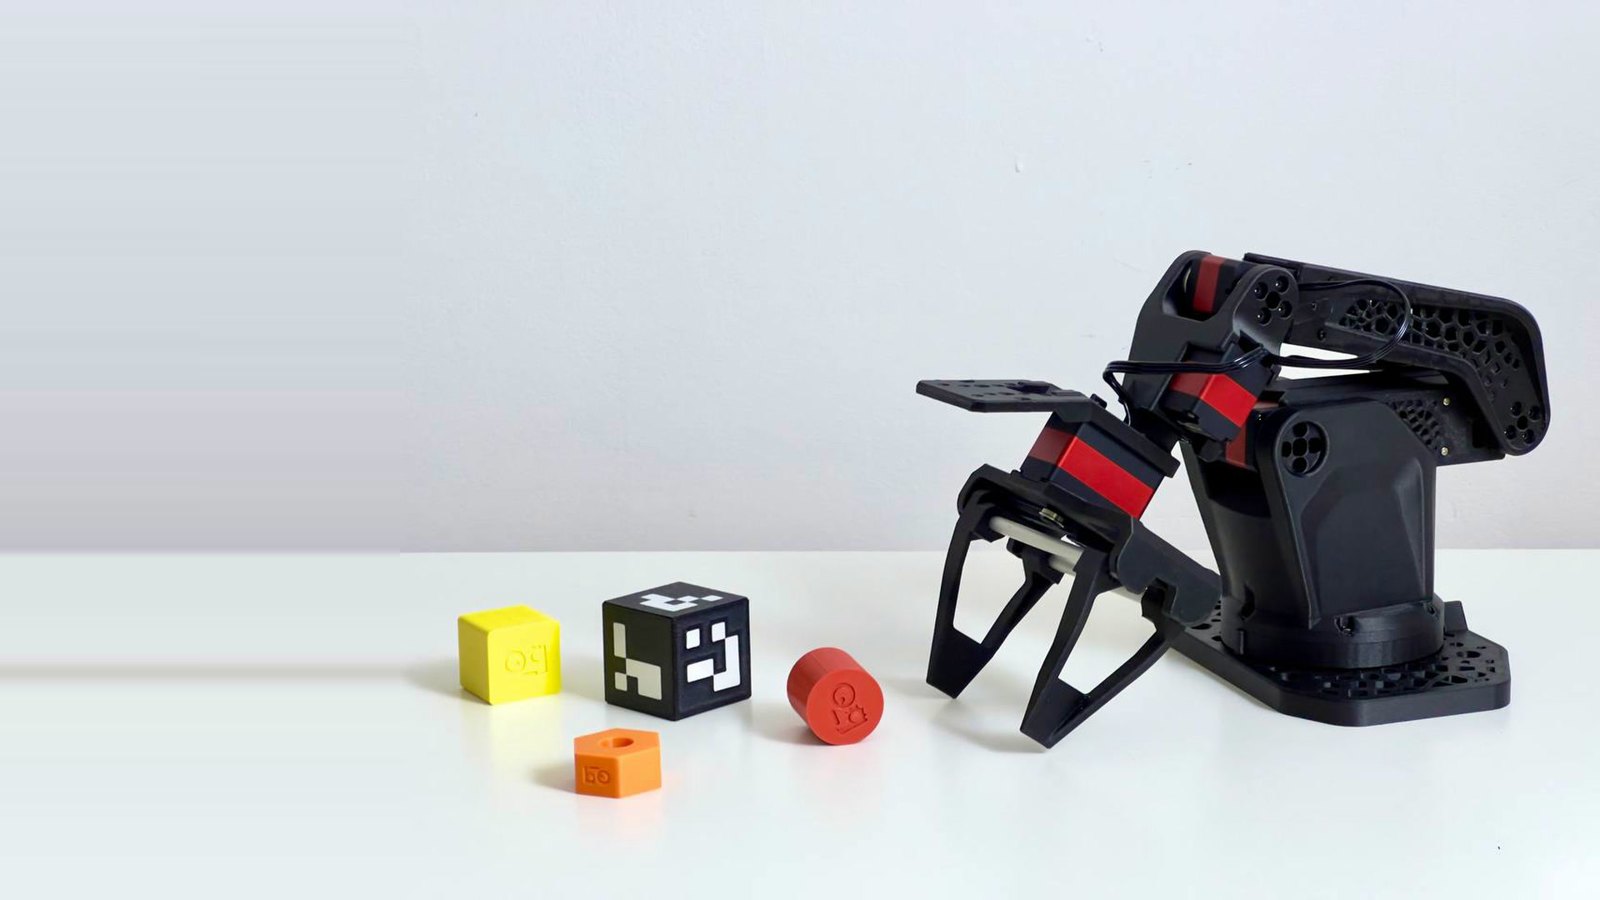
An open-source leader + follower robot arm kit with 5 degrees of freedom plus a gripper for teleoperation and imitation learning, designed by Robonine as a stiffer, faster successor to the SO-ARM 101.
DIY budget: ~$404 for components, or ~$444 including printing material. BOM summary · Itemised costs and purchase links
Rather not source the parts and print them yourself? Buy the SO-ARM 102 kit.
| SO-ARM 101 | SO-ARM 102 | |
|---|---|---|
| Gripper | Angular jaw | Parallel gripper, 85 mm span |
| Frame material | PLA | PET-CF (Fiberon PET-CF17 tested) |
| Structure | Solid links | Topology-optimised links |
| Base rotation range | 220° | 352° |
| Horizontal reach | 441 mm | 483 mm |
| Deflection at the gripper, 300 g load ¹ | 7.5 mm | 3.4–3.9 mm |
| Shoulder and elbow speed | 45 RPM (STS3215) | 75 RPM (STS3250) |
| Noise at 1 m | 70 dB | 60 dB |
¹ Both arms built with printed servo dummies, so the frame is compared, not the motors. Full results and test conditions are in docs/specifications.md.
The arm keeps the SO-ARM 101 joint layout, so it works with Hugging Face LeRobot datasets and policies.
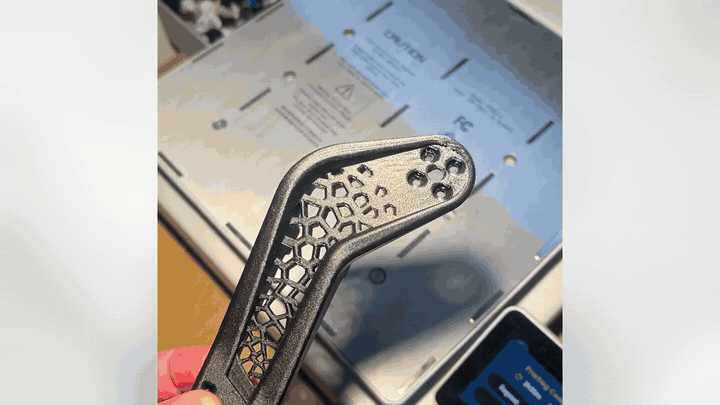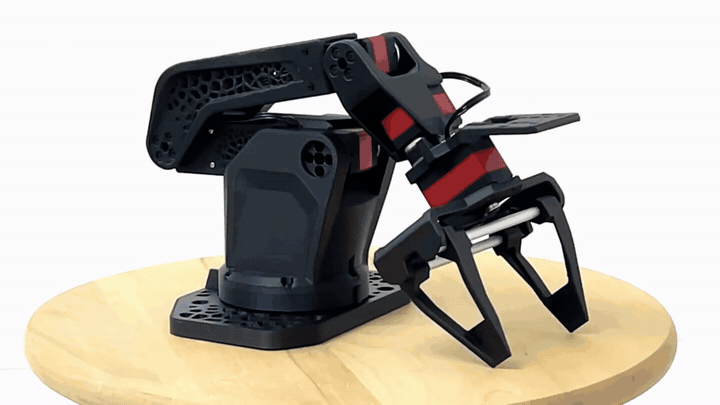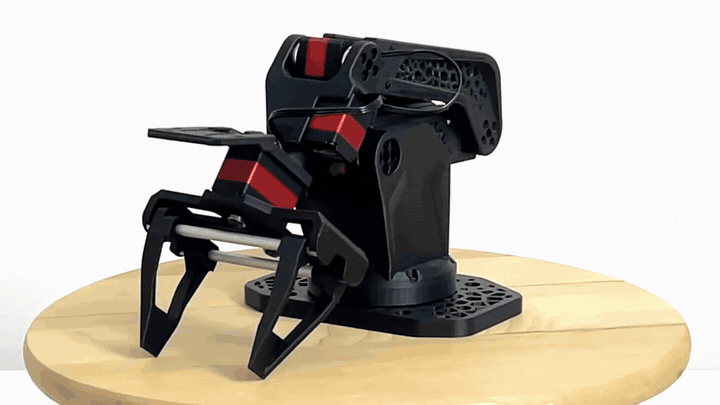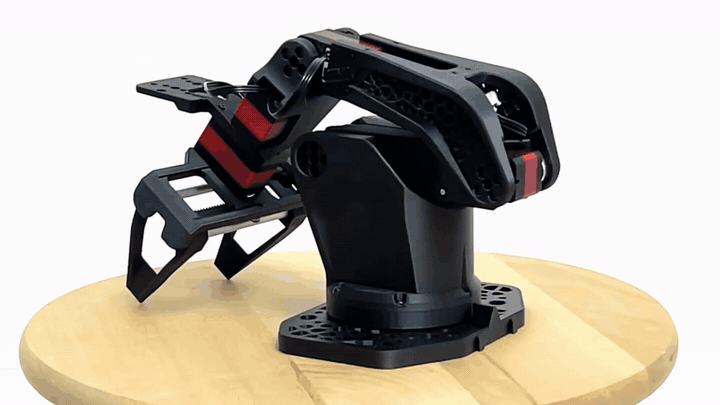
Click for the full video, 21 s
The standard kit. Move the leader by hand, and the follower repeats the motion. Use it for teleoperation and for recording demonstrations for imitation learning.
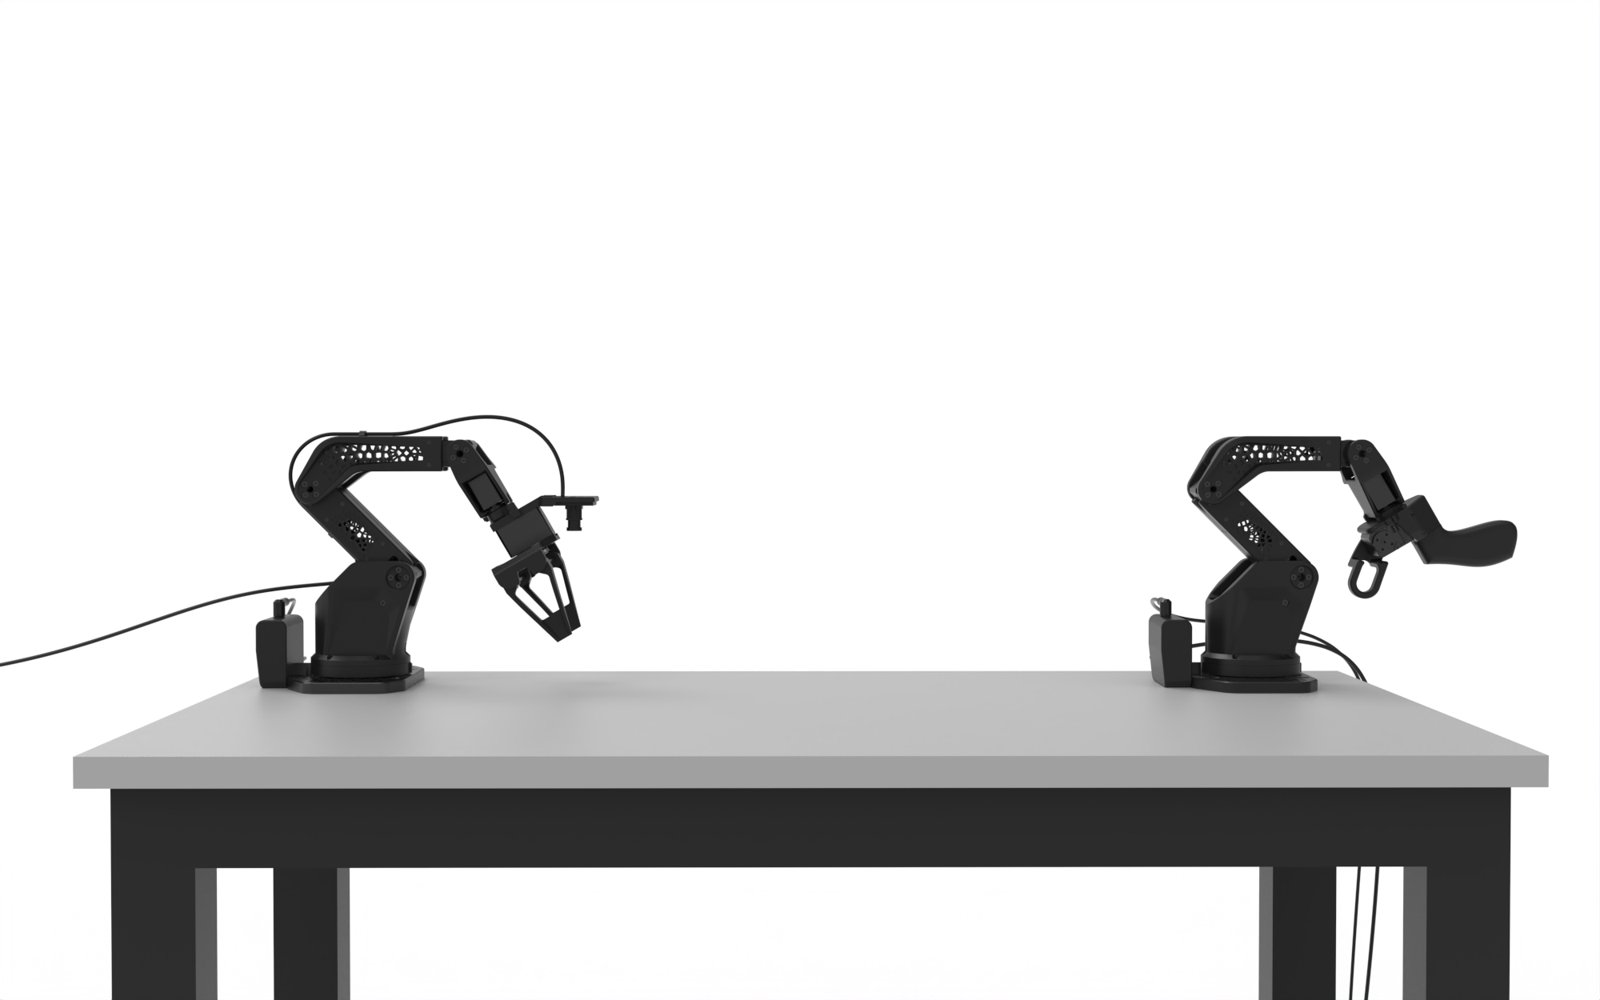
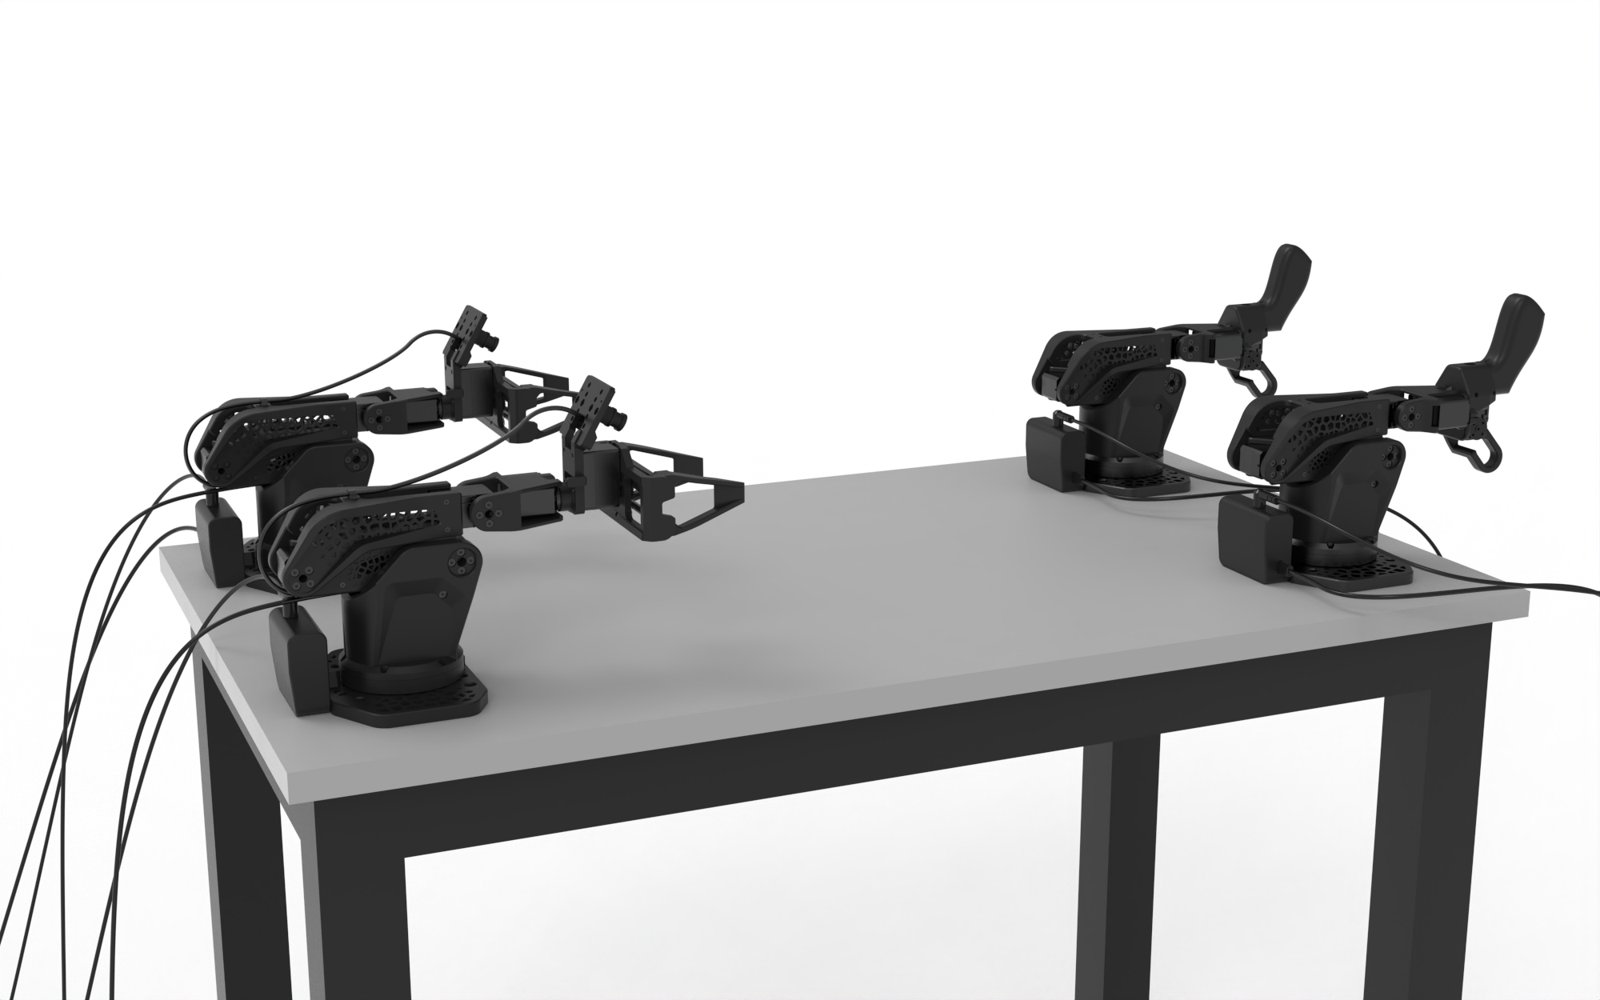
Two kits side by side. Each hand drives its own leader, so the followers can pass objects, hold and work on a part, or do any task that needs two hands.
| Follower | Leader |
|---|---|
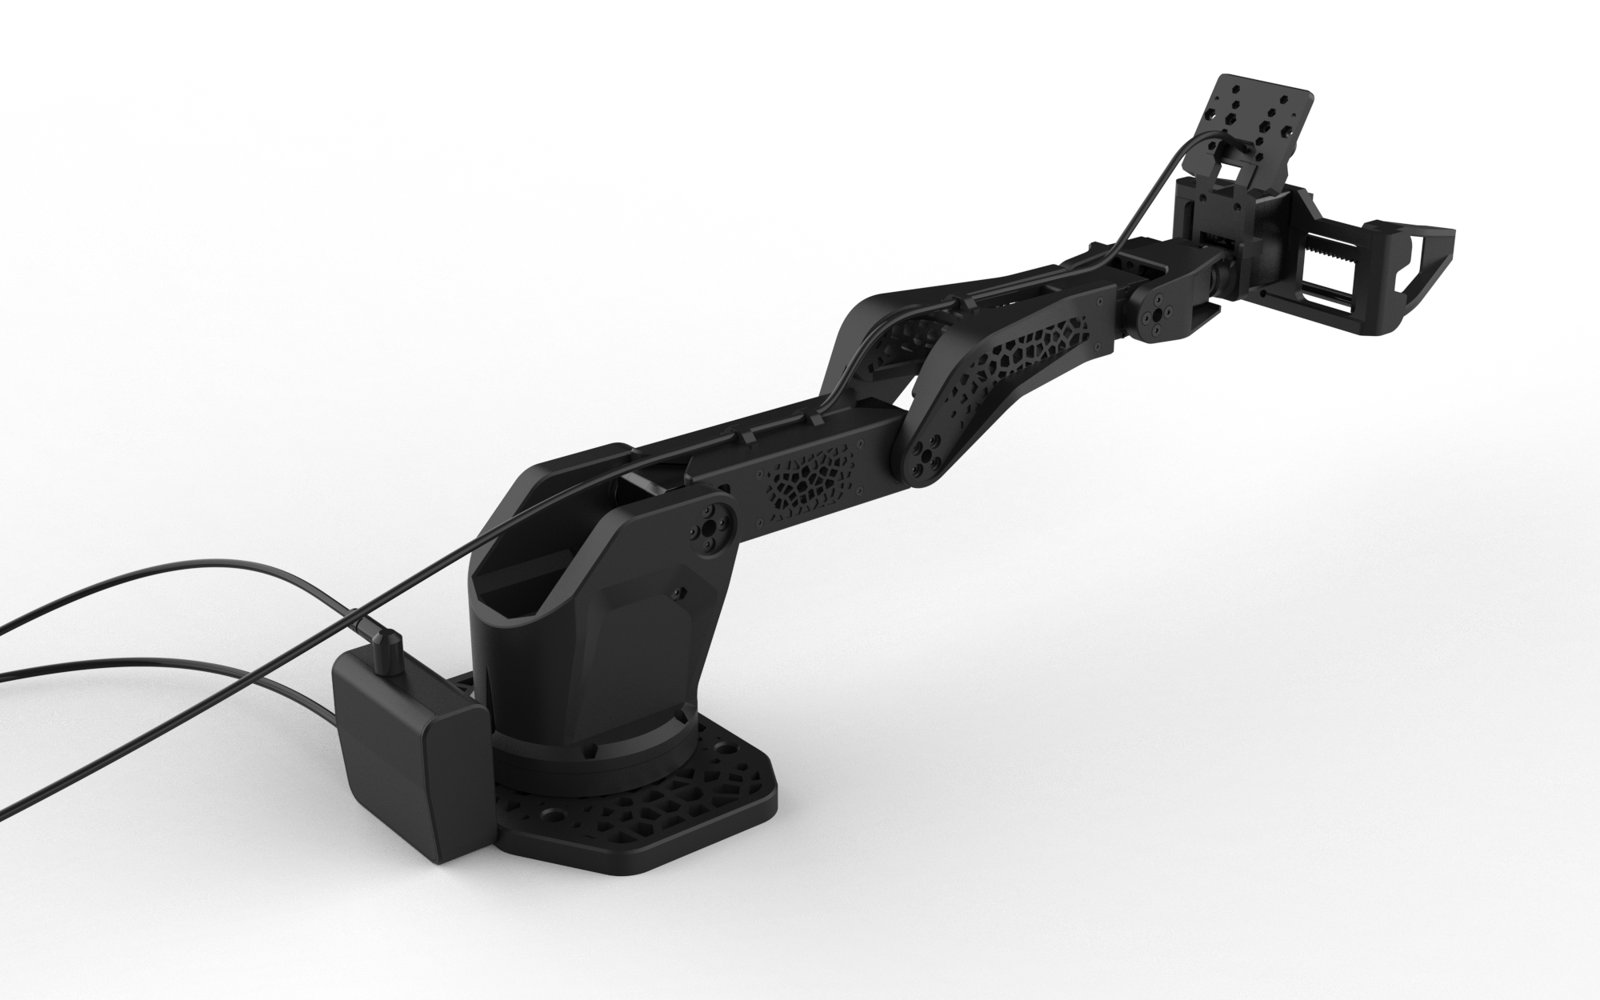 | 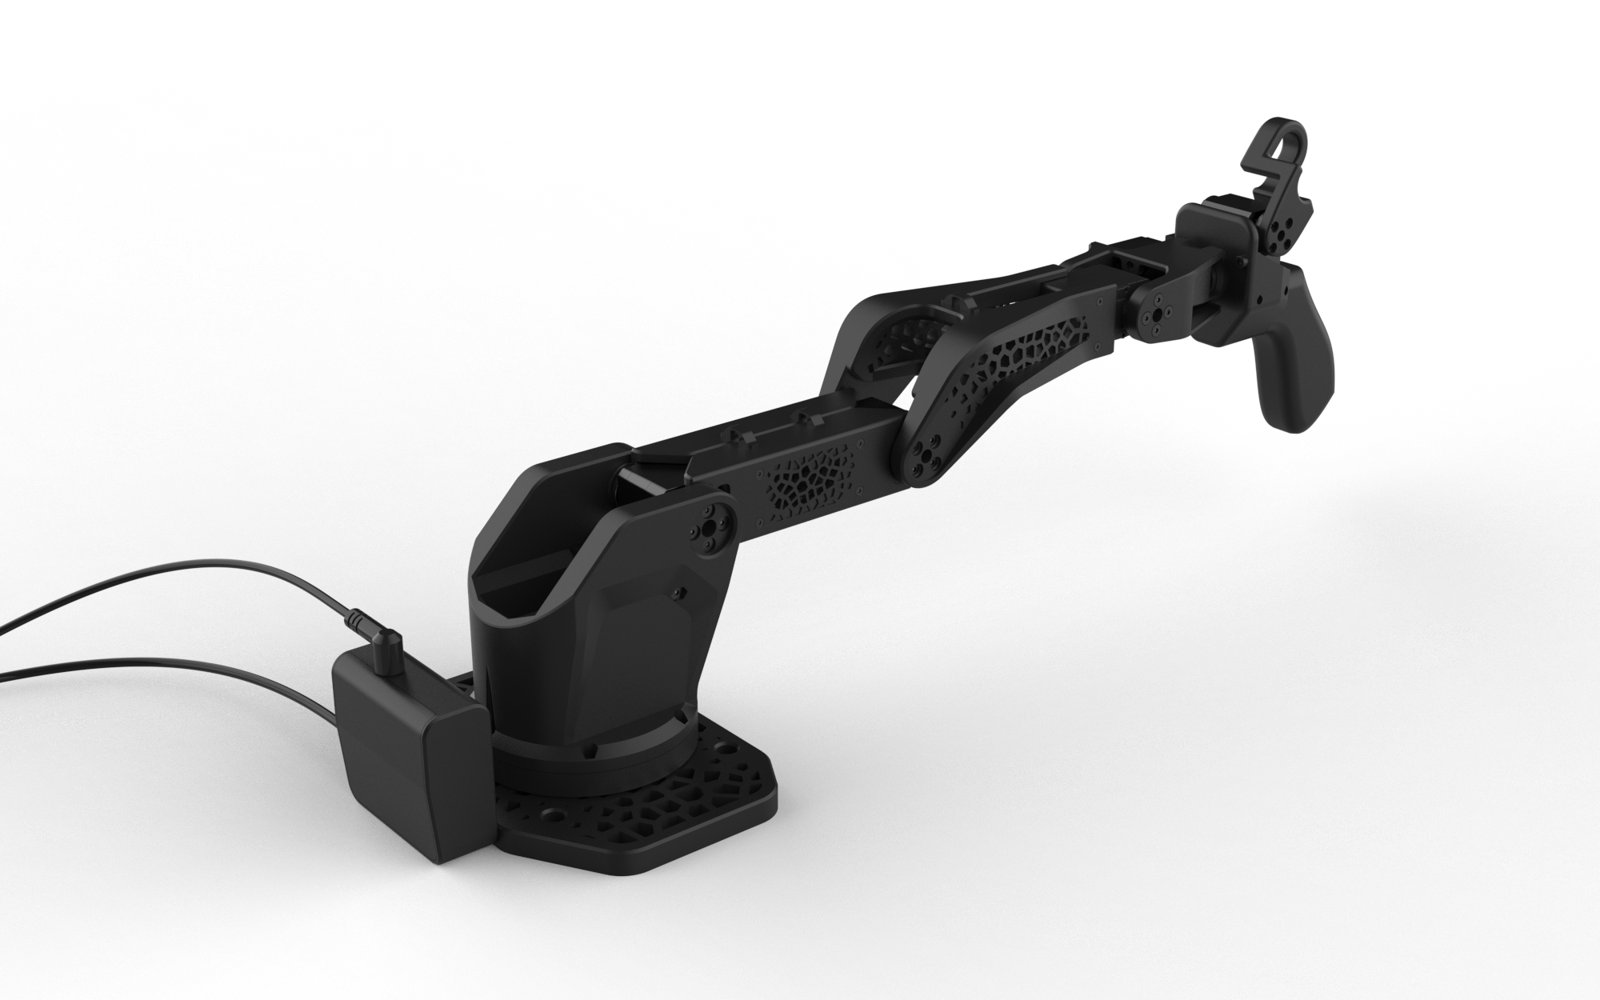 |
| Parallel gripper, wrist camera, 12 V | Handle with trigger, 5 V |
Prefer a ready kit? Buy the SO-ARM 102 kit.
Individual parts fit a 180 × 180 mm bed. The largest part is 160 mm long. The supplied 3MF plate layouts use a 256 × 256 mm bed.
models/3mf/
— leader, follower arm,
follower gripper and board casemodels/stl/models/step/The earlier test-arm settings gave slicer estimates of about 500 g of filament and 21 h for the arm parts, excluding the gripper. Re-slice the 3MF projects for current estimates.
Source the components from the BOM summary and full BOM with purchase links. Budget $404.09 for components, or $443.68 including printing material, before shipping and taxes.
| Arm | Servos | Controller | Power |
|---|---|---|---|
| Follower | 2 × STS3235, 2 × STS3250, 2 × STS3215 | Waveshare Bus Servo Driver HAT | 12 V |
| Leader | 6 × STS3215 | Waveshare Bus Servo Adapter | 5 V |
⚠️ The leader runs on 5 V and the follower on 12 V. Do not swap the power supplies.
Tools: hex keys 1.5 mm (M2 screws) and 2 mm (M3 screws).
Servo IDs, calibration and lessons: lab.robonine.com. The arm uses the LeRobot SO-101 leader/follower workflow.
Quantities and reference costs for one leader + one follower:
| Category / purchase links | Kit contents | Total (USD) |
|---|---|---|
| Servos | 6 × STS3215 7.4 V, 2 × STS3215 12 V, 2 × STS3235, 2 × STS3250 | $283.62 |
| Electronics | 2 controllers, 2 power supplies, 2 USB cables, 1 wrist camera | $71.50 |
| Mechanical parts | 4 bearings, 2 steel guide rods, 4 table clamps | $37.76 |
| Fasteners | Screws and nuts; specified servo-kit screws included | $11.21 |
| Components subtotal | $404.09 | |
| Printing material | 0.6 kg PET-CF17 + 0.6 kg PETG allowance | $39.59 |
| Total with printing material | $443.68 |
Buying the example full packs and filament spools from scratch costs about $504, including unused spares. These are reference estimates, not new supplier quotes. Shipping, taxes, tools, a computer, a printer, electricity and assembly labour are excluded. Confirm supplier prices, variants and minimum order quantities before ordering; re-slice the 3MF projects to check filament consumption.
Full BOM, purchase links and cost assumptions.
The current standalone export is in simulation/urdf/:
URDF · Xacro.
Keep meshes/ beside the description files; mesh paths are relative to this folder.
clamp2 mimics clamp1 with multiplier -1.Export settings and mass properties record the assumptions. Geometry and inertia checks are recorded in export_verification.json.
├── models/
│   ├── 3mf/                 # Slicer projects: leader, follower, gripper and board case
│   ├── stl/                 # Print-ready meshes
│   │   ├── common/          #   parts used by both arms
│   │   ├── follower/        #   parallel gripper, camera mount, board case
│   │   └── leader/          #   handle, trigger, wrist roll, board case
│   └── step/                # CAD sources, same layout as stl/
├── docs/
│   ├── printing.md          # Material, slicer settings, quantities
│   ├── bom.md               # Bill of materials
│   ├── assembly-guide.md    # Step list with parts and fasteners
│   ├── specifications.md    # Geometry, servos, measured results vs SO-ARM 101
│   └── SO-ARM102_assembly_A5_v0.6.pdf
├── assets/
│   ├── images/              # Photos, renders, booklet pages, test photos
│   └── video/               # Preview video and GIF
├── LICENSING.md             # Which licence covers which file
└── NOTICE                   # Third-party attribution
This is the first public release. An independent test build found the following. They are being fixed and will land in the next release.
Found something else? Please open an issue.
Copyright (c) 2026 Robonine. Different kinds of material carry different licences:
| Material | Licence |
|---|---|
Hardware designs in models/ | CERN-OHL-P-2.0 |
| Software and configuration | Apache-2.0 |
Documentation and images in docs/, assets/, all README.md | CC BY 4.0 |
See LICENSING.md and REUSE.toml for the file-by-file map.
| Name | Role | Contact |
|---|---|---|
| Alan Subin | Design Engineer: mechanical design, CAD, assembly booklet | |
| Boris Kotov | Software and Test Engineer: prototypes, printing, test rigs | Telegram |
| Nikita Bragin | Project Manager | |
| Mikhail Chistiakov | Industrial Designer: look and form of the arm | Telegram |
| Mikhail Zhmaylo | Structural Engineer: stiffness models, design changes to cut deflection | Telegram |
| Vladislav Eremenko | Structural Engineer: strength and thermal analysis, topology optimisation | Telegram |
| Vladimir Osipov | Tester and Consultant: independent test build |
Built for the robotics community by Robonine 🤖
432 followers · starred Oct 2026
Open-source leader + follower robot arm kit: 5 DOF + gripper, PET-CF frame, parallel gripper, LeRobot-compatible. STEP/STL, BOM, print and assembly guide.
See the codeEnglish · Русский · Español · Français · Deutsch · Português (Brasil) · 简体中文 · 日本語 · हिन्दी · العربية
🎥 Watch the preview video · 🛒 Buy the kit
An open-source leader + follower robot arm kit with 5 degrees of freedom plus a gripper for teleoperation and imitation learning, designed by Robonine as a stiffer, faster successor to the SO-ARM 101.
DIY budget: ~$404 for components, or ~$444 including printing material. BOM summary · Itemised costs and purchase links
Rather not source the parts and print them yourself? Buy the SO-ARM 102 kit.
| SO-ARM 101 | SO-ARM 102 | |
|---|---|---|
| Gripper | Angular jaw | Parallel gripper, 85 mm span |
| Frame material | PLA | PET-CF (Fiberon PET-CF17 tested) |
| Structure | Solid links | Topology-optimised links |
| Base rotation range | 220° | 352° |
| Horizontal reach | 441 mm | 483 mm |
| Deflection at the gripper, 300 g load ¹ | 7.5 mm | 3.4–3.9 mm |
| Shoulder and elbow speed | 45 RPM (STS3215) | 75 RPM (STS3250) |
| Noise at 1 m | 70 dB | 60 dB |
¹ Both arms built with printed servo dummies, so the frame is compared, not the motors. Full results and test conditions are in docs/specifications.md.
The arm keeps the SO-ARM 101 joint layout, so it works with Hugging Face LeRobot datasets and policies.
Click for the full video, 21 s
The standard kit. Move the leader by hand, and the follower repeats the motion. Use it for teleoperation and for recording demonstrations for imitation learning.
Two kits side by side. Each hand drives its own leader, so the followers can pass objects, hold and work on a part, or do any task that needs two hands.
| Follower | Leader |
|---|---|
| |
| Parallel gripper, wrist camera, 12 V | Handle with trigger, 5 V |
Prefer a ready kit? Buy the SO-ARM 102 kit.
Individual parts fit a 180 × 180 mm bed. The largest part is 160 mm long. The supplied 3MF plate layouts use a 256 × 256 mm bed.
models/3mf/
— leader, follower arm,
follower gripper and board casemodels/stl/models/step/The earlier test-arm settings gave slicer estimates of about 500 g of filament and 21 h for the arm parts, excluding the gripper. Re-slice the 3MF projects for current estimates.
Source the components from the BOM summary and full BOM with purchase links. Budget $404.09 for components, or $443.68 including printing material, before shipping and taxes.
| Arm | Servos | Controller | Power |
|---|---|---|---|
| Follower | 2 × STS3235, 2 × STS3250, 2 × STS3215 | Waveshare Bus Servo Driver HAT | 12 V |
| Leader | 6 × STS3215 | Waveshare Bus Servo Adapter | 5 V |
⚠️ The leader runs on 5 V and the follower on 12 V. Do not swap the power supplies.
Tools: hex keys 1.5 mm (M2 screws) and 2 mm (M3 screws).
Servo IDs, calibration and lessons: lab.robonine.com. The arm uses the LeRobot SO-101 leader/follower workflow.
Quantities and reference costs for one leader + one follower:
| Category / purchase links | Kit contents | Total (USD) |
|---|---|---|
| Servos | 6 × STS3215 7.4 V, 2 × STS3215 12 V, 2 × STS3235, 2 × STS3250 | $283.62 |
| Electronics | 2 controllers, 2 power supplies, 2 USB cables, 1 wrist camera | $71.50 |
| Mechanical parts | 4 bearings, 2 steel guide rods, 4 table clamps | $37.76 |
| Fasteners | Screws and nuts; specified servo-kit screws included | $11.21 |
| Components subtotal | $404.09 | |
| Printing material | 0.6 kg PET-CF17 + 0.6 kg PETG allowance | $39.59 |
| Total with printing material | $443.68 |
Buying the example full packs and filament spools from scratch costs about $504, including unused spares. These are reference estimates, not new supplier quotes. Shipping, taxes, tools, a computer, a printer, electricity and assembly labour are excluded. Confirm supplier prices, variants and minimum order quantities before ordering; re-slice the 3MF projects to check filament consumption.
Full BOM, purchase links and cost assumptions.
The current standalone export is in simulation/urdf/:
URDF · Xacro.
Keep meshes/ beside the description files; mesh paths are relative to this folder.
clamp2 mimics clamp1 with multiplier -1.Export settings and mass properties record the assumptions. Geometry and inertia checks are recorded in export_verification.json.
├── models/
│   ├── 3mf/                 # Slicer projects: leader, follower, gripper and board case
│   ├── stl/                 # Print-ready meshes
│   │   ├── common/          #   parts used by both arms
│   │   ├── follower/        #   parallel gripper, camera mount, board case
│   │   └── leader/          #   handle, trigger, wrist roll, board case
│   └── step/                # CAD sources, same layout as stl/
├── docs/
│   ├── printing.md          # Material, slicer settings, quantities
│   ├── bom.md               # Bill of materials
│   ├── assembly-guide.md    # Step list with parts and fasteners
│   ├── specifications.md    # Geometry, servos, measured results vs SO-ARM 101
│   └── SO-ARM102_assembly_A5_v0.6.pdf
├── assets/
│   ├── images/              # Photos, renders, booklet pages, test photos
│   └── video/               # Preview video and GIF
├── LICENSING.md             # Which licence covers which file
└── NOTICE                   # Third-party attribution
This is the first public release. An independent test build found the following. They are being fixed and will land in the next release.
Found something else? Please open an issue.
Copyright (c) 2026 Robonine. Different kinds of material carry different licences:
| Material | Licence |
|---|---|
Hardware designs in models/ | CERN-OHL-P-2.0 |
| Software and configuration | Apache-2.0 |
Documentation and images in docs/, assets/, all README.md | CC BY 4.0 |
See LICENSING.md and REUSE.toml for the file-by-file map.
| Name | Role | Contact |
|---|---|---|
| Alan Subin | Design Engineer: mechanical design, CAD, assembly booklet | |
| Boris Kotov | Software and Test Engineer: prototypes, printing, test rigs | Telegram |
| Nikita Bragin | Project Manager | |
| Mikhail Chistiakov | Industrial Designer: look and form of the arm | Telegram |
| Mikhail Zhmaylo | Structural Engineer: stiffness models, design changes to cut deflection | Telegram |
| Vladislav Eremenko | Structural Engineer: strength and thermal analysis, topology optimisation | Telegram |
| Vladimir Osipov | Tester and Consultant: independent test build |
Built for the robotics community by Robonine 🤖
432 followers · starred Oct 2026



