Project is licensed under Apache 2.0
Mechanical design is licensed under a:
Creative Commons Attribution 4.0 International License.


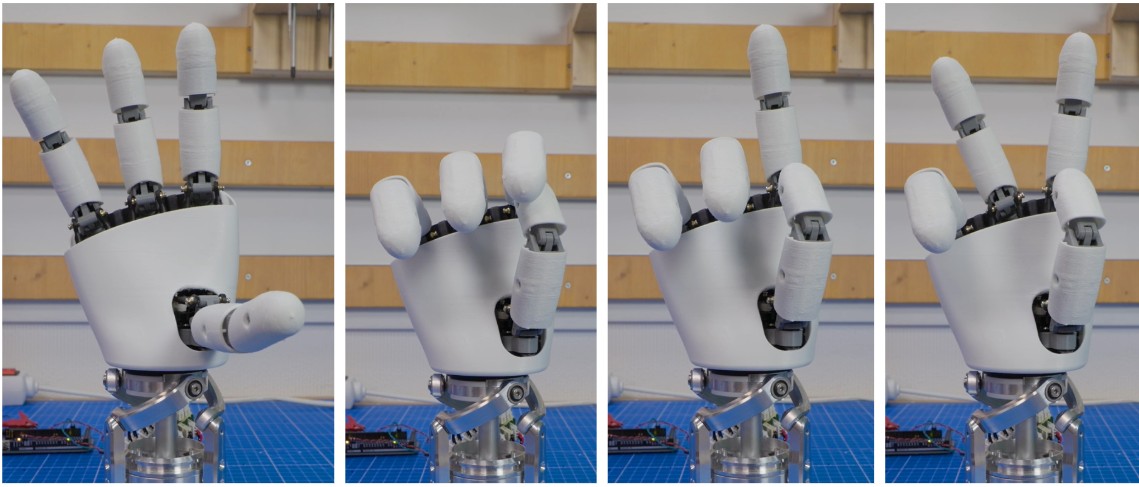
Robotic hands are often very expensive and not so expressive. More dexterous ones often need cables and deported actuators in the forearm, i.e.,
The aim of this project is to be able to explore humanoid hand possibilities on a real robot (and Reachy2 is the perfect candidate for that !) with moderate cost. => Wrist interface is designed for Reachy2's wrist (Orbita 3D), but it can be easily adapted to other robot's wrist...
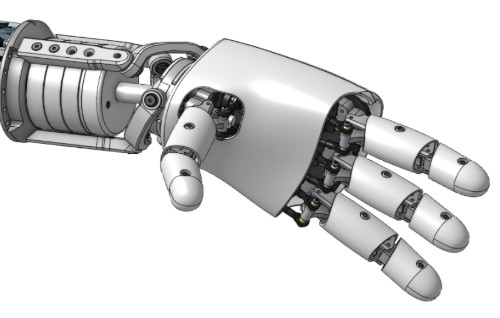
Amazing Hand is:
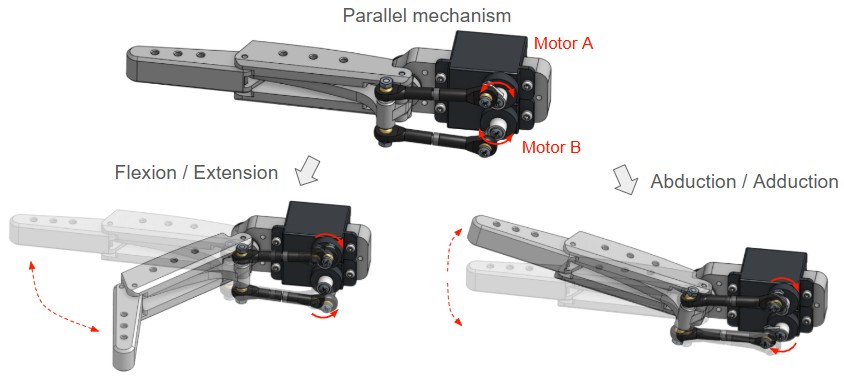
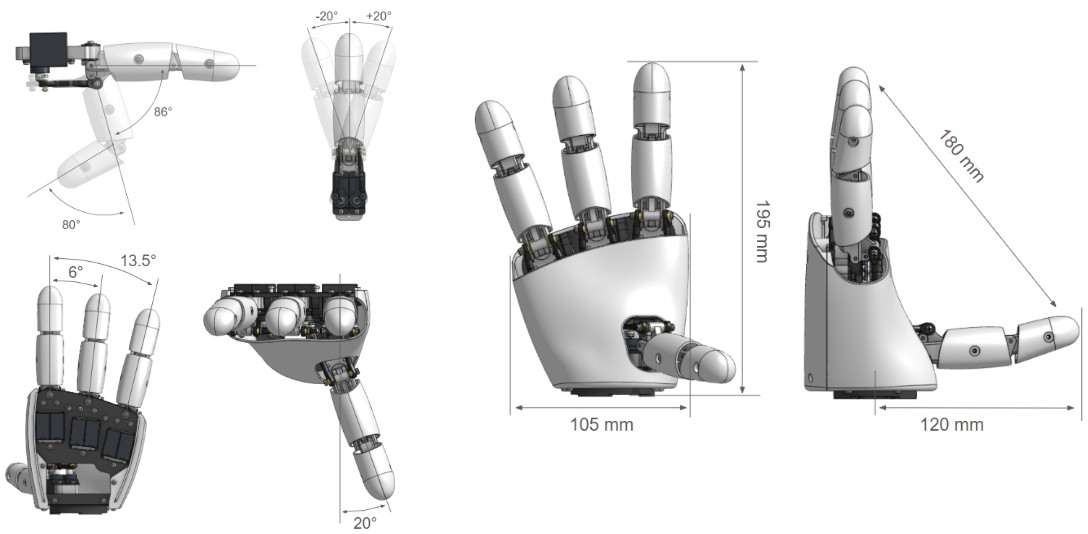 Each finger is driven by a parallel mechanism.
That means 2x small Feetech SCS0009 servos are used to move each finger in flexion/extension and abduction/adduction
Two control methods are available:
Detailed explanations are available for both ways, and basic demo software is also available. Up to you !
List of all needed components is available here:
AmazingHand BOM
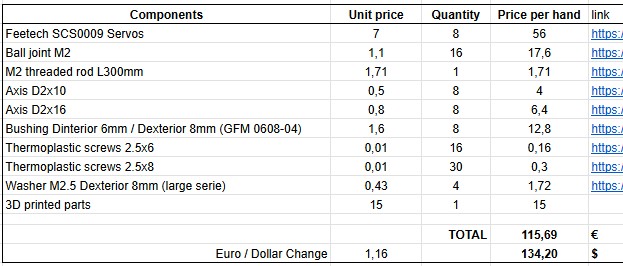
And remember to add control choice cost (2 options detailed previously)
Details for custom 3D printed parts are here: 3Dprinted parts
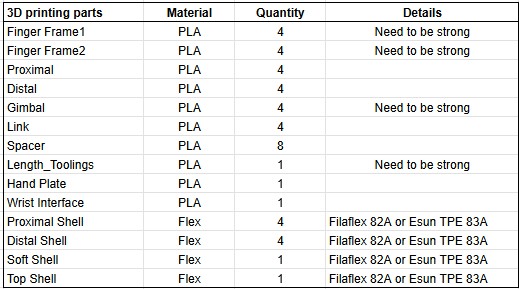
Here is a guide explaining how to print all the needed custom parts:
=> 3D Printing Guide

STL and Steps files can be found here
Note that fingers are the same if you want to build a left hand, but some parts are symmetrical. Specific right hand parts are preceded by an "R", and other left hand parts by an "L".

Everyone can access the Onshape document too:
Link Onshape
Note that predefined positions are available in the "named position" tooling, with corresponding servo angles

Assembly guide for the Amazing Hand in combination with standard components in the BOM is here:
=> Assembly Guide

You will need a simple program / script to calibrate each finger, available here:
Note that this assembly guide is for a standalone right hand.
If you need to build a standalone left hand, you can keep the same IDs for servo locations, and select if it's a right or left hand in the software.
A basic demo is available with both Python & Arduino.
You will need an external power supply to be able to power the 8 actuators inside the hand.
If you don't have one already, a simple external power supply could be a DC/DC 220V -> 5V / 2A adapter with jack connector. Check on the BOM list: AmazingHand BOM
https://github.com/user-attachments/assets/485fc1f4-cc57-4e59-90b5-e84518b9fed0
If you need to build both right and left hands to plug them on a robot, you will have to attribute different IDs for right and left hands. You can't have same ID for different servos on the same serial bus...
Very important thing is to keep same assembly order for servos, but set them different IDs than for the right hand, as follows:
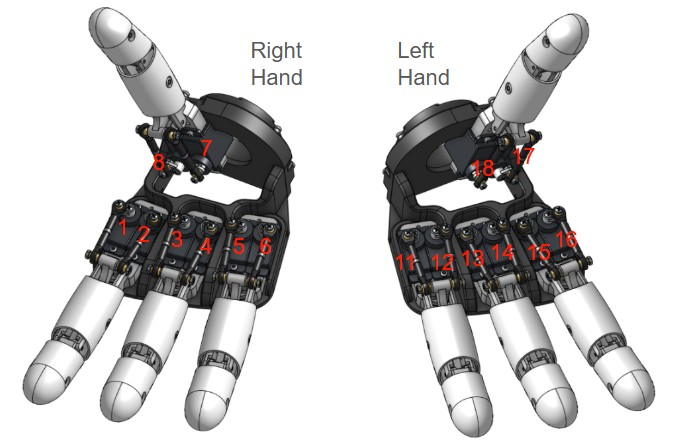
Specific software is also needed, in order to drive each hand independently. This simple demo runs the same hand patterns on both hands simultaneously, but it's only available in Python: "AmazingHand_Demo_Both" here
I noticed some variations between theoretical angles for Flexion / Extension, Abduction / Adduction and angles in real life prototypes. This is probably due to several sources of variation (3D printed parts are not perfect, balljoint rods are manually adjusted one by one, servo horn rework, flexibility of plastic parts...).
This design has not yet been tested for long and complex prehensile tasks. Before being able to grasp objects safely (that means without damaging servos or mechanical parts), a kind of smart software needs to be built. SCS0009 servos have smart capabilities as:

For more advanced usage using inverse/forward kinematics there are several examples in the Demo directory along with some useful tools to test/configure the motors.
=> Kits are available here :
Seeed Studio : https://www.seeedstudio.com/Amazing-Hand-Right-Hand-The-Open-Source-Robotic-Hand-Developer-Kit.html
WowRobo : https://shop.wowrobo.com/products/amazing-hand-the-open-source-robotic-hand-kit
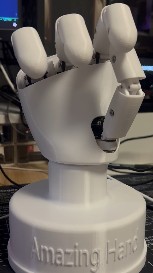 STL or Step file can be found here
Thanks to Jianliang Shen !
Key features :
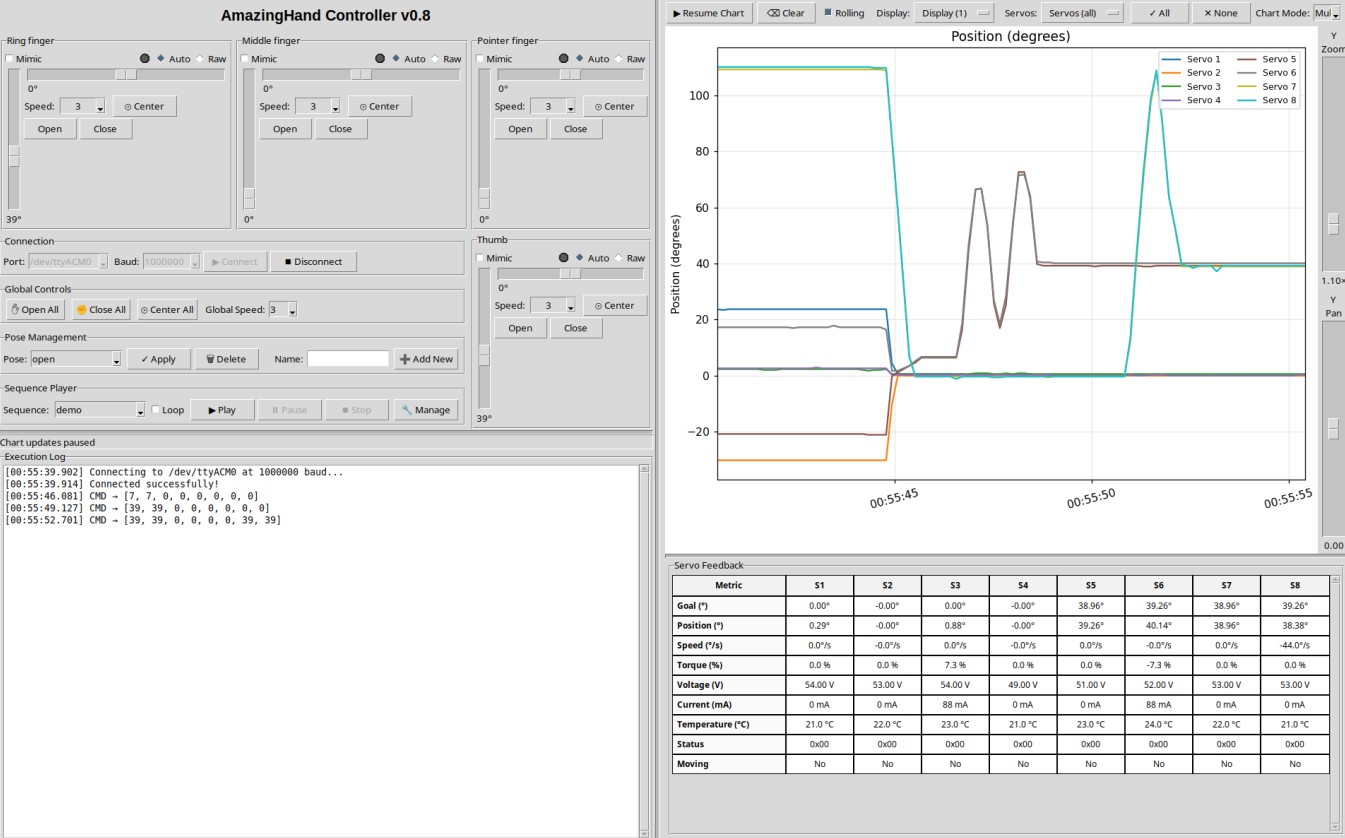
Link to repository : Link
Thanks to Betatester777 !


GitHub with code: (https://github.com/joanbox24/AmazingHand-with-sg90-servo-force-control)

STL or Step file can be found here Or directly on onshape workspace, folder "community update"
WIP
You can reach public discord channel here : Discord AmazingHand
Or Contact me or Pollen Robotics
Huge thanks to those who have contributed to this project so far:
(top 24 of 35)
61,633 followers · starred Jul 2025
53 followers · starred Jul 2025
40 followers · starred Sep 2025
193 followers · starred Jul 2025
Project is licensed under Apache 2.0
Mechanical design is licensed under a:
Creative Commons Attribution 4.0 International License.
Robotic hands are often very expensive and not so expressive. More dexterous ones often need cables and deported actuators in the forearm, i.e.,
The aim of this project is to be able to explore humanoid hand possibilities on a real robot (and Reachy2 is the perfect candidate for that !) with moderate cost. => Wrist interface is designed for Reachy2's wrist (Orbita 3D), but it can be easily adapted to other robot's wrist...
Amazing Hand is:
Each finger is driven by a parallel mechanism.
That means 2x small Feetech SCS0009 servos are used to move each finger in flexion/extension and abduction/adduction
Two control methods are available:
Detailed explanations are available for both ways, and basic demo software is also available. Up to you !
List of all needed components is available here:
AmazingHand BOM
And remember to add control choice cost (2 options detailed previously)
Details for custom 3D printed parts are here: 3Dprinted parts
Here is a guide explaining how to print all the needed custom parts:
=> 3D Printing Guide
STL and Steps files can be found here
Note that fingers are the same if you want to build a left hand, but some parts are symmetrical. Specific right hand parts are preceded by an "R", and other left hand parts by an "L".
Everyone can access the Onshape document too:
Link Onshape
Note that predefined positions are available in the "named position" tooling, with corresponding servo angles
Assembly guide for the Amazing Hand in combination with standard components in the BOM is here:
=> Assembly Guide
You will need a simple program / script to calibrate each finger, available here:
Note that this assembly guide is for a standalone right hand.
If you need to build a standalone left hand, you can keep the same IDs for servo locations, and select if it's a right or left hand in the software.
A basic demo is available with both Python & Arduino.
You will need an external power supply to be able to power the 8 actuators inside the hand.
If you don't have one already, a simple external power supply could be a DC/DC 220V -> 5V / 2A adapter with jack connector. Check on the BOM list: AmazingHand BOM
https://github.com/user-attachments/assets/485fc1f4-cc57-4e59-90b5-e84518b9fed0
If you need to build both right and left hands to plug them on a robot, you will have to attribute different IDs for right and left hands. You can't have same ID for different servos on the same serial bus...
Very important thing is to keep same assembly order for servos, but set them different IDs than for the right hand, as follows:
Specific software is also needed, in order to drive each hand independently. This simple demo runs the same hand patterns on both hands simultaneously, but it's only available in Python: "AmazingHand_Demo_Both" here
I noticed some variations between theoretical angles for Flexion / Extension, Abduction / Adduction and angles in real life prototypes. This is probably due to several sources of variation (3D printed parts are not perfect, balljoint rods are manually adjusted one by one, servo horn rework, flexibility of plastic parts...).
This design has not yet been tested for long and complex prehensile tasks. Before being able to grasp objects safely (that means without damaging servos or mechanical parts), a kind of smart software needs to be built. SCS0009 servos have smart capabilities as:
For more advanced usage using inverse/forward kinematics there are several examples in the Demo directory along with some useful tools to test/configure the motors.
=> Kits are available here :
Seeed Studio : https://www.seeedstudio.com/Amazing-Hand-Right-Hand-The-Open-Source-Robotic-Hand-Developer-Kit.html
WowRobo : https://shop.wowrobo.com/products/amazing-hand-the-open-source-robotic-hand-kit
STL or Step file can be found here
Thanks to Jianliang Shen !
Key features :
Link to repository : Link
Thanks to Betatester777 !
GitHub with code: (https://github.com/joanbox24/AmazingHand-with-sg90-servo-force-control)
STL or Step file can be found here Or directly on onshape workspace, folder "community update"
WIP
You can reach public discord channel here : Discord AmazingHand
Or Contact me or Pollen Robotics
Huge thanks to those who have contributed to this project so far:
(top 24 of 35)
61,633 followers · starred Jul 2025
53 followers · starred Jul 2025
40 followers · starred Sep 2025
193 followers · starred Jul 2025