Offline voice agent framework for robots — agents, skills, workflows, sub-second voice pipeline, 2D/3D simulation (IR-SIM + MuJoCo), 16 languages, 56 voices, ROS2-native. Runs on CPU/CUDA/Metal, no cloud.
See the codeOffline voice agent framework for robots and desktop apps. Local streaming voice pipeline. Fully private.



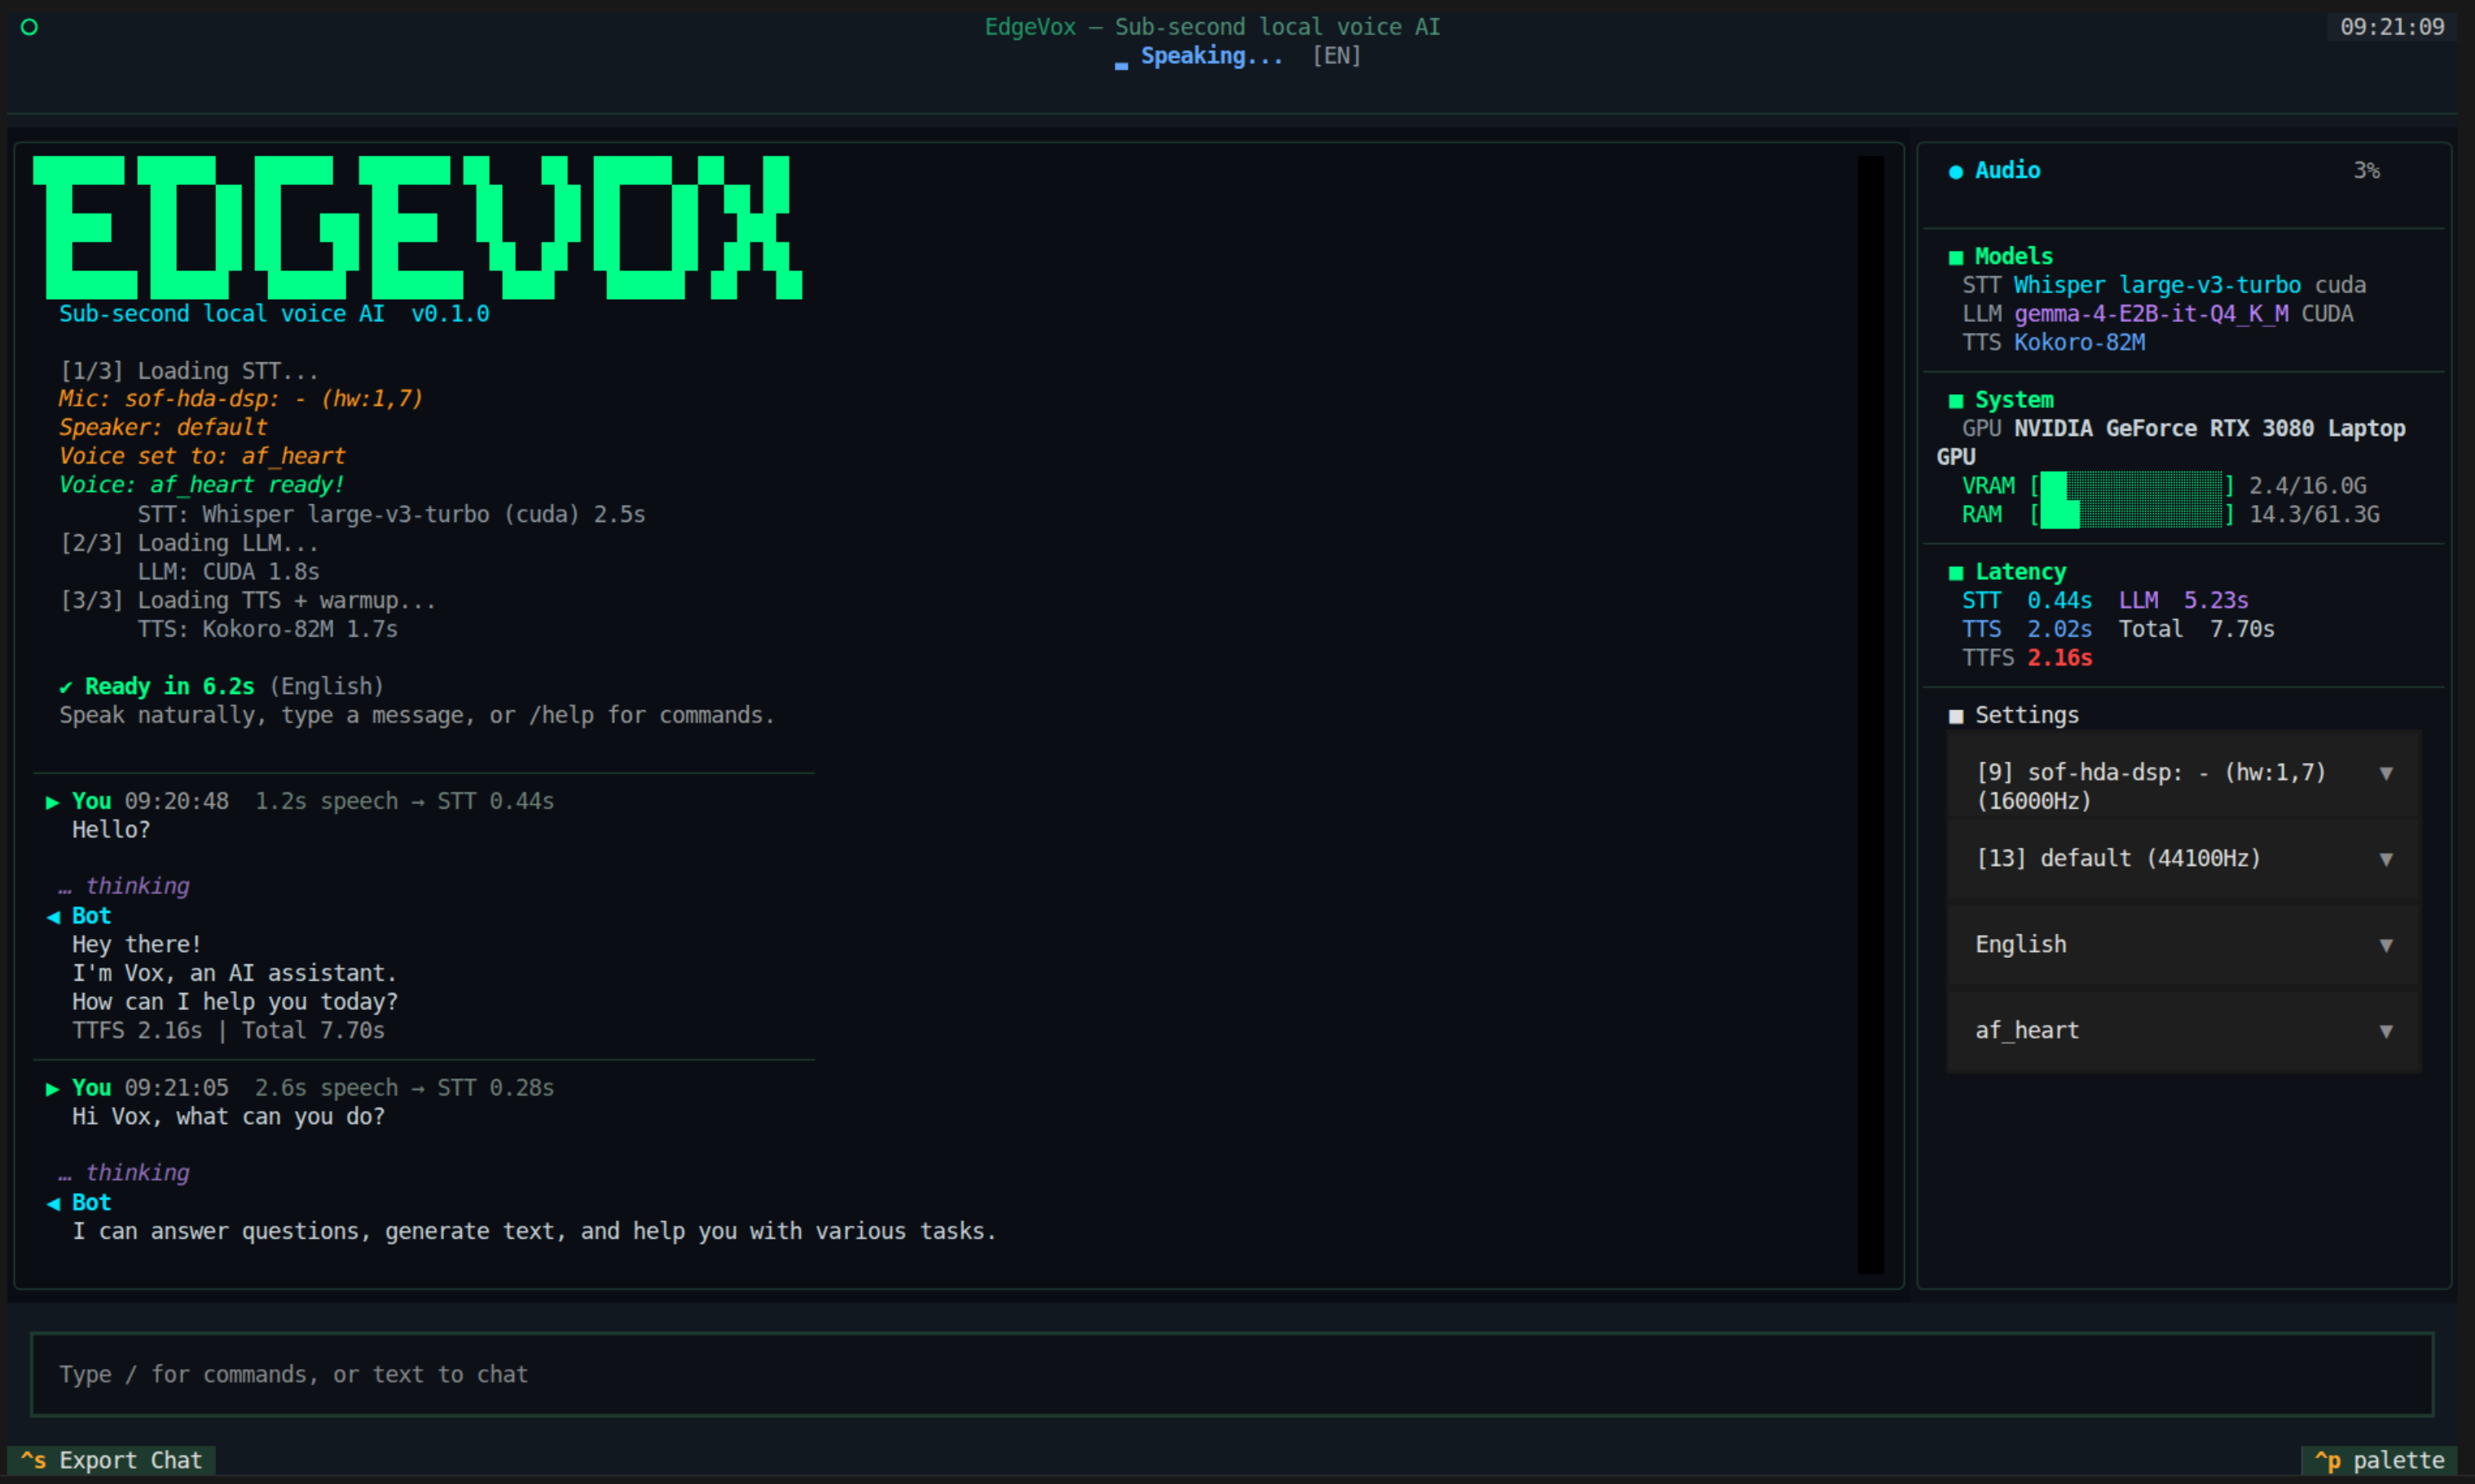
Voice pipeline TUI — streaming STT · LLM · TTS with VAD barge-in |
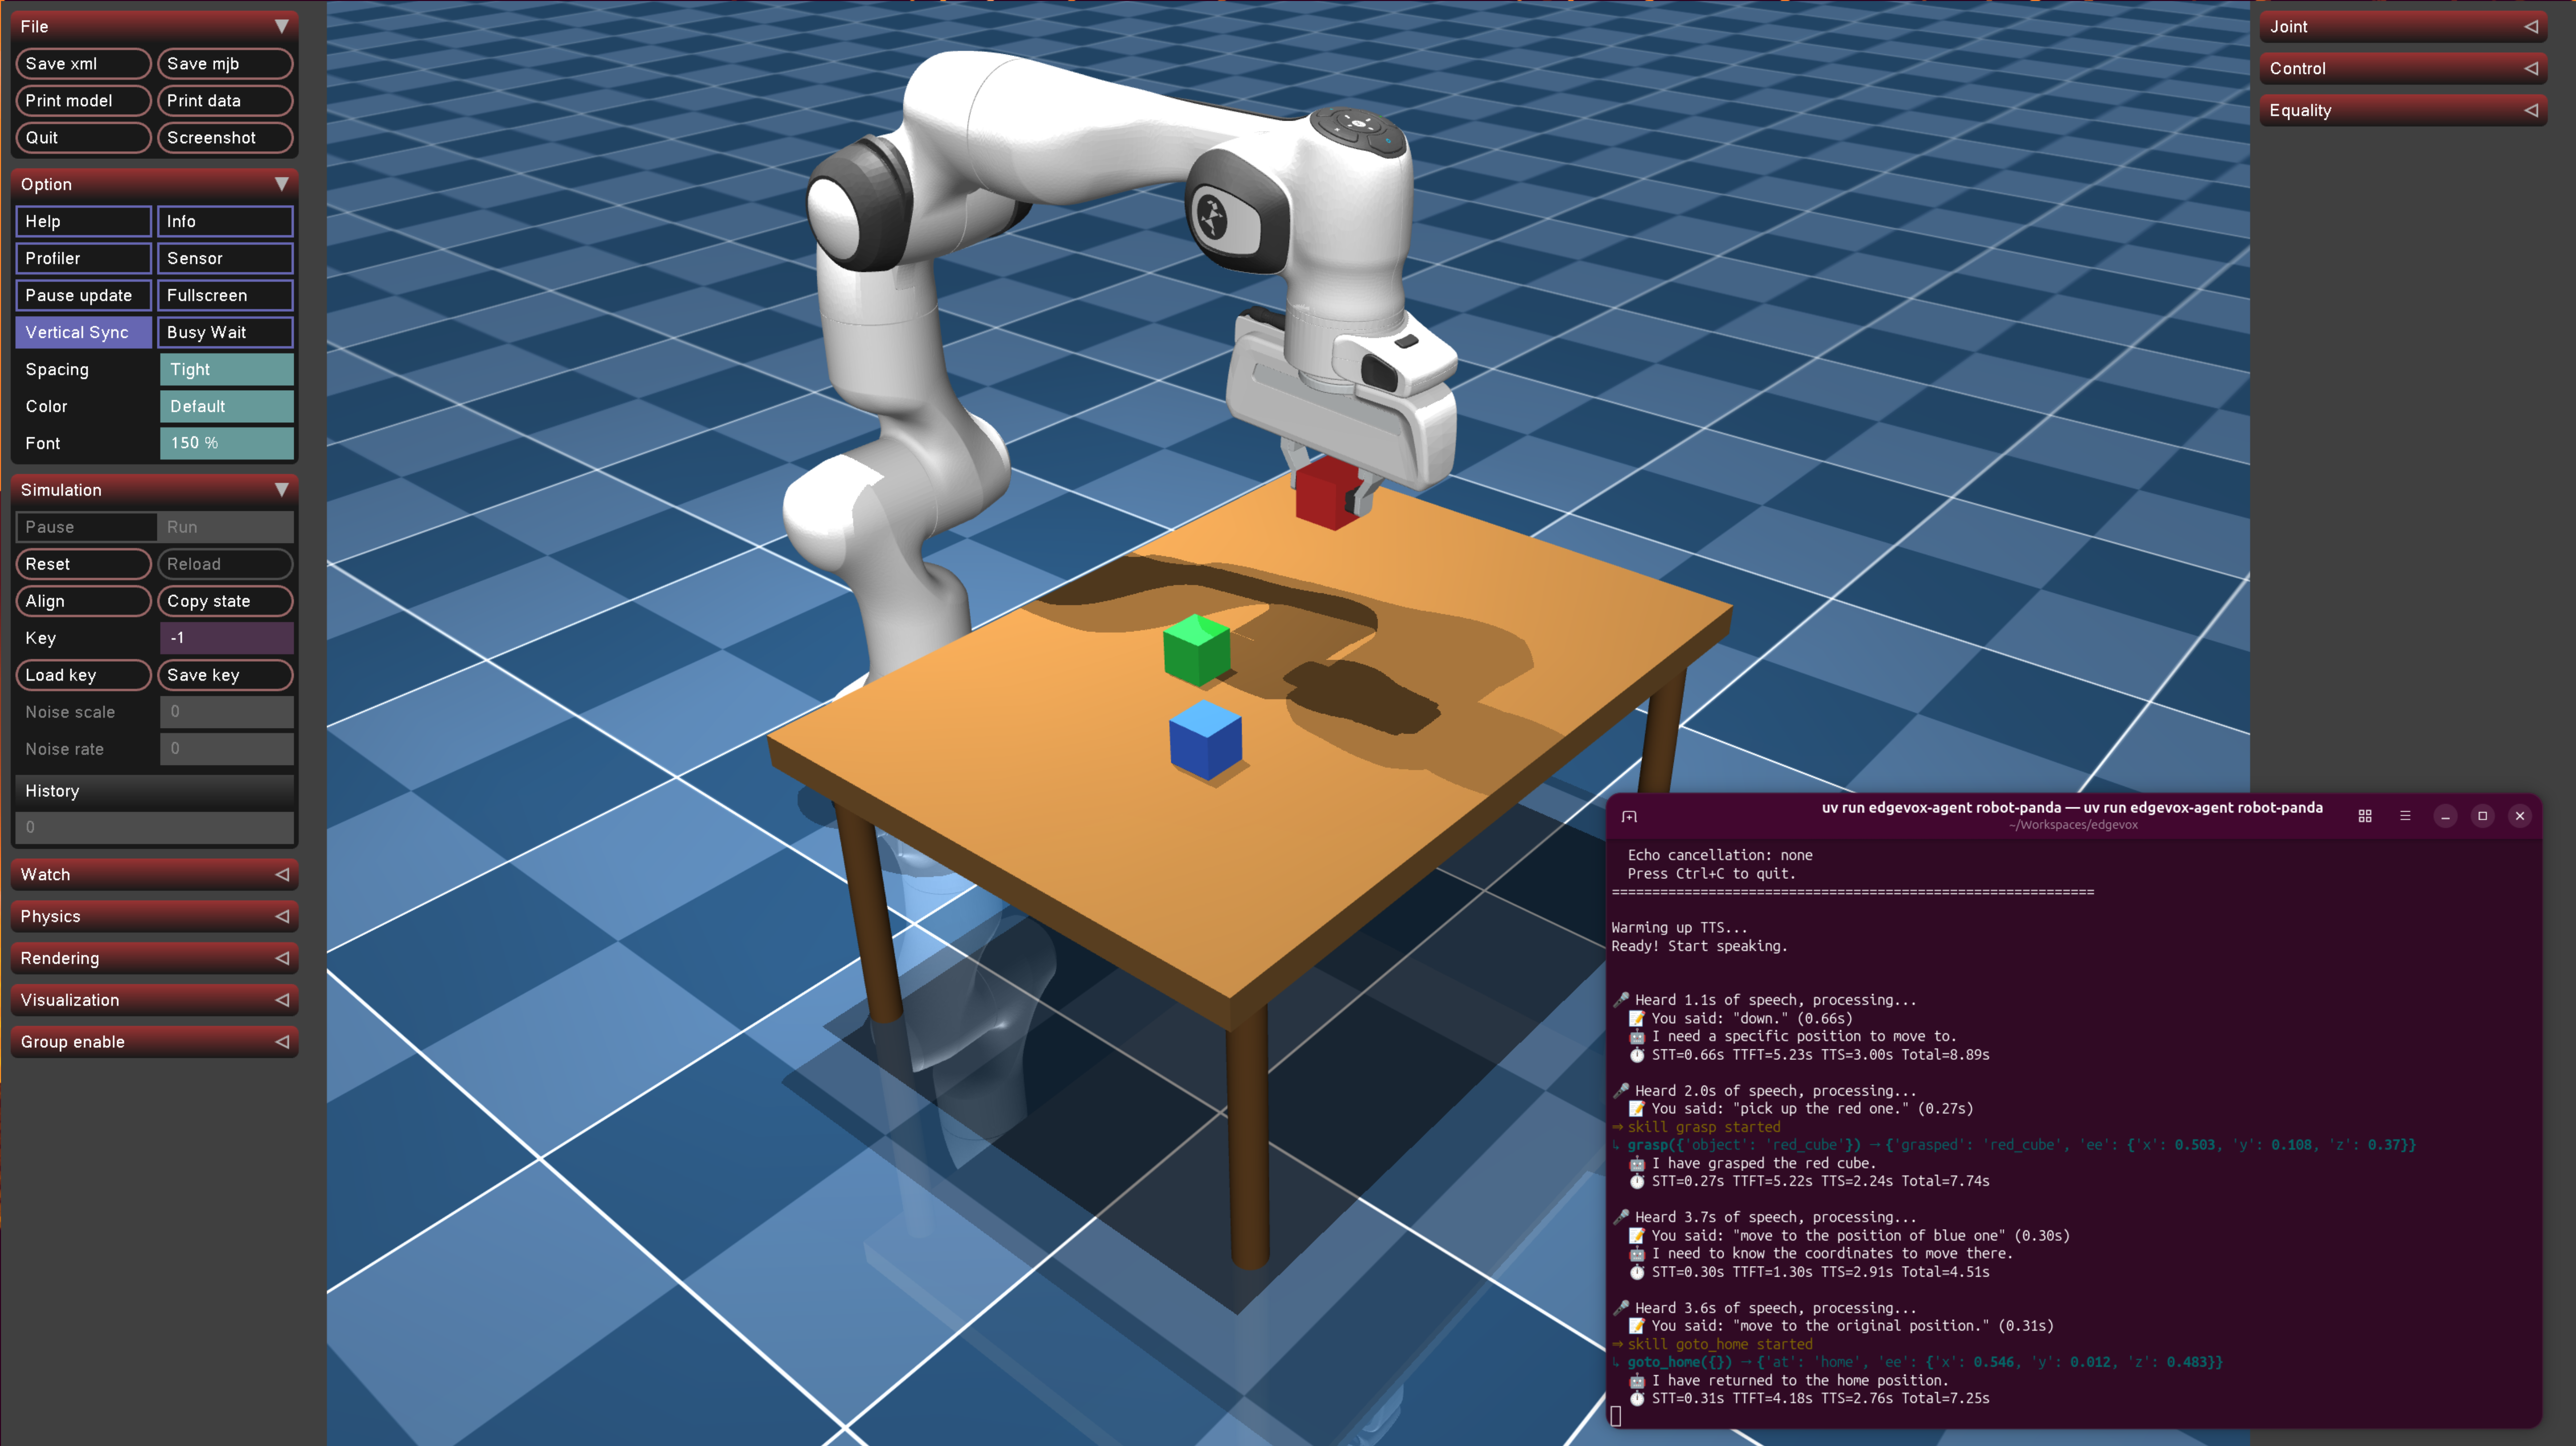
MuJoCo · Franka arm — voice-controlled pick-and-place |
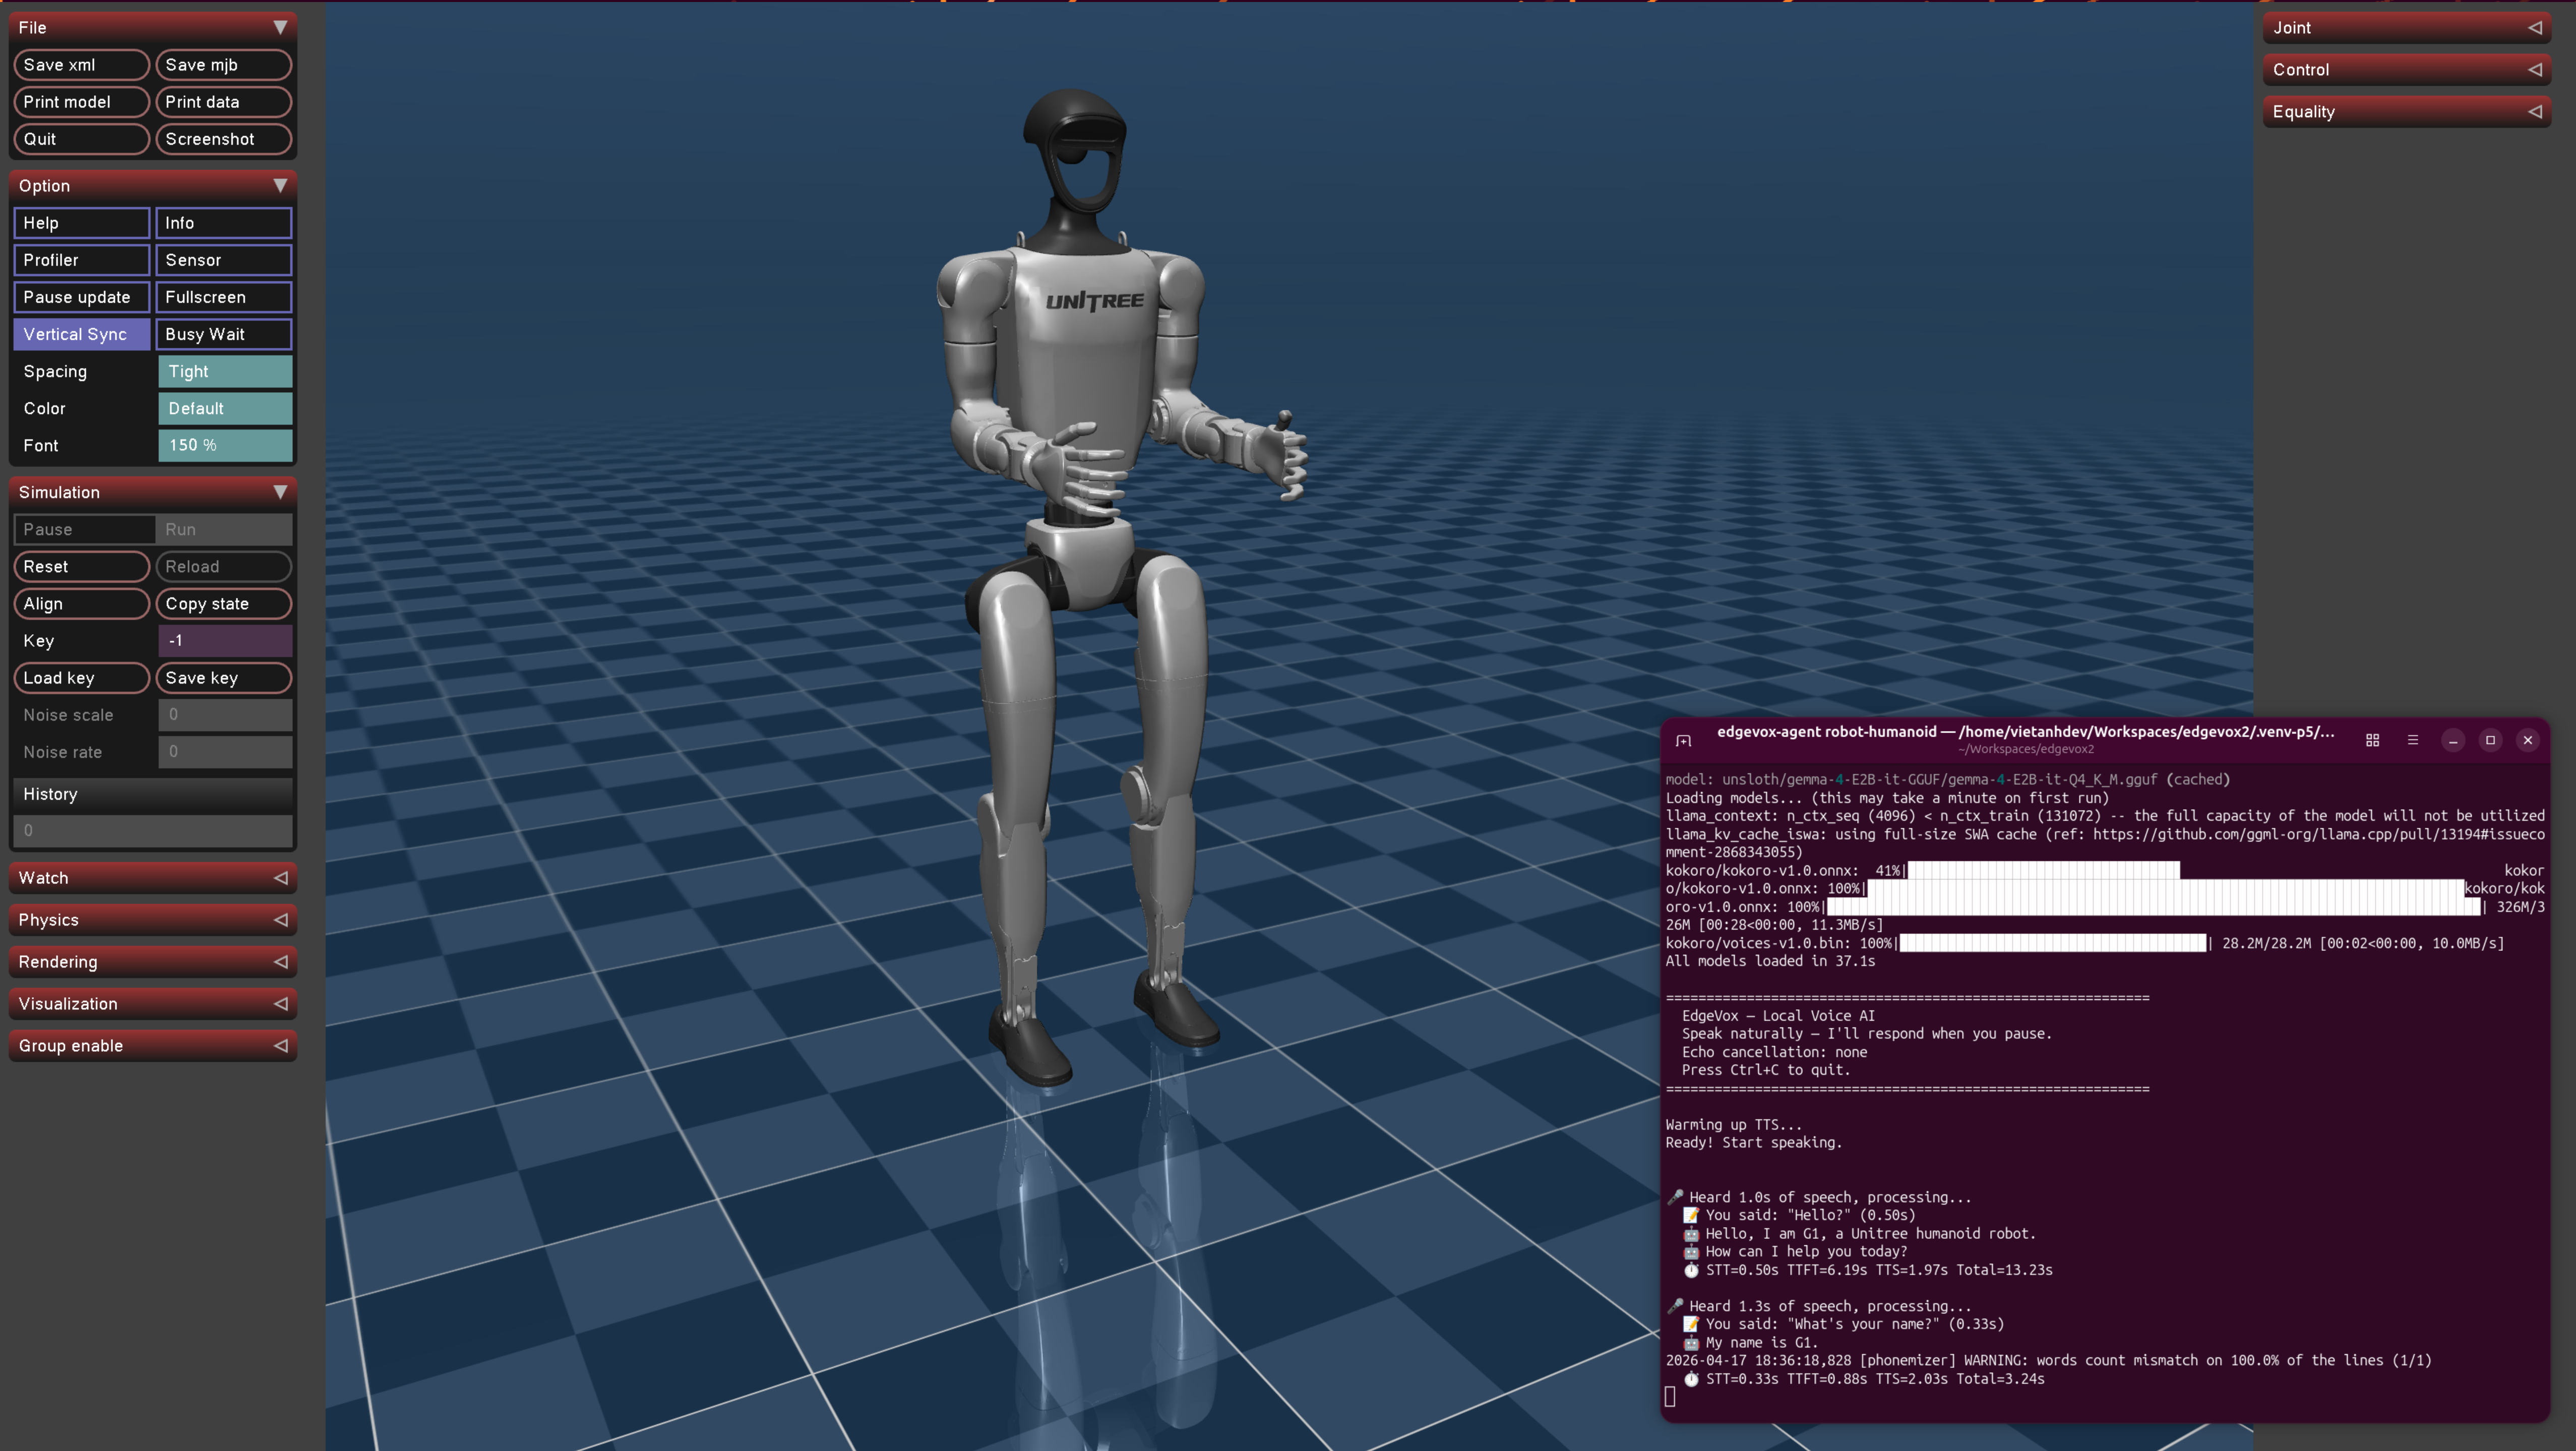
Unitree G1 humanoid — procedural gait + ONNX policy slot |
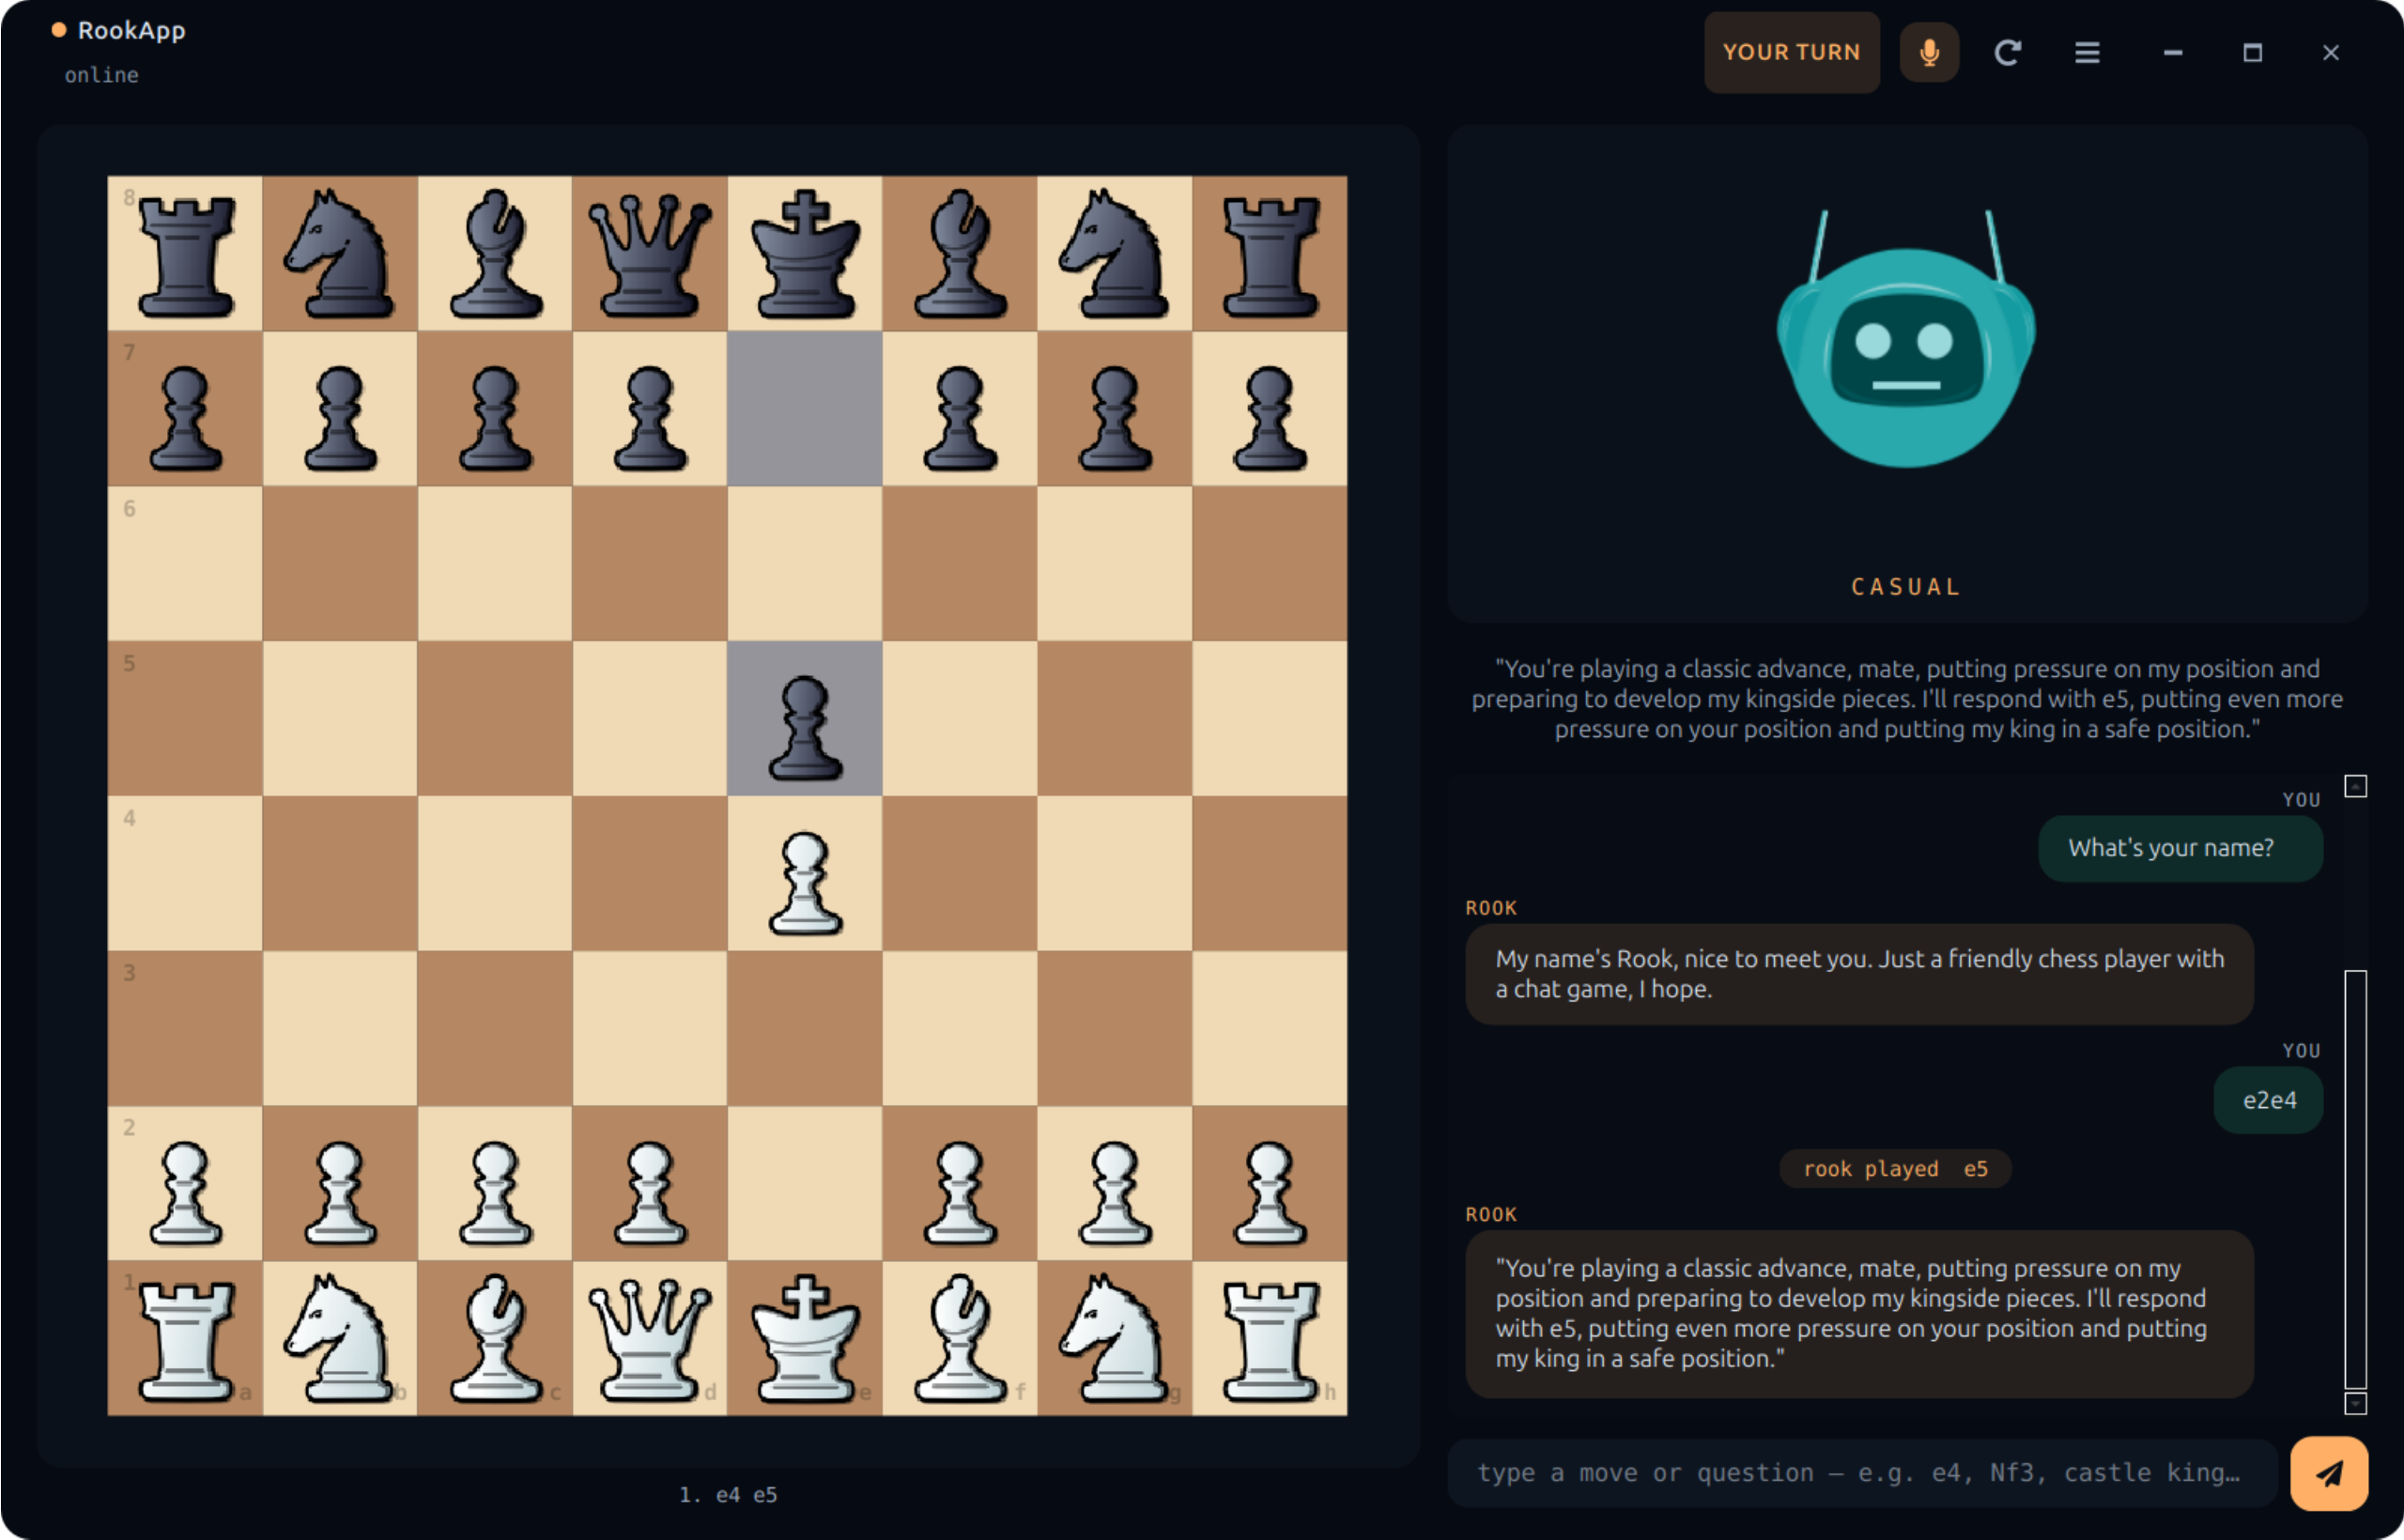
RookApp desktop — offline chess partner (Qt + LLMAgent + Stockfish, one Python process) |
Agents + Skills + Workflows | 2D sim (IR-SIM) | 3D sim (MuJoCo) | Streaming voice pipeline | 16 languages | 56 voices | ROS2-native | Ships as a desktop app
benchmarks/ for the harness; numbers land here once the first run completes.)@tool and @skill functions in Python; compose them with Sequence, Fallback, Loop, Parallel, and Router workflows; delegate across agents with OpenAI-SDK-style handoffs.GoalHandle, hard-stop SafetyMonitor that bypasses the LLM, three-tier simulation (stdlib → IR-SIM → MuJoCo), and a ROS2 bridge. Desktop apps get the same agent framework + voice pipeline shipped as a single PySide6 process — see RookApp below.2D — IR-SIM (mobile robot navigation)
pip install 'edgevox[sim]'
edgevox-setup                      # downloads ~3 GB of models, one time
edgevox-agent robot-irsim --text-mode
A matplotlib window opens showing a 10×10 apartment with four rooms. Type "go to the kitchen" — the blue robot drives visibly. Say "stop" mid-flight and the safety monitor preempts the skill before the LLM is consulted — the halt path doesn't wait on a model round-trip. Swap --text-mode for --simple-ui to drive it by voice.
3D — MuJoCo (tabletop arm pick-and-place)
pip install 'edgevox[sim-mujoco]'
edgevox-agent robot-panda --text-mode
A MuJoCo viewer opens with a Franka Panda arm above a table with three colored cubes. Type "pick up the red cube" — the arm moves, grasps, and lifts. Voice commands control move_to, grasp, release, and goto_home skills.
3D — MuJoCo humanoid (Unitree G1 / H1)
pip install 'edgevox[sim-mujoco]'
edgevox-agent robot-humanoid --simple-ui
A Unitree humanoid (auto-fetched from nrl-ai/edgevox-models on first use, ~15 MB) appears in the MuJoCo viewer standing on its home keyframe. Say "walk forward half a meter", "turn left ninety degrees", "stand" — a procedural gait swings the legs + arms while the root advances. Plug in an ONNX walking policy via MujocoHumanoidEnvironment.set_walking_policy(...) for real RL locomotion.
Real robot or external sim via ROS2
source /opt/ros/jazzy/setup.bash
edgevox-agent robot-external --text-mode
Subscribes to odom, optionally scan + camera/image_raw, and publishes cmd_vel + goal_pose. Drives any Gazebo Harmonic world, Isaac Sim (via ROS2 bridge), or a real mobile robot that speaks the standard contract — the same agent code works unchanged.
@tool / @skill decorators — auto-derive JSON schemas from Python signatures + docstringsLLMAgent with per-run history isolation, reentrant, thread-safeSequence, Fallback, Loop, Parallel, Router, Supervisor, Orchestrator, Retry, Timeout — behavior-tree-shaped + multi-agent patterns, nestablestate_update writes blackboard keys before the target runsToolRegistry schemas; tool_choice_policy="required_first_hop" is the canonical SLM loop-break (no malformed JSON, no fabricated tool names)on_run_start, before_llm, after_llm, before_tool, after_tool, on_run_end), priority-ordered (Safety 100 → Observability 0), 12 built-ins ship + 3 SLM hardening hooksFact schema (facts_as_of(t)), JSONMemoryStore + SQLiteSessionStore, Compactor with tokenizer-exact counts, file-based NotesFilemake_artifact_tools(store)GoalHandle lifecycle with poll / cancel / feedback; mid-flight preempt is bounded by the skill-poll interval (no LLM round-trip on the cancel path)SafetyMonitor — stop-word preempt before the LLM is consultedEventBus — thread-safe pub/sub for observability, metrics, main-thread schedulingSimEnvironment protocol — agent code swaps cleanly between ToyWorld (stdlib), IrSimEnvironment (IR-SIM), and MujocoArmEnvironment (MuJoCo)ThreadPoolExecutorhome, robot, dev, robot-scout, robot-irsim, robot-panda, robot-humanoid, robot-externalbenchmarks/)specsub AEC on by default + energy-ratio gate so the bot doesn't hear itself; LLM generation aborted via llama-cpp stopping_criteria (cancellation lands at the next decode step); back-to-back barge-ins re-arm cleanlyedgevox_msgs/action/ExecuteSkill action server, external-sim driver for Gazebo / Isaac / real hardware# 1. Install uv (fast Python package manager)
curl -LsSf https://astral.sh/uv/install.sh | sh
# 2. Create a virtual environment
uv venv --python 3.12
source .venv/bin/activate
# 3. Install llama-cpp-python (GPU or CPU, your choice)
uv pip install llama-cpp-python \
--extra-index-url https://abetlen.github.io/llama-cpp-python/whl/cu124
# For Apple Silicon: CMAKE_ARGS="-DGGML_METAL=on" uv pip install llama-cpp-python
# For CPU only: uv pip install llama-cpp-python
# 4. Install EdgeVox with the sim extra (pulls in ir-sim)
uv pip install -e '.[sim]'
# 5. Download models (~3 GB)
edgevox-setup
# 6a. Run a voice agent with a visible robot
edgevox-agent robot-irsim --text-mode
# 6b. OR run the classic voice pipeline
edgevox
from edgevox.agents import AgentContext, GoalHandle, ToyWorld, skill
from edgevox.examples.agents.framework import AgentApp
from edgevox.llm import tool


@tool
def set_light(room: str, on: bool, ctx: AgentContext) -> str:
    """Turn a room's light on or off.

    Args:
        room: the room name, e.g. "kitchen".
        on: true to turn on, false to turn off.
    """
    ctx.deps.apply_action("set_light", room=room, on=on)
    return f"{room} light is now {'on' if on else 'off'}"


@skill(latency_class="slow", timeout_s=30.0)
def navigate_to(room: str, ctx: AgentContext) -> GoalHandle:
    """Drive the robot to a named room.

    Args:
        room: target room, e.g. "kitchen", "bedroom".
    """
    return ctx.deps.apply_action("navigate_to", room=room)


AgentApp(
    name="Scout",
    instructions="You are Scout, a terse home robot. Confirm what you did in one sentence.",
    tools=[set_light],
    skills=[navigate_to],
    deps=ToyWorld(),
    stop_words=("stop", "halt", "freeze"),
).run()
Launch with python my_agent.py --text-mode and you have a voice-controllable robot running on a stdlib-only reference sim. Swap ToyWorld() for IrSimEnvironment() and a matplotlib window opens. Full guide: docs/documentation/agents.md.
The five built-in agents are subcommands of edgevox-agent:
| Command | What it does |
|---|---|
edgevox-agent home | Home automation — lights, thermostat, timers, weather |
edgevox-agent robot | Simple robot demo with pose + battery |
edgevox-agent dev | Developer toolbox — arithmetic, unit conversion, notes |
edgevox-agent robot-scout | Full agent demo on ToyWorld (stdlib, no extra deps) |
edgevox-agent robot-irsim | Full agent demo on IR-SIM with matplotlib window |
edgevox-agent robot-panda | MuJoCo Franka Panda — voice pick-and-place |
edgevox-agent robot-humanoid | MuJoCo Unitree G1 / H1 — voice walk / turn / stand |
edgevox-agent robot-external | Drive any external ROS2 robot (Gazebo, Isaac, real hardware) |
Each one supports --text-mode, --simple-ui, or (default) full TUI. Any of them composes with --ros2 to attach the full ROS2 bridge + Nav2 / TF2 / sensor adapter + execute_skill action server.
Voice-controlled offline chess partner built on EdgeVox — a PySide6 desktop app that runs the Qt UI, the LLMAgent, llama-cpp (Llama-3.2-1B Q4_K_M), and Stockfish all in one Python process. No browser, no web server, no Node toolchain. Three personas (casual, grandmaster, trash_talker), six board themes, three piece sets, Kokoro TTS, Whisper STT with barge-in.
# 1. Install the desktop extra (PySide6 + qtawesome + rlottie + pillow)
uv pip install -e '.[desktop]'

# 2. Stockfish on $PATH (GPL — stays out-of-process, app stays MIT)
sudo apt-get install -y stockfish          # Linux
brew install stockfish                     # macOS
# Windows: https://stockfishchess.org/download/

# 3. Download STT + LLM + TTS models (~3 GB, one time)
edgevox-setup

# 4. Launch
edgevox-chess-robot
Flags: --persona {grandmaster,casual,trash_talker}, --user-plays {white,black}, --engine {stockfish,maia}, --stockfish-skill 0..20, --maia-weights PATH, -v. Every flag also reads an EDGEVOX_CHESS_* env var. Piece set, board theme, persona, audio devices, and debug-mode settings live in the in-app ☰ → Settings… dialog. Preferences persist via QSettings. Full guide: docs/documentation/desktop.md.
| Tier | Sim | Dependencies | Role | Status |
|---|---|---|---|---|
| 0 | ToyWorld | stdlib only | unit tests, trivial examples | shipped |
| 1 | IrSimEnvironment | pip install ir-sim | 2D visual demo (matplotlib, diff-drive, LiDAR) | shipped |
| 2a | MujocoArmEnvironment | pip install mujoco | 3D physics, Franka Panda pick-and-place | shipped |
| 2b | MujocoHumanoidEnvironment | pip install mujoco | Unitree G1 / H1, procedural gait, ONNX policy slot | shipped |
| 3 | ExternalROS2Environment | sourced ROS2 workspace | Gazebo Harmonic, Isaac Sim (ROS2 bridge), real robots | shipped |
All tiers implement the same SimEnvironment protocol — agent code doesn't change when you swap backends. robot-irsim is Tier 1; robot-panda is Tier 2a; robot-humanoid is Tier 2b; robot-external is Tier 3 and can point at any Gazebo world or real robot that publishes nav_msgs/Odometry and accepts geometry_msgs/Twist.
EdgeVox's original identity and the agent framework's substrate. Streaming STT → LLM → TTS with voice interrupt, wake words, 16 languages, TUI and web UIs. Run it without any agent code:
edgevox                         # full TUI (default)
edgevox --web-ui                # browser interface
edgevox --wakeword "hey jarvis"
edgevox-cli                     # simple CLI
edgevox-cli --text-mode         # no microphone needed
| Language | STT | TTS | Voices |
|---|---|---|---|
| 🇺🇸 English, 🇫🇷 French, 🇪🇸 Spanish, 🇮🇳 Hindi, 🇮🇹 Italian, 🇧🇷 Portuguese, 🇯🇵 Japanese, 🇨🇳 Chinese | faster-whisper | Kokoro | 25 |
| 🇻🇳 Vietnamese | sherpa-onnx (Zipformer) | Piper | 20 |
| 🇩🇪 German, 🇷🇺 Russian, 🇸🇦 Arabic, 🇮🇩 Indonesian | faster-whisper | Piper | varies |
| 🇰🇷 Korean | faster-whisper | Supertonic | 10 |
| 🇹🇭 Thai | faster-whisper | PyThaiTTS | 1 |
Models are hosted on nrl-ai/edgevox-models (HuggingFace) with fallback to upstream repos.
Full TUI + slash-command reference: docs/documentation/commands.md.
| Device | RAM | GPU | Status |
|---|---|---|---|
| PC (i9 + RTX 3080 16 GB) | 64 GB | CUDA | supported — first-audio latency TBD |
| Jetson Orin Nano | 8 GB | CUDA | supported — first-audio latency TBD |
| MacBook Air M1 | 8 GB | Metal | supported — first-audio latency TBD |
| Any modern laptop | 16 GB+ | CPU only | supported — first-audio latency TBD |
Latency cells are intentionally TBD. EdgeVox does not publish projected or untested numbers. Once
benchmarks/perf/bench_voice_ttft.pyruns on a given device, the measured value lands here. PRs welcome with hardware fingerprint + script output.
EdgeVox ships a full ROS2 surface, opt-in with --ros2 on any agent or the voice pipeline. Topics live under a configurable namespace (default /edgevox).
source /opt/ros/jazzy/setup.bash
edgevox --ros2                                      # voice pipeline
edgevox-agent robot-humanoid --simple-ui --ros2     # G1 + voice + ROS2
edgevox-agent robot-external --text-mode            # drive an external ROS2 robot
Published: transcription, response, state (transient-local), audio_level, metrics, bot_token, bot_sentence, wakeword, info, robot_state (sim snapshot), agent_event (JSON stream of tool calls / skill goals / handoffs / safety preempts). With a sim attached, RobotROS2Adapter adds /tf, pose, scan (IR-SIM lidar), image_raw (MuJoCo camera).
Subscribed: tts_request, command, text_input, interrupt, set_language, set_voice, cmd_vel (Nav2 Twist), goal_pose (Nav2 PoseStamped).
Services: list_voices, list_languages, hardware_info, model_info — each an std_srvs/srv/Trigger returning JSON.
Actions: execute_skill (edgevox_msgs/action/ExecuteSkill) — generic skill_name + arguments_json goal so any agent skill is callable by a stock rclpy.action.ActionClient. Build the companion interface package with colcon build --packages-select edgevox_msgs.
Launch files under launch/: edgevox.launch.py, edgevox_irsim.launch.py, edgevox_panda.launch.py. Full reference: docs/documentation/ros2.md.
EdgeVox follows the classical robotics three-layer pattern. The agent framework lives only in the deliberative layer; safety reflexes and real-time control never touch the LLM.
flowchart TB
    D["`**Deliberative** — ≤ 1 Hz
LLMAgent · Workflows · Router · Handoff
@tool · @skill (Python functions)`"]
    E["`**Executive** — 10–50 Hz
Skill library · GoalHandle lifecycle · BT-shaped workflows
goal / feedback / cancel`"]
    R["`**Reactive** — ≥ 100 Hz
Motor control · watchdogs · SafetyMonitor
*(bypasses LLM)*`"]
    VP["`**Voice pipeline** — the substrate
Mic → VAD → STT → AgentProcessor → SentenceSplit → TTS → Spk`"]
    OUT["`ROS2 bridge · IR-SIM (Tier 1) · MuJoCo arm (Tier 2a) · Unitree G1/H1 (Tier 2b) · External ROS2 / Gazebo (Tier 3)`"]
    D --> E --> R
    R --> VP
    VP --> D
    VP --> OUT
    classDef deliberative fill:#f3bd92,stroke:#8c4000,color:#4a2200,stroke-width:2px
    classDef executive    fill:#e3e3e1,stroke:#a6a6a3,color:#2a2a2a
    classDef reactive     fill:#cececb,stroke:#7e7e7c,color:#1a1a1d
    classDef substrate    fill:#f1f1ef,stroke:#cececb,color:#424241
    classDef out          fill:#fafaf8,stroke:#cececb,color:#5c5c5a
    class D deliberative
    class E executive
    class R reactive
    class VP substrate
    class OUT out
The LLM never enters the reactive layer. Safety reflexes bypass it. Skills expose intents (navigate_to(room)), not control (set_speed(mps)). Every other design choice flows from this rule.
| Component | Model | Size | RAM |
|---|---|---|---|
| VAD | Silero VAD v6 | ~2 MB | ~10 MB |
| STT | whisper-small | 500 MB | ~600 MB |
| STT | whisper-large-v3-turbo | 1.5 GB | ~2 GB |
| LLM | Gemma 4 E2B IT Q4_K_M | 1.8 GB | ~2.5 GB |
| TTS | Kokoro 82M | 200 MB | ~300 MB |
| Wake | pymicro-wakeword | ~5 MB | ~10 MB |
PlanExecuteEvaluate and friends: one-line factories for the multi-agent harness patterns from Anthropic's "Harness Design for Long-running Apps". Includes a runnable demo on ToyWorld + a model-size benchmarkexecute_skill action, TF2 / Nav2 / sensor interop, launch filesIn-depth docs for each subsystem of the agent harness:
MemoryStore / SessionStore / Compactor / NotesFile, bi-temporal factscancel_token to llama-cpp stopping_criteria, AEC defaults, repeatable interruptstool_choice_policyFull site: EdgeVox Docs (VitePress). Run locally:
cd docs && npm run dev
If you use EdgeVox in research or production, please cite:
@software{edgevox2026,
  author = {Nguyen, Viet-Anh and {Neural Research Lab}},
  title  = {EdgeVox: on-device voice agents for robotics},
  year   = {2026},
  url    = {https://github.com/nrl-ai/edgevox},
  note   = {MIT License}
}
MIT
Offline voice agent framework for robots — agents, skills, workflows, sub-second voice pipeline, 2D/3D simulation (IR-SIM + MuJoCo), 16 languages, 56 voices, ROS2-native. Runs on CPU/CUDA/Metal, no cloud.
See the codeOffline voice agent framework for robots and desktop apps. Local streaming voice pipeline. Fully private.
|
Voice pipeline TUI — streaming STT · LLM · TTS with VAD barge-in |
MuJoCo · Franka arm — voice-controlled pick-and-place |
|
Unitree G1 humanoid — procedural gait + ONNX policy slot |
RookApp desktop — offline chess partner (Qt + LLMAgent + Stockfish, one Python process) |
Agents + Skills + Workflows | 2D sim (IR-SIM) | 3D sim (MuJoCo) | Streaming voice pipeline | 16 languages | 56 voices | ROS2-native | Ships as a desktop app
benchmarks/ for the harness; numbers land here once the first run completes.)@tool and @skill functions in Python; compose them with Sequence, Fallback, Loop, Parallel, and Router workflows; delegate across agents with OpenAI-SDK-style handoffs.GoalHandle, hard-stop SafetyMonitor that bypasses the LLM, three-tier simulation (stdlib → IR-SIM → MuJoCo), and a ROS2 bridge. Desktop apps get the same agent framework + voice pipeline shipped as a single PySide6 process — see RookApp below.2D — IR-SIM (mobile robot navigation)
pip install 'edgevox[sim]'
edgevox-setup                      # downloads ~3 GB of models, one time
edgevox-agent robot-irsim --text-mode
A matplotlib window opens showing a 10×10 apartment with four rooms. Type "go to the kitchen" — the blue robot drives visibly. Say "stop" mid-flight and the safety monitor preempts the skill before the LLM is consulted — the halt path doesn't wait on a model round-trip. Swap --text-mode for --simple-ui to drive it by voice.
3D — MuJoCo (tabletop arm pick-and-place)
pip install 'edgevox[sim-mujoco]'
edgevox-agent robot-panda --text-mode
A MuJoCo viewer opens with a Franka Panda arm above a table with three colored cubes. Type "pick up the red cube" — the arm moves, grasps, and lifts. Voice commands control move_to, grasp, release, and goto_home skills.
3D — MuJoCo humanoid (Unitree G1 / H1)
pip install 'edgevox[sim-mujoco]'
edgevox-agent robot-humanoid --simple-ui
A Unitree humanoid (auto-fetched from nrl-ai/edgevox-models on first use, ~15 MB) appears in the MuJoCo viewer standing on its home keyframe. Say "walk forward half a meter", "turn left ninety degrees", "stand" — a procedural gait swings the legs + arms while the root advances. Plug in an ONNX walking policy via MujocoHumanoidEnvironment.set_walking_policy(...) for real RL locomotion.
Real robot or external sim via ROS2
source /opt/ros/jazzy/setup.bash
edgevox-agent robot-external --text-mode
Subscribes to odom, optionally scan + camera/image_raw, and publishes cmd_vel + goal_pose. Drives any Gazebo Harmonic world, Isaac Sim (via ROS2 bridge), or a real mobile robot that speaks the standard contract — the same agent code works unchanged.
@tool / @skill decorators — auto-derive JSON schemas from Python signatures + docstringsLLMAgent with per-run history isolation, reentrant, thread-safeSequence, Fallback, Loop, Parallel, Router, Supervisor, Orchestrator, Retry, Timeout — behavior-tree-shaped + multi-agent patterns, nestablestate_update writes blackboard keys before the target runsToolRegistry schemas; tool_choice_policy="required_first_hop" is the canonical SLM loop-break (no malformed JSON, no fabricated tool names)on_run_start, before_llm, after_llm, before_tool, after_tool, on_run_end), priority-ordered (Safety 100 → Observability 0), 12 built-ins ship + 3 SLM hardening hooksFact schema (facts_as_of(t)), JSONMemoryStore + SQLiteSessionStore, Compactor with tokenizer-exact counts, file-based NotesFilemake_artifact_tools(store)GoalHandle lifecycle with poll / cancel / feedback; mid-flight preempt is bounded by the skill-poll interval (no LLM round-trip on the cancel path)SafetyMonitor — stop-word preempt before the LLM is consultedEventBus — thread-safe pub/sub for observability, metrics, main-thread schedulingSimEnvironment protocol — agent code swaps cleanly between ToyWorld (stdlib), IrSimEnvironment (IR-SIM), and MujocoArmEnvironment (MuJoCo)ThreadPoolExecutorhome, robot, dev, robot-scout, robot-irsim, robot-panda, robot-humanoid, robot-externalbenchmarks/)specsub AEC on by default + energy-ratio gate so the bot doesn't hear itself; LLM generation aborted via llama-cpp stopping_criteria (cancellation lands at the next decode step); back-to-back barge-ins re-arm cleanlyedgevox_msgs/action/ExecuteSkill action server, external-sim driver for Gazebo / Isaac / real hardware# 1. Install uv (fast Python package manager)
curl -LsSf https://astral.sh/uv/install.sh | sh
# 2. Create a virtual environment
uv venv --python 3.12
source .venv/bin/activate
# 3. Install llama-cpp-python (GPU or CPU, your choice)
uv pip install llama-cpp-python \
--extra-index-url https://abetlen.github.io/llama-cpp-python/whl/cu124
# For Apple Silicon: CMAKE_ARGS="-DGGML_METAL=on" uv pip install llama-cpp-python
# For CPU only: uv pip install llama-cpp-python
# 4. Install EdgeVox with the sim extra (pulls in ir-sim)
uv pip install -e '.[sim]'
# 5. Download models (~3 GB)
edgevox-setup
# 6a. Run a voice agent with a visible robot
edgevox-agent robot-irsim --text-mode
# 6b. OR run the classic voice pipeline
edgevox
from edgevox.agents import AgentContext, GoalHandle, ToyWorld, skill
from edgevox.examples.agents.framework import AgentApp
from edgevox.llm import tool


@tool
def set_light(room: str, on: bool, ctx: AgentContext) -> str:
    """Turn a room's light on or off.

    Args:
        room: the room name, e.g. "kitchen".
        on: true to turn on, false to turn off.
    """
    ctx.deps.apply_action("set_light", room=room, on=on)
    return f"{room} light is now {'on' if on else 'off'}"


@skill(latency_class="slow", timeout_s=30.0)
def navigate_to(room: str, ctx: AgentContext) -> GoalHandle:
    """Drive the robot to a named room.

    Args:
        room: target room, e.g. "kitchen", "bedroom".
    """
    return ctx.deps.apply_action("navigate_to", room=room)


AgentApp(
    name="Scout",
    instructions="You are Scout, a terse home robot. Confirm what you did in one sentence.",
    tools=[set_light],
    skills=[navigate_to],
    deps=ToyWorld(),
    stop_words=("stop", "halt", "freeze"),
).run()
Launch with python my_agent.py --text-mode and you have a voice-controllable robot running on a stdlib-only reference sim. Swap ToyWorld() for IrSimEnvironment() and a matplotlib window opens. Full guide: docs/documentation/agents.md.
The five built-in agents are subcommands of edgevox-agent:
| Command | What it does |
|---|---|
edgevox-agent home | Home automation — lights, thermostat, timers, weather |
edgevox-agent robot | Simple robot demo with pose + battery |
edgevox-agent dev | Developer toolbox — arithmetic, unit conversion, notes |
edgevox-agent robot-scout | Full agent demo on ToyWorld (stdlib, no extra deps) |
edgevox-agent robot-irsim | Full agent demo on IR-SIM with matplotlib window |
edgevox-agent robot-panda | MuJoCo Franka Panda — voice pick-and-place |
edgevox-agent robot-humanoid | MuJoCo Unitree G1 / H1 — voice walk / turn / stand |
edgevox-agent robot-external | Drive any external ROS2 robot (Gazebo, Isaac, real hardware) |
Each one supports --text-mode, --simple-ui, or (default) full TUI. Any of them composes with --ros2 to attach the full ROS2 bridge + Nav2 / TF2 / sensor adapter + execute_skill action server.
Voice-controlled offline chess partner built on EdgeVox — a PySide6 desktop app that runs the Qt UI, the LLMAgent, llama-cpp (Llama-3.2-1B Q4_K_M), and Stockfish all in one Python process. No browser, no web server, no Node toolchain. Three personas (casual, grandmaster, trash_talker), six board themes, three piece sets, Kokoro TTS, Whisper STT with barge-in.
# 1. Install the desktop extra (PySide6 + qtawesome + rlottie + pillow)
uv pip install -e '.[desktop]'

# 2. Stockfish on $PATH (GPL — stays out-of-process, app stays MIT)
sudo apt-get install -y stockfish          # Linux
brew install stockfish                     # macOS
# Windows: https://stockfishchess.org/download/

# 3. Download STT + LLM + TTS models (~3 GB, one time)
edgevox-setup

# 4. Launch
edgevox-chess-robot
Flags: --persona {grandmaster,casual,trash_talker}, --user-plays {white,black}, --engine {stockfish,maia}, --stockfish-skill 0..20, --maia-weights PATH, -v. Every flag also reads an EDGEVOX_CHESS_* env var. Piece set, board theme, persona, audio devices, and debug-mode settings live in the in-app ☰ → Settings… dialog. Preferences persist via QSettings. Full guide: docs/documentation/desktop.md.
| Tier | Sim | Dependencies | Role | Status |
|---|---|---|---|---|
| 0 | ToyWorld | stdlib only | unit tests, trivial examples | shipped |
| 1 | IrSimEnvironment | pip install ir-sim | 2D visual demo (matplotlib, diff-drive, LiDAR) | shipped |
| 2a | MujocoArmEnvironment | pip install mujoco | 3D physics, Franka Panda pick-and-place | shipped |
| 2b | MujocoHumanoidEnvironment | pip install mujoco | Unitree G1 / H1, procedural gait, ONNX policy slot | shipped |
| 3 | ExternalROS2Environment | sourced ROS2 workspace | Gazebo Harmonic, Isaac Sim (ROS2 bridge), real robots | shipped |
All tiers implement the same SimEnvironment protocol — agent code doesn't change when you swap backends. robot-irsim is Tier 1; robot-panda is Tier 2a; robot-humanoid is Tier 2b; robot-external is Tier 3 and can point at any Gazebo world or real robot that publishes nav_msgs/Odometry and accepts geometry_msgs/Twist.
EdgeVox's original identity and the agent framework's substrate. Streaming STT → LLM → TTS with voice interrupt, wake words, 16 languages, TUI and web UIs. Run it without any agent code:
edgevox                         # full TUI (default)
edgevox --web-ui                # browser interface
edgevox --wakeword "hey jarvis"
edgevox-cli                     # simple CLI
edgevox-cli --text-mode         # no microphone needed
| Language | STT | TTS | Voices |
|---|---|---|---|
| 🇺🇸 English, 🇫🇷 French, 🇪🇸 Spanish, 🇮🇳 Hindi, 🇮🇹 Italian, 🇧🇷 Portuguese, 🇯🇵 Japanese, 🇨🇳 Chinese | faster-whisper | Kokoro | 25 |
| 🇻🇳 Vietnamese | sherpa-onnx (Zipformer) | Piper | 20 |
| 🇩🇪 German, 🇷🇺 Russian, 🇸🇦 Arabic, 🇮🇩 Indonesian | faster-whisper | Piper | varies |
| 🇰🇷 Korean | faster-whisper | Supertonic | 10 |
| 🇹🇭 Thai | faster-whisper | PyThaiTTS | 1 |
Models are hosted on nrl-ai/edgevox-models (HuggingFace) with fallback to upstream repos.
Full TUI + slash-command reference: docs/documentation/commands.md.
| Device | RAM | GPU | Status |
|---|---|---|---|
| PC (i9 + RTX 3080 16 GB) | 64 GB | CUDA | supported — first-audio latency TBD |
| Jetson Orin Nano | 8 GB | CUDA | supported — first-audio latency TBD |
| MacBook Air M1 | 8 GB | Metal | supported — first-audio latency TBD |
| Any modern laptop | 16 GB+ | CPU only | supported — first-audio latency TBD |
Latency cells are intentionally TBD. EdgeVox does not publish projected or untested numbers. Once
benchmarks/perf/bench_voice_ttft.pyruns on a given device, the measured value lands here. PRs welcome with hardware fingerprint + script output.
EdgeVox ships a full ROS2 surface, opt-in with --ros2 on any agent or the voice pipeline. Topics live under a configurable namespace (default /edgevox).
source /opt/ros/jazzy/setup.bash
edgevox --ros2                                      # voice pipeline
edgevox-agent robot-humanoid --simple-ui --ros2     # G1 + voice + ROS2
edgevox-agent robot-external --text-mode            # drive an external ROS2 robot
Published: transcription, response, state (transient-local), audio_level, metrics, bot_token, bot_sentence, wakeword, info, robot_state (sim snapshot), agent_event (JSON stream of tool calls / skill goals / handoffs / safety preempts). With a sim attached, RobotROS2Adapter adds /tf, pose, scan (IR-SIM lidar), image_raw (MuJoCo camera).
Subscribed: tts_request, command, text_input, interrupt, set_language, set_voice, cmd_vel (Nav2 Twist), goal_pose (Nav2 PoseStamped).
Services: list_voices, list_languages, hardware_info, model_info — each an std_srvs/srv/Trigger returning JSON.
Actions: execute_skill (edgevox_msgs/action/ExecuteSkill) — generic skill_name + arguments_json goal so any agent skill is callable by a stock rclpy.action.ActionClient. Build the companion interface package with colcon build --packages-select edgevox_msgs.
Launch files under launch/: edgevox.launch.py, edgevox_irsim.launch.py, edgevox_panda.launch.py. Full reference: docs/documentation/ros2.md.
EdgeVox follows the classical robotics three-layer pattern. The agent framework lives only in the deliberative layer; safety reflexes and real-time control never touch the LLM.
flowchart TB
    D["`**Deliberative** — ≤ 1 Hz
LLMAgent · Workflows · Router · Handoff
@tool · @skill (Python functions)`"]
    E["`**Executive** — 10–50 Hz
Skill library · GoalHandle lifecycle · BT-shaped workflows
goal / feedback / cancel`"]
    R["`**Reactive** — ≥ 100 Hz
Motor control · watchdogs · SafetyMonitor
*(bypasses LLM)*`"]
    VP["`**Voice pipeline** — the substrate
Mic → VAD → STT → AgentProcessor → SentenceSplit → TTS → Spk`"]
    OUT["`ROS2 bridge · IR-SIM (Tier 1) · MuJoCo arm (Tier 2a) · Unitree G1/H1 (Tier 2b) · External ROS2 / Gazebo (Tier 3)`"]
    D --> E --> R
    R --> VP
    VP --> D
    VP --> OUT
    classDef deliberative fill:#f3bd92,stroke:#8c4000,color:#4a2200,stroke-width:2px
    classDef executive    fill:#e3e3e1,stroke:#a6a6a3,color:#2a2a2a
    classDef reactive     fill:#cececb,stroke:#7e7e7c,color:#1a1a1d
    classDef substrate    fill:#f1f1ef,stroke:#cececb,color:#424241
    classDef out          fill:#fafaf8,stroke:#cececb,color:#5c5c5a
    class D deliberative
    class E executive
    class R reactive
    class VP substrate
    class OUT out
The LLM never enters the reactive layer. Safety reflexes bypass it. Skills expose intents (navigate_to(room)), not control (set_speed(mps)). Every other design choice flows from this rule.
| Component | Model | Size | RAM |
|---|---|---|---|
| VAD | Silero VAD v6 | ~2 MB | ~10 MB |
| STT | whisper-small | 500 MB | ~600 MB |
| STT | whisper-large-v3-turbo | 1.5 GB | ~2 GB |
| LLM | Gemma 4 E2B IT Q4_K_M | 1.8 GB | ~2.5 GB |
| TTS | Kokoro 82M | 200 MB | ~300 MB |
| Wake | pymicro-wakeword | ~5 MB | ~10 MB |
PlanExecuteEvaluate and friends: one-line factories for the multi-agent harness patterns from Anthropic's "Harness Design for Long-running Apps". Includes a runnable demo on ToyWorld + a model-size benchmarkexecute_skill action, TF2 / Nav2 / sensor interop, launch filesIn-depth docs for each subsystem of the agent harness:
MemoryStore / SessionStore / Compactor / NotesFile, bi-temporal factscancel_token to llama-cpp stopping_criteria, AEC defaults, repeatable interruptstool_choice_policyFull site: EdgeVox Docs (VitePress). Run locally:
cd docs && npm run dev
If you use EdgeVox in research or production, please cite:
@software{edgevox2026,
  author = {Nguyen, Viet-Anh and {Neural Research Lab}},
  title  = {EdgeVox: on-device voice agents for robotics},
  year   = {2026},
  url    = {https://github.com/nrl-ai/edgevox},
  note   = {MIT License}
}
MIT





