Open-source physical AI platform bridging ROS and RL — from learning to earning.
1,171
37 commits
updated Oct 16, 2026
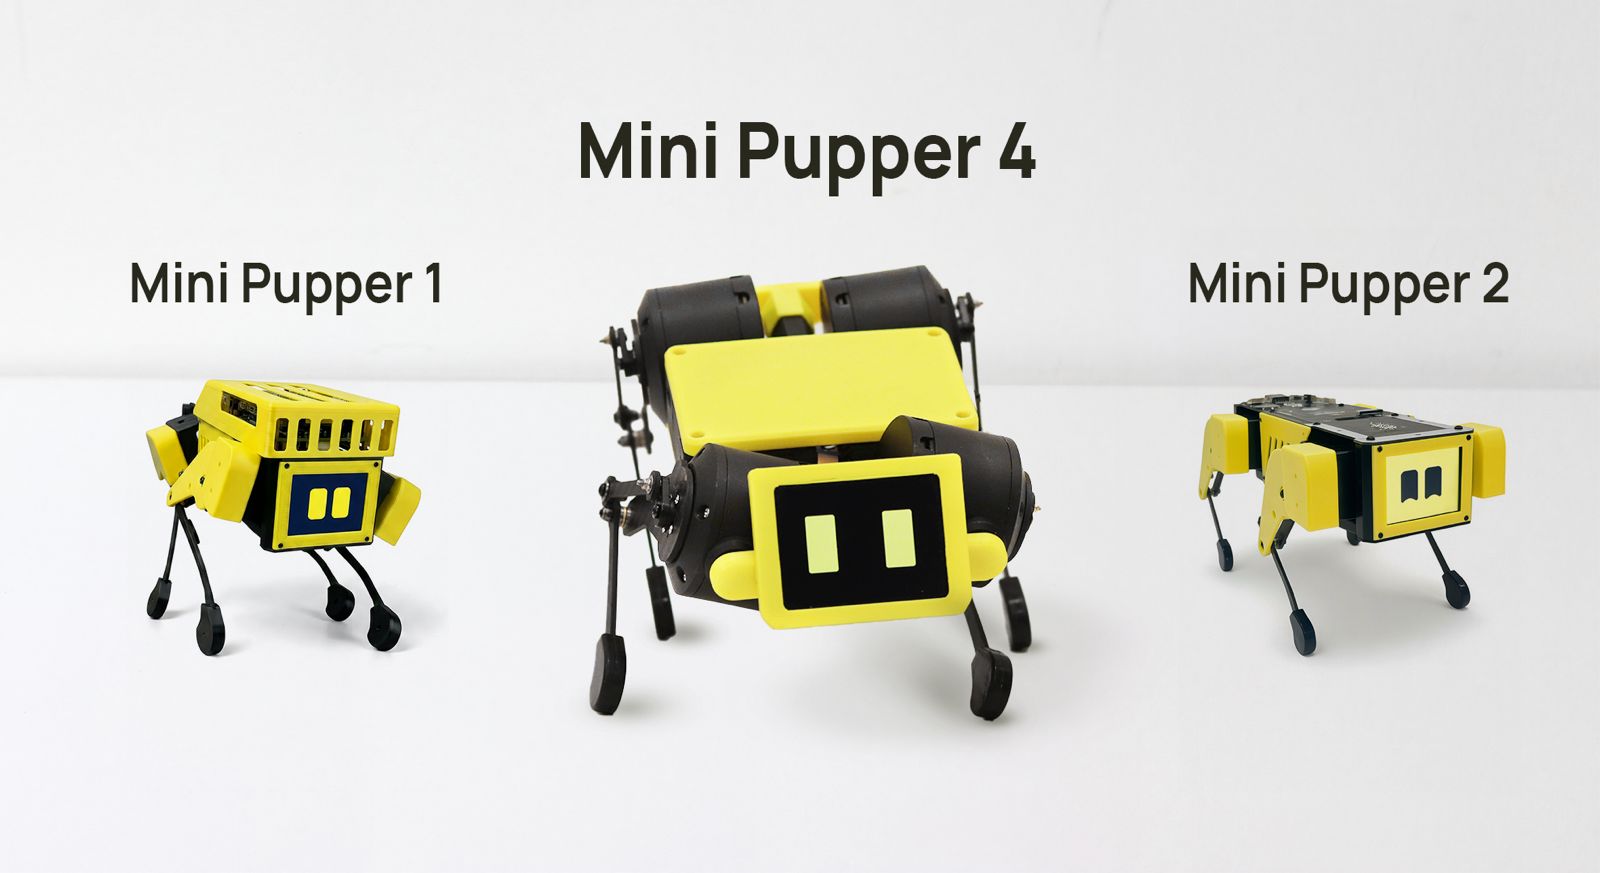
From Learning to Earning — Powered by 3-DoF Coreless Smart Servos.
Official Website · Facebook Group · Discord Community · Online Shop · Contributing Guide
|
|
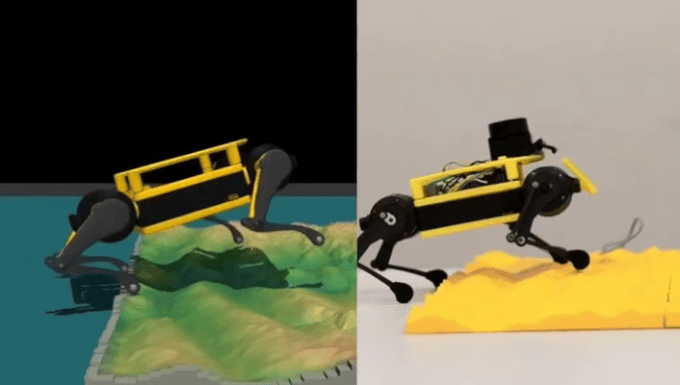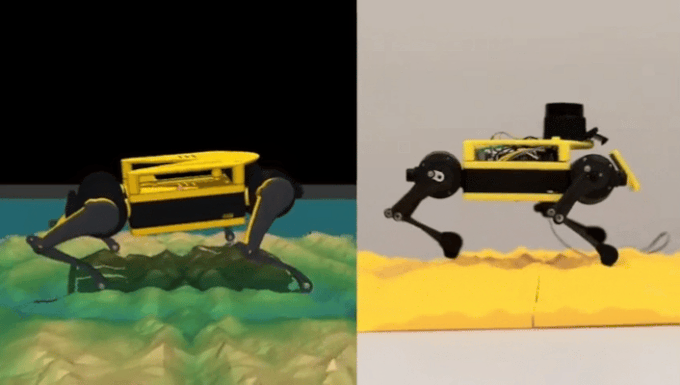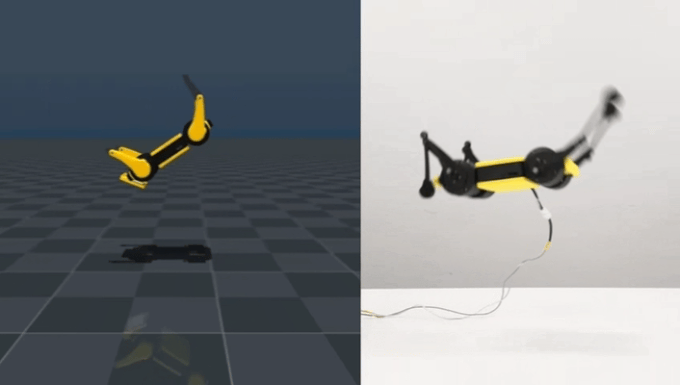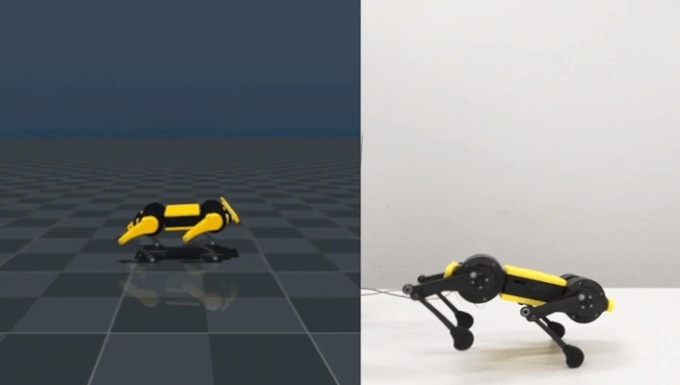
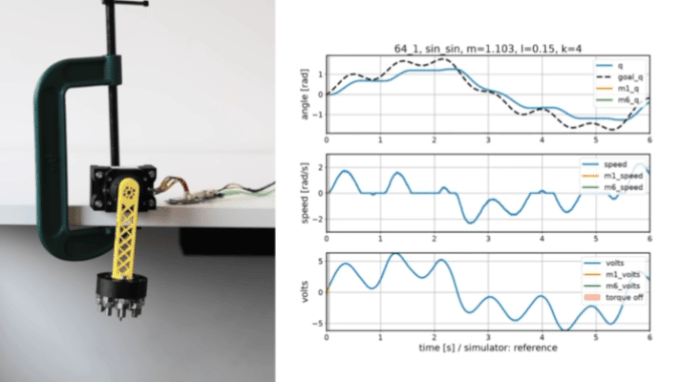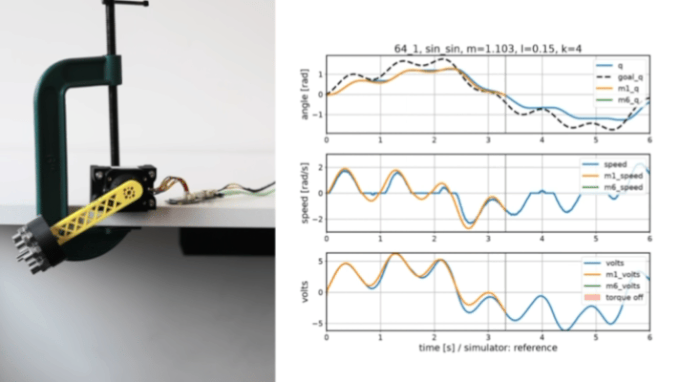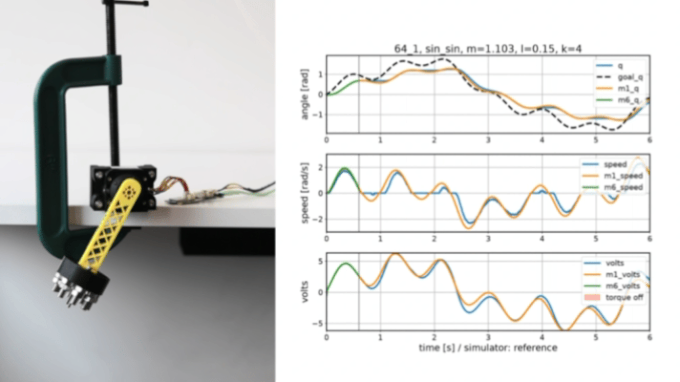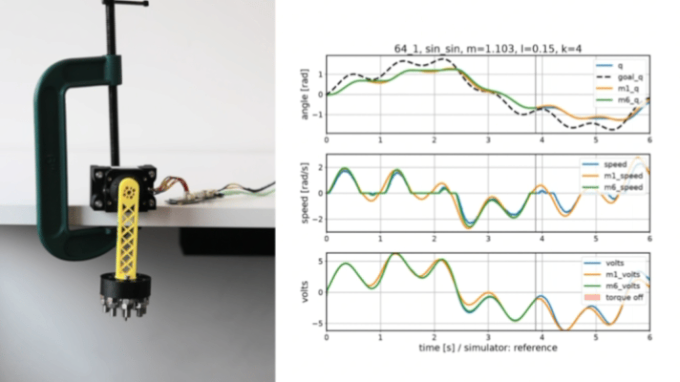
| Close the Sim2Real Gap. Train complex neural network policies flawlessly in high-fidelity simulation, and deploy straight to the real physical robot. | Native BAM Integration. Fully compatible with Better Actuator Models (BAM) to capture precise joint friction physics, letting you focus on your advanced applications. |
|
|
|
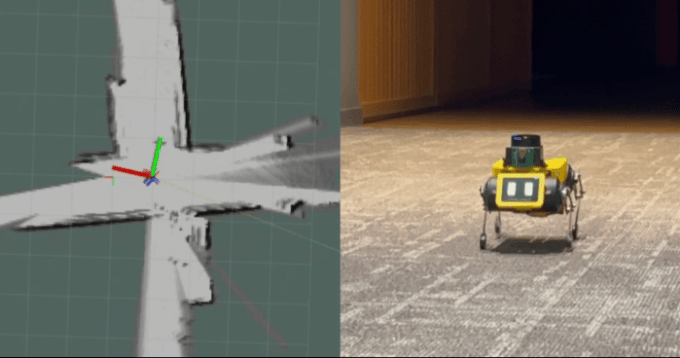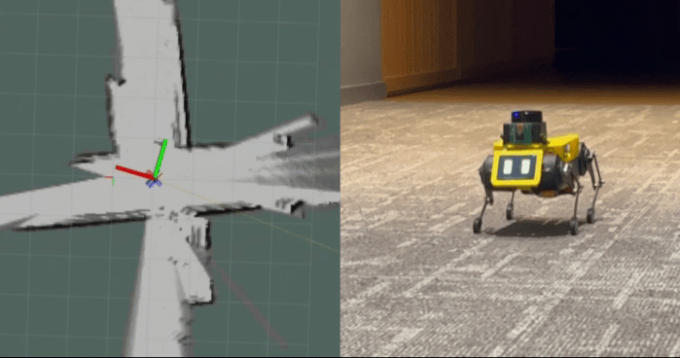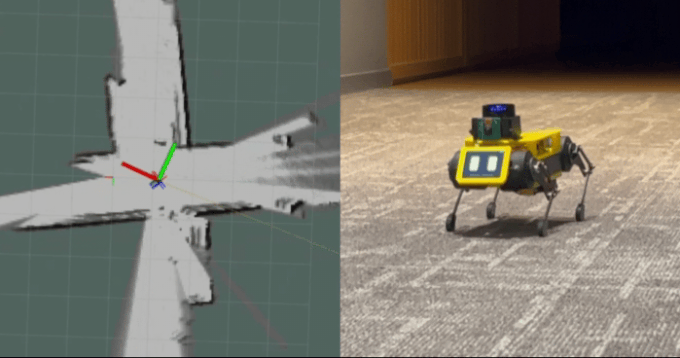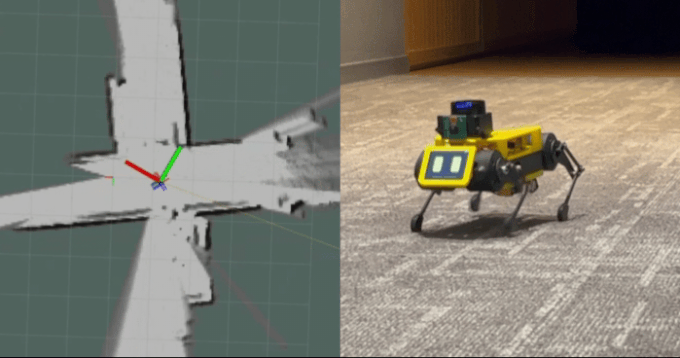
| Low-Level micro-ROS. Native support for micro-ROS pipelines directly on the microcontroller for reliable, real-time actuator control. | Next-Gen ROS 2 Jazzy. Ready-to-run out-of-the-box templates for advanced SLAM mapping, path planning, and autonomous Nav2 stacks. |
All capabilities stem from our proprietary high-performance, 3-DoF coreless smart servo joints — the ultimate, versatile building block for modern open-source robotics.
| Github Repo | Description |
|---|---|
| 🤖 RL | The physics engine backend: MuJoCo and NVIDIA Isaac environments, PPO pipelines, domain randomization, and the baked-in ONNX export runtime. |
| ⚙️ BAM Friction Engine | Hardware actuator physics repository. The MangDang MD-300C-150 servo is fully benchmarked and adapted to BAM. |
| 🛹 ROS 2 Core Stack | ROS software platform. We follow the official Open Robotics roadmap with stable support up to ROS 2 Jazzy and Lyrical. |
| 📡 micro-ROS Stack | micro ROS software platform. Real-time lower-level agent bridging. |
| 🧠 MCU Brain | Complete firmware layer source code for the onboard microcontroller, including embedded local AI routing. |
| 🍓 Raspberry Pi Brain | High-level application space source code tailored for the Raspberry Pi computing chassis. |
| 🤝 CONTRIBUTING.md | Developer guidelines for compiling, local simulation testing, layout conventions, and code submission rules. |
| 📖 Online Manual | Comprehensive documentation hub, including modular mechanical blueprints, PCB schematics, and open research challenges. |
| mini pupper 1 bsp | BSP(board support package) for Mini Pupper 1. |
| mini pupper 2 bsp | BSP(board support package) for Mini Pupper 2. |
| mini pupper web controller | This code provides a web GUI for Mini Pupper 1&2 running StanfordQuadruped. |
| Repository | Description | Status |
|---|---|---|
| minipupper_kinematics | This repositories contains Jupyter notebook that used to gain a better understanding of the kinematics of a quadruped robot in general and Mini Pupper 1 in particular. | experimental |
| mini-pupper-jupyter-notebooks | ROSCon2022 Jupyter Notebooks for Mini Pupper 1. | experimental |
171 followers · starred Feb 2022
36 followers · starred Jul 2022
17 followers · starred Oct 2025
27 followers · starred Jun 2021
Open-source physical AI platform bridging ROS and RL — from learning to earning.
1,171
37 commits
updated Oct 16, 2026
From Learning to Earning — Powered by 3-DoF Coreless Smart Servos.
Official Website · Facebook Group · Discord Community · Online Shop · Contributing Guide
|
|
|
| Close the Sim2Real Gap. Train complex neural network policies flawlessly in high-fidelity simulation, and deploy straight to the real physical robot. | Native BAM Integration. Fully compatible with Better Actuator Models (BAM) to capture precise joint friction physics, letting you focus on your advanced applications. |
|
|
|
| Low-Level micro-ROS. Native support for micro-ROS pipelines directly on the microcontroller for reliable, real-time actuator control. | Next-Gen ROS 2 Jazzy. Ready-to-run out-of-the-box templates for advanced SLAM mapping, path planning, and autonomous Nav2 stacks. |
All capabilities stem from our proprietary high-performance, 3-DoF coreless smart servo joints — the ultimate, versatile building block for modern open-source robotics.
| Github Repo | Description |
|---|---|
| 🤖 RL | The physics engine backend: MuJoCo and NVIDIA Isaac environments, PPO pipelines, domain randomization, and the baked-in ONNX export runtime. |
| ⚙️ BAM Friction Engine | Hardware actuator physics repository. The MangDang MD-300C-150 servo is fully benchmarked and adapted to BAM. |
| 🛹 ROS 2 Core Stack | ROS software platform. We follow the official Open Robotics roadmap with stable support up to ROS 2 Jazzy and Lyrical. |
| 📡 micro-ROS Stack | micro ROS software platform. Real-time lower-level agent bridging. |
| 🧠 MCU Brain | Complete firmware layer source code for the onboard microcontroller, including embedded local AI routing. |
| 🍓 Raspberry Pi Brain | High-level application space source code tailored for the Raspberry Pi computing chassis. |
| 🤝 CONTRIBUTING.md | Developer guidelines for compiling, local simulation testing, layout conventions, and code submission rules. |
| 📖 Online Manual | Comprehensive documentation hub, including modular mechanical blueprints, PCB schematics, and open research challenges. |
| mini pupper 1 bsp | BSP(board support package) for Mini Pupper 1. |
| mini pupper 2 bsp | BSP(board support package) for Mini Pupper 2. |
| mini pupper web controller | This code provides a web GUI for Mini Pupper 1&2 running StanfordQuadruped. |
| Repository | Description | Status |
|---|---|---|
| minipupper_kinematics | This repositories contains Jupyter notebook that used to gain a better understanding of the kinematics of a quadruped robot in general and Mini Pupper 1 in particular. | experimental |
| mini-pupper-jupyter-notebooks | ROSCon2022 Jupyter Notebooks for Mini Pupper 1. | experimental |
171 followers · starred Feb 2022
36 followers · starred Jul 2022
17 followers · starred Oct 2025
27 followers · starred Jun 2021