English / 简体中文

From mechanical design and electronics to firmware, control and learning.
Built to be understood. Open to be built upon.

RP1 is RoboParty's fully open-source humanoid platform: a shared foundation for building, understanding and extending a real robot.
The platform brings mechanical and electrical design, joint modules, firmware, robot models, deployment and learning into one connected development stack. Explore a single subsystem, reproduce a build, or develop your own control and learning workflows.
| Hardware you can inspect | Software you can extend | Intelligence you can explore |
|---|---|---|
| Mechanical CAD, schematics, PCB layouts, Gerber files, BOM and assembly documentation. | Linux BSP, communication, device interfaces, robot descriptions and deployment modules. | Locomotion training, motion imitation, tracking and behavior-model projects. |
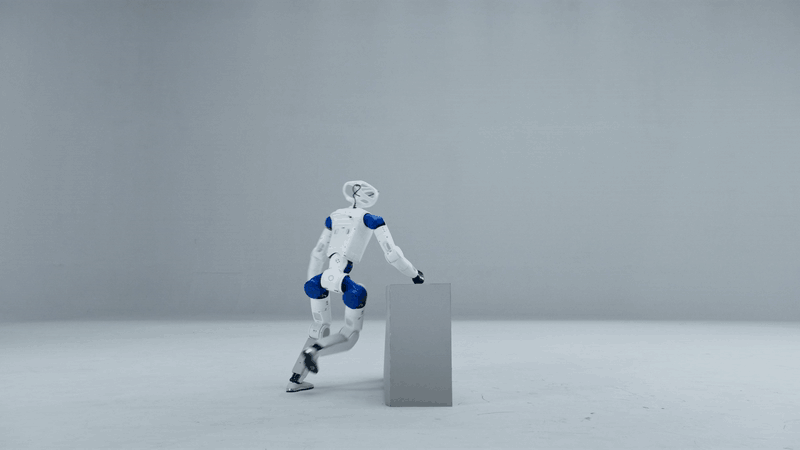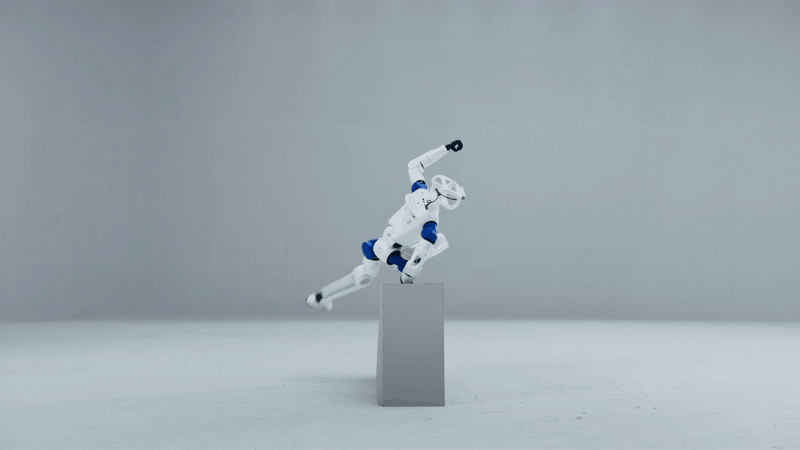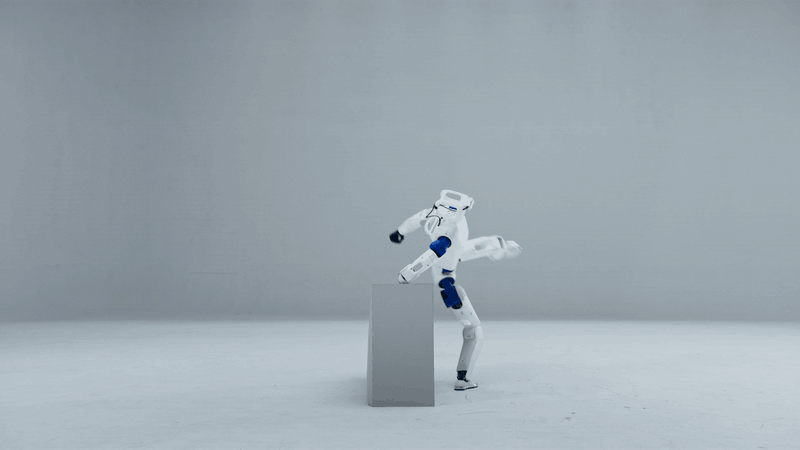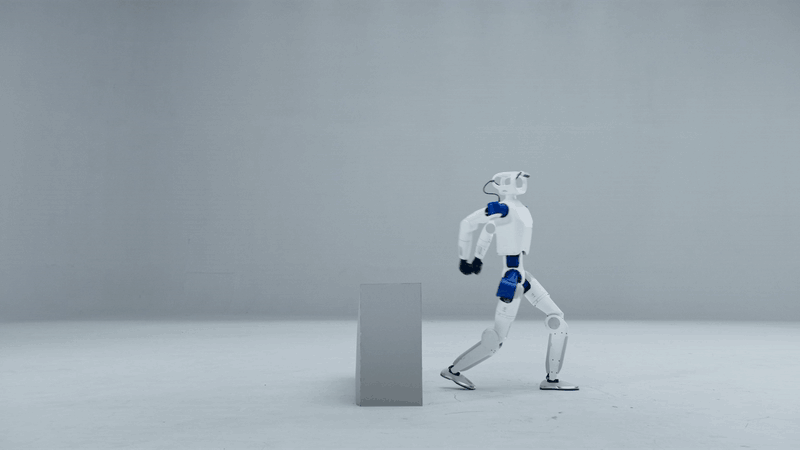
RP1, photographed in the real world.
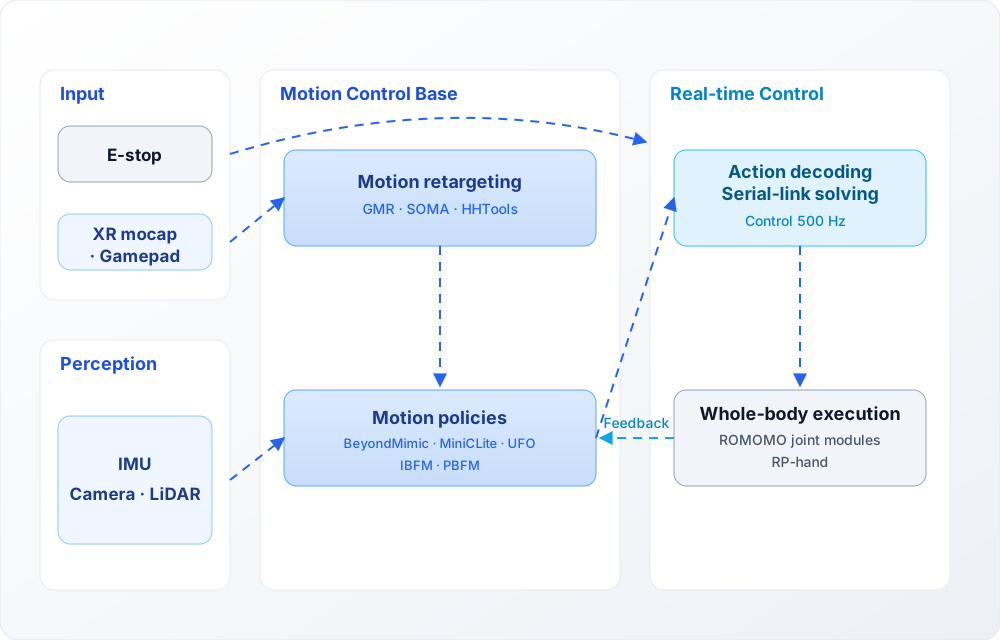
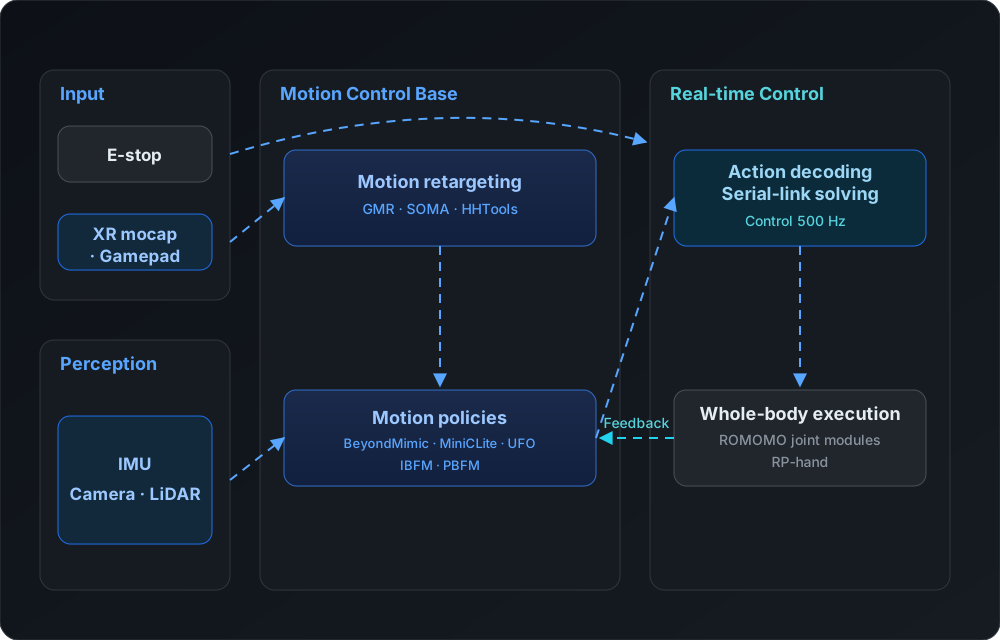
No black boxes, nothing withheld — full control handed back to the developer
Release contents, supported configurations and setup instructions are maintained in each repository.
Contributions belong in the relevant sub-repository. This overview repository does not accept pull requests; please open issues and pull requests in the project you are working on.
| Repository | Description |
|---|---|
| rp1_hardware | Mechanical source files, electronics, testing and assembly SOPs. |
| ROMOMO | Joint modules, firmware and host tools. |
| RP-hand | Dexterous hand wiring, CAN-FD communication and SDK integration. |
| RP1_TEST | RP1 full-machine testing. |
| robot_supplychain | Component selection, inspection, quality gates and acceptance. |
| roboparty_joystick | RoboParty controller and app. |
See the description repository's current release for supported robot configurations.
Supported configurations include 24, 28, 30 and 42 DoF variants.
| Repository | Description |
|---|---|
| roboparty_deploy | Runtime SDK for IMU, motor, dexhand, inference and camera modules. |
| RP1_description | URDF, MJCF, 3D assets and robot configurations. |
| roboparty_train | Locomotion, motion imitation and behavior foundation models. |
| RP1_firmware | Linux BSP, USB-CAN bridge, low-level SDK and packages. |
Coming soon.
| Project | Description |
|---|---|
| AMP | Learns motion priors from reference motions through adversarial training, supporting natural-looking locomotion and control. |
| BeyondMimic | Tracks reference motions to reproduce expressive whole-body movements, including dance and motion-imitation sequences. |
| MimicLite | Focuses on reference-motion tracking, translating target movements into coordinated whole-body robot actions. |
| UFO | Explores a shared behavior foundation for learning and controlling a range of humanoid movements. |
| PBFM | Connects environmental perception with a behavior foundation model to study movement in relation to the surrounding scene. |
| IBFM | Focuses on whole-body interaction with the environment, exploring coordinated movements for contact-rich tasks. |
| INTACT-JEPA | Learns an intent-to-action mapping with JEPA, translating visual goals into control actions without online search. |
Meet the community, share your work, and connect with RoboParty.

RoboParty
Open hardware. Open intelligence. Shared possibility.
GPL-3.0 · © RoboParty · Back to top
See each sub-repository for its applicable license.
61,665 followers · starred Oct 2026
English / 简体中文
From mechanical design and electronics to firmware, control and learning.
Built to be understood. Open to be built upon.
RP1 is RoboParty's fully open-source humanoid platform: a shared foundation for building, understanding and extending a real robot.
The platform brings mechanical and electrical design, joint modules, firmware, robot models, deployment and learning into one connected development stack. Explore a single subsystem, reproduce a build, or develop your own control and learning workflows.
| Hardware you can inspect | Software you can extend | Intelligence you can explore |
|---|---|---|
| Mechanical CAD, schematics, PCB layouts, Gerber files, BOM and assembly documentation. | Linux BSP, communication, device interfaces, robot descriptions and deployment modules. | Locomotion training, motion imitation, tracking and behavior-model projects. |
RP1, photographed in the real world.
No black boxes, nothing withheld — full control handed back to the developer
Release contents, supported configurations and setup instructions are maintained in each repository.
Contributions belong in the relevant sub-repository. This overview repository does not accept pull requests; please open issues and pull requests in the project you are working on.
| Repository | Description |
|---|---|
| rp1_hardware | Mechanical source files, electronics, testing and assembly SOPs. |
| ROMOMO | Joint modules, firmware and host tools. |
| RP-hand | Dexterous hand wiring, CAN-FD communication and SDK integration. |
| RP1_TEST | RP1 full-machine testing. |
| robot_supplychain | Component selection, inspection, quality gates and acceptance. |
| roboparty_joystick | RoboParty controller and app. |
See the description repository's current release for supported robot configurations.
Supported configurations include 24, 28, 30 and 42 DoF variants.
| Repository | Description |
|---|---|
| roboparty_deploy | Runtime SDK for IMU, motor, dexhand, inference and camera modules. |
| RP1_description | URDF, MJCF, 3D assets and robot configurations. |
| roboparty_train | Locomotion, motion imitation and behavior foundation models. |
| RP1_firmware | Linux BSP, USB-CAN bridge, low-level SDK and packages. |
Coming soon.
| Project | Description |
|---|---|
| AMP | Learns motion priors from reference motions through adversarial training, supporting natural-looking locomotion and control. |
| BeyondMimic | Tracks reference motions to reproduce expressive whole-body movements, including dance and motion-imitation sequences. |
| MimicLite | Focuses on reference-motion tracking, translating target movements into coordinated whole-body robot actions. |
| UFO | Explores a shared behavior foundation for learning and controlling a range of humanoid movements. |
| PBFM | Connects environmental perception with a behavior foundation model to study movement in relation to the surrounding scene. |
| IBFM | Focuses on whole-body interaction with the environment, exploring coordinated movements for contact-rich tasks. |
| INTACT-JEPA | Learns an intent-to-action mapping with JEPA, translating visual goals into control actions without online search. |
Meet the community, share your work, and connect with RoboParty.
RoboParty
Open hardware. Open intelligence. Shared possibility.
GPL-3.0 · © RoboParty · Back to top
See each sub-repository for its applicable license.
61,665 followers · starred Oct 2026



