
HOI-Retarget: Contact-Centric Retargeting for Human-Object Interaction
See the codeREADME
HOI-Retarget
Contact-Centric Retargeting for Human-Object Interaction
Jihwan Shin · Adrià López Escoriza · Junzhe He · Matthias Heyrman · Marco Hutter
Robotic Systems Lab, ETH Zürich
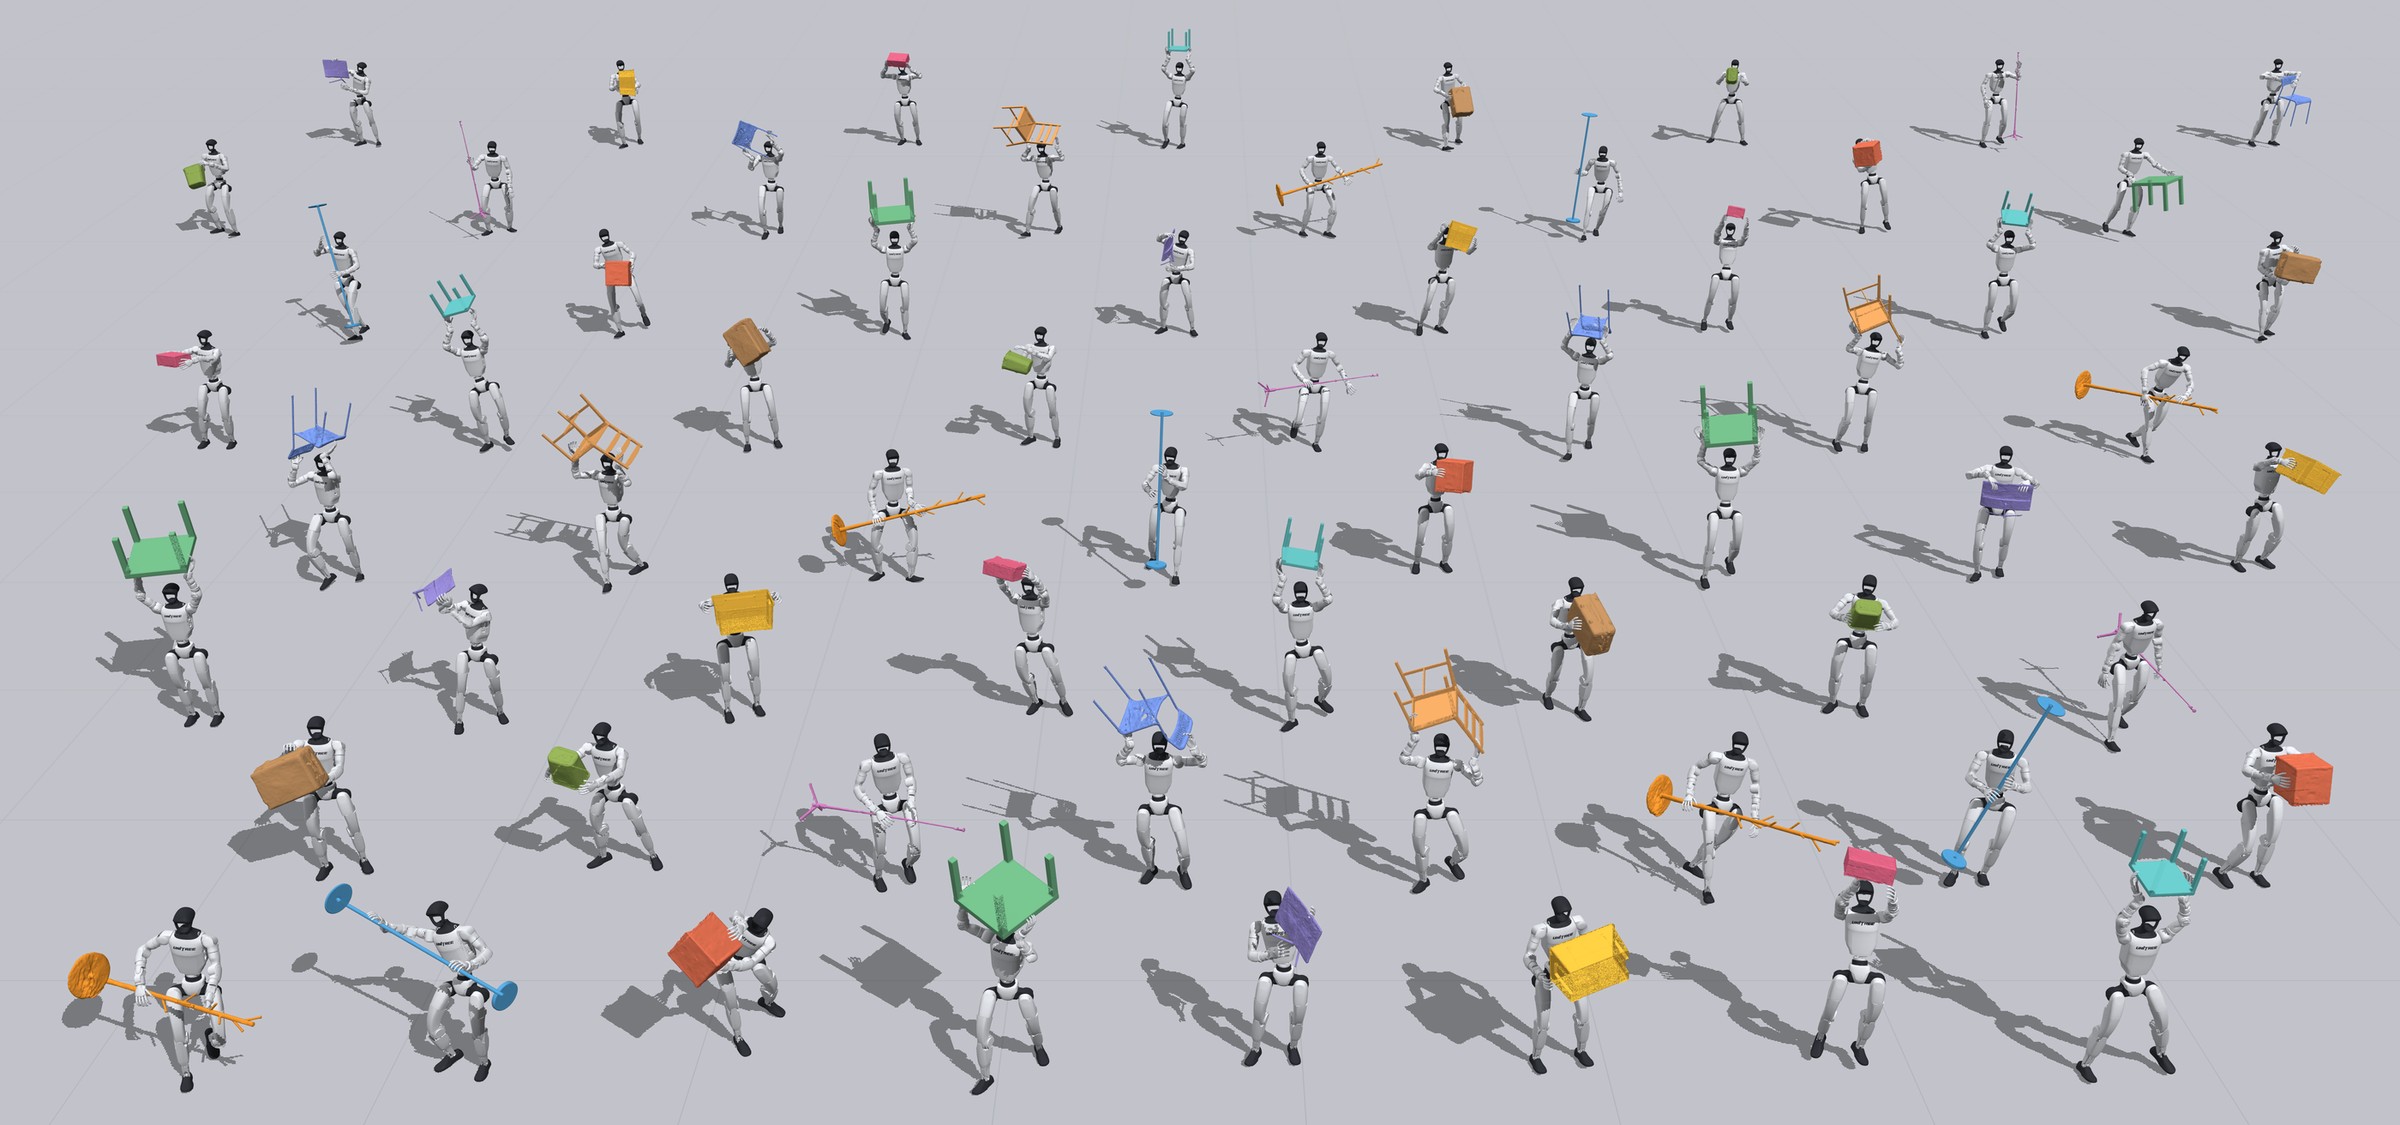
HOI-Retarget turns a human interaction clip — SMPL-X motion, object pose trajectory, per-body contact labels — into a humanoid trajectory that reproduces the interaction, not just the pose. Every labelled contact is a target in the object frame, recovered by a windowed trajectory optimization, so the robot grasps the same place on the object that the human did, at any object scale.
Method
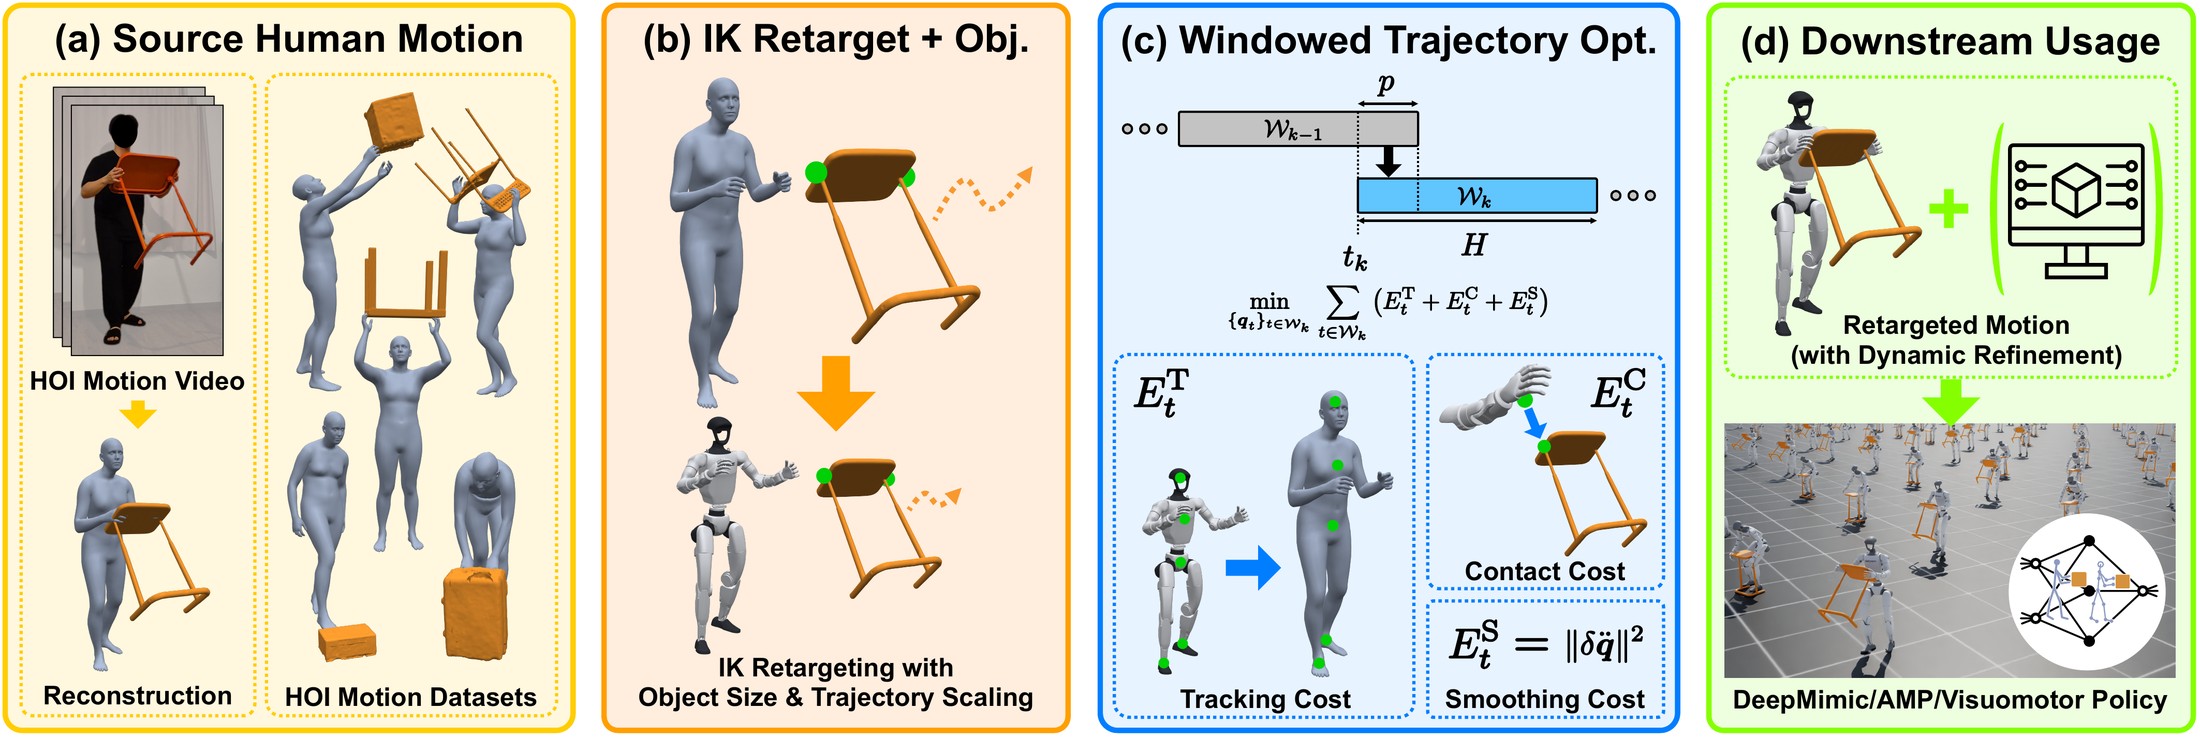
(a) A captured or video-reconstructed clip supplies human motion, an object trajectory and contact labels. (b) IK retargeting maps the human onto the robot; the object mesh and trajectory scale by the robot-to-human height ratio, carrying the contact targets with them. (c) A windowed trajectory optimization recovers those contacts under the robot's kinematic limits. (d) The result drives downstream policies.
| Paper | Module | What it does |
|---|---|---|
| Sec. III-A | hoi_retarget/retargeting/ | IK onto the robot, object mesh and trajectory rescaling, contact targets built in the object frame |
| Sec. III-B | hoi_retarget/optimization/ | Overlapping short-horizon NLPs over the configuration trajectory q: tracking + contact + smoothness, under joint position and velocity limits. The object pose is a fixed parameter, never a decision variable |
| Sec. III-C | hoi_retarget/contact/ | Viser editor: one draggable point per contact segment, then re-solve from the corrected targets. Never edits the source |
The IK backend is a fork of GMR in
hoi_retarget/gmr/ (MIT).
Installation
conda create -n hoi-retarget python=3.10 -y
conda activate hoi-retarget
conda install -c conda-forge pinocchio casadi parallel -y
pip install -e .
Details, EGL rendering and the HOI_RETARGET_* path overrides: docs/INSTALL.md.
SMPL-X body models and source motions are licensed downloads and are not shipped. Get them
first — docs/DATA.md, or docs/INTERACT.md for the
four InterAct datasets.
Quickstart
# one clip
hoi-retarget --input_file data/InterMimic/OMOMO_new/sub10_whitechair_049.pt \
             --out_dir outputs/sub10_whitechair_049

# an OMOMO folder (each clip's object is read from its file name)
hoi-retarget --src_folder data/InterMimic/OMOMO_new --tgt_folder outputs/omomo

# the OMOMO corpus, in parallel, resumable
mkdir -p outputs && find -L data/InterMimic/OMOMO_new -name '*.pt' > outputs/clips.txt
hoi_retarget/tools/batch_retarget.sh outputs/clips.txt outputs/omomo
For other sources, run one clip at a time with --object_model_path.
Every run writes kinematic_window.pkl (IK stage) and, in the default --mode contact,
the deliverable contact_window.pkl. --mode kinematic stops after the IK stage.
--robot unitree_h2 switches embodiment; --object_scale sets the object size (default 0.83 on
the G1, 1.0 on the H2), e.g. for a size-augmented variant of the same interaction. All options:
hoi-retarget --help.
Look at the result
hoi-retarget-view outputs/sub10_whitechair_049/contact_window.pkl   # Viser, any angle
hoi-retarget-render --input_dir outputs/sub10_whitechair_049        # MuJoCo mp4
hoi-retarget-render-batch --input_dir outputs/omomo                 # a corpus, in parallel
hoi-retarget-render-source --clip sub10_whitechair_049              # the SMPL-X source (OMOMO)
render-batch sizes its worker pool for the GPU; lower --workers if RAM is tight.
hoi-retarget-check-robot validates a robot description before you retarget onto it.
Edit contacts by hand (Sec. III-C)
hoi-retarget-edit-contacts data/InterMimic/OMOMO_new/sub10_whitechair_049.pt
hoi-retarget-edit-contacts <clip>.pt --robot unitree_h2        # the other embodiment
One draggable point per contact segment. Move a point that penetrates or floats, then re-solve from the corrected targets. The source data is never modified.
--robot picks the contact links, the marker meshes and the object scale (G1 0.83,
H2 1.0, or --object_scale), all read from the robot's own files; Go re-solves at the
size the preview shows. The editor serves on 127.0.0.1 on a free port; --host 0.0.0.0
exposes it on your network, or forward the port over SSH.
Repository layout
hoi_retarget/
├── retargeting/     Sec. III-A — IK retargeting, object scaling, contact targets
├── optimization/    Sec. III-B — the windowed NLP (Pinocchio + CasADi/IPOPT)
├── contact/         Sec. III-C — contact refinement and the Viser editor
├── datasets/        source readers: InterMimic/OMOMO, CARI4D
├── rendering/       MuJoCo and Viser views, and the paper's render styles
├── gmr/             vendored GMR fork (MIT) — the IK backend
├── tools/           viewing, rendering, asset checks, batch driver
├── config.py        every weight and window parameter, with the published defaults
└── cli.py           the `hoi-retarget` entry point
assets/
├── robots/{g1,h2}/  Unitree descriptions (BSD-3, Unitree)
└── objects/         13 object meshes (MIT, via InterMimic)
Licence
BSD 3-Clause, Copyright (c) 2026, ETH Zurich.
hoi_retarget/gmr/ is MIT, from GMR; see
THIRD_PARTY_NOTICES.md for the redistributed assets.
Citation
@article{shin2026hoiretarget,
  title   = {HOI-Retarget: Contact-Centric Retargeting for Human-Object Interaction},
  author  = {Shin, Jihwan and L\'opez Escoriza, Adri\`a and He, Junzhe and
             Heyrman, Matthias and Hutter, Marco},
  journal = {arXiv preprint arXiv:2609.34674},
  year    = {2026},
  url     = {https://arxiv.org/abs/2609.34674}
}
If you use the object meshes or the source motions, cite OMOMO and InterMimic
too — see CITATION.cff.
Similar repos


Languages
Python
99.6%
HOI-Retarget: Contact-Centric Retargeting for Human-Object Interaction
See the codeREADME
HOI-Retarget
Contact-Centric Retargeting for Human-Object Interaction
Jihwan Shin · Adrià López Escoriza · Junzhe He · Matthias Heyrman · Marco Hutter
Robotic Systems Lab, ETH Zürich
HOI-Retarget turns a human interaction clip — SMPL-X motion, object pose trajectory, per-body contact labels — into a humanoid trajectory that reproduces the interaction, not just the pose. Every labelled contact is a target in the object frame, recovered by a windowed trajectory optimization, so the robot grasps the same place on the object that the human did, at any object scale.
Method
(a) A captured or video-reconstructed clip supplies human motion, an object trajectory and contact labels. (b) IK retargeting maps the human onto the robot; the object mesh and trajectory scale by the robot-to-human height ratio, carrying the contact targets with them. (c) A windowed trajectory optimization recovers those contacts under the robot's kinematic limits. (d) The result drives downstream policies.
| Paper | Module | What it does |
|---|---|---|
| Sec. III-A | hoi_retarget/retargeting/ | IK onto the robot, object mesh and trajectory rescaling, contact targets built in the object frame |
| Sec. III-B | hoi_retarget/optimization/ | Overlapping short-horizon NLPs over the configuration trajectory q: tracking + contact + smoothness, under joint position and velocity limits. The object pose is a fixed parameter, never a decision variable |
| Sec. III-C | hoi_retarget/contact/ | Viser editor: one draggable point per contact segment, then re-solve from the corrected targets. Never edits the source |
The IK backend is a fork of GMR in
hoi_retarget/gmr/ (MIT).
Installation
conda create -n hoi-retarget python=3.10 -y
conda activate hoi-retarget
conda install -c conda-forge pinocchio casadi parallel -y
pip install -e .
Details, EGL rendering and the HOI_RETARGET_* path overrides: docs/INSTALL.md.
SMPL-X body models and source motions are licensed downloads and are not shipped. Get them
first — docs/DATA.md, or docs/INTERACT.md for the
four InterAct datasets.
Quickstart
# one clip
hoi-retarget --input_file data/InterMimic/OMOMO_new/sub10_whitechair_049.pt \
             --out_dir outputs/sub10_whitechair_049

# an OMOMO folder (each clip's object is read from its file name)
hoi-retarget --src_folder data/InterMimic/OMOMO_new --tgt_folder outputs/omomo

# the OMOMO corpus, in parallel, resumable
mkdir -p outputs && find -L data/InterMimic/OMOMO_new -name '*.pt' > outputs/clips.txt
hoi_retarget/tools/batch_retarget.sh outputs/clips.txt outputs/omomo
For other sources, run one clip at a time with --object_model_path.
Every run writes kinematic_window.pkl (IK stage) and, in the default --mode contact,
the deliverable contact_window.pkl. --mode kinematic stops after the IK stage.
--robot unitree_h2 switches embodiment; --object_scale sets the object size (default 0.83 on
the G1, 1.0 on the H2), e.g. for a size-augmented variant of the same interaction. All options:
hoi-retarget --help.
Look at the result
hoi-retarget-view outputs/sub10_whitechair_049/contact_window.pkl   # Viser, any angle
hoi-retarget-render --input_dir outputs/sub10_whitechair_049        # MuJoCo mp4
hoi-retarget-render-batch --input_dir outputs/omomo                 # a corpus, in parallel
hoi-retarget-render-source --clip sub10_whitechair_049              # the SMPL-X source (OMOMO)
render-batch sizes its worker pool for the GPU; lower --workers if RAM is tight.
hoi-retarget-check-robot validates a robot description before you retarget onto it.
Edit contacts by hand (Sec. III-C)
hoi-retarget-edit-contacts data/InterMimic/OMOMO_new/sub10_whitechair_049.pt
hoi-retarget-edit-contacts <clip>.pt --robot unitree_h2        # the other embodiment
One draggable point per contact segment. Move a point that penetrates or floats, then re-solve from the corrected targets. The source data is never modified.
--robot picks the contact links, the marker meshes and the object scale (G1 0.83,
H2 1.0, or --object_scale), all read from the robot's own files; Go re-solves at the
size the preview shows. The editor serves on 127.0.0.1 on a free port; --host 0.0.0.0
exposes it on your network, or forward the port over SSH.
Repository layout
hoi_retarget/
├── retargeting/     Sec. III-A — IK retargeting, object scaling, contact targets
├── optimization/    Sec. III-B — the windowed NLP (Pinocchio + CasADi/IPOPT)
├── contact/         Sec. III-C — contact refinement and the Viser editor
├── datasets/        source readers: InterMimic/OMOMO, CARI4D
├── rendering/       MuJoCo and Viser views, and the paper's render styles
├── gmr/             vendored GMR fork (MIT) — the IK backend
├── tools/           viewing, rendering, asset checks, batch driver
├── config.py        every weight and window parameter, with the published defaults
└── cli.py           the `hoi-retarget` entry point
assets/
├── robots/{g1,h2}/  Unitree descriptions (BSD-3, Unitree)
└── objects/         13 object meshes (MIT, via InterMimic)
Licence
BSD 3-Clause, Copyright (c) 2026, ETH Zurich.
hoi_retarget/gmr/ is MIT, from GMR; see
THIRD_PARTY_NOTICES.md for the redistributed assets.
Citation
@article{shin2026hoiretarget,
  title   = {HOI-Retarget: Contact-Centric Retargeting for Human-Object Interaction},
  author  = {Shin, Jihwan and L\'opez Escoriza, Adri\`a and He, Junzhe and
             Heyrman, Matthias and Hutter, Marco},
  journal = {arXiv preprint arXiv:2609.34674},
  year    = {2026},
  url     = {https://arxiv.org/abs/2609.34674}
}
If you use the object meshes or the source motions, cite OMOMO and InterMimic
too — see CITATION.cff.
Similar repos
Languages
Python
99.6%