Embodied-Reasoner Embodied‑Navigator Embodied‑Memory
Python
257
76 commits
updated Oct 9, 2026

A series of open-source embodied-AI projects from ZJU-OmniAI — models that observe, reason, and act in the physical world.
Long-horizon task planning · environment-state reasoning · self-reflection · real-robot deployment




Embodied-Reasoner · Embodied-Navigator · EmbodiedMemory-Bench · Quick start · Citation
[!NOTE] This repository was renamed. It was previously
zwq2018/embodied_reasoner— the URL cited in the Embodied-Reasoner paper — and is nowZJU-OmniAI/Embodied-Omni, hosting the whole Embodied-Omni series. GitHub redirects the old URL here automatically, so existing links, clones, and remotes keep working. Looking for Embodied-Reasoner? It now lives inembodied_reasoner/.
Automatically updated all-time counts from Hugging Face. Cross-repository totals are refreshed every 5 minutes. Badges are cached and may lag behind the source. Refresh details.
| Project | Resource | Type | All-time downloads |
|---|---|---|---|
| Embodied-Reasoner | embodied_reasoner | Dataset |  |
| Embodied-Navigator | Embodied-Navigator-7B-GRPO | Model |  |
| EmbodiedMemory-Bench | EmbodiedMemoryBench | Dataset |  |


Embodied intelligence needs more than a strong VLM: an agent has to keep interacting with the world, remember what it has already seen, reason about where things are, and correct itself when a plan fails. Embodied-Omni collects our work on exactly this loop, and releases it end to end — data engines, training recipes, evaluation harnesses, and real-robot deployment code.
Three projects live here today, covering complementary parts of physical-world competence:
| Project | One-line summary | Embodiment & benchmark | Status |
|---|---|---|---|
| 🔍 Embodied-Reasoner | An embodied reasoning model for the physical world: it plans long-horizon tasks, reasons about the state of its environment, and reflects on its own actions while it keeps interacting. | Indoor agent in AI2-THOR (107 scenes) | ACL 2026 Main ✅ |
| 🧭 Embodied-Navigator | A vision-language navigation framework: the VLM points at a pixel instead of regressing coordinates, thinks only at critical nodes, compresses history into anchors, and is aligned with Two-Level GRPO. | Habitat R2R-CE / RxR-CE + Unitree Go2 quadruped | |
| 🧠 EmbodiedMemory-Bench | A benchmark for embodied memory: agents must retain observations, update world state, learn from interaction outcomes, and transfer experience across later tasks. | AI2-THOR & ProcTHOR · 2,554 episodes | |
Common design principles across the series:
Synergizing Visual Search, Reasoning, and Action for Embodied Interactive Tasks
ACL 2026 Main Conference
📄 Paper · 📑 arXiv · 🌐 Project page · 🤗 Dataset · 📺 Talk (Bilibili) · 📂 Code
https://github.com/user-attachments/assets/da9c5b42-ab8e-4101-9ec0-a226590d23fc
Embodied-Reasoner explores a room, reflects on what it has already checked, and finds hidden objects to complete a long-horizon instruction.
Embodied-Reasoner is an embodied reasoning model: given an instruction such as "Locate the apple and put it in the microwave", it sees only ego-centric images and alternates between thinking and acting for dozens of turns until the physical goal is reached.
Training is a three-stage recipe — imitation learning → self-exploration tuning → self-correction (reflection) tuning — producing the Embodied-Interactor / Explorer / Reasoner checkpoints in 7B and 2B sizes.
➡️ Full README, benchmarks, training, evaluation, and data engine →
Point, Think, Memorize, and Align for Efficient Embodied Navigation
"Point in pixels. Move in 3D. Think when needed. Remember what matters."
https://github.com/user-attachments/assets/695b83b4-7672-4d77-ac5b-dc455258e036
Method overview and zero-shot deployment on a Unitree Go2 quadruped.
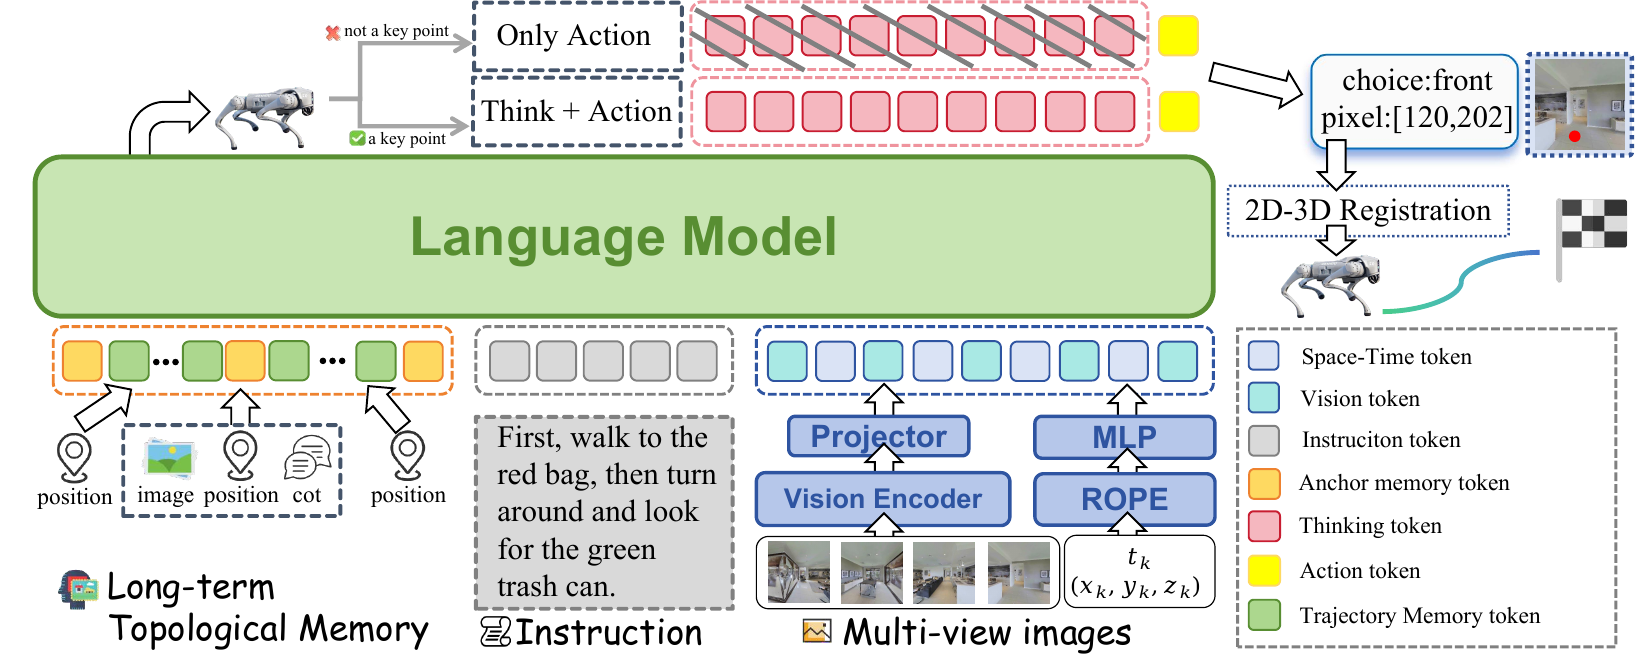
Instead of asking a VLM to regress 3D coordinates or emit long strings of atomic actions, Embodied-Navigator lets it act as a visual pointer: pick one of four RGB views, point at a pixel, and let a SLAM controller execute the projected 3D waypoint.
| Component | Mechanism | Effect |
|---|---|---|
| Point | Predict a 2D pixel waypoint, then project it to 3D through depth | Reuses the VLM's pretrained visual grounding; leaves metric geometry to deterministic modules |
| Think | Trigger chain-of-thought only at critical topological nodes | Concentrates computation on crossroads, doorways, and target-relevant decisions |
| Memorize | Anchor-Trajectory Memory: keep critical states as anchors, compress the rest into Space-Time Indicators | Preserves long-horizon topology without storing every frame |
| Align | Two-Level GRPO combining local action and global trajectory advantages | Closes the credit-assignment gap between final success and individual decisions |
The policy is trained on R2R-CE and RxR-CE in Habitat and deployed zero-shot on a Unitree Go2 quadruped — no robot-specific fine-tuning.
Six representative zero-shot trials, drawn from the 100-episode real-world evaluation (click to play on GitHub, or watch them inline on the project page):
| Scene | Video | Notes |
|---|---|---|
| Cross-scenario | cross-scenario.mp4 | Long-horizon episode with an indoor→outdoor transition |
| Indoor hall | hall.mp4 | Long-corridor navigation with sparse reasoning |
| Meeting room | meeting-room.mp4 | Cluttered indoor navigation |
| Outdoors | outdoors.mp4 | Open outdoor scene |
| Laboratory test area | playground.mp4 | Indoor lab navigation |
| Outdoors (failure case) | outdoors-failed.mp4 | Target leaves all camera views; the policy stops prematurely |
➡️ Full README, benchmarks, training, evaluation, and robot serving →
Benchmarking Embodied Memory for Long-Horizon Embodied Tasks
📄 Paper · 🌐 Project page · 🤗 Dataset · 📂 Code
https://github.com/user-attachments/assets/13a1025d-c691-4b15-892d-ecc5544418c4
EmbodiedMemory-Bench evaluates whether an agent can retain, update, and use embodied memory across long-horizon interactive tasks.
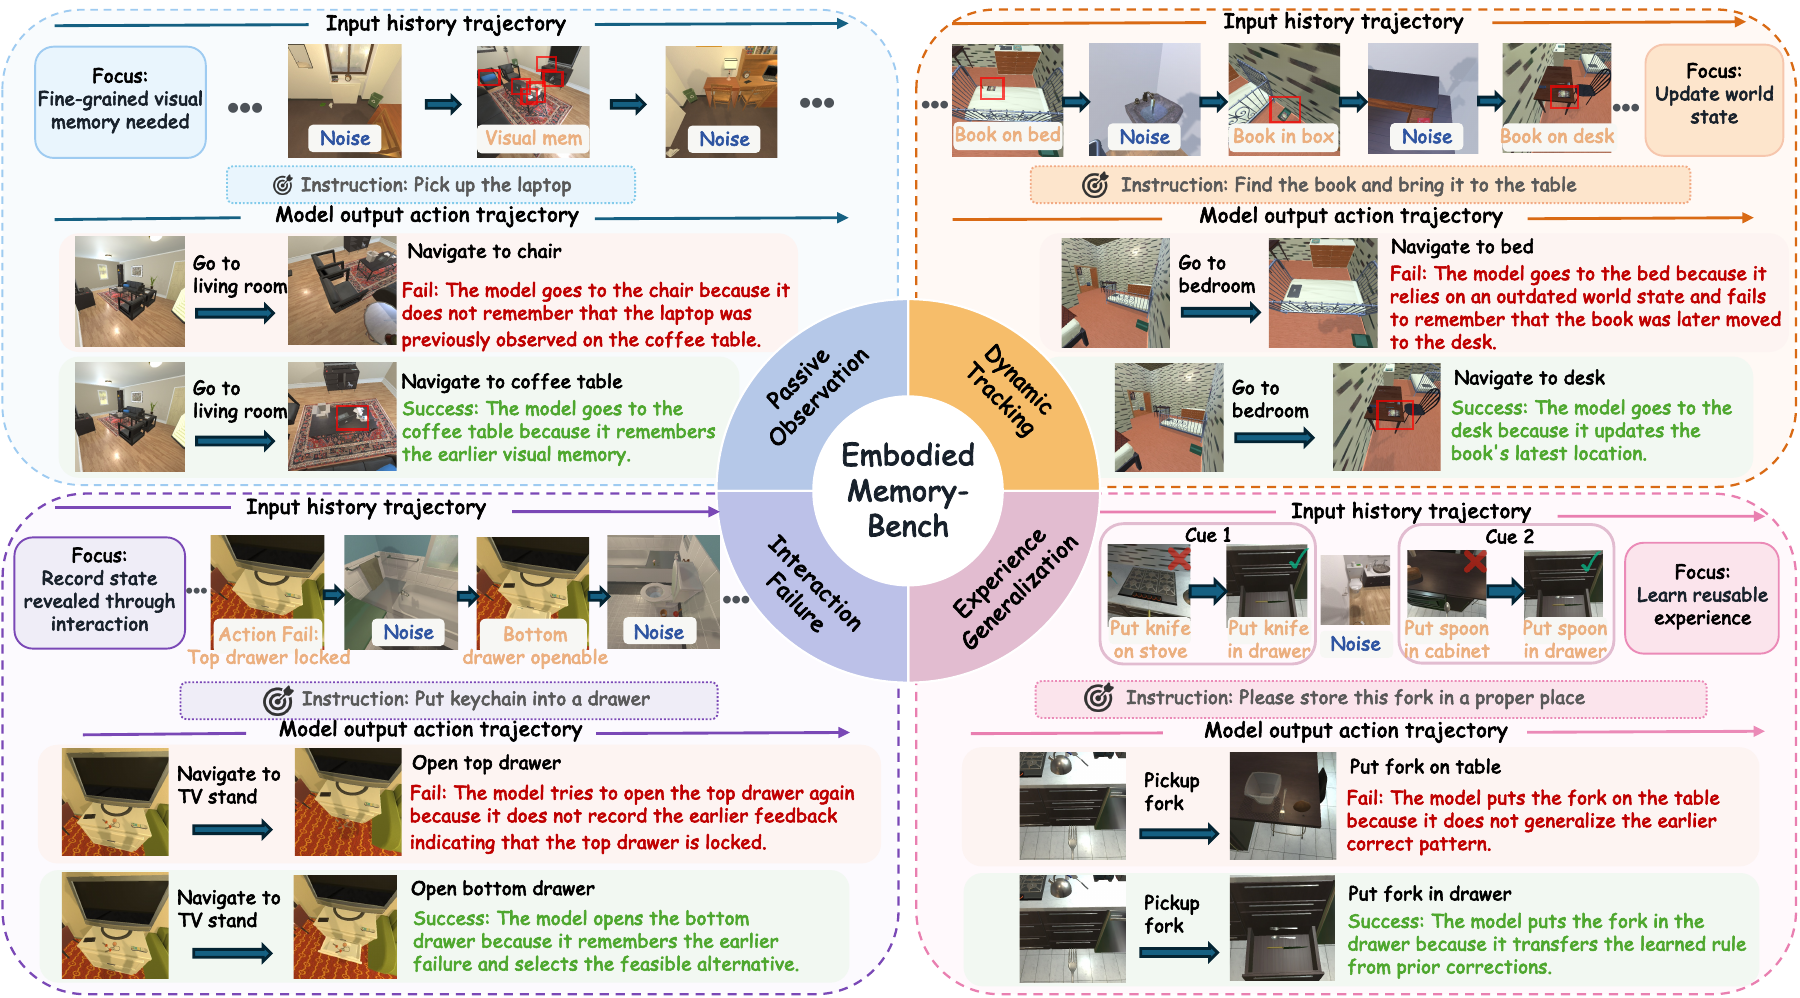
EmbodiedMemory-Bench evaluates whether an agent can build, maintain, and use memory while interacting with a changing environment. It contains 2,554 executable episodes across four challenges: passive observation, dynamic tracking, interaction-derived state, and experience generalization.
The release includes a simulator-grounded construction pipeline, a transparent Embodied-Memorizer baseline, and an evaluation runner. The complete benchmark data is available on Hugging Face, while this repository contains the public implementation and reproducible interfaces.
➡️ Full README, benchmark format, memory system, evaluation, and data access →
Each project is self-contained in its own top-level directory, with its own README, requirements, and scripts.
Embodied-Omni/
├── embodied_reasoner/        # ACL 2026 · interactive embodied reasoning
│   ├── data_engine/          # Task & O1-style trajectory synthesis (AI2-THOR)
│   ├── data/                 # Dataset format and samples
│   ├── finetune/             # Three-stage training configs
│   ├── evaluate/             # 809-case interactive evaluation framework
│   ├── inference/            # Model inference
│   └── scripts/              # train.sh / eval.sh
├── embodied_navigator/       # Vision-language navigation
│   ├── src/agent/            # Policy, selective reasoning, Anchor-Trajectory Memory
│   ├── src/model/            # Navigation-adapted Qwen2.5-VL
│   ├── src/train/            # SFT + Two-Level GRPO
│   ├── src/env/ src/eval/    # Continuous-navigation env, NE/OS/SR/SPL/nDTW metrics
│   ├── src/server/           # FastAPI + ROS2 service for the Unitree Go2
│   ├── config/ scripts/      # Experiment configs and launch scripts
│   └── docs/                 # Project homepage, figures, deployment videos
├── embodied_memory/          # Embodied memory benchmark and memory system
│   ├── src/                  # EMem-Bench and Embodied-Memorizer packages
│   ├── assets/               # Paper and project figures
│   └── pyproject.toml        # Package and optional dependencies
└── assets/                   # Shared repository assets
git clone https://github.com/ZJU-OmniAI/Embodied-Omni.git
cd Embodied-Omni

# Interactive embodied reasoning (AI2-THOR)
cd embodied_reasoner && cat README.md

# Vision-language navigation (Habitat / real robot)
cd ../embodied_navigator && cat README.md

# Embodied memory benchmark (AI2-THOR / ProcTHOR)
cd ../embodied_memory && cat README.md
Each project ships its own environment setup; do not mix them in one conda environment. Paths inside a project README are relative to that project directory.
zwq2018/embodied_reasoner becomes ZJU-OmniAI/Embodied-Omni, the home of the whole series.If you find this series useful, please cite the corresponding paper.
@inproceedings{zhang-etal-2026-embodied,
    title = "Embodied-Reasoner: Synergizing Visual Search, Reasoning, and Action for Embodied Interactive Tasks",
    author = "Zhang, Wenqi  and
      Wang, Mengna  and
      Liu, Gangao  and
      Xu, Huixin  and
      Jiang, Yiwei  and
      Shen, Yongliang  and
      Hou, Guiyang  and
      Zheng, Zhe  and
      Zhang, Hang  and
      Li, Xin  and
      Liu, Jiajun  and
      Lu, Weiming  and
      Li, Peng  and
      Zhuang, Yueting",
    booktitle = "Proceedings of the 64th Annual Meeting of the {A}ssociation for {C}omputational {L}inguistics (Volume 1: Long Papers)",
    month = jul,
    year = "2026",
    address = "San Diego, California, United States",
    publisher = "Association for Computational Linguistics",
    url = "https://aclanthology.org/2026.acl-long.1910/",
    doi = "10.18653/v1/2026.acl-long.1910",
    pages = "41178--41207",
    ISBN = "979-8-89176-390-6"
}
@misc{feng2026embodiednavigator,
  title     = {Embodied-Navigator: Point, Think, Memorize, and Align
               for Efficient Embodied Navigation},
  author    = {Feng, Hongyan and Chen, Sunlai and Liu, Xuanyu and Pan, Miao and
               Xie, Yangfan and Cui, Yuxiang and Zhou, Zhongxiang and
               Xiong, Rong and Zhang, Wenqi and Yin, Jianwei and
               Zhuang, Yueting and Zhang, Xuhong},
  year      = {2026},
  eprint    = {2608.17512},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url       = {https://arxiv.org/abs/2608.17512}
}
@misc{embodiedmemorybench,
  title         = {EmbodiedMemory-Bench: Benchmarking Embodied Memory for Long-Horizon Embodied Tasks},
  author        = {Liang, Lizhou and Zhong, Xinyu and Pan, Miao and Zhou, Xiaohe and Liu, Xuanyu and Li, Qinfeng and Li, Peng and Chen, Jintao and Zhang, Xuhong and Zhang, Wenqi},
  year          = {2026},
  eprint        = {2609.28236},
  archivePrefix = {arXiv},
  primaryClass  = {cs.CV},
  url           = {https://arxiv.org/abs/2609.28236}
}
Embodied-Reasoner builds on AI2-THOR for simulation and LLaMA-Factory for training. Embodied-Navigator builds on Habitat-Lab and Qwen2.5-VL. EmbodiedMemory-Bench builds on AI2-THOR and ProcTHOR for simulator-grounded benchmark construction. Thanks to all of these projects.
Questions, issues, and collaborations are welcome — open an issue or email us:
Released under the Mulan PSL v2 license.
⭐ If this work helps your research, please consider starring the repository.
464 followers · starred Mar 2025
9 followers · starred Apr 2025
84 followers · starred May 2025
Embodied-Reasoner Embodied‑Navigator Embodied‑Memory
Python
257
76 commits
updated Oct 9, 2026
A series of open-source embodied-AI projects from ZJU-OmniAI — models that observe, reason, and act in the physical world.
Long-horizon task planning · environment-state reasoning · self-reflection · real-robot deployment
Embodied-Reasoner · Embodied-Navigator · EmbodiedMemory-Bench · Quick start · Citation
[!NOTE] This repository was renamed. It was previously
zwq2018/embodied_reasoner— the URL cited in the Embodied-Reasoner paper — and is nowZJU-OmniAI/Embodied-Omni, hosting the whole Embodied-Omni series. GitHub redirects the old URL here automatically, so existing links, clones, and remotes keep working. Looking for Embodied-Reasoner? It now lives inembodied_reasoner/.
Automatically updated all-time counts from Hugging Face. Cross-repository totals are refreshed every 5 minutes. Badges are cached and may lag behind the source. Refresh details.
| Project | Resource | Type | All-time downloads |
|---|---|---|---|
| Embodied-Reasoner | embodied_reasoner | Dataset | |
| Embodied-Navigator | Embodied-Navigator-7B-GRPO | Model | |
| EmbodiedMemory-Bench | EmbodiedMemoryBench | Dataset | |
Embodied intelligence needs more than a strong VLM: an agent has to keep interacting with the world, remember what it has already seen, reason about where things are, and correct itself when a plan fails. Embodied-Omni collects our work on exactly this loop, and releases it end to end — data engines, training recipes, evaluation harnesses, and real-robot deployment code.
Three projects live here today, covering complementary parts of physical-world competence:
| Project | One-line summary | Embodiment & benchmark | Status |
|---|---|---|---|
| 🔍 Embodied-Reasoner | An embodied reasoning model for the physical world: it plans long-horizon tasks, reasons about the state of its environment, and reflects on its own actions while it keeps interacting. | Indoor agent in AI2-THOR (107 scenes) | ACL 2026 Main ✅ |
| 🧭 Embodied-Navigator | A vision-language navigation framework: the VLM points at a pixel instead of regressing coordinates, thinks only at critical nodes, compresses history into anchors, and is aligned with Two-Level GRPO. | Habitat R2R-CE / RxR-CE + Unitree Go2 quadruped | |
| 🧠 EmbodiedMemory-Bench | A benchmark for embodied memory: agents must retain observations, update world state, learn from interaction outcomes, and transfer experience across later tasks. | AI2-THOR & ProcTHOR · 2,554 episodes | |
Common design principles across the series:
Synergizing Visual Search, Reasoning, and Action for Embodied Interactive Tasks
ACL 2026 Main Conference
📄 Paper · 📑 arXiv · 🌐 Project page · 🤗 Dataset · 📺 Talk (Bilibili) · 📂 Code
https://github.com/user-attachments/assets/da9c5b42-ab8e-4101-9ec0-a226590d23fc
Embodied-Reasoner explores a room, reflects on what it has already checked, and finds hidden objects to complete a long-horizon instruction.
Embodied-Reasoner is an embodied reasoning model: given an instruction such as "Locate the apple and put it in the microwave", it sees only ego-centric images and alternates between thinking and acting for dozens of turns until the physical goal is reached.
Training is a three-stage recipe — imitation learning → self-exploration tuning → self-correction (reflection) tuning — producing the Embodied-Interactor / Explorer / Reasoner checkpoints in 7B and 2B sizes.
➡️ Full README, benchmarks, training, evaluation, and data engine →
Point, Think, Memorize, and Align for Efficient Embodied Navigation
"Point in pixels. Move in 3D. Think when needed. Remember what matters."
https://github.com/user-attachments/assets/695b83b4-7672-4d77-ac5b-dc455258e036
Method overview and zero-shot deployment on a Unitree Go2 quadruped.
Instead of asking a VLM to regress 3D coordinates or emit long strings of atomic actions, Embodied-Navigator lets it act as a visual pointer: pick one of four RGB views, point at a pixel, and let a SLAM controller execute the projected 3D waypoint.
| Component | Mechanism | Effect |
|---|---|---|
| Point | Predict a 2D pixel waypoint, then project it to 3D through depth | Reuses the VLM's pretrained visual grounding; leaves metric geometry to deterministic modules |
| Think | Trigger chain-of-thought only at critical topological nodes | Concentrates computation on crossroads, doorways, and target-relevant decisions |
| Memorize | Anchor-Trajectory Memory: keep critical states as anchors, compress the rest into Space-Time Indicators | Preserves long-horizon topology without storing every frame |
| Align | Two-Level GRPO combining local action and global trajectory advantages | Closes the credit-assignment gap between final success and individual decisions |
The policy is trained on R2R-CE and RxR-CE in Habitat and deployed zero-shot on a Unitree Go2 quadruped — no robot-specific fine-tuning.
Six representative zero-shot trials, drawn from the 100-episode real-world evaluation (click to play on GitHub, or watch them inline on the project page):
| Scene | Video | Notes |
|---|---|---|
| Cross-scenario | cross-scenario.mp4 | Long-horizon episode with an indoor→outdoor transition |
| Indoor hall | hall.mp4 | Long-corridor navigation with sparse reasoning |
| Meeting room | meeting-room.mp4 | Cluttered indoor navigation |
| Outdoors | outdoors.mp4 | Open outdoor scene |
| Laboratory test area | playground.mp4 | Indoor lab navigation |
| Outdoors (failure case) | outdoors-failed.mp4 | Target leaves all camera views; the policy stops prematurely |
➡️ Full README, benchmarks, training, evaluation, and robot serving →
Benchmarking Embodied Memory for Long-Horizon Embodied Tasks
📄 Paper · 🌐 Project page · 🤗 Dataset · 📂 Code
https://github.com/user-attachments/assets/13a1025d-c691-4b15-892d-ecc5544418c4
EmbodiedMemory-Bench evaluates whether an agent can retain, update, and use embodied memory across long-horizon interactive tasks.
EmbodiedMemory-Bench evaluates whether an agent can build, maintain, and use memory while interacting with a changing environment. It contains 2,554 executable episodes across four challenges: passive observation, dynamic tracking, interaction-derived state, and experience generalization.
The release includes a simulator-grounded construction pipeline, a transparent Embodied-Memorizer baseline, and an evaluation runner. The complete benchmark data is available on Hugging Face, while this repository contains the public implementation and reproducible interfaces.
➡️ Full README, benchmark format, memory system, evaluation, and data access →
Each project is self-contained in its own top-level directory, with its own README, requirements, and scripts.
Embodied-Omni/
├── embodied_reasoner/        # ACL 2026 · interactive embodied reasoning
│   ├── data_engine/          # Task & O1-style trajectory synthesis (AI2-THOR)
│   ├── data/                 # Dataset format and samples
│   ├── finetune/             # Three-stage training configs
│   ├── evaluate/             # 809-case interactive evaluation framework
│   ├── inference/            # Model inference
│   └── scripts/              # train.sh / eval.sh
├── embodied_navigator/       # Vision-language navigation
│   ├── src/agent/            # Policy, selective reasoning, Anchor-Trajectory Memory
│   ├── src/model/            # Navigation-adapted Qwen2.5-VL
│   ├── src/train/            # SFT + Two-Level GRPO
│   ├── src/env/ src/eval/    # Continuous-navigation env, NE/OS/SR/SPL/nDTW metrics
│   ├── src/server/           # FastAPI + ROS2 service for the Unitree Go2
│   ├── config/ scripts/      # Experiment configs and launch scripts
│   └── docs/                 # Project homepage, figures, deployment videos
├── embodied_memory/          # Embodied memory benchmark and memory system
│   ├── src/                  # EMem-Bench and Embodied-Memorizer packages
│   ├── assets/               # Paper and project figures
│   └── pyproject.toml        # Package and optional dependencies
└── assets/                   # Shared repository assets
git clone https://github.com/ZJU-OmniAI/Embodied-Omni.git
cd Embodied-Omni

# Interactive embodied reasoning (AI2-THOR)
cd embodied_reasoner && cat README.md

# Vision-language navigation (Habitat / real robot)
cd ../embodied_navigator && cat README.md

# Embodied memory benchmark (AI2-THOR / ProcTHOR)
cd ../embodied_memory && cat README.md
Each project ships its own environment setup; do not mix them in one conda environment. Paths inside a project README are relative to that project directory.
zwq2018/embodied_reasoner becomes ZJU-OmniAI/Embodied-Omni, the home of the whole series.If you find this series useful, please cite the corresponding paper.
@inproceedings{zhang-etal-2026-embodied,
    title = "Embodied-Reasoner: Synergizing Visual Search, Reasoning, and Action for Embodied Interactive Tasks",
    author = "Zhang, Wenqi  and
      Wang, Mengna  and
      Liu, Gangao  and
      Xu, Huixin  and
      Jiang, Yiwei  and
      Shen, Yongliang  and
      Hou, Guiyang  and
      Zheng, Zhe  and
      Zhang, Hang  and
      Li, Xin  and
      Liu, Jiajun  and
      Lu, Weiming  and
      Li, Peng  and
      Zhuang, Yueting",
    booktitle = "Proceedings of the 64th Annual Meeting of the {A}ssociation for {C}omputational {L}inguistics (Volume 1: Long Papers)",
    month = jul,
    year = "2026",
    address = "San Diego, California, United States",
    publisher = "Association for Computational Linguistics",
    url = "https://aclanthology.org/2026.acl-long.1910/",
    doi = "10.18653/v1/2026.acl-long.1910",
    pages = "41178--41207",
    ISBN = "979-8-89176-390-6"
}
@misc{feng2026embodiednavigator,
  title     = {Embodied-Navigator: Point, Think, Memorize, and Align
               for Efficient Embodied Navigation},
  author    = {Feng, Hongyan and Chen, Sunlai and Liu, Xuanyu and Pan, Miao and
               Xie, Yangfan and Cui, Yuxiang and Zhou, Zhongxiang and
               Xiong, Rong and Zhang, Wenqi and Yin, Jianwei and
               Zhuang, Yueting and Zhang, Xuhong},
  year      = {2026},
  eprint    = {2608.17512},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url       = {https://arxiv.org/abs/2608.17512}
}
@misc{embodiedmemorybench,
  title         = {EmbodiedMemory-Bench: Benchmarking Embodied Memory for Long-Horizon Embodied Tasks},
  author        = {Liang, Lizhou and Zhong, Xinyu and Pan, Miao and Zhou, Xiaohe and Liu, Xuanyu and Li, Qinfeng and Li, Peng and Chen, Jintao and Zhang, Xuhong and Zhang, Wenqi},
  year          = {2026},
  eprint        = {2609.28236},
  archivePrefix = {arXiv},
  primaryClass  = {cs.CV},
  url           = {https://arxiv.org/abs/2609.28236}
}
Embodied-Reasoner builds on AI2-THOR for simulation and LLaMA-Factory for training. Embodied-Navigator builds on Habitat-Lab and Qwen2.5-VL. EmbodiedMemory-Bench builds on AI2-THOR and ProcTHOR for simulator-grounded benchmark construction. Thanks to all of these projects.
Questions, issues, and collaborations are welcome — open an issue or email us:
Released under the Mulan PSL v2 license.
⭐ If this work helps your research, please consider starring the repository.
464 followers · starred Mar 2025
9 followers · starred Apr 2025
84 followers · starred May 2025





