
README
Open6DOR: Open6DOR: Benchmarking Open-instruction 6-DoF Object Rearrangement and A VLM-based Approach
IROS 2024


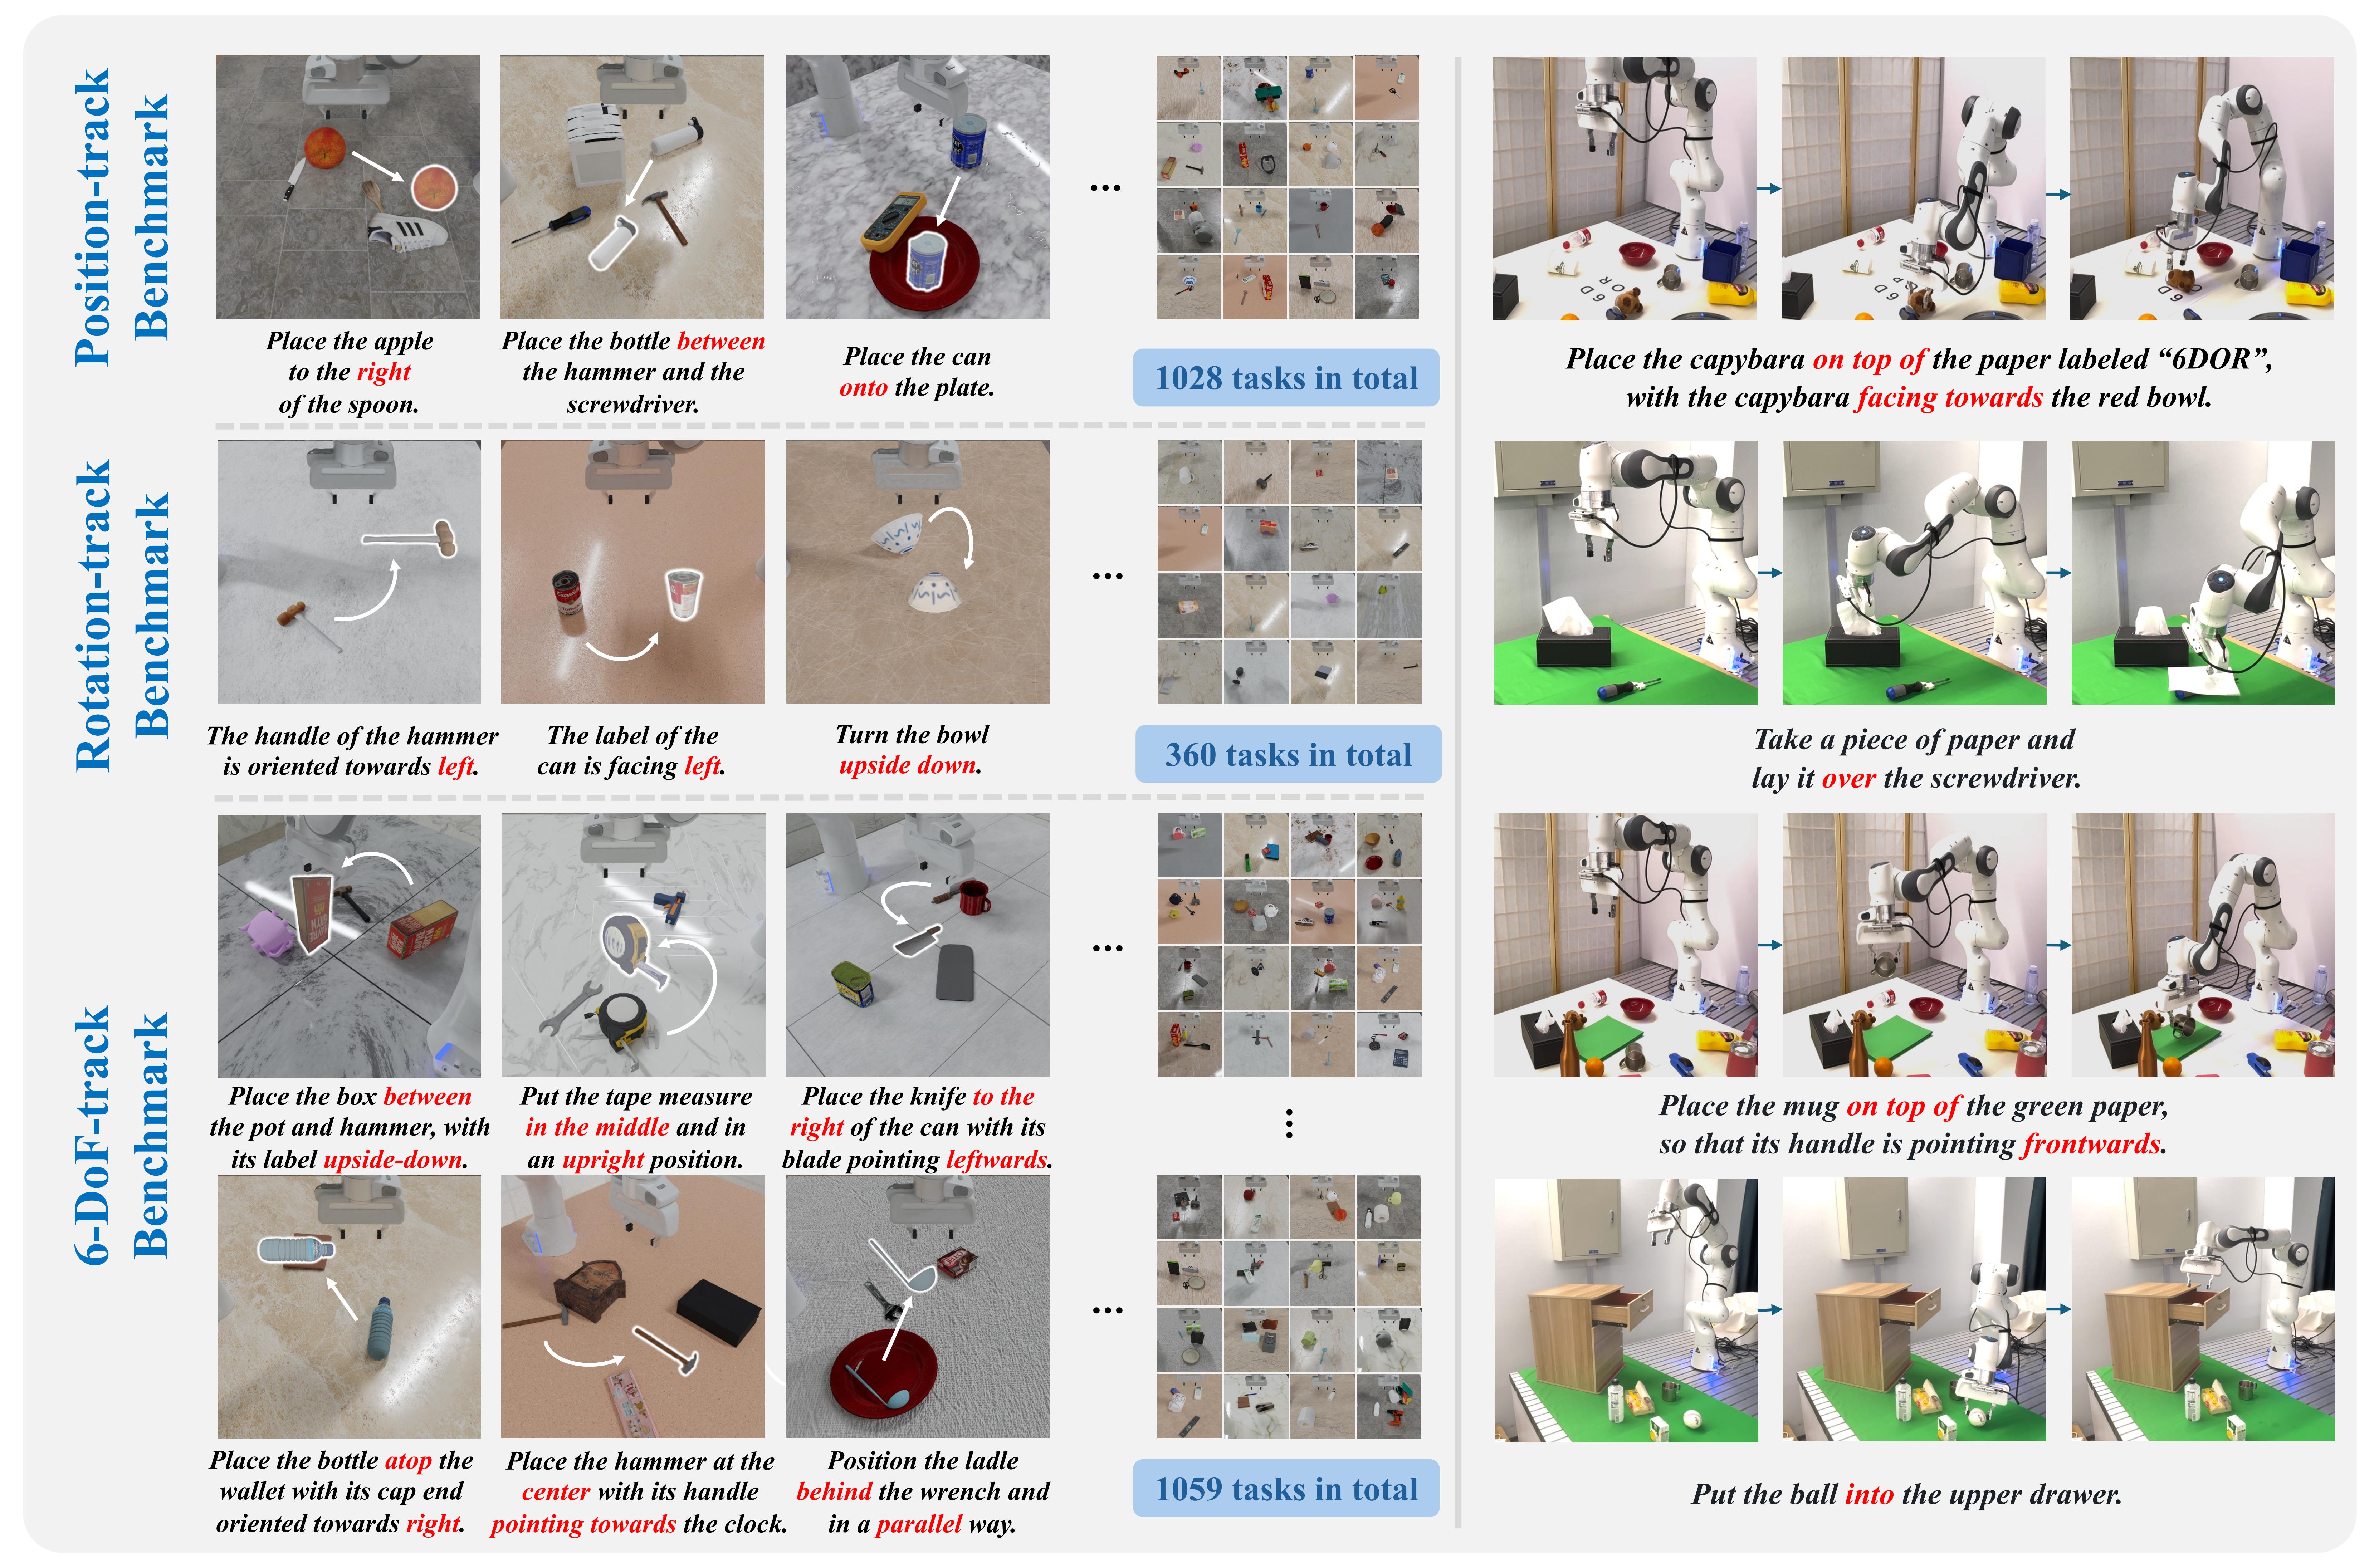 This is the official repository of Open6DOR: Benchmarking Open-instruction 6-DoF Object Rearrangement and A VLM-based Approach. In this work, we propel the pioneer construction of the benchmark and approach for table-top Open-instruction 6-DoF Object Rearrangement (Open6DOR). Specifically, we collect a synthetic dataset of 200+ objects and carefully design 2400+ Open6DOR tasks. These tasks are divided into the Position-track, Rotation-track, and 6-DoF-track for evaluating different embodied agents in predicting the positions and rotations of target objects. Besides, we also propose a VLM-based approach for Open6DOR, named Open6DOR-GPT, which empowers GPT-4V with 3D-awareness and simulation-assistance while exploiting its strengths in generalizability and instruction-following for this task. We compare the existing embodied agents with our Open6DOR-GPT on the proposed Open6DOR benchmark and find that Open6DOR-GPT achieves the state-of-the-art performance. We further show the impressive performance of Open6DOR-GPT in diverse real-world experiments.
We plan to release the final version of the benchmark, along with our refined method, in early September, and we recommend waiting until then to download the dataset.
News
- We update method with gpt-4o api. See Method folder.
Benchmark
The Open6DOR Benchmark is specifically designed for table-top Open6DOR tasks within a simulation environment. Our dataset encompasses 200+ high-quality objects, forming diverse scenes and totaling 2400+ diverse tasks. All tasks are carefully configured and accompanied by detailed annotations. To ensure comprehensive evaluation, we provide three specialized tracks of benchmark: the Rotation-track Benchmark ($B_r$), the Position-track benchmark ($B_p$), and the 6-DoF-track Benchmark ($B_\text{6DoF}$). In this repository, we provide:
- A dataset of diverse objects
- 2400+ Open6DOR tasks with detailed annotations
- A set of evaluation metrics for each track of tasks
Installation
Environment Setup
We recommend using Linux system for better compatability with our modules (including Blender and Isaacgym).
# Clone the repository
git clone git@github.com:Selina2023/Open6DOR.git
cd Open6DOR
# Create an environment
conda create -n Open6DOR python=3.9
# Install dependencies
pip install -r requirements.txt
Dataset Downloads
Refer to the subsequent section for specific file locations.
- Download the object datasets and uncompress.
- Download the task datasets and uncompress. (The refined version will be released along with our paper)
Rendering Dependencies
- Download Blender 2.93.3 (Linux x64) and uncompress.
- Download the environment map asset and uncompress.
- Download the .blend file and uncompress.
- Install the Python packages (Numpy, etc.) into the Blender built-in Python environment.
cd Benchmark/renderer/blender-2.93.3-linux-x64/2.93/python/bin
./python3.9 -m ensurepip
./python3.9 -m pip install --upgrade pip --user
./python3.9 -m pip install numpy --user
File Structure
After downloading the datasets, organize the file structure as follows:
Benchmark
├── benchmark_catalogue
│   ├── annotation
│   │   └── ...
│   ├── category_dictionary.json
│   └── ...
├── dataset
│   ├── objects
│   │   ├── objaverse_rescale
│   │   └── ycb
│   └── tasks
│       ├── 6DoF_track
│       ├── position_track
│       └── rotation_track
├── evaluation
│   └── evaluator.py
├── renderer
│   ├── blender-2.93.3-linux-x64
│   ├── envmap_lib
│   │   ├── abandoned_factory_canteen_01_1k.hdr
│   │   └── ...
│   ├── texture
│   │   └── texture0.jpg
│   ├── material_lib_v2.blend
│   ├── modify_material.py
│   └── open6dor_renderer.py
├── task_examples
│   ├── 6DoF
│   ├── position
│   └── rotation
└── bench.py
Usage
Along with the dataset, we provide several functions to enable visualization and evaluation of the tasks:
- To load a task example, run the following command (you may change the image_mode to RENDER_IMAGE_BLENDER or others):
cd Benchmark
python bench.py load_task --task_path ./task_examples/6DoF/behind/Place_the_apple_behind_the_box_on_the_table.__upright/20240704-145831_no_interaction/task_config.json --image_mode GIVEN_IMAGE_ISAACGYM --output_path ./output/test
For personalized rendering, you may try arbitrary camera positions and background settings:
python bench.py load_task --task_path ./task_examples/rotation/None/mug_handle_left/20240717-075819_no_interaction/task_config.json --image_mode RENDER_IMAGE_BLENDER --cam_quaternion 0 0 0.0 1.0 --cam_translation 0.0 0.0 4 --background_material_id 44 --env_map_id 25
- To evaluate the task, run the following command( you need to fill the predicted pose into a json file):
python bench.py eval_task --task_id my_test --pred_pose path/to/pred_pose.json
- Besides evaluating the numerical results of the pose prediction directly, we provide another set of metrics where users are allowed to control the robot arm and interact with the simulation environment. Such evaluation is soely based on the final pose of the target object after execution. To do this, run the following command (currently not available):
python interaction.py
Method
 By incorporating 3D awareness and simulation assistance, we effectively tackle the Open6DOR task through a decomposed approach.
Specifically, Open6DOR-GPT takes the RGB-D image and instruction as input and outputs the corresponding robot motion trajectory. Firstly, the preprocessing module extracts the object names and masks. Then, the two modules simultaneously predict the position and rotation of the target object in a decoupled way. Finally, the planning module generates a trajectory for execution.
See README in Method folder.
Contact
For further details or questions, please feel free to contact us:
Similar repos


README
Open6DOR: Open6DOR: Benchmarking Open-instruction 6-DoF Object Rearrangement and A VLM-based Approach
IROS 2024
This is the official repository of Open6DOR: Benchmarking Open-instruction 6-DoF Object Rearrangement and A VLM-based Approach. In this work, we propel the pioneer construction of the benchmark and approach for table-top Open-instruction 6-DoF Object Rearrangement (Open6DOR). Specifically, we collect a synthetic dataset of 200+ objects and carefully design 2400+ Open6DOR tasks. These tasks are divided into the Position-track, Rotation-track, and 6-DoF-track for evaluating different embodied agents in predicting the positions and rotations of target objects. Besides, we also propose a VLM-based approach for Open6DOR, named Open6DOR-GPT, which empowers GPT-4V with 3D-awareness and simulation-assistance while exploiting its strengths in generalizability and instruction-following for this task. We compare the existing embodied agents with our Open6DOR-GPT on the proposed Open6DOR benchmark and find that Open6DOR-GPT achieves the state-of-the-art performance. We further show the impressive performance of Open6DOR-GPT in diverse real-world experiments.
We plan to release the final version of the benchmark, along with our refined method, in early September, and we recommend waiting until then to download the dataset.
News
- We update method with gpt-4o api. See Method folder.
Benchmark
The Open6DOR Benchmark is specifically designed for table-top Open6DOR tasks within a simulation environment. Our dataset encompasses 200+ high-quality objects, forming diverse scenes and totaling 2400+ diverse tasks. All tasks are carefully configured and accompanied by detailed annotations. To ensure comprehensive evaluation, we provide three specialized tracks of benchmark: the Rotation-track Benchmark ($B_r$), the Position-track benchmark ($B_p$), and the 6-DoF-track Benchmark ($B_\text{6DoF}$). In this repository, we provide:
- A dataset of diverse objects
- 2400+ Open6DOR tasks with detailed annotations
- A set of evaluation metrics for each track of tasks
Installation
Environment Setup
We recommend using Linux system for better compatability with our modules (including Blender and Isaacgym).
# Clone the repository
git clone git@github.com:Selina2023/Open6DOR.git
cd Open6DOR
# Create an environment
conda create -n Open6DOR python=3.9
# Install dependencies
pip install -r requirements.txt
Dataset Downloads
Refer to the subsequent section for specific file locations.
- Download the object datasets and uncompress.
- Download the task datasets and uncompress. (The refined version will be released along with our paper)
Rendering Dependencies
- Download Blender 2.93.3 (Linux x64) and uncompress.
- Download the environment map asset and uncompress.
- Download the .blend file and uncompress.
- Install the Python packages (Numpy, etc.) into the Blender built-in Python environment.
cd Benchmark/renderer/blender-2.93.3-linux-x64/2.93/python/bin
./python3.9 -m ensurepip
./python3.9 -m pip install --upgrade pip --user
./python3.9 -m pip install numpy --user
File Structure
After downloading the datasets, organize the file structure as follows:
Benchmark
├── benchmark_catalogue
│   ├── annotation
│   │   └── ...
│   ├── category_dictionary.json
│   └── ...
├── dataset
│   ├── objects
│   │   ├── objaverse_rescale
│   │   └── ycb
│   └── tasks
│       ├── 6DoF_track
│       ├── position_track
│       └── rotation_track
├── evaluation
│   └── evaluator.py
├── renderer
│   ├── blender-2.93.3-linux-x64
│   ├── envmap_lib
│   │   ├── abandoned_factory_canteen_01_1k.hdr
│   │   └── ...
│   ├── texture
│   │   └── texture0.jpg
│   ├── material_lib_v2.blend
│   ├── modify_material.py
│   └── open6dor_renderer.py
├── task_examples
│   ├── 6DoF
│   ├── position
│   └── rotation
└── bench.py
Usage
Along with the dataset, we provide several functions to enable visualization and evaluation of the tasks:
- To load a task example, run the following command (you may change the image_mode to RENDER_IMAGE_BLENDER or others):
cd Benchmark
python bench.py load_task --task_path ./task_examples/6DoF/behind/Place_the_apple_behind_the_box_on_the_table.__upright/20240704-145831_no_interaction/task_config.json --image_mode GIVEN_IMAGE_ISAACGYM --output_path ./output/test
For personalized rendering, you may try arbitrary camera positions and background settings:
python bench.py load_task --task_path ./task_examples/rotation/None/mug_handle_left/20240717-075819_no_interaction/task_config.json --image_mode RENDER_IMAGE_BLENDER --cam_quaternion 0 0 0.0 1.0 --cam_translation 0.0 0.0 4 --background_material_id 44 --env_map_id 25
- To evaluate the task, run the following command( you need to fill the predicted pose into a json file):
python bench.py eval_task --task_id my_test --pred_pose path/to/pred_pose.json
- Besides evaluating the numerical results of the pose prediction directly, we provide another set of metrics where users are allowed to control the robot arm and interact with the simulation environment. Such evaluation is soely based on the final pose of the target object after execution. To do this, run the following command (currently not available):
python interaction.py
Method
By incorporating 3D awareness and simulation assistance, we effectively tackle the Open6DOR task through a decomposed approach.
Specifically, Open6DOR-GPT takes the RGB-D image and instruction as input and outputs the corresponding robot motion trajectory. Firstly, the preprocessing module extracts the object names and masks. Then, the two modules simultaneously predict the position and rotation of the target object in a decoupled way. Finally, the planning module generates a trajectory for execution.
See README in Method folder.
Contact
For further details or questions, please feel free to contact us: