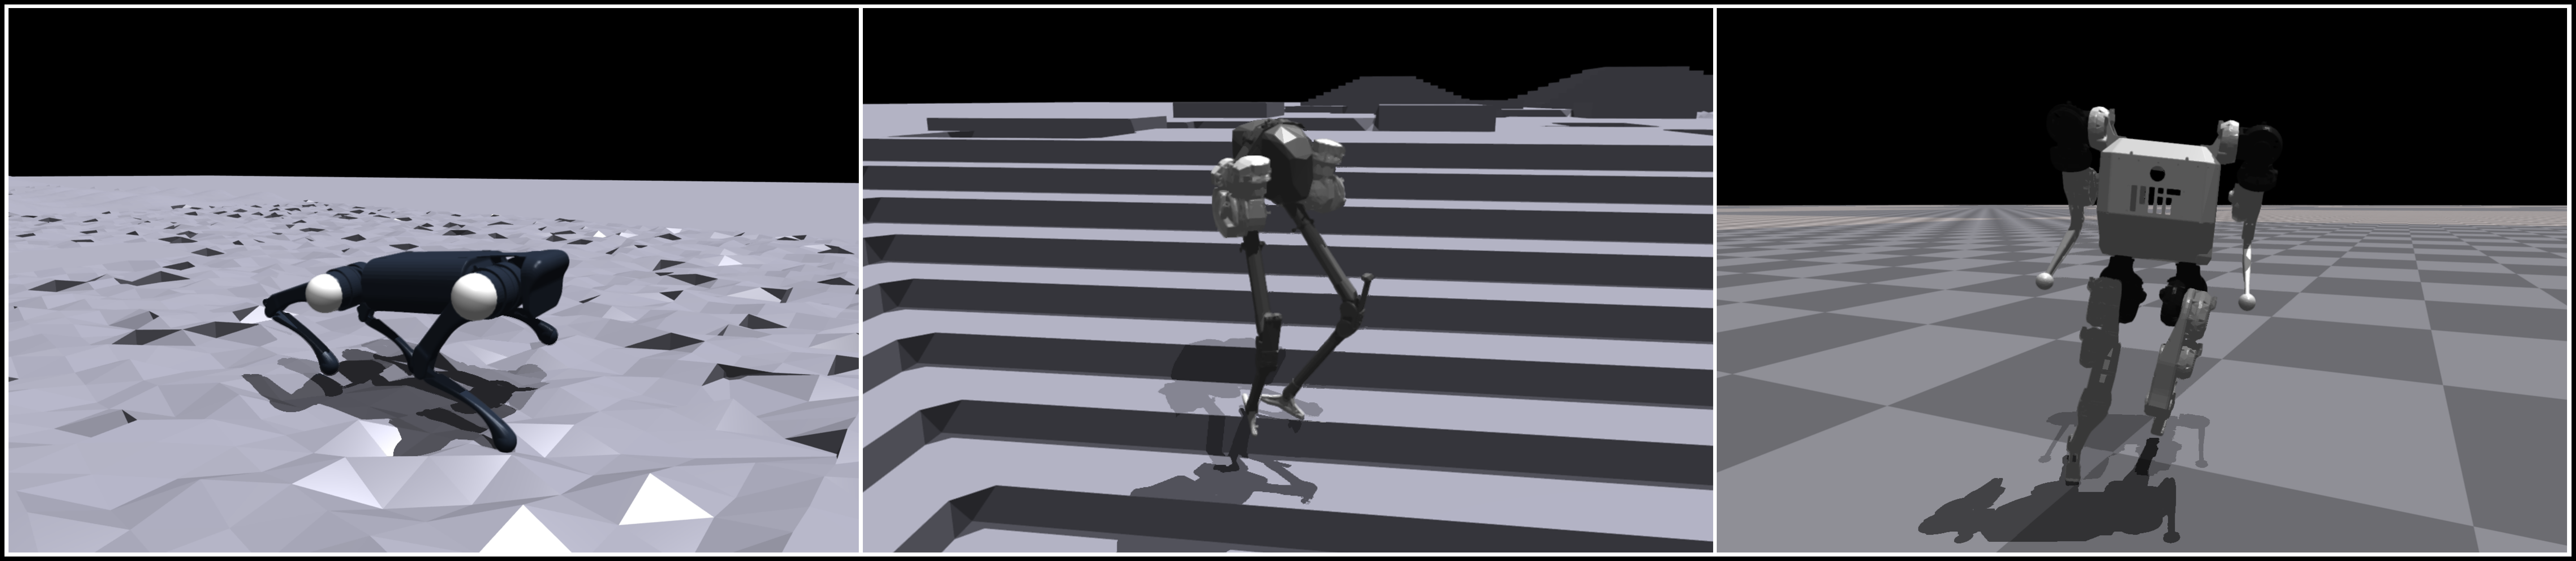
A SNN-based based policy applied to two reinforcement learning methods, history trajectory and imitation learning, respectively, and deployed on robots such as A1, MIT Humanoid, and Cassie.
This is the GitHub repo for the paper "Fully Spiking Neural Network for Legged Robots"
This repository consists of below directories (It is recommended that different virtual environments are prepared for each of them, as described in readme.md in the respective folders):
[legged_gym] https://github.com/leggedrobotics/legged_gym.git
If you have any question, please contact jxxxxxygoat@gmail.com



