[CoRL 2024] Learning to Walk from Three Minutes of Real-World Data with Semi-structured Dynamics Models
Python
52
10 commits
updated Oct 19, 2024
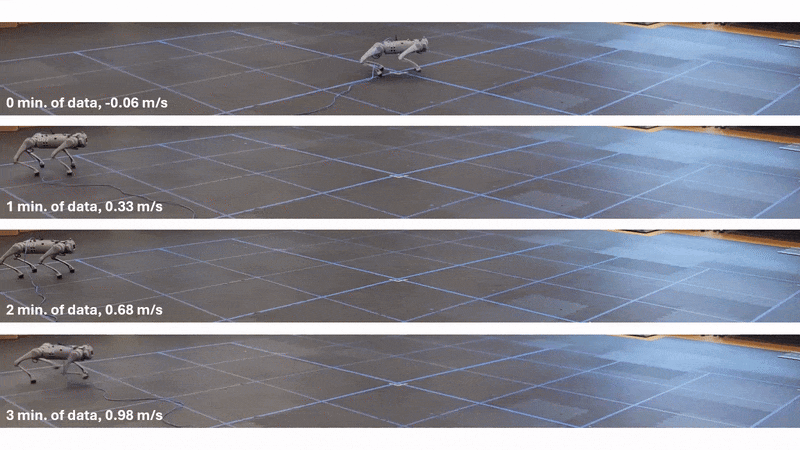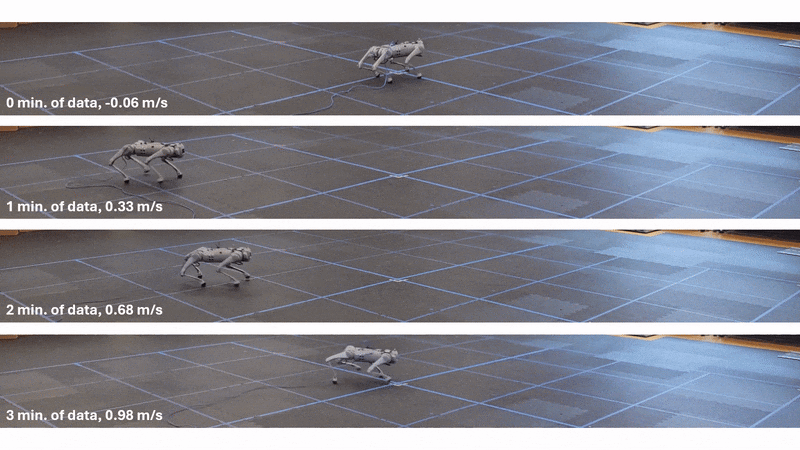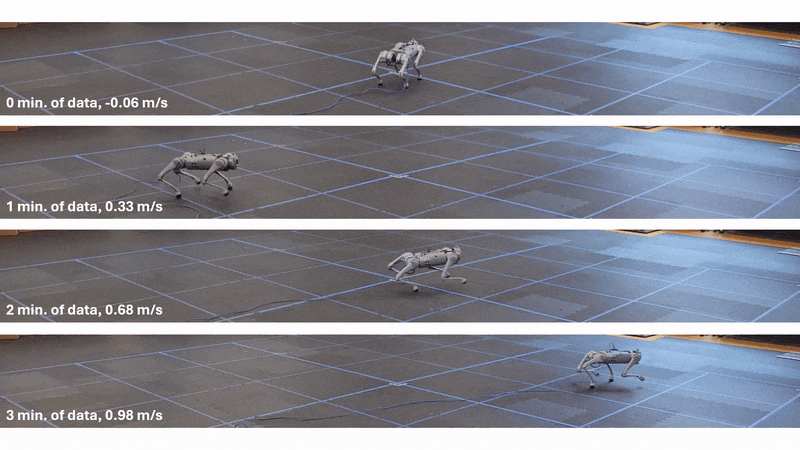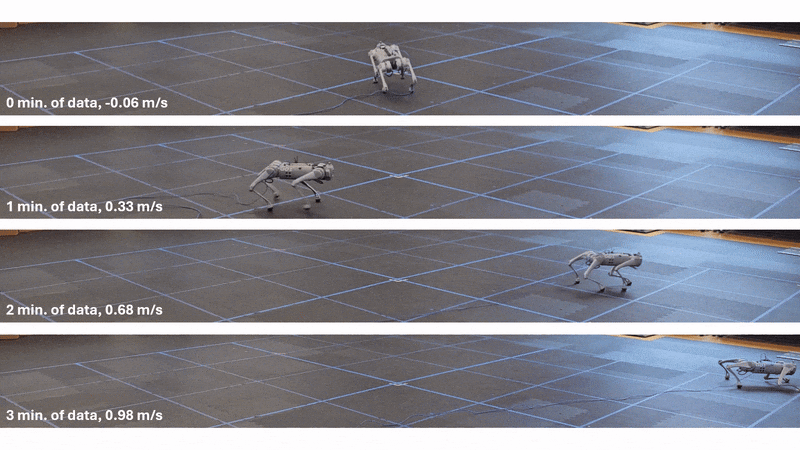
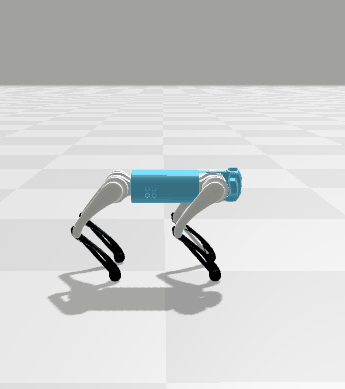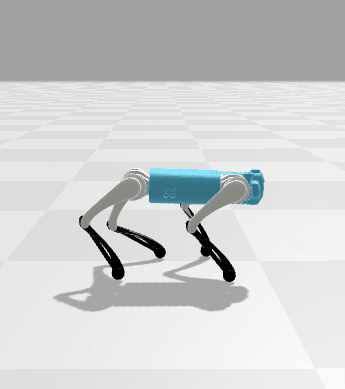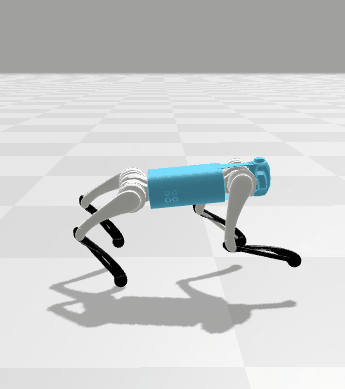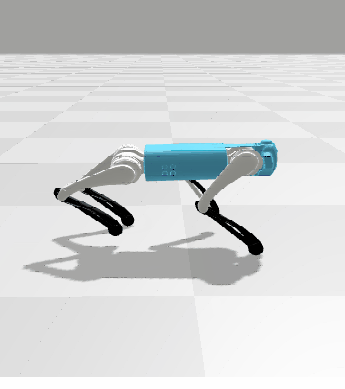
Code for our paper "Learning to Walk from Three Minutes of Real-World Data with Semi-structured Dynamics Models".
@inproceedings{levy2024learning,
  title={Learning to Walk from Three Minutes of Real-World Data with Semi-structured Dynamics Models},
  author={Levy, Jacob and Westenbroek, Tyler and Fridovich-Keil, David},
  booktitle={8th Annual Conference on Robot Learning},
  year={2024}
}
[CoRL 2024] Learning to Walk from Three Minutes of Real-World Data with Semi-structured Dynamics Models
Python
52
10 commits
updated Oct 19, 2024
Code for our paper "Learning to Walk from Three Minutes of Real-World Data with Semi-structured Dynamics Models".
@inproceedings{levy2024learning,
  title={Learning to Walk from Three Minutes of Real-World Data with Semi-structured Dynamics Models},
  author={Levy, Jacob and Westenbroek, Tyler and Fridovich-Keil, David},
  booktitle={8th Annual Conference on Robot Learning},
  year={2024}
}



