[CVPR 2025 Highlight] Truncated Diffusion Model for Real-Time End-to-End Autonomous Driving
See the code
Bencheng Liao1,2, Shaoyu Chen2,3, Haoran Yin3, Bo Jiang2, Cheng Wang1,2, Sixu Yan2, Xinbang Zhang3, Xiangyu Li3, Ying Zhang3, Qian Zhang3, Xinggang Wang2 📧
1 Institute of Artificial Intelligence, HUST, 2 School of EIC, HUST, 3 Horizon Robotics
(📧) corresponding author, [email protected]
Accepted to CVPR 2025 as Highlight!
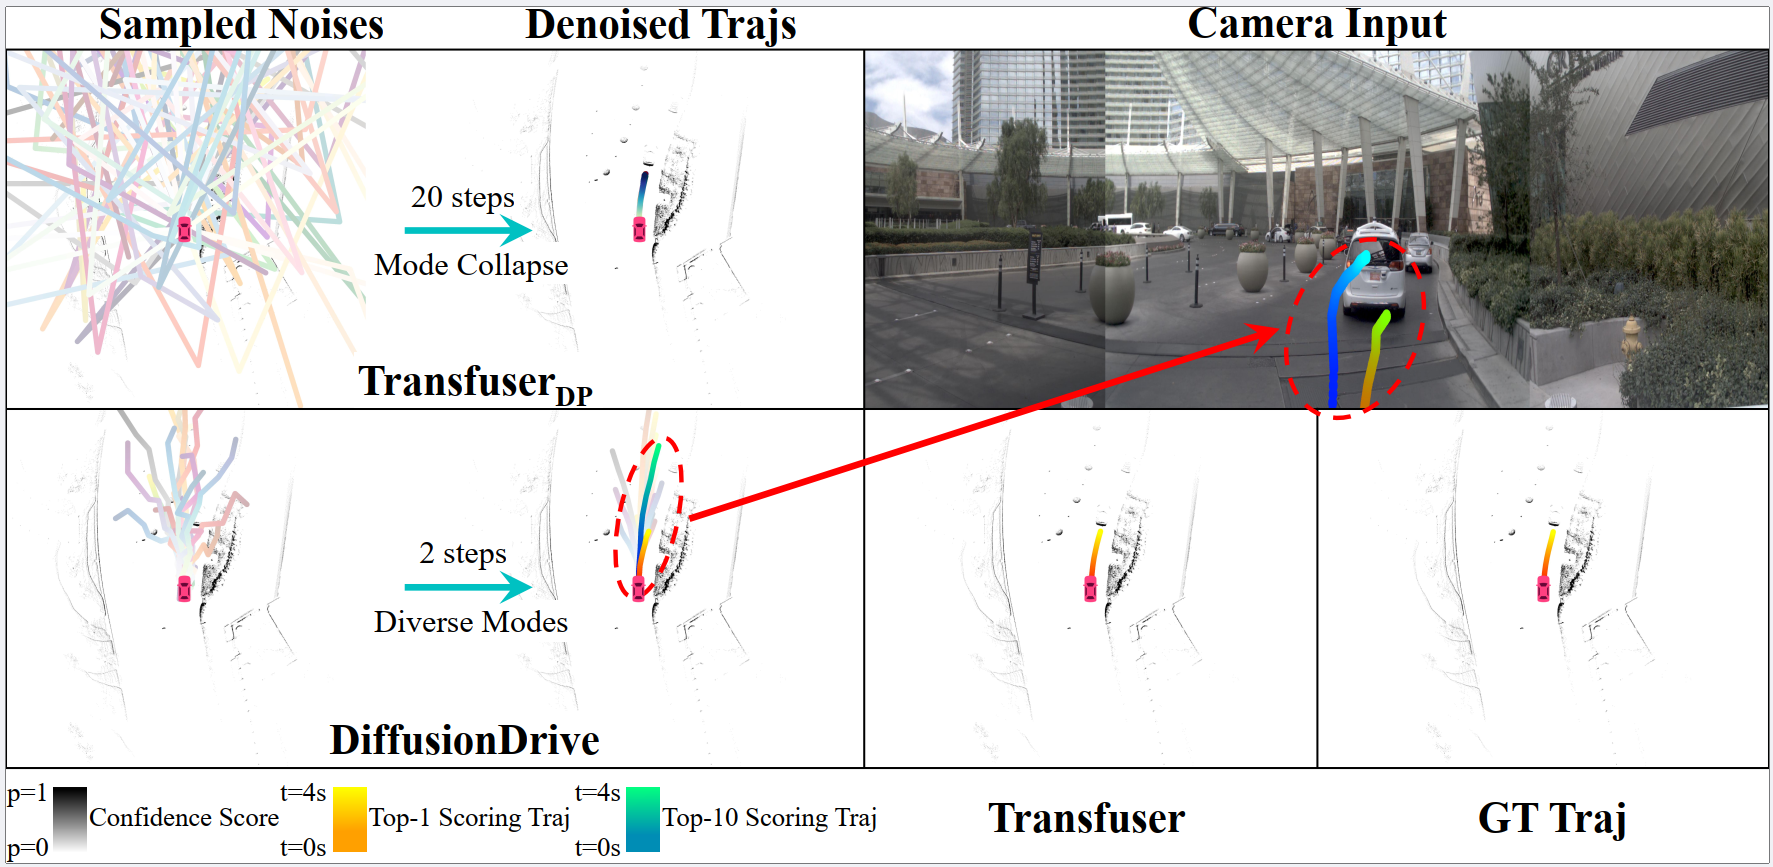
Apr. 4th, 2025: DiffusionDrive is awarded as CVPR 2025 Highlight! Feb. 27th, 2025: DiffusionDrive is accepted to CVPR 2025! Jan. 18th, 2025: We release the initial version of code and weight on nuScenes, along with documentation and training/evaluation scripts. Please run git checkout nusc to use it. Dec. 16th, 2024: We release the initial version of code and weight on NAVSIM, along with documentation and training/evaluation scripts. Nov. 25th, 2024: We released our paper on Arxiv. Code/Models are coming soon. Please stay tuned! ☕️Diffusion policy exhibits promising multimodal property and distributional expressivity in robotic field, while not ready for real-time end-to-end autonomous driving in more dynamic and open-world traffic scenes. To bridge this gap, we propose a novel truncated diffusion model, DiffusionDrive, for real-time end-to-end autonomous driving, which is much faster (10x reduction in diffusion denoising steps), more accurate (3.5 higher PDMS on NAVSIM), and more diverse (64% higher mode diversity score) than the vanilla diffusion policy. Without bells and whistles, DiffusionDrive achieves record-breaking 88.1 PDMS on NAVSIM benchmark with the same ResNet-34 backbone by directly learning from human demonstrations, while running at a real-time speed of 45 FPS.
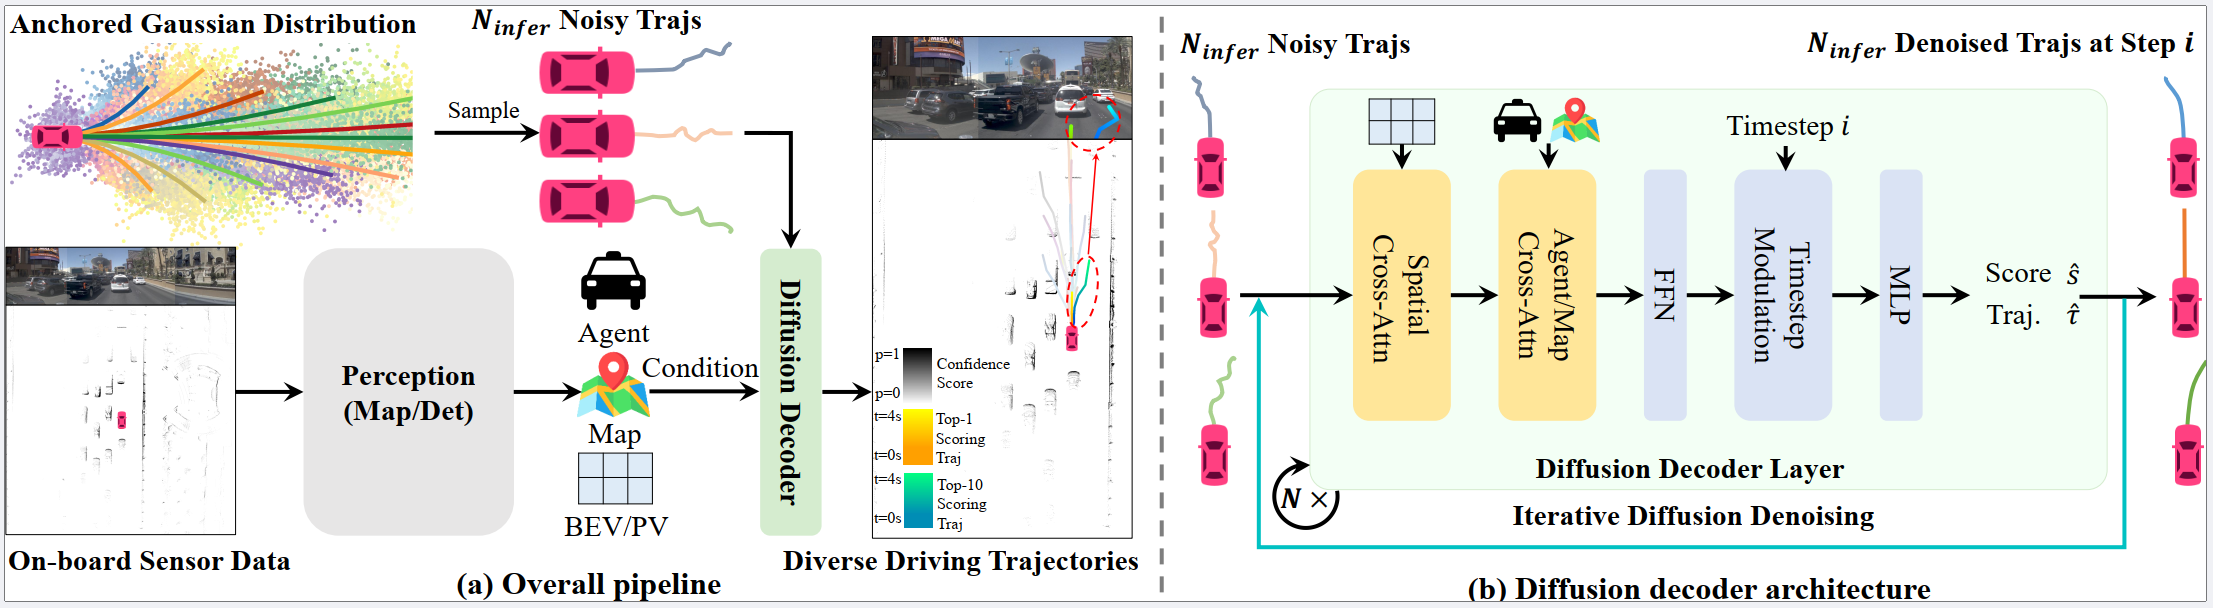
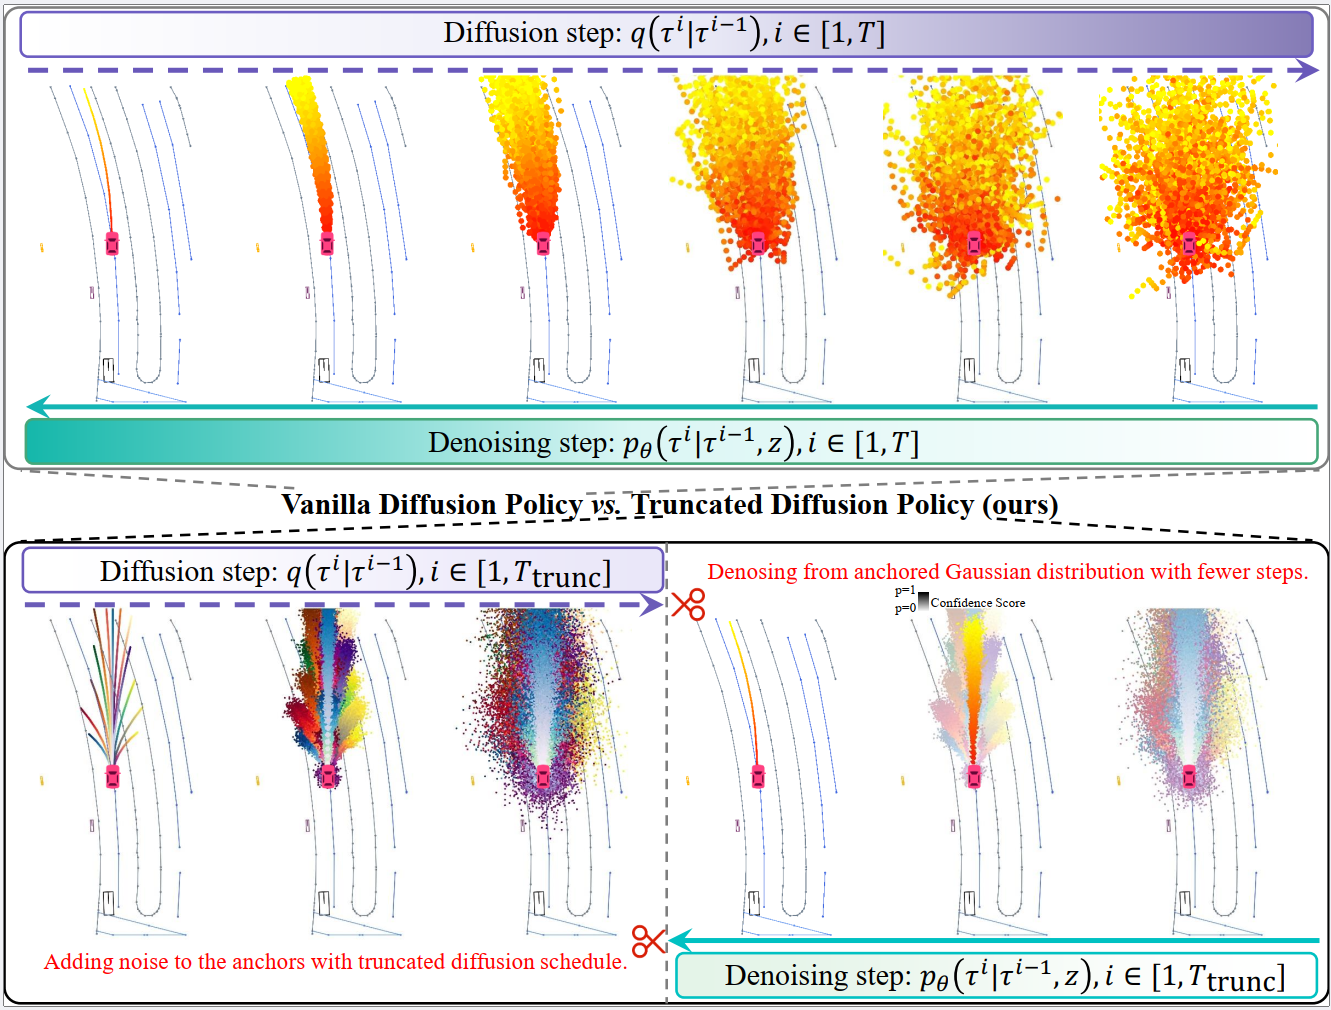 Pipeline of DiffusionDrive. DiffusionDrive is highly flexible to integrate with onboard sensor data and existing perception modules.
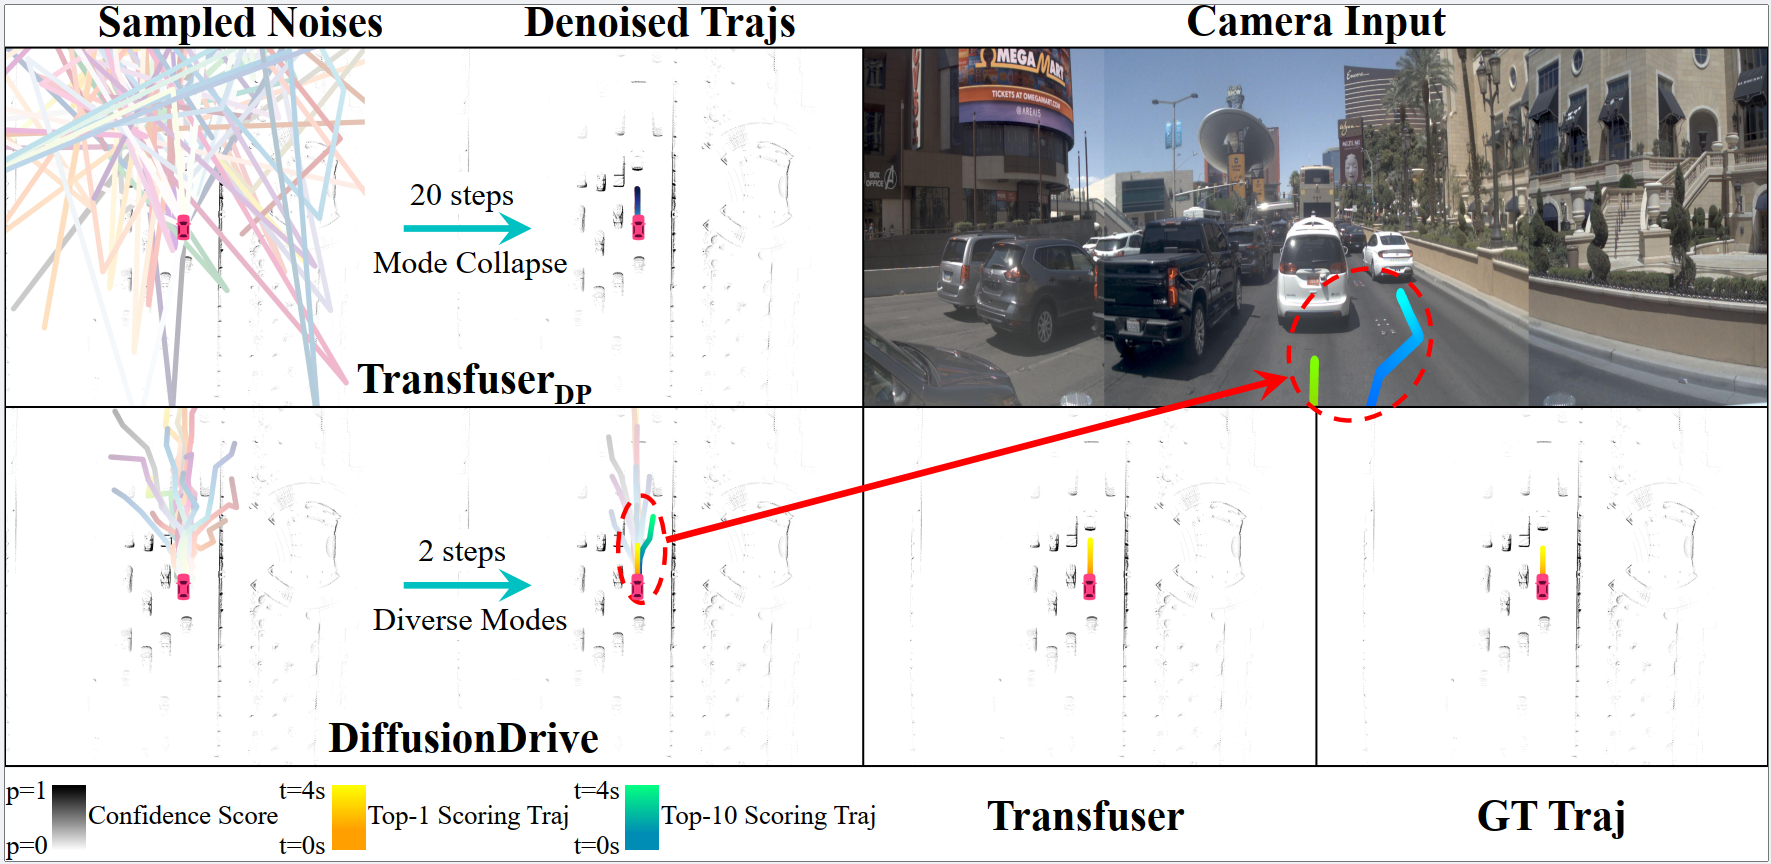 Going straight with diverse lane-changing behavior, which interacts with traffic light and stops at the stop line.
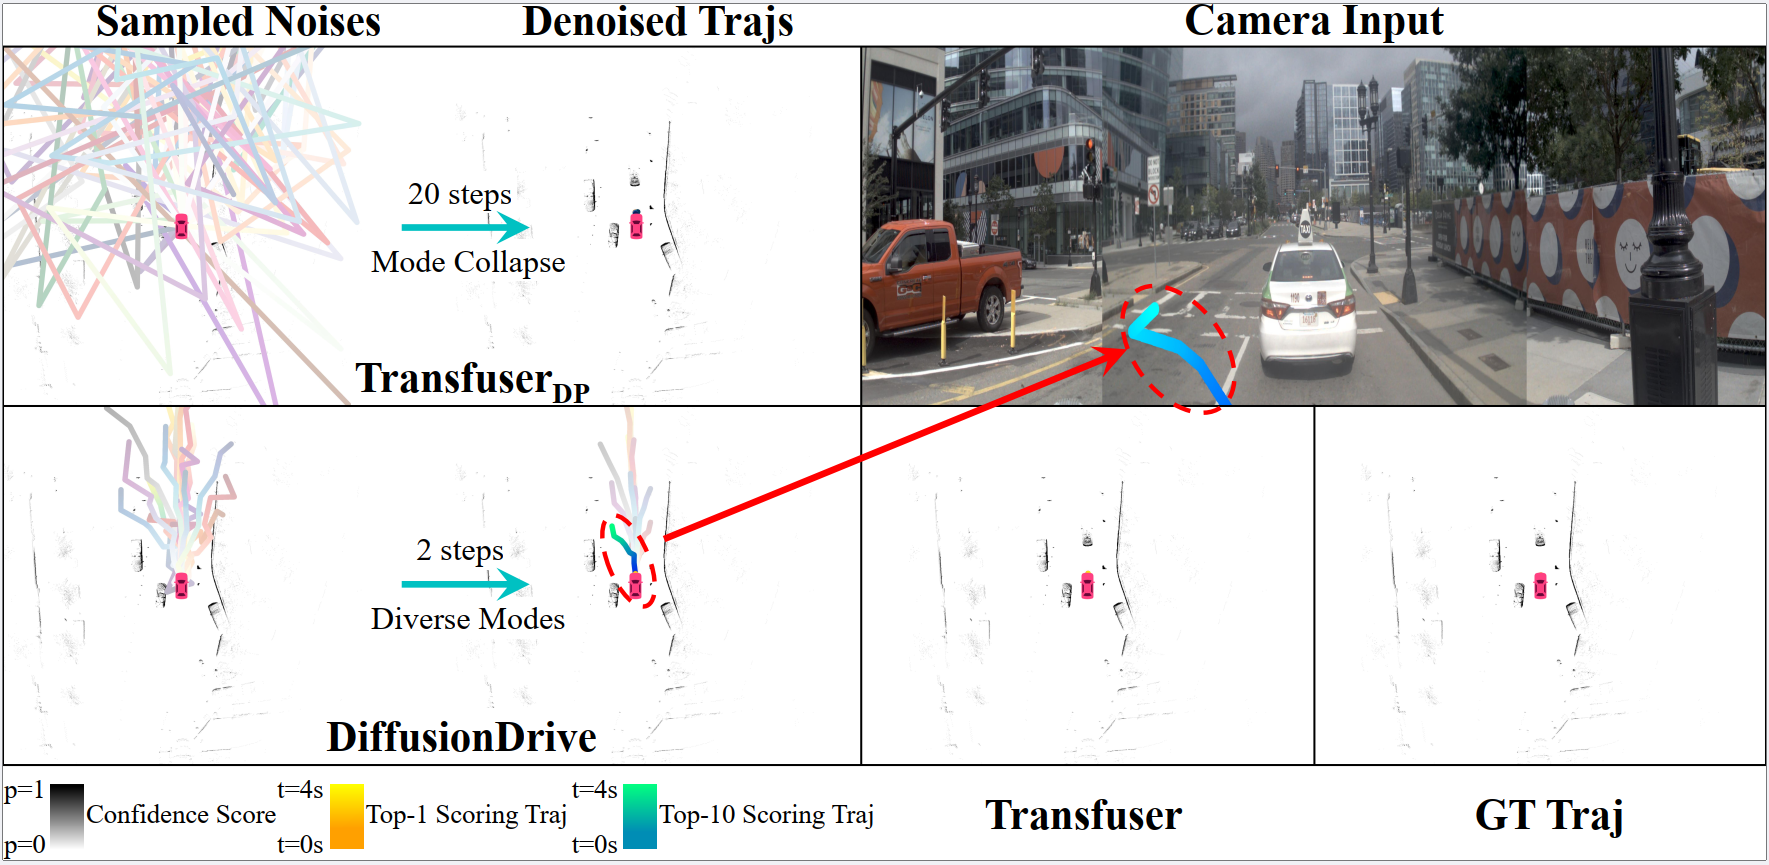 Turning left with diverse lane-changing behavior, which interacts with surrounding agents.
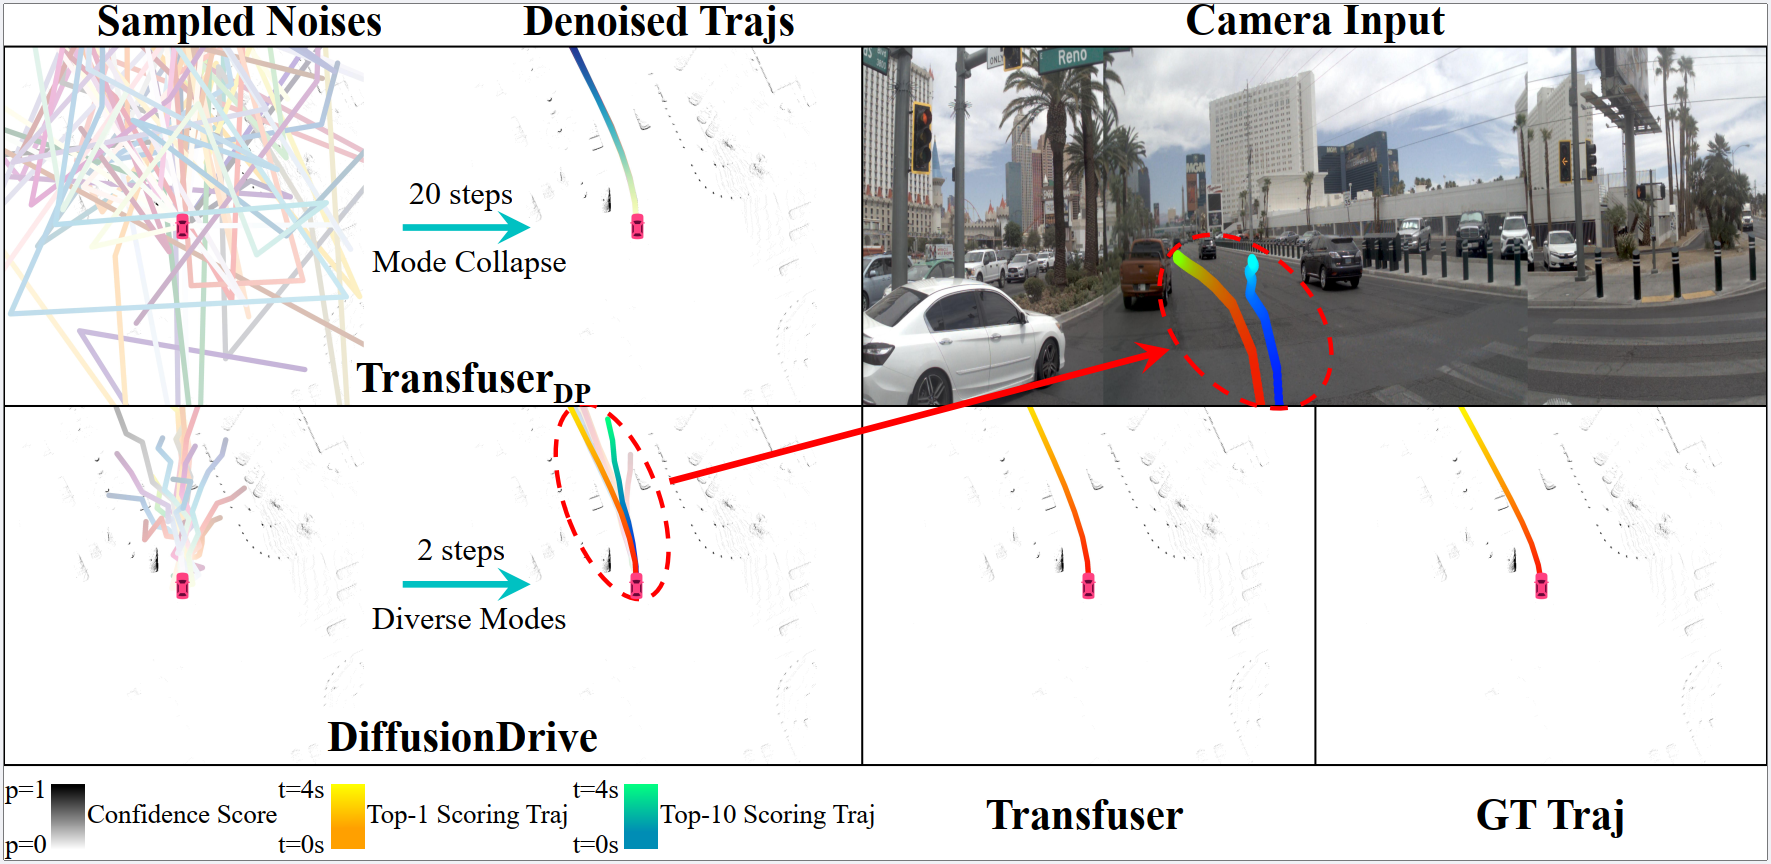 Turning right with car-following and overtaking behaviors.
https://github.com/user-attachments/assets/bd2364f3-73fd-4c29-b8b2-ead11f78926d
Results on NAVSIM
| Method | Model Size | Backbone | PDMS | Weight Download |
|---|---|---|---|---|
| DiffusionDrive | 60M | ResNet-34 | 88.1 | Hugging Face |
Results on nuScenes
| Method | Backbone | Weight | Log | L2 (m) 1s | L2 (m) 2s | L2 (m) 3s | L2 (m) Avg | Col. (%) 1s | Col. (%) 2s | Col. (%) 3s | Col. (%) Avg |
|---|---|---|---|---|---|---|---|---|---|---|---|
| DiffusionDrive | ResNet-50 | HF | Github | 0.27 | 0.54 | 0.90 | 0.57 | 0.03 | 0.05 | 0.16 | 0.08 |
If you have any questions, please contact Bencheng Liao via email ([email protected]).
DiffusionDrive is greatly inspired by the following outstanding contributions to the open-source community: NAVSIM, Transfuser, Diffusion Policy, MapTR, VAD, SparseDrive.
If you find DiffusionDrive is useful in your research or applications, please consider giving us a star 🌟 and citing it by the following BibTeX entry.
 @article{diffusiondrive,
  title={DiffusionDrive: Truncated Diffusion Model for End-to-End Autonomous Driving},
  author={Bencheng Liao and Shaoyu Chen and Haoran Yin and Bo Jiang and Cheng Wang and Sixu Yan and Xinbang Zhang and Xiangyu Li and Ying Zhang and Qian Zhang and Xinggang Wang},
  booktitle    = {{IEEE/CVF} Conference on Computer Vision and Pattern Recognition,
                  {CVPR} 2025, Nashville, TN, USA, June 11-15, 2025},
  pages        = {12037--12047},
  publisher    = {Computer Vision Foundation / {IEEE}},
  year         = {2025},
  url          = {https://openaccess.thecvf.com/content/CVPR2025/html/Liao\_DiffusionDrive\_Truncated\_Diffusion\_Model\_for\_End-to-End\_Autonomous\_Driving\_CVPR\_2025\_paper.html},
  doi          = {10.1109/CVPR52734.2025.01124}
}
381 followers · starred Nov 2024
90 followers · starred Jun 2025
38 followers · starred Jan 2025
20 followers · starred Jan 2026
[CVPR 2025 Highlight] Truncated Diffusion Model for Real-Time End-to-End Autonomous Driving
See the code
Bencheng Liao1,2, Shaoyu Chen2,3, Haoran Yin3, Bo Jiang2, Cheng Wang1,2, Sixu Yan2, Xinbang Zhang3, Xiangyu Li3, Ying Zhang3, Qian Zhang3, Xinggang Wang2 📧
1 Institute of Artificial Intelligence, HUST, 2 School of EIC, HUST, 3 Horizon Robotics
(📧) corresponding author, [email protected]
Accepted to CVPR 2025 as Highlight!
Apr. 4th, 2025: DiffusionDrive is awarded as CVPR 2025 Highlight! Feb. 27th, 2025: DiffusionDrive is accepted to CVPR 2025! Jan. 18th, 2025: We release the initial version of code and weight on nuScenes, along with documentation and training/evaluation scripts. Please run git checkout nusc to use it. Dec. 16th, 2024: We release the initial version of code and weight on NAVSIM, along with documentation and training/evaluation scripts. Nov. 25th, 2024: We released our paper on Arxiv. Code/Models are coming soon. Please stay tuned! ☕️Diffusion policy exhibits promising multimodal property and distributional expressivity in robotic field, while not ready for real-time end-to-end autonomous driving in more dynamic and open-world traffic scenes. To bridge this gap, we propose a novel truncated diffusion model, DiffusionDrive, for real-time end-to-end autonomous driving, which is much faster (10x reduction in diffusion denoising steps), more accurate (3.5 higher PDMS on NAVSIM), and more diverse (64% higher mode diversity score) than the vanilla diffusion policy. Without bells and whistles, DiffusionDrive achieves record-breaking 88.1 PDMS on NAVSIM benchmark with the same ResNet-34 backbone by directly learning from human demonstrations, while running at a real-time speed of 45 FPS.
Pipeline of DiffusionDrive. DiffusionDrive is highly flexible to integrate with onboard sensor data and existing perception modules.
Going straight with diverse lane-changing behavior, which interacts with traffic light and stops at the stop line.
Turning left with diverse lane-changing behavior, which interacts with surrounding agents.
Turning right with car-following and overtaking behaviors.
https://github.com/user-attachments/assets/bd2364f3-73fd-4c29-b8b2-ead11f78926d
Results on NAVSIM
| Method | Model Size | Backbone | PDMS | Weight Download |
|---|---|---|---|---|
| DiffusionDrive | 60M | ResNet-34 | 88.1 | Hugging Face |
Results on nuScenes
| Method | Backbone | Weight | Log | L2 (m) 1s | L2 (m) 2s | L2 (m) 3s | L2 (m) Avg | Col. (%) 1s | Col. (%) 2s | Col. (%) 3s | Col. (%) Avg |
|---|---|---|---|---|---|---|---|---|---|---|---|
| DiffusionDrive | ResNet-50 | HF | Github | 0.27 | 0.54 | 0.90 | 0.57 | 0.03 | 0.05 | 0.16 | 0.08 |
If you have any questions, please contact Bencheng Liao via email ([email protected]).
DiffusionDrive is greatly inspired by the following outstanding contributions to the open-source community: NAVSIM, Transfuser, Diffusion Policy, MapTR, VAD, SparseDrive.
If you find DiffusionDrive is useful in your research or applications, please consider giving us a star 🌟 and citing it by the following BibTeX entry.
 @article{diffusiondrive,
  title={DiffusionDrive: Truncated Diffusion Model for End-to-End Autonomous Driving},
  author={Bencheng Liao and Shaoyu Chen and Haoran Yin and Bo Jiang and Cheng Wang and Sixu Yan and Xinbang Zhang and Xiangyu Li and Ying Zhang and Qian Zhang and Xinggang Wang},
  booktitle    = {{IEEE/CVF} Conference on Computer Vision and Pattern Recognition,
                  {CVPR} 2025, Nashville, TN, USA, June 11-15, 2025},
  pages        = {12037--12047},
  publisher    = {Computer Vision Foundation / {IEEE}},
  year         = {2025},
  url          = {https://openaccess.thecvf.com/content/CVPR2025/html/Liao\_DiffusionDrive\_Truncated\_Diffusion\_Model\_for\_End-to-End\_Autonomous\_Driving\_CVPR\_2025\_paper.html},
  doi          = {10.1109/CVPR52734.2025.01124}
}
381 followers · starred Nov 2024
90 followers · starred Jun 2025
38 followers · starred Jan 2025
20 followers · starred Jan 2026



