A Handy Extrinsic Calibration Tool for LiDAR-camera Systems.
C++
1,107
19 commits
updated May 12, 2026
FAST-Calib is an efficient target-based extrinsic calibration tool for LiDAR-camera systems (eg., FAST-LIVO2).
Key highlights include:
In short, it makes extrinsic calibration as simple as intrinsic calibration.
Related paper:
FAST-Calib: LiDAR-Camera Extrinsic Calibration in One Second
📬 For further assistance or inquiries, please feel free to contact Chunran Zheng at [email protected].
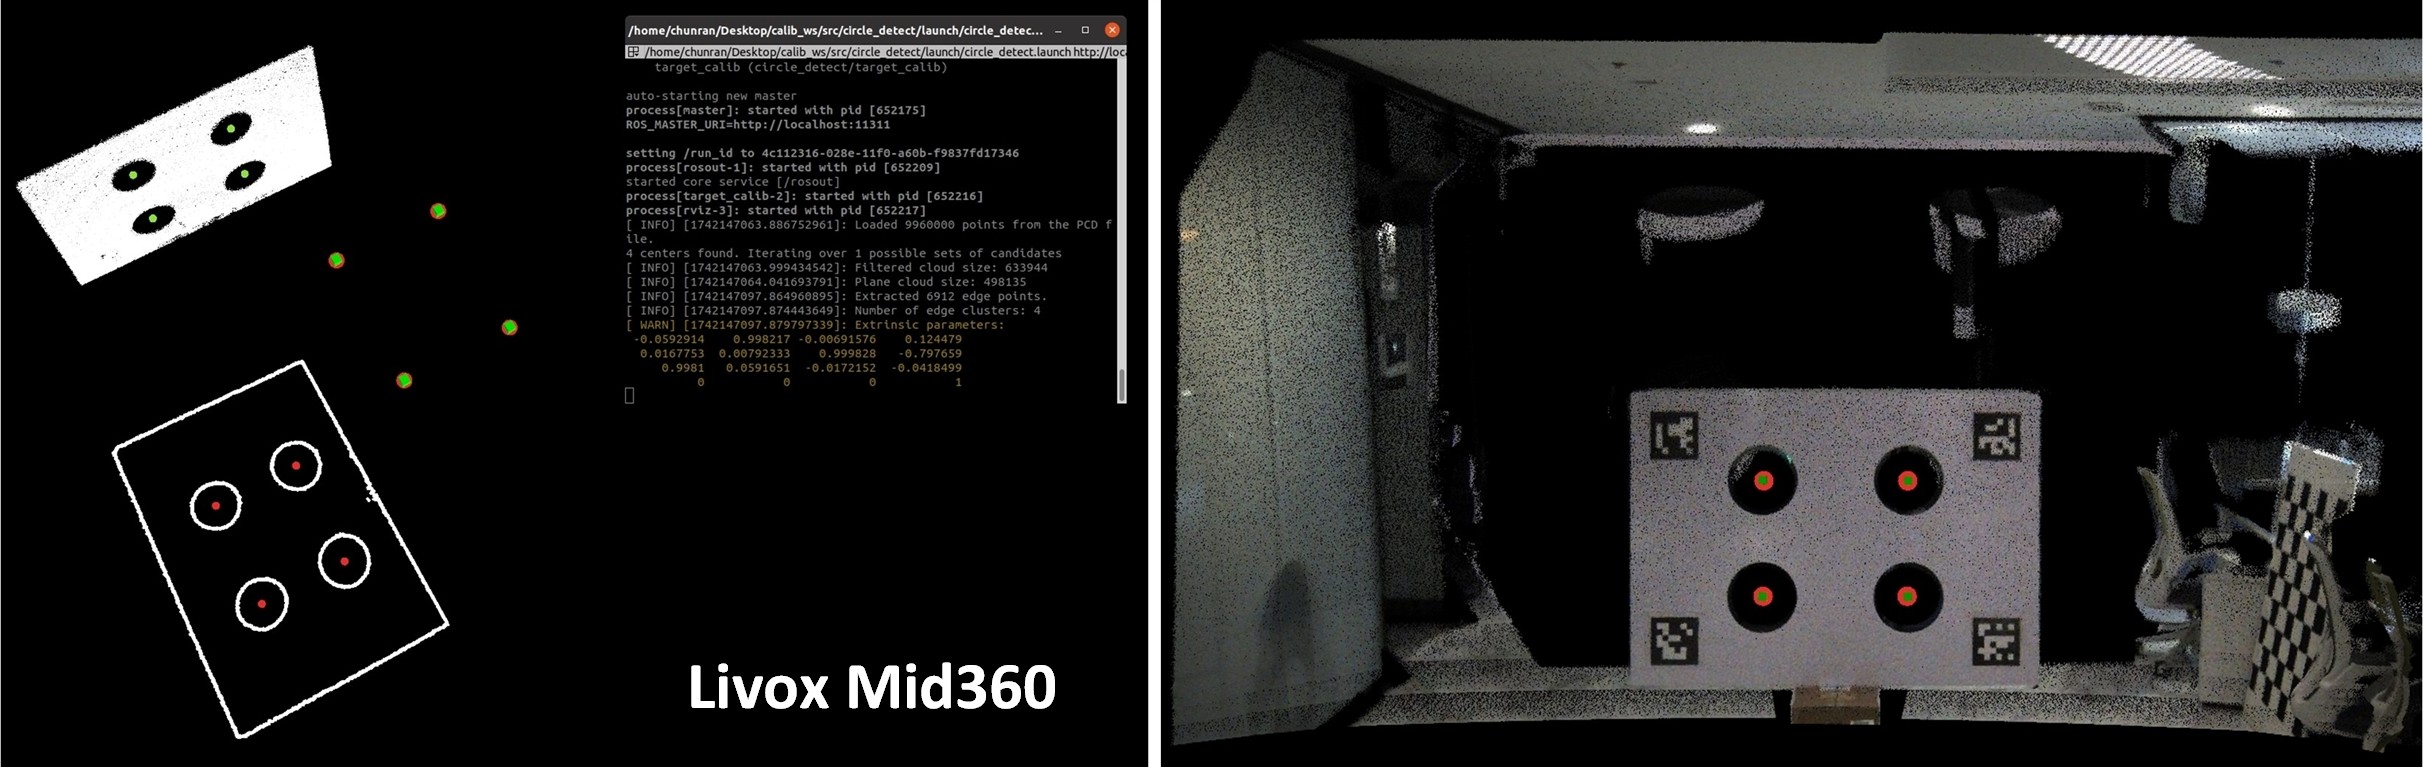 Left: Example of Mid360 LiDAR calibration. Right: Point cloud colored with the calibrated extrinsics.
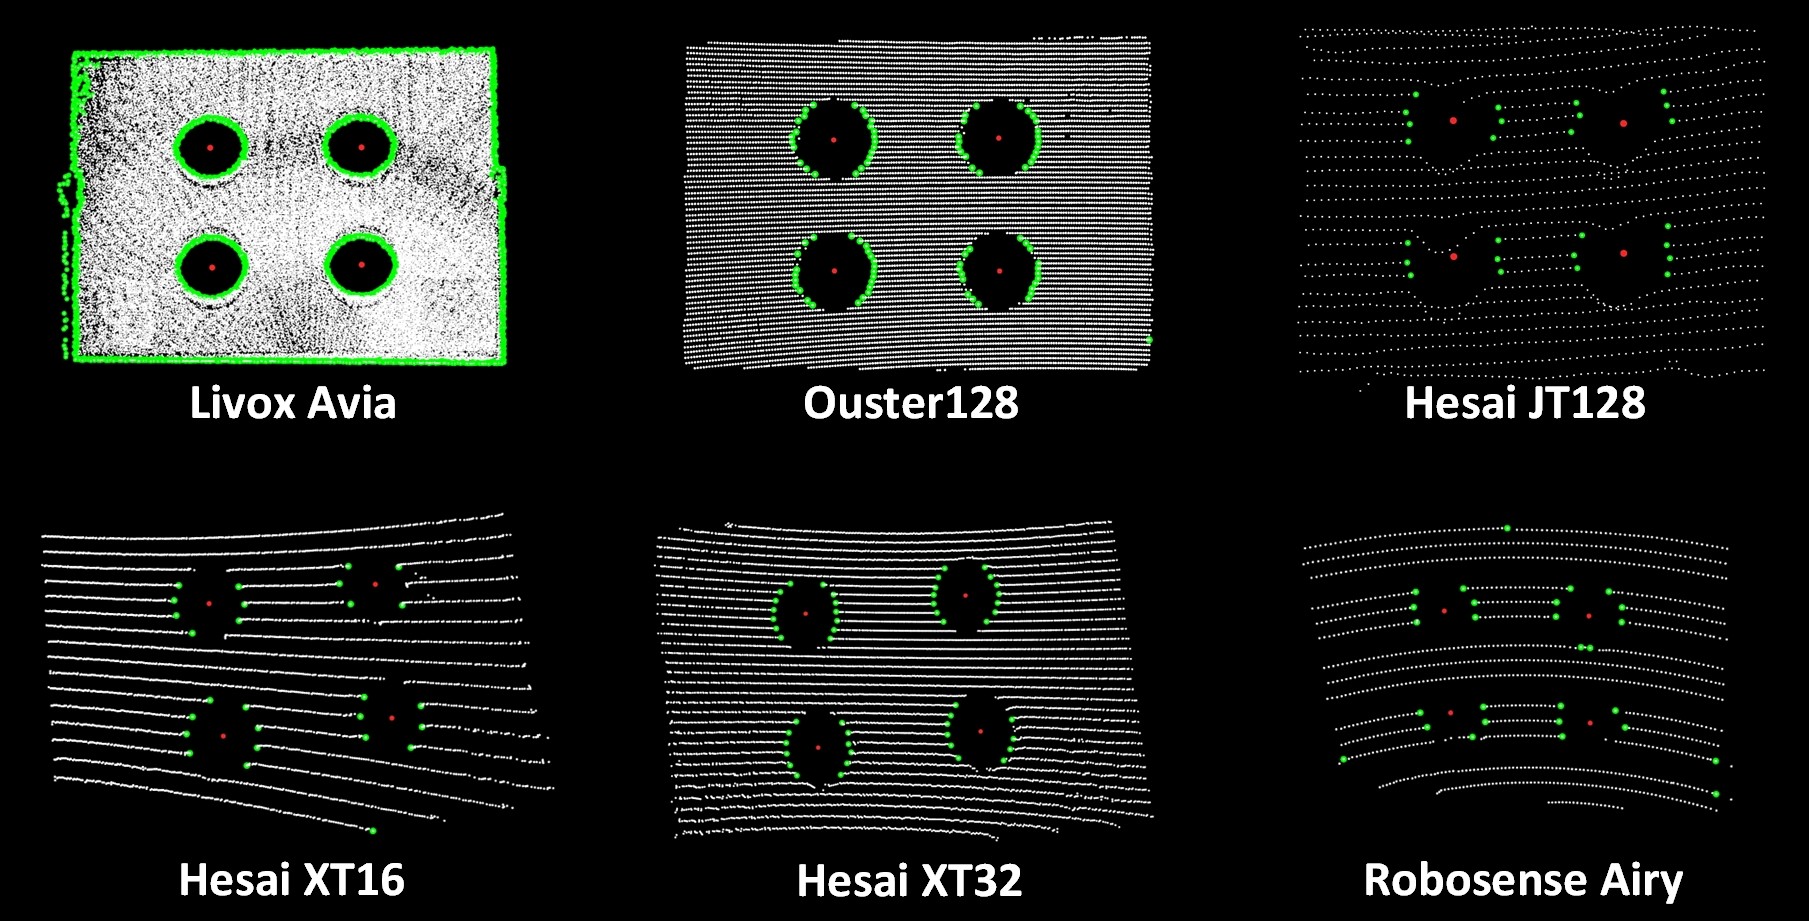 Circular hole extraction supports multiple LiDAR models.
PCL>=1.8, OpenCV>=4.0.
calib_data folder (see Single-scene Calibration Sample Data from Mid360, Avia and Ouster, and Multi-scene Calibration Sample Data from Avia):roslaunch fast_calib calib.launch
roslaunch fast_calib multi_calib.launch
qr_params.yaml.qr_params.yaml for board point cloud (extra points are acceptable).💡 Note: You can run scripts/distance_filter_tool.py to quickly obtain suitable filter parameters.
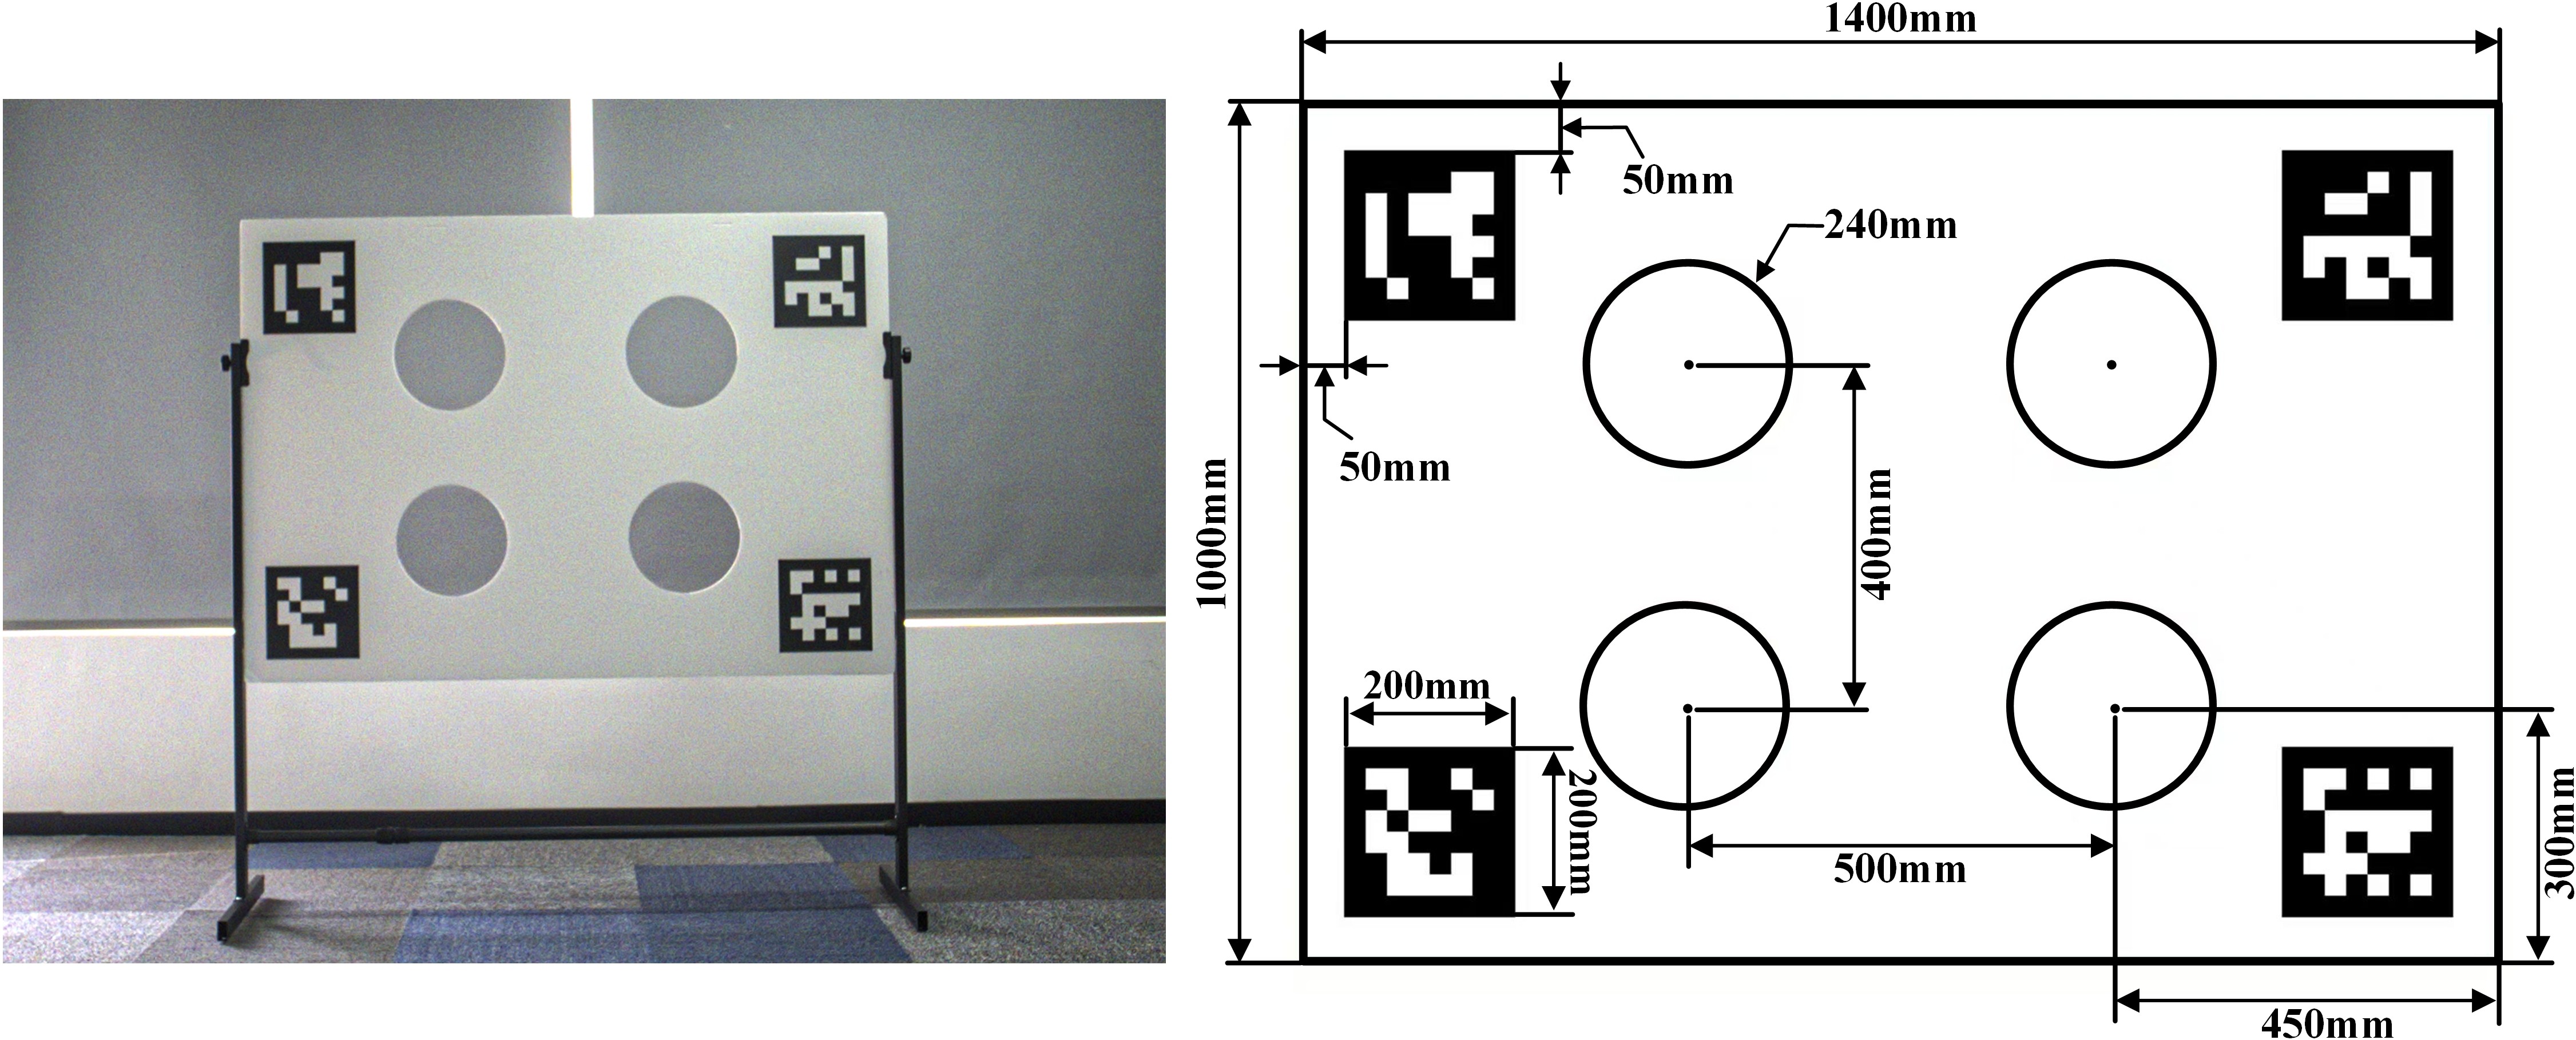 Left: Actual calibration target | Right: Technical drawing with annotated dimensions.
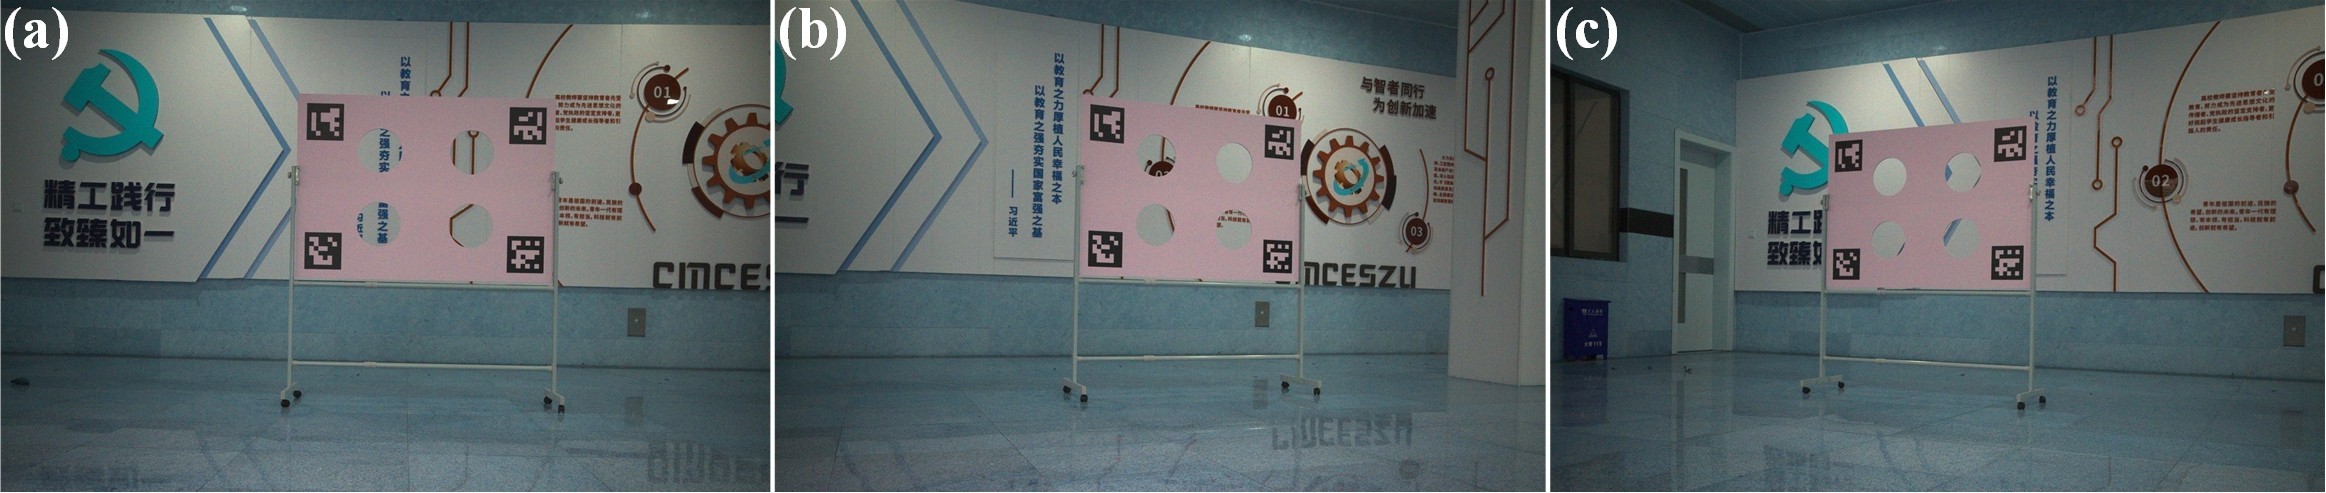 Placement of the calibration target for multi-scene data collection: (a) facing forward, (b) oriented to the right, (c) oriented to the left.
The calibration target design is based on the velo2cam_calibration.
For further details on the algorithm workflow, see this document.
Special thanks to Jiaming Xu for his support, Haotian Li for the equipment, and the velo2cam_calibration algorithm.
785 followers · starred Jan 2026
696 followers · starred Jul 2026
116 followers · starred May 2025
A Handy Extrinsic Calibration Tool for LiDAR-camera Systems.
C++
1,107
19 commits
updated May 12, 2026
FAST-Calib is an efficient target-based extrinsic calibration tool for LiDAR-camera systems (eg., FAST-LIVO2).
Key highlights include:
In short, it makes extrinsic calibration as simple as intrinsic calibration.
Related paper:
FAST-Calib: LiDAR-Camera Extrinsic Calibration in One Second
📬 For further assistance or inquiries, please feel free to contact Chunran Zheng at [email protected].
Left: Example of Mid360 LiDAR calibration. Right: Point cloud colored with the calibrated extrinsics.
Circular hole extraction supports multiple LiDAR models.
PCL>=1.8, OpenCV>=4.0.
calib_data folder (see Single-scene Calibration Sample Data from Mid360, Avia and Ouster, and Multi-scene Calibration Sample Data from Avia):roslaunch fast_calib calib.launch
roslaunch fast_calib multi_calib.launch
qr_params.yaml.qr_params.yaml for board point cloud (extra points are acceptable).💡 Note: You can run scripts/distance_filter_tool.py to quickly obtain suitable filter parameters.
Left: Actual calibration target | Right: Technical drawing with annotated dimensions.
Placement of the calibration target for multi-scene data collection: (a) facing forward, (b) oriented to the right, (c) oriented to the left.
The calibration target design is based on the velo2cam_calibration.
For further details on the algorithm workflow, see this document.
Special thanks to Jiaming Xu for his support, Haotian Li for the equipment, and the velo2cam_calibration algorithm.
785 followers · starred Jan 2026
696 followers · starred Jul 2026
116 followers · starred May 2025



