High-fidelity world models for general embodied intelligence, such as data engines and world simulators.
Python
1,839
75 commits
updated Sep 9, 2026


BWM is a physically consistent, action-conditioned video world model built upon Wan2.2-TI2V-5B, serving as a low-cost yet high-fidelity simulator for robotic manipulation.
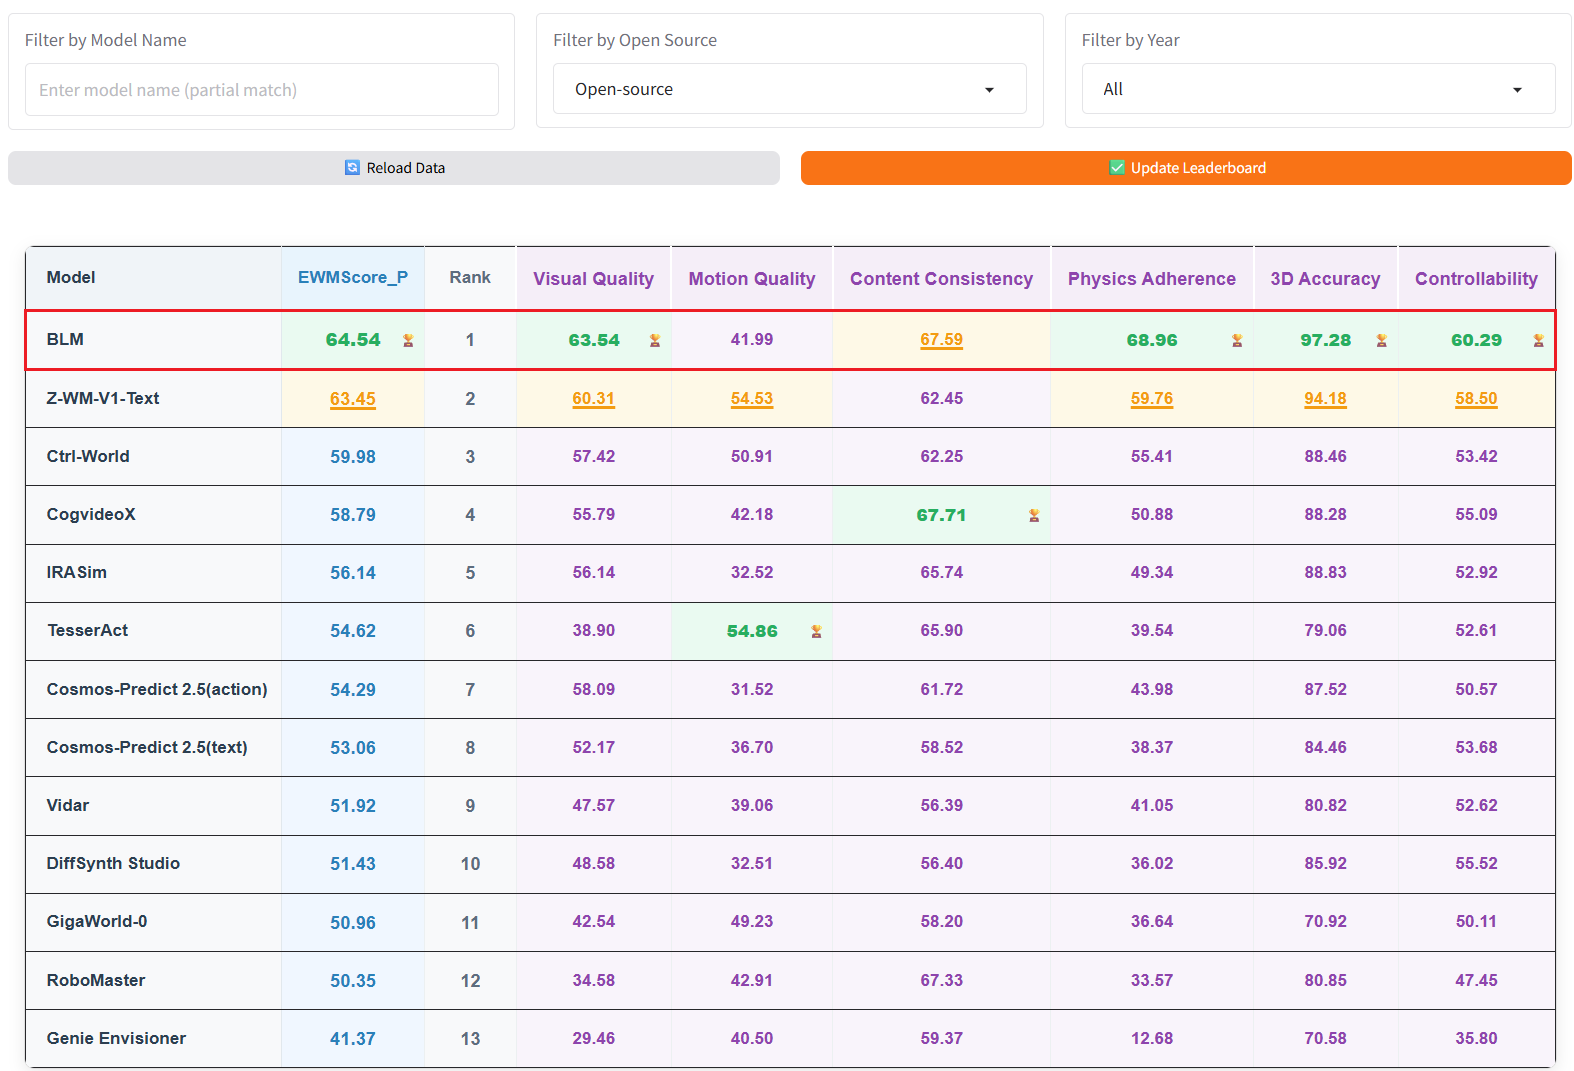 Track 1 open-source leaderboard |
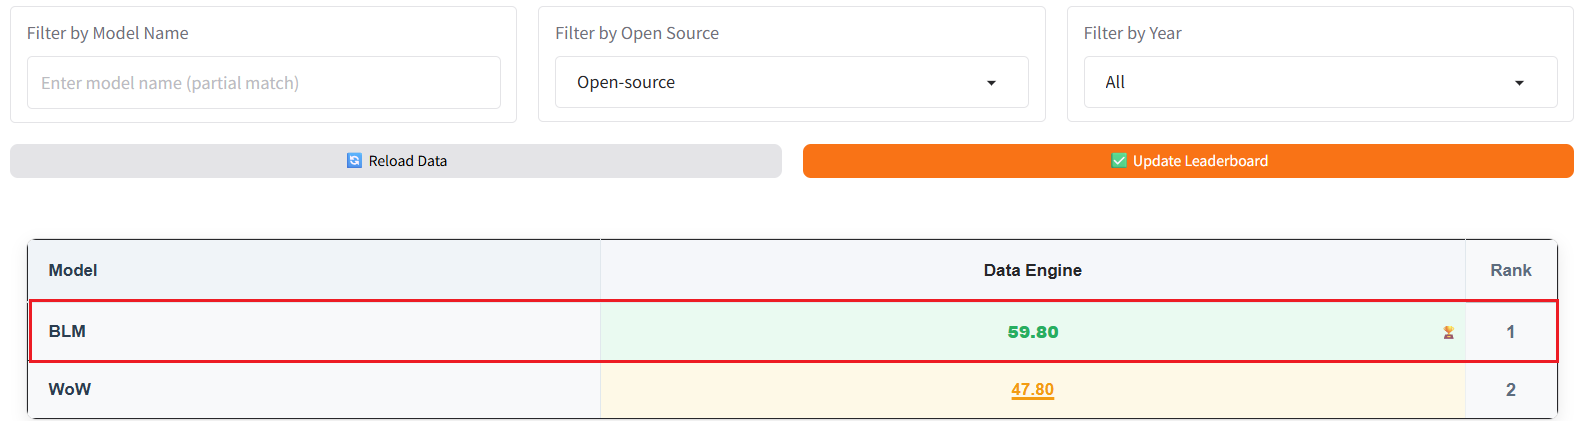 Track 2 Data Engine open-source leaderboard |
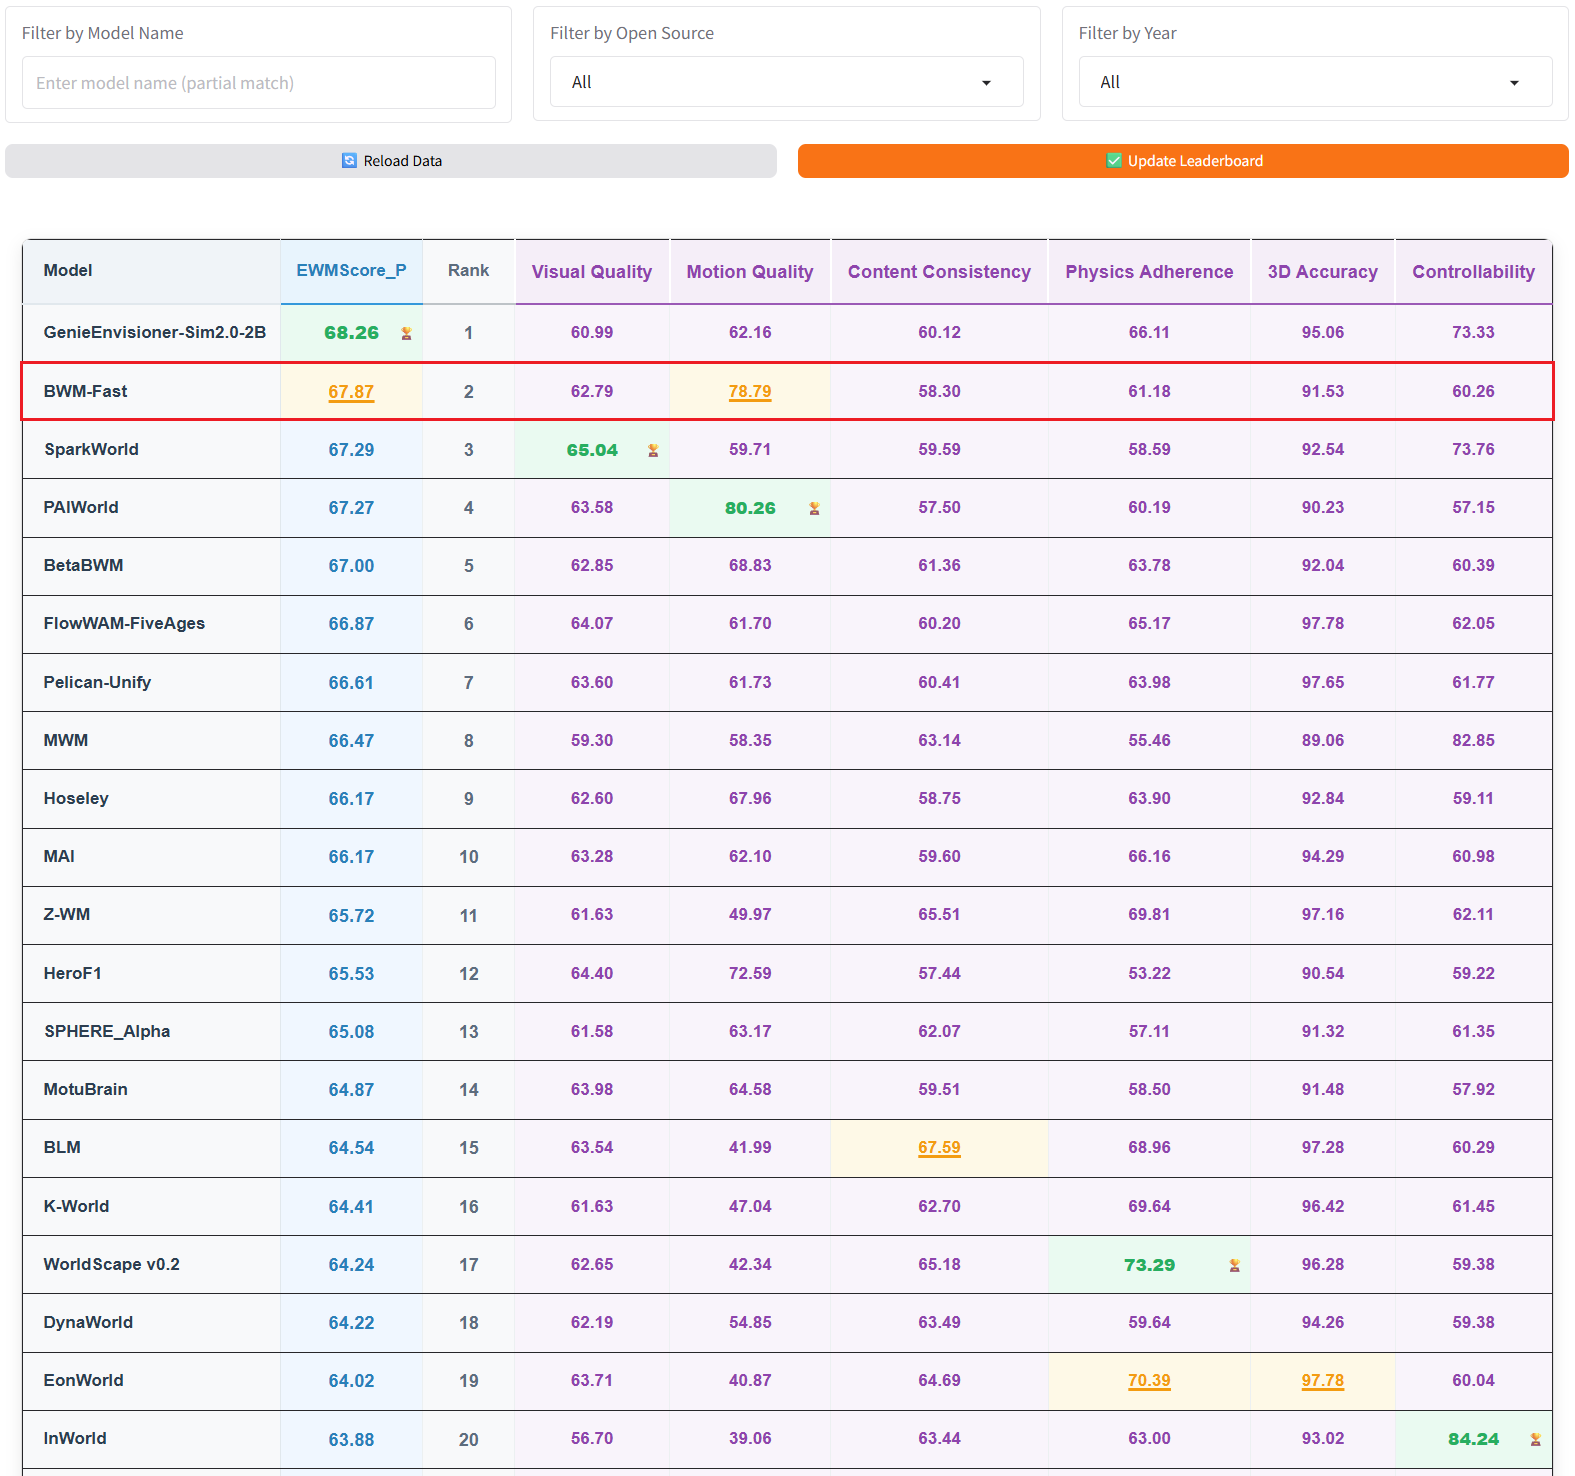 Track 1 overall leaderboard |
Leaderboard: https://huggingface.co/spaces/WorldArena/WorldArena
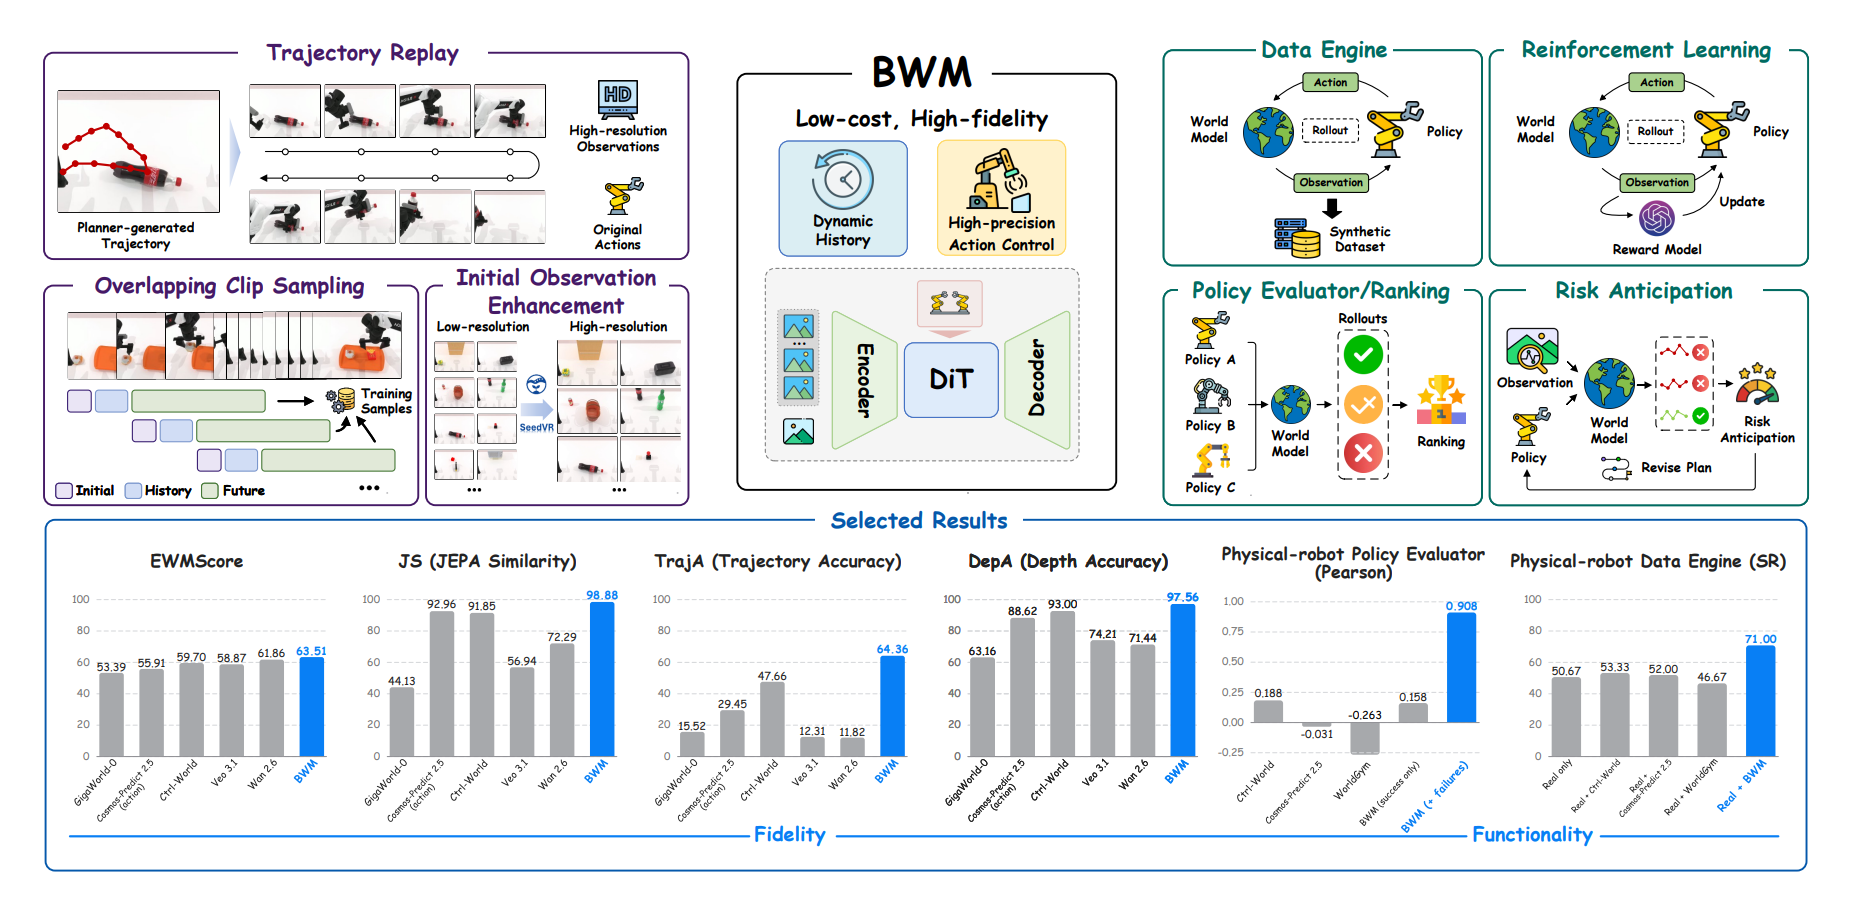
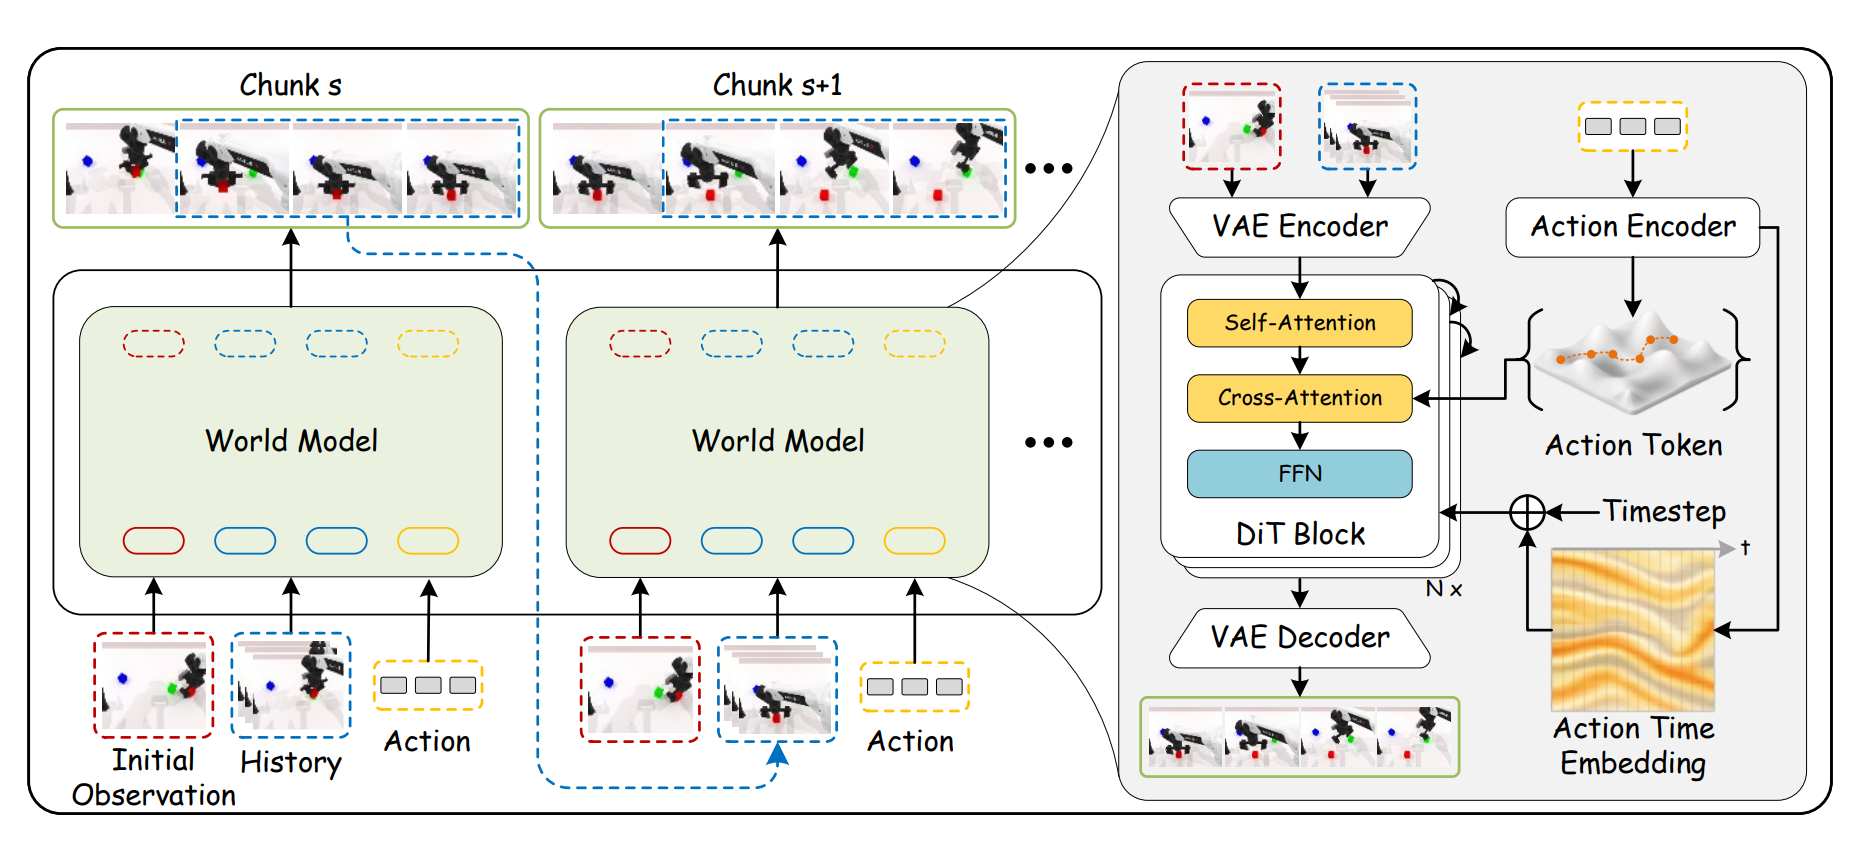
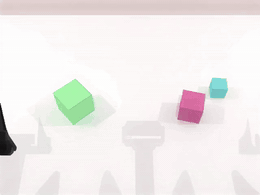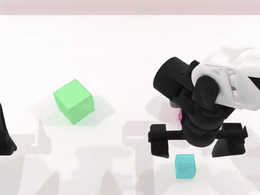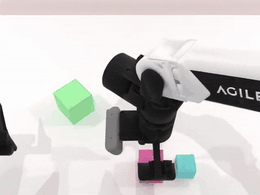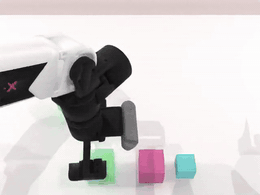
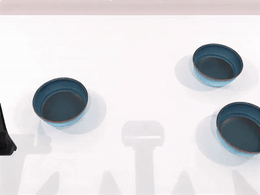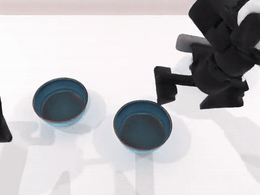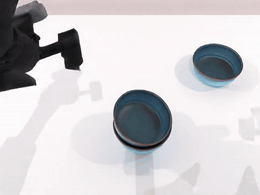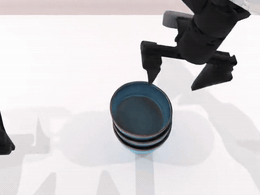
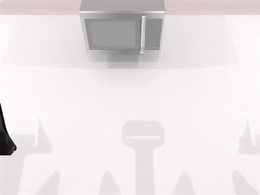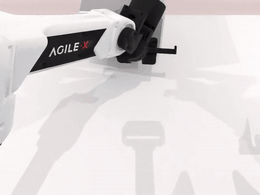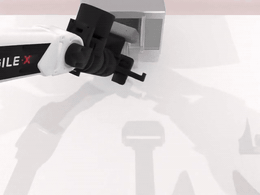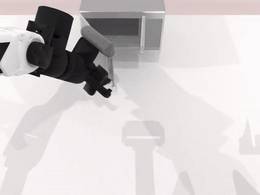
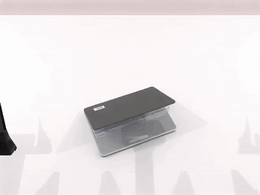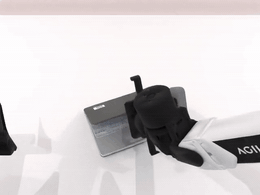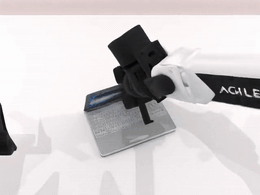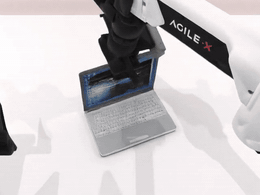
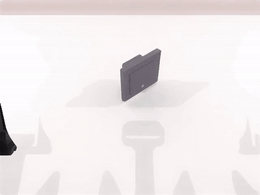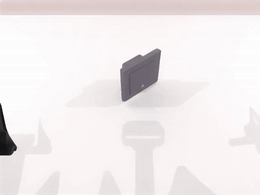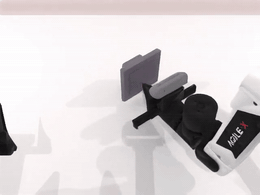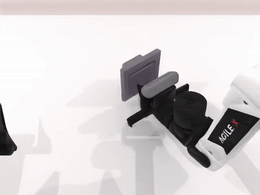
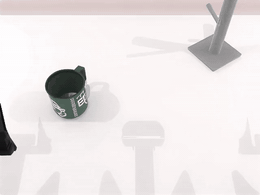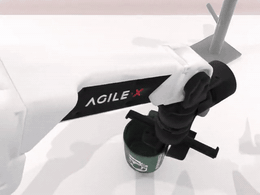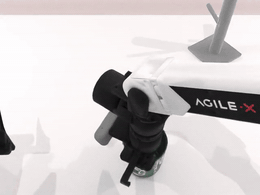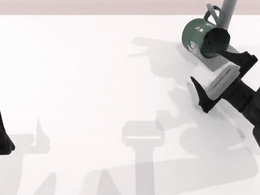
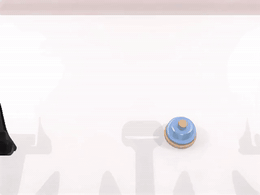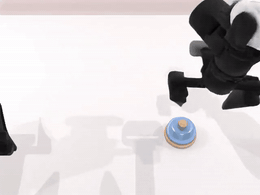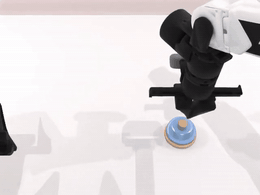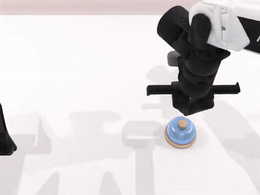
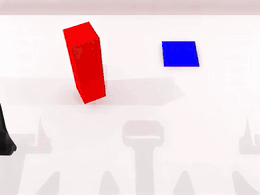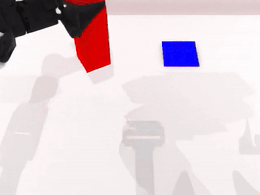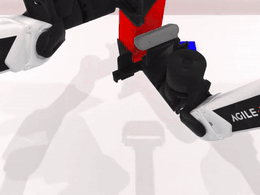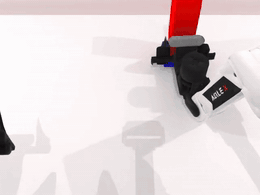
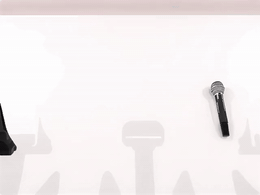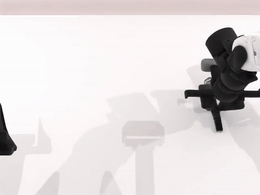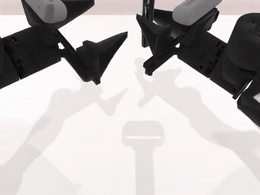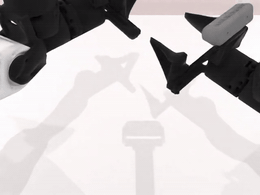
The following simulation scenes are generated autoregressively by BWM from initial frames and action sequences in the WorldArena test set, achieving high-fidelity visual realism while maintaining long-horizon physical consistency.
 |  |
 |  |
 |  |
 | 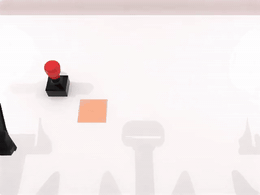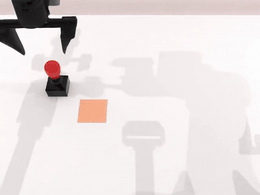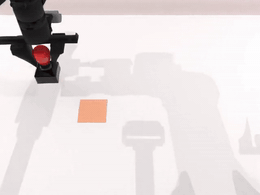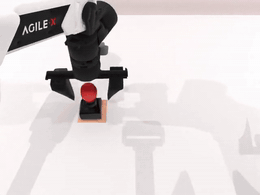 |
 |  |
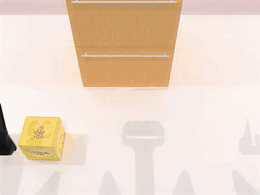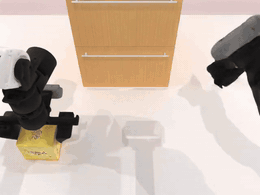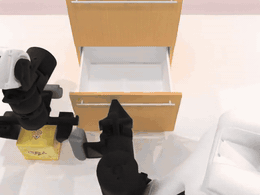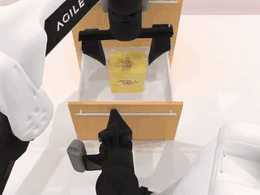 | 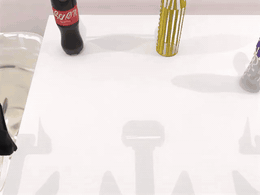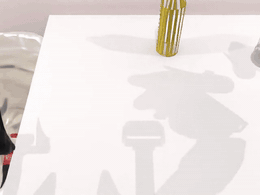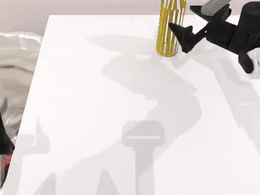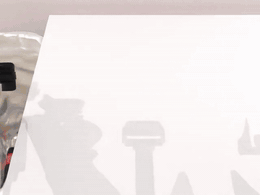 |
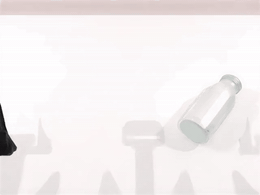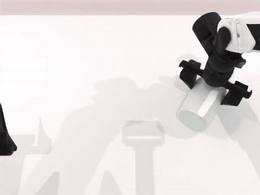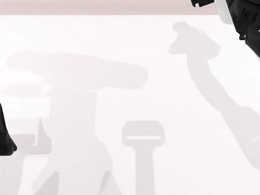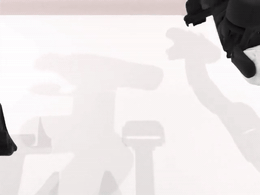
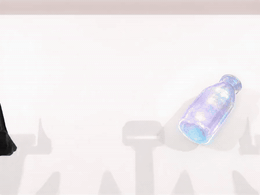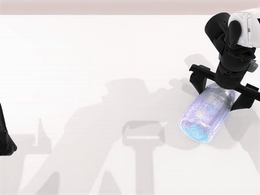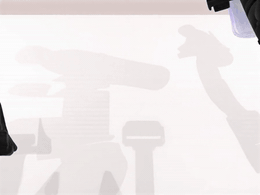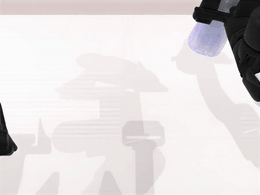
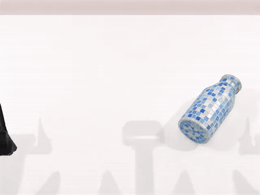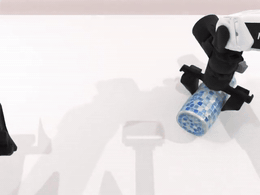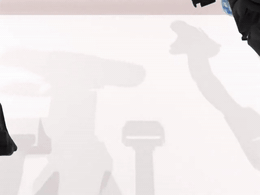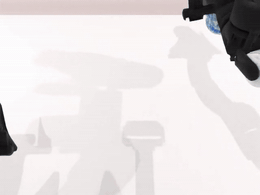
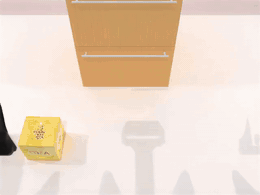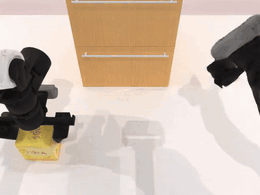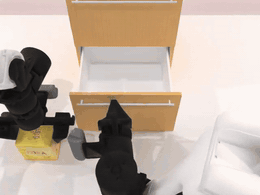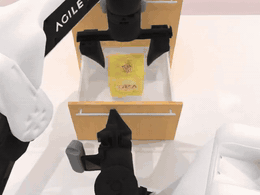
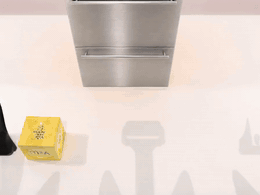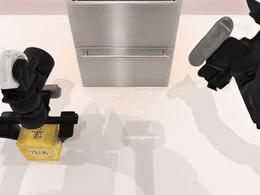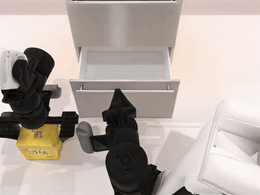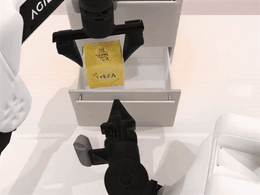
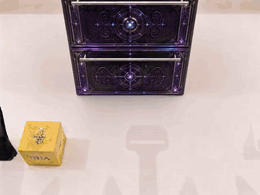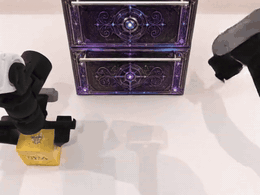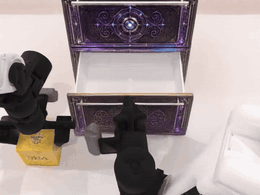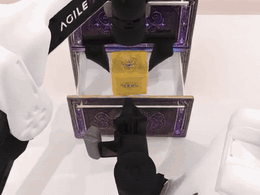
To test generalization beyond benchmark initial states, we use GPT-Image-2-created initial scenes with original robot action sequences and let BWM autoregressively roll out the future under object appearance shifts.
 |  |  |
 |  |  |
# Create conda environment
conda create -n BWM python=3.10.20
conda activate BWM

# Install PyTorch with CUDA support
pip install torch==2.8.0 torchvision==0.23.0 torchaudio==2.8.0 --index-url https://download.pytorch.org/whl/cu128

# Install DiffSynth-Studio
pip install diffsynth==2.0.11

# Install dependencies
pip install -r requirements.txt
Download the Wan2.2-TI2V-5B base model from ModelScope:
modelscope download --model Wan-AI/Wan2.2-TI2V-5B --local_dir models/Wan2.2-TI2V-5B
Download the BWM checkpoint from Hugging Face:
hf download BLM-Lab/Boundless-World-Model step-12000.safetensors --local-dir ckpt/BLM
The demo metadata, videos, actions, and normalization statistics are already included under demo/.
Set local paths before running inference:
cp scripts/local.example.sh scripts/local.sh
Update MODEL_PATHS and CKPT_PATH in scripts/local.sh, then run:
bash scripts/infer_example.sh
Coming soon !
This project builds upon the following open-source projects and benchmarks. We thank these teams for their contributions:
We also acknowledge the following engineering contributions:
We further thank all project contributors for their valuable discussions, support for the paper experiments, and participation in the WorldArena challenge.
Contributors are listed in alphabetical order by English name.
Baixu Ji, Bowen Wang, Chen Xu, Chenming Li, Chenyu Liu, Enci Xie, Fengling Li, Hao Xue, Heng Tao Shen, Heng Zhi, Lei Zhu, Pengfei Zhang, Tianshi Wang, Wenhao Liu, Wenjie Yang, Wentao Tan, Xuebin Fang, Yang Sun, Yipeng Chen, Zengrong Lin, Zequn Wang, Zhe Li
If you find BWM is useful in your research or applications, please consider giving us a star 🌟.
@article{bwm2026,
  author       = {{BWM Team}},
  title        = {{BWM}: A Low-Cost High-Fidelity World Simulator for Robot Learning},
  year         = {2026},
  journal      = {arXiv preprint arXiv:2607.29302}
}
37 followers · starred May 2026
1 followers · starred May 2026
2 followers · starred May 2026
High-fidelity world models for general embodied intelligence, such as data engines and world simulators.
Python
1,839
75 commits
updated Sep 9, 2026
BWM is a physically consistent, action-conditioned video world model built upon Wan2.2-TI2V-5B, serving as a low-cost yet high-fidelity simulator for robotic manipulation.
|
Track 1 open-source leaderboard |
|
Track 2 Data Engine open-source leaderboard |
|
Track 1 overall leaderboard |
Leaderboard: https://huggingface.co/spaces/WorldArena/WorldArena
The following simulation scenes are generated autoregressively by BWM from initial frames and action sequences in the WorldArena test set, achieving high-fidelity visual realism while maintaining long-horizon physical consistency.
| |
| |
| |
| |
| |
| |
To test generalization beyond benchmark initial states, we use GPT-Image-2-created initial scenes with original robot action sequences and let BWM autoregressively roll out the future under object appearance shifts.
| | |
| | |
# Create conda environment
conda create -n BWM python=3.10.20
conda activate BWM

# Install PyTorch with CUDA support
pip install torch==2.8.0 torchvision==0.23.0 torchaudio==2.8.0 --index-url https://download.pytorch.org/whl/cu128

# Install DiffSynth-Studio
pip install diffsynth==2.0.11

# Install dependencies
pip install -r requirements.txt
Download the Wan2.2-TI2V-5B base model from ModelScope:
modelscope download --model Wan-AI/Wan2.2-TI2V-5B --local_dir models/Wan2.2-TI2V-5B
Download the BWM checkpoint from Hugging Face:
hf download BLM-Lab/Boundless-World-Model step-12000.safetensors --local-dir ckpt/BLM
The demo metadata, videos, actions, and normalization statistics are already included under demo/.
Set local paths before running inference:
cp scripts/local.example.sh scripts/local.sh
Update MODEL_PATHS and CKPT_PATH in scripts/local.sh, then run:
bash scripts/infer_example.sh
Coming soon !
This project builds upon the following open-source projects and benchmarks. We thank these teams for their contributions:
We also acknowledge the following engineering contributions:
We further thank all project contributors for their valuable discussions, support for the paper experiments, and participation in the WorldArena challenge.
Contributors are listed in alphabetical order by English name.
Baixu Ji, Bowen Wang, Chen Xu, Chenming Li, Chenyu Liu, Enci Xie, Fengling Li, Hao Xue, Heng Tao Shen, Heng Zhi, Lei Zhu, Pengfei Zhang, Tianshi Wang, Wenhao Liu, Wenjie Yang, Wentao Tan, Xuebin Fang, Yang Sun, Yipeng Chen, Zengrong Lin, Zequn Wang, Zhe Li
If you find BWM is useful in your research or applications, please consider giving us a star 🌟.
@article{bwm2026,
  author       = {{BWM Team}},
  title        = {{BWM}: A Low-Cost High-Fidelity World Simulator for Robot Learning},
  year         = {2026},
  journal      = {arXiv preprint arXiv:2607.29302}
}
37 followers · starred May 2026
1 followers · starred May 2026
2 followers · starred May 2026



