Official Implementation of "KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills"
See the code
Weiji Xie* 1,2,
Jinrui Han* 1,2,
Jiakun Zheng* 1,3,
Huanyu Li1,4,
Xinzhe Liu1,5,
Jiyuan Shi1,
Weinan Zhang2,
Chenjia Bai†1,
Xuelong Li1
* Equal Contribution † Corresponding Author
1Institute of Artificial Intelligence (TeleAI), China Telecom
2Shanghai Jiao Tong University
3East China University of Science and Technology
4Harbin Institute of Technology
5ShanghaiTech University
Jinrui Han 1,2,
Weiji Xie 1,2,
Jiakun Zheng 1,3,
Jiyuan Shi1,
Weinan Zhang2,
Ting Xiao2,
Chenjia Bai†1,
† Corresponding Author
1Institute of Artificial Intelligence (TeleAI), China Telecom
2Shanghai Jiao Tong University
3East China University of Science and Technology
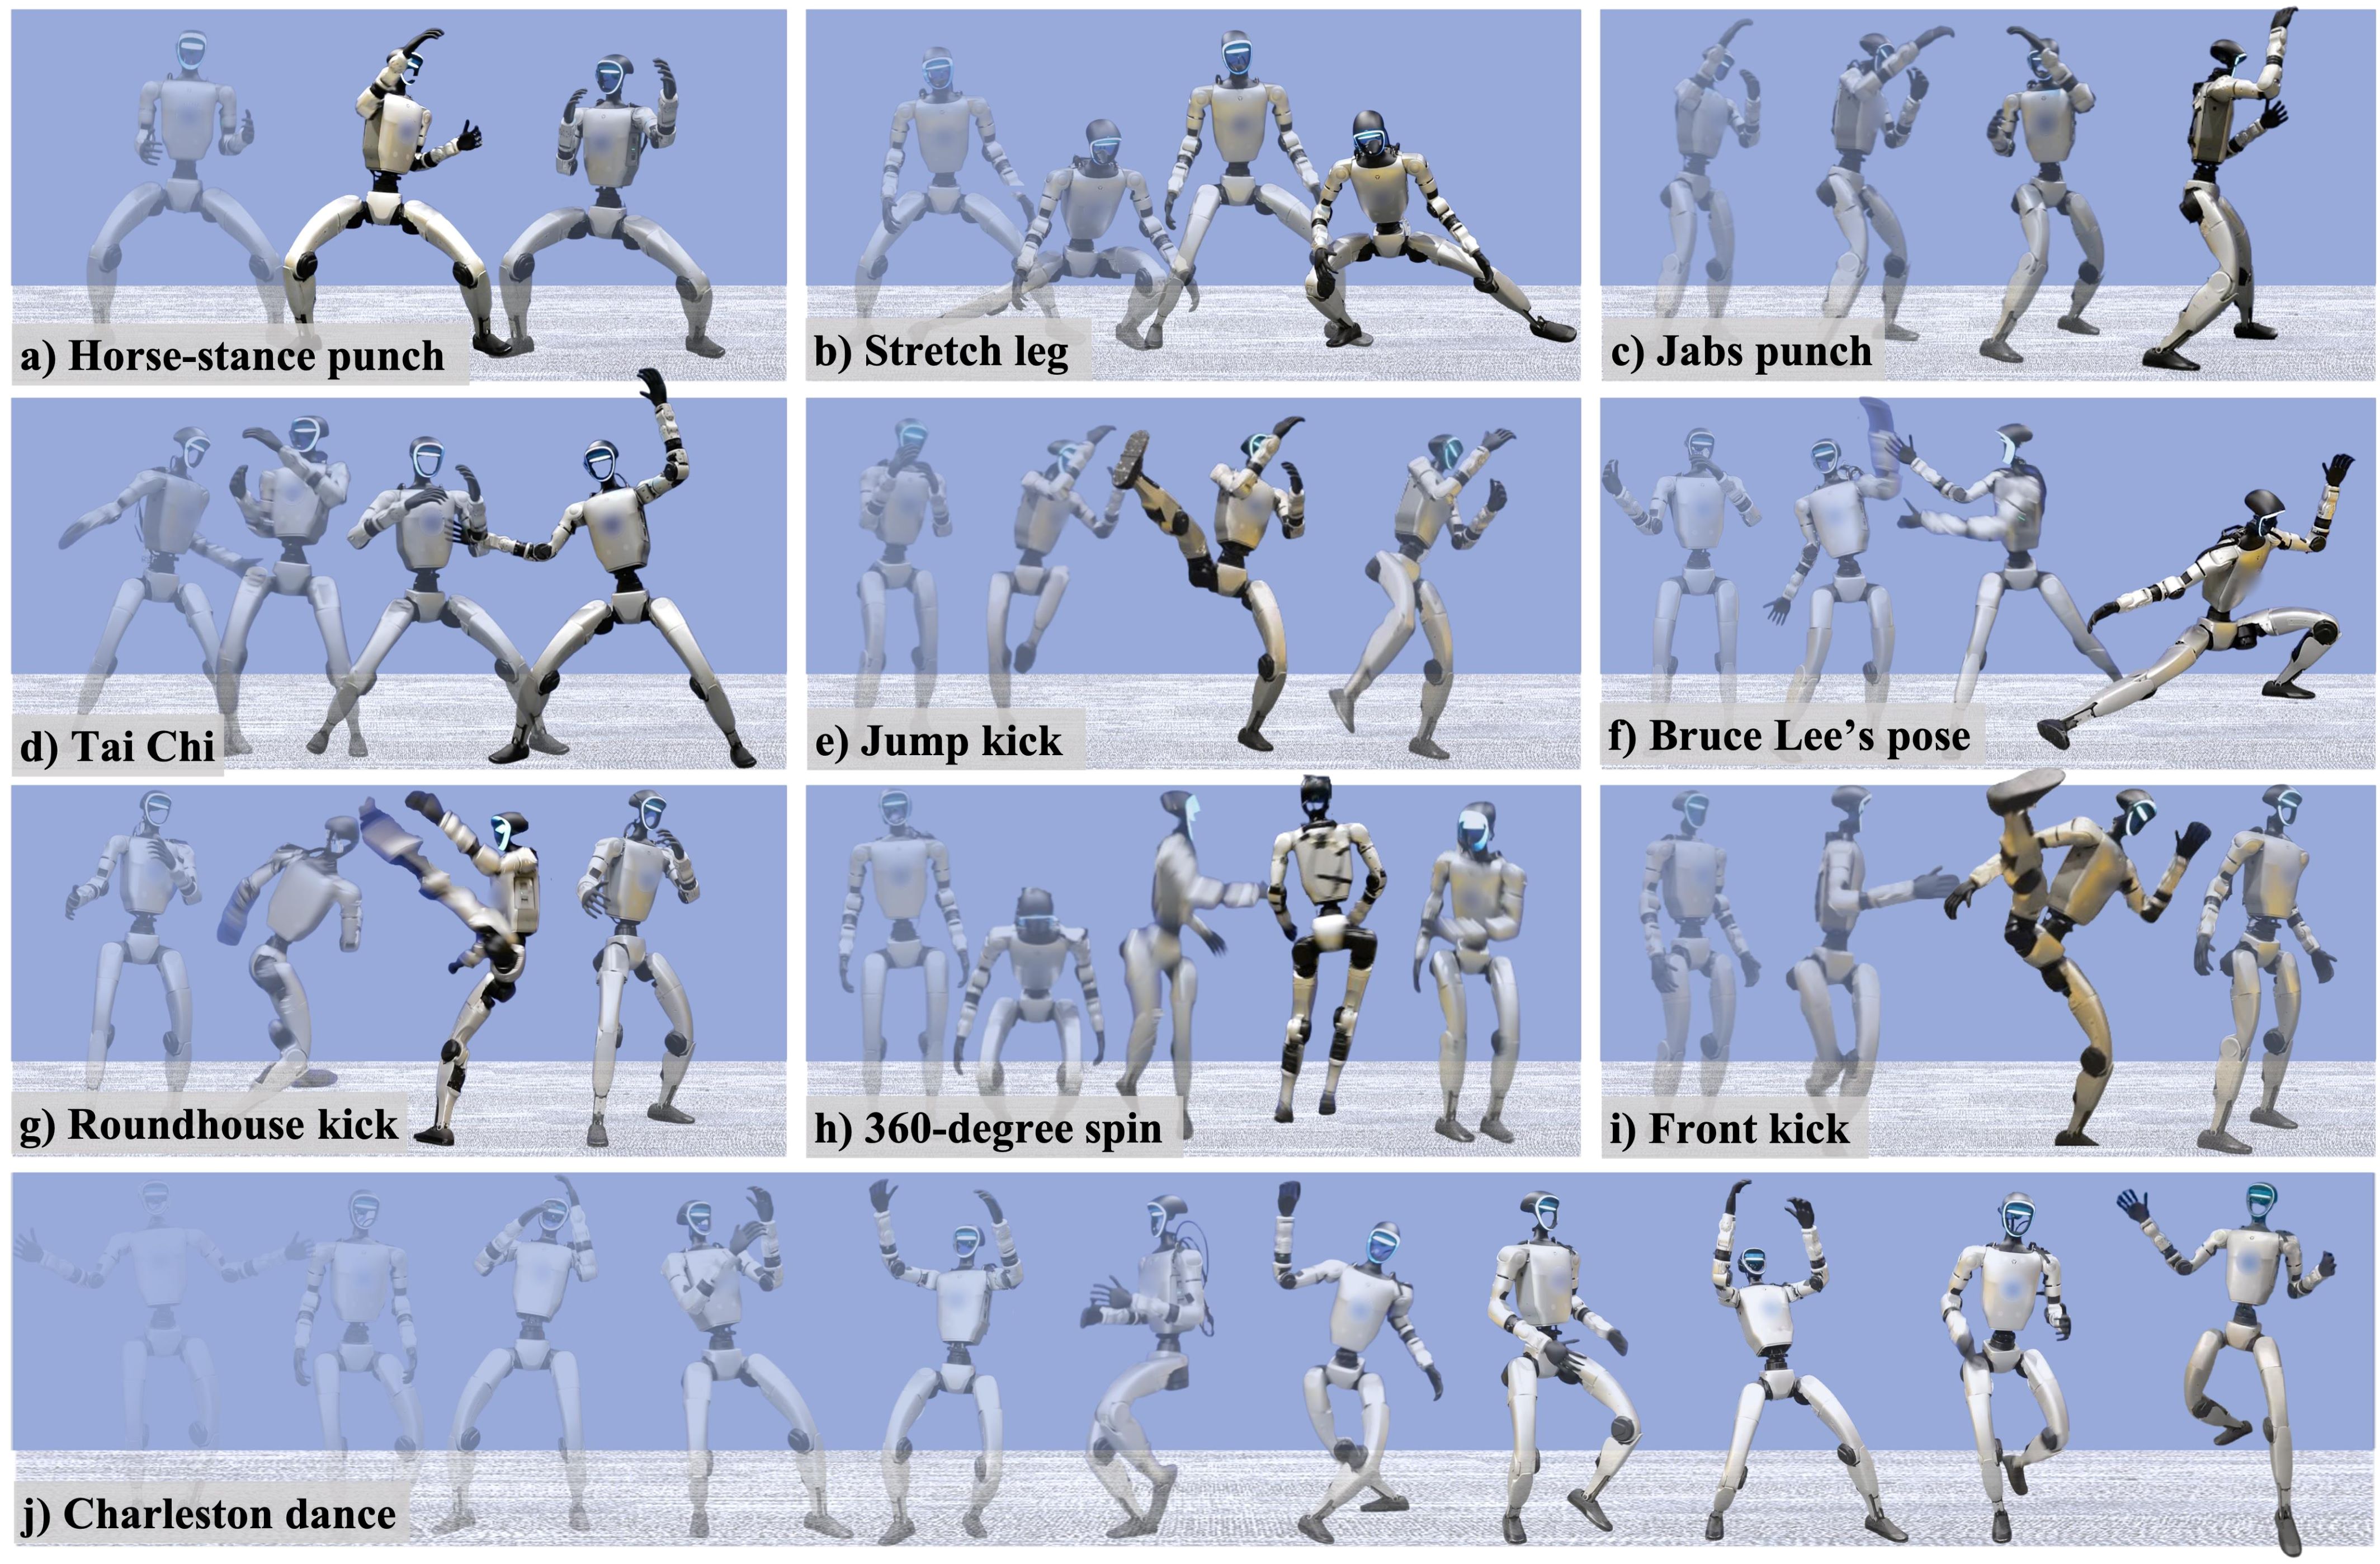
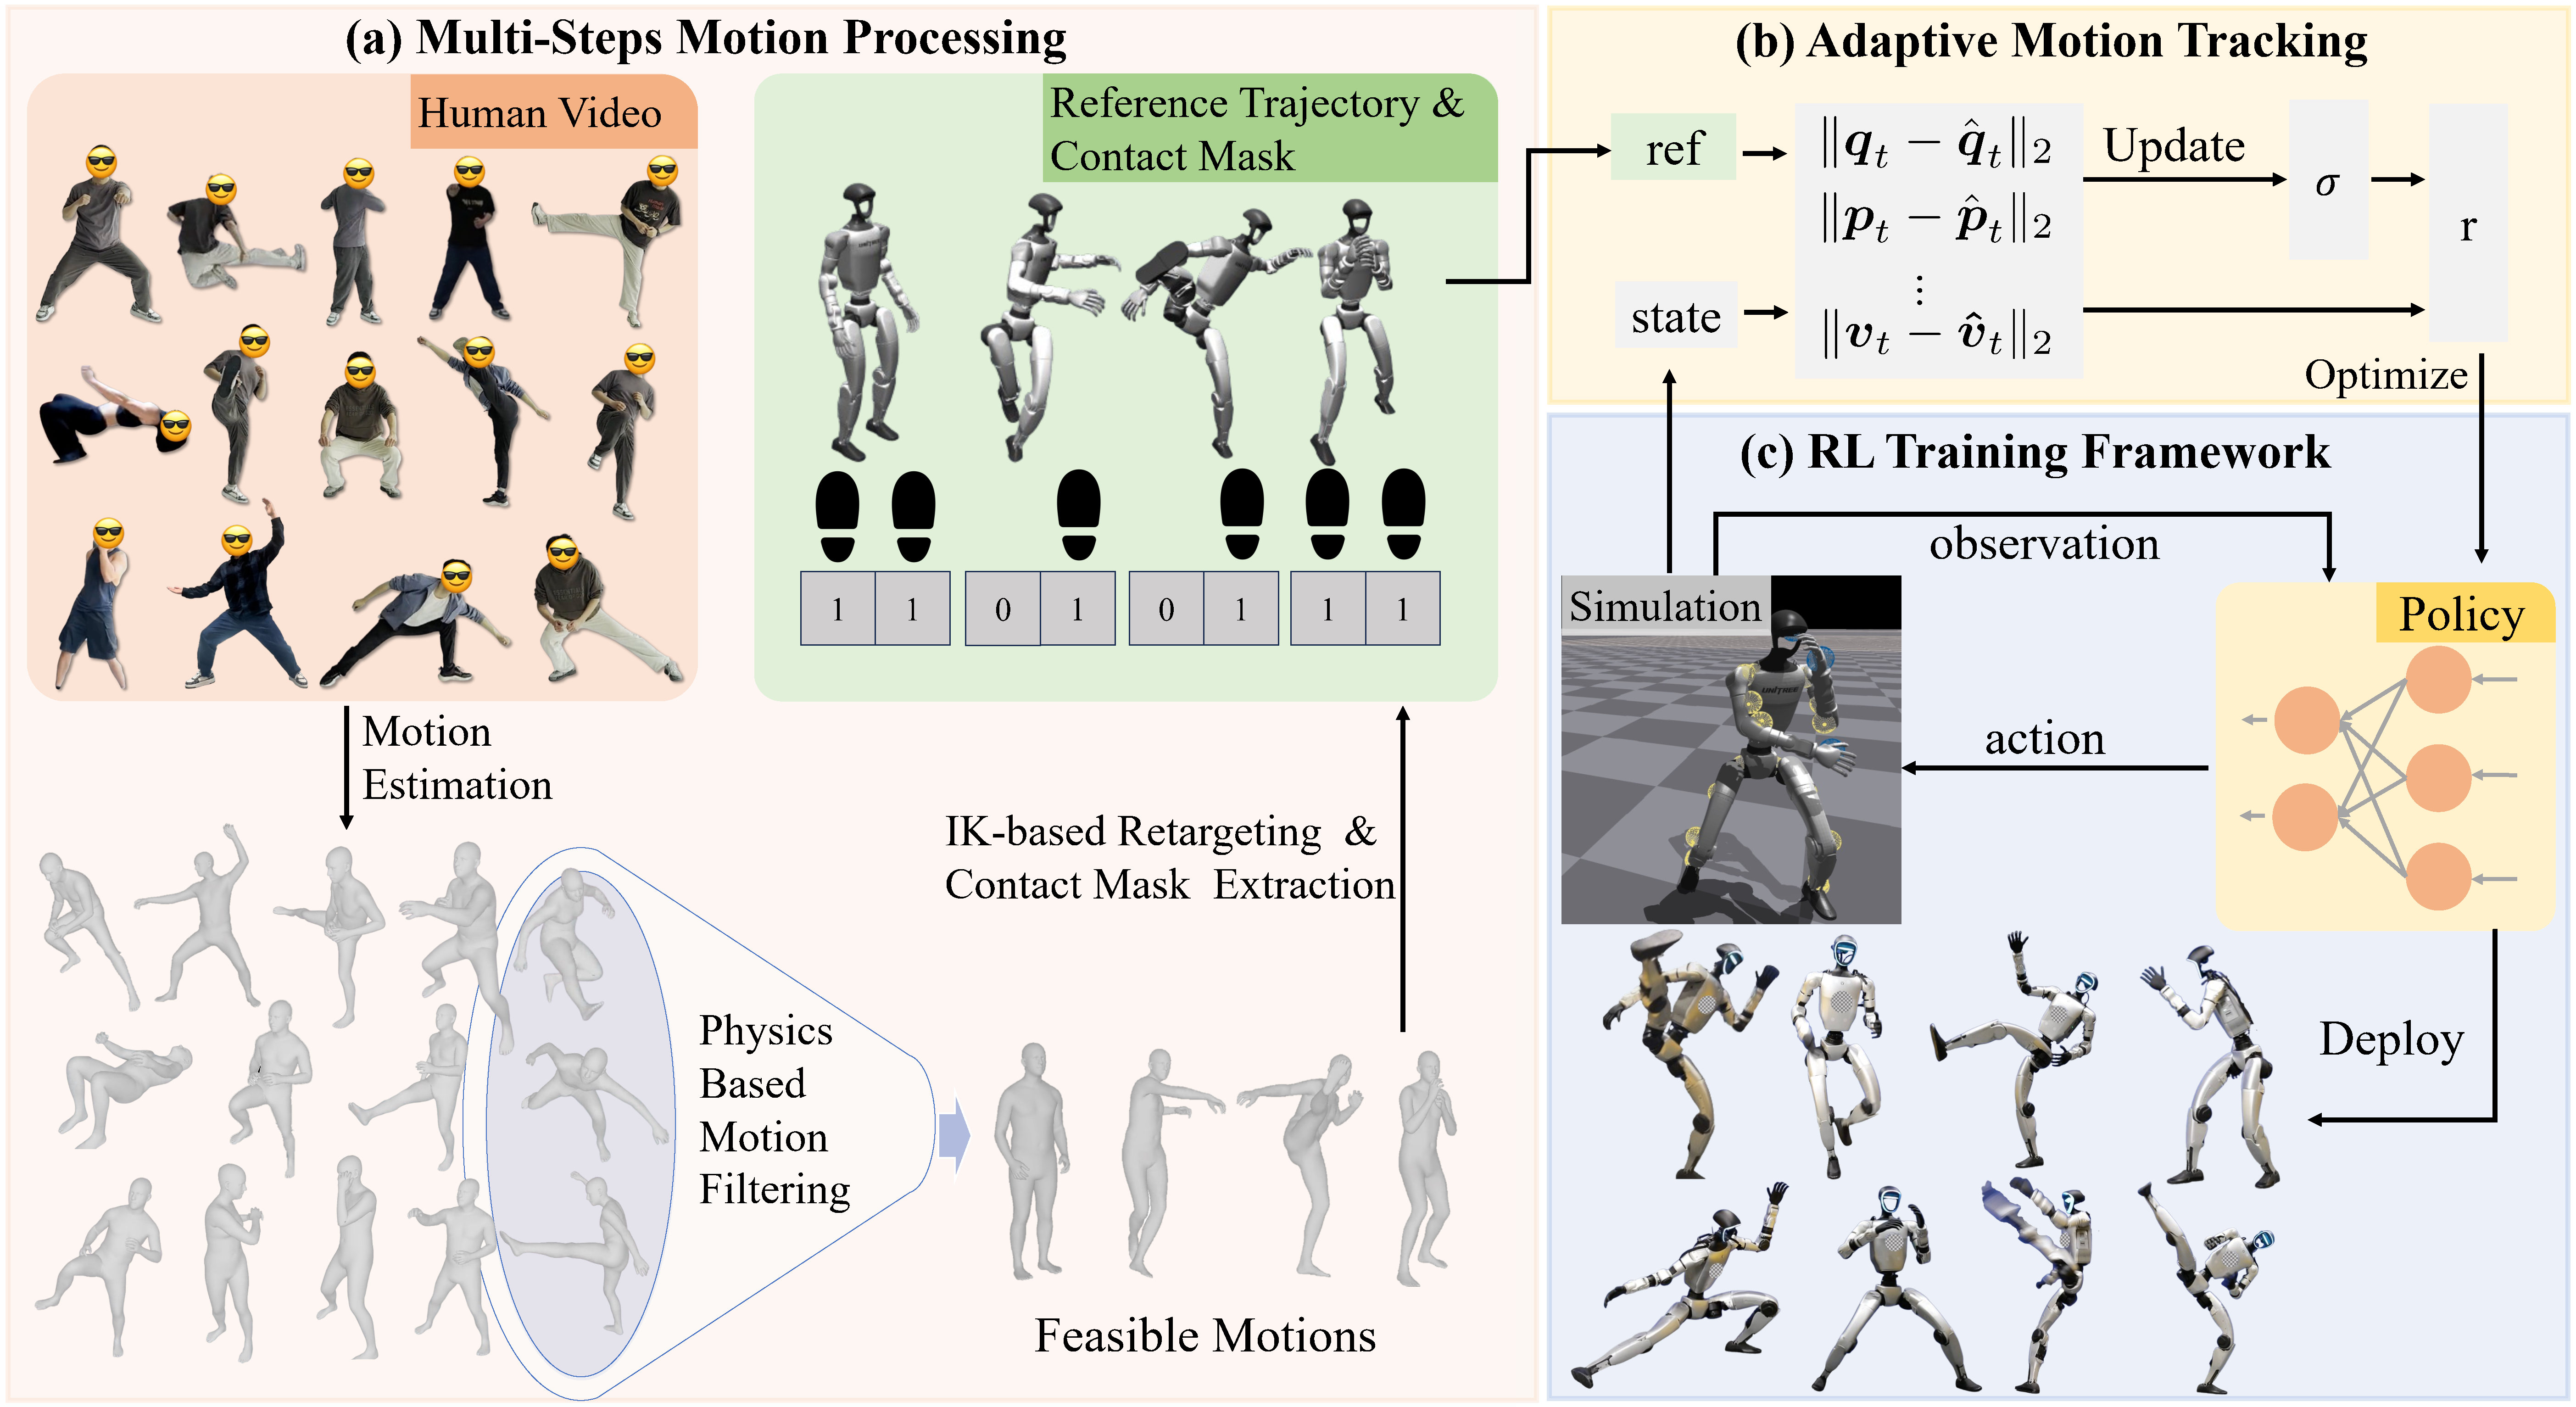
This is the official implementation of the paper KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills, supporting general motion tracking of the paper KungfuBot2: Learning Versatile Motion Skills for Humanoid Whole-Body Control.
Our paper introduces a physics-based control framework that enables humanoid robots to learn and reproduce challenging motions through multi-stage motion processing and adaptive policy training.
This repository includes:
motion_source/)smpl_retarget/)smpl_vis/, robot_motion_process/)humanoidverse/)
example/)
example/motion_data/, you can visualize the motion data with tools in robot_motion_process/)example/pretrained_hors_stance_pose/)Refer to INSTALL.md for environment setup and installation instructions.
Each module folder (e.g., humanoidverse, smpl_retarget) contains a dedicated README.md explaining its purpose and usage.
How to let your robot perform a new motion?
motion_source/).smpl_retarget/, choose Mink or PHC pipeline as you like).smpl_vis/, robot_motion_process/).humanoidverse/).humanoidverse/).description: provide description file for SMPL and G1 robot.motion_source: docs for getting SMPL format data.smpl_retarget: tools for SMPL to G1 robot retargeting.smpl_vis: tools for visualizing SMPL format data.robot_motion_process: tools for processing robot format motion. Including visualization, interpolation, and trajectory analysis.humanoidverse: training RL policyexample: example motion and ckpt for using PBHCIf you find our work helpful, please cite:
@article{xie2025kungfubot,
  title={KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills},
  author={Xie, Weiji and Han, Jinrui and Zheng, Jiakun and Li, Huanyu and Liu, Xinzhe and Shi, Jiyuan and Zhang, Weinan and Bai, Chenjia and Li, Xuelong},
  journal={Advances in Neural Information Processing Systems},
  year={2025}
}

@article{han2025kungfubot2,
  title={KungfuBot2: Learning Versatile Motion Skills for Humanoid Whole-Body Control},
  author={Han, Jinrui and Xie, Weiji and Zheng, Jiakun and Shi, Jiyuan and Zhang, Weinan and Xiao, Ting and Bai, Chenjia},
  journal={arXiv preprint arXiv:2509.16638},
  year={2025}
}
This codebase is under CC BY-NC 4.0 license. You may not use the material for commercial purposes, e.g., to make demos to advertise your commercial products.
ASAP library to build our RL codebase.Beyondmimic features into policy training.rsl_rl library for the PPO implementation.Unitree G1 as our testbed robot.Maskedmimic, which based on Mink.PHC into our implementation.GVHMR to extract motions from videos.IPMAN codebase.Feel free to open an issue or discussion if you encounter any problems or have questions about this project.
For collaborations, feedback, or further inquiries, please reach out to:
shisoulBw_rooneYWe welcome contributions and are happy to support the community in building upon this work!
578 followers · starred Apr 2026
1,826 followers · starred Jun 2025
Official Implementation of "KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills"
See the code
Weiji Xie* 1,2,
Jinrui Han* 1,2,
Jiakun Zheng* 1,3,
Huanyu Li1,4,
Xinzhe Liu1,5,
Jiyuan Shi1,
Weinan Zhang2,
Chenjia Bai†1,
Xuelong Li1
* Equal Contribution † Corresponding Author
1Institute of Artificial Intelligence (TeleAI), China Telecom
2Shanghai Jiao Tong University
3East China University of Science and Technology
4Harbin Institute of Technology
5ShanghaiTech University
Jinrui Han 1,2,
Weiji Xie 1,2,
Jiakun Zheng 1,3,
Jiyuan Shi1,
Weinan Zhang2,
Ting Xiao2,
Chenjia Bai†1,
† Corresponding Author
1Institute of Artificial Intelligence (TeleAI), China Telecom
2Shanghai Jiao Tong University
3East China University of Science and Technology
This is the official implementation of the paper KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills, supporting general motion tracking of the paper KungfuBot2: Learning Versatile Motion Skills for Humanoid Whole-Body Control.
Our paper introduces a physics-based control framework that enables humanoid robots to learn and reproduce challenging motions through multi-stage motion processing and adaptive policy training.
This repository includes:
motion_source/)smpl_retarget/)smpl_vis/, robot_motion_process/)humanoidverse/)
example/)
example/motion_data/, you can visualize the motion data with tools in robot_motion_process/)example/pretrained_hors_stance_pose/)Refer to INSTALL.md for environment setup and installation instructions.
Each module folder (e.g., humanoidverse, smpl_retarget) contains a dedicated README.md explaining its purpose and usage.
How to let your robot perform a new motion?
motion_source/).smpl_retarget/, choose Mink or PHC pipeline as you like).smpl_vis/, robot_motion_process/).humanoidverse/).humanoidverse/).description: provide description file for SMPL and G1 robot.motion_source: docs for getting SMPL format data.smpl_retarget: tools for SMPL to G1 robot retargeting.smpl_vis: tools for visualizing SMPL format data.robot_motion_process: tools for processing robot format motion. Including visualization, interpolation, and trajectory analysis.humanoidverse: training RL policyexample: example motion and ckpt for using PBHCIf you find our work helpful, please cite:
@article{xie2025kungfubot,
  title={KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills},
  author={Xie, Weiji and Han, Jinrui and Zheng, Jiakun and Li, Huanyu and Liu, Xinzhe and Shi, Jiyuan and Zhang, Weinan and Bai, Chenjia and Li, Xuelong},
  journal={Advances in Neural Information Processing Systems},
  year={2025}
}

@article{han2025kungfubot2,
  title={KungfuBot2: Learning Versatile Motion Skills for Humanoid Whole-Body Control},
  author={Han, Jinrui and Xie, Weiji and Zheng, Jiakun and Shi, Jiyuan and Zhang, Weinan and Xiao, Ting and Bai, Chenjia},
  journal={arXiv preprint arXiv:2509.16638},
  year={2025}
}
This codebase is under CC BY-NC 4.0 license. You may not use the material for commercial purposes, e.g., to make demos to advertise your commercial products.
ASAP library to build our RL codebase.Beyondmimic features into policy training.rsl_rl library for the PPO implementation.Unitree G1 as our testbed robot.Maskedmimic, which based on Mink.PHC into our implementation.GVHMR to extract motions from videos.IPMAN codebase.Feel free to open an issue or discussion if you encounter any problems or have questions about this project.
For collaborations, feedback, or further inquiries, please reach out to:
shisoulBw_rooneYWe welcome contributions and are happy to support the community in building upon this work!
578 followers · starred Apr 2026
1,826 followers · starred Jun 2025



