An open-source, hands-on mobile robotics course covering Jetson, ROS 2, AI perception, SLAM, autonomous navigation, semantic understanding, and robotic manipulation.
Python
48
49 commits
updated Oct 12, 2026
Build a complete mobile robotics development loop from sensor integration, AI perception, SLAM, and autonomous navigation to semantic understanding, active vision, and robotic grasping.


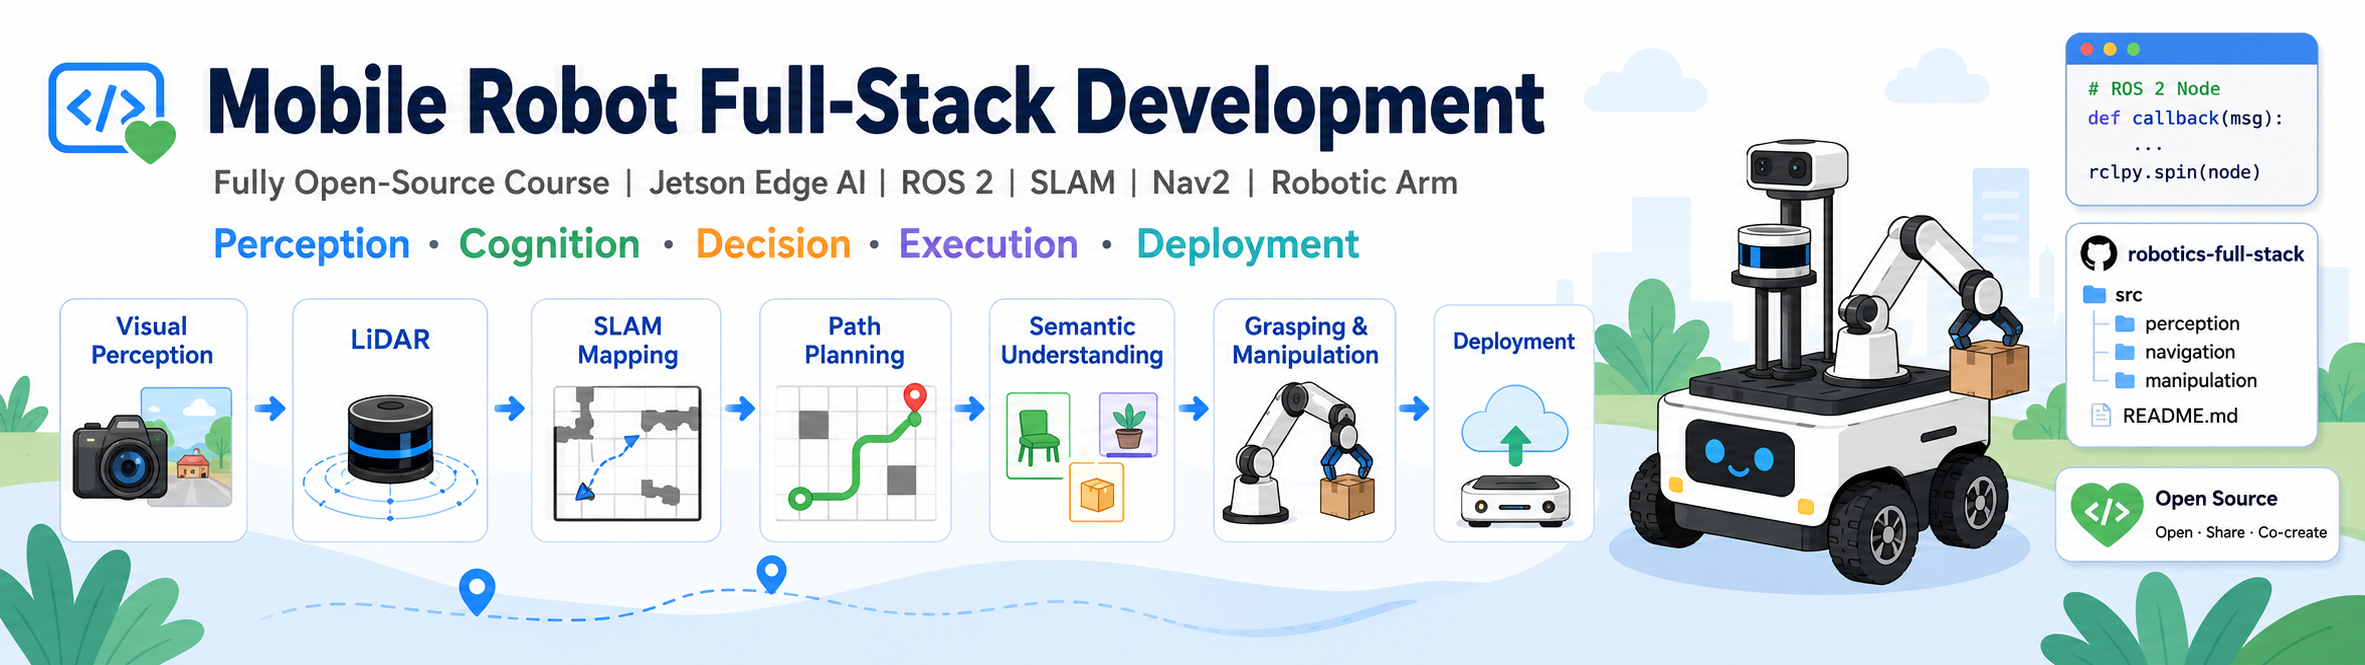
This project is an open-source hands-on course for robotics developers, AI engineers, and university students. It uses Seeed Studio reComputer J501 (Jetson AGX Orin 32GB/64GB) as the core compute platform and covers:
Perception -> Cognition -> Decision -> Actuation -> Deployment
The course emphasizes system integration on real robots rather than explaining only a single algorithm in isolation. The content will be opened progressively. If you are interested in this project, Star it and contribute with us.
flowchart LR
    M1[M1 Platform and Environment]
    M2[M2 Vision System]
    M3[M3 Multi-Sensor Fusion]
    M4[M4 AI Perception]
    M5[M5 SLAM and Reconstruction]
    M6[M6 Autonomous Navigation]
    M7[M7 Semantic Navigation]
    M8[M8 Active Vision]
    M9[M9 Robotic Arm Manipulation]
    M10[M10 Integrated Projects]
    M11[M11 Engineering Deployment]

    M1 --> M2
    M1 --> M3
    M2 --> M4
    M2 --> M5
    M3 --> M5
    M5 --> M6
    M4 --> M7
    M6 --> M7
    M4 --> M8
    M6 --> M8
    M4 --> M9
    M7 --> M10
    M8 --> M10
    M9 --> M10
    M10 --> M11
The course is planned as 11 modules, about 43 class hours in total. Starting from July 22, 2026, the plan is to complete one module every two weeks. If there are no major changes, all modules are planned to be completed before December 22, 2026.
| Module | Theme | Main Content | Planned Window |
|---|---|---|---|
| M1 | Platform Introduction and Development Environment | J501, JetPack, Docker, ROS 2 | ✅ Completed |
| M2 | Vision System Foundations | CSI, GMSL2, RGB-D, calibration, BEV | ✅ Completed |
| M3 | LiDAR and Sensor Fusion | LiDAR, IMU, GNSS, CAN-FD, PTP, EKF | ✅ Completed |
| M4 | AI Vision and Edge Acceleration | YOLO, tracking, segmentation, 6D pose, Isaac ROS | ✅ Completed |
| M5 | 3D Reconstruction and SLAM | ORB-SLAM3, Fast-LIO, R3LIVE, 3DGS, semantic maps | ⏳ Planned 10-02 |
| M6 | Localization, Navigation, and Path Planning | Nav2, planning, dynamic obstacle avoidance, multi-robot collaboration | ⏳ Planned |
| M7 | VLN Semantic Navigation | instruction parsing, topological maps, semantic landmarks | ⏳ Planned |
| M8 | PTZ and Active Vision | PTZ control, target tracking, chassis coordination | ⏳ Planned |
| M9 | Robotic Arm and Manipulation | MoveIt 2, Pinocchio, hand-eye calibration, GraspNet | ⏳ Planned |
| M10 | Integrated Projects | inspection, BEV+3DGS, VLN, semantic grasping | ⏳ Planned |
| M11 | Deployment Optimization and Engineering | ONNX, TensorRT, DeepStream, monitoring, OTA | ⏳ Planned |
The progress status will be updated to
✅ Completedafter each module is released, together with the corresponding documentation, code, configurations, test results, and demo videos.
| Category | Recommended Configuration |
|---|---|
| Main Controller | reComputer Robotics J5012 |
| Vision | CSI / GMSL2 / RGB-D cameras |
| Localization | LiDAR, IMU, GNSS |
| Actuation | Mobile chassis, 2-axis PTZ, reBot or compatible robotic arm |
| Bus | CAN-FD, UART, Ethernet |
| Power | Mobile robot power supply system |
You do not need to purchase all hardware at once. Early modules can be completed with only the J501 and a single camera. Navigation- and robotic-arm-related hardware can be added gradually later.
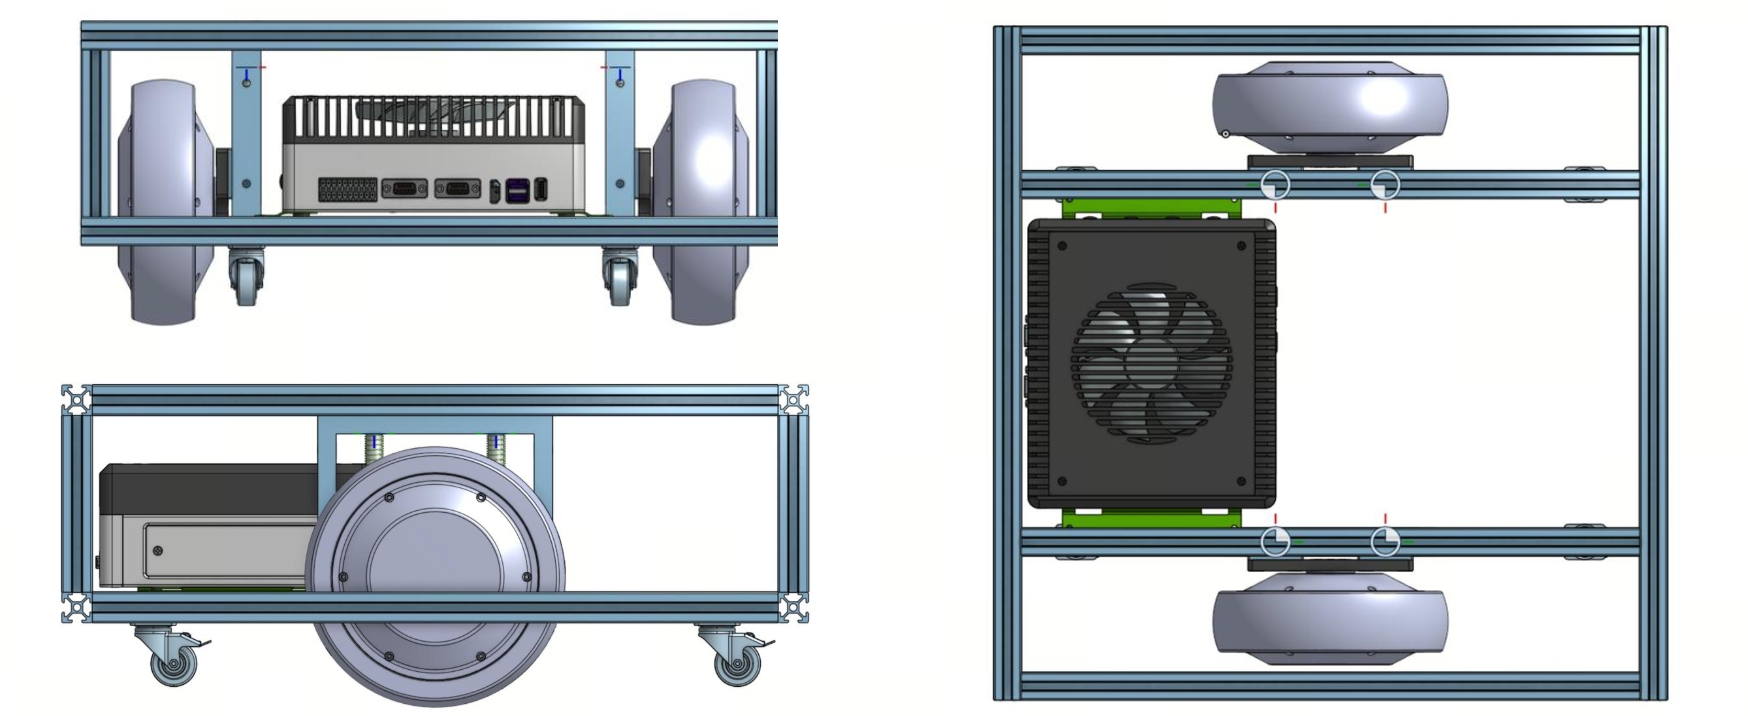
The repository includes an installable DM-H65 two-wheel chassis Python SDK with SocketCAN communication, differential-drive control, CLI diagnostics, Jetson services, and a remote debugging WebUI. This integration is Python-only; no C++ implementation is included.
mobile-robot-full-stack-course/
├── hardware/             # Hardware-related files
├── docs/                 # Course documentation
├── modules/              # Per-module course code
├── projects/             # Integrated projects
├── robot_drivers/        # Mobile chassis Python drivers and WebUI
├── assets/               # Images and videos
├── README.md
├── README_CN.md
├── CONTRIBUTING.md
└── LICENSE
Suitable for:
Basic knowledge of Linux, Python, Git, and linear algebra is recommended. ROS 2, Docker, and Jetson basics will be introduced in the course.
This project will be released in a fully open-source manner. All self-developed course content will be made public, including:
The specific license terms will be defined in the root LICENSE file and in any subdirectory-specific license notes. Code, documentation, data, and hardware design files may use different open-source licenses depending on content type.
Robotic systems involve batteries, motors, robotic arms, and high-speed moving parts. Before operating real hardware, make sure to:
This course will use or reference open-source projects including ROS 2, NVIDIA Jetson, Isaac ROS, Nav2, MoveIt 2, OpenCV, PyTorch, Open3D, ORB-SLAM3, Fast-LIO, LIO-SAM, 3D Gaussian Splatting, GraspNet, and LeRobot.
From “seeing” to “understanding,” from “autonomous mobility” to “autonomous manipulation.”
Star, Watch, Fork, and contribute.
An open-source, hands-on mobile robotics course covering Jetson, ROS 2, AI perception, SLAM, autonomous navigation, semantic understanding, and robotic manipulation.
Python
48
49 commits
updated Oct 12, 2026
Build a complete mobile robotics development loop from sensor integration, AI perception, SLAM, and autonomous navigation to semantic understanding, active vision, and robotic grasping.
This project is an open-source hands-on course for robotics developers, AI engineers, and university students. It uses Seeed Studio reComputer J501 (Jetson AGX Orin 32GB/64GB) as the core compute platform and covers:
Perception -> Cognition -> Decision -> Actuation -> Deployment
The course emphasizes system integration on real robots rather than explaining only a single algorithm in isolation. The content will be opened progressively. If you are interested in this project, Star it and contribute with us.
flowchart LR
    M1[M1 Platform and Environment]
    M2[M2 Vision System]
    M3[M3 Multi-Sensor Fusion]
    M4[M4 AI Perception]
    M5[M5 SLAM and Reconstruction]
    M6[M6 Autonomous Navigation]
    M7[M7 Semantic Navigation]
    M8[M8 Active Vision]
    M9[M9 Robotic Arm Manipulation]
    M10[M10 Integrated Projects]
    M11[M11 Engineering Deployment]

    M1 --> M2
    M1 --> M3
    M2 --> M4
    M2 --> M5
    M3 --> M5
    M5 --> M6
    M4 --> M7
    M6 --> M7
    M4 --> M8
    M6 --> M8
    M4 --> M9
    M7 --> M10
    M8 --> M10
    M9 --> M10
    M10 --> M11
The course is planned as 11 modules, about 43 class hours in total. Starting from July 22, 2026, the plan is to complete one module every two weeks. If there are no major changes, all modules are planned to be completed before December 22, 2026.
| Module | Theme | Main Content | Planned Window |
|---|---|---|---|
| M1 | Platform Introduction and Development Environment | J501, JetPack, Docker, ROS 2 | ✅ Completed |
| M2 | Vision System Foundations | CSI, GMSL2, RGB-D, calibration, BEV | ✅ Completed |
| M3 | LiDAR and Sensor Fusion | LiDAR, IMU, GNSS, CAN-FD, PTP, EKF | ✅ Completed |
| M4 | AI Vision and Edge Acceleration | YOLO, tracking, segmentation, 6D pose, Isaac ROS | ✅ Completed |
| M5 | 3D Reconstruction and SLAM | ORB-SLAM3, Fast-LIO, R3LIVE, 3DGS, semantic maps | ⏳ Planned 10-02 |
| M6 | Localization, Navigation, and Path Planning | Nav2, planning, dynamic obstacle avoidance, multi-robot collaboration | ⏳ Planned |
| M7 | VLN Semantic Navigation | instruction parsing, topological maps, semantic landmarks | ⏳ Planned |
| M8 | PTZ and Active Vision | PTZ control, target tracking, chassis coordination | ⏳ Planned |
| M9 | Robotic Arm and Manipulation | MoveIt 2, Pinocchio, hand-eye calibration, GraspNet | ⏳ Planned |
| M10 | Integrated Projects | inspection, BEV+3DGS, VLN, semantic grasping | ⏳ Planned |
| M11 | Deployment Optimization and Engineering | ONNX, TensorRT, DeepStream, monitoring, OTA | ⏳ Planned |
The progress status will be updated to
✅ Completedafter each module is released, together with the corresponding documentation, code, configurations, test results, and demo videos.
| Category | Recommended Configuration |
|---|---|
| Main Controller | reComputer Robotics J5012 |
| Vision | CSI / GMSL2 / RGB-D cameras |
| Localization | LiDAR, IMU, GNSS |
| Actuation | Mobile chassis, 2-axis PTZ, reBot or compatible robotic arm |
| Bus | CAN-FD, UART, Ethernet |
| Power | Mobile robot power supply system |
You do not need to purchase all hardware at once. Early modules can be completed with only the J501 and a single camera. Navigation- and robotic-arm-related hardware can be added gradually later.
The repository includes an installable DM-H65 two-wheel chassis Python SDK with SocketCAN communication, differential-drive control, CLI diagnostics, Jetson services, and a remote debugging WebUI. This integration is Python-only; no C++ implementation is included.
mobile-robot-full-stack-course/
├── hardware/             # Hardware-related files
├── docs/                 # Course documentation
├── modules/              # Per-module course code
├── projects/             # Integrated projects
├── robot_drivers/        # Mobile chassis Python drivers and WebUI
├── assets/               # Images and videos
├── README.md
├── README_CN.md
├── CONTRIBUTING.md
└── LICENSE
Suitable for:
Basic knowledge of Linux, Python, Git, and linear algebra is recommended. ROS 2, Docker, and Jetson basics will be introduced in the course.
This project will be released in a fully open-source manner. All self-developed course content will be made public, including:
The specific license terms will be defined in the root LICENSE file and in any subdirectory-specific license notes. Code, documentation, data, and hardware design files may use different open-source licenses depending on content type.
Robotic systems involve batteries, motors, robotic arms, and high-speed moving parts. Before operating real hardware, make sure to:
This course will use or reference open-source projects including ROS 2, NVIDIA Jetson, Isaac ROS, Nav2, MoveIt 2, OpenCV, PyTorch, Open3D, ORB-SLAM3, Fast-LIO, LIO-SAM, 3D Gaussian Splatting, GraspNet, and LeRobot.
From “seeing” to “understanding,” from “autonomous mobility” to “autonomous manipulation.”
Star, Watch, Fork, and contribute.



