Extension and update of M2DGR: a novel Multi-modal and Multi-scenario SLAM Dataset for Ground Robots (ICRA2022 & ICRA2024)
211
86 commits
updated Aug 8, 2026
First Author: Jie Yin 殷杰 📝 [Paper] / [Arxiv] 🎯 [M2DGR Dataset] ⭐️ [Presentation Video] 🔥[News]




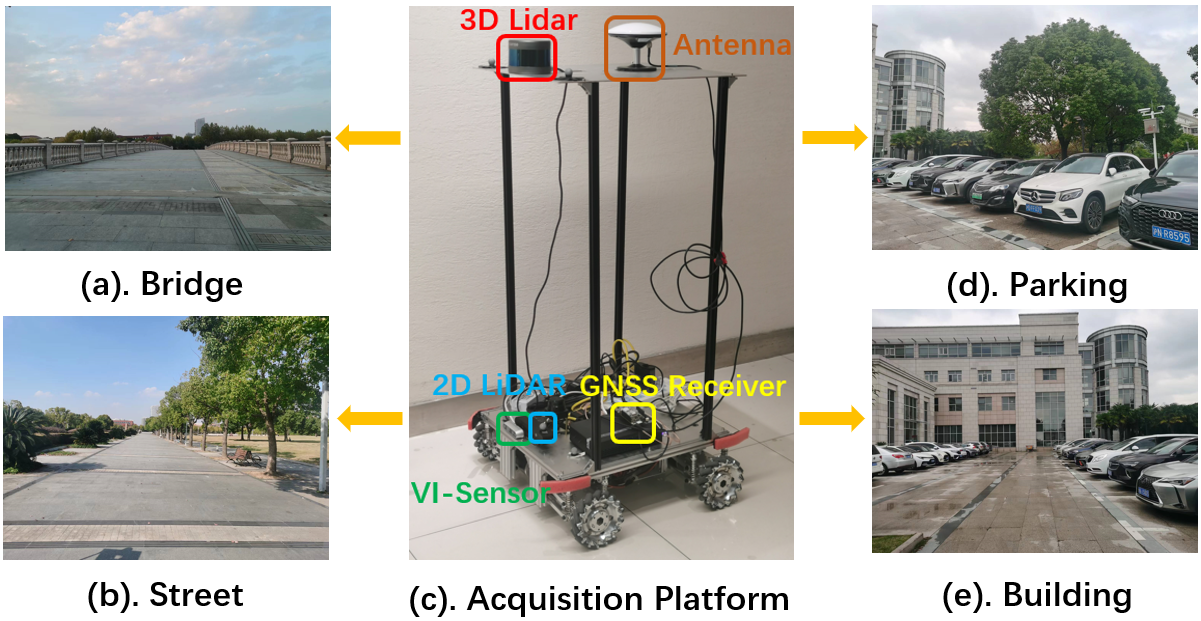
Figure 1. Acquisition Platform and Diverse Scenarios.
🔥2024/10/11: Introducing M2DGR-benchmark, benchmarking newest SOTA LiDAR-visual SLAM alrogithms on both M2DGR and M2DGR-plus!
2024/07/15: Introducing a list of LiDAR-Visual SLAM systems at awesome-LiDAR-Visual-SLAM, wheel-based SLAM systems at awesome-wheel-slam, and Isaac Sim resources at awesome-isaac-sim (keep updating)
This work is licensed under GPL-3.0 license. International License and is provided for academic purpose. If you are interested in our project for commercial purposes, please contact us on [email protected] for further communication.
If you use this work in an academic work, please cite:
@article{yin2021m2dgr,
  title={M2dgr: A multi-sensor and multi-scenario slam dataset for ground robots},
  author={Yin, Jie and Li, Ang and Li, Tao and Yu, Wenxian and Zou, Danping},
  journal={IEEE Robotics and Automation Letters},
  volume={7},
  number={2},
  pages={2266--2273},
  year={2021},
  publisher={IEEE}
}

@INPROCEEDINGS{yin2024ground,
  author={Yin, Jie and Li, Ang and Xi, Wei and Yu, Wenxian and Zou, Danping},
  booktitle={2024 IEEE International Conference on Robotics and Automation (ICRA)},
  title={Ground-Fusion: A Low-cost Ground SLAM System Robust to Corner Cases},
  year={2024},
  volume={},
  number={},
  pages={8603-8609},
  keywords={Location awareness;Visualization;Simultaneous localization and mapping;Accuracy;Wheels;Sensor fusion;Land vehicles},
  doi={10.1109/ICRA57147.2024.10610070}}
The calibration results are here. All the sensors and track devices and their most important parameters are listed as below:
The rostopics of our rosbag sequences are listed as follows:
3D LIDAR: /rslidar_points
2D LIDAR: /scan
Odom: /odom
GNSS Ublox F9p:
/ublox_driver/ephem ,
/ublox_driver/glo_ephem ,
/ublox_driver/range_meas ,
/ublox_driver/receiver_lla ,
/ublox_driver/receiver_pvt
V-I Sensor:
/camera/color/image_raw,
/camera/imu
IMU: /imu
[!TIP] We are delighted to see that many users enjoy our M2DGR-plus dataset. However, due to an overwhelming number of download requests, OneDrive has become unstable. If you encounter any issues, please wait for about 10 minutes and try again.
| Sequence Name | Collection Date | Total Size | Duration | Features | Rosbag |
|---|---|---|---|---|---|
| Anomaly | 2023-8 | 1.5g | 57s | wheel anomaly | Rosbag |
| Switch | 2023-8 | 9.5g | 292s | indoor-outdoor switch | Rosbag |
| Tree | 2023-8 | 3.7g | 160s | Dense tree leave cover | Rosbag |
| Bridge_01 | 2022-11 | 2.4g | 75s | Bridge, Zigzag | Rosbag |
| Bridge_02 | 2022-11 | 16.0g | 501s | Bridge, Long-term,Straight line | Rosbag |
| Street_01 | 2022-11 | 1.7g | 58s | Street, Straight line | Rosbag |
| Street_02 | 2022-11 | 3.9g | 126s | Bridge, Sharp turn | Rosbag |
| Parking_01 | 2022-11 | 3.3g | 105s | Parking lot, Side moving | Rosbag |
| Parking_02 | 2022-11 | 5.4g | 149s | Parking lot, Rectangle loop | Rosbag |
| Building_01 | 2022-11 | 3.7g | 120s | Building, Far features | Rosbag |
| Building_02 | 2022-11 | 3.4g | 110s | Building, Far features | Rosbag |
And in some cases, our Ground-Fusion achieves comparable performance to Lidar SLAM!
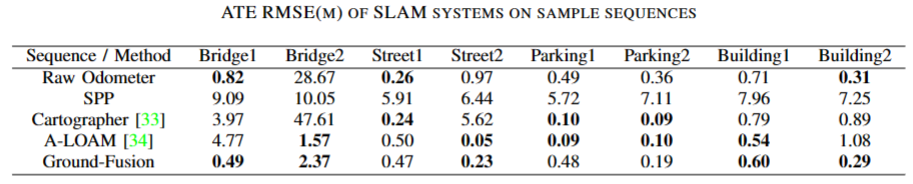
Figure 2. The ATE RMSE (m) result on some sequences.
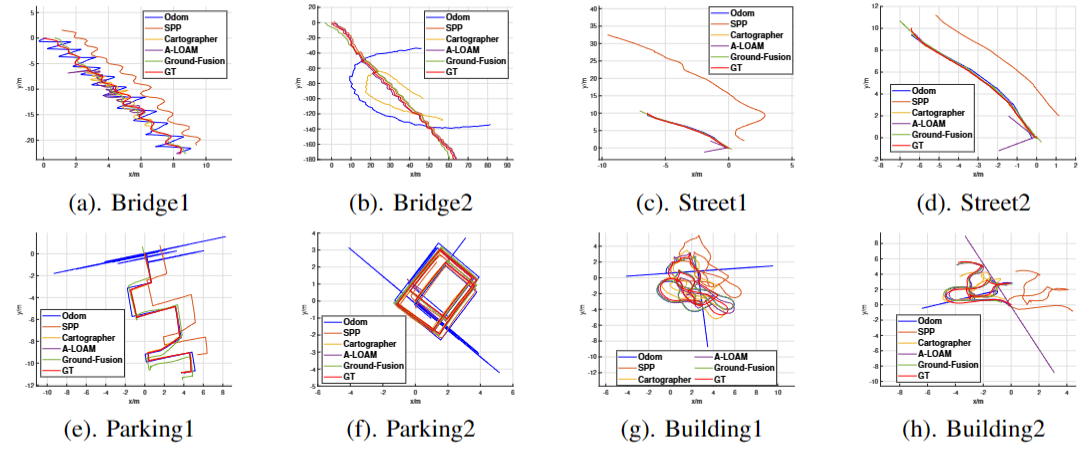
Figure 3. The visualized trajectory.
We provide configuration files for several cutting-edge baseline methods, including VINS-RGBD,TartanVO,VINS-Mono and VIW-Fusion and GVINS.
Extension and update of M2DGR: a novel Multi-modal and Multi-scenario SLAM Dataset for Ground Robots (ICRA2022 & ICRA2024)
211
86 commits
updated Aug 8, 2026
First Author: Jie Yin 殷杰 📝 [Paper] / [Arxiv] 🎯 [M2DGR Dataset] ⭐️ [Presentation Video] 🔥[News]
Figure 1. Acquisition Platform and Diverse Scenarios.
🔥2024/10/11: Introducing M2DGR-benchmark, benchmarking newest SOTA LiDAR-visual SLAM alrogithms on both M2DGR and M2DGR-plus!
2024/07/15: Introducing a list of LiDAR-Visual SLAM systems at awesome-LiDAR-Visual-SLAM, wheel-based SLAM systems at awesome-wheel-slam, and Isaac Sim resources at awesome-isaac-sim (keep updating)
This work is licensed under GPL-3.0 license. International License and is provided for academic purpose. If you are interested in our project for commercial purposes, please contact us on [email protected] for further communication.
If you use this work in an academic work, please cite:
@article{yin2021m2dgr,
  title={M2dgr: A multi-sensor and multi-scenario slam dataset for ground robots},
  author={Yin, Jie and Li, Ang and Li, Tao and Yu, Wenxian and Zou, Danping},
  journal={IEEE Robotics and Automation Letters},
  volume={7},
  number={2},
  pages={2266--2273},
  year={2021},
  publisher={IEEE}
}

@INPROCEEDINGS{yin2024ground,
  author={Yin, Jie and Li, Ang and Xi, Wei and Yu, Wenxian and Zou, Danping},
  booktitle={2024 IEEE International Conference on Robotics and Automation (ICRA)},
  title={Ground-Fusion: A Low-cost Ground SLAM System Robust to Corner Cases},
  year={2024},
  volume={},
  number={},
  pages={8603-8609},
  keywords={Location awareness;Visualization;Simultaneous localization and mapping;Accuracy;Wheels;Sensor fusion;Land vehicles},
  doi={10.1109/ICRA57147.2024.10610070}}
The calibration results are here. All the sensors and track devices and their most important parameters are listed as below:
The rostopics of our rosbag sequences are listed as follows:
3D LIDAR: /rslidar_points
2D LIDAR: /scan
Odom: /odom
GNSS Ublox F9p:
/ublox_driver/ephem ,
/ublox_driver/glo_ephem ,
/ublox_driver/range_meas ,
/ublox_driver/receiver_lla ,
/ublox_driver/receiver_pvt
V-I Sensor:
/camera/color/image_raw,
/camera/imu
IMU: /imu
[!TIP] We are delighted to see that many users enjoy our M2DGR-plus dataset. However, due to an overwhelming number of download requests, OneDrive has become unstable. If you encounter any issues, please wait for about 10 minutes and try again.
| Sequence Name | Collection Date | Total Size | Duration | Features | Rosbag |
|---|---|---|---|---|---|
| Anomaly | 2023-8 | 1.5g | 57s | wheel anomaly | Rosbag |
| Switch | 2023-8 | 9.5g | 292s | indoor-outdoor switch | Rosbag |
| Tree | 2023-8 | 3.7g | 160s | Dense tree leave cover | Rosbag |
| Bridge_01 | 2022-11 | 2.4g | 75s | Bridge, Zigzag | Rosbag |
| Bridge_02 | 2022-11 | 16.0g | 501s | Bridge, Long-term,Straight line | Rosbag |
| Street_01 | 2022-11 | 1.7g | 58s | Street, Straight line | Rosbag |
| Street_02 | 2022-11 | 3.9g | 126s | Bridge, Sharp turn | Rosbag |
| Parking_01 | 2022-11 | 3.3g | 105s | Parking lot, Side moving | Rosbag |
| Parking_02 | 2022-11 | 5.4g | 149s | Parking lot, Rectangle loop | Rosbag |
| Building_01 | 2022-11 | 3.7g | 120s | Building, Far features | Rosbag |
| Building_02 | 2022-11 | 3.4g | 110s | Building, Far features | Rosbag |
And in some cases, our Ground-Fusion achieves comparable performance to Lidar SLAM!
Figure 2. The ATE RMSE (m) result on some sequences.
Figure 3. The visualized trajectory.
We provide configuration files for several cutting-edge baseline methods, including VINS-RGBD,TartanVO,VINS-Mono and VIW-Fusion and GVINS.



