A simulation platform for versatile Embodied AI research and developments.
See the code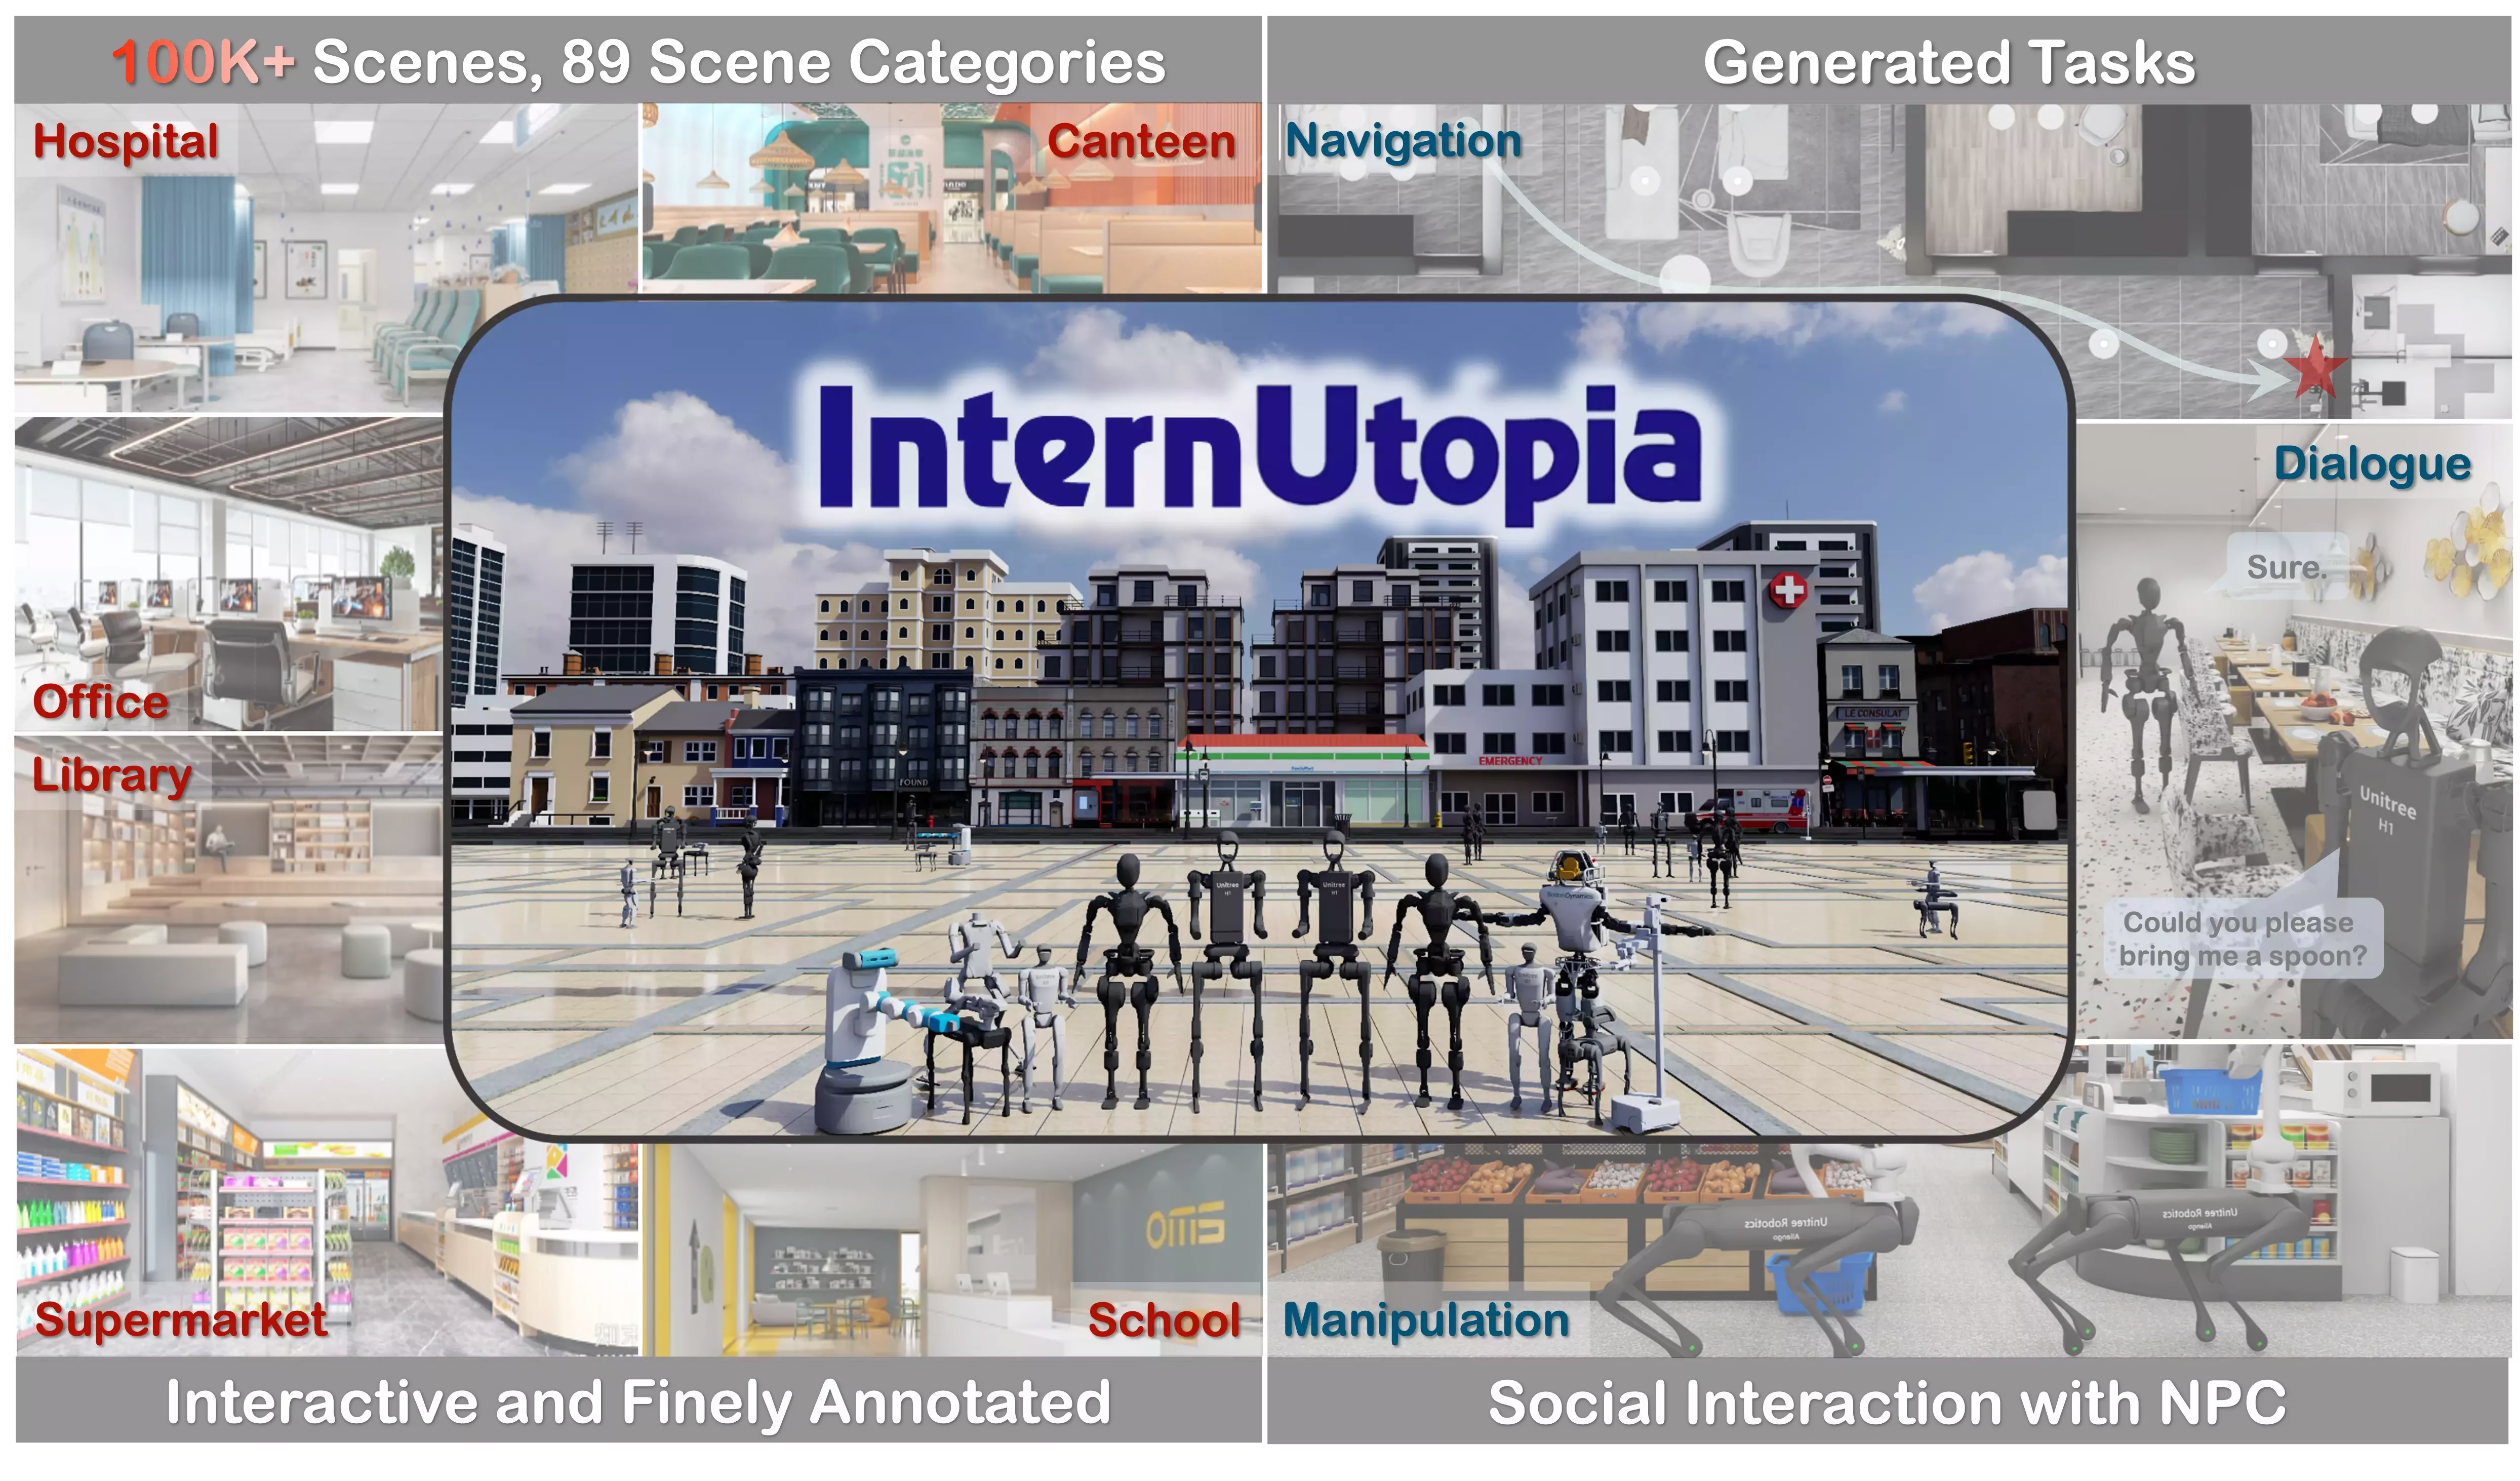


Recent works have been exploring the scaling laws in the field of Embodied AI. Given the prohibitive costs of collecting real-world data, we believe the Simulation-to-Real (Sim2Real) paradigm is a more feasible path for scaling the learning of embodied models.
We introduce project InternUtopia (aka. 桃源 in Chinese), a general-purpose research platform for embodied AGI. It features several advancements:
We hope that this work can alleviate the scarcity of high-quality data in this field and provide a more comprehensive assessment of embodied AI research.
We provide the installation guide here. You can install locally or use docker and verify the installation easily.
We provide detailed docs for the basic usage of different modules supported in InternUtopia. Welcome to try and post your suggestions!
[!NOTE] 📝First of all you MUST complete the User Agreement for GRScenes-100 Dataset Access.
Then you can choose to download all assets (~80GB) or a minimum set (~500MB) to examine installation by running the following script with InternUtopia installed:
$ python -m internutopia.download_assets
The default path to store the downloaded assets is ${PATH/TO/INTERNUTOPIA/ROOT}/internutopia/assets. Users have two ways to configure the asset path:
python -m internutopia.download_assets.python -m internutopia.set_assets_path and entering the preferred directory.If you want to separately download the GRScenes-100 scene assets, you can manually download them from OpenDataLab, ModelScope and HuggingFace. Please refer to the instructions for scene usage.
If you want to separately download robots and policy weights, you can manually download the robot directory from from OpenDataLab, ModelScope and HuggingFace and move it to the root of the asset path.
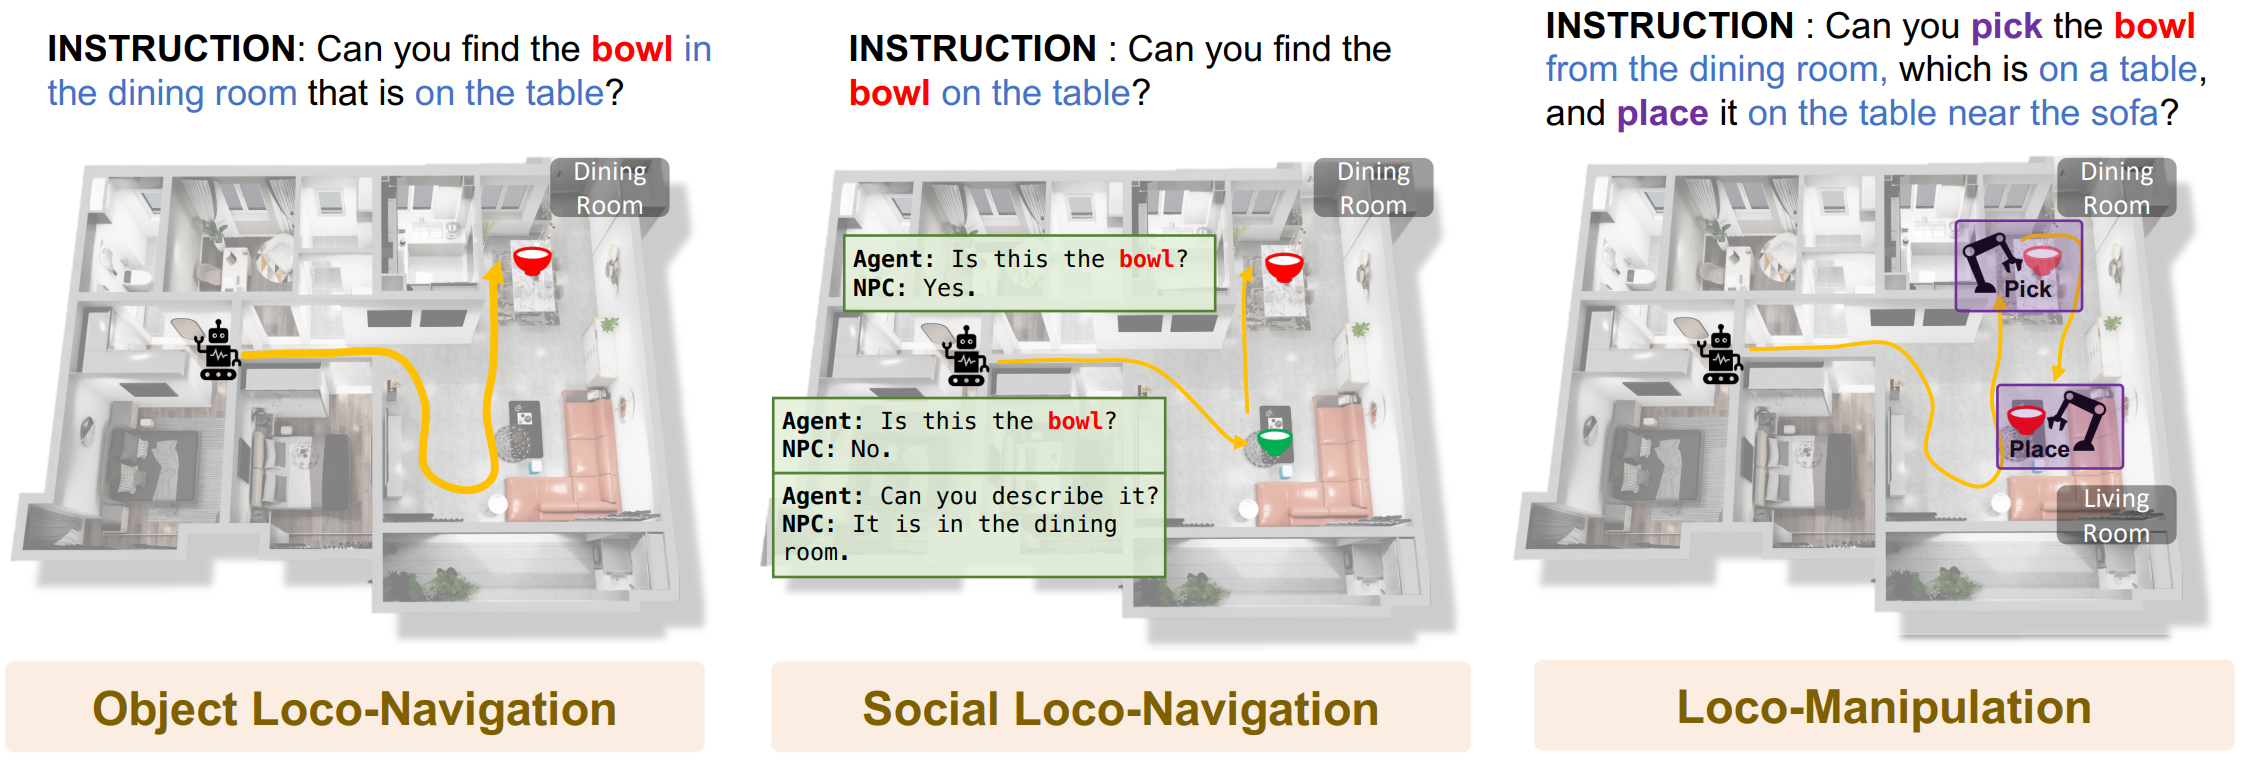
We preliminarily establish three benchmarks for evaluating the capabilities of embodied agents from different aspects: Object Loco-Navigation, Social Loco-Navigation, and Loco-Manipulation. Please refer to the InternNav and InternManip for running the benchmarks.
Join our WeChat support group or Discord for any help.
If you find our work helpful, please cite:
@inproceedings{grutopia,
    title={GRUtopia: Dream General Robots in a City at Scale},
    author={Wang, Hanqing and Chen, Jiahe and Huang, Wensi and Ben, Qingwei and Wang, Tai and Mi, Boyu and Huang, Tao and Zhao, Siheng and Chen, Yilun and Yang, Sizhe and Cao, Peizhou and Yu, Wenye and Ye, Zichao and Li, Jialun and Long, Junfeng and Wang, ZiRui and Wang, Huiling and Zhao, Ying and Tu, Zhongying and Qiao, Yu and Lin, Dahua and Pang Jiangmiao},
    year={2024},
    booktitle={arXiv},
}
InternUtopia's simulation platform is MIT licensed. The open-sourced GRScenes are under the Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International License  .
rsl_rl library to train the control policies for legged robots.157 followers · starred Feb 2025
134 followers · starred Jul 2024
41 followers · starred Jul 2024
159 followers · starred Feb 2025
A simulation platform for versatile Embodied AI research and developments.
See the code
Recent works have been exploring the scaling laws in the field of Embodied AI. Given the prohibitive costs of collecting real-world data, we believe the Simulation-to-Real (Sim2Real) paradigm is a more feasible path for scaling the learning of embodied models.
We introduce project InternUtopia (aka. 桃源 in Chinese), a general-purpose research platform for embodied AGI. It features several advancements:
We hope that this work can alleviate the scarcity of high-quality data in this field and provide a more comprehensive assessment of embodied AI research.
We provide the installation guide here. You can install locally or use docker and verify the installation easily.
We provide detailed docs for the basic usage of different modules supported in InternUtopia. Welcome to try and post your suggestions!
[!NOTE] 📝First of all you MUST complete the User Agreement for GRScenes-100 Dataset Access.
Then you can choose to download all assets (~80GB) or a minimum set (~500MB) to examine installation by running the following script with InternUtopia installed:
$ python -m internutopia.download_assets
The default path to store the downloaded assets is ${PATH/TO/INTERNUTOPIA/ROOT}/internutopia/assets. Users have two ways to configure the asset path:
python -m internutopia.download_assets.python -m internutopia.set_assets_path and entering the preferred directory.If you want to separately download the GRScenes-100 scene assets, you can manually download them from OpenDataLab, ModelScope and HuggingFace. Please refer to the instructions for scene usage.
If you want to separately download robots and policy weights, you can manually download the robot directory from from OpenDataLab, ModelScope and HuggingFace and move it to the root of the asset path.
We preliminarily establish three benchmarks for evaluating the capabilities of embodied agents from different aspects: Object Loco-Navigation, Social Loco-Navigation, and Loco-Manipulation. Please refer to the InternNav and InternManip for running the benchmarks.
Join our WeChat support group or Discord for any help.
If you find our work helpful, please cite:
@inproceedings{grutopia,
    title={GRUtopia: Dream General Robots in a City at Scale},
    author={Wang, Hanqing and Chen, Jiahe and Huang, Wensi and Ben, Qingwei and Wang, Tai and Mi, Boyu and Huang, Tao and Zhao, Siheng and Chen, Yilun and Yang, Sizhe and Cao, Peizhou and Yu, Wenye and Ye, Zichao and Li, Jialun and Long, Junfeng and Wang, ZiRui and Wang, Huiling and Zhao, Ying and Tu, Zhongying and Qiao, Yu and Lin, Dahua and Pang Jiangmiao},
    year={2024},
    booktitle={arXiv},
}
InternUtopia's simulation platform is MIT licensed. The open-sourced GRScenes are under the Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International License .
rsl_rl library to train the control policies for legged robots.157 followers · starred Feb 2025
134 followers · starred Jul 2024
41 followers · starred Jul 2024
159 followers · starred Feb 2025