An All-in-one robot manipulation learning suite for policy models training and evaluation on various datasets and benchmarks.
Python
175
38 commits
updated Oct 15, 2025
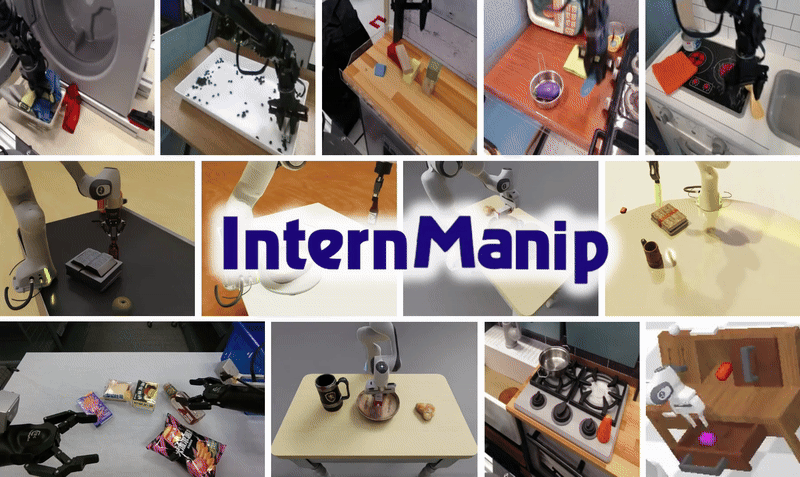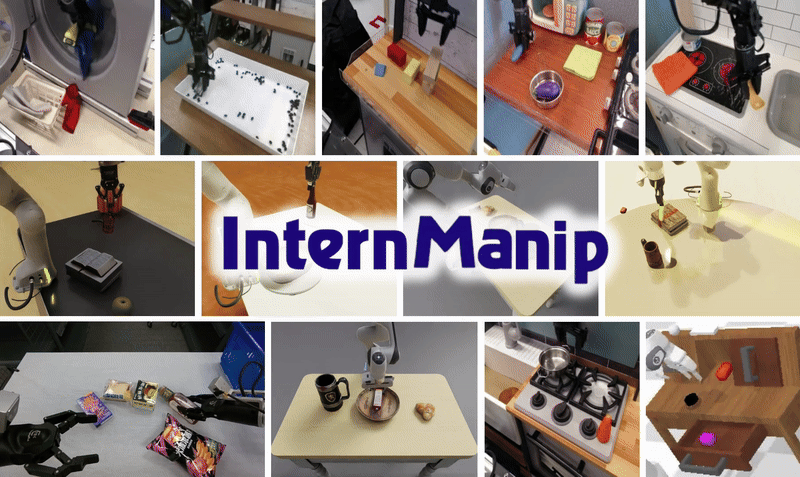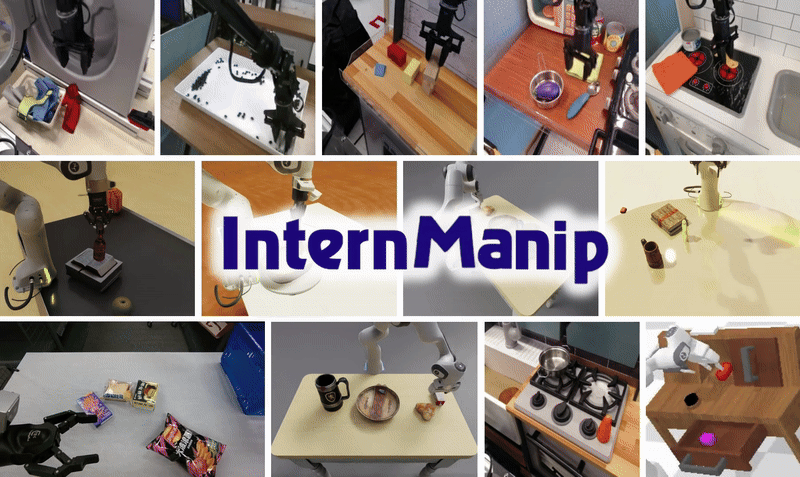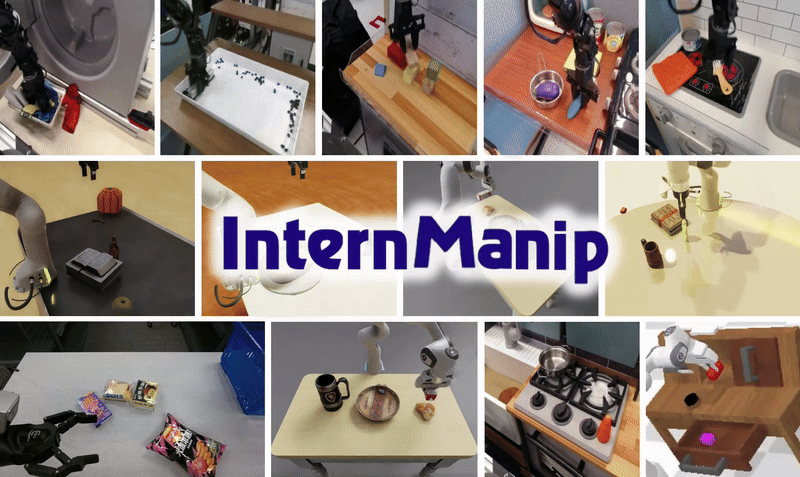


An All-in-one Robot Manipulation Learning Suite for Policy Models Training and Evaluation on Various Datasets and Benchmarks.
InternManip provides the infrastructure for reproducing & developing the state-of-the-art robot manipulation policies, standardizing 🗄️dataset formats, ⚙️model interfaces, and 📝evaluation protocols.
Available Content
| Policy Models | Training Datasets | Benchmarks |
|
|
|
v0.1.0 released, change log.| GPU | Model Training & Inference | Simulation | ||
| CALVIN | Simpler-Env | Genmanip | ||
| NVIDIA RTX Series | ✅ | ✅ | ✅ | ✅ |
| NVIDIA V/A/H100 | ✅ | ✅ | ✅ | ❌ |
[!NOTE] We provide a flexible installation tool for users who want to use InternManip for different purposes. Users can choose to install the training and inference environment, and the individual simulation environment independently.
We provide the installation guide here. You can install locally or use docker and verify the installation easily.
We provide detailed docs for the basic usage of different modules supported in InternManip. Here are some shortcuts to common scenarios:
Welcome to try and post your suggestions!
InternManip offers implementations of multiple manipulation policy models—GR00T-N1, GR00T-N1.5, Pi-0, DP-CLIP, and ACT-CLIP—as well as curated datasets including GenManip, Simpler-Env, and CALVIN, all organized in the standardized LeRobot format.
The available ${MODEL}, ${DATASET}, ${BENCHMARK} and their results are summarized in the following tables:
| Model | Dataset/Benchmark | Score (Main Metric) | Model Weights |
|---|---|---|---|
gr00t_n1 | calvin_abcd | ||
gr00t_n1_5 | calvin_abcd | ||
pi0 | calvin_abcd | ||
dp_clip | calvin_abcd | ||
act_clip | calvin_abcd |
| Model | Dataset/Benchmark | Success Rate | Model Weights |
|---|---|---|---|
gr00t_n1 | google_robot | ||
gr00t_n1_5 | google_robot | ||
pi0 | google_robot | ||
dp_clip | google_robot | ||
act_clip | google_robot | ||
gr00t_n1 | bridgedata_v2 | ||
gr00t_n1_5 | bridgedata_v2 | ||
pi0 | bridgedata_v2 | ||
dp_clip | bridgedata_v2 | ||
act_clip | bridgedata_v2 |
| Model | Dataset/Benchmark | Success Rate | Model Weights |
|---|---|---|---|
gr00t_n1 | genmanip_v1 | ||
gr00t_n1_5 | genmanip_v1 | ||
pi0 | genmanip_v1 | ||
dp_clip | genmanip_v1 | ||
act_clip | genmanip_v1 |
Please refer to the benchmark documentation for more details on how to run the benchmarks and reproduce the results.
Join our WeChat support group or Discord for any help.
If you would like to contribute to InternManip, please check out our contribution guide. For example, raising issues, fixing bugs in the framework, and adapting or adding new policies and data to the framework.
If you find our work helpful, please cite:
@misc{internmanip2025,
    title = {InternManip: An All-in-one Robot Manipulation Learning Suite for Polcy Models Training and Evaluation on Various Datasets and Benchmarks},
    author = {InternManip Contributors},
    howpublished={\url{https://github.com/InternRobotics/InternManip}},
    year = {2025}
}
@inproceedings{gao2025genmanip,
    title={GENMANIP: LLM-driven Simulation for Generalizable Instruction-Following Manipulation},
    author={Gao, Ning and Chen, Yilun and Yang, Shuai and Chen, Xinyi and Tian, Yang and Li, Hao and Huang, Haifeng and Wang, Hanqing and Wang, Tai and Pang, Jiangmiao},
    booktitle={Proceedings of the Computer Vision and Pattern Recognition Conference},
    pages={12187--12198},
    year={2025}
}
@inproceedings{grutopia,
    title={GRUtopia: Dream General Robots in a City at Scale},
    author={Wang, Hanqing and Chen, Jiahe and Huang, Wensi and Ben, Qingwei and Wang, Tai and Mi, Boyu and Huang, Tao and Zhao, Siheng and Chen, Yilun and Yang, Sizhe and Cao, Peizhou and Yu, Wenye and Ye, Zichao and Li, Jialun and Long, Junfeng and Wang, ZiRui and Wang, Huiling and Zhao, Ying and Tu, Zhongying and Qiao, Yu and Lin, Dahua and Pang Jiangmiao},
    year={2024},
    booktitle={arXiv},
}
InternManip's assets and codes are MIT licensed.
The open-sourced data are under the Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International License  .
Other datasets (including Calvin and Simpler) inherit their own distribution licenses.
GRUtopia): The evaluation on GenManip relies on the InternUtopia platform.134 followers · starred Jul 2025
An All-in-one robot manipulation learning suite for policy models training and evaluation on various datasets and benchmarks.
Python
175
38 commits
updated Oct 15, 2025
An All-in-one Robot Manipulation Learning Suite for Policy Models Training and Evaluation on Various Datasets and Benchmarks.
InternManip provides the infrastructure for reproducing & developing the state-of-the-art robot manipulation policies, standardizing 🗄️dataset formats, ⚙️model interfaces, and 📝evaluation protocols.
Available Content
| Policy Models | Training Datasets | Benchmarks |
|
|
|
v0.1.0 released, change log.| GPU | Model Training & Inference | Simulation | ||
| CALVIN | Simpler-Env | Genmanip | ||
| NVIDIA RTX Series | ✅ | ✅ | ✅ | ✅ |
| NVIDIA V/A/H100 | ✅ | ✅ | ✅ | ❌ |
[!NOTE] We provide a flexible installation tool for users who want to use InternManip for different purposes. Users can choose to install the training and inference environment, and the individual simulation environment independently.
We provide the installation guide here. You can install locally or use docker and verify the installation easily.
We provide detailed docs for the basic usage of different modules supported in InternManip. Here are some shortcuts to common scenarios:
Welcome to try and post your suggestions!
InternManip offers implementations of multiple manipulation policy models—GR00T-N1, GR00T-N1.5, Pi-0, DP-CLIP, and ACT-CLIP—as well as curated datasets including GenManip, Simpler-Env, and CALVIN, all organized in the standardized LeRobot format.
The available ${MODEL}, ${DATASET}, ${BENCHMARK} and their results are summarized in the following tables:
| Model | Dataset/Benchmark | Score (Main Metric) | Model Weights |
|---|---|---|---|
gr00t_n1 | calvin_abcd | ||
gr00t_n1_5 | calvin_abcd | ||
pi0 | calvin_abcd | ||
dp_clip | calvin_abcd | ||
act_clip | calvin_abcd |
| Model | Dataset/Benchmark | Success Rate | Model Weights |
|---|---|---|---|
gr00t_n1 | google_robot | ||
gr00t_n1_5 | google_robot | ||
pi0 | google_robot | ||
dp_clip | google_robot | ||
act_clip | google_robot | ||
gr00t_n1 | bridgedata_v2 | ||
gr00t_n1_5 | bridgedata_v2 | ||
pi0 | bridgedata_v2 | ||
dp_clip | bridgedata_v2 | ||
act_clip | bridgedata_v2 |
| Model | Dataset/Benchmark | Success Rate | Model Weights |
|---|---|---|---|
gr00t_n1 | genmanip_v1 | ||
gr00t_n1_5 | genmanip_v1 | ||
pi0 | genmanip_v1 | ||
dp_clip | genmanip_v1 | ||
act_clip | genmanip_v1 |
Please refer to the benchmark documentation for more details on how to run the benchmarks and reproduce the results.
Join our WeChat support group or Discord for any help.
If you would like to contribute to InternManip, please check out our contribution guide. For example, raising issues, fixing bugs in the framework, and adapting or adding new policies and data to the framework.
If you find our work helpful, please cite:
@misc{internmanip2025,
    title = {InternManip: An All-in-one Robot Manipulation Learning Suite for Polcy Models Training and Evaluation on Various Datasets and Benchmarks},
    author = {InternManip Contributors},
    howpublished={\url{https://github.com/InternRobotics/InternManip}},
    year = {2025}
}
@inproceedings{gao2025genmanip,
    title={GENMANIP: LLM-driven Simulation for Generalizable Instruction-Following Manipulation},
    author={Gao, Ning and Chen, Yilun and Yang, Shuai and Chen, Xinyi and Tian, Yang and Li, Hao and Huang, Haifeng and Wang, Hanqing and Wang, Tai and Pang, Jiangmiao},
    booktitle={Proceedings of the Computer Vision and Pattern Recognition Conference},
    pages={12187--12198},
    year={2025}
}
@inproceedings{grutopia,
    title={GRUtopia: Dream General Robots in a City at Scale},
    author={Wang, Hanqing and Chen, Jiahe and Huang, Wensi and Ben, Qingwei and Wang, Tai and Mi, Boyu and Huang, Tao and Zhao, Siheng and Chen, Yilun and Yang, Sizhe and Cao, Peizhou and Yu, Wenye and Ye, Zichao and Li, Jialun and Long, Junfeng and Wang, ZiRui and Wang, Huiling and Zhao, Ying and Tu, Zhongying and Qiao, Yu and Lin, Dahua and Pang Jiangmiao},
    year={2024},
    booktitle={arXiv},
}
InternManip's assets and codes are MIT licensed.
The open-sourced data are under the Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International License .
Other datasets (including Calvin and Simpler) inherit their own distribution licenses.
GRUtopia): The evaluation on GenManip relies on the InternUtopia platform.134 followers · starred Jul 2025