Time-Optimal Gate-Traversing (TOGT) Planner is a lightweight trajectory generator for racing drones that can accommodate a broad range of race tracks comprising gates with diverse shapes and sizes. It provides high trajectory quality in terms of dynamic feasibility by employing the differential-flat nature of quadrotor systems and incorporating single-rotor thrust constraints.
If the TOGT planner helps your academic projects, please cite our papers. Thank you!
Time-Optimal Gate-Traversing Planner for Autonomous Drone Racing, Chao Qin, Maxime SJ Michet, Jingxiang Chen, and Hugh H.-T. Liu, IEEE International Conference on Robotics and Automation (ICRA-2024)
Time optimal quadrotor maneuver: From optimality analysis to trajectory planning, Chao Qin, Jingxiang Chen, Yifan Lin, Abhishek Goudar, Angela P.Schoellig, and Hugh H.-T. Liu, (IJRR-2026)
git clone https://github.com/FSC-Lab/TOGT-Planner/
cd TOGT-Planner
mkdir build; cd build
cmake ..
make
./tests
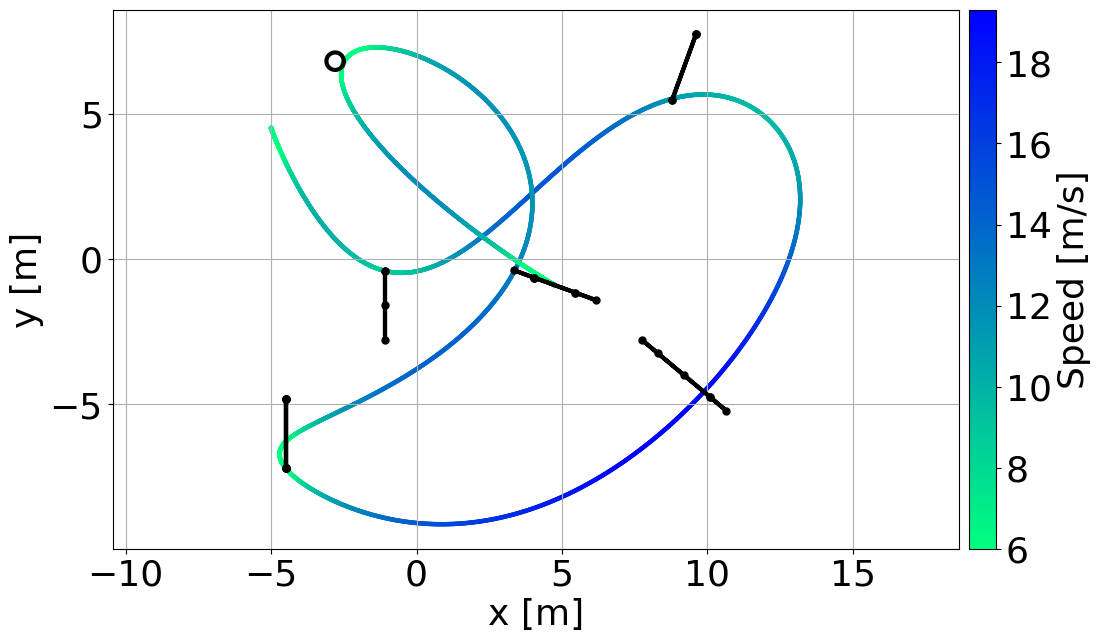
The default race track race_uzh_7g_multiprisma.yaml contains 7 gates with different shapes, respectively, triangle, rectangle, pentagon, rectangle, rectangle, hexagon, and ball gates in order. The resulting lap time is 8.23 s.
cd ../scripts/plots
python3 plot_togt_traj.py
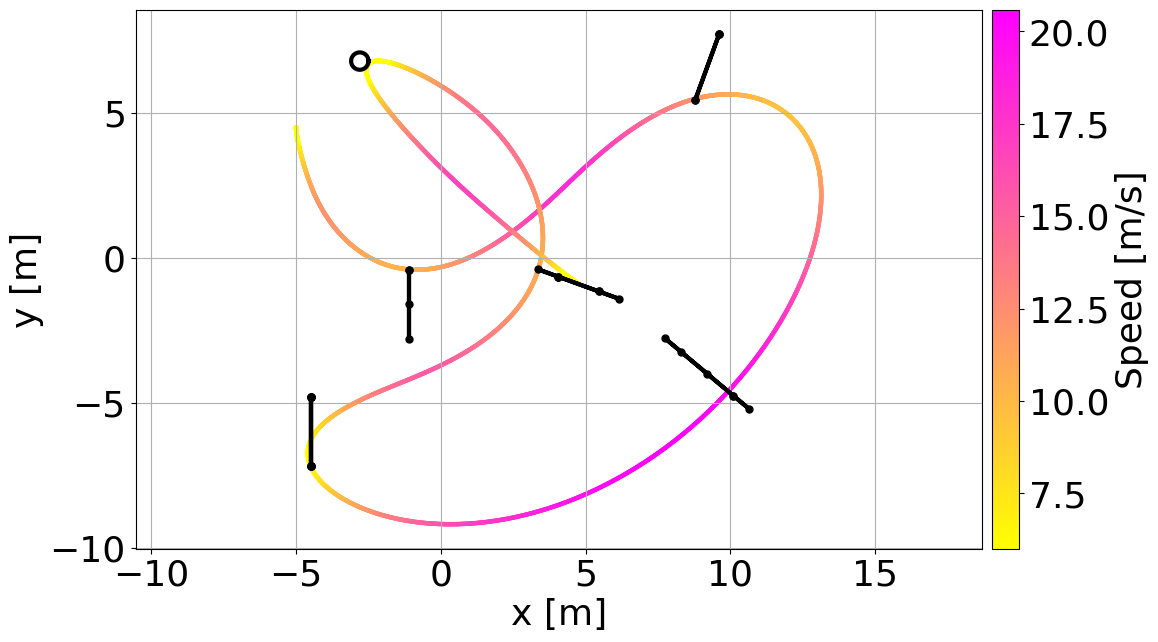
The TOGT trajectory can be refined to reach true time optimality. We take the optimal gate-traversal point as the waypoint and use the obtained time allocation to compute a proper node number for each segment between two consecutive waypoints. Then, we warm-start the multiple-shooting method with the planned TOGT trajectory. The following Python script conducts the refinement for us. The resulting lap time is 7.01 s.
cd ../scripts/togt_refine
python3 togt_refine.py
cd ../plots
python3 plot_togt_refined_traj.py
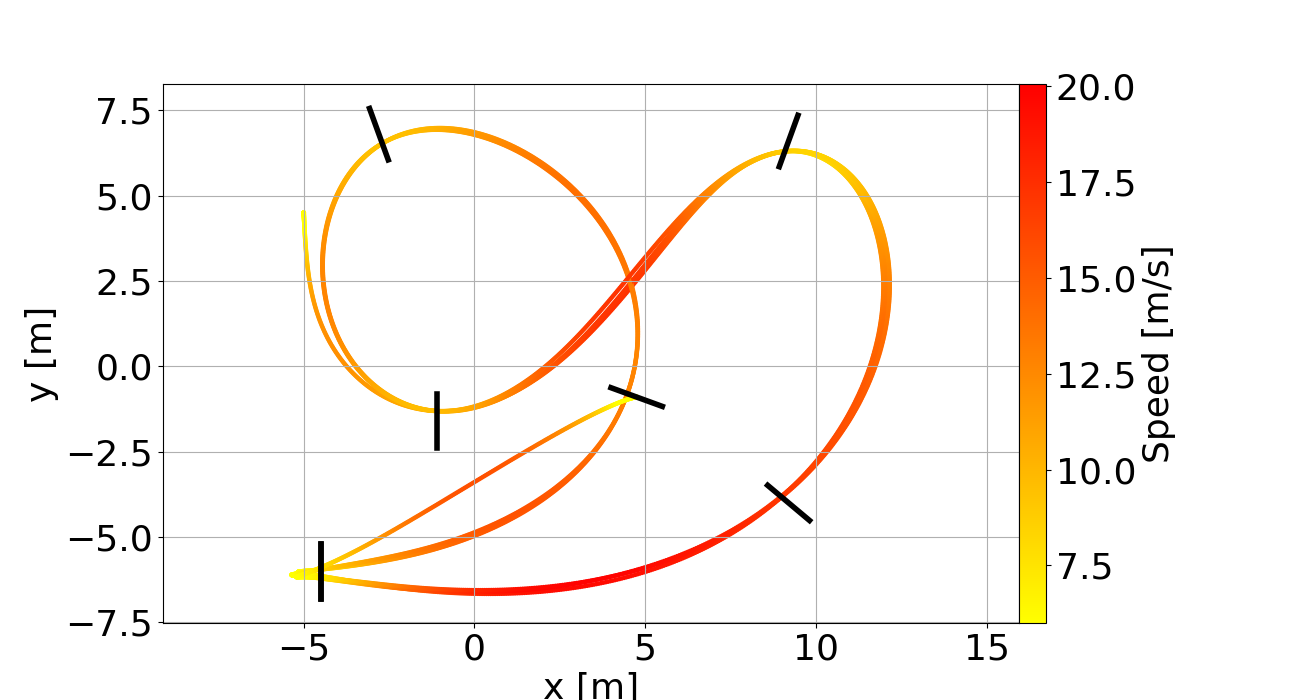
Another example is the Split-S track provided in this paper. It consists of 19 waypoints in total with a tolerance of 0.3 m for each point. Below is our generated trajectory. The AOS stands for Automatic Optimal Synthesis, a novel framework to address time-optimal planning problems. It is part of the result from the second reference above. It takes around 6 seconds to solve the minimum-time trajectory that originally required ~50 minutes in previous methods. The resulting lap time is only 1~2% longer than the optimal solution. We will provide an in-depth analytical analysis in the paper about its distance-insensitive nature. The resulting lap time is 17.93 s while the true optimal is 17.56 s.
cd ../scripts/plots
python3 plot_aos_traj.py
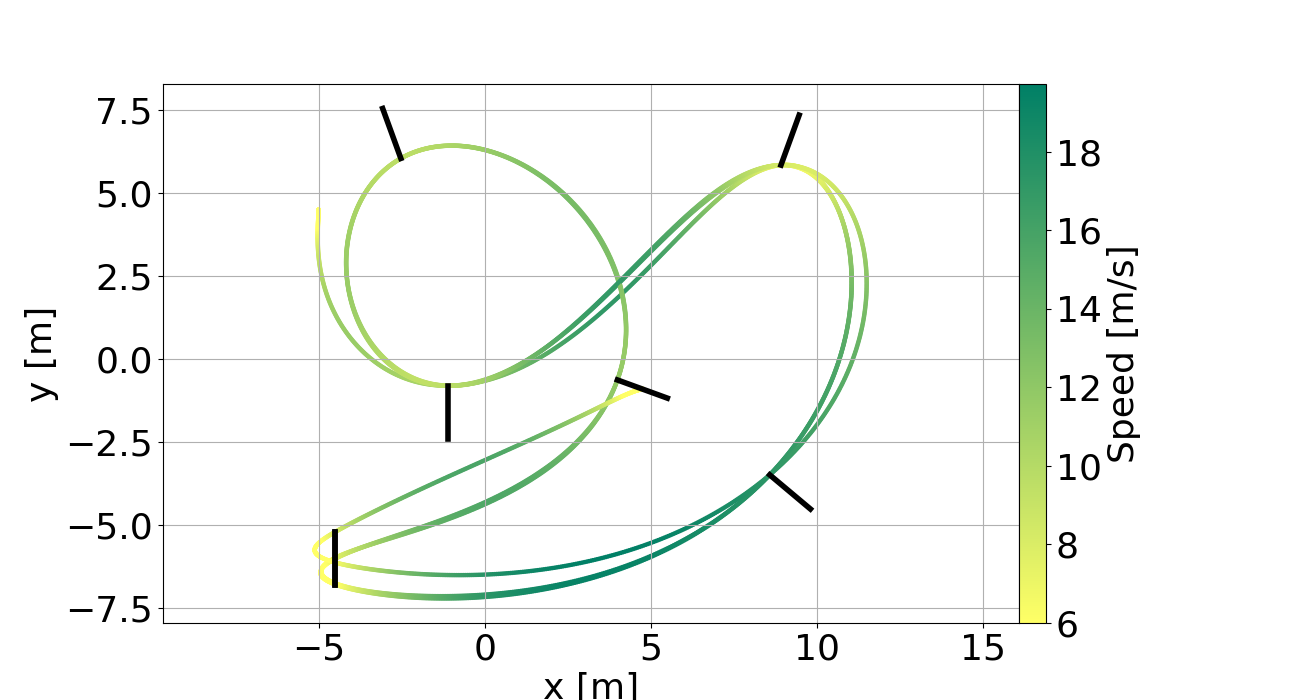
The TOGT and AOS planners can be seamlessly integrated, contributing to a highly efficient and accurate method to solve the time-optimal gate-traversing problem. The code below can visualize the result. The resulting lap time is 16.83 s, which is 4% faster than time-optimal waypoint flights.
cd ../scripts/plots
python3 plot_aos_togt_traj.py
Time-Optimal Gate-Traversing (TOGT) Planner is a lightweight trajectory generator for racing drones that can accommodate a broad range of race tracks comprising gates with diverse shapes and sizes. It provides high trajectory quality in terms of dynamic feasibility by employing the differential-flat nature of quadrotor systems and incorporating single-rotor thrust constraints.
If the TOGT planner helps your academic projects, please cite our papers. Thank you!
Time-Optimal Gate-Traversing Planner for Autonomous Drone Racing, Chao Qin, Maxime SJ Michet, Jingxiang Chen, and Hugh H.-T. Liu, IEEE International Conference on Robotics and Automation (ICRA-2024)
Time optimal quadrotor maneuver: From optimality analysis to trajectory planning, Chao Qin, Jingxiang Chen, Yifan Lin, Abhishek Goudar, Angela P.Schoellig, and Hugh H.-T. Liu, (IJRR-2026)
git clone https://github.com/FSC-Lab/TOGT-Planner/
cd TOGT-Planner
mkdir build; cd build
cmake ..
make
./tests
The default race track race_uzh_7g_multiprisma.yaml contains 7 gates with different shapes, respectively, triangle, rectangle, pentagon, rectangle, rectangle, hexagon, and ball gates in order. The resulting lap time is 8.23 s.
cd ../scripts/plots
python3 plot_togt_traj.py
The TOGT trajectory can be refined to reach true time optimality. We take the optimal gate-traversal point as the waypoint and use the obtained time allocation to compute a proper node number for each segment between two consecutive waypoints. Then, we warm-start the multiple-shooting method with the planned TOGT trajectory. The following Python script conducts the refinement for us. The resulting lap time is 7.01 s.
cd ../scripts/togt_refine
python3 togt_refine.py
cd ../plots
python3 plot_togt_refined_traj.py
Another example is the Split-S track provided in this paper. It consists of 19 waypoints in total with a tolerance of 0.3 m for each point. Below is our generated trajectory. The AOS stands for Automatic Optimal Synthesis, a novel framework to address time-optimal planning problems. It is part of the result from the second reference above. It takes around 6 seconds to solve the minimum-time trajectory that originally required ~50 minutes in previous methods. The resulting lap time is only 1~2% longer than the optimal solution. We will provide an in-depth analytical analysis in the paper about its distance-insensitive nature. The resulting lap time is 17.93 s while the true optimal is 17.56 s.
cd ../scripts/plots
python3 plot_aos_traj.py
The TOGT and AOS planners can be seamlessly integrated, contributing to a highly efficient and accurate method to solve the time-optimal gate-traversing problem. The code below can visualize the result. The resulting lap time is 16.83 s, which is 4% faster than time-optimal waypoint flights.
cd ../scripts/plots
python3 plot_aos_togt_traj.py



