
README
🤖 HRDexDB
A Paired Human-Robot Dataset for Cross-Embodiment Dexterous Grasping
Jongbin Lim1, · Taeyun Ha1, · Mingi Choi1 · Jisoo Kim1 · Byungjun Kim1 · Subin Jeon1 · Hanbyul Joo1,2,†
1 Seoul National University · 2 RLWRLD
* Equal contribution · † Corresponding author
Official dataset repository and lightweight visualization toolkit for HRDexDB.
TL;DR: HRDexDB is a paired cross-embodiment dataset of high-fidelity dexterous grasping sequences featuring both human and robotic hands.
Dataset Overview
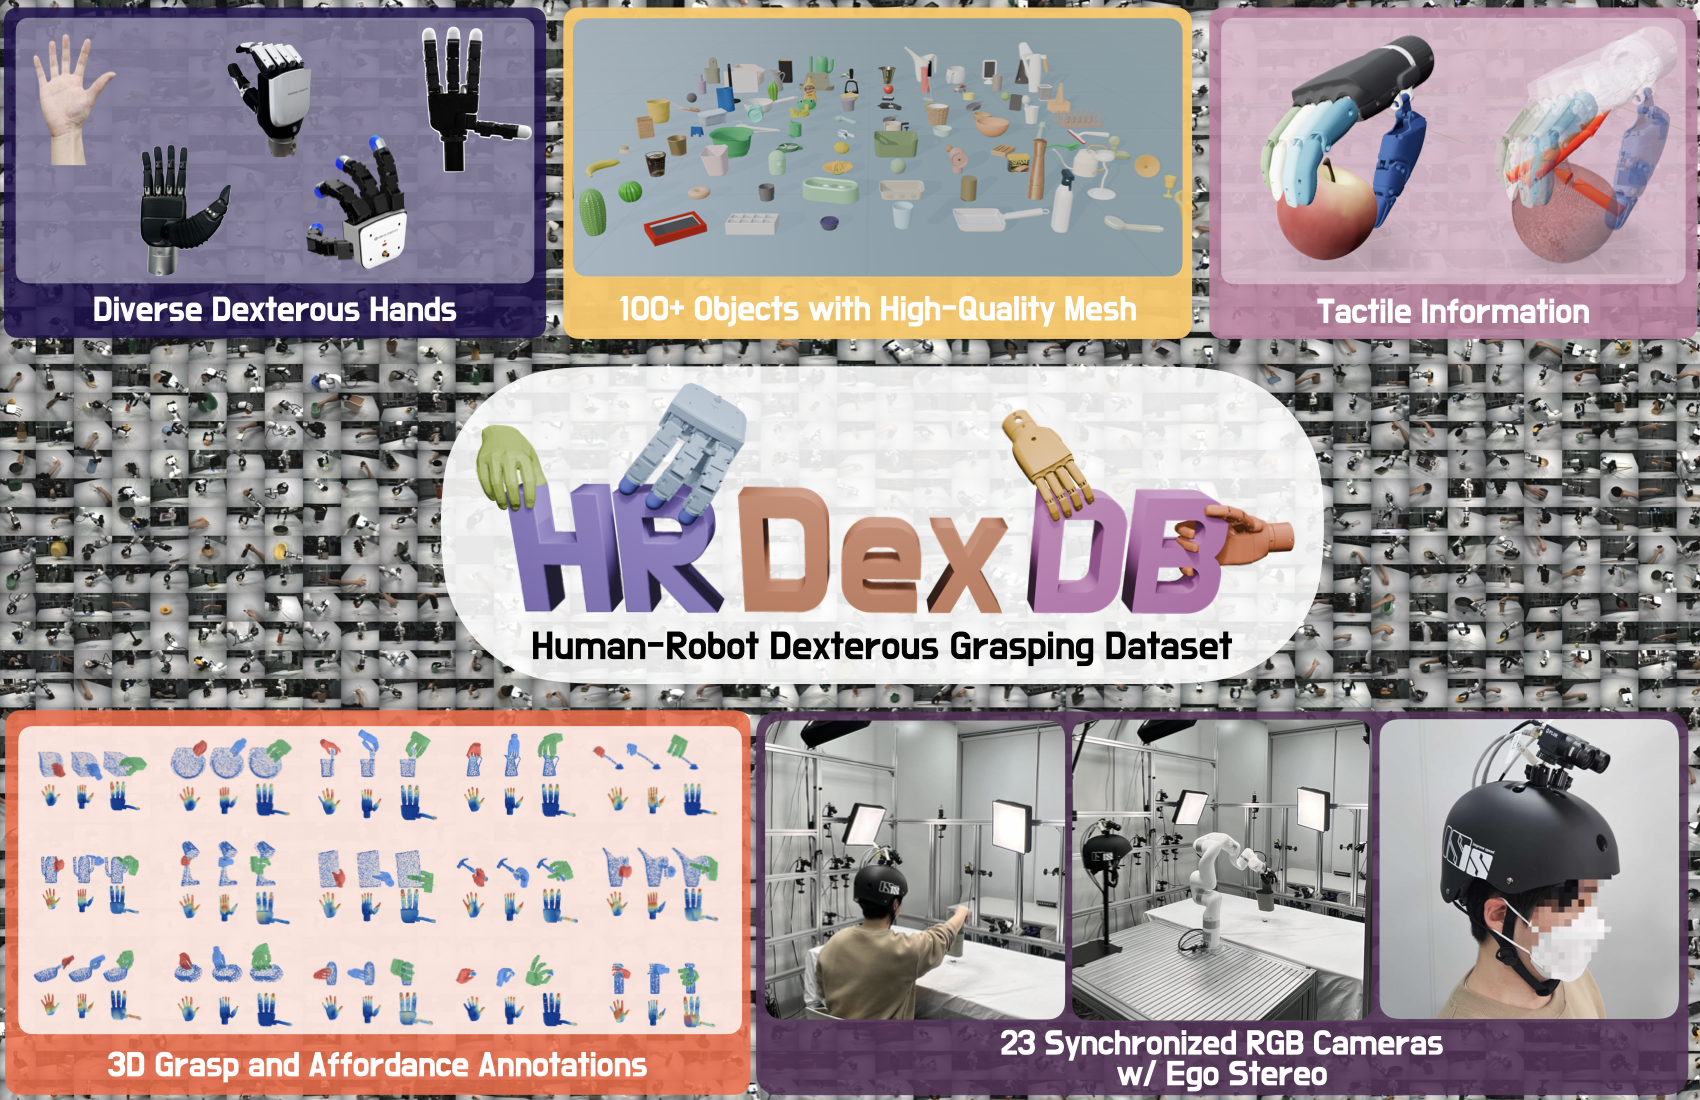
HRDexDB provides paired dexterous grasping trajectories across human hands and robotic hand embodiments, captured on the same target objects under comparable grasping motions. The dataset includes synchronized visual, kinematic, and 3D annotation modalities, with contact-force signals available for tactile-enabled robot hands.
Key statistics:
- 2.1K grasping sequences
- 100+ diverse objects
- 5 hand embodiments
- 23 synchronized cameras
- High-precision 3D trajectories for both hand/robot and manipulated objects
Installation
git clone https://github.com/snuvclab/HRDexDB
cd HRDexDB

conda env create -f environment.yml
conda activate hrdexdb-vis
For an existing Python environment:
pip install -r requirements.txt
All commands below assume they are run from the repository root.
Dataset Placement
Place the released dataset folder v0 directly under the repository root:
HRDexDB/
├── README.md
├── visualize_trajectory.py
├── hrdexdb/
├── assets/
│   └── robots/
└── v0/
    ├── assets/
    │   └── mesh/
    │       └── <object_name>/
    │           └── <object_name>.obj
    ├── human/
    │   └── <object_name>/
    │       └── <scene_id>/
    └── inspire_f1/
        └── <object_name>/
            └── <scene_id>/
By default, the viewer resolves:
- dataset root:
./v0 - object mesh root:
./v0/assets/mesh
If v0 is stored elsewhere, pass --dataset-root /path/to/v0. The mesh root then defaults to /path/to/v0/assets/mesh.
Quick Visualization
Visualize an Inspire F1 robot scene:
python visualize_trajectory.py \
  --hand inspire_f1 \
  --object banana \
  --scene 2
Visualize a human hand scene:
python visualize_trajectory.py \
  --hand human \
  --object banana \
  --scene 2
Use a dataset stored outside the repository:
python visualize_trajectory.py \
  --dataset-root /path/to/v0 \
  --hand inspire_f1 \
  --object french_mustard \
  --scene 2
Expected Scene Layout
Each scene is expected to follow this structure:
<dataset-root>/<hand>/<object>/<scene_id>/
├── cam_param/
│   ├── intrinsics.json
│   ├── extrinsics.json
│   └── ego_calib.json          # optional, for human ego cameras
├── C2R.npy
├── object_6d/
│   └── pose_*.txt
└── vid/
    └── <camera_id>.mp4

<dataset-root>/assets/mesh/<object>/<object>.obj
Robot scenes additionally include:
raw/
├── arm/*.npy
├── hand/*.npy
└── timestamps/
    ├── timestamp.npy
    └── frame_id.npy
Human scenes include MANO mesh sequences under one of:
hand/mano/*.obj
Contact
For questions, please contact Jongbin Lim at whdqls0534@snu.ac.kr or Taeyun Ha at taeyun012@snu.ac.kr.
Citation
If you find HRDexDB useful, please cite:
@misc{lim2026hrdexdb,
      title={HRDexDB: A Paired Human-Robot Dataset for Cross-Embodiment Dexterous Grasping},
      author={Jongbin Lim and Taeyun Ha and Mingi Choi and Jisoo Kim and Byungjun Kim and Subin Jeon and Hanbyul Joo},
      year={2026},
      eprint={2604.14944},
      archivePrefix={arXiv},
      primaryClass={cs.RO},
      url={https://arxiv.org/abs/2604.14944},
}
Similar repos





Languages
Python
100.0%
README
🤖 HRDexDB
A Paired Human-Robot Dataset for Cross-Embodiment Dexterous Grasping
Jongbin Lim1, · Taeyun Ha1, · Mingi Choi1 · Jisoo Kim1 · Byungjun Kim1 · Subin Jeon1 · Hanbyul Joo1,2,†
1 Seoul National University · 2 RLWRLD
* Equal contribution · † Corresponding author
Official dataset repository and lightweight visualization toolkit for HRDexDB.
TL;DR: HRDexDB is a paired cross-embodiment dataset of high-fidelity dexterous grasping sequences featuring both human and robotic hands.
Dataset Overview
HRDexDB provides paired dexterous grasping trajectories across human hands and robotic hand embodiments, captured on the same target objects under comparable grasping motions. The dataset includes synchronized visual, kinematic, and 3D annotation modalities, with contact-force signals available for tactile-enabled robot hands.
Key statistics:
- 2.1K grasping sequences
- 100+ diverse objects
- 5 hand embodiments
- 23 synchronized cameras
- High-precision 3D trajectories for both hand/robot and manipulated objects
Installation
git clone https://github.com/snuvclab/HRDexDB
cd HRDexDB

conda env create -f environment.yml
conda activate hrdexdb-vis
For an existing Python environment:
pip install -r requirements.txt
All commands below assume they are run from the repository root.
Dataset Placement
Place the released dataset folder v0 directly under the repository root:
HRDexDB/
├── README.md
├── visualize_trajectory.py
├── hrdexdb/
├── assets/
│   └── robots/
└── v0/
    ├── assets/
    │   └── mesh/
    │       └── <object_name>/
    │           └── <object_name>.obj
    ├── human/
    │   └── <object_name>/
    │       └── <scene_id>/
    └── inspire_f1/
        └── <object_name>/
            └── <scene_id>/
By default, the viewer resolves:
- dataset root:
./v0 - object mesh root:
./v0/assets/mesh
If v0 is stored elsewhere, pass --dataset-root /path/to/v0. The mesh root then defaults to /path/to/v0/assets/mesh.
Quick Visualization
Visualize an Inspire F1 robot scene:
python visualize_trajectory.py \
  --hand inspire_f1 \
  --object banana \
  --scene 2
Visualize a human hand scene:
python visualize_trajectory.py \
  --hand human \
  --object banana \
  --scene 2
Use a dataset stored outside the repository:
python visualize_trajectory.py \
  --dataset-root /path/to/v0 \
  --hand inspire_f1 \
  --object french_mustard \
  --scene 2
Expected Scene Layout
Each scene is expected to follow this structure:
<dataset-root>/<hand>/<object>/<scene_id>/
├── cam_param/
│   ├── intrinsics.json
│   ├── extrinsics.json
│   └── ego_calib.json          # optional, for human ego cameras
├── C2R.npy
├── object_6d/
│   └── pose_*.txt
└── vid/
    └── <camera_id>.mp4

<dataset-root>/assets/mesh/<object>/<object>.obj
Robot scenes additionally include:
raw/
├── arm/*.npy
├── hand/*.npy
└── timestamps/
    ├── timestamp.npy
    └── frame_id.npy
Human scenes include MANO mesh sequences under one of:
hand/mano/*.obj
Contact
For questions, please contact Jongbin Lim at whdqls0534@snu.ac.kr or Taeyun Ha at taeyun012@snu.ac.kr.
Citation
If you find HRDexDB useful, please cite:
@misc{lim2026hrdexdb,
      title={HRDexDB: A Paired Human-Robot Dataset for Cross-Embodiment Dexterous Grasping},
      author={Jongbin Lim and Taeyun Ha and Mingi Choi and Jisoo Kim and Byungjun Kim and Subin Jeon and Hanbyul Joo},
      year={2026},
      eprint={2604.14944},
      archivePrefix={arXiv},
      primaryClass={cs.RO},
      url={https://arxiv.org/abs/2604.14944},
}
Similar repos
Languages
Python
100.0%