
README
Discrete Reasoning
Looped MLP-Mixer sudoku solver with an outer commit loop, inner mixer iterations, and a learned halt head, trained from scratch on sapientinc/sudoku-extreme.
Getting started
Install with uv sync, download the dataset (~798 MB), train, and open the local viz server. Minimal path:
uv sync
uv run download-dataset
uv run train \
  --min-rating 0 --max-rating 0 \
  --max-samples 100 --epochs 30 \
  --dim 512 --num-blocks 2 \
  --inner-iters 5 --train-max-outer-iters 10 \
  --eval-max-outer-iters 10 \
  --train-batch-size 8 --batches-per-epoch 100
uv run python -m http.server 8000
Open http://localhost:8000/viz/. Serve from the repo root.
Method
Shared MLP-Mixer stack reused across an outer commit loop: each outer step applies the previous prediction, runs inner mixer iterations on encoded grid state, and updates detached cell memory. A halt head learns when the grid matches the solution. Training uses parallel puzzle slots with optional augmentations and partial ground-truth reveal.
CLI
Entry points: download-dataset, train, eval, resume. Eval supports test-time restarts and one-dimensional compute sweeps (inner steps, outer commits, tries). PyTorch profiler hooks are available on train.
Runs & viz
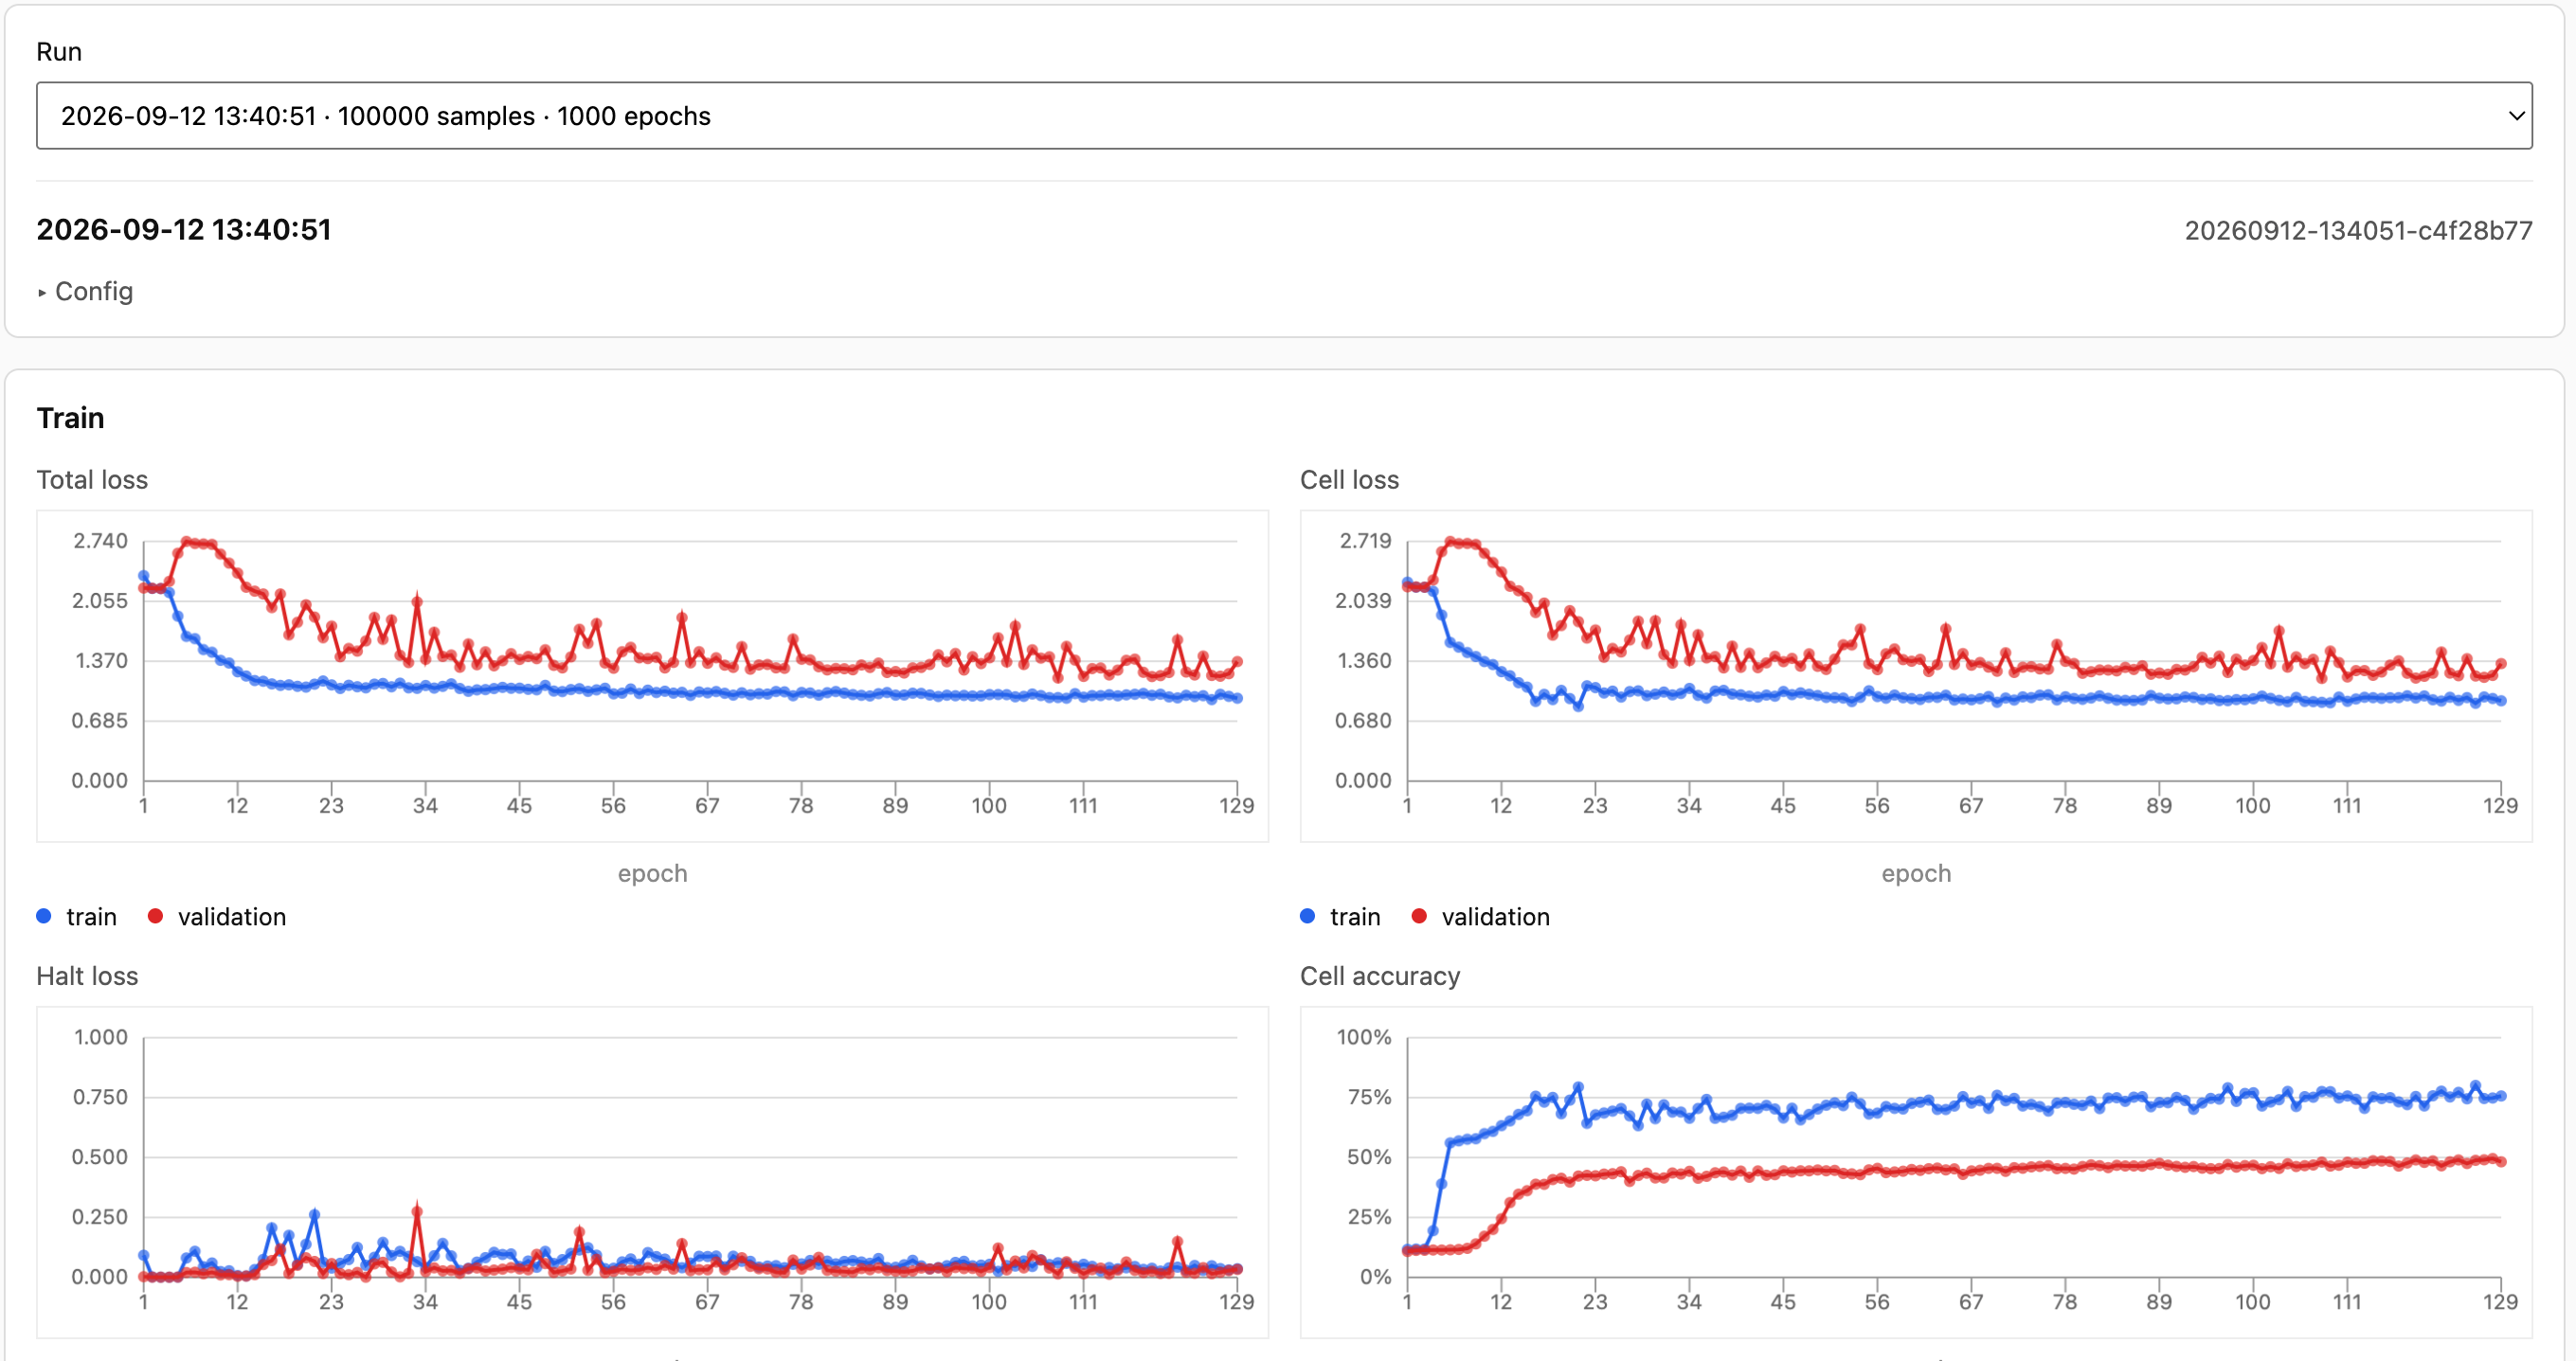
Each run writes history.json, checkpoints, and per-puzzle trajectory JSON under runs/<run-id>/. The viz page charts train/val metrics and plays back outer-commit trajectories.
Train and validation metrics per epoch: loss, cell/puzzle accuracy, halt rate, and accuracy by rating group.
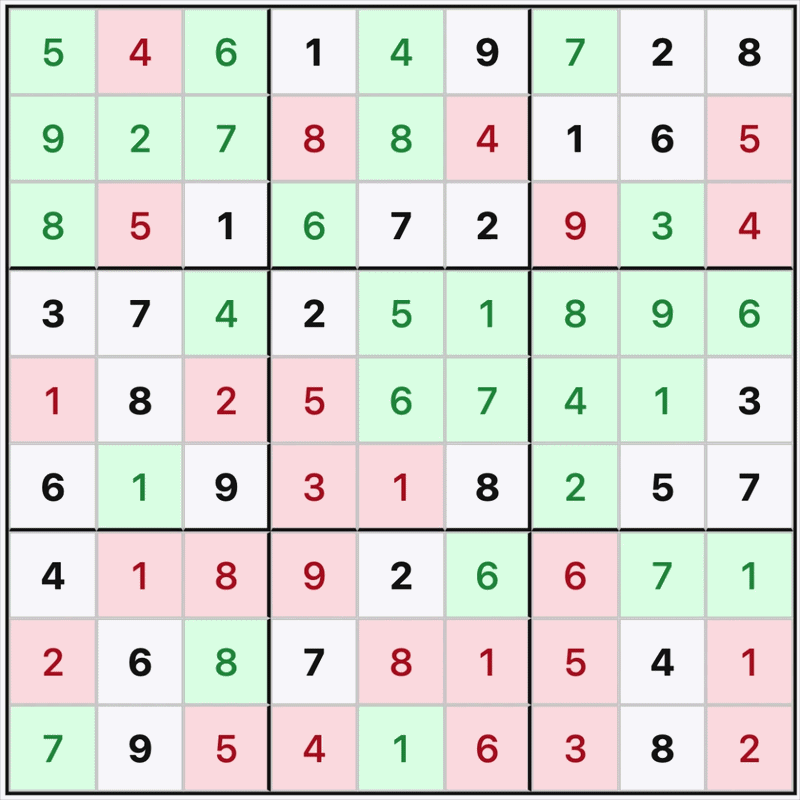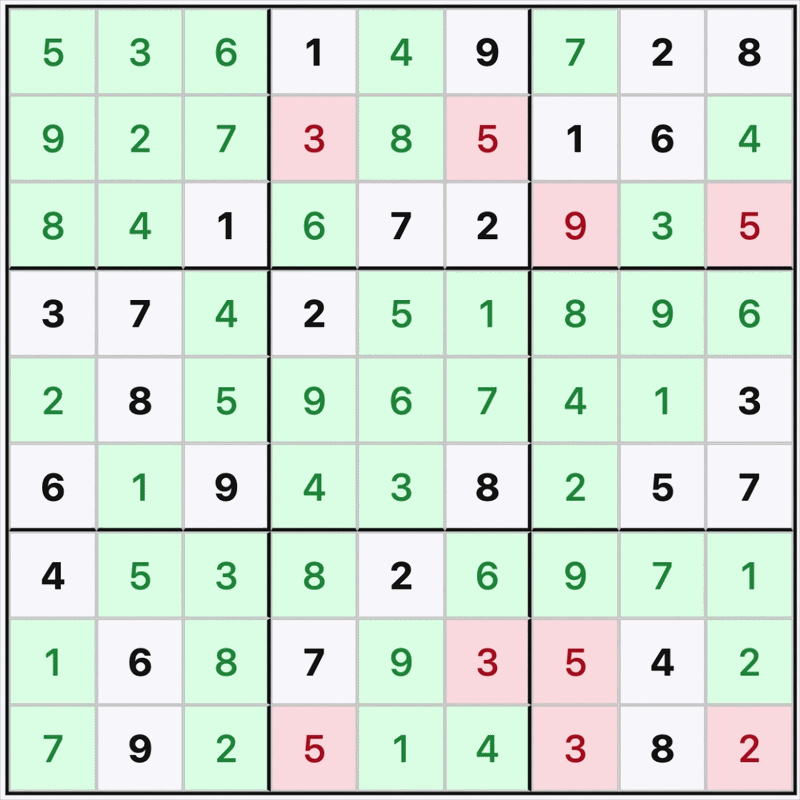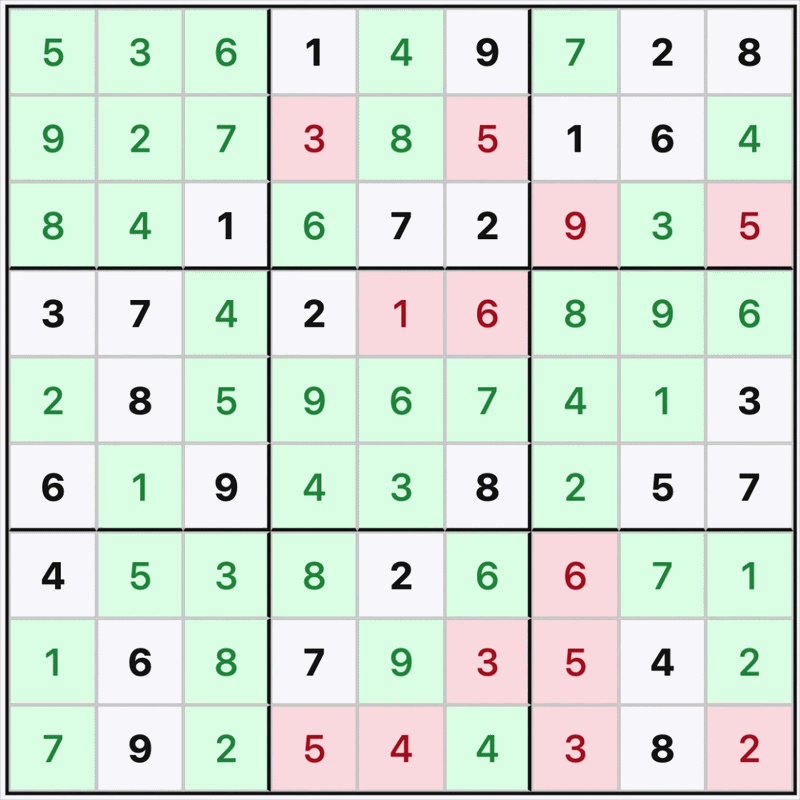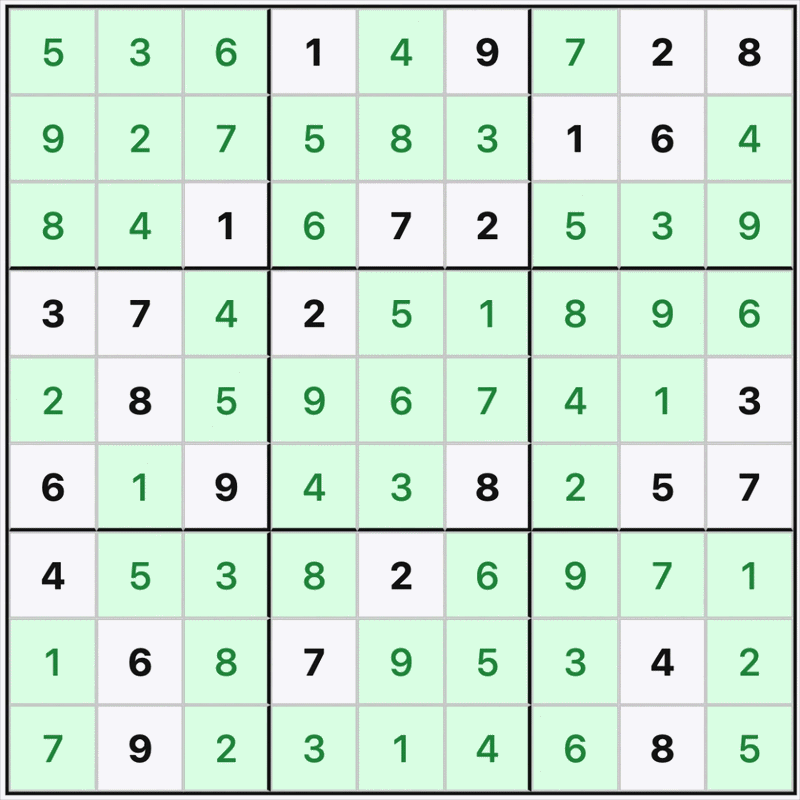
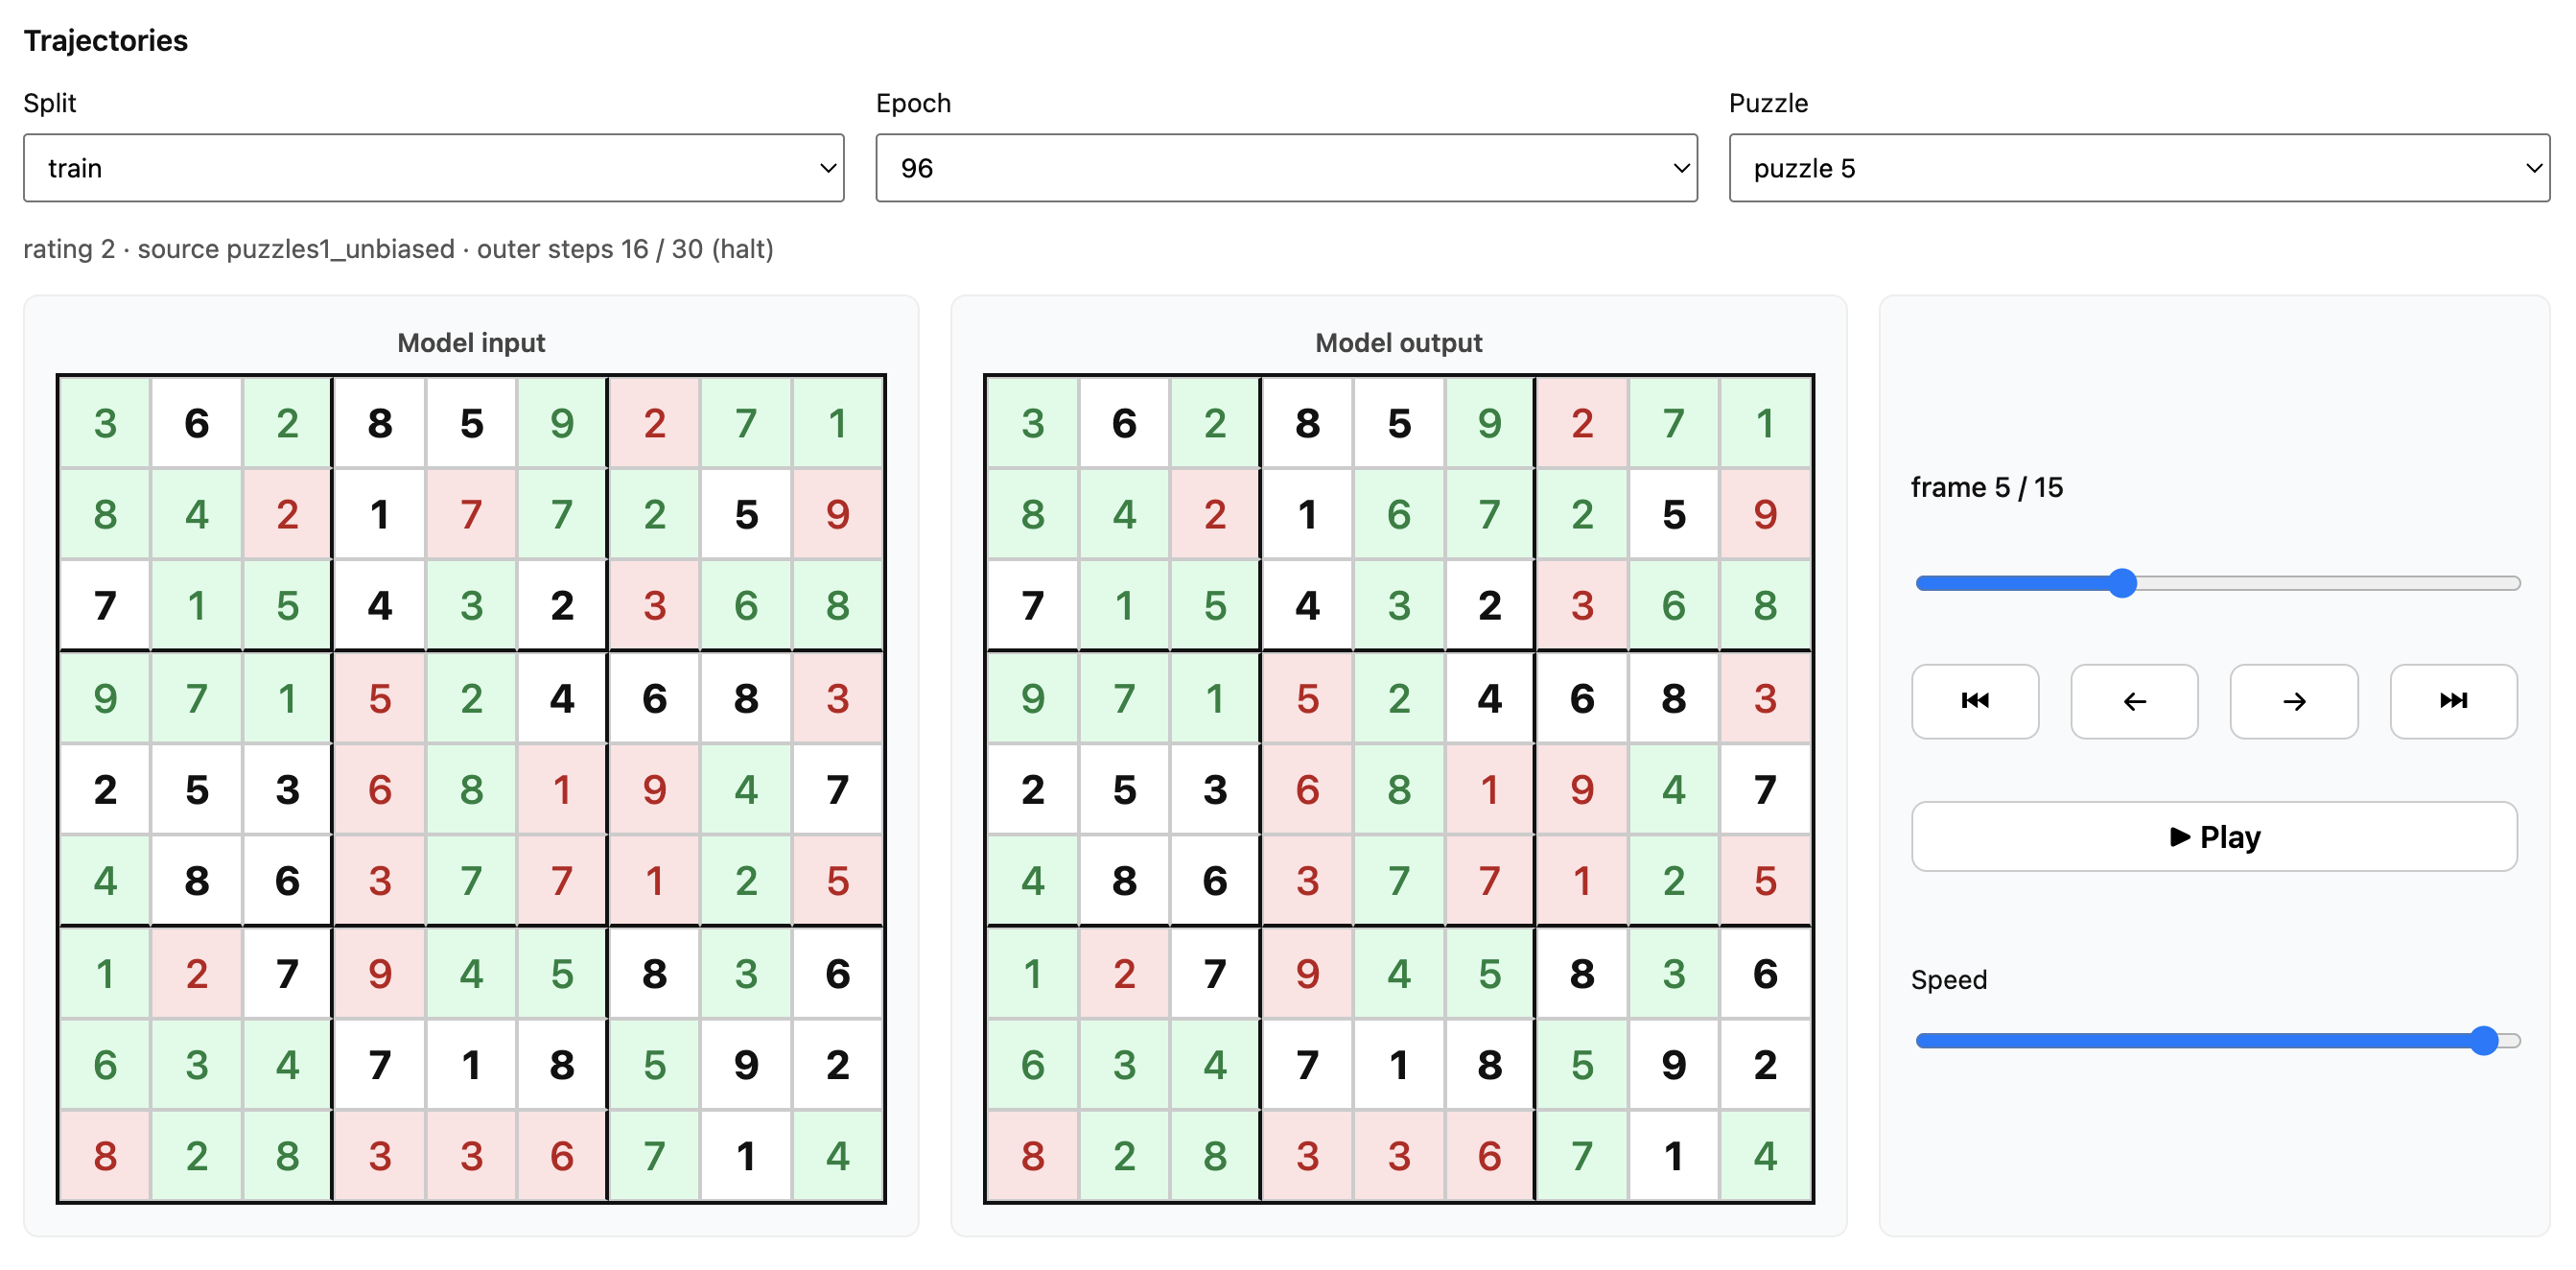
Trajectory player for one puzzle: model input and output at each outer commit until halt or max steps.
Jetson
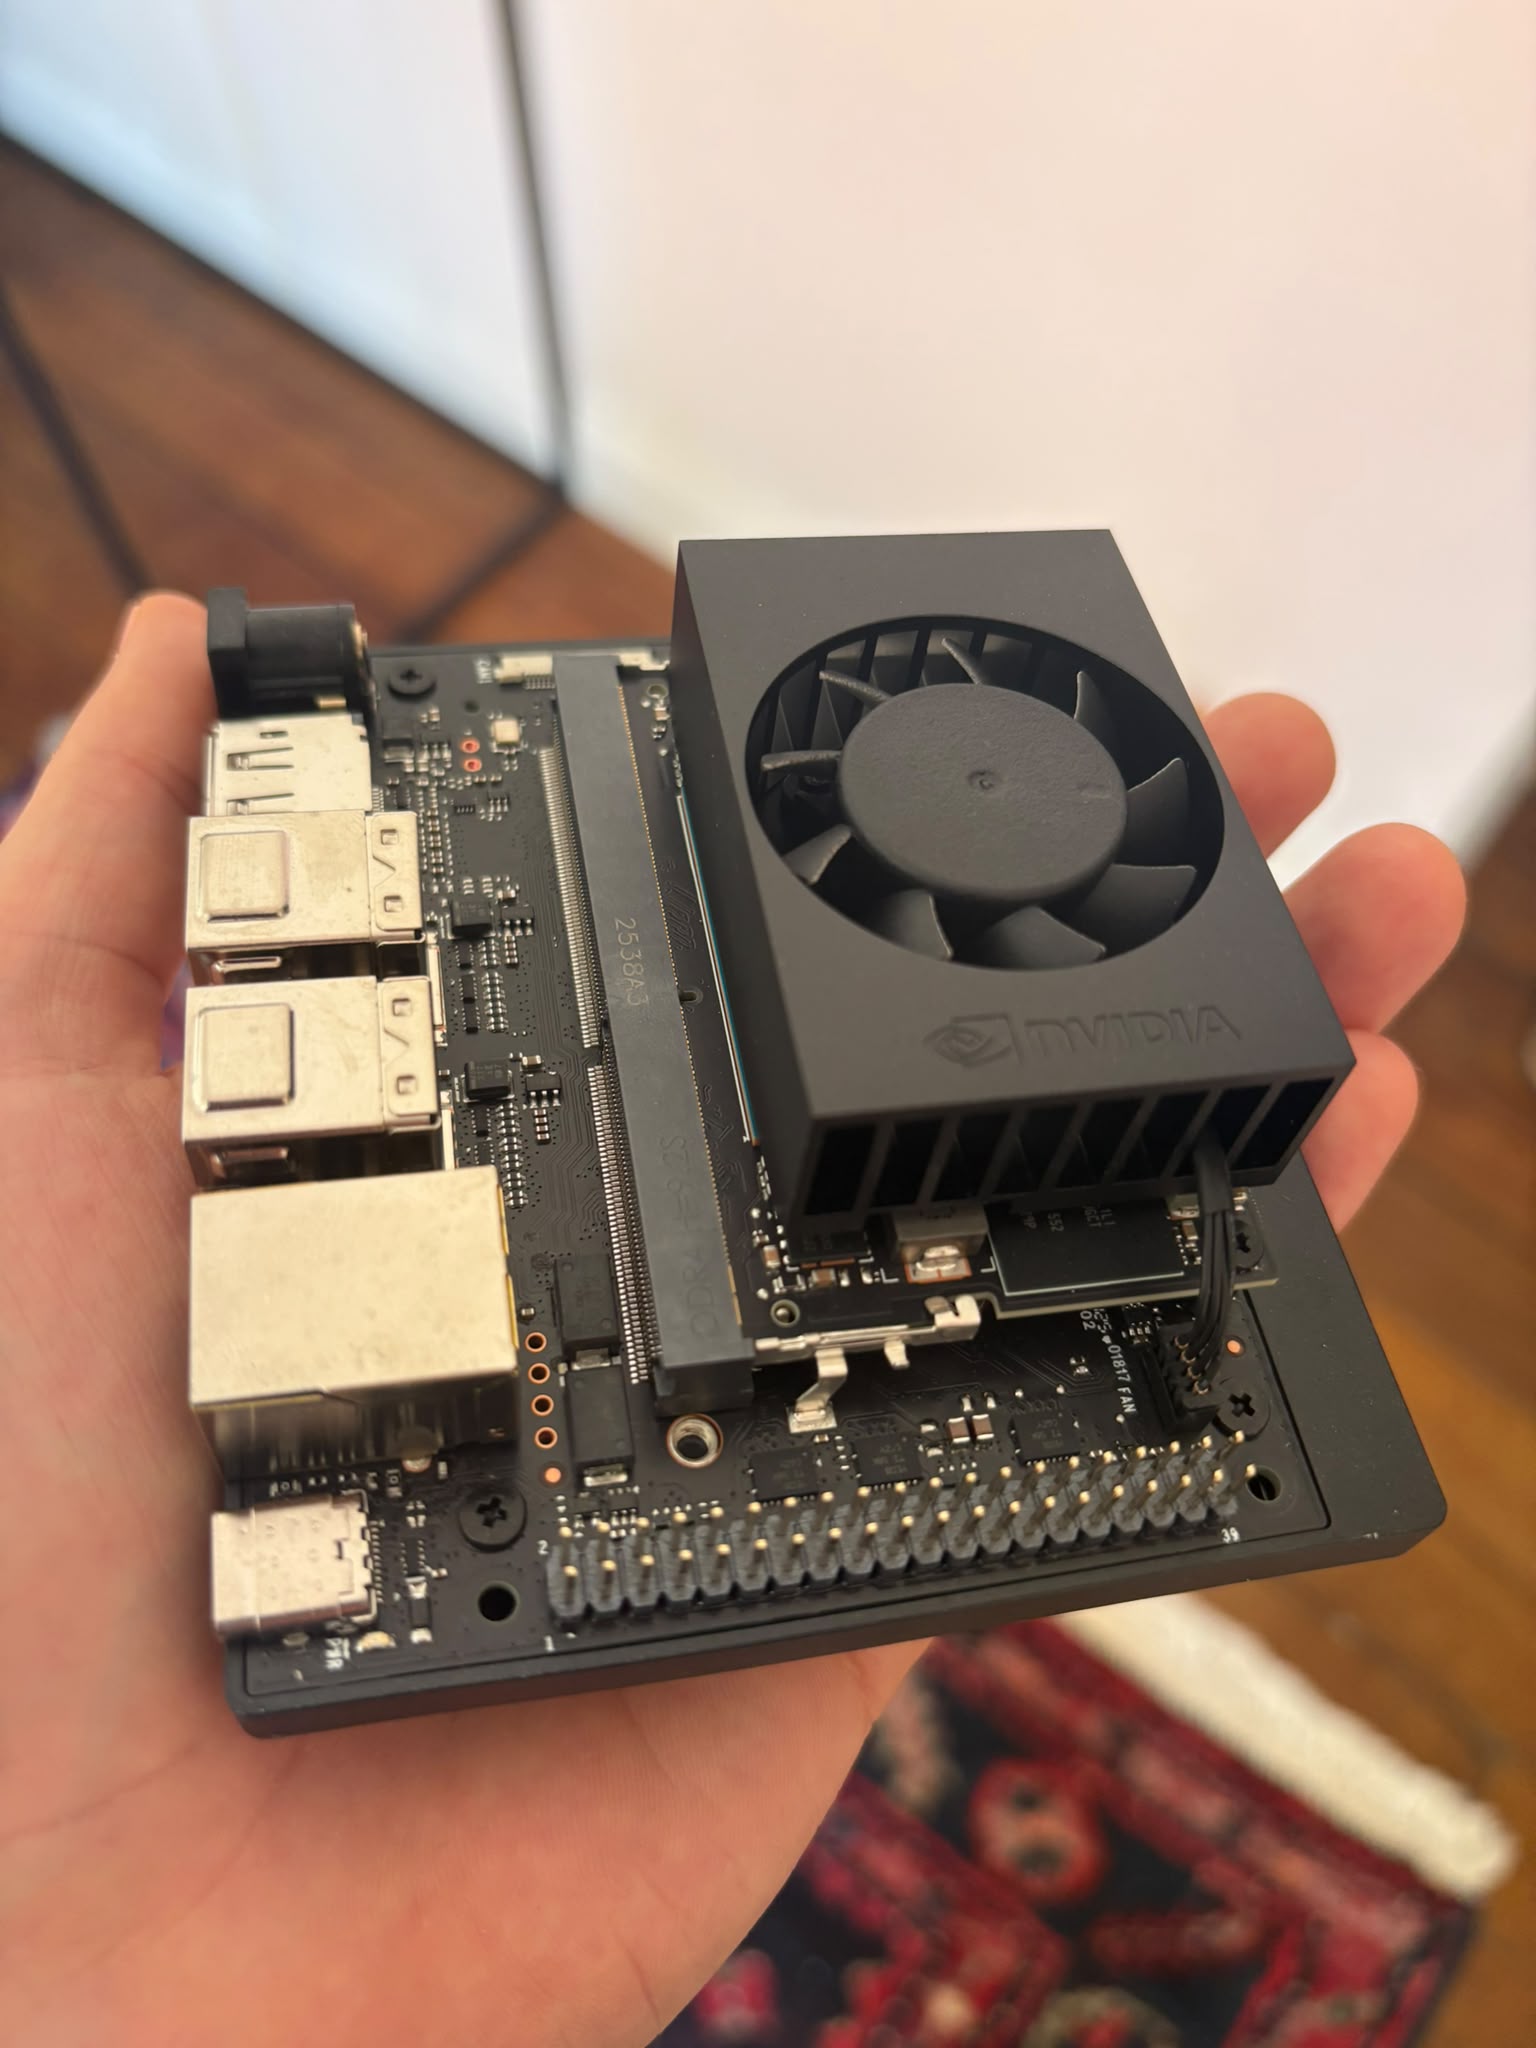
Docker setup for training and eval on NVIDIA Jetson (JetPack). Source is bind-mounted; rebuild only when dependencies change.
References
- Dataset: sapientinc/sudoku-extreme on Hugging Face
- Hierarchical Reasoning Model (HRM)
- Less is More: Recursive Reasoning with Tiny Networks (TRM)
- Looped Transformers are Better at Learning Learning Algorithms
- Diffusion as a Training Curriculum for Timestep-Free Iterative Reasoning
- Flow Reasoning Models: Turning Flows Into Efficient Recurrent Reasoners
MIT License.
Contributors

50 commits
See what people are saying
Similar repos


Languages
Python
79.6%
HTML
18.7%
Shell
1.2%
README
Discrete Reasoning
Looped MLP-Mixer sudoku solver with an outer commit loop, inner mixer iterations, and a learned halt head, trained from scratch on sapientinc/sudoku-extreme.
Getting started
Install with uv sync, download the dataset (~798 MB), train, and open the local viz server. Minimal path:
uv sync
uv run download-dataset
uv run train \
  --min-rating 0 --max-rating 0 \
  --max-samples 100 --epochs 30 \
  --dim 512 --num-blocks 2 \
  --inner-iters 5 --train-max-outer-iters 10 \
  --eval-max-outer-iters 10 \
  --train-batch-size 8 --batches-per-epoch 100
uv run python -m http.server 8000
Open http://localhost:8000/viz/. Serve from the repo root.
Method
Shared MLP-Mixer stack reused across an outer commit loop: each outer step applies the previous prediction, runs inner mixer iterations on encoded grid state, and updates detached cell memory. A halt head learns when the grid matches the solution. Training uses parallel puzzle slots with optional augmentations and partial ground-truth reveal.
CLI
Entry points: download-dataset, train, eval, resume. Eval supports test-time restarts and one-dimensional compute sweeps (inner steps, outer commits, tries). PyTorch profiler hooks are available on train.
Runs & viz
Each run writes history.json, checkpoints, and per-puzzle trajectory JSON under runs/<run-id>/. The viz page charts train/val metrics and plays back outer-commit trajectories.
Train and validation metrics per epoch: loss, cell/puzzle accuracy, halt rate, and accuracy by rating group.
Trajectory player for one puzzle: model input and output at each outer commit until halt or max steps.
Jetson
Docker setup for training and eval on NVIDIA Jetson (JetPack). Source is bind-mounted; rebuild only when dependencies change.
References
- Dataset: sapientinc/sudoku-extreme on Hugging Face
- Hierarchical Reasoning Model (HRM)
- Less is More: Recursive Reasoning with Tiny Networks (TRM)
- Looped Transformers are Better at Learning Learning Algorithms
- Diffusion as a Training Curriculum for Timestep-Free Iterative Reasoning
- Flow Reasoning Models: Turning Flows Into Efficient Recurrent Reasoners
MIT License.
See what people are saying
Similar repos
Contributors
50 commits
Languages
Python
79.6%
HTML
18.7%
Shell
1.2%