
Resources for the ICRA2026 Keynote Tutorial "Title: Building, running and deploying modern software tools for robotics"
Jupyter Notebook
74
129 commits
updated Jun 10, 2026
README
Building, running and deploying modern software tools for robotics
- ICRA2026 Keynote Tutorial 3 (was 4)
- When: Wednesday, 3 June 15:00 to 16:30 (90 minutes)
- Where: Strauss 1-2
Important links
On the day, go to the tutorial landing page
https://petercorke.github.io/ICRA2026-modern-software-tools/
and from there you get access to all the resources we'll use in the session.
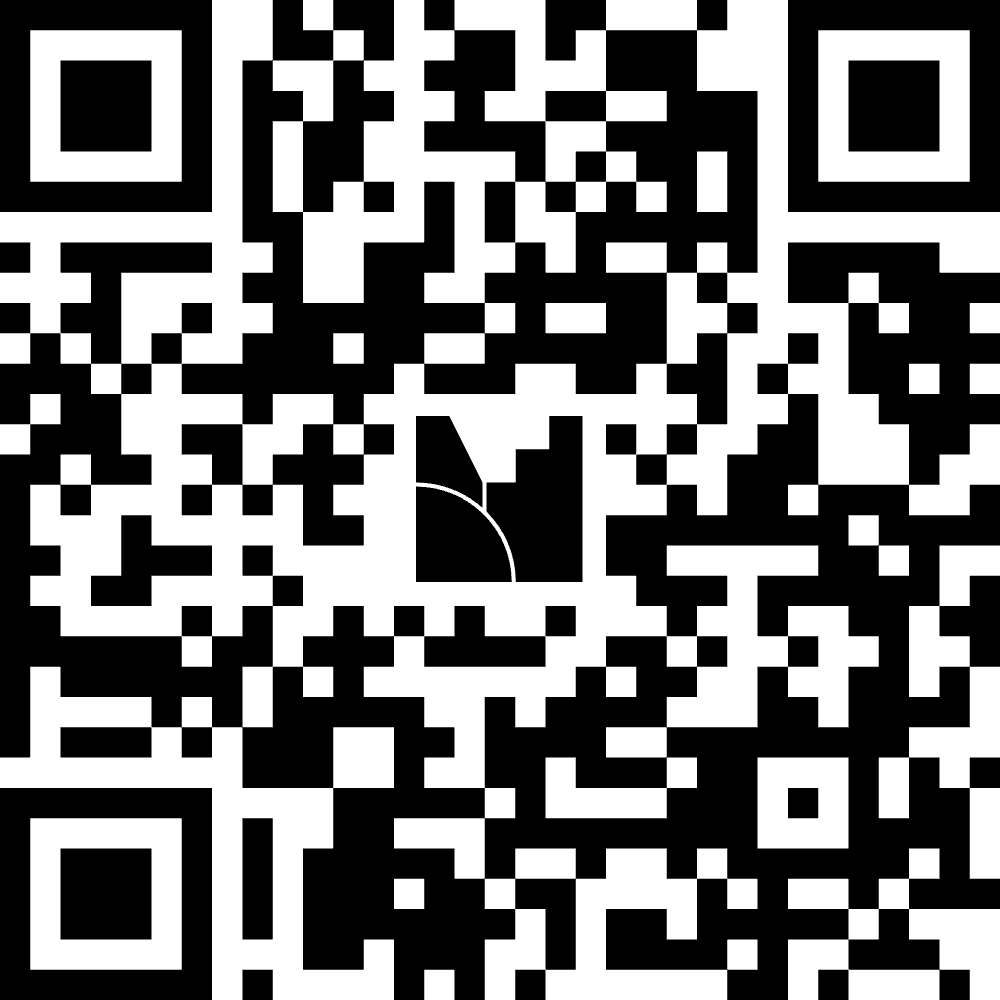
We will use mentimeter to capture questions from the floor, and we'll do our best to answer them. It might be convenient to use your phone for questions, so point it here
Tutorial structure
Beyond Fragments: A Unified Python Ecosystem for Robotics, Vision, and Control; Peter (45 minutes)
Head over to Peter's README.
From Research Code to Running Systems: Cross-Platform Robotics and ML Workflows; Tobi (45 minutes)
Locally running Tobi's presentation (recommended!)
To follow Tobi's Part 2 presentation locally:
- Install pixi:
- On Unix (Linux/MacOS):
curl -fsSL https://pixi.sh/install.sh | sh - On Windows:
powershell -ExecutionPolicy ByPass -c "irm -useb https://pixi.sh/install.ps1 | iex" - Make sure to restart your shell after installation!
- Run
pixi run presentationwithin this directory in a terminal.
Run Tobi's presentation on GitHub codespaces
- From the repository page, select the Code button.
- Instead of cloning the repository to your local machine, select the Codespaces tab.
- Do not open the Codespace using the default configuration. Some examples may not run correctly with the default resource allocation.
- Instead, select: "New with options". Recommended configuration: 8 cores as a minimum recommended option or 16 cores for best performance, where available
- After selecting the machine type, create the Codespace. GitHub will open a cloud-based VS Code environment and automatically begin setting up the development environment for the repository. The Codespace setup process will install and configure the required dependencies, including pixi, which is used to manage the software environment.
- Running Graphical Examples. Some examples use graphical output. These will run in a dedicated graphical window within the Codespace environment. For graphical displays, open
vnc_lite.html. - Notes
- The initial setup may take several minutes, particularly when using the repository for the first time.
- If graphical examples do not appear, check the VNC display through vnc_lite.html. The link to the port can also be found through the ports tab, under Codespaces desktop.
- On first attach, the presentation also auto-starts once in the container. To trigger that one-time startup again, remove
~/.cache/icra2026_presentation_autostartedin the Codespace.
Abstract
Robotics is powered by software. The tools we use shape the pace of innovation in research, drive growth in industry, and underpin the education of future developers. This hands-on tutorial presents a modern view of robotics software through live coding examples.
We begin with open-source Python toolboxes for robotics, machine vision, and spatial mathematics, illustrating how they enable clear abstractions and rapid prototyping of complex systems. We then show how these tools can be executed, shared, and extended across major platforms and even in the browser using Pixi and the conda-forge ecosystem.
Participants will see how robotics frameworks such as ROS and machine learning frameworks such as PyTorch can be composed into portable workflows, reducing setup overhead and enabling reproducible experimentation and large-scale benchmarking, including applications such as SLAM.
This tutorial equips attendees to move from fragmented research code to robust, running systems that can be deployed across platforms, from phones to high-performance computing environments, and readily extended by others.
Format
We have 90 minutes, and we'll take half each.
-
Peter: Beyond Fragments: A Unified Python Ecosystem for Robotics, Vision, and Control
-
Tobi: From Research Code to Running Systems: Cross-Platform Robotics and ML Workflows
We will be demonstrating tools: what they do, how to use them, and how to install them. Lots of terminal time, not so much Powerpoints.
The room we've been allocated seats 470 so it might be a big crowd. We will use mentimeter to capture questions from the floor and we'll do our best to answer them.
Presenters

Peter Corke is a robotics researcher, educator, and open-source creator. He is a distinguished professor emeritus at Queensland University of Technology; a fellow of the IEEE and has held many editorial roles. He wrote the best selling textbook “Robotics, Vision, and Control”, now in its third edition; created robotics and vision Toolboxes for Python; and has won international recognition for teaching, including the 2025 Engelberger Award for Education.
Tobias Fischer is a Senior Lecturer and ARC DECRA Fellow at the Queensland University of Technology, working on robotic perception and localisation, including in marine environments. He is a strong advocate for open-source robotics and reproducible research, developing cross-platform software workflows that integrate robotics and machine learning. He is a Fellow of the IET, Senior Member of the IEEE, Associate Editor for the IEEE Robotics and Automation Letters, and co-chair of the IEEE-RAS Women in Engineering committee.
Additional resources
Repositories
- Machine Vision Toolbox for Python
- Robotics Toolbox for Python
- Spatial Maths for Python
- bdsim: Block Diagram Simulation for Python
- RoboStack - currently providing ros-noetic, ros2-humble, ros2-jazzy, ros2-kilted and ros2-rolling
- Pixi
Papers and books
- Robotics, Vision and Control Fundamental Algorithms in Python
- Not your grandmother’s toolbox – the Robotics Toolbox reinvented for Python, IEEE International Conference on Robotics and Automation (ICRA) 2021
- A RoboStack Tutorial: Using the Robot Operating System Alongside the Conda and Jupyter Data Science Ecosystems , IEEE Robotics & Automation Magazine (Volume: 29, Issue: 2, June 2022)
- Pixi: Unified Software Development and Distribution for Robotics and AI, arXiv:2511.04827
- ROS2WASM: Bringing the Robot Operating System to the Web, IEEE International Conference on Robotics and Automation (ICRA) 2025
- VSLAM-LAB: A Comprehensive Framework for Visual SLAM Methods and Datasets, IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2025
Acknowledgements
Tobi would like to thank the fantastic team at prefix.dev for the great work on Pixi over the last few years, and the nice and productive collaboration. He also thanks all contributors to RoboStack, and in particular Silvio Traversaro for his never-ending support. Tobi acknowledges partial support from the QUT Centre for Robotics and an ARC DECRA Fellowship DE240100149.
Similar repos


Languages
Jupyter Notebook
59.6%
Python
34.0%
HTML
4.6%
Shell
1.8%
Resources for the ICRA2026 Keynote Tutorial "Title: Building, running and deploying modern software tools for robotics"
Jupyter Notebook
74
129 commits
updated Jun 10, 2026
README
Building, running and deploying modern software tools for robotics
- ICRA2026 Keynote Tutorial 3 (was 4)
- When: Wednesday, 3 June 15:00 to 16:30 (90 minutes)
- Where: Strauss 1-2
Important links
On the day, go to the tutorial landing page
https://petercorke.github.io/ICRA2026-modern-software-tools/
and from there you get access to all the resources we'll use in the session.
We will use mentimeter to capture questions from the floor, and we'll do our best to answer them. It might be convenient to use your phone for questions, so point it here
Tutorial structure
Beyond Fragments: A Unified Python Ecosystem for Robotics, Vision, and Control; Peter (45 minutes)
Head over to Peter's README.
From Research Code to Running Systems: Cross-Platform Robotics and ML Workflows; Tobi (45 minutes)
Locally running Tobi's presentation (recommended!)
To follow Tobi's Part 2 presentation locally:
- Install pixi:
- On Unix (Linux/MacOS):
curl -fsSL https://pixi.sh/install.sh | sh - On Windows:
powershell -ExecutionPolicy ByPass -c "irm -useb https://pixi.sh/install.ps1 | iex" - Make sure to restart your shell after installation!
- Run
pixi run presentationwithin this directory in a terminal.
Run Tobi's presentation on GitHub codespaces
- From the repository page, select the Code button.
- Instead of cloning the repository to your local machine, select the Codespaces tab.
- Do not open the Codespace using the default configuration. Some examples may not run correctly with the default resource allocation.
- Instead, select: "New with options". Recommended configuration: 8 cores as a minimum recommended option or 16 cores for best performance, where available
- After selecting the machine type, create the Codespace. GitHub will open a cloud-based VS Code environment and automatically begin setting up the development environment for the repository. The Codespace setup process will install and configure the required dependencies, including pixi, which is used to manage the software environment.
- Running Graphical Examples. Some examples use graphical output. These will run in a dedicated graphical window within the Codespace environment. For graphical displays, open
vnc_lite.html. - Notes
- The initial setup may take several minutes, particularly when using the repository for the first time.
- If graphical examples do not appear, check the VNC display through vnc_lite.html. The link to the port can also be found through the ports tab, under Codespaces desktop.
- On first attach, the presentation also auto-starts once in the container. To trigger that one-time startup again, remove
~/.cache/icra2026_presentation_autostartedin the Codespace.
Abstract
Robotics is powered by software. The tools we use shape the pace of innovation in research, drive growth in industry, and underpin the education of future developers. This hands-on tutorial presents a modern view of robotics software through live coding examples.
We begin with open-source Python toolboxes for robotics, machine vision, and spatial mathematics, illustrating how they enable clear abstractions and rapid prototyping of complex systems. We then show how these tools can be executed, shared, and extended across major platforms and even in the browser using Pixi and the conda-forge ecosystem.
Participants will see how robotics frameworks such as ROS and machine learning frameworks such as PyTorch can be composed into portable workflows, reducing setup overhead and enabling reproducible experimentation and large-scale benchmarking, including applications such as SLAM.
This tutorial equips attendees to move from fragmented research code to robust, running systems that can be deployed across platforms, from phones to high-performance computing environments, and readily extended by others.
Format
We have 90 minutes, and we'll take half each.
-
Peter: Beyond Fragments: A Unified Python Ecosystem for Robotics, Vision, and Control
-
Tobi: From Research Code to Running Systems: Cross-Platform Robotics and ML Workflows
We will be demonstrating tools: what they do, how to use them, and how to install them. Lots of terminal time, not so much Powerpoints.
The room we've been allocated seats 470 so it might be a big crowd. We will use mentimeter to capture questions from the floor and we'll do our best to answer them.
Presenters
Peter Corke is a robotics researcher, educator, and open-source creator. He is a distinguished professor emeritus at Queensland University of Technology; a fellow of the IEEE and has held many editorial roles. He wrote the best selling textbook “Robotics, Vision, and Control”, now in its third edition; created robotics and vision Toolboxes for Python; and has won international recognition for teaching, including the 2025 Engelberger Award for Education.
Tobias Fischer is a Senior Lecturer and ARC DECRA Fellow at the Queensland University of Technology, working on robotic perception and localisation, including in marine environments. He is a strong advocate for open-source robotics and reproducible research, developing cross-platform software workflows that integrate robotics and machine learning. He is a Fellow of the IET, Senior Member of the IEEE, Associate Editor for the IEEE Robotics and Automation Letters, and co-chair of the IEEE-RAS Women in Engineering committee.
Additional resources
Repositories
- Machine Vision Toolbox for Python
- Robotics Toolbox for Python
- Spatial Maths for Python
- bdsim: Block Diagram Simulation for Python
- RoboStack - currently providing ros-noetic, ros2-humble, ros2-jazzy, ros2-kilted and ros2-rolling
- Pixi
Papers and books
- Robotics, Vision and Control Fundamental Algorithms in Python
- Not your grandmother’s toolbox – the Robotics Toolbox reinvented for Python, IEEE International Conference on Robotics and Automation (ICRA) 2021
- A RoboStack Tutorial: Using the Robot Operating System Alongside the Conda and Jupyter Data Science Ecosystems , IEEE Robotics & Automation Magazine (Volume: 29, Issue: 2, June 2022)
- Pixi: Unified Software Development and Distribution for Robotics and AI, arXiv:2511.04827
- ROS2WASM: Bringing the Robot Operating System to the Web, IEEE International Conference on Robotics and Automation (ICRA) 2025
- VSLAM-LAB: A Comprehensive Framework for Visual SLAM Methods and Datasets, IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2025
Acknowledgements
Tobi would like to thank the fantastic team at prefix.dev for the great work on Pixi over the last few years, and the nice and productive collaboration. He also thanks all contributors to RoboStack, and in particular Silvio Traversaro for his never-ending support. Tobi acknowledges partial support from the QUT Centre for Robotics and an ARC DECRA Fellowship DE240100149.
Similar repos
Languages
Jupyter Notebook
59.6%
Python
34.0%
HTML
4.6%
Shell
1.8%