Making an ESP32-based quadcopter from scratch
See the code
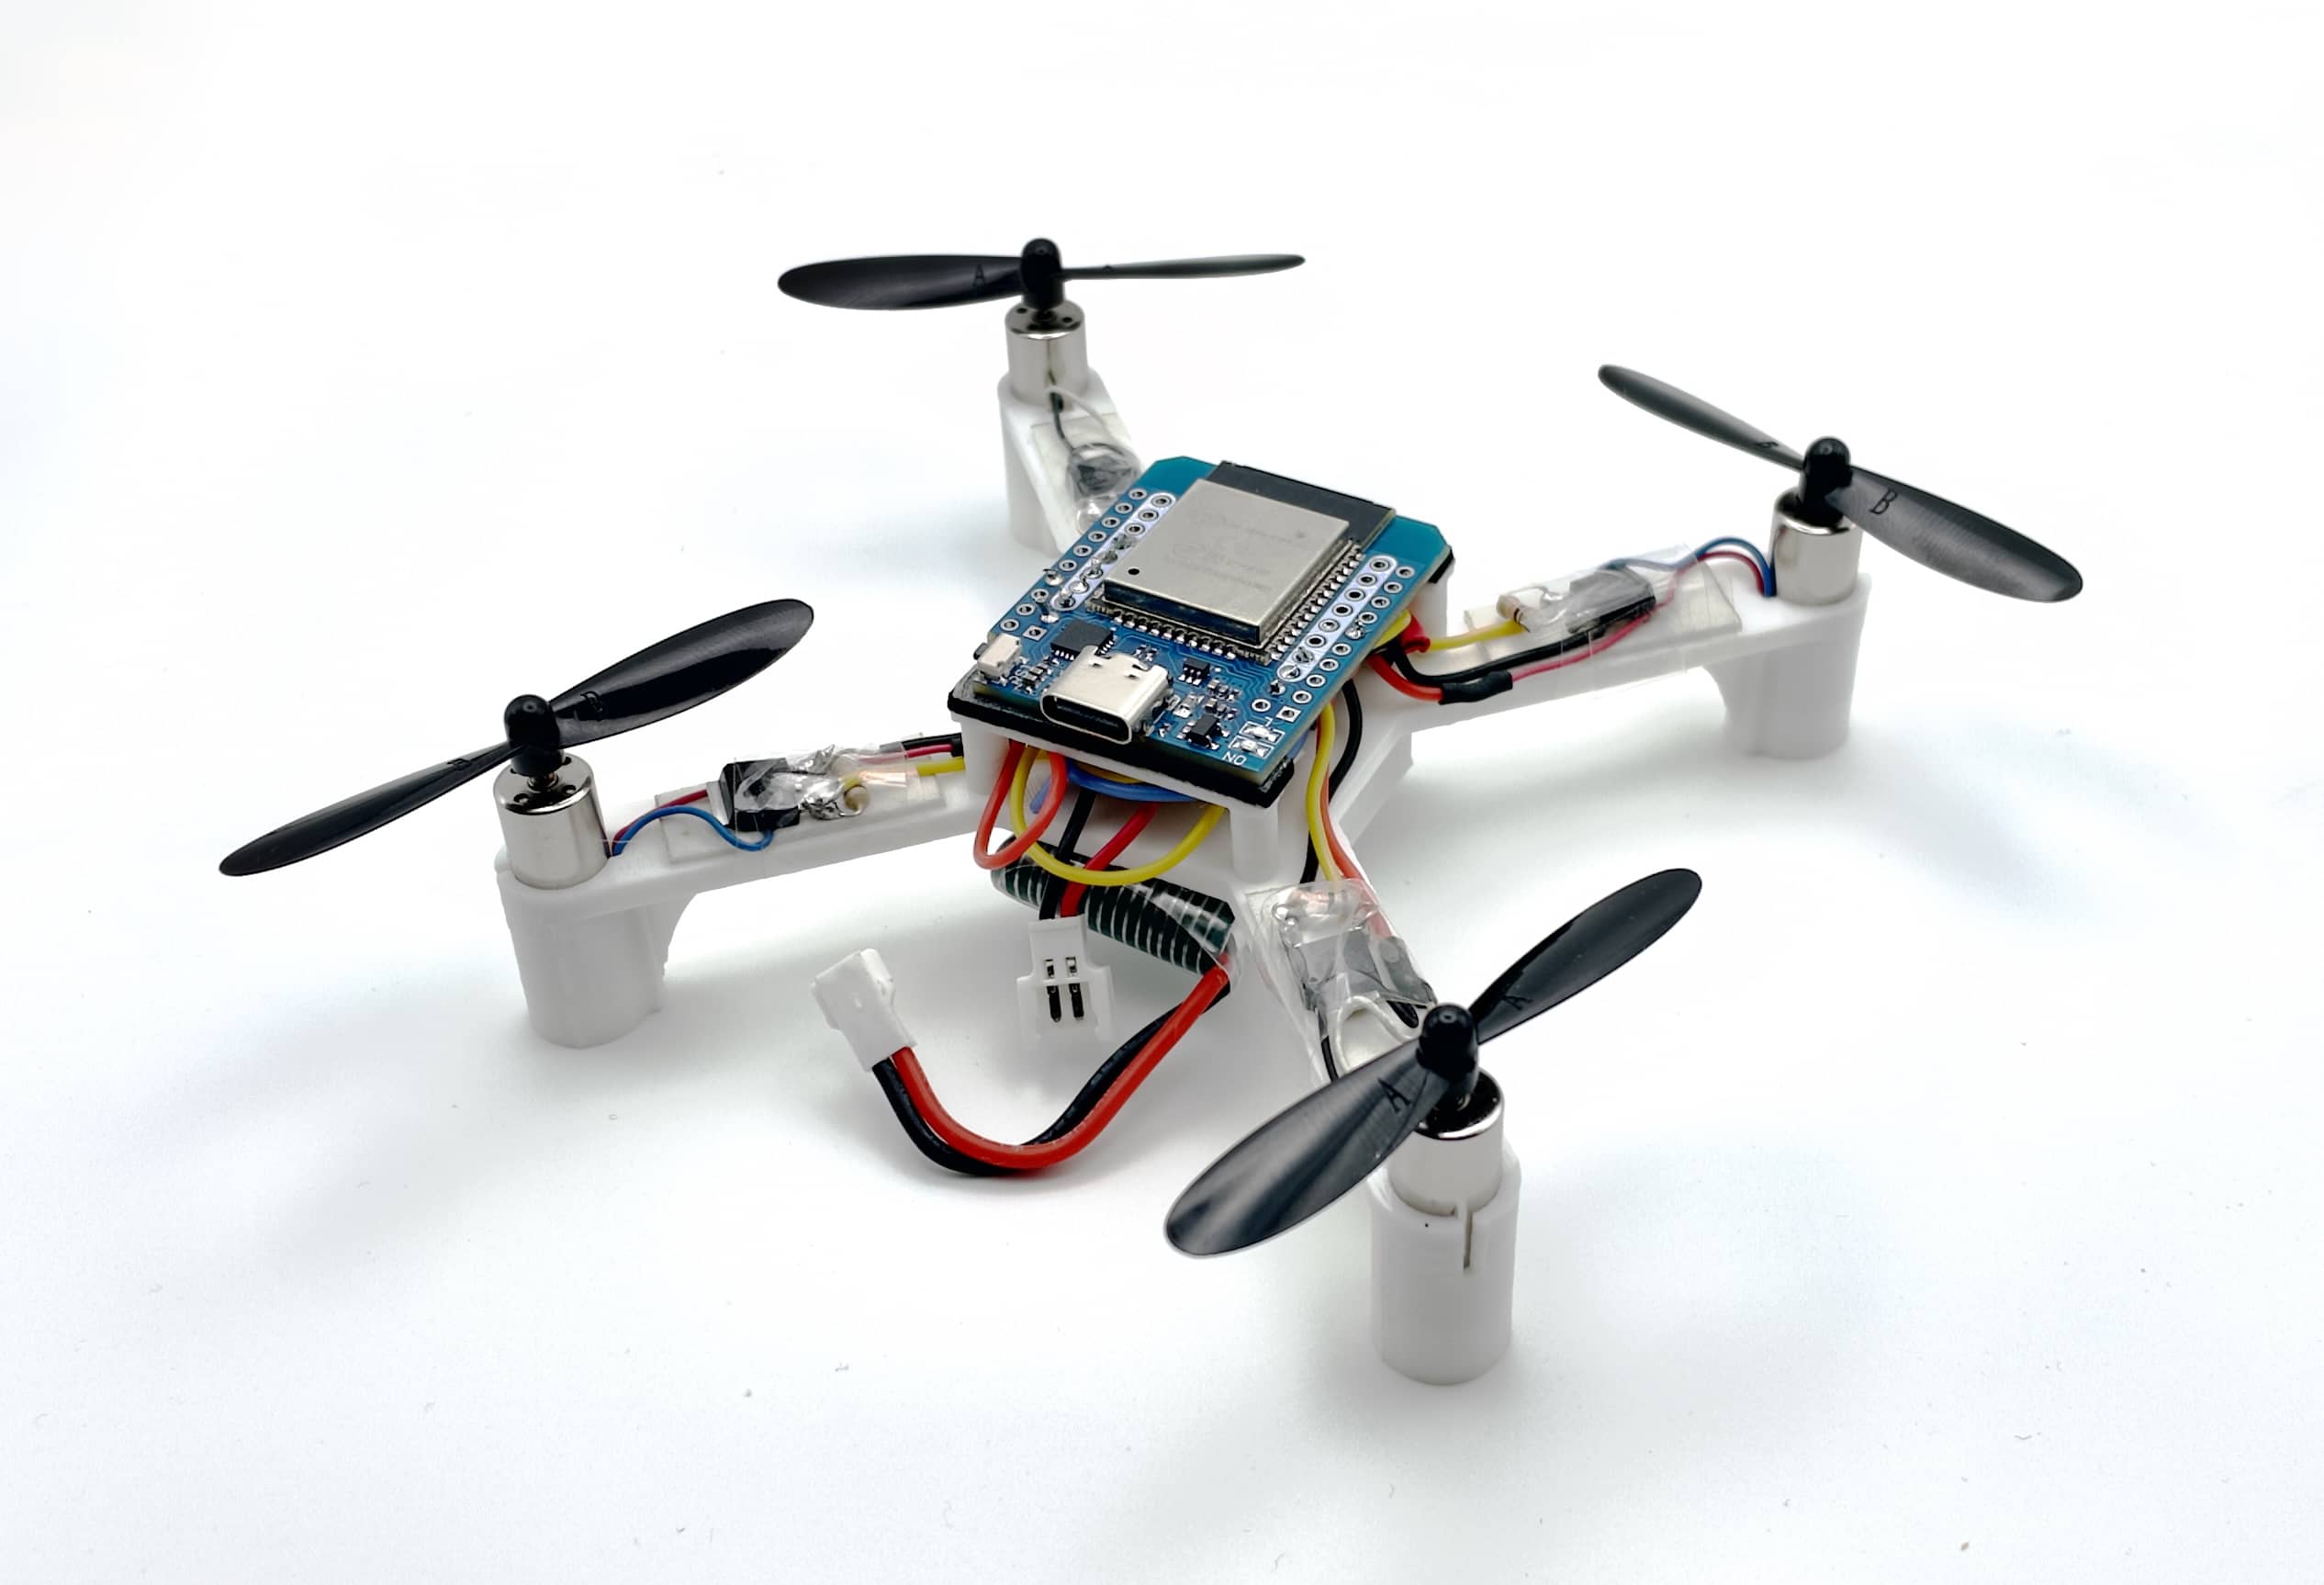
Flix (flight + X) — open source ESP32-based quadcopter made from scratch.
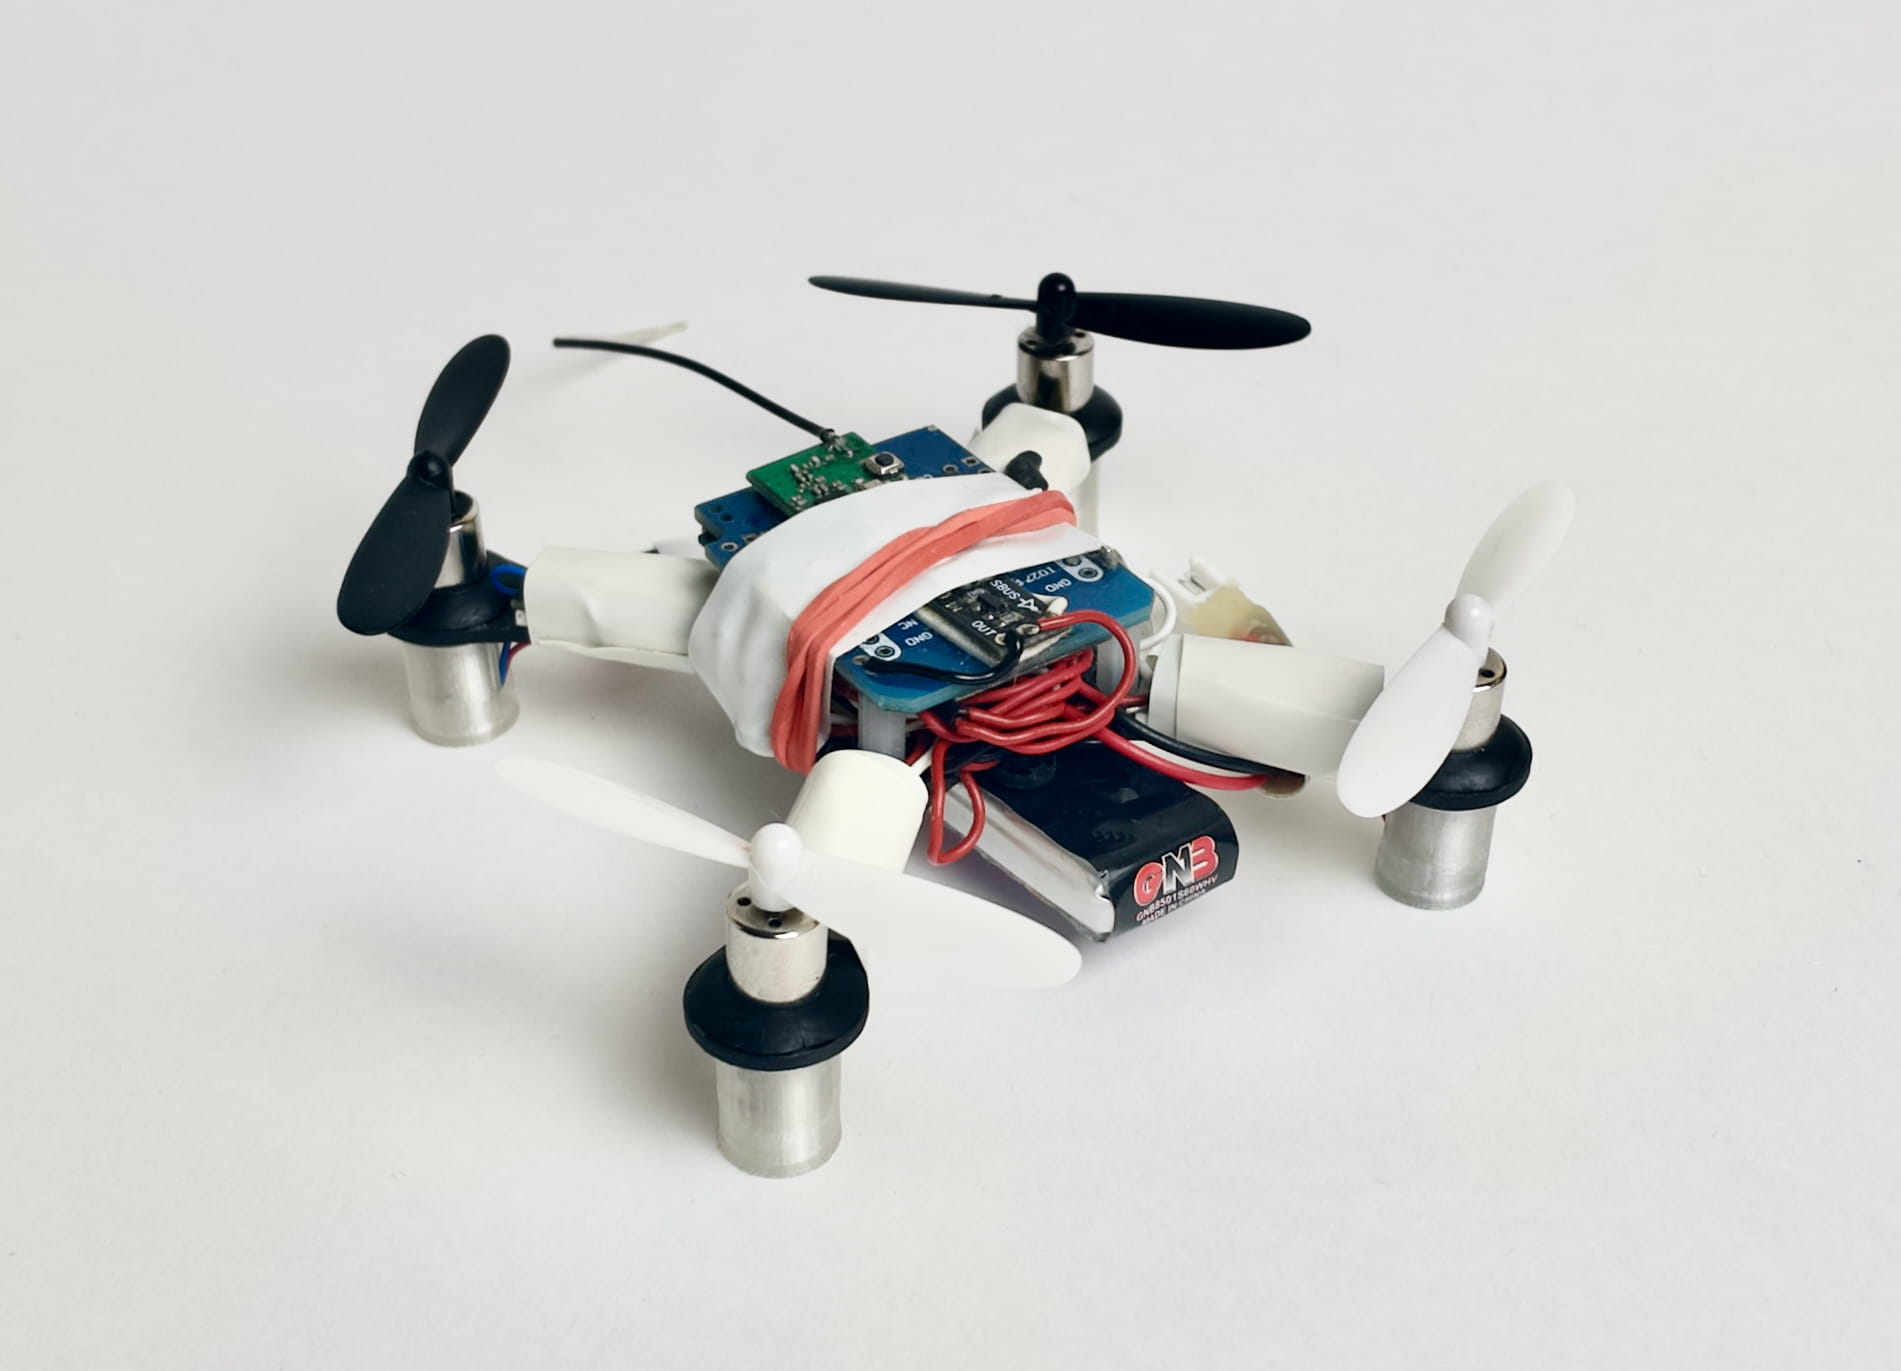
| Version 1.1 (3D-printed frame) | Version 0 |
 |  |
See detailed demo video: https://youtu.be/hT46CZ1CgC4.
Version 0 demo video: https://youtu.be/8GzzIQ3C6DQ.

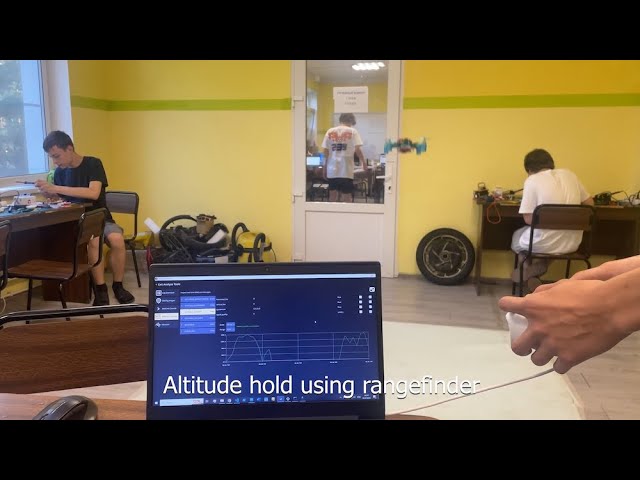
Usage in education (RoboCamp 2025): https://youtu.be/Wd3yaorjTx0.
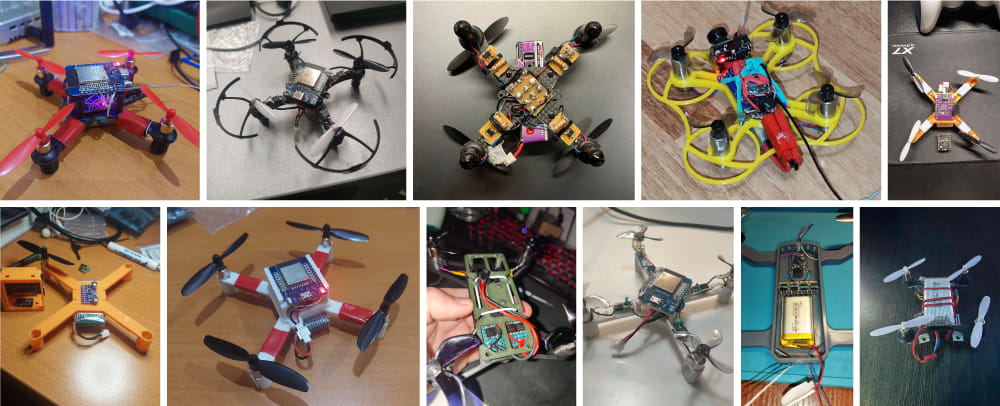
See the user builds gallery:
The official PCB (Flix2) is in development now. Follow the project's channel to track the progress.
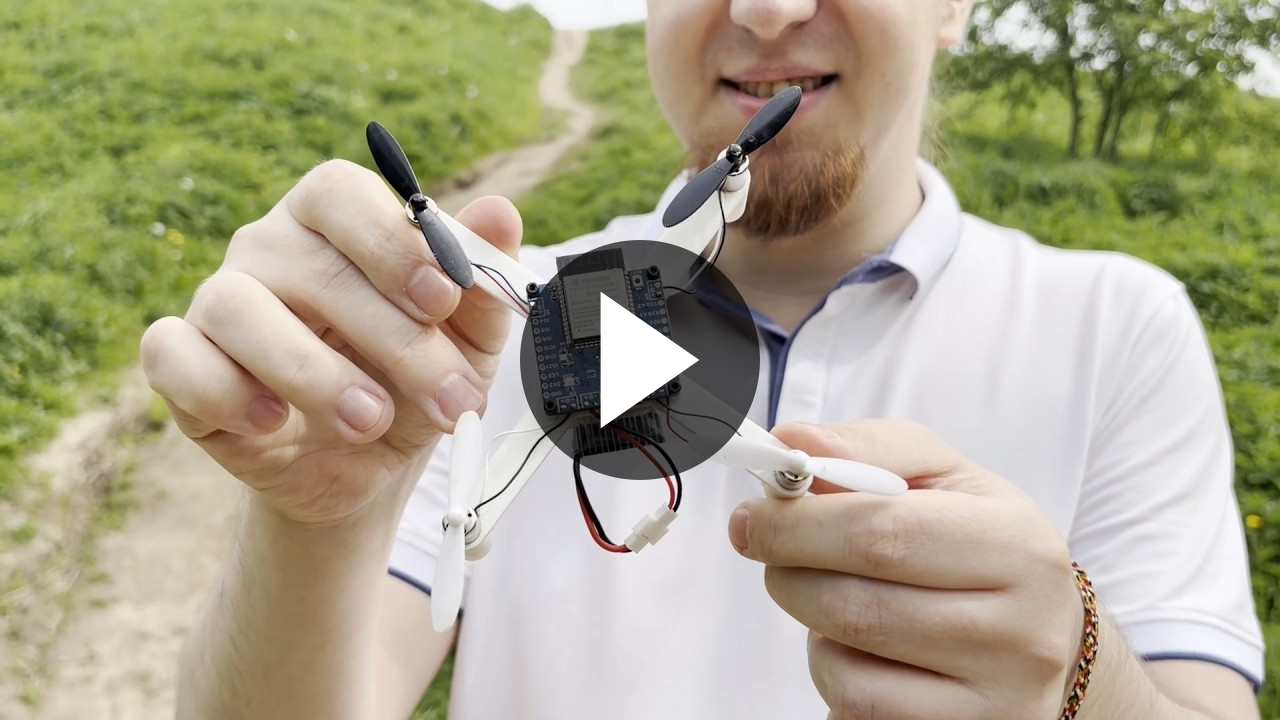
Outdoor flights demo video of the current prototype:
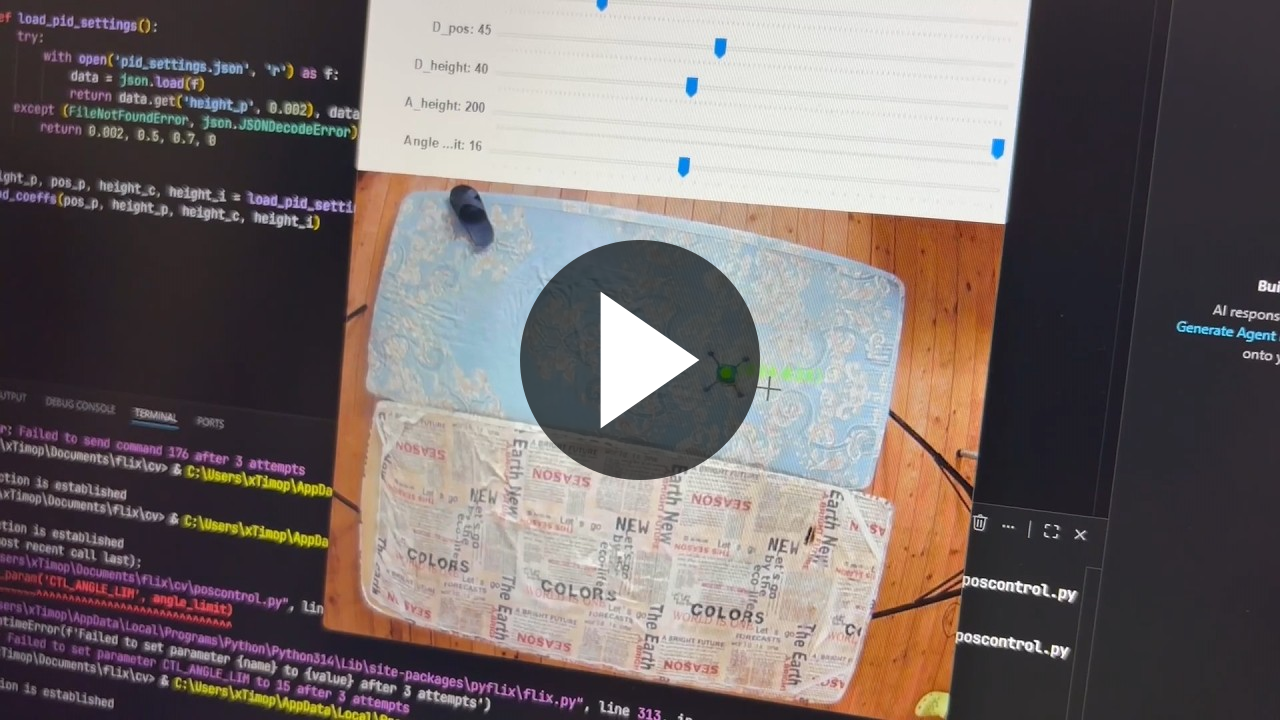
The position control feature is in development. RoboCamp 2026 demo (using an overhead camera, sources):
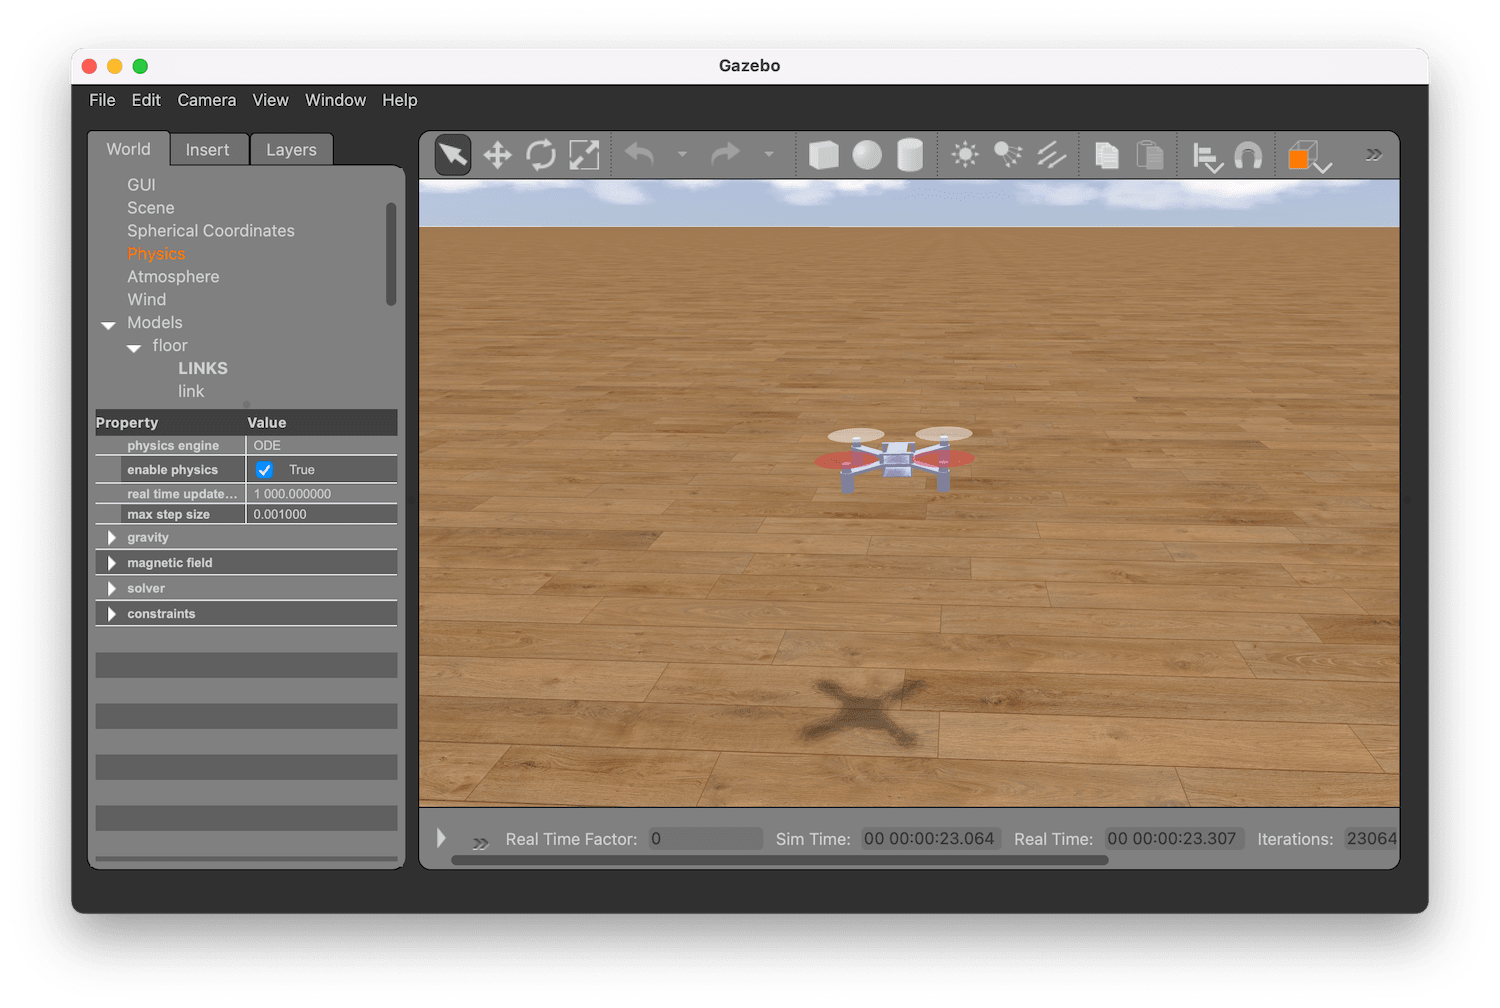
The simulator is implemented using Gazebo and runs the original Arduino code:
Additional articles:
| Type | Part | Image | Quantity |
|---|---|---|---|
| Microcontroller board | ESP32 Mini. ESP32-S3/ESP32-C3 boards are also supported. | 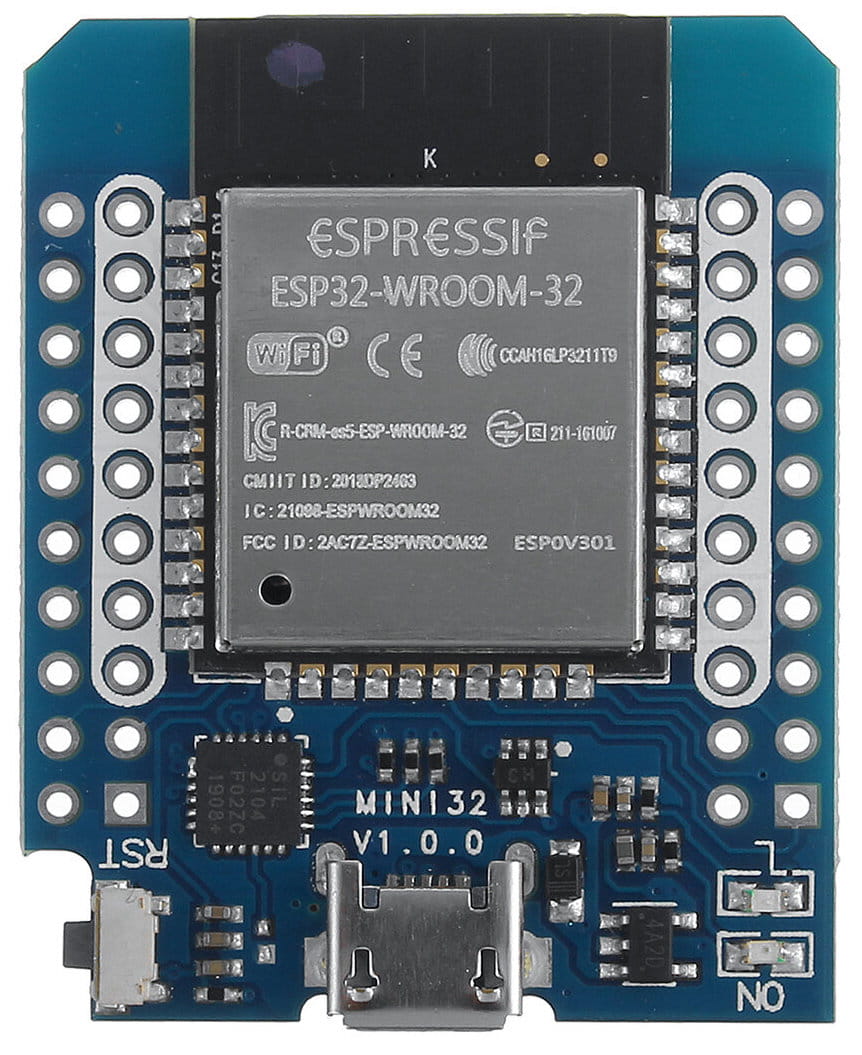 | 1 |
| IMU (and barometer¹) board | GY‑91, MPU-9265 (or other MPU‑9250/MPU‑6500 board) ICM20948V2 (ICM‑20948) GY-521 (MPU-6050) | 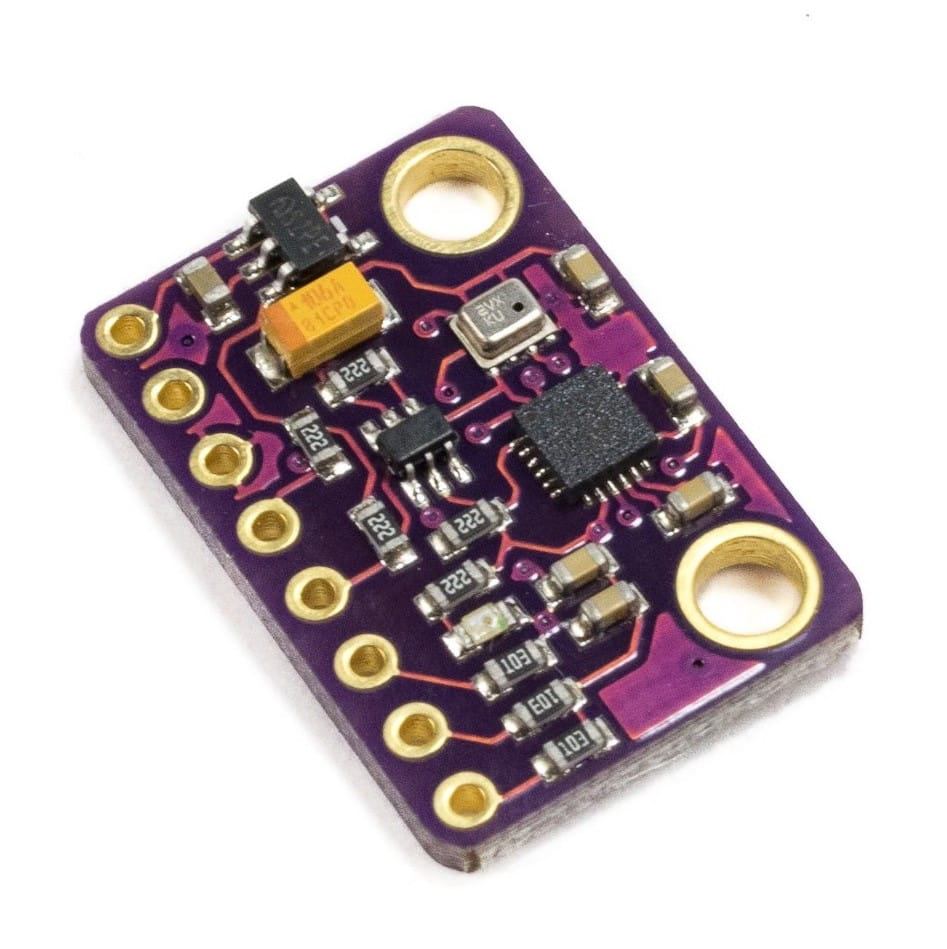 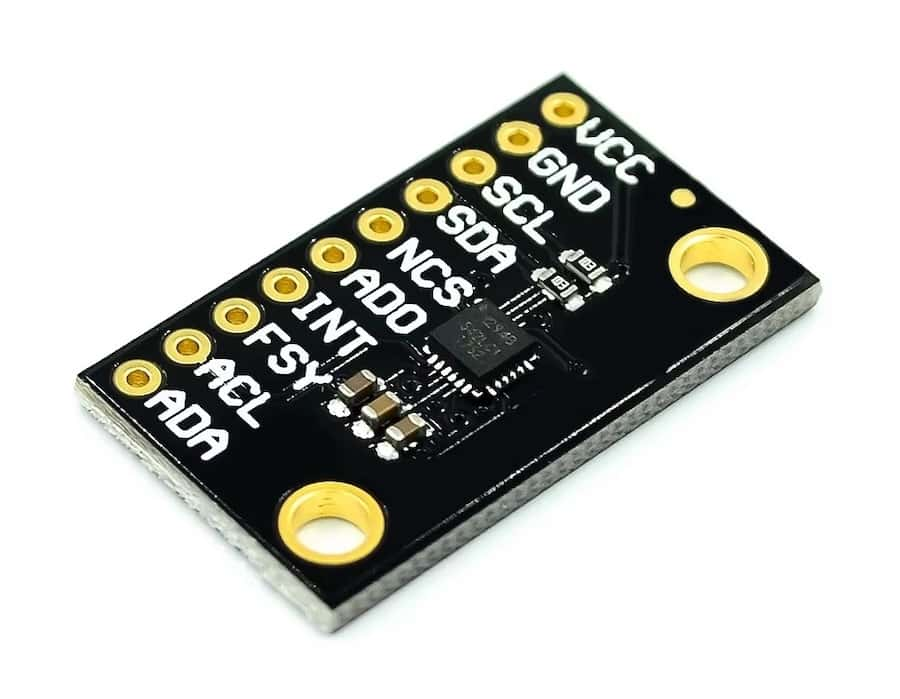 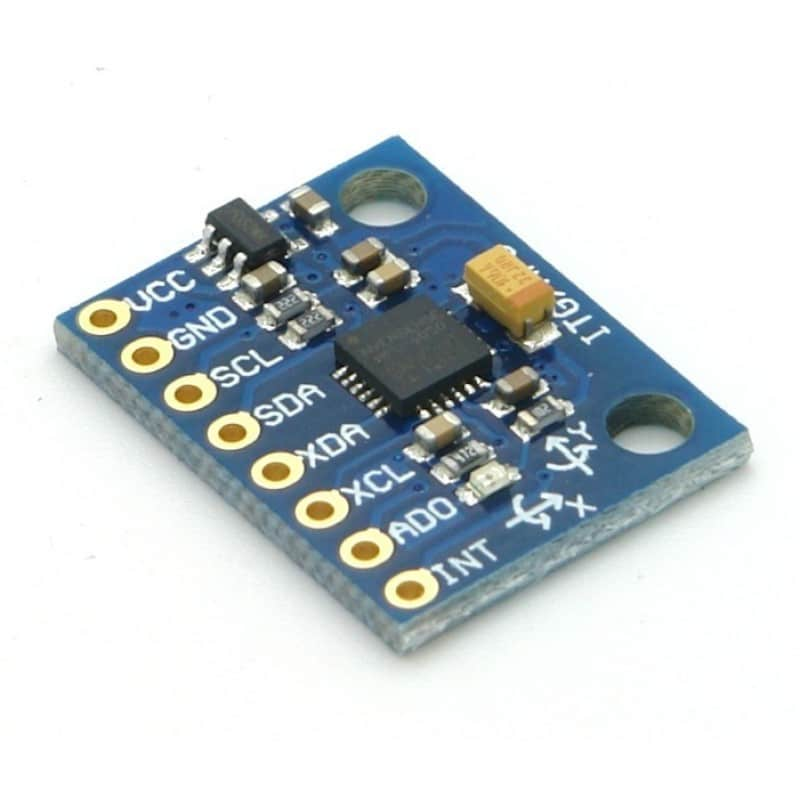 | 1 |
| Boost converter (optional, for more stable power supply) | 5V output | 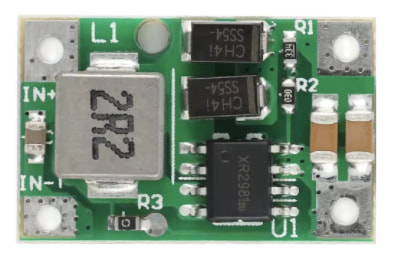 | 1 |
| Motor | 8520 3.7V brushed motor. Motor with exact 3.7V voltage is needed, not ranged working voltage (3.7V — 6V). Make sure the motor shaft diameter and propeller hole diameter match! | 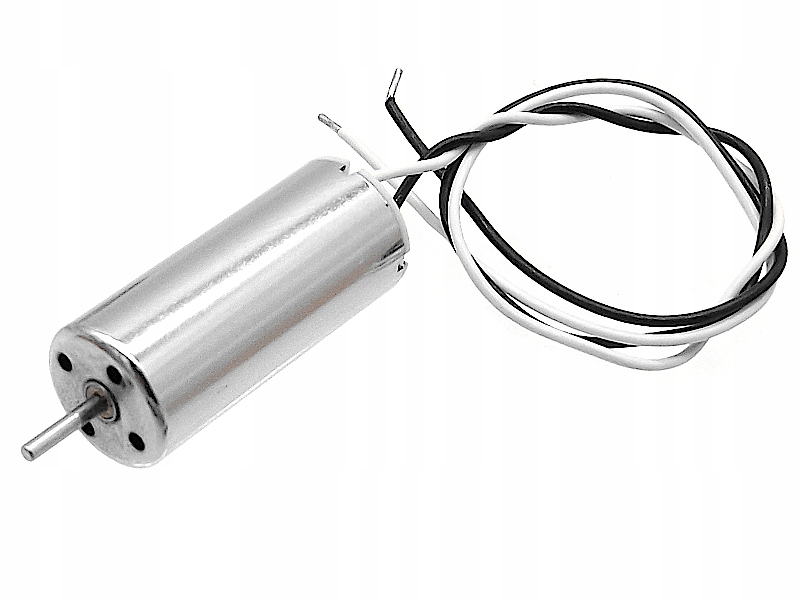 | 4 |
| Propeller | 55 mm or 65 mm | 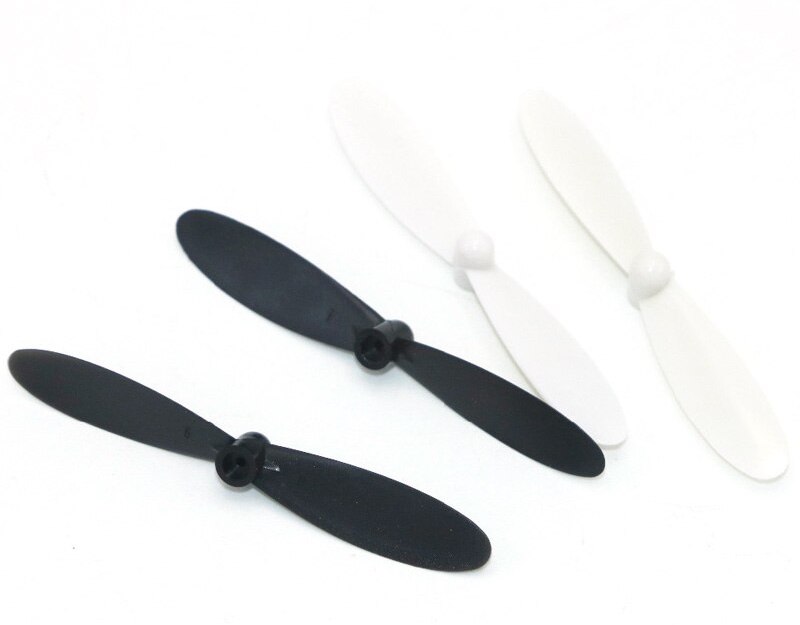 | 4 |
| MOSFET (transistor) | UMW 100N03A or analog. Warning: don't use KIA 100N03A or other manufacturers, they might not work! | 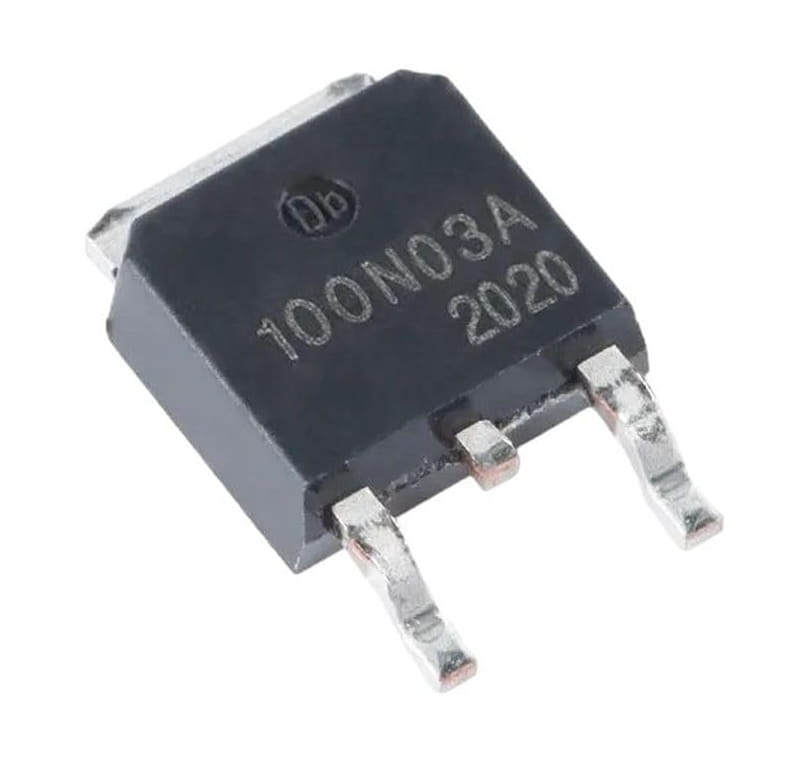 | 4 |
| Pull-down resistor Voltage measurement resistor | 10 kΩ | 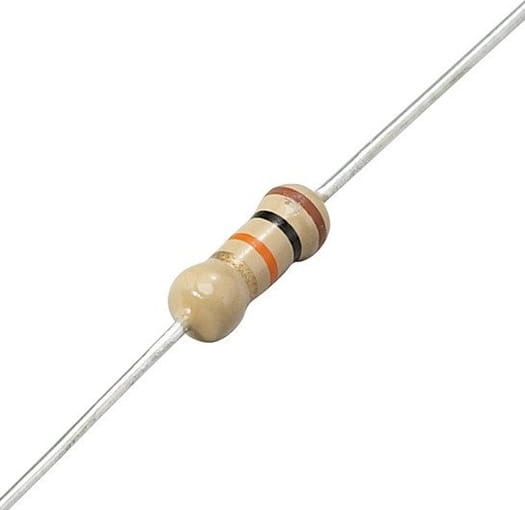 | 6 |
| 3.7V Li-Po battery | LW 952540 (or any compatible by the size). Make sure the battery has enough discharge rate and capacity — 25C with 1000 mAh or more is recommended! | 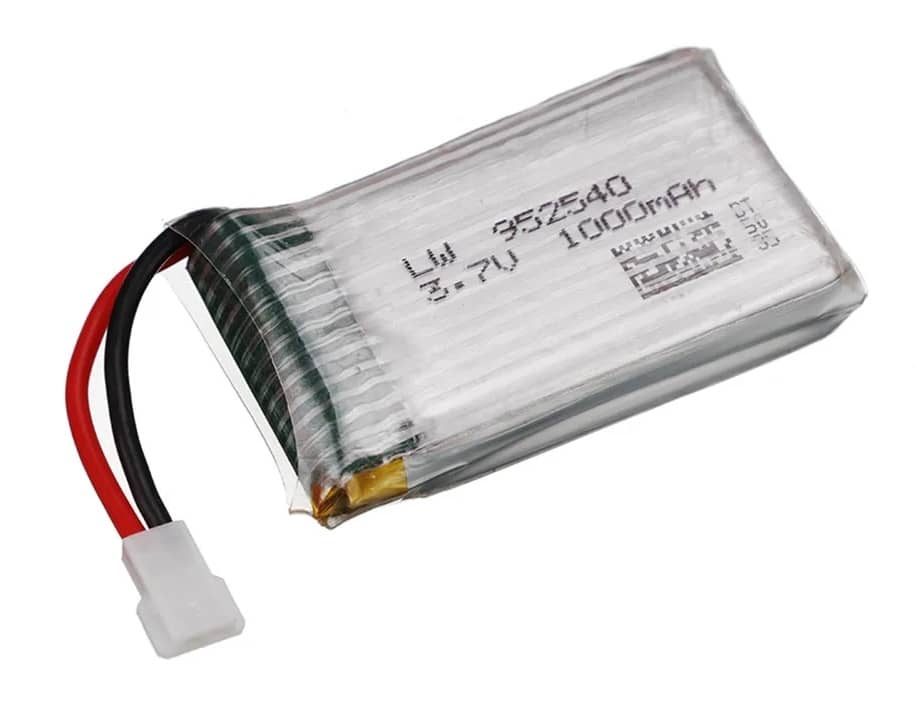 | 1 |
| Battery connector cable | MX2.0 2P female | 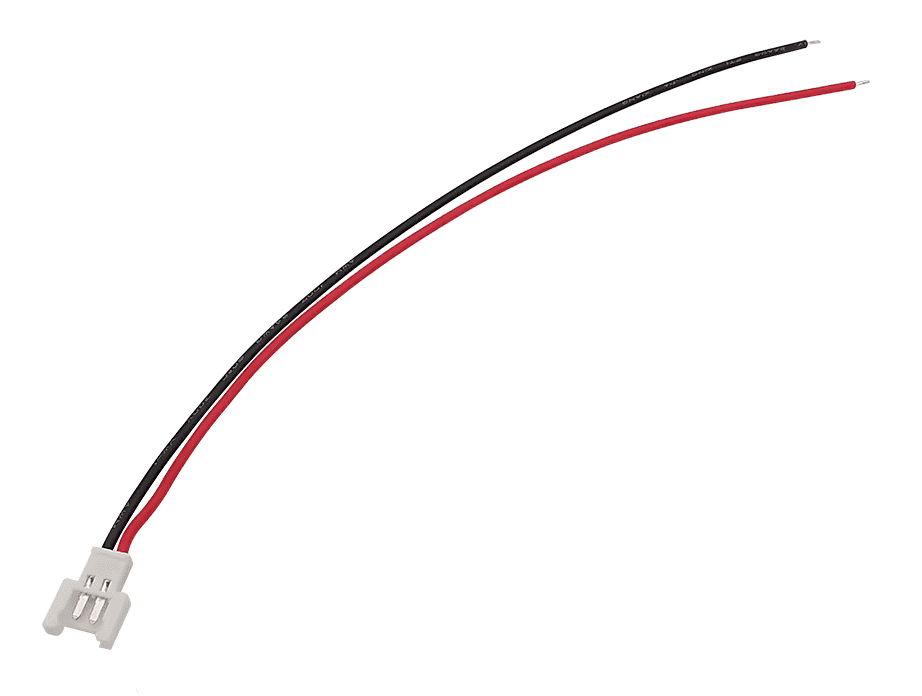 | 1 |
| Li-Po Battery charger | Any | 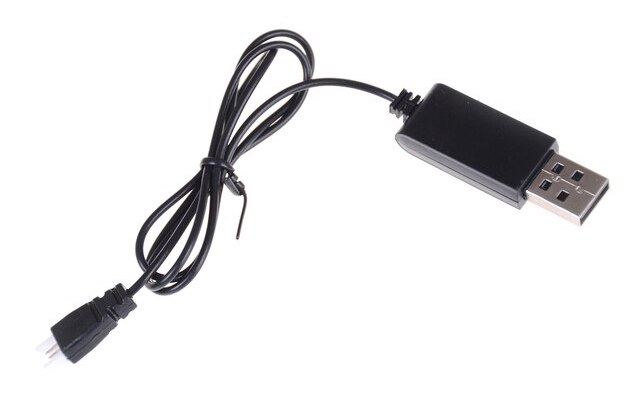 | 1 |
| Screws for IMU board mounting | M3x5 |  | 2 |
| Screws for frame assembly | M1.4x5 |  | 4 |
| Frame main part | 3D printed²: stl stepRecommended settings: layer 0.2 mm, line 0.4 mm, infill 100%. | 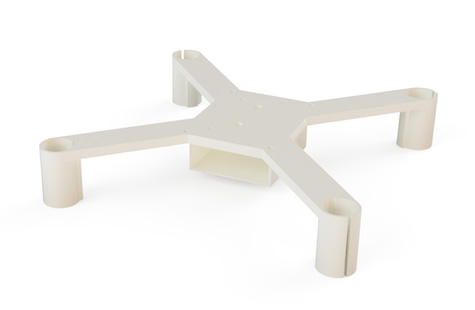 | 1 |
| Frame top part | 3D printed: stl step | 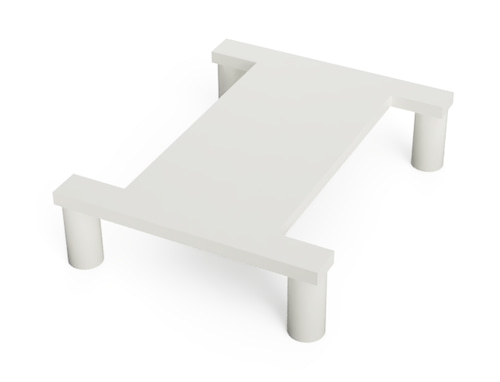 | 1 |
| Washer for IMU board mounting | 3D printed: stl step | 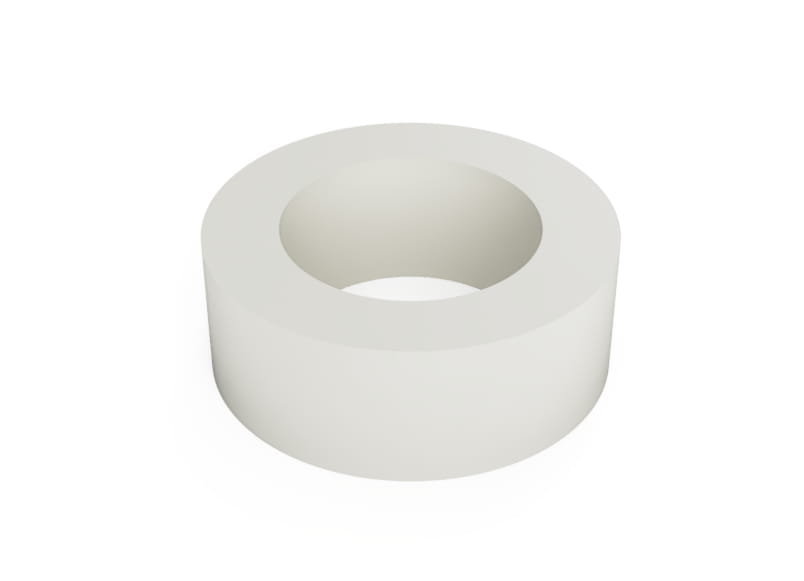 | 2 |
| Controller (recommended) | CC2500 transmitter, like BetaFPV LiteRadio CC2500 (RC receiver/Wi-Fi). Two-sticks gamepad (Wi-Fi only) — see recommended gamepads. Other⁵ | 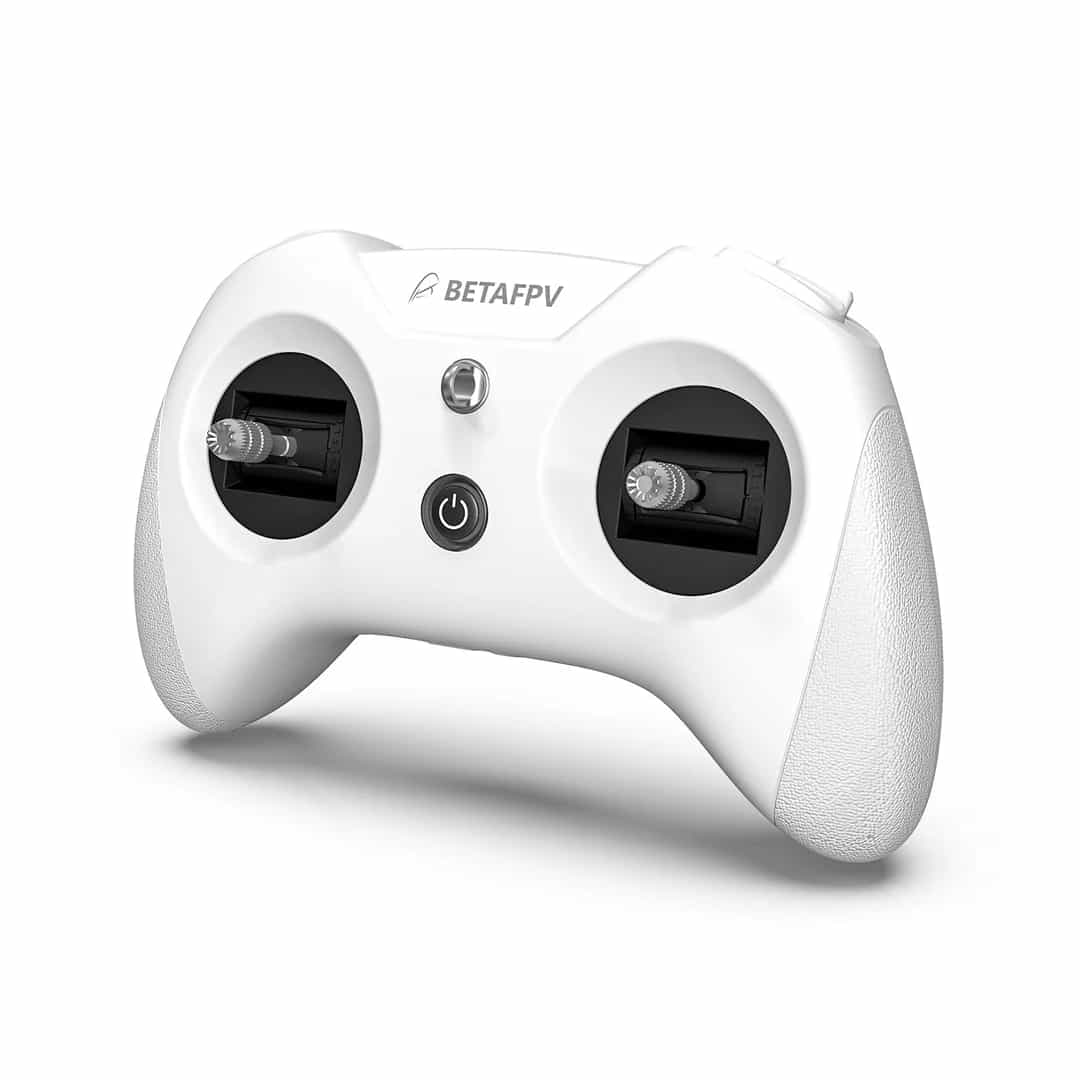 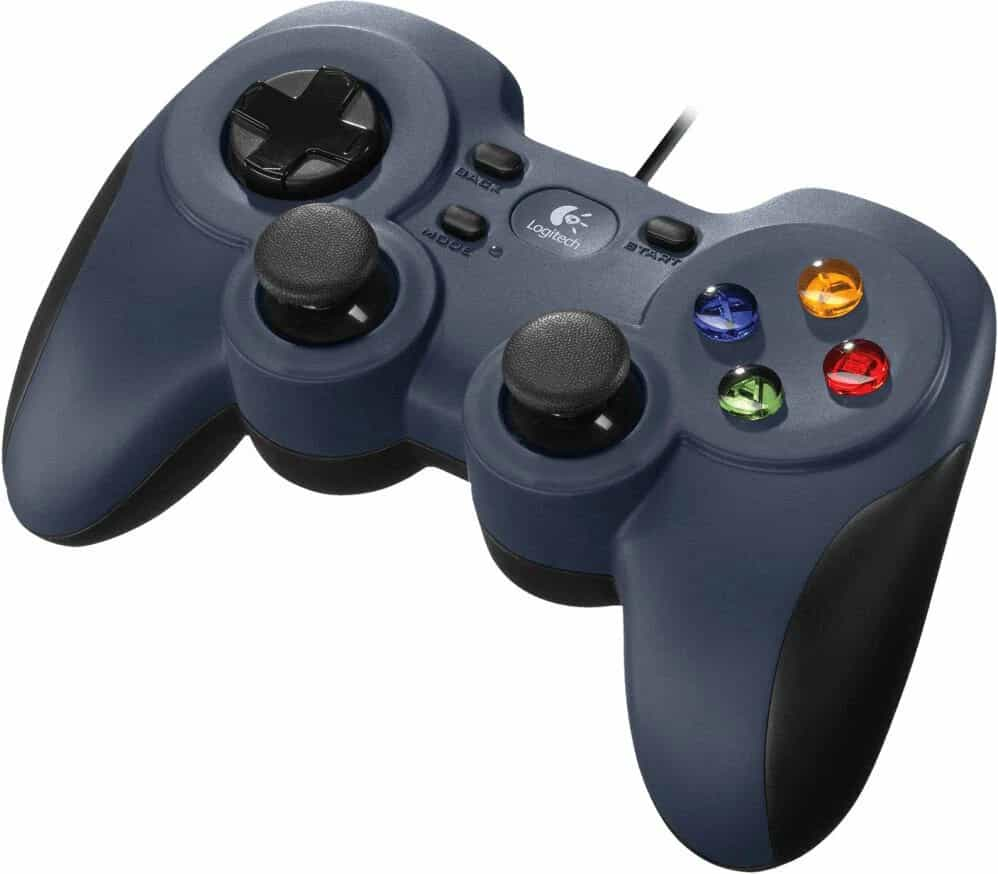 | 1 |
| RC receiver (optional) | DF500 or other³ | 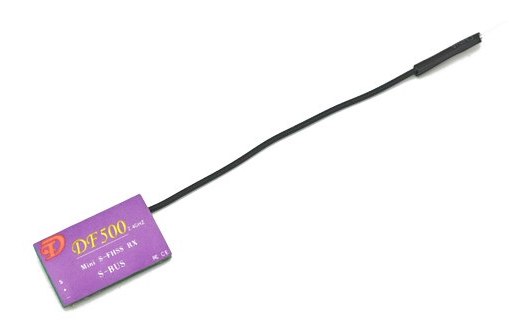 | 1 |
| Wires | 28 AWG recommended |  | |
| Tape, double-sided tape |
¹ — barometer is not used for now.
² — this frame is optimized for GY-91 board, if using other, the board mount holes positions should be modified.
³ — you also may use any transmitter-receiver pair with SBUS interface.
Tools required for assembly:
Feel free to modify the design and or code, and create your own improved versions. Send your results to the official Telegram chat, or directly to the author (E-mail, Telegram).

(Dashed elements are optional).
Motor connection scheme:
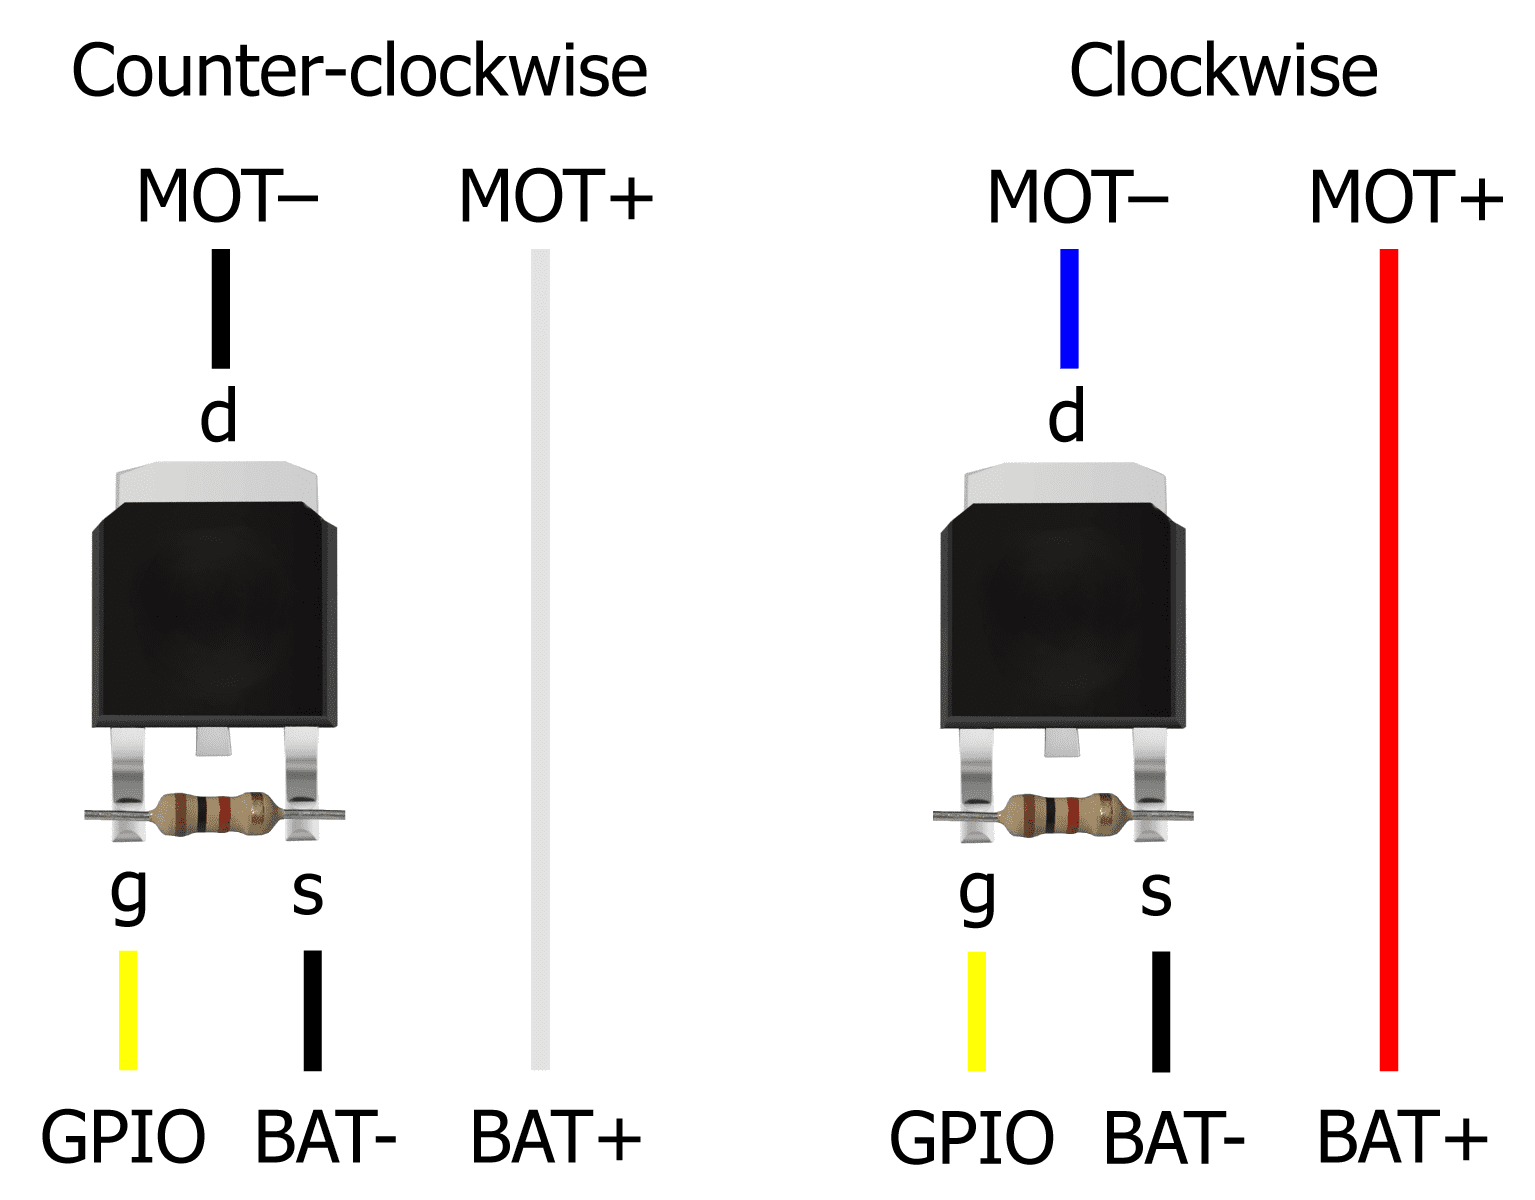
You can see a user-contributed variant of complete circuit diagram of the drone.
Power ESP32 Mini with Li-Po battery using VCC (+) and GND (-) pins.
Connect the IMU board to the ESP32 Mini using VSPI, power it using 3.3V and GND pins:
| IMU pin | ESP32 pin |
|---|---|
| GND | GND |
| 3.3V | 3.3V |
| SCL (SCK) | SVP (GPIO18) |
| SDA (MOSI) | GPIO23 |
| SAO (MISO) | GPIO19 |
| NCS | GPIO5 |
Solder pull-down resistors to the MOSFETs.
Connect the motors to the ESP32 Mini using MOSFETs, by following scheme:
| Motor | Position | Direction | Prop type | Motor wires | GPIO |
|---|---|---|---|---|---|
| Motor 0 | Rear left | Counter-clockwise | B | Black & White | GPIO12 (TDI) |
| Motor 1 | Rear right | Clockwise | A | Blue & Red | GPIO13 (TCK) |
| Motor 2 | Front right | Counter-clockwise | B | Black & White | GPIO14 (TMS) |
| Motor 3 | Front left | Clockwise | A | Blue & Red | GPIO15 (TD0) |
Clockwise motors have blue & red wires and correspond to propeller type A (marked on the propeller). Counter-clockwise motors have black & white wires correspond to propeller type B.
Optionally connect the RC receiver to the ESP32's UART2:
| Receiver pin | ESP32 pin |
|---|---|
| GND | GND |
| VIN | VCC (or 3.3V depending on the receiver) |
| Signal (TX) | GPIO4 |
Optionally connect the battery voltage divider for voltage monitoring to any ADC1 pin (e. g. GPIO32 on ESP32, GPIO3 on ESP32-S3).
ESP32 and ESP32-S3 can measure up to 3.1 V and ESP32-S3/ESP32-C3 can measure up to 2.5 V, so choose the voltage divider resistors accordingly.
This is a DIY project, and I hope you find it interesting and useful. However, it's not easy to assemble and set up, and it's provided "as is" without any warranties. There's no guarantee that it will work perfectly, or even work at all.
⚠️ The author is not responsible for any damage, injury, or loss resulting from the use of this project. Use at your own risk!
163 followers · starred Oct 2026
49 followers · starred Sep 2026
24 followers · starred Oct 2024
25 followers · starred May 2024
Making an ESP32-based quadcopter from scratch
See the code
Flix (flight + X) — open source ESP32-based quadcopter made from scratch.
| Version 1.1 (3D-printed frame) | Version 0 |
| |
See detailed demo video: https://youtu.be/hT46CZ1CgC4.
Version 0 demo video: https://youtu.be/8GzzIQ3C6DQ.
Usage in education (RoboCamp 2025): https://youtu.be/Wd3yaorjTx0.
See the user builds gallery:
The official PCB (Flix2) is in development now. Follow the project's channel to track the progress.
Outdoor flights demo video of the current prototype:
The position control feature is in development. RoboCamp 2026 demo (using an overhead camera, sources):
The simulator is implemented using Gazebo and runs the original Arduino code:
Additional articles:
| Type | Part | Image | Quantity |
|---|---|---|---|
| Microcontroller board | ESP32 Mini. ESP32-S3/ESP32-C3 boards are also supported. | | 1 |
| IMU (and barometer¹) board | GY‑91, MPU-9265 (or other MPU‑9250/MPU‑6500 board) ICM20948V2 (ICM‑20948) GY-521 (MPU-6050) | | 1 |
| Boost converter (optional, for more stable power supply) | 5V output | | 1 |
| Motor | 8520 3.7V brushed motor. Motor with exact 3.7V voltage is needed, not ranged working voltage (3.7V — 6V). Make sure the motor shaft diameter and propeller hole diameter match! | | 4 |
| Propeller | 55 mm or 65 mm | | 4 |
| MOSFET (transistor) | UMW 100N03A or analog. Warning: don't use KIA 100N03A or other manufacturers, they might not work! | | 4 |
| Pull-down resistor Voltage measurement resistor | 10 kΩ | | 6 |
| 3.7V Li-Po battery | LW 952540 (or any compatible by the size). Make sure the battery has enough discharge rate and capacity — 25C with 1000 mAh or more is recommended! | | 1 |
| Battery connector cable | MX2.0 2P female | | 1 |
| Li-Po Battery charger | Any | | 1 |
| Screws for IMU board mounting | M3x5 | | 2 |
| Screws for frame assembly | M1.4x5 | | 4 |
| Frame main part | 3D printed²: stl stepRecommended settings: layer 0.2 mm, line 0.4 mm, infill 100%. | | 1 |
| Frame top part | 3D printed: stl step | | 1 |
| Washer for IMU board mounting | 3D printed: stl step | | 2 |
| Controller (recommended) | CC2500 transmitter, like BetaFPV LiteRadio CC2500 (RC receiver/Wi-Fi). Two-sticks gamepad (Wi-Fi only) — see recommended gamepads. Other⁵ | | 1 |
| RC receiver (optional) | DF500 or other³ | | 1 |
| Wires | 28 AWG recommended | | |
| Tape, double-sided tape |
¹ — barometer is not used for now.
² — this frame is optimized for GY-91 board, if using other, the board mount holes positions should be modified.
³ — you also may use any transmitter-receiver pair with SBUS interface.
Tools required for assembly:
Feel free to modify the design and or code, and create your own improved versions. Send your results to the official Telegram chat, or directly to the author (E-mail, Telegram).
(Dashed elements are optional).
Motor connection scheme:
You can see a user-contributed variant of complete circuit diagram of the drone.
Power ESP32 Mini with Li-Po battery using VCC (+) and GND (-) pins.
Connect the IMU board to the ESP32 Mini using VSPI, power it using 3.3V and GND pins:
| IMU pin | ESP32 pin |
|---|---|
| GND | GND |
| 3.3V | 3.3V |
| SCL (SCK) | SVP (GPIO18) |
| SDA (MOSI) | GPIO23 |
| SAO (MISO) | GPIO19 |
| NCS | GPIO5 |
Solder pull-down resistors to the MOSFETs.
Connect the motors to the ESP32 Mini using MOSFETs, by following scheme:
| Motor | Position | Direction | Prop type | Motor wires | GPIO |
|---|---|---|---|---|---|
| Motor 0 | Rear left | Counter-clockwise | B | Black & White | GPIO12 (TDI) |
| Motor 1 | Rear right | Clockwise | A | Blue & Red | GPIO13 (TCK) |
| Motor 2 | Front right | Counter-clockwise | B | Black & White | GPIO14 (TMS) |
| Motor 3 | Front left | Clockwise | A | Blue & Red | GPIO15 (TD0) |
Clockwise motors have blue & red wires and correspond to propeller type A (marked on the propeller). Counter-clockwise motors have black & white wires correspond to propeller type B.
Optionally connect the RC receiver to the ESP32's UART2:
| Receiver pin | ESP32 pin |
|---|---|
| GND | GND |
| VIN | VCC (or 3.3V depending on the receiver) |
| Signal (TX) | GPIO4 |
Optionally connect the battery voltage divider for voltage monitoring to any ADC1 pin (e. g. GPIO32 on ESP32, GPIO3 on ESP32-S3).
ESP32 and ESP32-S3 can measure up to 3.1 V and ESP32-S3/ESP32-C3 can measure up to 2.5 V, so choose the voltage divider resistors accordingly.
This is a DIY project, and I hope you find it interesting and useful. However, it's not easy to assemble and set up, and it's provided "as is" without any warranties. There's no guarantee that it will work perfectly, or even work at all.
⚠️ The author is not responsible for any damage, injury, or loss resulting from the use of this project. Use at your own risk!
163 followers · starred Oct 2026
49 followers · starred Sep 2026
24 followers · starred Oct 2024
25 followers · starred May 2024



