
Code for "Temporal Difference Learning for Model Predictive Control"
Python
528
11 commits
updated Nov 25, 2023
README
Temporal Difference Learning for Model Predictive Control
(Nov 2023) Announcement: TD-MPC2 is out! Visit https://github.com/nicklashansen/tdmpc2 for more information.
Original PyTorch implementation of TD-MPC from
Temporal Difference Learning for Model Predictive Control by
Nicklas Hansen, Xiaolong Wang*, Hao Su*
Method
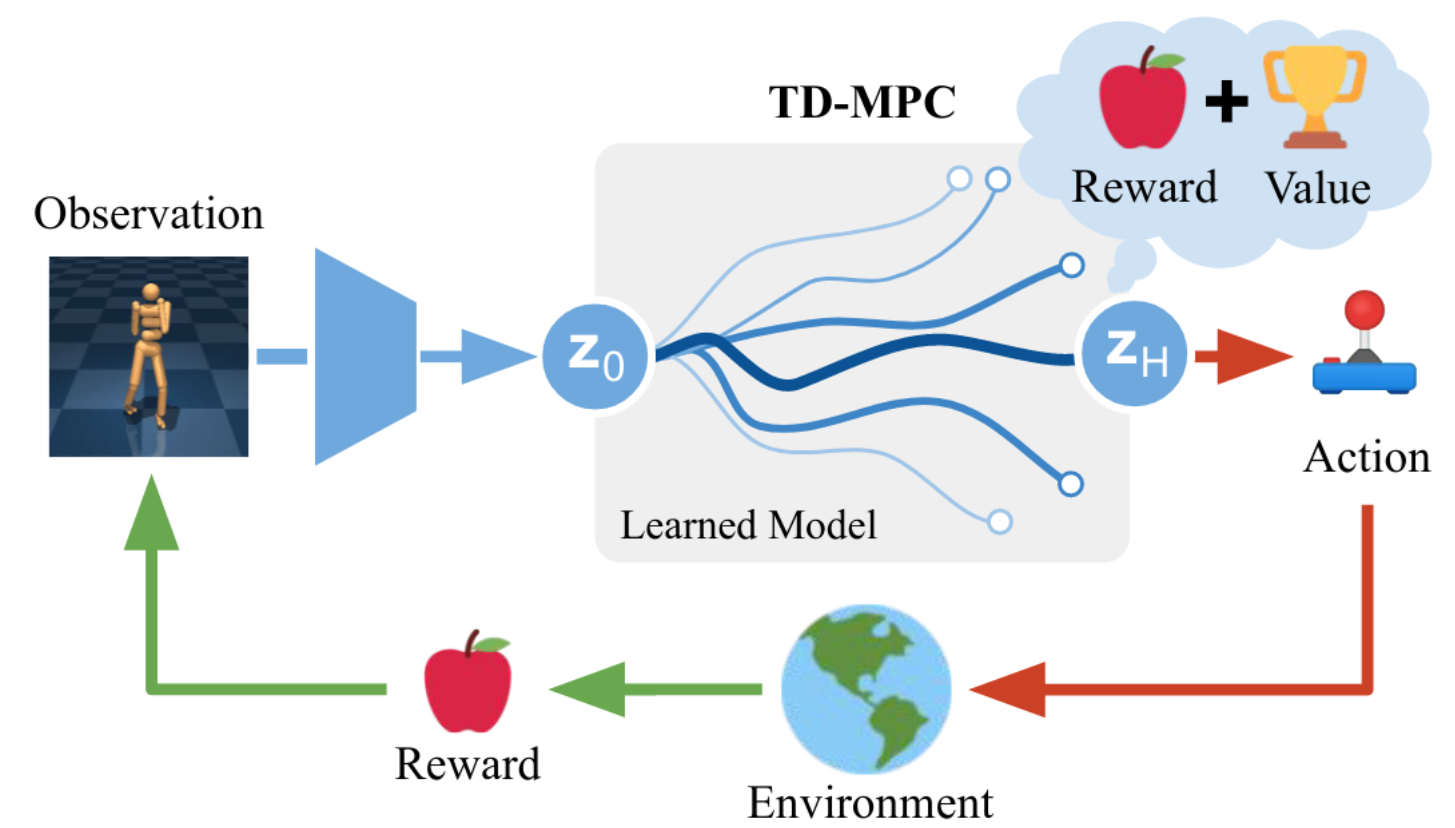
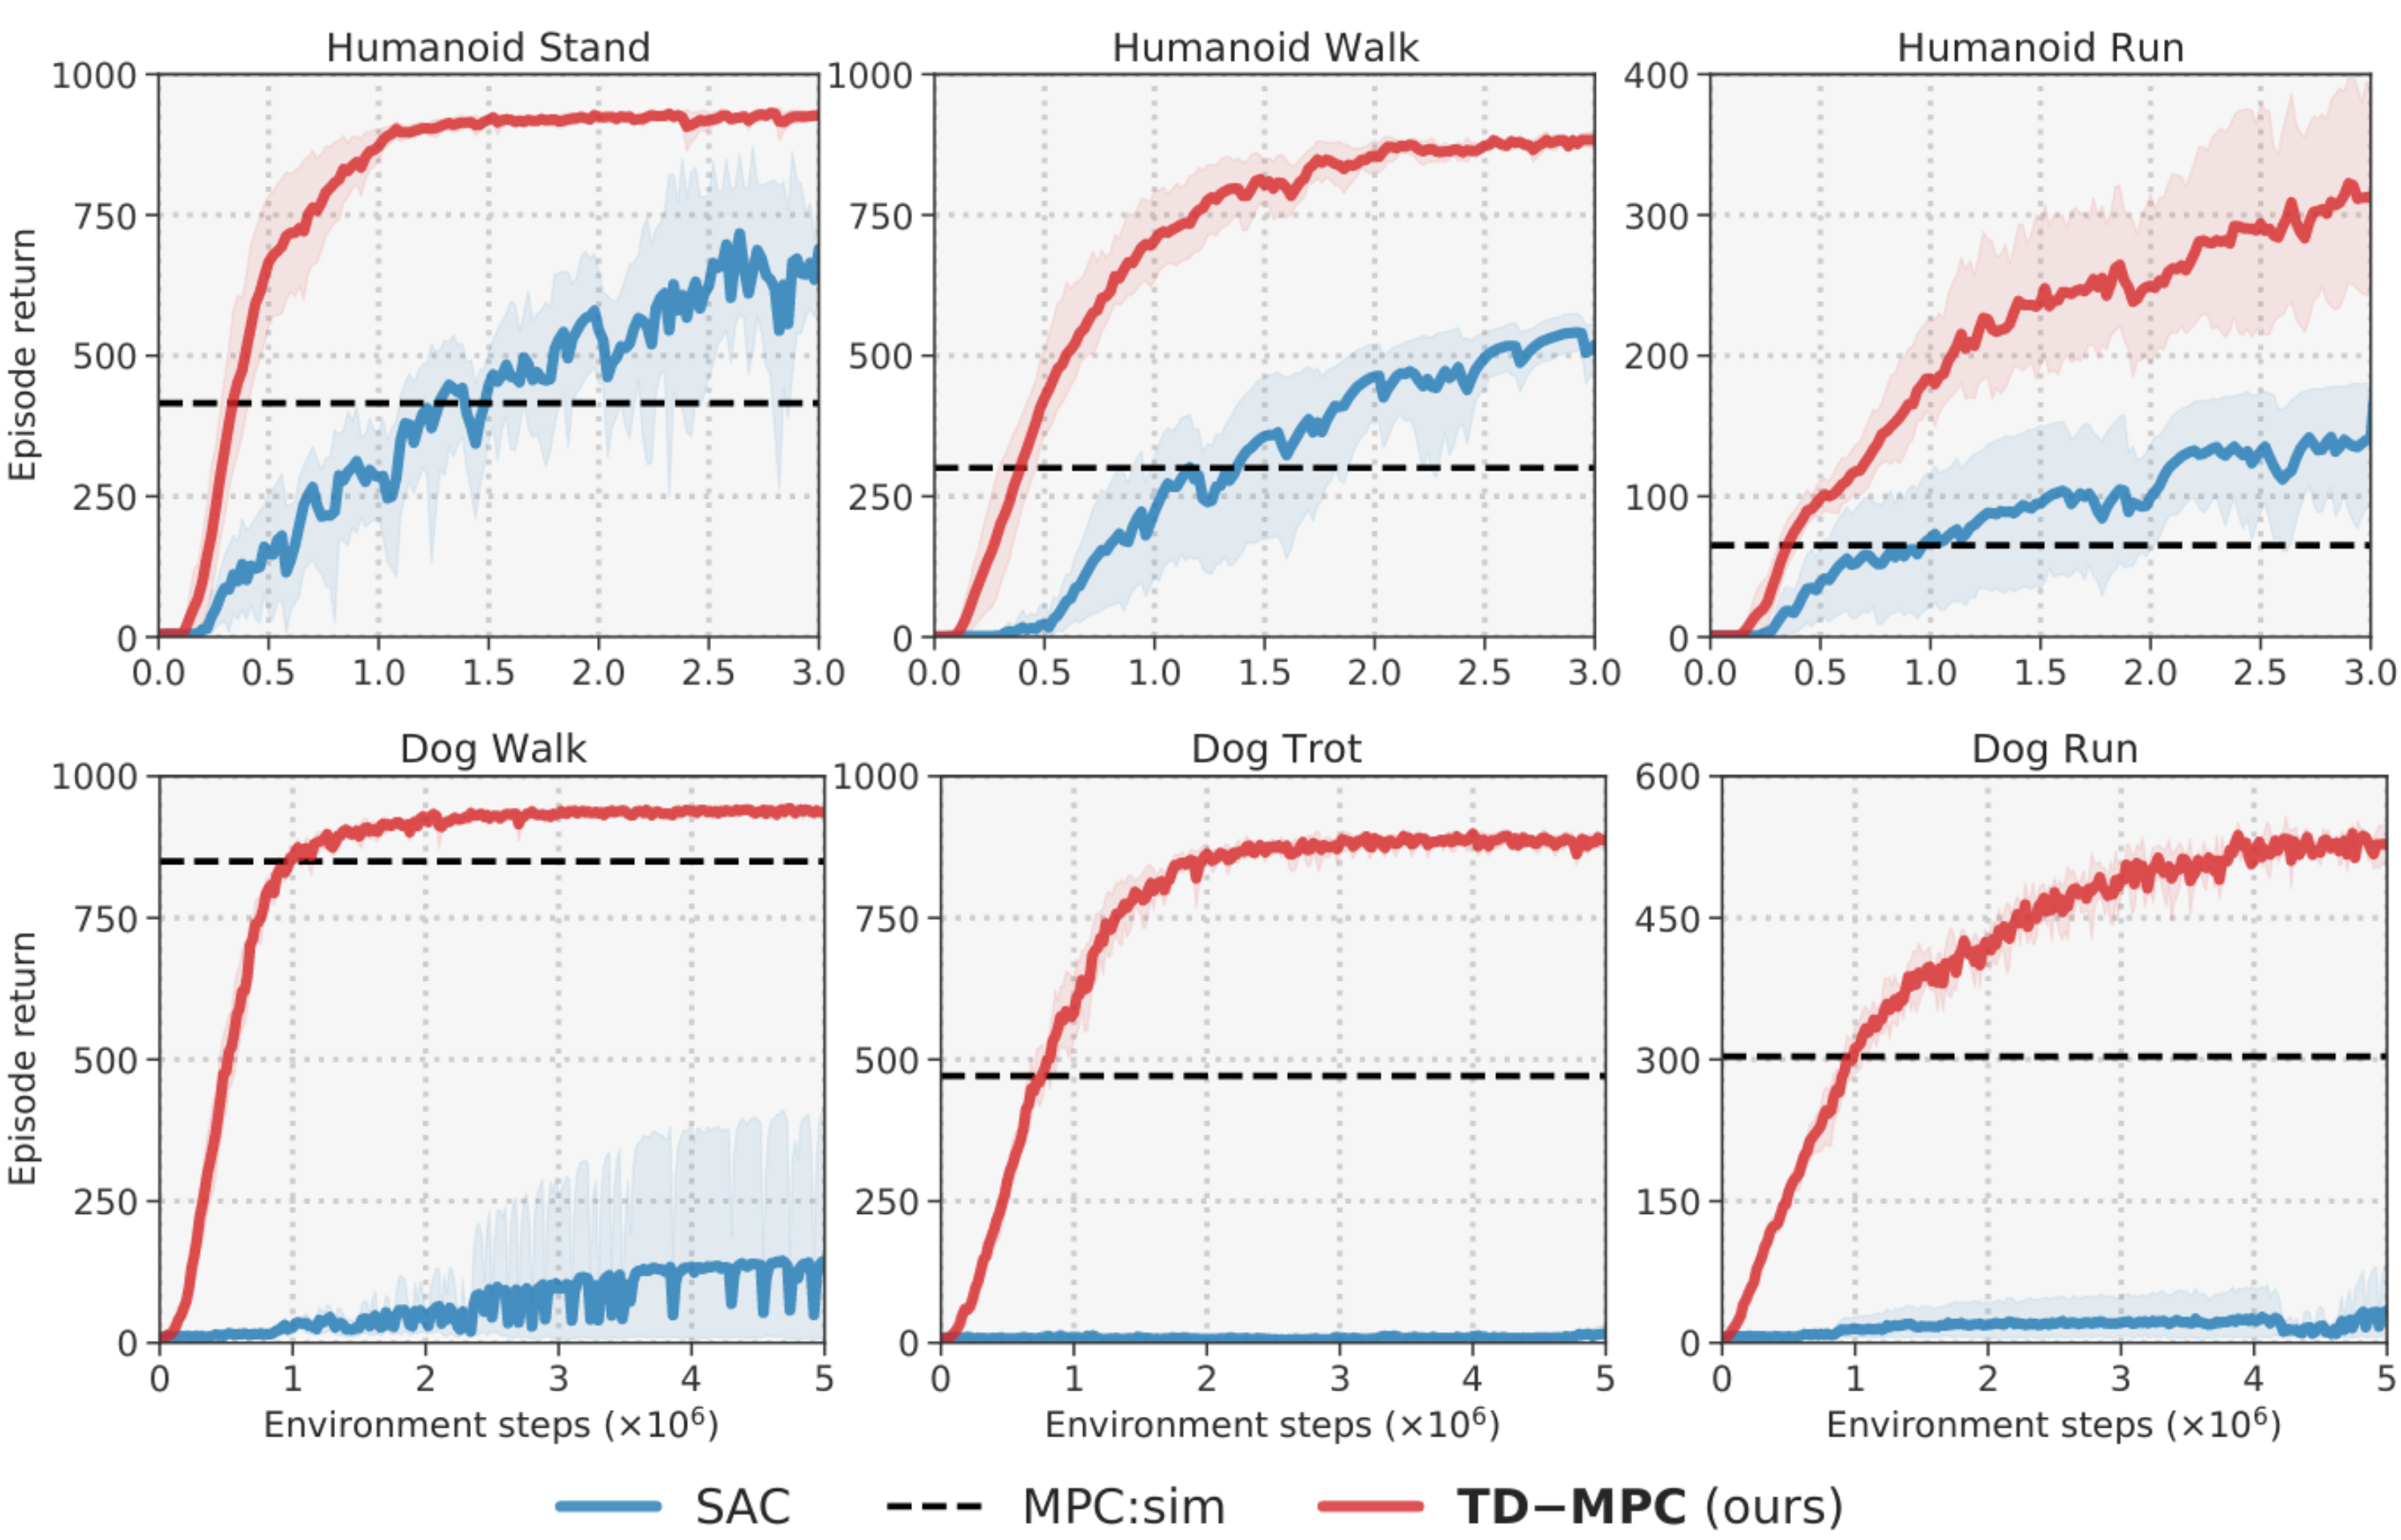
TD-MPC is a framework for model predictive control (MPC) using a Task-Oriented Latent Dynamics (TOLD) model and a terminal value function learned jointly by temporal difference (TD) learning. TD-MPC plans actions entirely in latent space using the TOLD model, which learns compact task-centric representations from either state or image inputs. TD-MPC solves challenging Humanoid and Dog locomotion tasks in 1M environment steps.
Citation
If you use our method or code in your research, please consider citing the paper as follows:
@article{Hansen2022tdmpc,
	title={Temporal Difference Learning for Model Predictive Control},
	author={Nicklas Hansen and Xiaolong Wang and Hao Su},
	eprint={2203.04955},
	archivePrefix={arXiv},
	primaryClass={cs.LG},
	year={2022}
}
Instructions
Assuming that you already have MuJoCo installed, install dependencies using conda:
conda env create -f environment.yaml
conda activate tdmpc
After installing dependencies, you can train an agent by calling
python src/train.py task=dog-run
Evaluation videos and model weights can be saved with arguments save_video=True and save_model=True. Refer to the cfgs directory for a full list of options and default hyperparameters, and see tasks.txt for a list of supported tasks. We also provide results for all 23 state-based DMControl tasks in the results directory.
The training script supports both local logging as well as cloud-based logging with Weights & Biases. To use W&B, provide a key by setting the environment variable WANDB_API_KEY=<YOUR_KEY> and add your W&B project and entity details to cfgs/default.yaml.
Changelog
- [08-29-2022] Added safeguard against NaNs in rare cases. Fixed an issue that caused multi-dimensional observation spaces to be inferred incorrectly.
- [03-27-2022] Reduced memory usage in pixel experiments by 6x. Code improvements. Refactoring. Update default pixel hyperparameters.
- [03-10-2022] Initial code release.
License & Acknowledgements
TD-MPC is licensed under the MIT license. MuJoCo and DeepMind Control Suite are licensed under the Apache 2.0 license. We thank the DrQv2 authors for their implementation of DMControl wrappers.
Contributors

10 commits

1 commits
Similar repos



Languages
Python
100.0%
Code for "Temporal Difference Learning for Model Predictive Control"
Python
528
11 commits
updated Nov 25, 2023
README
Temporal Difference Learning for Model Predictive Control
(Nov 2023) Announcement: TD-MPC2 is out! Visit https://github.com/nicklashansen/tdmpc2 for more information.
Original PyTorch implementation of TD-MPC from
Temporal Difference Learning for Model Predictive Control by
Nicklas Hansen, Xiaolong Wang*, Hao Su*
Method
TD-MPC is a framework for model predictive control (MPC) using a Task-Oriented Latent Dynamics (TOLD) model and a terminal value function learned jointly by temporal difference (TD) learning. TD-MPC plans actions entirely in latent space using the TOLD model, which learns compact task-centric representations from either state or image inputs. TD-MPC solves challenging Humanoid and Dog locomotion tasks in 1M environment steps.
Citation
If you use our method or code in your research, please consider citing the paper as follows:
@article{Hansen2022tdmpc,
	title={Temporal Difference Learning for Model Predictive Control},
	author={Nicklas Hansen and Xiaolong Wang and Hao Su},
	eprint={2203.04955},
	archivePrefix={arXiv},
	primaryClass={cs.LG},
	year={2022}
}
Instructions
Assuming that you already have MuJoCo installed, install dependencies using conda:
conda env create -f environment.yaml
conda activate tdmpc
After installing dependencies, you can train an agent by calling
python src/train.py task=dog-run
Evaluation videos and model weights can be saved with arguments save_video=True and save_model=True. Refer to the cfgs directory for a full list of options and default hyperparameters, and see tasks.txt for a list of supported tasks. We also provide results for all 23 state-based DMControl tasks in the results directory.
The training script supports both local logging as well as cloud-based logging with Weights & Biases. To use W&B, provide a key by setting the environment variable WANDB_API_KEY=<YOUR_KEY> and add your W&B project and entity details to cfgs/default.yaml.
Changelog
- [08-29-2022] Added safeguard against NaNs in rare cases. Fixed an issue that caused multi-dimensional observation spaces to be inferred incorrectly.
- [03-27-2022] Reduced memory usage in pixel experiments by 6x. Code improvements. Refactoring. Update default pixel hyperparameters.
- [03-10-2022] Initial code release.
License & Acknowledgements
TD-MPC is licensed under the MIT license. MuJoCo and DeepMind Control Suite are licensed under the Apache 2.0 license. We thank the DrQv2 authors for their implementation of DMControl wrappers.
Similar repos
Contributors
10 commits
1 commits
Languages
Python
100.0%