
CarlaAir: Fly Drones Inside a CARLA World!! A Unified Infrastructure for Air-Ground Embodied Intelligence
C++
1,100
135 commits
updated Aug 14, 2026
README
CARLA-Air: Fly Drones Inside a CARLA World
A Unified Infrastructure for Air-Ground Embodied Intelligence
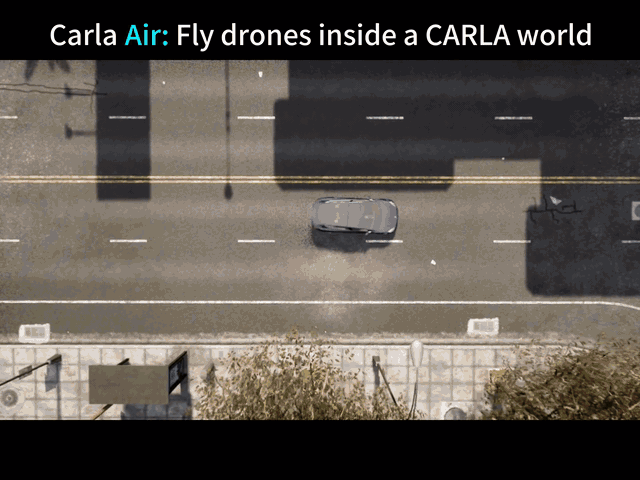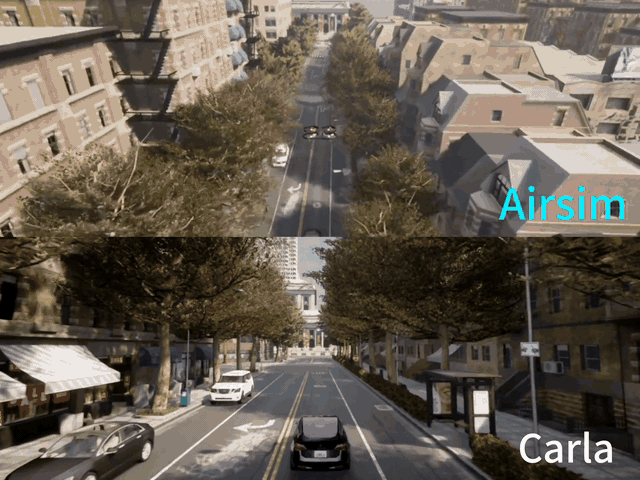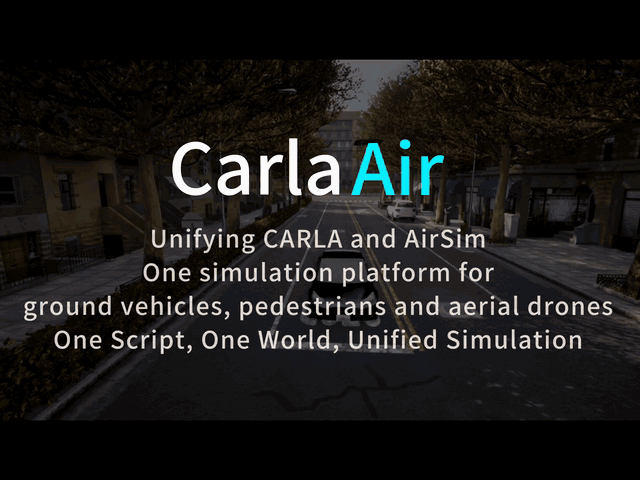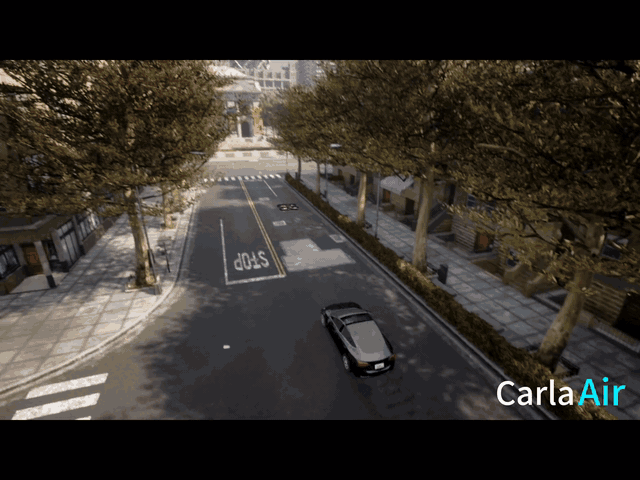
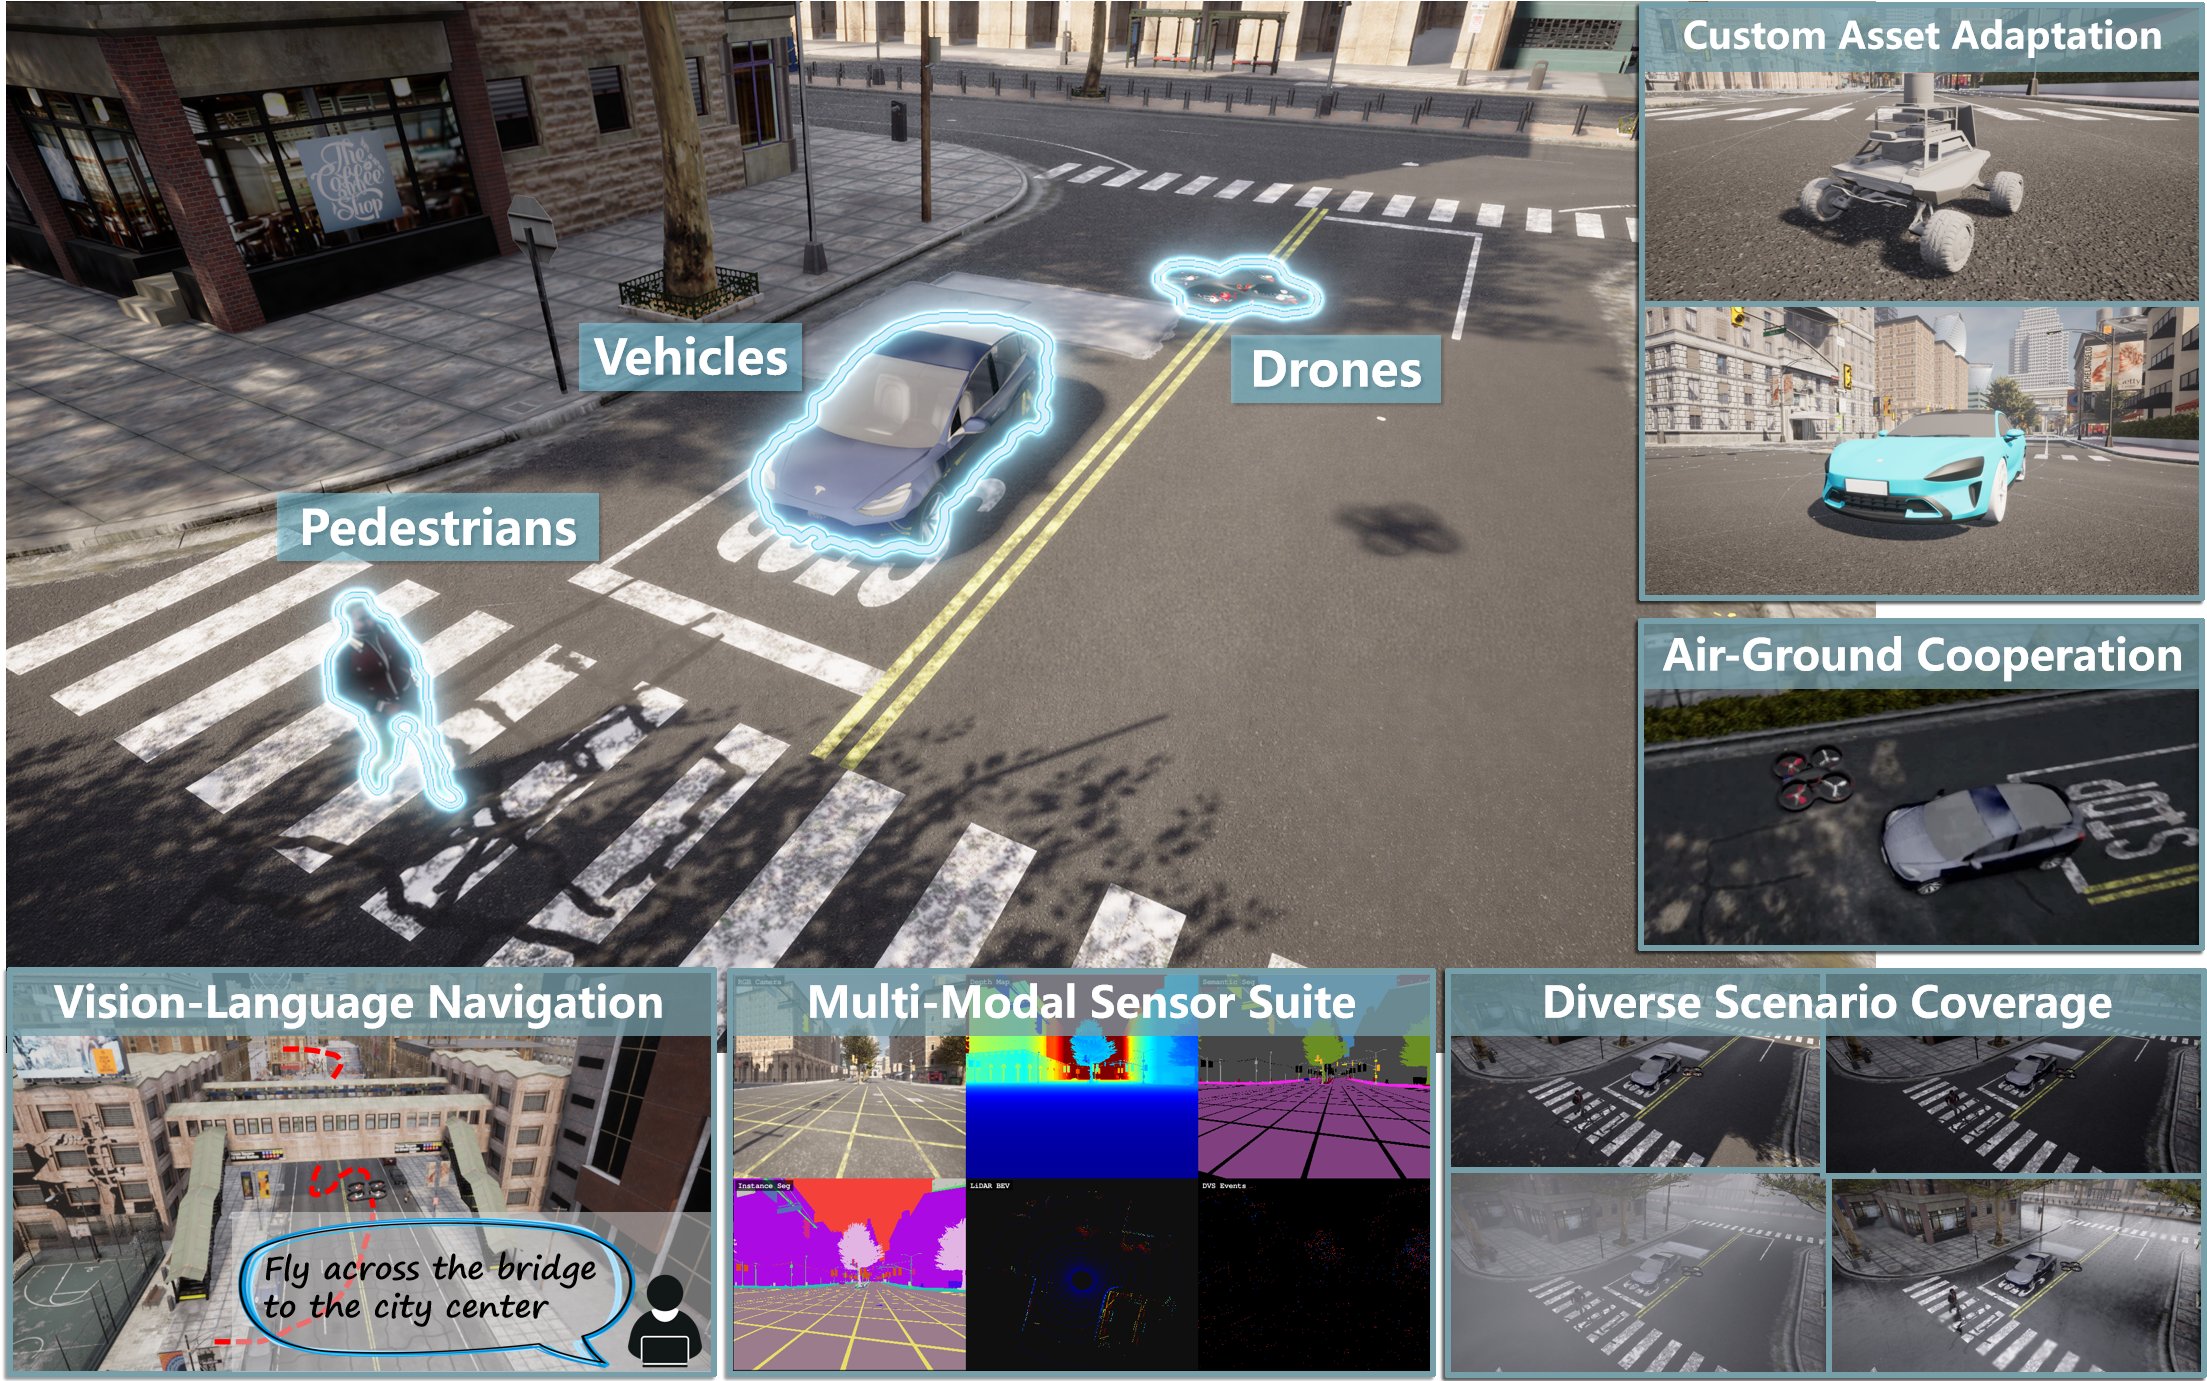
CARLA-Air is an open-source infrastructure that unifies high-fidelity urban driving and physics-accurate multirotor flight within a single Unreal Engine process, providing a practical simulation foundation for air-ground embodied intelligence research.
👉 Pre-built executable — Ubuntu (20.04 / 22.04), no compilation required:
Baidu Pan | Hugging Face
👉 Pre-built executable — Windows (Windows 11 x86_64 recommended), no compilation required:
Baidu Pan



English | 简体中文 | 📄 Paper | 🌐 Project Page | 📖 Docs | 🎬 Video


📌 Table of Contents
- 🔥 News
- ✨ Highlights
- 🏆 Platform Comparison — 15 simulators, side-by-side
- 🎮 Quick Start — up and running in 4 steps
- 🐍 One Script, Two Worlds — dual API code examples
- 🔬 Research Directions & Workflows — W1–W5 validated workflows
- ⌨️ Flight Controls
- 📚 Documentation & Tutorials — 8 step-by-step tutorials
- 🗺️ Roadmap
- 📝 Citation
- 📜 License & Acknowledgments
- ⭐ Star History
🔥 News
- [2026-04-20] 🤖 ROS 2 examples released! -- Minimal vehicle/drone sensor bridges + RViz 2 preset under
examples/ros2/. Humble-ready, nocarla-ros-bridgesource build required. - [2026-04-17] 🌐 Project page is live! -- Explore CARLA-Air features, tutorials, and demos at our official website.
- [2026-04-16] $\color{red}{\textbf{Windows pre-built package is now available.}}$ Download: Baidu Pan — Windows build (Win11 x86_64 recommended; no compilation)
- [2026-04-10]
Windows source branch published -- Windows build and runtime support is now available on the dedicated branch
- [2026-04-01] 🏆 $\color{red}{\text{\textbf{No.~1 Paper of the Day — Hugging Face Daily Papers!}}}$ (paper / leaderboard)
- [2026-03-30] 📄 Technical report released -- Read the paper
- [2026-03]
v0.1.7released -- VSync fix, stable traffic, one-click env setup, drone recording toolkit, coordinate docs - [2026-03]
v0.1.6released -- Auto traffic spawn, UE4 native Sweep collision, ground clamping - [2026-03]
v0.1.5released -- 12-direction collision system, bilingual help overlay (H) - [2026-03]
v0.1.4released -- ROS2 validation (63 topics), first official binary release
✨ Highlights
| 🏗️ Single-Process Composition | CARLAAirGameMode inherits CARLA and composes AirSim. Only 3 upstream files modified (~35 lines). No bridge, no latency. |
| 🎯 Absolute Coordinate Alignment | Exact 0.0000 m error between CARLA (left-handed) and AirSim (NED) coordinate frames. |
| 📸 Up to 18 Sensor Modalities | RGB, Depth, Semantic Seg, Instance Seg, LiDAR, Radar, Surface Normals, IMU, GNSS, Barometry -- all frame-aligned across air and ground. |
| 🔄 Zero-Modification Code Migration | Existing CARLA and AirSim Python scripts and ROS 2 nodes run on CARLA-Air without any code changes. 89/89 CARLA API tests passing. |
| ⚡ ~20 FPS Joint Workloads | Moderate joint configuration (vehicles + drone + 8 sensors) sustains 19.8 +/- 1.1 FPS. Communication overhead < 0.5 ms (vs. 1--5 ms bridge co-sim). |
| 🛡️ 3-Hour Stability Verified | 357 spawn/destroy cycles, zero crashes, zero memory accumulation (R² = 0.11). |
| 🚁 Built-in FPS Drone Control | Fly the drone in viewport using WASD + Mouse -- no Python scripts needed. |
| 🚦 Realistic Urban Traffic | Rule-compliant traffic flow, socially-aware pedestrians, 13 urban maps. |
| 🧩 Extensible Asset Pipeline | Import custom robot platforms, UAV configurations, vehicles, and environment maps. |
🏆 Platform Comparison
A comprehensive comparison of CARLA-Air against 14 existing simulation platforms (based on Table 1 from the technical report).
| Category | Platform | Urban Traffic | Pedestrians | UAV Flight | Single Process | Shared Renderer | Native APIs | Joint Sensors | Prebuilt Binary | Test Suite | Custom Assets | Open Source |
|---|---|---|---|---|---|---|---|---|---|---|---|---|
| Autonomous Driving | CARLA | ✓ | ✓ | ✗ | ✓ | ✓ | ✓ | ✗ | ✓ | ✗ | ✓ | ✓ |
| LGSVL | ✓ | ✓ | ✗ | ✓ | ✓ | ✓ | ✗ | ✓ | ✗ | ~ | ✓ | |
| SUMO | ✓ | ✓ | ✗ | ✓ | ✗ | ✓ | ✗ | ✓ | ✗ | ✗ | ✓ | |
| MetaDrive | ✓ | ~ | ✗ | ✓ | ~ | ✓ | ✗ | ✗ | ✗ | ✗ | ✓ | |
| VISTA | ~ | ✗ | ✗ | ✓ | ~ | ✓ | ✗ | ✗ | ✗ | ✗ | ✓ | |
| Aerial / UAV | AirSim | ✗ | ✗ | ✓ | ✓ | ✓ | ✓ | ✗ | ✓ | ✗ | ✓ | ✓ |
| Flightmare | ✗ | ✗ | ✓ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ~ | ✓ | |
| FlightGoggles | ✗ | ✗ | ✓ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ~ | ✓ | |
| Gazebo/RotorS | ~ | ~ | ✓ | ✓ | ~ | ✓ | ✗ | ✓ | ✗ | ✓ | ✓ | |
| OmniDrones | ✗ | ✗ | ✓ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ✓ | ✓ | |
| gym-pybullet-drones | ✗ | ✗ | ✓ | ✓ | ~ | ✓ | ✗ | ✗ | ✗ | ~ | ✓ | |
| Joint / Co-Sim | TranSimHub | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ~ | — | ✗ | ✗ | ✓ |
| CARLA+SUMO | ✓ | ✓ | ✗ | ✗ | ✗ | ~ | ✗ | — | ✗ | ✗ | ✓ | |
| AirSim+Gazebo | ~ | ~ | ✓ | ✗ | ✗ | ~ | ~ | — | ✗ | ~ | ✓ | |
| Embodied AI & RL | Isaac Lab | ✗ | ✗ | ~ | ✓ | ✓ | ✓ | ✗ | ✗ | ✓ | ✓ | ✓ |
| Isaac Gym | ✗ | ✗ | ~ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ✗ | ✓ | |
| Habitat | ✗ | ~ | ✗ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ✗ | ✓ | |
| SAPIEN | ✗ | ✗ | ✗ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ~ | ✓ | |
| RoboSuite | ✗ | ✗ | ✗ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ~ | ✓ | |
| Ours | CARLA-Air | ✓ | ✓† | ✓ | ✓ | ✓ | ✓ | ✓ | ✓ | ✓ | ✓ | ✓ |
✓ = supported; ~ = partial or constrained; ✗ = not supported; — = not applicable.
† Pedestrian AI is inherited from CARLA and fully functional; behavior under high actor density in joint scenarios is an active engineering target.
🎮 Quick Start
Option A: Binary Release (Recommended)
# 1. Download and extract CARLA-Air v0.1.7
tar xzf CarlaAir-v0.1.7.tar.gz
cd CarlaAir-v0.1.7

# 2. One-click environment setup (first time only)
bash env_setup/setup_env.sh      # creates conda env, installs deps, deploys carla module
conda activate carlaAir
bash env_setup/test_env.sh        # verify: should show all PASS

# 3. Launch the simulator (auto-spawns traffic)
./CarlaAir.sh Town10HD

# 4. Run the showcase! (in another terminal)
conda activate carlaAir
python3 examples/quick_start_showcase.py
What you'll see: A Tesla cruises through the city while a drone chases it from above. A 4-panel display shows RGB, Depth, Semantic Segmentation, and LiDAR BEV -- all synchronized. Weather cycles automatically.
Option B: Build from Source
Please refer to the Build Guide for detailed instructions on compiling CARLA-Air with UE4.26.
🐍 One Script, Two Worlds
Both APIs share the same simulated world -- no bridge, no sync headaches.
import carla, airsim

carla_client = carla.Client("localhost", 2000)
air_client   = airsim.MultirotorClient(port=41451)
world = carla_client.get_world()

# One weather call affects EVERY sensor — ground AND air
world.set_weather(carla.WeatherParameters.HardRainSunset)

# Spawn a car, let it drive
vehicle = world.spawn_actor(vehicle_bp, spawn_point)
vehicle.set_autopilot(True)

# Fly the drone above — same world, same rain, same physics
air_client.takeoffAsync().join()
air_client.moveToPositionAsync(80, 30, -25, 5)
6 demo scripts -- try them all:
python3 examples/quick_start_showcase.py   # 🎬 4-panel sensors + drone chase + weather cycling
python3 examples/drive_vehicle.py          # 🚗 Drive a Tesla with WASD
python3 examples/walk_pedestrian.py        # 🚶 Walk the city on foot (mouse look)
python3 examples/switch_maps.py            # 🗺️  Fly through all 13 maps automatically
python3 examples/sensor_gallery.py         # 📸 6-grid sensor showcase on one vehicle
python3 examples/air_ground_sync.py        # 🔄 Car + drone split-screen: same rain, same world
Recording toolkit -- record trajectories for vehicle, drone, and pedestrian, then replay them with a director camera:
python3 examples/recording/record_vehicle.py     # 🚗 Drive & record vehicle trajectory
python3 examples/recording/record_drone.py       # 🚁 Fly & record drone trajectory (zero intrusion)
python3 examples/recording/record_walker.py      # 🚶 Walk & record pedestrian trajectory
python3 examples/recording/demo_director.py \    # 🎬 Replay all + free camera + MP4 recording
    trajectories/vehicle_*.json trajectories/drone_*.json
Docs: Coordinate Systems (CARLA to AirSim) | Quick Start Guide | FAQ
🔬 Research Directions & Workflows
CARLA-Air is designed to support four major research directions in air-ground embodied intelligence:
- Air-Ground Cooperation -- Heterogeneous air-ground agents collaborating in a shared urban environment.
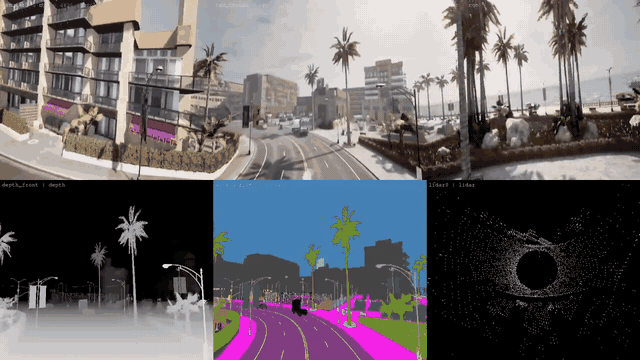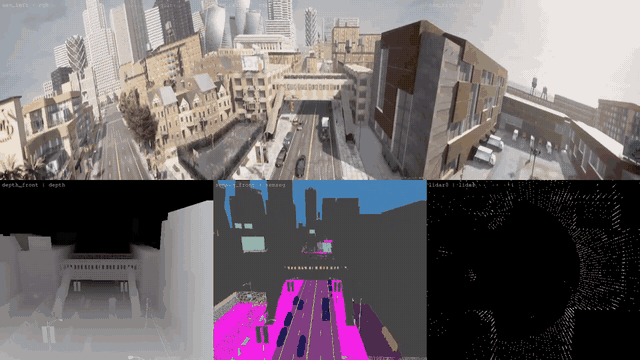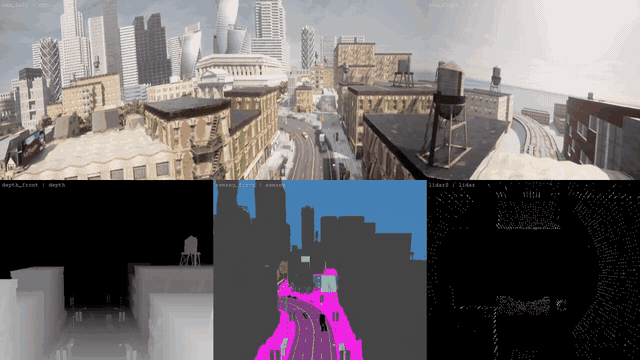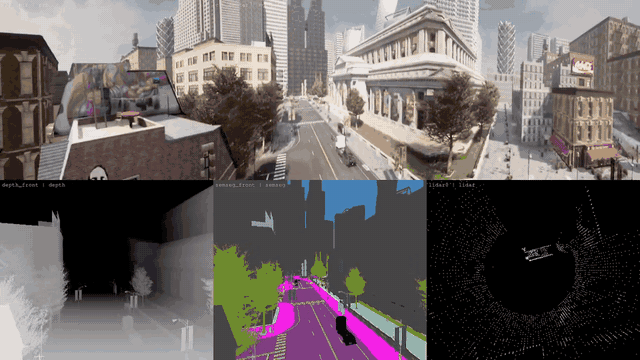
- Embodied Navigation (VLN/VLA) -- Vision-and-language-driven navigation and action in photorealistic cities.
- Multi-Modal Perception and Dataset Collection -- Synchronized aerial-ground sensor data acquisition across diverse conditions.
- RL-Based Policy Training -- Closed-loop reinforcement learning with joint air-ground interaction.
The platform provides five reference workflows that cover these directions:
| Workflow | Direction | Key Result | |
|---|---|---|---|
| W1 | Air-Ground Cooperation | Air-ground cooperation | Real-time cross-domain coordination |
| W2 | VLN/VLA Tasks | Embodied navigation | Cross-view VLN data pipeline |
| W3 | Multi-Modal Dataset Collection | Perception and dataset | 12-stream sync, 1-tick alignment |
| W4 | Cross-View Perception | Perception and dataset | 14/14 weather presets verified |
| W5 | RL Training Environment | RL policy training | 357 reset cycles, 0 crashes |
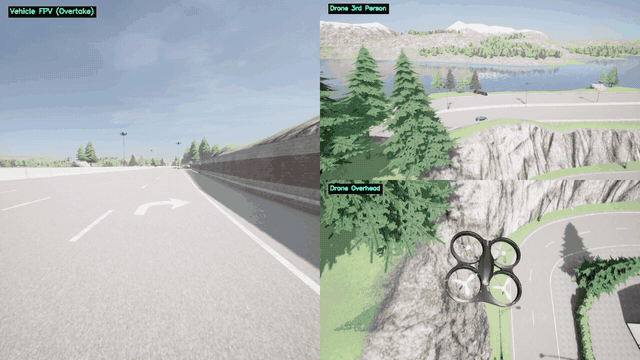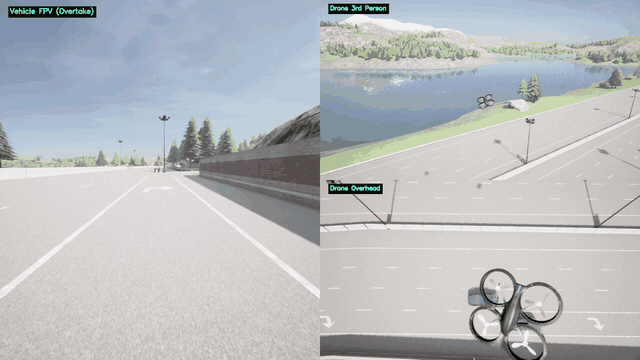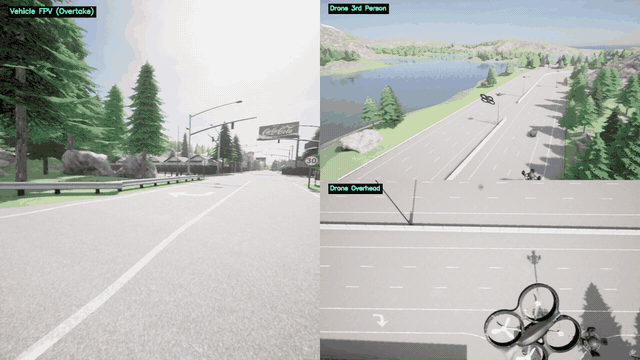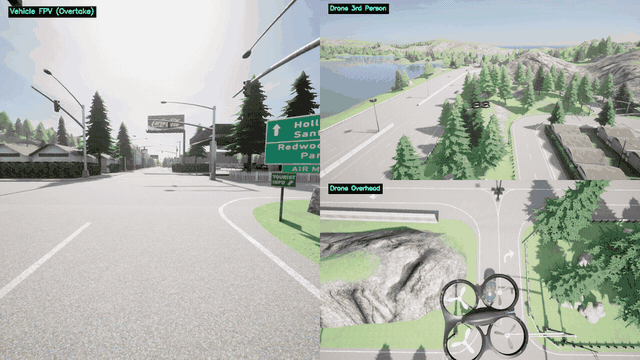 W1: Air-Ground Cooperation |
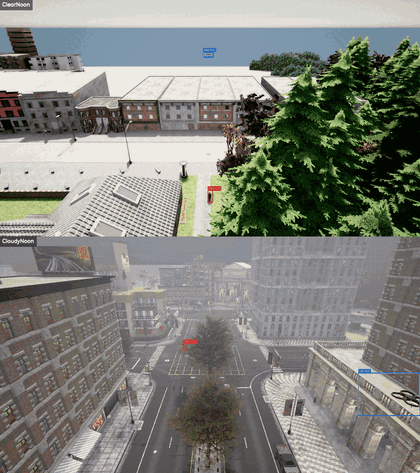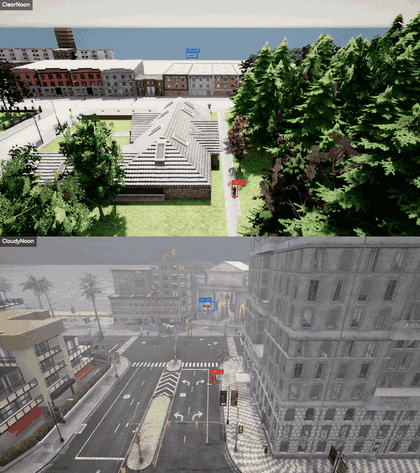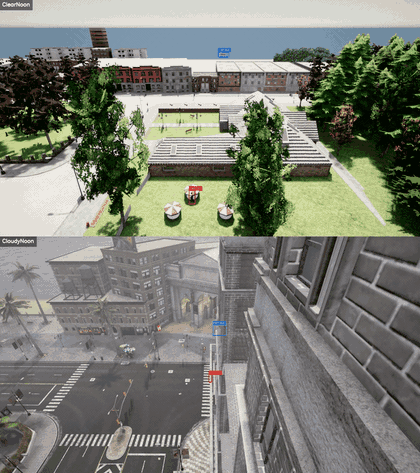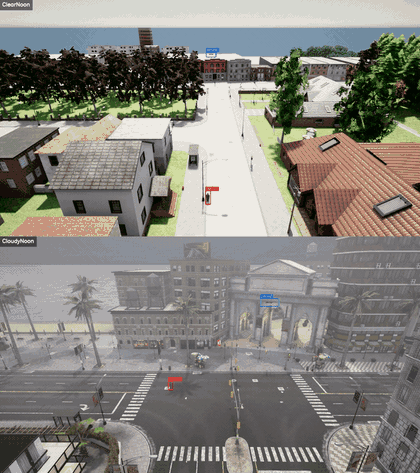 W2: VLN/VLA Tasks |
 W3: Multi-Modal Dataset Collection |
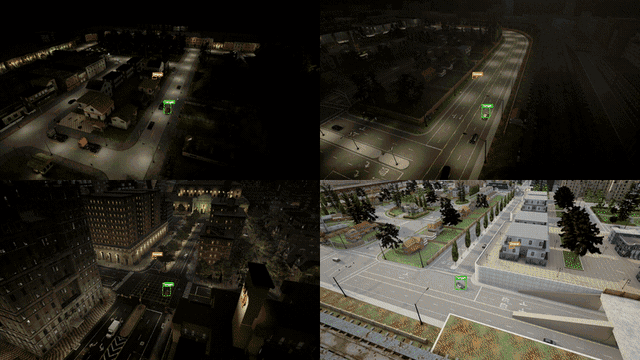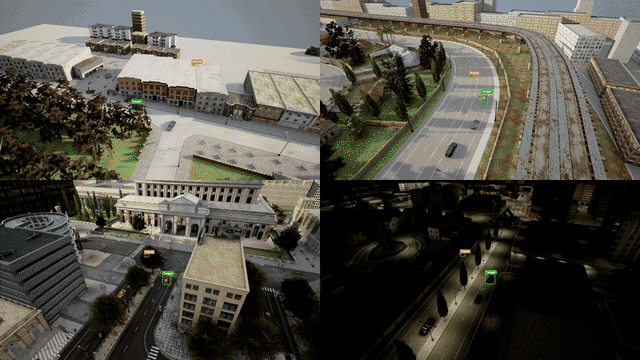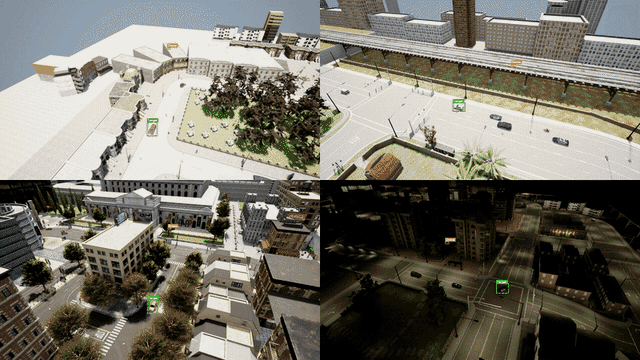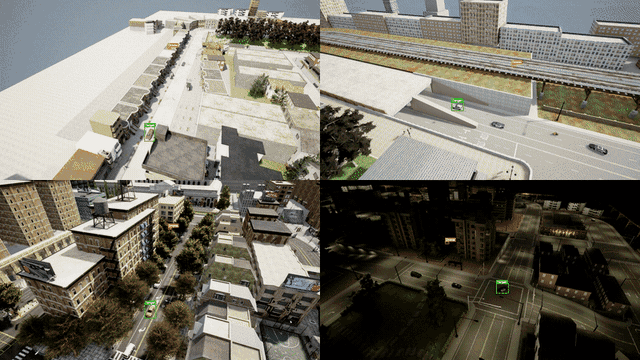 W4: Cross-View Perception |
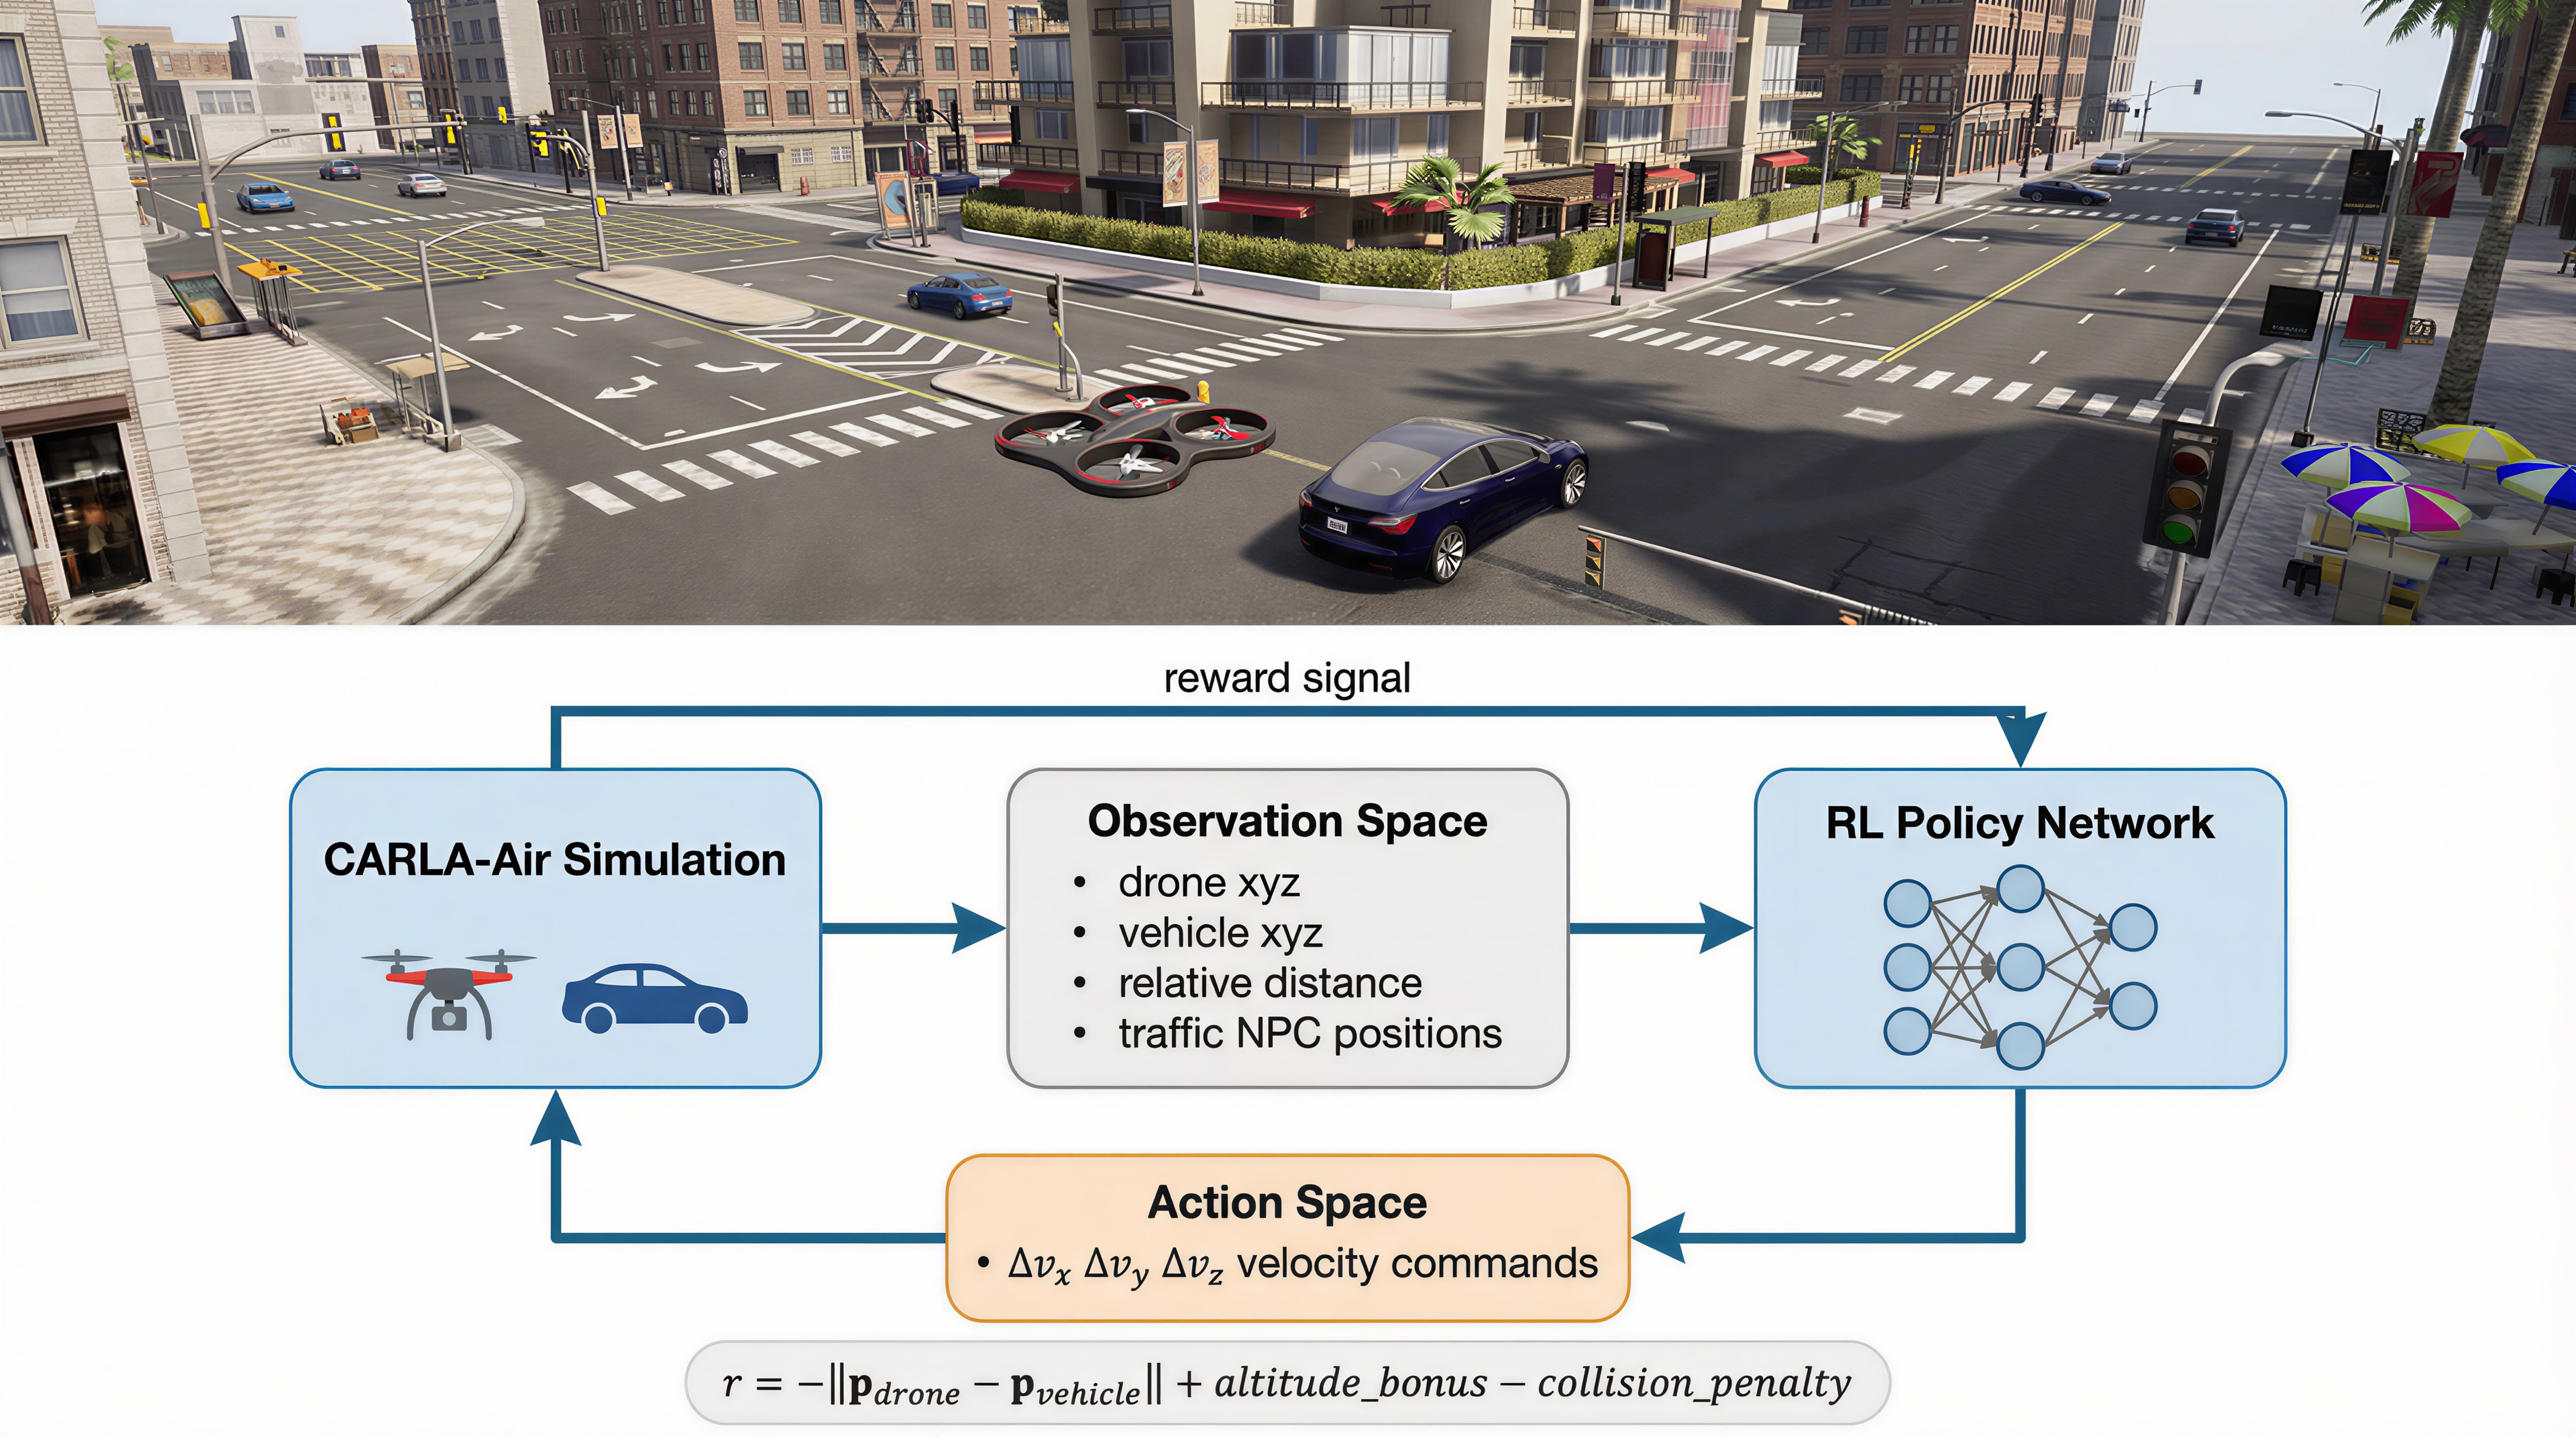 W5: RL Training Environment |
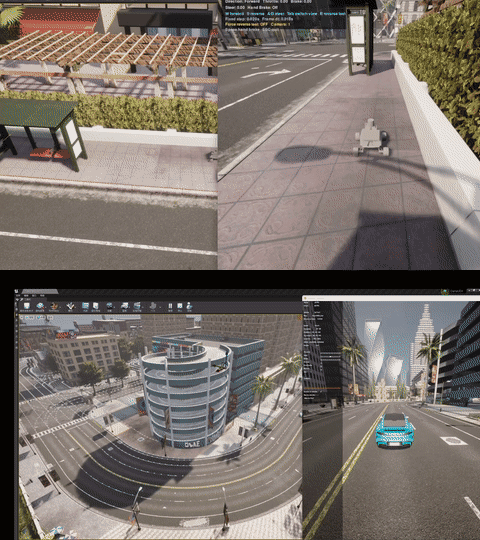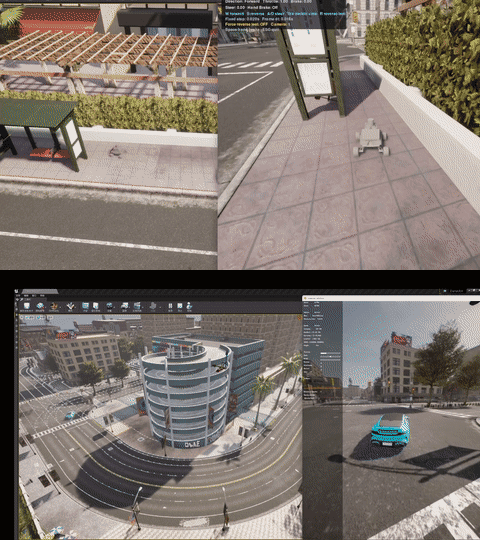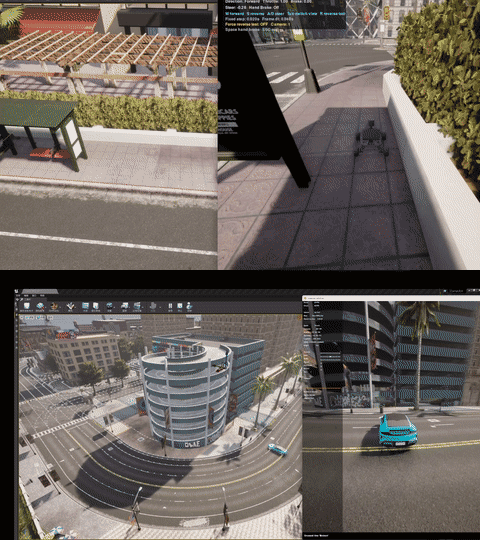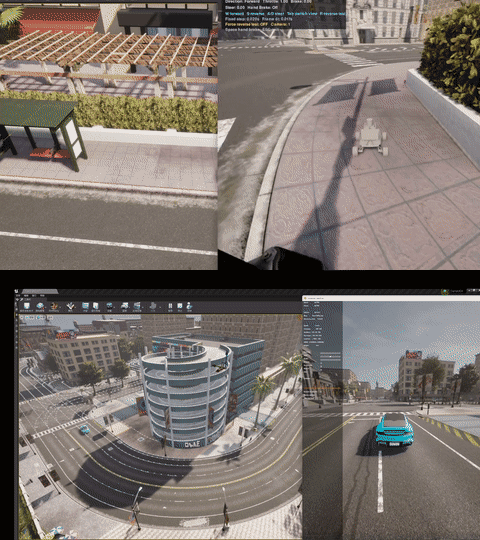 Custom Asset Import |
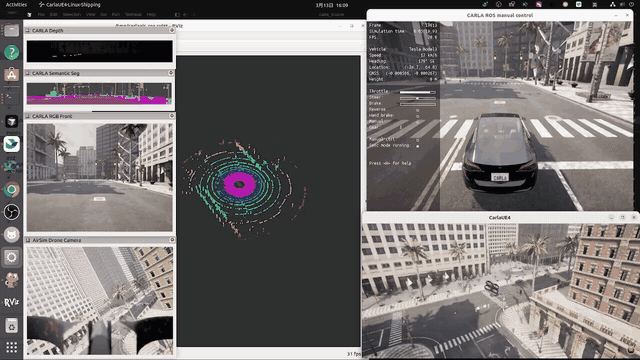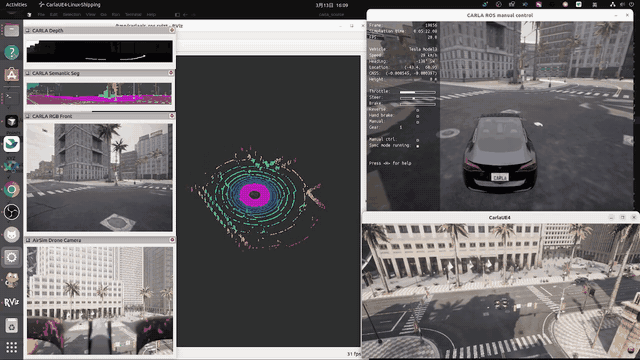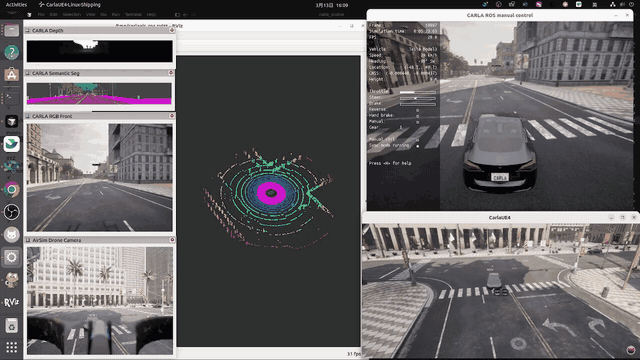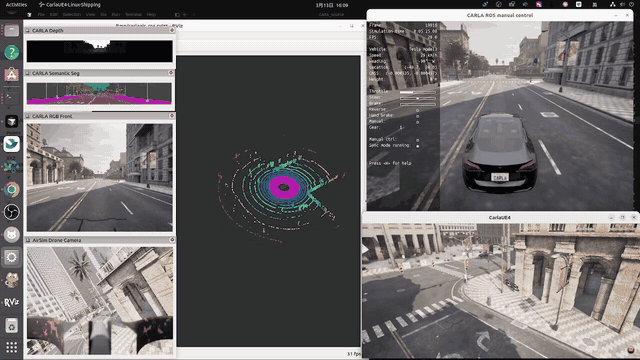 ROS 2 Integration — 63 Topics across Both Backends | |
⌨️ Flight Controls
When the simulator is running, click inside the window to capture the mouse:
| Key | Action |
|---|---|
W / A / S / D | Move Forward / Left / Backward / Right |
Space / Shift | Ascend / Descend |
Mouse | Yaw (Turn Left/Right) |
Scroll Wheel | Adjust Flight Speed |
N | Cycle Weather Presets (Clear, Rain, Fog, Night, etc.) |
P | Toggle Collision Mode (Physics vs. Noclip/Invincible) |
H | Show/Hide On-Screen Help Menu |
Tab | Release / Capture Mouse |
📚 Documentation & Tutorials
We provide 6 curated Python examples showcasing the core air-ground cooperative capabilities:
| Example | Description |
|---|---|
quick_start_showcase.py | 4-panel sensors + drone chase + weather cycling |
drive_vehicle.py | Drive a Tesla with WASD keyboard control |
walk_pedestrian.py | Walk the city on foot with mouse look |
switch_maps.py | Fly through all 13 maps automatically |
sensor_gallery.py | 6-grid sensor showcase on one vehicle |
air_ground_sync.py | Car + drone split-screen: same rain, same world |
Step-by-step tutorials (8 scripts in CarlaAir_Release/guide/examples/, beginner-friendly):
| # | Tutorial | What You Will Learn |
|---|---|---|
| 01 | 01_hello_world.py | Connect to both APIs, verify setup |
| 02 | 02_weather_control.py | Change weather parameters in real-time |
| 03 | 03_spawn_traffic.py | Generate vehicles and pedestrians |
| 04 | 04_sensor_capture.py | Attach and read sensors |
| 05 | 05_drone_takeoff.py | Basic drone flight commands |
| 06 | 06_drone_sensors.py | Aerial sensor configuration |
| 07 | 07_combined_demo.py | Air-ground joint operation |
| 08 | 08_full_showcase.py | Full platform capabilities |
Full Documentation:
- Quick Start Guide
- Coordinate Systems (CARLA to AirSim)
- Architecture Details
- Modifications from Upstream
- FAQ
🗺️ Roadmap
- Single-process CARLA + AirSim integration (UE4.26)
- FPS drone control (WASD + Mouse)
- Auto traffic spawn (vehicles + pedestrians)
- 18-channel synchronized sensors
- Dual Python API (CARLA + AirSim)
- ROS2 validation (63 topics)
- One-click environment setup
- Recording toolkit (vehicle, drone, pedestrian trajectories)
- Technical report (PDF)
- Project page (carla-air.com)
- Tutorial documentation
- 3DGS rendering pipeline integration
- World Model integration
- Multi-drone support
📝 Citation
If you find CARLA-Air useful in your research, please consider citing our paper:
@misc{zeng2026carlaairflydronesinside,
  title={CARLA-Air: Fly Drones Inside a CARLA World -- A Unified Infrastructure for Air-Ground Embodied Intelligence},
  author={Tianle Zeng and Yanci Wen and Hong Zhang},
  year={2026},
  eprint={2603.28032},
  archivePrefix={arXiv},
  primaryClass={cs.RO},
  url={https://arxiv.org/abs/2603.28032}
}
📜 License & Acknowledgments
CARLA-Air is built upon the shoulders of giants. We sincerely thank the developers of:
- CARLA Simulator (MIT License)
- Microsoft AirSim (MIT License)
- Unreal Engine
CARLA-Air specific code is distributed under the MIT License. CARLA specific assets are distributed under the CC-BY License.
⭐ Star History
Contributors


Similar repos


Languages
C++
61.9%
QMake
22.5%
Python
11.2%
C
1.8%
Shell
1.0%
CarlaAir: Fly Drones Inside a CARLA World!! A Unified Infrastructure for Air-Ground Embodied Intelligence
C++
1,100
135 commits
updated Aug 14, 2026
README
CARLA-Air: Fly Drones Inside a CARLA World
A Unified Infrastructure for Air-Ground Embodied Intelligence
CARLA-Air is an open-source infrastructure that unifies high-fidelity urban driving and physics-accurate multirotor flight within a single Unreal Engine process, providing a practical simulation foundation for air-ground embodied intelligence research.
👉 Pre-built executable — Ubuntu (20.04 / 22.04), no compilation required:
Baidu Pan | Hugging Face
👉 Pre-built executable — Windows (Windows 11 x86_64 recommended), no compilation required:
Baidu Pan
English | 简体中文 | 📄 Paper | 🌐 Project Page | 📖 Docs | 🎬 Video
📌 Table of Contents
- 🔥 News
- ✨ Highlights
- 🏆 Platform Comparison — 15 simulators, side-by-side
- 🎮 Quick Start — up and running in 4 steps
- 🐍 One Script, Two Worlds — dual API code examples
- 🔬 Research Directions & Workflows — W1–W5 validated workflows
- ⌨️ Flight Controls
- 📚 Documentation & Tutorials — 8 step-by-step tutorials
- 🗺️ Roadmap
- 📝 Citation
- 📜 License & Acknowledgments
- ⭐ Star History
🔥 News
- [2026-04-20] 🤖 ROS 2 examples released! -- Minimal vehicle/drone sensor bridges + RViz 2 preset under
examples/ros2/. Humble-ready, nocarla-ros-bridgesource build required. - [2026-04-17] 🌐 Project page is live! -- Explore CARLA-Air features, tutorials, and demos at our official website.
- [2026-04-16] $\color{red}{\textbf{Windows pre-built package is now available.}}$ Download: Baidu Pan — Windows build (Win11 x86_64 recommended; no compilation)
- [2026-04-10]
- [2026-04-01] 🏆 $\color{red}{\text{\textbf{No.~1 Paper of the Day — Hugging Face Daily Papers!}}}$ (paper / leaderboard)
- [2026-03-30] 📄 Technical report released -- Read the paper
- [2026-03]
v0.1.7released -- VSync fix, stable traffic, one-click env setup, drone recording toolkit, coordinate docs - [2026-03]
v0.1.6released -- Auto traffic spawn, UE4 native Sweep collision, ground clamping - [2026-03]
v0.1.5released -- 12-direction collision system, bilingual help overlay (H) - [2026-03]
v0.1.4released -- ROS2 validation (63 topics), first official binary release
✨ Highlights
| 🏗️ Single-Process Composition | CARLAAirGameMode inherits CARLA and composes AirSim. Only 3 upstream files modified (~35 lines). No bridge, no latency. |
| 🎯 Absolute Coordinate Alignment | Exact 0.0000 m error between CARLA (left-handed) and AirSim (NED) coordinate frames. |
| 📸 Up to 18 Sensor Modalities | RGB, Depth, Semantic Seg, Instance Seg, LiDAR, Radar, Surface Normals, IMU, GNSS, Barometry -- all frame-aligned across air and ground. |
| 🔄 Zero-Modification Code Migration | Existing CARLA and AirSim Python scripts and ROS 2 nodes run on CARLA-Air without any code changes. 89/89 CARLA API tests passing. |
| ⚡ ~20 FPS Joint Workloads | Moderate joint configuration (vehicles + drone + 8 sensors) sustains 19.8 +/- 1.1 FPS. Communication overhead < 0.5 ms (vs. 1--5 ms bridge co-sim). |
| 🛡️ 3-Hour Stability Verified | 357 spawn/destroy cycles, zero crashes, zero memory accumulation (R² = 0.11). |
| 🚁 Built-in FPS Drone Control | Fly the drone in viewport using WASD + Mouse -- no Python scripts needed. |
| 🚦 Realistic Urban Traffic | Rule-compliant traffic flow, socially-aware pedestrians, 13 urban maps. |
| 🧩 Extensible Asset Pipeline | Import custom robot platforms, UAV configurations, vehicles, and environment maps. |
🏆 Platform Comparison
A comprehensive comparison of CARLA-Air against 14 existing simulation platforms (based on Table 1 from the technical report).
| Category | Platform | Urban Traffic | Pedestrians | UAV Flight | Single Process | Shared Renderer | Native APIs | Joint Sensors | Prebuilt Binary | Test Suite | Custom Assets | Open Source |
|---|---|---|---|---|---|---|---|---|---|---|---|---|
| Autonomous Driving | CARLA | ✓ | ✓ | ✗ | ✓ | ✓ | ✓ | ✗ | ✓ | ✗ | ✓ | ✓ |
| LGSVL | ✓ | ✓ | ✗ | ✓ | ✓ | ✓ | ✗ | ✓ | ✗ | ~ | ✓ | |
| SUMO | ✓ | ✓ | ✗ | ✓ | ✗ | ✓ | ✗ | ✓ | ✗ | ✗ | ✓ | |
| MetaDrive | ✓ | ~ | ✗ | ✓ | ~ | ✓ | ✗ | ✗ | ✗ | ✗ | ✓ | |
| VISTA | ~ | ✗ | ✗ | ✓ | ~ | ✓ | ✗ | ✗ | ✗ | ✗ | ✓ | |
| Aerial / UAV | AirSim | ✗ | ✗ | ✓ | ✓ | ✓ | ✓ | ✗ | ✓ | ✗ | ✓ | ✓ |
| Flightmare | ✗ | ✗ | ✓ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ~ | ✓ | |
| FlightGoggles | ✗ | ✗ | ✓ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ~ | ✓ | |
| Gazebo/RotorS | ~ | ~ | ✓ | ✓ | ~ | ✓ | ✗ | ✓ | ✗ | ✓ | ✓ | |
| OmniDrones | ✗ | ✗ | ✓ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ✓ | ✓ | |
| gym-pybullet-drones | ✗ | ✗ | ✓ | ✓ | ~ | ✓ | ✗ | ✗ | ✗ | ~ | ✓ | |
| Joint / Co-Sim | TranSimHub | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ~ | — | ✗ | ✗ | ✓ |
| CARLA+SUMO | ✓ | ✓ | ✗ | ✗ | ✗ | ~ | ✗ | — | ✗ | ✗ | ✓ | |
| AirSim+Gazebo | ~ | ~ | ✓ | ✗ | ✗ | ~ | ~ | — | ✗ | ~ | ✓ | |
| Embodied AI & RL | Isaac Lab | ✗ | ✗ | ~ | ✓ | ✓ | ✓ | ✗ | ✗ | ✓ | ✓ | ✓ |
| Isaac Gym | ✗ | ✗ | ~ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ✗ | ✓ | |
| Habitat | ✗ | ~ | ✗ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ✗ | ✓ | |
| SAPIEN | ✗ | ✗ | ✗ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ~ | ✓ | |
| RoboSuite | ✗ | ✗ | ✗ | ✓ | ✓ | ✓ | ✗ | ✗ | ✗ | ~ | ✓ | |
| Ours | CARLA-Air | ✓ | ✓† | ✓ | ✓ | ✓ | ✓ | ✓ | ✓ | ✓ | ✓ | ✓ |
✓ = supported; ~ = partial or constrained; ✗ = not supported; — = not applicable.
† Pedestrian AI is inherited from CARLA and fully functional; behavior under high actor density in joint scenarios is an active engineering target.
🎮 Quick Start
Option A: Binary Release (Recommended)
# 1. Download and extract CARLA-Air v0.1.7
tar xzf CarlaAir-v0.1.7.tar.gz
cd CarlaAir-v0.1.7

# 2. One-click environment setup (first time only)
bash env_setup/setup_env.sh      # creates conda env, installs deps, deploys carla module
conda activate carlaAir
bash env_setup/test_env.sh        # verify: should show all PASS

# 3. Launch the simulator (auto-spawns traffic)
./CarlaAir.sh Town10HD

# 4. Run the showcase! (in another terminal)
conda activate carlaAir
python3 examples/quick_start_showcase.py
What you'll see: A Tesla cruises through the city while a drone chases it from above. A 4-panel display shows RGB, Depth, Semantic Segmentation, and LiDAR BEV -- all synchronized. Weather cycles automatically.
Option B: Build from Source
Please refer to the Build Guide for detailed instructions on compiling CARLA-Air with UE4.26.
🐍 One Script, Two Worlds
Both APIs share the same simulated world -- no bridge, no sync headaches.
import carla, airsim

carla_client = carla.Client("localhost", 2000)
air_client   = airsim.MultirotorClient(port=41451)
world = carla_client.get_world()

# One weather call affects EVERY sensor — ground AND air
world.set_weather(carla.WeatherParameters.HardRainSunset)

# Spawn a car, let it drive
vehicle = world.spawn_actor(vehicle_bp, spawn_point)
vehicle.set_autopilot(True)

# Fly the drone above — same world, same rain, same physics
air_client.takeoffAsync().join()
air_client.moveToPositionAsync(80, 30, -25, 5)
6 demo scripts -- try them all:
python3 examples/quick_start_showcase.py   # 🎬 4-panel sensors + drone chase + weather cycling
python3 examples/drive_vehicle.py          # 🚗 Drive a Tesla with WASD
python3 examples/walk_pedestrian.py        # 🚶 Walk the city on foot (mouse look)
python3 examples/switch_maps.py            # 🗺️  Fly through all 13 maps automatically
python3 examples/sensor_gallery.py         # 📸 6-grid sensor showcase on one vehicle
python3 examples/air_ground_sync.py        # 🔄 Car + drone split-screen: same rain, same world
Recording toolkit -- record trajectories for vehicle, drone, and pedestrian, then replay them with a director camera:
python3 examples/recording/record_vehicle.py     # 🚗 Drive & record vehicle trajectory
python3 examples/recording/record_drone.py       # 🚁 Fly & record drone trajectory (zero intrusion)
python3 examples/recording/record_walker.py      # 🚶 Walk & record pedestrian trajectory
python3 examples/recording/demo_director.py \    # 🎬 Replay all + free camera + MP4 recording
    trajectories/vehicle_*.json trajectories/drone_*.json
Docs: Coordinate Systems (CARLA to AirSim) | Quick Start Guide | FAQ
🔬 Research Directions & Workflows
CARLA-Air is designed to support four major research directions in air-ground embodied intelligence:
- Air-Ground Cooperation -- Heterogeneous air-ground agents collaborating in a shared urban environment.
- Embodied Navigation (VLN/VLA) -- Vision-and-language-driven navigation and action in photorealistic cities.
- Multi-Modal Perception and Dataset Collection -- Synchronized aerial-ground sensor data acquisition across diverse conditions.
- RL-Based Policy Training -- Closed-loop reinforcement learning with joint air-ground interaction.
The platform provides five reference workflows that cover these directions:
| Workflow | Direction | Key Result | |
|---|---|---|---|
| W1 | Air-Ground Cooperation | Air-ground cooperation | Real-time cross-domain coordination |
| W2 | VLN/VLA Tasks | Embodied navigation | Cross-view VLN data pipeline |
| W3 | Multi-Modal Dataset Collection | Perception and dataset | 12-stream sync, 1-tick alignment |
| W4 | Cross-View Perception | Perception and dataset | 14/14 weather presets verified |
| W5 | RL Training Environment | RL policy training | 357 reset cycles, 0 crashes |
|
W1: Air-Ground Cooperation |
W2: VLN/VLA Tasks |
|
W3: Multi-Modal Dataset Collection |
W4: Cross-View Perception |
|
W5: RL Training Environment |
Custom Asset Import |
|
ROS 2 Integration — 63 Topics across Both Backends | |
⌨️ Flight Controls
When the simulator is running, click inside the window to capture the mouse:
| Key | Action |
|---|---|
W / A / S / D | Move Forward / Left / Backward / Right |
Space / Shift | Ascend / Descend |
Mouse | Yaw (Turn Left/Right) |
Scroll Wheel | Adjust Flight Speed |
N | Cycle Weather Presets (Clear, Rain, Fog, Night, etc.) |
P | Toggle Collision Mode (Physics vs. Noclip/Invincible) |
H | Show/Hide On-Screen Help Menu |
Tab | Release / Capture Mouse |
📚 Documentation & Tutorials
We provide 6 curated Python examples showcasing the core air-ground cooperative capabilities:
| Example | Description |
|---|---|
quick_start_showcase.py | 4-panel sensors + drone chase + weather cycling |
drive_vehicle.py | Drive a Tesla with WASD keyboard control |
walk_pedestrian.py | Walk the city on foot with mouse look |
switch_maps.py | Fly through all 13 maps automatically |
sensor_gallery.py | 6-grid sensor showcase on one vehicle |
air_ground_sync.py | Car + drone split-screen: same rain, same world |
Step-by-step tutorials (8 scripts in CarlaAir_Release/guide/examples/, beginner-friendly):
| # | Tutorial | What You Will Learn |
|---|---|---|
| 01 | 01_hello_world.py | Connect to both APIs, verify setup |
| 02 | 02_weather_control.py | Change weather parameters in real-time |
| 03 | 03_spawn_traffic.py | Generate vehicles and pedestrians |
| 04 | 04_sensor_capture.py | Attach and read sensors |
| 05 | 05_drone_takeoff.py | Basic drone flight commands |
| 06 | 06_drone_sensors.py | Aerial sensor configuration |
| 07 | 07_combined_demo.py | Air-ground joint operation |
| 08 | 08_full_showcase.py | Full platform capabilities |
Full Documentation:
- Quick Start Guide
- Coordinate Systems (CARLA to AirSim)
- Architecture Details
- Modifications from Upstream
- FAQ
🗺️ Roadmap
- Single-process CARLA + AirSim integration (UE4.26)
- FPS drone control (WASD + Mouse)
- Auto traffic spawn (vehicles + pedestrians)
- 18-channel synchronized sensors
- Dual Python API (CARLA + AirSim)
- ROS2 validation (63 topics)
- One-click environment setup
- Recording toolkit (vehicle, drone, pedestrian trajectories)
- Technical report (PDF)
- Project page (carla-air.com)
- Tutorial documentation
- 3DGS rendering pipeline integration
- World Model integration
- Multi-drone support
📝 Citation
If you find CARLA-Air useful in your research, please consider citing our paper:
@misc{zeng2026carlaairflydronesinside,
  title={CARLA-Air: Fly Drones Inside a CARLA World -- A Unified Infrastructure for Air-Ground Embodied Intelligence},
  author={Tianle Zeng and Yanci Wen and Hong Zhang},
  year={2026},
  eprint={2603.28032},
  archivePrefix={arXiv},
  primaryClass={cs.RO},
  url={https://arxiv.org/abs/2603.28032}
}
📜 License & Acknowledgments
CARLA-Air is built upon the shoulders of giants. We sincerely thank the developers of:
- CARLA Simulator (MIT License)
- Microsoft AirSim (MIT License)
- Unreal Engine
CARLA-Air specific code is distributed under the MIT License. CARLA specific assets are distributed under the CC-BY License.
⭐ Star History
Similar repos
Contributors
Languages
C++
61.9%
QMake
22.5%
Python
11.2%
C
1.8%
Shell
1.0%