
Ao Liang*,1,2,3,4
Lingdong Kong*,1
Dongyue Lu*,1
Youquan Liu5
Jian Fang4
Huaici Zhao4
Wei Tsang Ooi1
1National University of Singapore
2University of Chinese Academy of Sciences
3Key Laboratory of Opto-Electronic Information Processing, Chinese Academy of Sciences
4Shenyang Institute of Automation, Chinese Academy of Sciences
5Fudan University
*Equally contributed to this work


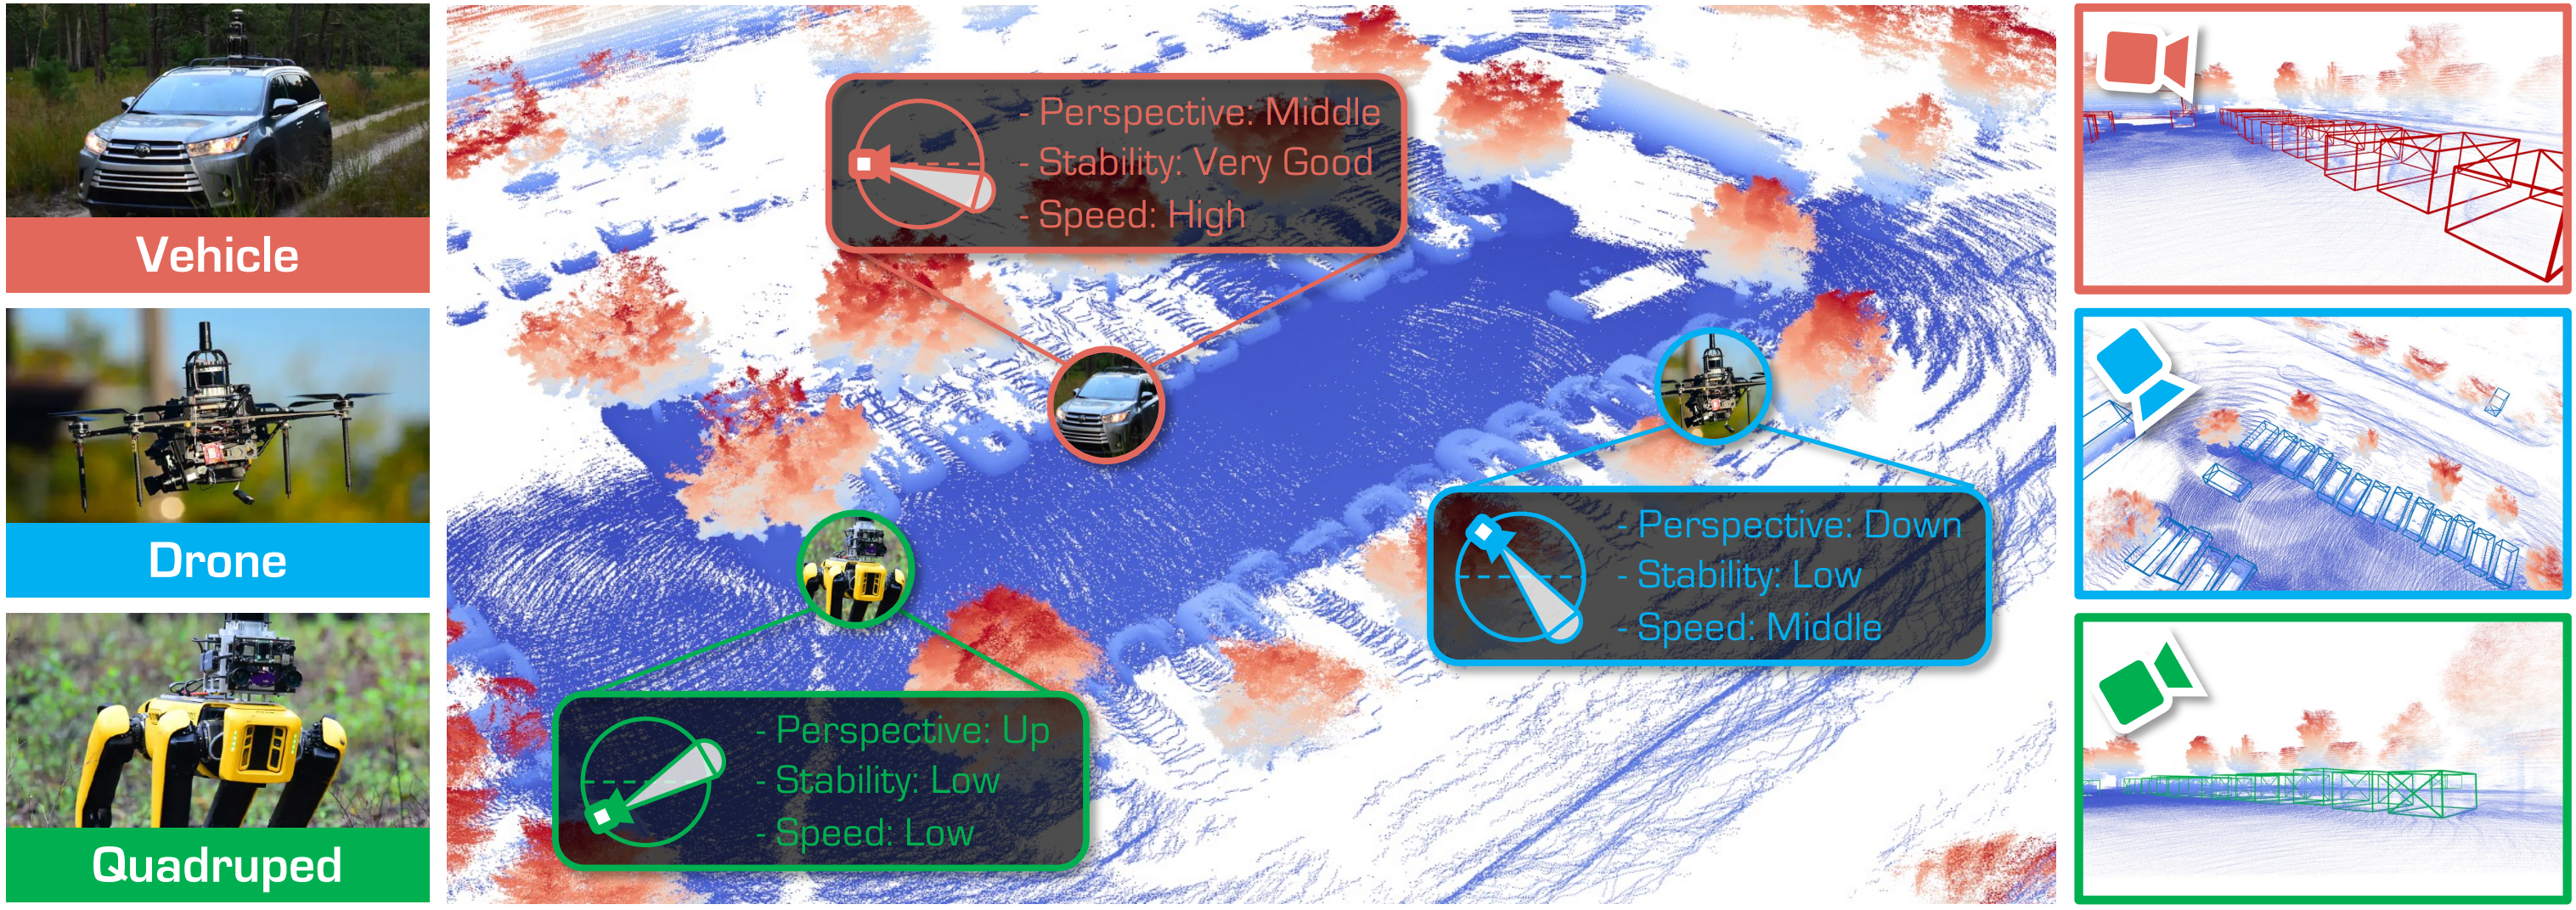
Since the Pi3DET dataset is being used for Track 5: Cross-Platform 3D Object Detection of the RoboSense Challenge at IROS 2025, in the interest of fairness we are temporarily not releasing all of the data and annotations. If you’re interested, we have open‑sourced a subset of the data and code—please refer to the track details for more information.
The Track 5 dataset follows the KITTI format. Each sample consists of:
Calibration and annotations are packaged together in
.pklfiles.
We use the same training set (vehicle platform) for both phases, but different validation sets. The full dataset is hosted on Hugging Face:
robosense/track5-cross-platform-3d-object-detection
python tools/load_dataset.py $USER_DEFINE_OUTPUT_PATH
 # Create target directory
 mkdir -p data/pi3det

 # Link the training split
 ln -s $USER_DEFINE_OUTPUT_PATH/track5-cross-platform-3d-object-detection/phase12_vehicle_training/training \
     data/pi3det/training

 # Link the validation split for Phase 1 (Drone)
 ln -s $USER_DEFINE_OUTPUT_PATH/track5-cross-platform-3d-object-detection/phase1_drone_validation/validation \
     data/pi3det/validation

 # Link the .pkl info files
 ln -s $USER_DEFINE_OUTPUT_PATH/track5-cross-platform-3d-object-detection/phase12_vehicle_training/training/pi3det_infos_train.pkl \
     data/pi3det/pi3det_infos_train.pkl
 ln -s $USER_DEFINE_OUTPUT_PATH/track5-cross-platform-3d-object-detection/phase1_drone_validation/validation/pi3det_infos_val.pkl \
     data/pi3det/pi3det_infos_val.pkl
data/ folder should look like this:
 data/
 └── pi3det/
     ├── training/
     │   ├── image/
     │   │   ├── 0000000.jpg
     │   │   └── 0000001.jpg
     │   └── point_cloud/
     │       ├── 0000000.bin
     │       └── 0000001.bin
     ├── validation/
     │   ├── image/
     │   │   ├── 0000000.jpg
     │   │   └── 0000001.jpg
     │   └── point_cloud/
     │       ├── 0000000.bin
     │       └── 0000001.bin
     ├── pi3det_infos_train.pkl
     └── pi3det_infos_val.pkl
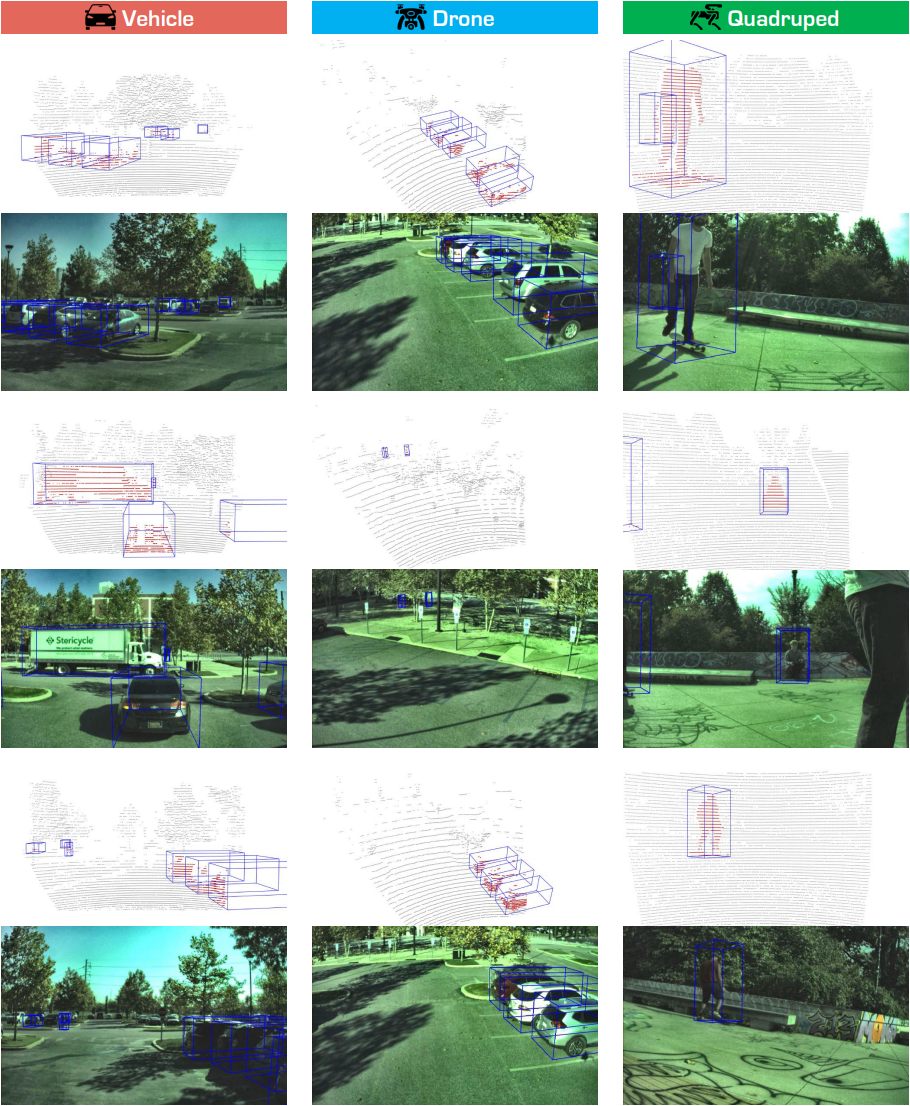
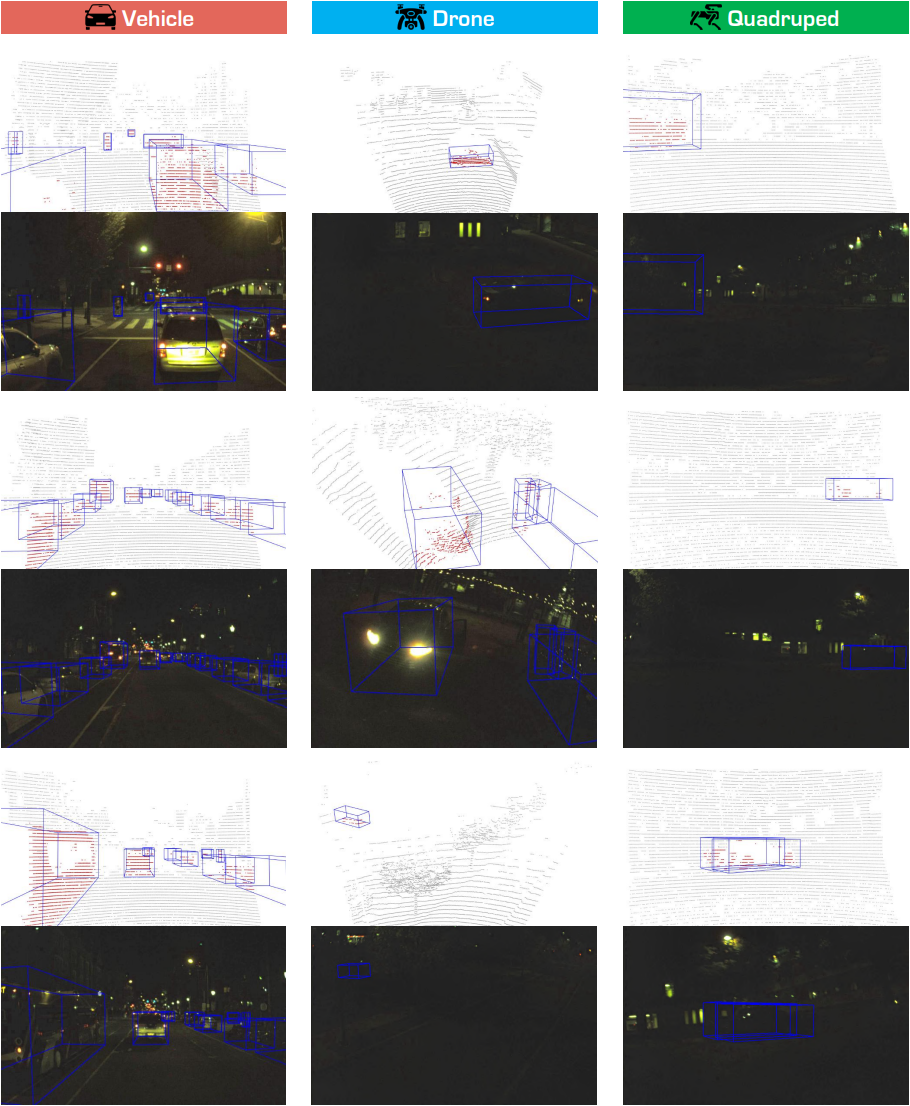
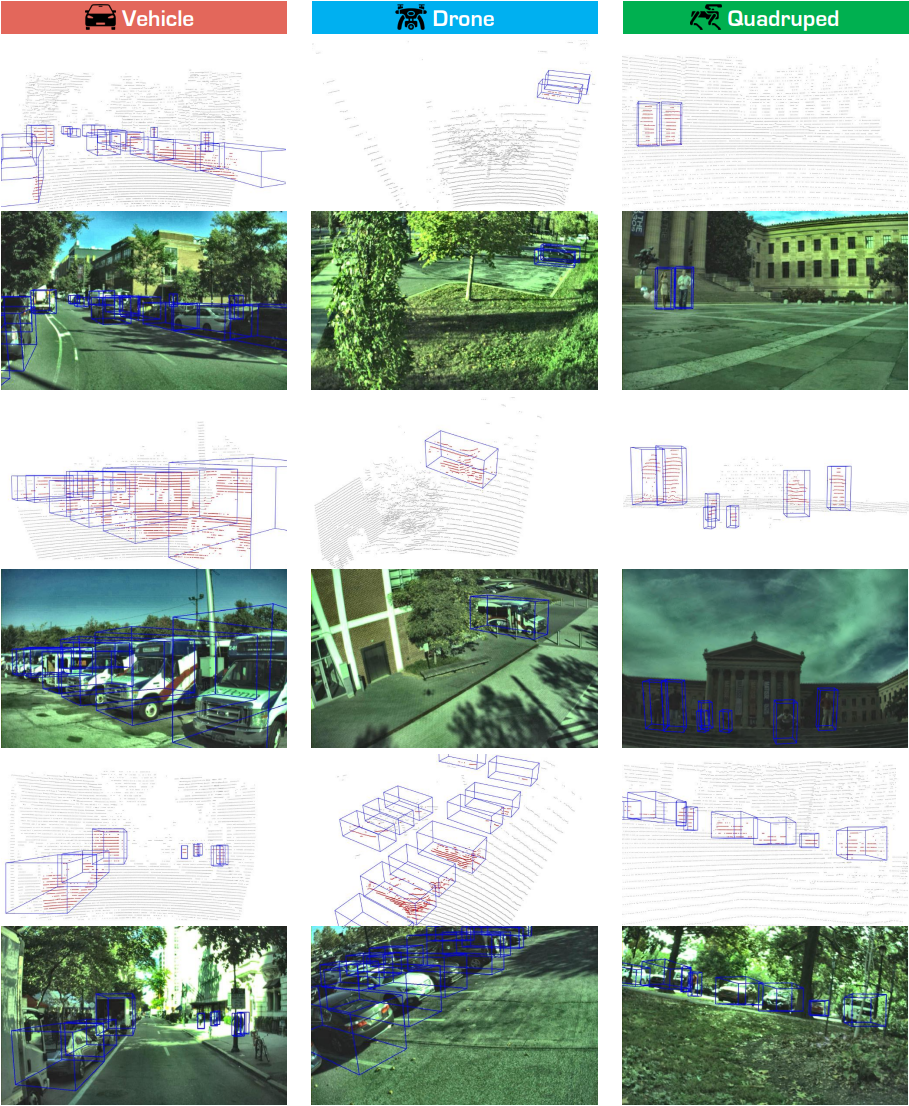
| Platform | Condition | Sequence | # of Frames | # of Points (M) | # of Vehicles | # of Pedestrians |
|---|---|---|---|---|---|---|
| Vehicle (8) | Daytime (4) | city_hall | 2,982 | 26.61 | 19,489 | 12,199 |
| penno_big_loop | 3,151 | 33.29 | 17,240 | 1,886 | ||
| rittenhouse | 3,899 | 49.36 | 11,056 | 12,003 | ||
| ucity_small_loop | 6,746 | 67.49 | 34,049 | 34,346 | ||
| Nighttime (4) | city_hall | 2,856 | 26.16 | 12,655 | 5,492 | |
| penno_big_loop | 3,291 | 38.04 | 8,068 | 106 | ||
| rittenhouse | 4,135 | 52.68 | 11,103 | 14,315 | ||
| ucity_small_loop | 5,133 | 53.32 | 18,251 | 8,639 | ||
| Summary (Vehicle) | 32,193 | 346.95 | 131,911 | 88,986 | ||
| Drone (7) | Daytime (4) | penno_parking_1 | 1,125 | 8.69 | 6,075 | 115 |
| penno_parking_2 | 1,086 | 8.55 | 5,896 | 340 | ||
| penno_plaza | 678 | 5.60 | 721 | 65 | ||
| penno_trees | 1,319 | 11.58 | 657 | 160 | ||
| Nighttime (3) | high_beams | 674 | 5.51 | 578 | 211 | |
| penno_parking_1 | 1,030 | 9.42 | 524 | 151 | ||
| penno_parking_2 | 1,140 | 10.12 | 83 | 230 | ||
| Summary (Drone) | 7,052 | 59.47 | 14,534 | 1,272 | ||
| Quadruped (10) | Daytime (8) | art_plaza_loop | 1,446 | 14.90 | 0 | 3,579 |
| penno_short_loop | 1,176 | 14.68 | 3,532 | 89 | ||
| rocky_steps | 1,535 | 14.42 | 0 | 5,739 | ||
| skatepark_1 | 661 | 12.21 | 0 | 893 | ||
| skatepark_2 | 921 | 8.47 | 0 | 916 | ||
| srt_green_loop | 639 | 9.23 | 1,349 | 285 | ||
| srt_under_bridge_1 | 2,033 | 28.95 | 0 | 1,432 | ||
| srt_under_bridge_2 | 1,813 | 25.85 | 0 | 1,463 | ||
| Nighttime (2) | penno_plaza_lights | 755 | 11.25 | 197 | 52 | |
| penno_short_loop | 1,321 | 16.79 | 904 | 103 | ||
| Summary (Quadruped) | 12,300 | 156.75 | 5,982 | 14,551 | ||
| All Three Platforms (25) | Summary (All) | 51,545 | 563.17 | 152,427 | 104,809 |
Ao Liang*,1,2,3,4
Lingdong Kong*,1
Dongyue Lu*,1
Youquan Liu5
Jian Fang4
Huaici Zhao4
Wei Tsang Ooi1
1National University of Singapore
2University of Chinese Academy of Sciences
3Key Laboratory of Opto-Electronic Information Processing, Chinese Academy of Sciences
4Shenyang Institute of Automation, Chinese Academy of Sciences
5Fudan University
*Equally contributed to this work
Since the Pi3DET dataset is being used for Track 5: Cross-Platform 3D Object Detection of the RoboSense Challenge at IROS 2025, in the interest of fairness we are temporarily not releasing all of the data and annotations. If you’re interested, we have open‑sourced a subset of the data and code—please refer to the track details for more information.
The Track 5 dataset follows the KITTI format. Each sample consists of:
Calibration and annotations are packaged together in
.pklfiles.
We use the same training set (vehicle platform) for both phases, but different validation sets. The full dataset is hosted on Hugging Face:
robosense/track5-cross-platform-3d-object-detection
python tools/load_dataset.py $USER_DEFINE_OUTPUT_PATH
 # Create target directory
 mkdir -p data/pi3det

 # Link the training split
 ln -s $USER_DEFINE_OUTPUT_PATH/track5-cross-platform-3d-object-detection/phase12_vehicle_training/training \
     data/pi3det/training

 # Link the validation split for Phase 1 (Drone)
 ln -s $USER_DEFINE_OUTPUT_PATH/track5-cross-platform-3d-object-detection/phase1_drone_validation/validation \
     data/pi3det/validation

 # Link the .pkl info files
 ln -s $USER_DEFINE_OUTPUT_PATH/track5-cross-platform-3d-object-detection/phase12_vehicle_training/training/pi3det_infos_train.pkl \
     data/pi3det/pi3det_infos_train.pkl
 ln -s $USER_DEFINE_OUTPUT_PATH/track5-cross-platform-3d-object-detection/phase1_drone_validation/validation/pi3det_infos_val.pkl \
     data/pi3det/pi3det_infos_val.pkl
data/ folder should look like this:
 data/
 └── pi3det/
     ├── training/
     │   ├── image/
     │   │   ├── 0000000.jpg
     │   │   └── 0000001.jpg
     │   └── point_cloud/
     │       ├── 0000000.bin
     │       └── 0000001.bin
     ├── validation/
     │   ├── image/
     │   │   ├── 0000000.jpg
     │   │   └── 0000001.jpg
     │   └── point_cloud/
     │       ├── 0000000.bin
     │       └── 0000001.bin
     ├── pi3det_infos_train.pkl
     └── pi3det_infos_val.pkl
| Platform | Condition | Sequence | # of Frames | # of Points (M) | # of Vehicles | # of Pedestrians |
|---|---|---|---|---|---|---|
| Vehicle (8) | Daytime (4) | city_hall | 2,982 | 26.61 | 19,489 | 12,199 |
| penno_big_loop | 3,151 | 33.29 | 17,240 | 1,886 | ||
| rittenhouse | 3,899 | 49.36 | 11,056 | 12,003 | ||
| ucity_small_loop | 6,746 | 67.49 | 34,049 | 34,346 | ||
| Nighttime (4) | city_hall | 2,856 | 26.16 | 12,655 | 5,492 | |
| penno_big_loop | 3,291 | 38.04 | 8,068 | 106 | ||
| rittenhouse | 4,135 | 52.68 | 11,103 | 14,315 | ||
| ucity_small_loop | 5,133 | 53.32 | 18,251 | 8,639 | ||
| Summary (Vehicle) | 32,193 | 346.95 | 131,911 | 88,986 | ||
| Drone (7) | Daytime (4) | penno_parking_1 | 1,125 | 8.69 | 6,075 | 115 |
| penno_parking_2 | 1,086 | 8.55 | 5,896 | 340 | ||
| penno_plaza | 678 | 5.60 | 721 | 65 | ||
| penno_trees | 1,319 | 11.58 | 657 | 160 | ||
| Nighttime (3) | high_beams | 674 | 5.51 | 578 | 211 | |
| penno_parking_1 | 1,030 | 9.42 | 524 | 151 | ||
| penno_parking_2 | 1,140 | 10.12 | 83 | 230 | ||
| Summary (Drone) | 7,052 | 59.47 | 14,534 | 1,272 | ||
| Quadruped (10) | Daytime (8) | art_plaza_loop | 1,446 | 14.90 | 0 | 3,579 |
| penno_short_loop | 1,176 | 14.68 | 3,532 | 89 | ||
| rocky_steps | 1,535 | 14.42 | 0 | 5,739 | ||
| skatepark_1 | 661 | 12.21 | 0 | 893 | ||
| skatepark_2 | 921 | 8.47 | 0 | 916 | ||
| srt_green_loop | 639 | 9.23 | 1,349 | 285 | ||
| srt_under_bridge_1 | 2,033 | 28.95 | 0 | 1,432 | ||
| srt_under_bridge_2 | 1,813 | 25.85 | 0 | 1,463 | ||
| Nighttime (2) | penno_plaza_lights | 755 | 11.25 | 197 | 52 | |
| penno_short_loop | 1,321 | 16.79 | 904 | 103 | ||
| Summary (Quadruped) | 12,300 | 156.75 | 5,982 | 14,551 | ||
| All Three Platforms (25) | Summary (All) | 51,545 | 563.17 | 152,427 | 104,809 |



