A ROS package tool to analyze the IMU performance.
See the codeA ROS package tool to analyze the IMU performance. C++ version of Allan Variance Tool.
The figures are drawn by Matlab, in scripts.
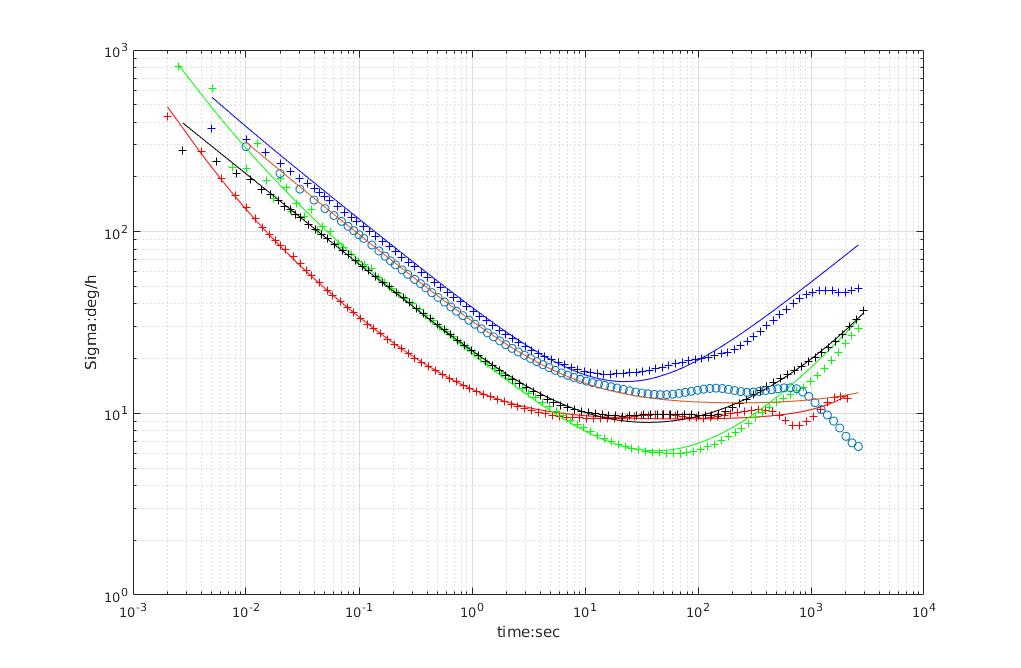
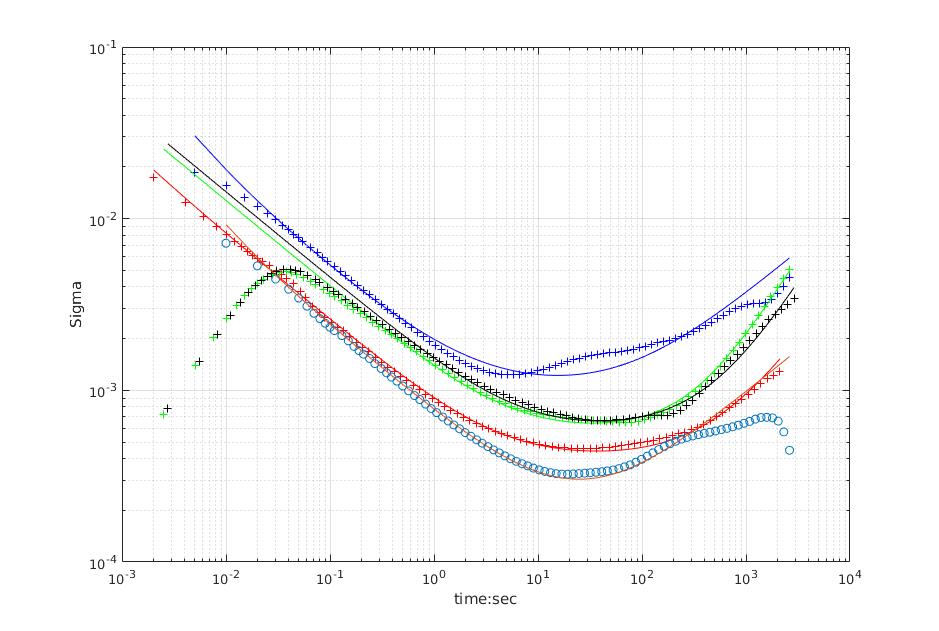
Actually, just analyze the Allan Variance for the IMU data. Collect the data while the IMU is Stationary, with a two hours duration.
Refrence technical report: Allan Variance: Noise Analysis for Gyroscopes, vectornav gyroscope and
An introduction to inertial navigation.
Woodman, O.J., 2007. An introduction to inertial navigation (No. UCAM-CL-TR-696). University of Cambridge, Computer Laboratory.
Refrence Matlab code: GyroAllan
| Parameter | YAML element | Symbol | Units |
|---|---|---|---|
| Gyroscope "white noise" | gyr_n | ||
| Accelerometer "white noise" | acc_n | ||
| Gyroscope "bias Instability" | gyr_w | ||
| Accelerometer "bias Instability" | acc_w |
White noise is at tau=1;
Bias Instability is around the minimum;
(according to technical report: Allan Variance: Noise Analysis for Gyroscopes)
200Hz500Hz400Hz400Hz100Hzsudo apt-get install libdw-dev
put the ROS package imu_utils into your workspace src folder, usually named catkin_ws;
cd to your workspace, build with catkin_make;
collect the data while the IMU is Stationary, with a two hours duration;
(or) play rosbag dataset;
rosbag play -r 200 imu_A3.bag
roslaunch imu_utils A3.launch
Be careful of your roslaunch file:
<launch>
    <node pkg="imu_utils" type="imu_an" name="imu_an" output="screen">
        <param name="imu_topic" type="string" value= "/djiros/imu"/>
        <param name="imu_name" type="string" value= "A3"/>
        <param name="data_save_path" type="string" value= "$(find imu_utils)/data/"/>
        <param name="max_time_min" type="int" value= "120"/>
        <param name="max_cluster" type="int" value= "100"/>
    </node>
</launch>
type: IMU
name: A3
Gyr:
   unit: " rad/s"
   avg-axis:
      gyr_n: 1.0351286977809465e-04
      gyr_w: 2.9438676109223402e-05
   x-axis:
      gyr_n: 1.0312669892959053e-04
      gyr_w: 3.3765827874234673e-05
   y-axis:
      gyr_n: 1.0787155789128671e-04
      gyr_w: 3.1970693666470835e-05
   z-axis:
      gyr_n: 9.9540352513406743e-05
      gyr_w: 2.2579506786964707e-05
Acc:
   unit: " m/s^2"
   avg-axis:
      acc_n: 1.3985049290745563e-03
      acc_w: 6.3249251509920116e-04
   x-axis:
      acc_n: 1.1687799474421937e-03
      acc_w: 5.3044554054317266e-04
   y-axis:
      acc_n: 1.2050535351630543e-03
      acc_w: 6.0281218607825414e-04
   z-axis:
      acc_n: 1.8216813046184213e-03
      acc_w: 7.6421981867617645e-04
DJI A3: 400Hz
Download link: 百度网盘
DJI A3: 400Hz
Download link: 百度网盘
ADIS16448: 200Hz
Download link:百度网盘
3dM-GX4: 500Hz
Download link:百度网盘
xsens-MTI-100: 100Hz
Download link:百度网盘
291 followers · starred Oct 2019
266 followers · starred Jun 2018
34 followers · starred May 2026
57 followers · starred Feb 2025
A ROS package tool to analyze the IMU performance.
See the codeA ROS package tool to analyze the IMU performance. C++ version of Allan Variance Tool.
The figures are drawn by Matlab, in scripts.
Actually, just analyze the Allan Variance for the IMU data. Collect the data while the IMU is Stationary, with a two hours duration.
Refrence technical report: Allan Variance: Noise Analysis for Gyroscopes, vectornav gyroscope and
An introduction to inertial navigation.
Woodman, O.J., 2007. An introduction to inertial navigation (No. UCAM-CL-TR-696). University of Cambridge, Computer Laboratory.
Refrence Matlab code: GyroAllan
| Parameter | YAML element | Symbol | Units |
|---|---|---|---|
| Gyroscope "white noise" | gyr_n | ||
| Accelerometer "white noise" | acc_n | ||
| Gyroscope "bias Instability" | gyr_w | ||
| Accelerometer "bias Instability" | acc_w |
White noise is at tau=1;
Bias Instability is around the minimum;
(according to technical report: Allan Variance: Noise Analysis for Gyroscopes)
200Hz500Hz400Hz400Hz100Hzsudo apt-get install libdw-dev
put the ROS package imu_utils into your workspace src folder, usually named catkin_ws;
cd to your workspace, build with catkin_make;
collect the data while the IMU is Stationary, with a two hours duration;
(or) play rosbag dataset;
rosbag play -r 200 imu_A3.bag
roslaunch imu_utils A3.launch
Be careful of your roslaunch file:
<launch>
    <node pkg="imu_utils" type="imu_an" name="imu_an" output="screen">
        <param name="imu_topic" type="string" value= "/djiros/imu"/>
        <param name="imu_name" type="string" value= "A3"/>
        <param name="data_save_path" type="string" value= "$(find imu_utils)/data/"/>
        <param name="max_time_min" type="int" value= "120"/>
        <param name="max_cluster" type="int" value= "100"/>
    </node>
</launch>
type: IMU
name: A3
Gyr:
   unit: " rad/s"
   avg-axis:
      gyr_n: 1.0351286977809465e-04
      gyr_w: 2.9438676109223402e-05
   x-axis:
      gyr_n: 1.0312669892959053e-04
      gyr_w: 3.3765827874234673e-05
   y-axis:
      gyr_n: 1.0787155789128671e-04
      gyr_w: 3.1970693666470835e-05
   z-axis:
      gyr_n: 9.9540352513406743e-05
      gyr_w: 2.2579506786964707e-05
Acc:
   unit: " m/s^2"
   avg-axis:
      acc_n: 1.3985049290745563e-03
      acc_w: 6.3249251509920116e-04
   x-axis:
      acc_n: 1.1687799474421937e-03
      acc_w: 5.3044554054317266e-04
   y-axis:
      acc_n: 1.2050535351630543e-03
      acc_w: 6.0281218607825414e-04
   z-axis:
      acc_n: 1.8216813046184213e-03
      acc_w: 7.6421981867617645e-04
DJI A3: 400Hz
Download link: 百度网盘
DJI A3: 400Hz
Download link: 百度网盘
ADIS16448: 200Hz
Download link:百度网盘
3dM-GX4: 500Hz
Download link:百度网盘
xsens-MTI-100: 100Hz
Download link:百度网盘
291 followers · starred Oct 2019
266 followers · starred Jun 2018
34 followers · starred May 2026
57 followers · starred Feb 2025



