
MuJoCo specification file and assets for OpenArm
60
stars
90
commits
JavaScript
primary language
Sep 14, 2026
updated
README
MuJoCo Description Files (MJCF) for OpenArm
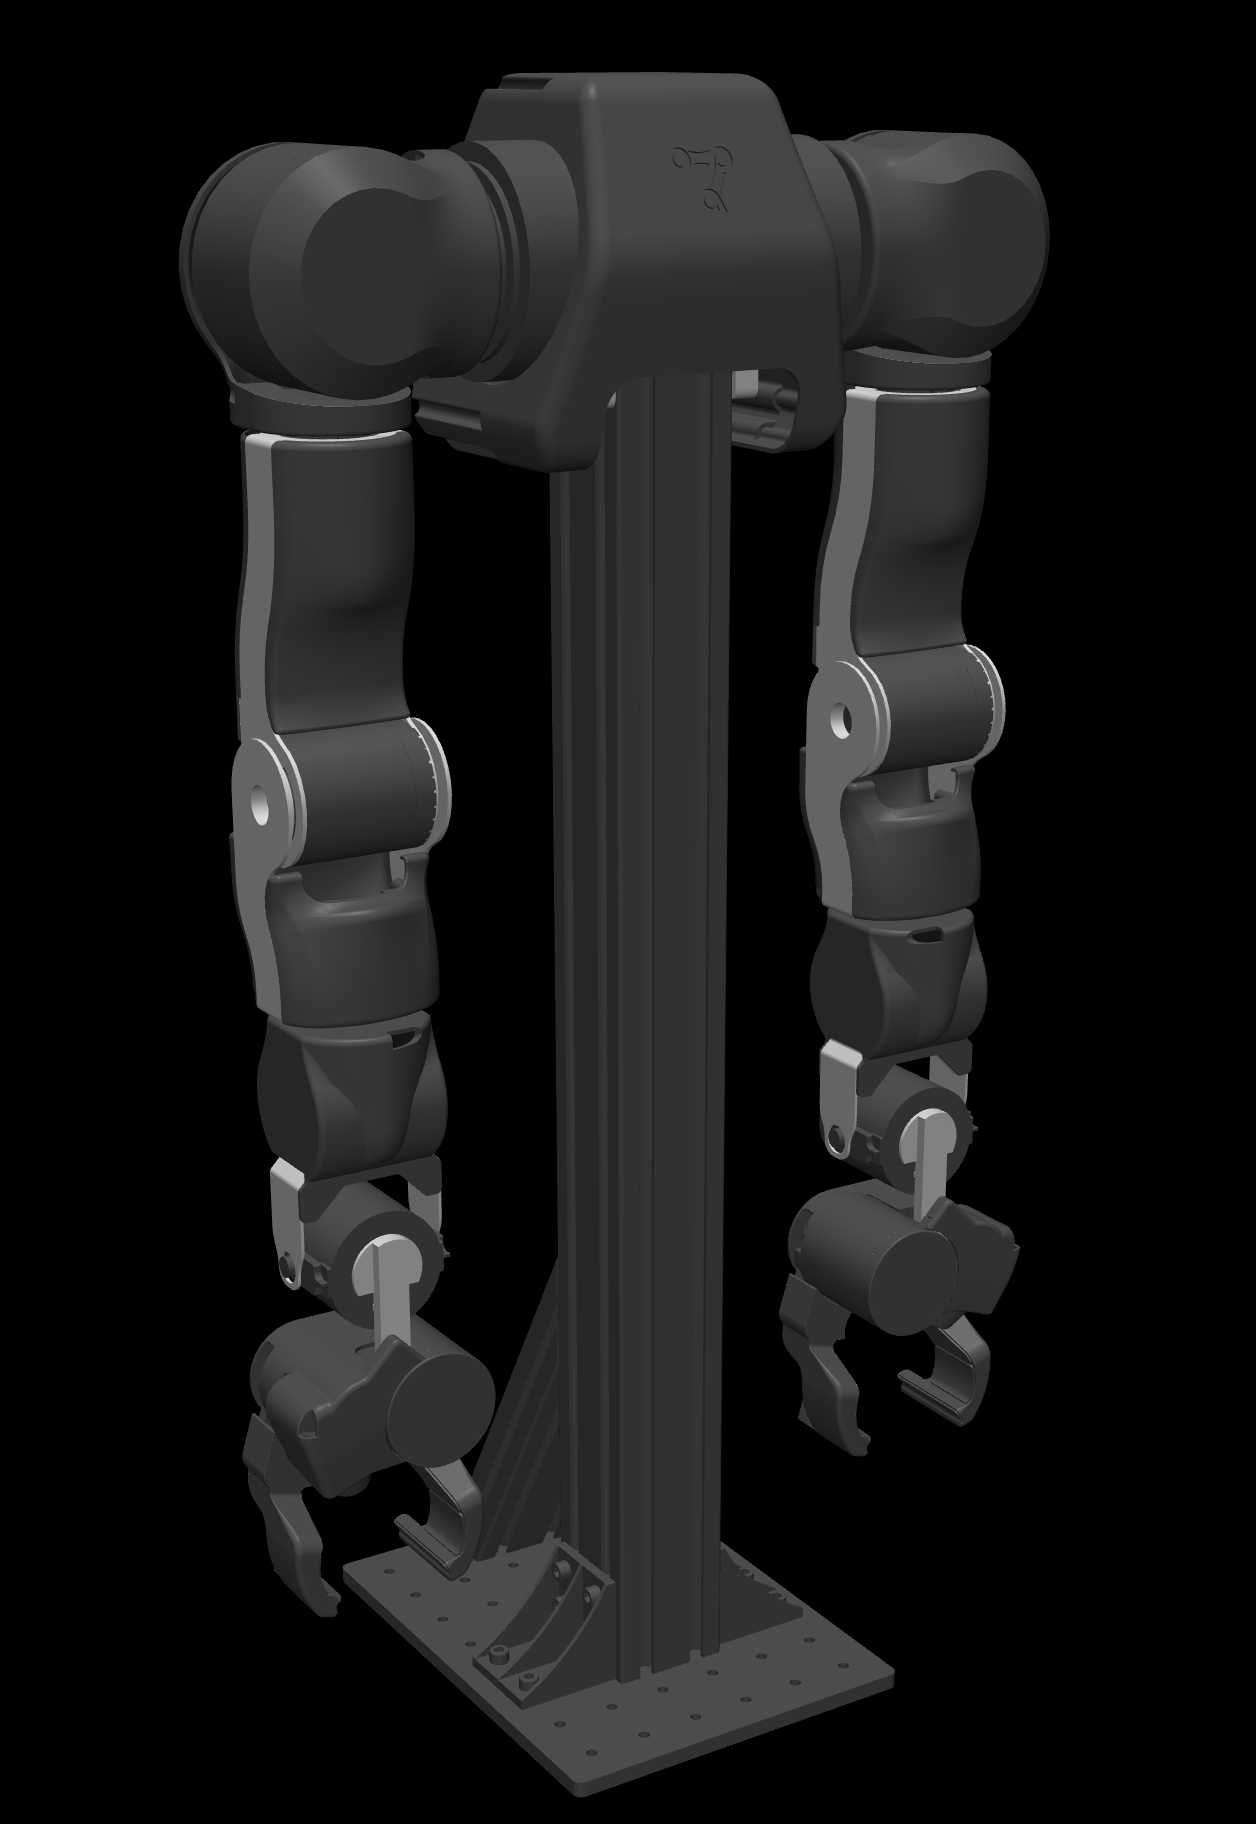
This repository contains assets for OpenArm v2 (above), Cell, v1 and v0.3 (below) simulation in MuJoCo.
Usage
Install openarm-mujoco:
pip install openarm-mujoco
Launch the simulation:
openarm-mujoco-launch
Without White Sheet:
openarm-mujoco-launch --no-sheet
With Wall Collisions:
openarm-mujoco-launch --walls
OpenArm MuJoCo Web
OpenArm MuJoCo Web runs these models right in the
browser (MuJoCo WASM + three.js, no installation): open
https://enactic.github.io/openarm_mujoco/, or serve the repository
root locally (npm run serve in web/) and open
http://localhost:8080/. Drive the arms by keyboard or sliders; see
web/README.md for details.
Collision Visualization
- To view collision meshes, activate
Rendering>Model Elements>Convex HullandGroup Enable>Geom groups>Geom 3in the left sidebar - It may also help to hide the visual meshes by deselecting
Geom 2
Related links
- 📚 Read the documentation
- 💬 Join the community on Discord
- 📬 Contact us through openarm@enactic.ai
Pull request and preview
You can enable preview on your fork by the following:
- Enable GitHub Pages on your fork:
- Open https://github.com/${YOUR_GITHUB_ACCOUNT}/openarm_mujoco/settings/pages
- Select "GitHub Actions" as "Source"
- Accept publishing GitHub Pages from all branches on your fork:
- Open https://github.com/${YOUR_GITHUB_ACCOUNT}/openarm_mujoco/settings/environments
- Select the "github-pages" environment
- Change the default "Deployment branches and tags" rule:
- Press the "Edit" button
- Change the "Name pattern" to
*frommain
You can preview your changes at https://${YOUR_GITHUB_ACCOUNT}.github.io/openarm_mujoco/ .
License
Licensed under the Apache License 2.0. See LICENSE for details.
Copyright 2025 Enactic, Inc.
Code of Conduct
All participation in the OpenArm project is governed by our Code of Conduct.
Contributors



See what people are saying
Similar repos




Languages
JavaScript
76.3%
Python
18.1%
HTML
3.4%
Shell
2.1%
MuJoCo specification file and assets for OpenArm
60
stars
90
commits
JavaScript
primary language
Sep 14, 2026
updated
README
MuJoCo Description Files (MJCF) for OpenArm
This repository contains assets for OpenArm v2 (above), Cell, v1 and v0.3 (below) simulation in MuJoCo.
Usage
Install openarm-mujoco:
pip install openarm-mujoco
Launch the simulation:
openarm-mujoco-launch
Without White Sheet:
openarm-mujoco-launch --no-sheet
With Wall Collisions:
openarm-mujoco-launch --walls
OpenArm MuJoCo Web
OpenArm MuJoCo Web runs these models right in the
browser (MuJoCo WASM + three.js, no installation): open
https://enactic.github.io/openarm_mujoco/, or serve the repository
root locally (npm run serve in web/) and open
http://localhost:8080/. Drive the arms by keyboard or sliders; see
web/README.md for details.
Collision Visualization
- To view collision meshes, activate
Rendering>Model Elements>Convex HullandGroup Enable>Geom groups>Geom 3in the left sidebar - It may also help to hide the visual meshes by deselecting
Geom 2
Related links
- 📚 Read the documentation
- 💬 Join the community on Discord
- 📬 Contact us through openarm@enactic.ai
Pull request and preview
You can enable preview on your fork by the following:
- Enable GitHub Pages on your fork:
- Open https://github.com/${YOUR_GITHUB_ACCOUNT}/openarm_mujoco/settings/pages
- Select "GitHub Actions" as "Source"
- Accept publishing GitHub Pages from all branches on your fork:
- Open https://github.com/${YOUR_GITHUB_ACCOUNT}/openarm_mujoco/settings/environments
- Select the "github-pages" environment
- Change the default "Deployment branches and tags" rule:
- Press the "Edit" button
- Change the "Name pattern" to
*frommain
You can preview your changes at https://${YOUR_GITHUB_ACCOUNT}.github.io/openarm_mujoco/ .
License
Licensed under the Apache License 2.0. See LICENSE for details.
Copyright 2025 Enactic, Inc.
Code of Conduct
All participation in the OpenArm project is governed by our Code of Conduct.
See what people are saying
Similar repos
Contributors
Languages
JavaScript
76.3%
Python
18.1%
HTML
3.4%
Shell
2.1%