
A curated awesome list for dexterous robot manipulation, tactile sensing, dexterous hands, robot learning, datasets, benchmarks, and simulators.
See the codeREADME
Awesome-Dexterous-Manipulation
A curated map of papers, hardware, sensors, methods, datasets, benchmarks, and infrastructure for dexterous robot manipulation.
About
Awesome-Dexterous-Manipulation is a curated list for the ecosystem around dexterous robot manipulation: dexterous hands, tactile sensing, hand-centric tasks, robot learning, optimal control, teleoperation, benchmarks, datasets, and simulators.
This list is intentionally dexterity-first. It includes strong adjacent manipulation work only when it materially helps understand, build, evaluate, or deploy dexterous manipulation systems.
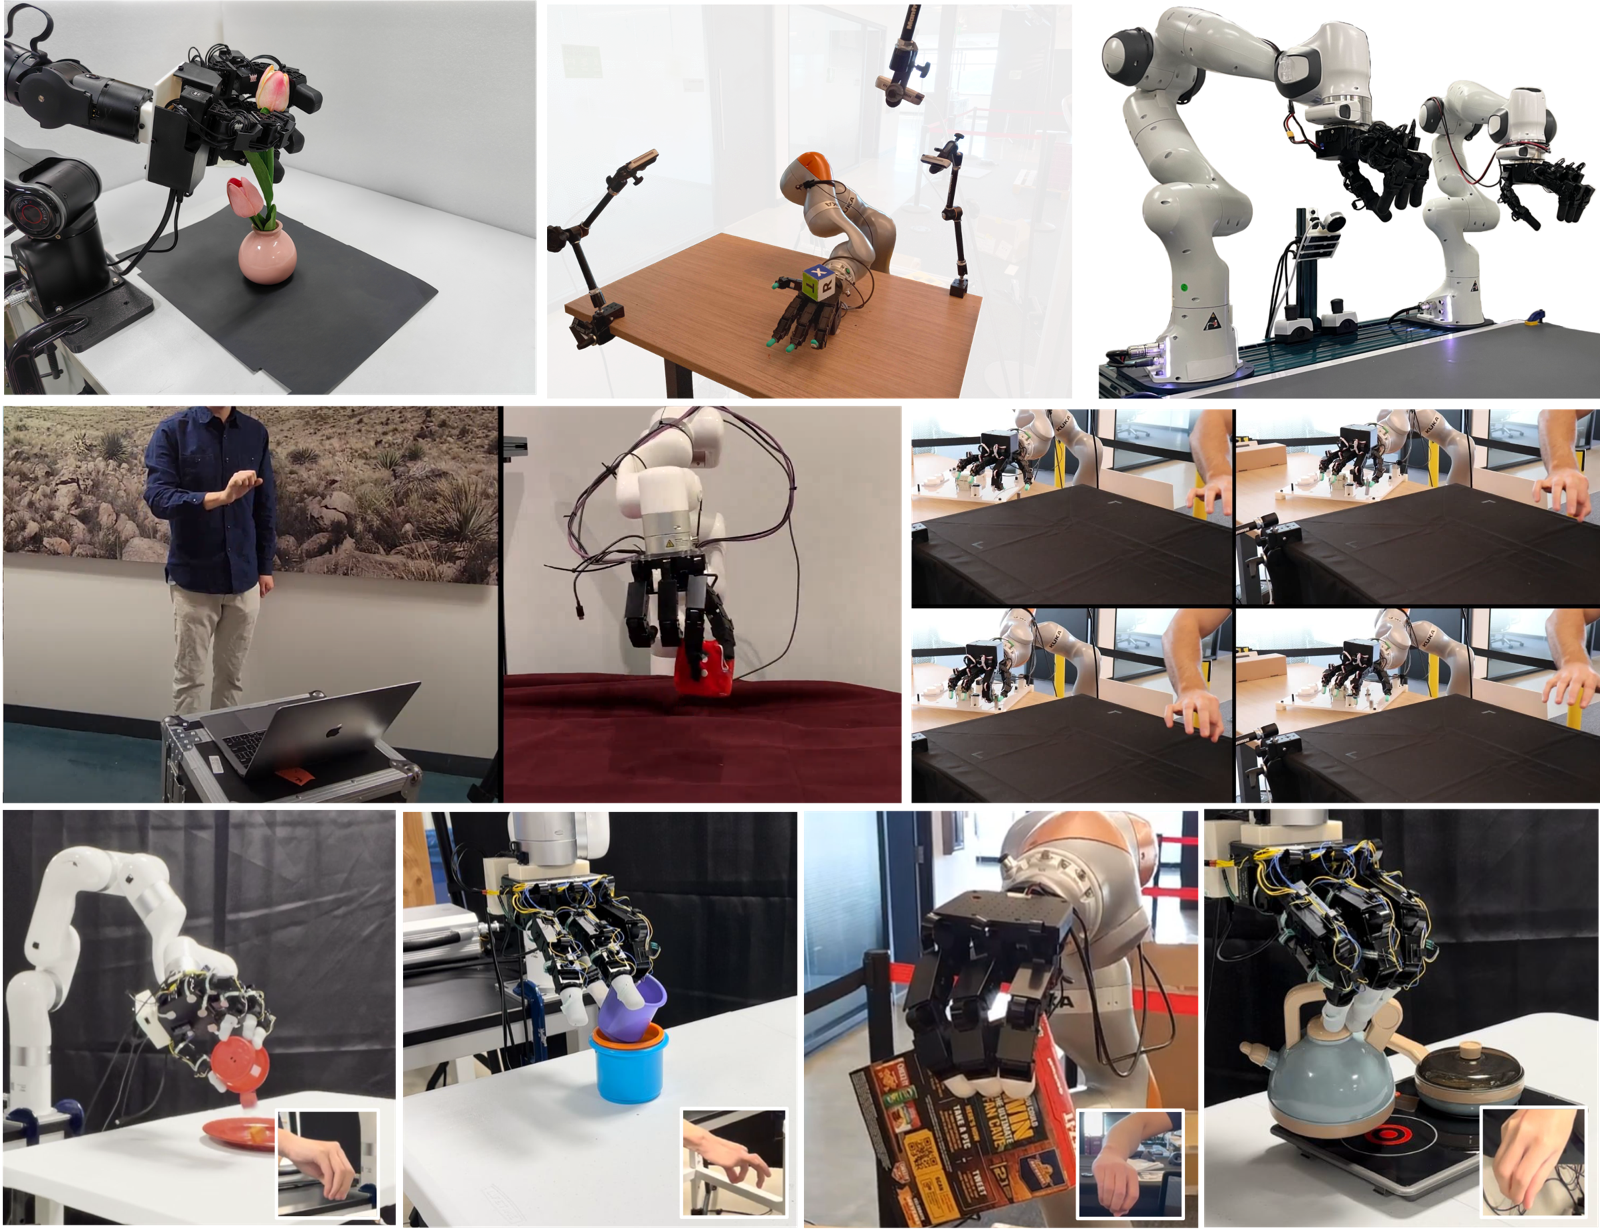
Source: Fig. 1 from Dexterous Manipulation through Imitation Learning: A Survey.
Must Read
Start here if you want the shortest path through the field.
| Goal | Start with |
|---|---|
| Understand classic dexterous manipulation | A Mathematical Introduction to Robotic Manipulation, A framework for planning dexterous manipulation |
| Learn modern in-hand RL | Learning Dexterous In-Hand Manipulation, Learning Complex Dexterous Manipulation with Deep RL and Demonstrations, HORA: In-Hand Object Rotation via Rapid Motor Adaptation |
| Study dexterous hands | LEAP Hand, Shadow Dexterous Hand, Allegro Hand |
| Study tactile sensing | TacThru, GelSight, DIGIT, ReSkin, Awesome Touch |
| Find benchmarks and datasets | DexYCB, DexGraspNet, Adroit, Shadow Hand environments |
| Build with simulators | Isaac Lab, MuJoCo, SAPIEN, PyBullet |
| Explore data collection | Pre-training Visual Dexterity in Simulation, YUBI, AutoDex, DexDirect, DexCap, DexUMI, DexWild |
News
- 2026-06-24: Realigned the README navigation to the canonical five-section taxonomy and folded enabling-system material into Infrastructure.
Contents
- Awesome-Dexterous-Manipulation
🦾 1. Hardware & Sensor Systems
Physical systems and sensing layers for dexterous manipulation.
1.1 Dexterous Hands
Anthropomorphic Hands
Non-Anthropomorphic & Multi-Finger Grippers
1.2 Tactile Sensors
Vision-Based Tactile
Capacitive & Piezoresistive
1.3 Multi-Modal Fusion Setups
Visuo-Tactile Integration
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-09-08 | Contact-Aware Tactile VLA, Latent Co-Imagination, Bimanual DexHands | Peking University | DeCAL: Towards Physically-Grounded Dexterous Vision-Language-Action Models via Contact-Aware Latent Co-Imagination | CoRL 2026 | project / github |
| 2026-09-07 | Human Video, Simulated Touch Completion, Zero-Shot Sim-to-Real | Tsinghua University | Dex-X: Learning Visual-Tactile Dexterous Manipulation From Human Videos with Simulated Interaction | arXiv | project |
| 2026-09-04 | Tactile World-Action Model, Execution-Time Correction, 20.7x Cheaper | Fudan University | TacPAC: Tactile Prediction and Real-Time Action Correction in World-Action Models for Contact-Rich Manipulation | arXiv | github |
| 2026-08-26 | Streaming Actions, Execution-Time Touch, Tactile VLA | Shanghai Jiao Tong University | TacForcing: Streaming Action Generation with Execution-Time Tactile Feedback | arXiv | project |
| 2026-08-21 | Physical Properties, Human Visuo-Tactile Data, Adaptive Grasping | Xiaomi Robotics | ViTacPhys: Physical Property-Aware Grasping from Human Visual-Tactile Demonstrations | arXiv | project |
| 2026-08-21 | Sequential Visuo-Tactile Pretraining, Temporal Alignment, Policy Learning | Shanghai Jiao Tong University | VT-MUSE: Multimodal Unified Sequential Visuotactile Representation Learning for Manipulation | arXiv | data |
| 2026-08-20 | Tactile World Action Model, Contact+Deformation+Slip Forecast | Institute of Automation, CAS | HiTac-WAM: A Hierarchical Tactile World Action Model for Contact-Rich Robot Manipulation | arXiv | paper |
| 2026-08-03 | Tactile VLA, Online Prediction, XHand, 900 Demonstrations | Authors | ReTouch: Empowering Contact-Rich Dexterous Manipulation with Online-Refined Tactile Prediction | arXiv | paper |
| 2026-07-30 | Tactile World Action Model, Force/Deformation Futures, In-Hand Manipulation | Tsinghua University | TacWAM: Anchor-Guided World Action Model with Mechanics-Aware Tactile Prediction | arXiv | paper |
| 2026-07-27 | Visuo-Tactile World Model, Contact Prediction, Planning | Institute of Automation, CAS | FeelWorld: Visuo-Tactile World Model for Hierarchical Contact Prediction and Planning | arXiv | paper |
| 2026-07-24 | Action-Conditioned World Model, Visuo-Tactile Rollouts, Policy Evaluation | ShanghaiTech University | ViTacWorld: Scaling Visuo-Tactile World Models for Contact-Rich Robot Manipulation | arXiv | project |
| 2026-07-22 | Tactile Generation, RGB-to-Touch, Data Augmentation, Imitation Learning | USC | FELT: Generating Tactile Signals from Vision for Visuo-Tactile Manipulation | arXiv | project |
| 2026-07-16 | Tactile-Grounded VLA, Future Touch Prediction, Latent Alignment | Fudan University | Representation-Aligned Tactile Grounding for Contact-Rich Robotic Manipulation | arXiv | paper |
| 2026-07-10 | Whole-Hand Tactile, Human-to-Robot Transfer, Benchmark | Authors | TactiDex: A Real-World Tactile-Guided Benchmark for Human-Like Dexterous Manipulation | arXiv | project |
| 2026-07-08 | Tactile Foundation Model, Predictive+Reactive, DexHand | Harbin Institute of Technology | TouchWorld: A Predictive and Reactive Tactile Foundation Model for Dexterous Manipulation | arXiv | paper |
| 2026-07-01 | Tactile Pretraining, 160 Hours, 135k Episodes, Human-to-Robot | Peking University | Human-Centric Transferable Tactile Pre-Training for Dexterous Robotic Manipulation | arXiv | paper |
| 2026-06-25 | Vibro-Tactile, Contact/Slip, Reactive Dexterity | CMU | VibeAct: Vibration to Actions for Contact-Rich Reactive Robot Dexterity | arXiv | project |
| 2026-06-15 | Tactile-Reactive VLA, Variable-Rate MoT, 100-Hour Dataset | Authors | T-Rex: Tactile-Reactive Dexterous Manipulation | arXiv | project |
| 2026-04-26 | Diffusion Policy, Visual-Tactile, Contact-Rich, Reactive, Tube | CMU / Stevens | Tube Diffusion Policy: Reactive Visual-Tactile Policy Learning for Contact-rich Manipulation | arXiv | paper |
| 2026-03-05 | Generative Contact Grounding, Compliance Control, Allegro+DG-5F | Purdue University | Contact-Grounded Policy: Dexterous Visuotactile Policy with Generative Contact Grounding | RSS 2026 | project |
| 2026-03-04 | Privileged Tactile Latent, No Tactile Simulation, In-Hand Reorientation | Carnegie Mellon University | PTLD: Sim-to-Real Privileged Tactile Latent Distillation for Dexterous Manipulation | arXiv | project |
| 2026-02-10 | Normalizing Flow, Action-Chunked Critics, Real-World Fine-Tuning | ETH Zurich | SERNF: Sample-Efficient Real-World Dexterous Policy Fine-Tuning via Action-Chunked Critics and Normalizing Flows | arXiv | paper |
| 2026-02-01 | Unified Force, Zero-Shot Transfer, Multi-Sensor | University of Liverpool | UniForce: A Unified Latent Force Model for Robot Manipulation with Diverse Tactile Sensors | arXiv | paper |
| 2026-01-21 | Tactile, Force/Torque, Contact-Rich | TU Munich | TacUMI: A Multi-Modal Universal Manipulation Interface for Contact-Rich Tasks | arXiv | github |
| 2025-12-24 | Cross-Embodiment Transfer, MANO Hand Model, Zero-Shot, Spatio-Tactile | Peking University | UniTacHand: Unified Spatio-Tactile Representation for Human to Robotic Hand Skill Transfer | arXiv | paper |
| 2025-12-10 | See-Through-Skin, TacThru-UMI, Diffusion Policy | Peking University | Simultaneous Tactile-Visual Perception for Learning Multimodal Robot Manipulation | RA-L 2026 | project / github |
| 2025-11-08 | Vision+Tactile, Fine Manipulation, Bimanual | Tsinghua | ViTaMIn-B | arXiv | project / paper |
| 2025-10-16 | Kinematic-Frame-Anchored, Sub-mm Precision, Geometric Reasoning | Shanghai Jiao Tong | SaTA: Spatially Anchored Tactile Awareness for Robust Dexterous Manipulation | arXiv | paper |
| 2025-09-23 | Conformable Skin, Contact-Rich, RL | UC Berkeley | DexSkin: High-Coverage Conformable Robotic Skin for Learning Contact-Rich Manipulation | CoRL 2025 | paper |
| 2025-08-20 | Visuotactile, Flow Dynamics, FBI, In-Hand Manipulation | Shanghai Jiao Tong | FBI: Learning Dexterous In-hand Manipulation with Dynamic Visuotactile Shortcut Policy | arXiv | paper |
| 2025-08-12 | Vision-Tactile-Language-Action, Semantic-Aligned, Dual-Encoder | Zhejiang University | OmniVTLA: Vision-Tactile-Language-Action Model with Semantic-Aligned Tactile Sensing | arXiv | paper |
| 2025-08-04 | Tactile Control, Articulated Objects, Proactive | Peking University | TacMan-Turbo: Proactive Tactile Control for Robust and Efficient Articulated Object Manipulation | T-ASE 2026 | paper |
| 2025-06-19 | Cross-Modal Fusion, Autoregressive Prediction, Long-Horizon Manipulation | Cornell University | ViTacFormer: Learning Cross-Modal Representation for Visuo-Tactile Dexterous Manipulation | arXiv | paper |
| 2025-06-13 | Diffusion Recipe, 16-DoF, Tendon-Driven, Teleoperation | ETH Zurich / Cornell | mimic-one: A Scalable Model Recipe for General Purpose Robot Dexterity | arXiv | paper |
| 2025-06-13 | Visuo-Tactile, Implicit Representation, Pose Estimation | UConn | ViTaSCOPE: Visuo-tactile Implicit Representation for In-hand Pose and Extrinsic Contact Estimation | RSS 2025 | paper |
| 2025-06-02 | Tactile Glove, Human-to-Robot Force Transfer, Contact-Driven Learning | Cornell University | Feel the Force: Contact-Driven Learning from Humans | arXiv | paper |
| 2025-05-16 | Egocentric Video, Apple Vision Pro, Large-Scale, Dexterous | MIT | EgoDex: Learning Dexterous Manipulation from Large-Scale Egocentric Video | arXiv | paper |
| 2025-05-16 | Self-Supervised, Magnetic Skin, PercepSkin | Intel Labs | Sparsh-skin: Self-supervised Perception for Tactile Skin Covered Dexterous Hands | CoRL 2025 | paper |
| 2025-04-23 | Paper Picking, Tactile Feedback, Diffusion Policy, Slip Detection | Tsinghua | PP-Tac: Paper Picking Using Tactile Feedback in Dexterous Robotic Hands | RSS 2025 | paper |
| 2025-04-08 | Robot-Free, Visuo-Tactile, Contact-Rich | Tsinghua | ViTaMIn: Learning Contact-Rich Tasks Through Robot-Free Visuo-Tactile Manipulation Interface | arXiv | project |
| 2025-03-02 | Force Sensing Transfer, Multi-Sensor Alignment, Shared Representation | King's College London | GenForce: Training Tactile Sensors to Learn Force Sensing from Each Other | arXiv | paper |
| 2025-02-12 | Correspondence, Visuomotor, Diffusion Policy | Peking University | CordViP: Correspondence-based Visuomotor Policy for Dexterous Manipulation in Real-World | RSS 2025 | project |
| 2024-03-04 | Tactile, Articulated Objects, Prior-Free | Peking University | Tac-Man: Tactile-Informed Prior-Free Manipulation of Articulated Objects | T-RO 2024 | project |
| 2023-09-18 | Vision+Touch, In-Hand Rotation, Sim2Real | UC Berkeley | RotateIt: General In-Hand Object Rotation with Vision and Touch | CoRL 2023 | project |
| 2023-03-25 | Visuo-Tactile, In-Hand Reconstruction, DIGIT | Shanghai Jiao Tong University | Visual-Tactile Sensing for In-Hand Object Reconstruction | CVPR 2023 | cvf |
| 2022-09-30 | Multimodal, Contact-Rich, Learning | MIT | Visuo-Tactile Transformers for Manipulation | CoRL 2022 | paper |
| 2018-05-28 | Vision+GelSight, Closed-Loop Regrasping, 6,450 Trials | UC Berkeley | More Than a Feeling: Learning to Grasp and Regrasp Using Vision and Touch | RA-L 2018 | publication |
Proprioception & Force-Torque
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-07-20 | Force Memory, Non-Markovian VLA, Contact Events | Tsinghua University | FM-VLA: Force-based Memory for Vision-Language-Action Models in Contact-Rich Manipulation | arXiv | project / github |
| 2026-07-19 | Vision+Force, Asynchronous Fusion, Reactive Diffusion Policy | Shanghai Jiao Tong | Asynchronous Multimodal Diffusion Policy Composition via Latency-Aware Guidance Fusion | arXiv | project |
| 2026-07-03 | Motor Current, Contact Feedback, Compliant Dexterity | UNC Chapel Hill | Current as Touch: Proprioceptive Contact Feedback for Compliant Dexterous Manipulation | arXiv | project |
| 2026-06-23 | Vision+Proprioception, Contact Estimation, In-Hand | IIIT Hyderabad | NoContactNoWorries: Estimating Contact through Vision and Proprioception for In-Hand Dexterous Manipulation | IROS 2026 | project |
| 2026-05-20 | Joint-Only, Proprioceptive Transformer, Tendon-Driven Hand | ETH Zurich | Learning Robust Dexterous In-Hand Manipulation from Joint Sensors with Proprioceptive Transformer | arXiv | paper |
| 2026-01-15 | Force, Compliance, Contact-Rich | Stanford | In-the-Wild Compliant Manipulation with UMI-FT | ICRA 2026 | github |
| 2025-09-23 | Force-Guided, Wrist F/T, Contact-Rich | GIST | ManipForce | ICRA 2026 | project / github |
| 2022-10-10 | Proprioception, Adaptation, Sim2Real | UC Berkeley | HORA: In-Hand Object Rotation via Rapid Motor Adaptation | arXiv | paper |
| 2019-10-16 | Proprioception, Vision, Rubik's Cube | OpenAI | Solving Rubik's Cube with a Robot Hand | arXiv | blog |
🖐️ 2. Dexterity Capabilities & Tasks
Hand-centric capabilities, organized by manipulation taxonomy rather than by only individual benchmark names.
2.1 Prehensile Manipulation
In-Hand Reorientation / Rotation
Finger Gaiting / Regrasping
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2025-09-22 | Tactile RL, Contact-Aware, Finger Gaiting | University of Southern Denmark | Tac2Motion: Contact-Aware Reinforcement Learning with Tactile Feedback for Robotic Hand Manipulation | arXiv | video |
| 2024-09-13 | Teleoperation, Finger Gaiting, Residual Learning | UIUC | ResPilot: Teleoperated Finger Gaiting via Gaussian Process Residual Learning | CoRL 2024 | project |
| 2021-09-26 | Finger Gaiting, Intrinsic Sensing, Tactile | Columbia | On the Feasibility of Learning Finger-gaiting In-hand Manipulation with Intrinsic Sensing | arXiv | project / pdf |
| 1991-04-01 | Contact Planning, Classic, ICRA | Rensselaer Polytechnic Institute | A framework for planning dexterous manipulation | ICRA 1991 | author-bib |
Tool Use & Extrinsic Dexterity
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-07-20 | Underactuated Hand, Grasp Compliance, Forceful Tool Use, AMINN | Stevens Institute of Technology | Predicting Grasping Compliance in Robotic Hands through Analytical-Model-Informed Neural Networks | arXiv | paper |
| 2026-06-30 | Functional Tool Use, VLM Constraints, Zero-Demo, Sim-to-Real | UT Austin | CoDex: Learning Compositional Dexterous Functional Manipulation without Demonstrations | ICRA 2026 | project |
| 2026-06-29 | Grasp Pretraining, Articulated Tools, DexCraft | CMU | From Grasps to Dexterity: Large-Scale Grasp Pretraining for Dexterous Manipulation | arXiv | project |
| 2026-06-11 | Articulated Tools, Functional Retargeting, RL | Stanford University | Mana: Dexterous Manipulation of Articulated Tools | arXiv | project |
| 2026-02-18 | Zero-Shot Tool Manipulation, Object-Centric, Sim2Real | Stanford | SimToolReal: An Object-Centric Policy for Zero-Shot Dexterous Tool Manipulation | arXiv | project |
| 2025-09-27 | Articulated Tools, Cross-Attention, Sim2Real | UC San Diego | In-Hand Manipulation of Articulated Tools with Dexterous Robot Hands with Sim-to-Real Transfer | IROS 2025 | paper |
| 2014-05-31 | Extrinsic Dexterity, External Forces, Robot Hand | Carnegie Mellon | Extrinsic Dexterity: In-Hand Manipulation with External Forces | ICRA 2014 | paper |
2.2 Non-Prehensile Manipulation
Pushing, Sliding & Flipping
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2016-09-28 | Pushing, Planar Manipulation, Learning | MIT | Learning to Push by Grasping: Using Multiple Tasks for Effective Learning | ICRA 2017 | paper |
Rolling & Pivoting
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 1998-05-20 | Rolling, Finger Gaiting, Contact Planning | Texas A&M | Dextrous Manipulation by Rolling and Finger Gaiting | ICRA 1998 |
2.3 Dynamic & Agile Manipulation
Catching, Throwing & Juggling
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-08-27 | Bimanual Juggling, Multi-Finger Hands, Online Adaptation, Five Patterns | Robotics and AI Institute | Rapid On-Robot Learning for Dynamic Manipulation Skills: Robot Juggling | arXiv | paper |
| 2026-05-10 | Reactive Catching, Zero-Shot Sim-to-Real, Instance-Set Randomization | Rice University | Zero-Shot Sim-to-Real Robot Learning: A Dexterous Manipulation Study on Reactive Catching | arXiv | paper |
| 2019-10-16 | Rubik's Cube, Disturbance, Dynamic Recovery | OpenAI | Solving Rubik's Cube with a Robot Hand | arXiv | blog |
Pen Spinning / Twirling / Fine Motor Skills
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-09-10 | In-Hand Pen Writing, Online Jacobian, 18s Initialization, 0.6mm Error | ETH Zurich | Rapid Learning of Dexterous In-Hand Pen Writing through Real-Time Jacobian Estimation | arXiv | project |
| 2026-03-23 | Robot Drumming, In-Hand Control, Contact-Rich, Long-Horizon | Stanford University | DexDrummer: In-Hand, Contact-Rich, and Long-Horizon Dexterous Robot Drumming | arXiv | paper |
| 2024-07-26 | Pen Spinning, Sim2Real, Real Fine-Tuning | UC San Diego | Lessons from Learning to Spin "Pens" | arXiv | project |
| 2023-04-09 | Piano Playing, Fine Motor Control, RL | Google Research | RoboPianist: Dexterous Piano Playing with Deep Reinforcement Learning | CoRL 2023 | project / openreview |
2.4 Complex & Specialized Tasks
Bimanual Dexterous Manipulation
Deformable Object Manipulation
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-08-19 | Deformable Objects, Visuo-Tactile, 4k Demonstrations, Deformation-Aware Evaluation | Tuojing Intelligence | SoftVTBench: A Deformation-Aware Visuo-Tactile Dataset and Benchmark for Deformable-Object Manipulation | arXiv | project / github |
| 2026-07-22 | Deformable Dynamics, Material Identification, Differentiable MPM, World Model | Georgia Tech | PhysCoRe: Physics-Corrected Residual World Models for Material-Aware Deformable Dynamics | arXiv | paper |
| 2020-11-14 | Cloth, Benchmark, Deformable | UC Berkeley | SoftGym: Benchmarking Deep Reinforcement Learning for Deformable Object Manipulation | CoRL 2020 | project / github |
🧠 3. Methodology
Learning, planning, control, and data-pipeline methods for dexterous manipulation.
3.1 Reinforcement Learning
Sim-to-Real Transfer
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-09-09 | Generated HOI Video, Simulation Grounding, 1.5k+ Trajectories, Unified Controller | UC Berkeley | Grounding Generated Video Plans in Simulation Towards Versatile Dexterous Controllers | arXiv | project / github |
| 2026-09-07 | Human Video, Simulated Tactile Supervision, Zero-Shot Sim-to-Real | Tsinghua University | Dex-X: Learning Visual-Tactile Dexterous Manipulation From Human Videos with Simulated Interaction | arXiv | project |
| 2026-09-07 | Visuo-Tactile World Model, 49 Objects, Multi-Axis Rotation, Sim-to-Real | Sharpa Robotics | WM-Craftnet: World Synesthesia Model for Generalizable and Robust Dexterous In-Hand Manipulation | CoRL 2026 | project |
| 2026-09-05 | Intervention-Aware World Model, Real-World RL, LEAP Hand, Safety | HKUST (Guangzhou) | How to Learn from What a Human Would Avoid? Intervention-Aware World Models with Real-World RL for Dexterous Manipulation | CoRL 2026 | project |
| 2026-09-01 | Single Demo, Contact-Centric Reward, Cross-Object Generalization | Stanford University | One Demonstration, Many Objects: Generalizing Manipulation via Local Contact Geometry | arXiv | project |
| 2026-08-19 | Dexterity Pretraining, RL Post-Training, Visuo-Tactile, Multi-Embodiment | NVIDIA | ADEPT: Accelerating Dexterity via Pre-Training and Post-Training using Reinforcement Learning | arXiv | project |
| 2026-08-16 | Tactile Sim-to-Real, Sensor-Agnostic Oracle, GelSight+DIGIT, Zero-Shot | University of Michigan | Tactile Sim2Real without Tactile Simulation via Bottlenecked Latent Reconstruction | arXiv | paper |
| 2026-07-13 | Physics Priors, Grasp Quality, Fingertip Geometry, In-Hand Rotation | Northwestern University | Robust In-Hand Manipulation via Priors in Reinforcement Learning and Mechanical Design | arXiv | paper |
| 2026-07-13 | Retargeting-Guided RL, Single Demo, Tool Use | Cornell University | A Minimalist Retargeting-Guided Reinforcement Learning Recipe for Dexterous Manipulation | arXiv | project |
| 2026-07-07 | Latent Motion Prior, Real-World Learning, DexHand | Authors | LAMP: Latent Motion Prior-Guided Real-World Learning for Dexterous Hand Manipulation | arXiv | paper |
| 2026-07-05 | Segmentation Masks, Sim-to-Real, Dexterous World Models | ETH Zurich | Mask2Real-WM: Segmentation Masks as a Sim-to-Real Bridge for Controllable Dexterous World Models | arXiv | project |
| 2026-06-24 | Dexterous Play, Precise Assembly, RL Pretraining, Sim-to-Real | Stanford | Play2Perfect: What Matters in Dexterous Play Pretraining for Precise Assembly? | arXiv | project / github |
| 2026-06-08 | Real-World Post-Training, HIL, DAgger, Diffusion Policy | Hunan University | DexPIE: Stable Dexterous Policy Improvement from Real-World Experience | arXiv | project |
| 2026-04-13 | Monocular RGB, 3DGS, Visual Sim2Real | ETH Zurich | ViserDex | arXiv | project |
| 2026-03-11 | Few-Shot Augmentation, Adaptive Residual Policy, Arm-Hand Coordination | Institute of Automation, CAS | FAR-Dex: Few-shot Data Augmentation and Adaptive Residual Policy Refinement for Dexterous Manipulation | arXiv | paper |
| 2026-03-11 | Contact Coverage, Exploration, General-Purpose | Shanghai AI Lab | ContactExplorer: Contact Coverage-Guided Exploration for General-Purpose Dexterous Manipulation | arXiv | paper |
| 2026-03-04 | Privileged Tactile Distillation, No Tactile Simulation, Allegro | Carnegie Mellon University | PTLD: Sim-to-Real Privileged Tactile Latent Distillation for Dexterous Manipulation | arXiv | project |
| 2026-03-01 | Differentiable Real-to-Sim, Mass Identification, Force-Aware Grasping | University of Southern California | D-REX: Differentiable Real-to-Sim-to-Real Engine for Learning Dexterous Grasping | ICLR 2026 | paper |
| 2026-02-09 | Cross-Embodiment, Transformer, LEAP Hand | HKUST(GZ) | DexFormer | arXiv | project |
| 2026-02-02 | Residual Flow Steering, Generative Policies, Fine-Tuning | University of Washington | RFS: Reinforcement Learning with Residual Flow Steering for Dexterous Manipulation | arXiv | project |
| 2026-01-06 | Zero-Shot Sim2Real, Force-Based Grasping, Tactile | CMU | Closing the Reality Gap: Zero-Shot Sim-to-Real Deployment | arXiv | paper |
| 2025-11-10 | Tactile Equivariance, Residual Rotation, SO(2) | CMU / Boston University | EquiTac: Residual Rotation Correction using Tactile Equivariance | arXiv | paper |
| 2025-10-09 | Neural Dynamics, In-Hand Rotation, Sim2Real | Tsinghua | DexNDM | ICLR 2026 | project |
| 2025-09-28 | Self-Improving Data Generation, Sim-to-Real, Grasp Curriculum | Harbin Institute of Technology | DexFlyWheel: A Scalable and Self-improving Data Generation Framework for Dexterous Manipulation | NeurIPS 2025 Spotlight | project |
| 2025-08-03 | Mixture-of-Experts, Object Generalization, RL | HUST | DexReMoE | arXiv | project |
| 2025-07-15 | Vision-to-Force Policy, Contact-Rich, SE(3) Equivariance | University of Washington | EquiContact: A Hierarchical SE(3) Vision-to-Force Equivariant Policy for Spatially Generalizable Contact-rich Tasks | arXiv (rev. Jan 2026) | paper |
| 2025-07-09 | Hierarchical RL, Articulated Tools, Multifingered Hand | Shanghai Jiao Tong | Hierarchical Reinforcement Learning for Articulated Tool Manipulation with Multifingered Hand | IROS 2025 | paper |
| 2025-07-06 | Model-Based Simulation, Sim2Real, Visual RL | Tsinghua | SimLauncher: Launching Dexterous Hand Manipulation Policies with Model-Based Simulation | IROS 2025 | paper |
| 2025-05-30 | Functional Retargeting, Bimanual, Sim2Real | NVIDIA | DexMachina: Functional Retargeting for Bimanual Dexterous Manipulation | arXiv | project |
| 2025-03-06 | Geometric Algebra, SE(3) Equivariant, Diffusion | Georgia Tech | GAGrasp: Geometric Algebra Diffusion for Dexterous Grasping | ICRA 2025 | paper |
| 2025-03-04 | Variable Friction, Sim2Real, Imitation Learning | CMU | Variable-Friction In-Hand Manipulation for Arbitrary Objects via Diffusion-Based Imitation Learning | ICRA 2025 | paper |
| 2025-03-04 | Visuomotor Diffusion, In-Hand Manipulation, Multifingered | KTH | Learning Dexterous In-Hand Manipulation with Multifingered Hands via Visuomotor Diffusion Policies | IROS 2025 | paper |
| 2025-02-27 | Humanoid, DexHand, Sim2Real | NVIDIA | Sim-to-Real Reinforcement Learning for Vision-Based Dexterous Manipulation on Humanoids | arXiv | project |
| 2025-02-06 | Foundation Controller, Motion Primitives, RL Pretraining | Physical Intelligence | DexterityGen | arXiv | project |
| 2025-01-09 | Hierarchical Skills, Any-Axis, Sim2Real | UC Berkeley | From Simple to Complex Skills: The Case of In-Hand Object Reorientation | arXiv | project |
| 2024-11-27 | Interaction-Aware, Diffusion, Adaptive | Tsinghua | DexHandDiff: Interaction-aware Diffusion Planning for Adaptive Dexterous Manipulation | CVPR 2025 | paper |
| 2024-11-20 | Bimanual Dexterity, RL, Sim2Real | Georgia Tech | AsymDex | arXiv | project |
| 2024-10-02 | Cross-Embodiment, Unified Representation, D(R,O) | Tsinghua | (R,O) Grasp: A Unified Representation of Robot and Object Interaction for Cross-Embodiment Dexterous Grasping | ICRA 2025 | paper |
| 2024-09-22 | Online Planning, Sampling, Dexterous Reorientation | CMU | DROP: Dexterous Reorientation via Online Planning | ICRA 2025 | paper |
| 2024-07-26 | Pen Spinning, Real Fine-Tuning, Sim2Real | UC San Diego | Lessons from Learning to Spin "Pens" | arXiv | project |
| 2023-09-02 | Long-Horizon, Chaining Policies, RL | Stanford | Sequential Dexterity: Chaining Dexterous Policies for Long-Horizon Manipulation | CoRL 2023 | paper |
| 2022-11-17 | Point Cloud, Generalizable, Sim2Real | UC San Diego | DexPoint: Generalizable Point Cloud RL for Sim-to-Real Dexterous Manipulation | CoRL 2022 | paper |
| 2022-10-10 | Adaptation, Domain Randomization, Shadow Hand | UC Berkeley | HORA: In-Hand Object Rotation via Rapid Motor Adaptation | arXiv | paper |
| 2021-11-04 | General Reorientation, Zero-Shot, Distillation | MIT | A System for General In-Hand Object Re-Orientation | CoRL 2021 Oral | project |
| 2019-10-16 | Rubik's Cube, Automatic Domain Randomization | OpenAI | Solving Rubik's Cube with a Robot Hand | arXiv | blog |
| 2018-08-01 | In-Hand Manipulation, Domain Randomization | OpenAI | Learning Dexterous In-Hand Manipulation | IJRR 2020 | dblp / blog |
| 2018-02-26 | Multi-Goal RL, Shadow Hand, Sparse Rewards | OpenAI | Multi-Goal Reinforcement Learning: Challenging Robotics Environments and Request for Research | arXiv | github |
Reward Design & State Estimation
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-03-11 | Adaptive Force Control, Contact-Rich, Cartesian Impedance, RL | University of Southern California | Learning Adaptive Force Control for Contact-Rich Sample Scraping with Heterogeneous Materials | IROS 2026 | paper |
| 2025-10-09 | Human Video, Contact Rewards, Humanoid | Shanghai AI Lab | DexMan | arXiv | paper |
| 2025-09-22 | Tactile Feedback, Reward Shaping, Finger Gaiting | University of Southern Denmark | Tac2Motion | arXiv | video |
| 2025-09-09 | LLM Reward, Tactile, In-Hand Rotation | University of Bristol | Text2Touch: Tactile In-Hand Manipulation with LLM-Designed Reward Functions | CoRL 2025 | project / proceedings |
| 2025-03-06 | Real-World RL, Dexterous Grasping, Online | Beihang University | Dexterous Grasping with Real-World Robotic Reinforcement Learning | arXiv | paper |
| 2024-07-10 | Tactile Skin, Shear/Normal Force, Translation | Meta FAIR | Learning In-Hand Translation Using Tactile Skin With Shear and Normal Force Sensing | arXiv | project |
| 2023-09-18 | Vision+Touch, State Estimation, Rotation | UC Berkeley | RotateIt: General In-Hand Object Rotation with Vision and Touch | CoRL 2023 | project |
| 2017-09-28 | Demonstrations, Sparse Rewards, Adroit | University of Washington | Learning Complex Dexterous Manipulation with Deep RL and Demonstrations | RSS 2018 | github |
3.2 Imitation Learning
Behavior Cloning & Action Chunking
Diffusion Policies
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-07-30 | Frequency-Adaptive, Visual-Force, Reactive Diffusion, Contact-Rich | Shanghai Jiao Tong University | FA-RDP: A Frequency-Adaptive Reactive Diffusion Policy for Contact-Rich Manipulation | arXiv | project |
| 2026-07-28 | Reactive, Flow Matching, Proprioception, XHand, Real-Time | Carnegie Mellon University | $\pi\mathbf{R}^2$: Reactive Real-time Flow Policies | arXiv | project |
| 2026-07-19 | Asynchronous Fusion, Vision+Force, Reactive Diffusion Policy | Shanghai Jiao Tong | Asynchronous Multimodal Diffusion Policy Composition via Latency-Aware Guidance Fusion | arXiv | project |
| 2025-08-24 | Long-Horizon, Synthetic Data, Skill Routing | HKU | LodeStar: Long-horizon Dexterity via Synthetic Data Augmentation from Human Demonstrations | arXiv | paper |
| 2025-08-20 | Force Closure, Differentiable Optimization, Grasp Synthesis | ETH Zurich | GraspQP: Differentiable Optimization of Force Closure for Diverse and Robust Dexterous Grasping | IROS 2025 | paper |
| 2025-06-17 | Sim-to-Real, Clutter, Diffusion Policy | Tsinghua | ClutterDexGrasp: A Sim-to-Real System for General Dexterous Grasping in Cluttered Scenes | CoRL 2025 | project |
| 2025-03-03 | Soft Hands, Diffusion Policy, Proprioceptive | University of Michigan | KineSoft: Learning Proprioceptive Manipulation Policies with Soft Robot Hands | ICRA 2025 | paper |
| 2024-12-19 | Dexterous Fine-Tuning, Real-World Hands | UC Berkeley | DEFT: Dexterous Fine-Tuning for Real-World Hand Policies | Website | project |
| 2024-10-25 | Diffusion Policy, Compliant Manipulation, Contact-Rich, Stiffness Control | University of Tokyo | DIPCOM: Learning Diffusion Policies from Demonstrations For Compliant Contact-rich Manipulation | arXiv | paper |
| 2024-10-10 | Bimanual, Diffusion Foundation, Manipulation | Tsinghua | RDT-1B: a Diffusion Foundation Model for Bimanual Manipulation | arXiv | project / github |
| 2024-07-21 | Flow Matching, Uncertainty-Aware, Dexterous Grasping | TUM | FFHFlow: Diverse and Uncertainty-Aware Dexterous Grasp Generation via Flow Variational Inference | ICRA 2025 | paper |
| 2024-03-06 | 3D Diffusion, Point Cloud, Dexterous | Zhejiang University | DP3: 3D Diffusion Policy for Generalizable Visuomotor Policy Learning | ICRA 2025 | project |
| 2023-03-07 | Diffusion Policy, Visuomotor, Robot Learning | Columbia | Diffusion Policy: Visuomotor Policy Learning via Action Diffusion | RSS 2023 | project / github |
3.3 Vision-Language-Action (VLA) & Foundation Models
Dexterous VLA Models
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-09-08 | Contact-Aware Tactile VLA, Latent Co-Imagination, Factorized Flow | Peking University | DeCAL: Towards Physically-Grounded Dexterous Vision-Language-Action Models via Contact-Aware Latent Co-Imagination | CoRL 2026 | project / github |
| 2026-08-31 | General World Model, Dual DexHands, 130K h Human Data, Tactile Control | GensPI | Motus2: A Self-Evolving General World Model for Dexterous Manipulation | arXiv | project |
| 2026-08-16 | Frozen VLA, Tactile Residual Adaptation, UniVTAC, Physical Robot | Beijing Institute of Technology | ViTaR: Visuo-Tactile Residual Adaptation for Foundation VLA Manipulation | arXiv | project |
| 2026-08-14 | Human+Robot Demonstrations, Joint-Aligned Actions, Cross-Embodiment, Tactile VLA | Zhejiang University | AdvDex: Learning Dexterous Manipulation from Human Demonstrations via Joint-Aligned Actions and Adversarial Learning | arXiv | paper |
| 2026-07-30 | Tactile World Action Model, Mechanics-Aware, Contact-Rich, In-Hand | Tsinghua University | TacWAM: Anchor-Guided World Action Model with Mechanics-Aware Tactile Prediction | arXiv | paper |
| 2026-07-26 | Tactile-Native World Action Model, Contact-Rich, Multi-Embodiment | Authors | $N_0$-TWAM: Scaling Tactile-Native World-Action Model for Contact-Rich Manipulation | arXiv | paper |
| 2026-07-24 | Visuo-Tactile World Model, Rollout Generation, Policy Improvement | ShanghaiTech University | ViTacWorld: Scaling Visuo-Tactile World Models for Contact-Rich Robot Manipulation | arXiv | project |
| 2026-07-20 | Force Memory, Non-Markovian VLA, Contact-Rich | Tsinghua University | FM-VLA: Force-based Memory for Vision-Language-Action Models in Contact-Rich Manipulation | arXiv | project / github |
| 2026-07-16 | Tactile-Grounded VLA, Future Touch Prediction, Latent Alignment | Fudan University | Representation-Aligned Tactile Grounding for Contact-Rich Robotic Manipulation | arXiv | paper |
| 2026-07-07 | LingBot-VLA 2.0, Cross-Embodiment, DexHands | Robbyant | From Foundation to Application: Improving VLA Models in Practice | Tech Report | github / model / paper |
| 2026-07-03 | Tactile World Model, Failure Recovery, VLA Post-Training | Peking University | TACO: TActile World Model as a Self-COrrector for Scalable VLA Post-Training | arXiv | project |
| 2026-07-01 | Tactile Pretraining, Dexterous VLA, Human-to-Robot, Contact Dynamics | Peking University | Human-Centric Transferable Tactile Pre-Training for Dexterous Robotic Manipulation | arXiv | paper |
| 2026-06-30 | Tactile VLA, Contact Prediction, Tactile-Action Control | Harbin Institute of Technology | UniTacVLA: Unified Tactile Understanding and Prediction in Vision Language Action Models | arXiv | paper |
| 2026-06-17 | Zero-Shot Long-Horizon, Multi-View 3D Grounding, VLM Planning | Seoul National University | ZeroDex: Zero-Shot Long-Horizon Dexterous Manipulation via Multi-View 3D-Grounded VLM Reasoning | arXiv | project |
| 2026-06-10 | Dexterous VLA, Morphology Gap, Intent Conditioning, Fine-Tuning | Beihang University | Bridging the Morphology Gap: Adapting VLA Models to Dexterous Manipulation via Intent-Conditioned Fine-Tuning | arXiv | paper |
| 2026-05-14 | Dexterous VLA, Human-in-the-Loop, Bimanual, Policy Refinement | Shanghai Jiao Tong | Hand-in-the-Loop: Improving VLA Policies for Dexterous Manipulation via Seamless Hand-Arm Intervention | arXiv | project |
| 2026-05-07 | World Action Model, Object-Addressable, Slot-Based Attention | Southeast University | OA-WAM: Object-Addressable World Action Model for Robust Robot Manipulation | arXiv | paper |
| 2026-05-07 | Triadic Relational Structure, VLA, Object-Hand-Task | NUS | TriRelVLA: Triadic Relational Structure for Generalizable Embodied Manipulation | arXiv | paper |
| 2026-05-06 | Contact-Free, ToF Sensors, Grasp Stability, 86% Accuracy | Cornell | Contact-Free Grasp Stability Prediction with In-Hand Time-of-Flight Sensors | arXiv | paper |
| 2026-05-03 | Foundation Model, VLM Critic, Tactile-Visual, Sim-to-Real Gap 8.3% | Zhejiang University | DexSim2Real: Foundation Model-Guided Sim-to-Real Transfer for Generalizable Dexterous Manipulation | arXiv | paper |
| 2026-03-23 | Egocentric Video, Foundation Suite, Universal Dexterous, Cross-Hand | Shanghai AI Lab | UniDex: A Robot Foundation Suite for Universal Dexterous Hand Control from Egocentric Human Videos | CVPR 2026 | paper |
| 2026-03-12 | Humanoid, Reproducible Demonstrations, DexHand | Physical Intelligence Lab | HumDex: Humanoid Dexterous Manipulation Made Easy | arXiv | github |
| 2026-02-28 | DexHand, VLM, Unified Dexterous, Language-Guided, Physics-Refinement | Tsinghua | UniHM: Unified Dexterous Hand Manipulation with Vision Language Model | ICLR 2026 | project |
| 2025-02-28 | Dexterous Grasping, VLA, Open-Vocabulary | Shanghai AI Lab | DexGraspVLA: A Vision-Language-Action Framework Towards General Dexterous Grasping | AAAI 2026 | paper |
Zero-shot / Few-shot Dexterity
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-07-03 | Unified Hand Action Space, Zero-Shot Cross-Hand Transfer | Authors | Cross-Embodiment Robot Manipulation via a Unified Hand Action Space | arXiv | paper |
| 2026-02-18 | Canonical Hand, Cross-Embodiment, LEAP Hand | UNC Chapel Hill | One Hand to Rule Them All: Canonical Representations for Unified Dexterous Manipulation | arXiv | project |
| 2025-08-09 | Gaussian Splatting, Fruit Inspection, Dexterous Manipulation | Stanford | DexFruit: Dexterous Manipulation and Gaussian Splatting Inspection of Fruit | RA-L 2026 | paper |
| 2025-07-05 | Human Hand, Few-Shot, Robot-Free | Peking University | RwoR: Generating Robot Demonstrations from Human Hand Collection for Policy Learning without Robot | IROS 2025 | project |
| 2024-10-31 | Egocentric Video, Imitation, Scaling | Georgia Tech | EgoMimic: Scaling Imitation Learning via Egocentric Video | arXiv | project / github |
3.4 Trajectory Optimization & Optimal Control
Trajectory Optimization
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2025-02-11 | In-Grasp Movement, Trajectory Optimization, RGMC | Tsinghua | Robotic In-Hand Manipulation for Large-Range Precise Object Movement: The RGMC Champion Solution | RA-L | project |
| 2022-09-28 | Trajectory Optimization, RL, Dexterous | University of Washington | Solving Complex Dexterous Manipulation Tasks With Trajectory Optimisation and Reinforcement Learning | CoRL 2022 | project |
Kinematics & Motion Planning
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-02-09 | Human Videos, 3D Reconstruction, Dexterous Policies | Carnegie Mellon | Dexterous Manipulation Policies from RGB Human Videos via 3D Hand-Object Trajectory Reconstruction | arXiv | project |
| 2025-11-12 | Physics-Informed, Retargeting, Scalable | Columbia University | SPIDER: Scalable Physics-Informed Dexterous Retargeting | arXiv | paper |
| 2024-05-29 | Teleoperation, DeltaHand, In-Hand | CMU | Tilde: Teleoperation for Dexterous In-Hand Manipulation Learning with a DeltaHand | RSS 2024 | paper |
| 2024-04-24 | Human Videos, Visuomotor, Sim2Real | UC San Diego | ViViDex: Learning Vision-based Dexterous Manipulation from Human Videos | ICRA 2025 | project |
| 2024-03-12 | Mocap, Retargeting, DexHand | Stanford | DexCap: Scalable and Portable Mocap Data Collection System for Dexterous Manipulation | arXiv | github |
| 1994-01-01 | Kinematics, Grasping, Classic Textbook | Caltech | A Mathematical Introduction to Robotic Manipulation | Book |
3.5 Data Collection Paradigms
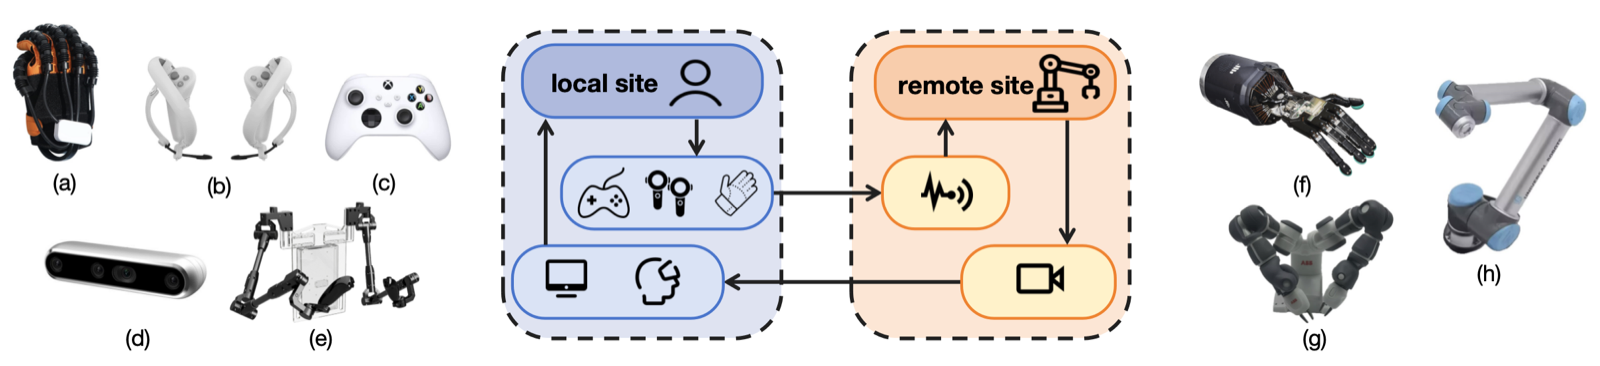
Source: teleoperation framework figure from Dexterous Manipulation through Imitation Learning: A Survey.
Vision-based Teleoperation
Exoskeleton & Glove-based
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-09-10 | Shared Human/Robot Exoskeleton, 20-DoF Encoders, Paired Contact Retargeting | Peking University | SEED-UMI: Sharing the Exoskeleton between human and robot for onE-to-one Dexterous demonstration | arXiv | project |
| 2026-08-25 | Fiber-Optic Glove, 60Hz Full-Hand Pose, 4.9mm Error, Bimanual | Meta | Fiber Optic Sensing Glove for High Performance Dexterous Manipulation Capture | arXiv | paper |
| 2026-06-15 | 22-DoF, 2048-Taxel, 120Hz, Interaction Capture | Carnegie Mellon | ART-Glove: Articulated Tactile Glove for Contact-Grounded Dexterous Interaction Capture | arXiv | project |
| 2026-03-30 | Tactile Feedback Array, Magnetic MoCap, Glove Teleop | Shanghai AI Lab | Feel Robot Feels: Tactile Feedback Array Glove for Dexterous Manipulation | arXiv | project / github |
| 2025-09-04 | Passive Hand Exoskeleton, Perioperation, Robot-Transferable Data | MIT | DEXOP: A Device for Robotic Transfer of Dexterous Human Manipulation | arXiv | paper |
| 2025-02-11 | Haptic Glove, Force Feedback, Teleoperation | University of Bristol | DOGlove: Dexterous Manipulation with a Low-Cost Open-Source Haptic Force Feedback Glove | RSS 2025 | project |
| 2024-08-21 | Visual-Exoskeleton, Retargeting, Teleop | UC San Diego | ACE | CoRL 2024 | project |
| 2019-06-06 | Tactile Glove, Human Demonstrations, Grasp | MIT | Learning the Signatures of the Human Grasp Using a Scalable Tactile Glove | Nature 2019 | paper |
Passive Video & Internet Data Extraction
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-09-09 | Generated HOI Video, 2k References, Simulation Grounding | UC Berkeley | Grounding Generated Video Plans in Simulation Towards Versatile Dexterous Controllers | arXiv | project / github |
| 2026-09-07 | Monocular Human Video, Tactile Completion in Simulation, No Robot Data | Tsinghua University | Dex-X: Learning Visual-Tactile Dexterous Manipulation From Human Videos with Simulated Interaction | arXiv | project |
| 2026-09-02 | Internet Video Retrieval, Actor-Centric 3D Hand Trajectories, Dexterous Policies | Rice University | RoboTok: An Internet-Scale Data Engine for Human Demonstration Retrieval and Dexterous Manipulation Learning | arXiv | project / models+evaluation data |
| 2026-09-01 | One Human Demo, Contact-Centric Sim-to-Real, Cross-Object Transfer | Stanford University | One Demonstration, Many Objects: Generalizing Manipulation via Local Contact Geometry | arXiv | project |
| 2026-08-23 | Egocentric Forecasting, Explicit Manipulation Plans, 651k Windows, 111 Tasks | Institute of Computing Technology, CAS | EMPIRE: Explicit Manipulation Planning as a Learnable Intermediate Representation for Egocentric Hand-Motion Forecasting | arXiv | github |
| 2026-08-15 | Egocentric Video, Vision-to-Touch, 5.7M Image-Tactile Pairs | Shanghai Qi Zhi Institute | EgoTac: In-the-wild Tactile Prediction from Egocentric Vision | arXiv | paper |
| 2026-08-07 | Monocular Video, Contact-Consistent, Retargeting, Sim-to-Real | Nanjing University | C2Dex: Contact-Consistent Reconstruction and Retargeting for Dexterous Manipulation from Monocular Video | arXiv | project |
| 2026-08-04 | Egocentric Video Retrieval, Cross-Embodiment, Similarity Mining | University of Tokyo | SiMDex: Mining Similar Egocentric Videos for Cross-Embodiment Dexterous Manipulation | arXiv | paper |
| 2026-07-30 | Ambient Capture, Hand-Object Interaction, Full-Body, Tactile, 150 Hours | Nanyang Technological University | ACE-Data-0: Human-Centric Ambient Capture as Embodied Data Engine | arXiv | project |
| 2026-06-20 | Generative World Model, Egocentric Hand Data, Scalable Synthesis | Shanghai Innovation Institute | Wh0: Generative World Models as Scalable Sources of Egocentric Human Hand Manipulation Data | arXiv | paper |
| 2026-06-17 | Human Video, 4D Reconstruction, Retargeting, DexHand Data | UC Berkeley | Do as I Do: Dexterous Manipulation Data from Everyday Human Videos | arXiv | project / github |
| 2026-06-15 | Monocular Human Video, 4D Reconstruction, Sim-to-Real | Zhejiang University | V2P-Manip: Learning Dexterous Manipulation from Monocular Human Videos | arXiv | paper |
| 2026-06-10 | Internet Video, Intent Model, Embodiment-Agnostic, Sim-to-Real | UIUC | LUCID: Learning Embodiment-Agnostic Intent Models from Unstructured Human Videos for Scalable Dexterous Robot Skill Acquisition | arXiv | project |
| 2026-06-10 | Egocentric Video, High-Fidelity Robot Demonstrations, Residual RL | Georgia Institute of Technology | EgoEngine: From Egocentric Human Videos to High-Fidelity Dexterous Robot Demonstrations | arXiv | paper |
| 2026-06-07 | Single Human Video, Digital Twin, Residual RL, Sim-to-Real | Georgia Tech | Video2Sim2Real: Full-Stack Autonomous Dexterous Skill Acquisition from a Single Human Video | arXiv | project |
| 2026-02-09 | RGB Video, Dexterous Policies, Human Video | Carnegie Mellon | Dexterous Manipulation Policies from RGB Human Videos via 3D Hand-Object Trajectory Reconstruction | arXiv | project |
| 2026-01-04 | Single RGB-D Demo, Bimanual DexHands, Residual RL, Assembly | ByteDance Seed | DemoBot: Efficient Learning of Bimanual Manipulation with Dexterous Hands From Third-Person Human Videos | arXiv | project |
| 2025-10-09 | Human Videos, Bimanual, Generated Videos | Shanghai AI Lab | DexMan | arXiv | paper |
| 2025-09-11 | Scalable Exploration, Reference-Scoped, Neural Control | Georgia Tech | Dexplore: Scalable Neural Control for Dexterous Manipulation from Reference-Scoped Exploration | CoRL 2025 | paper |
| 2025-07-02 | Manipulation Types, Teleoperation, Dexterity | Tsinghua | TypeTele: Releasing Dexterity in Teleoperation by Dexterous Manipulation Types | IROS 2025 | paper |
| 2025-04-08 | Egocentric Video, Manipulation Priors, Affordance | ETH Zurich | MAPLE: Encoding Dexterous Robotic Manipulation Priors Learned From Egocentric Videos | arXiv | paper |
| 2025-03-10 | GeoRT, Neural Retargeting, 1kHz | UC Berkeley | Geometric Retargeting: A Principled, Ultrafast Neural Hand Retargeting Algorithm | arXiv | project / github |
| 2024-10-31 | Egocentric Video, Imitation, Scaling | Georgia Tech | EgoMimic | arXiv | project |
| 2024-04-24 | Human Videos, Visuomotor, Sim2Real | UC San Diego | ViViDex: Learning Vision-based Dexterous Manipulation from Human Videos | ICRA 2025 | project |
| 2023-12-05 | Functional Grasping, Affordance, Zero-Shot | UC Berkeley | Dexterous Functional Grasping | CoRL 2023 | paper |
| 2023-09-06 | Data Reuse, Bootstrapping, Real-World RL | Google DeepMind | REBOOT: Reuse Data for Bootstrapping Efficient Real-World Dexterous Manipulation | CoRL 2023 | paper |
| 2022-02-21 | Human Video, Telekinesis, Dexterous Hand | Stanford | Robotic Telekinesis: Learning a Robotic Hand Imitator by Watching Humans on YouTube | RSS 2022 | project |
| 2021-08-12 | Human Video, Retargeting, DexHand | UC San Diego | DexMV: Imitation Learning for Dexterous Manipulation from Human Videos | ECCV 2022 | project |
🛠️ 4. Infrastructure
Reusable simulators, benchmark suites, datasets, robot descriptions, and training resources.
4.1 Simulators
GPU-Accelerated
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-06-21 | GPU Tactile Simulation, Multi-Sensor, 20k Envs, XHand1 | Carnegie Mellon | Tactile Genesis: Exploring Tactile Sensors at Scale for Learning Dexterous Tasks | arXiv | project / github |
| 2026-06-17 | Tactile Simulation, Shared Latent, Zero-Shot Sim-to-Real, Isaac Lab | ETH Zurich | TactSpace: Learning a Physics-enriched Shared Latent Space for Tactile Sim-to-Real Transfer | IROS 2026 | project |
| 2026-05-23 | Real-Time Video Simulation, Causal Diffusion, Hand-Object Interaction | UC Berkeley | DexSIM: Real-time Dexterous Simulation with Unified Causal Video Diffusion | arXiv | paper |
| 2026-04-22 | Tactile Simulation, Lightweight Rendering, Dexterous Policy Learning | ShanghaiTech University | ETac: A Lightweight and Efficient Tactile Simulation Framework for Learning Dexterous Manipulation | arXiv | project |
| 2025-11-03 | Generative Simulation, Cross-Hand Morphologies, Scalable Training | University of Hong Kong | GenDexHand: Generative Simulation for Dexterous Hands | arXiv | paper |
| 2025-04-17 | Tactile Simulation, GPU, Vision-Based Touch | Peking University | Taccel: Scaling Up Vision-based Tactile Robotics via High-performance GPU Simulation | NeurIPS 2025 Spotlight | project / github |
| 2024-06-14 | Isaac Lab, GPU Sim, RL Environments | NVIDIA | Isaac Lab | GitHub | github / docs |
| 2021-08-24 | GPU Physics, Massive RL, Dexterous Tasks | NVIDIA | Isaac Gym: High Performance GPU-Based Physics Simulation for Robot Learning | NeurIPS 2021 | paper |
| 2021-08-01 | Isaac Sim, Omniverse, Robotics Simulation | NVIDIA | Isaac Sim | Website | docs |
CPU-based & High-Fidelity Physics
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-05-15 | MuJoCo Toolkit, Task-Oriented Dexterity, Multi-Hand Benchmark | Institute of Automation, CAS | DexJoCo: A Benchmark and Toolkit for Task-Oriented Dexterous Manipulation on MuJoCo | arXiv | project |
| 2020-03-19 | SAPIEN, Manipulation, Simulation | UC San Diego | SAPIEN: A SimulAted Part-Based Interactive ENvironment | CVPR 2020 | project / github |
| 2016-10-27 | PyBullet, Robotics Simulation, Open Source | Erwin Coumans | PyBullet | GitHub | docs / pypi |
| 2012-12-11 | MuJoCo, Contact Dynamics, Model-Based Control | University of Washington | MuJoCo: A Physics Engine for Model-Based Control | IROS 2012 | website / github |
4.2 Benchmarks & Datasets
Dexterous Grasping Datasets
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-07-22 | Language-Guided, Multi-Embodiment, 2.5M Grasps, Clutter | University of Toronto | SeededGrasp: Language-Guided Grasping in Complex Scenes with Multiple Embodiments | arXiv | project / github |
| 2026-06-22 | Autonomous Real-World Collection, 3,593 Trials, Success+Failure Labels | Seoul National University | AutoDex: An Automated Real-World System for Dexterous Grasping Data Collection | arXiv | project |
| 2026-04-16 | Paired Human+Robot Grasps, 100 Objects, 2.1K Sequences, Tactile | Seoul National University | HRDexDB: A Paired Human-Robot Dataset for Cross-Embodiment Dexterous Grasping | arXiv | project / github / dataset |
| 2025-04-26 | Grasp Taxonomy, Type-Conditional, 10.7k Objects, 9.5M Grasps, 31 Grasp Types | Shanghai AI Lab / Peking | Dexonomy: Synthesizing All Dexterous Grasp Types in a Grasp Taxonomy | RSS 2025 | paper |
| 2023-10-24 | Multi-Object, DexHand, Synthetic Dataset | Peking University | Grasp Multiple Objects with One Hand | RA-L 2024 | project |
| 2022-10-06 | Large-Scale, DexHand, Grasp Synthesis | Peking University | DexGraspNet: A Large-Scale Robotic Dexterous Grasp Dataset for General Objects Based on Simulation | ICRA 2023 | project / github |
| 2022-10-03 | Hand-Agnostic, MultiDex, Grasp Synthesis | BIGAI | GenDexGrasp: Generalizable Dexterous Grasping | ICRA 2023 | project / github |
| 2021-04-09 | Hand-Object, RGB-D, Pose, YCB | NVIDIA | DexYCB: A Benchmark for Capturing Hand Grasping of Objects | CVPR 2021 | project |
| 2020-08-25 | Human Grasp, Object Pose, Contact | University of Tuebingen | GRAB: A Dataset of Whole-Body Human Grasping of Objects | ECCV 2020 | project |
| 2019-07-02 | Hand-Object, 3D Reconstruction, HO-3D | IIT Delhi | HOnnotate: A Method for 3D Annotation of Hand and Object Poses | CVPR 2020 | project |
Hand-Object & Bimanual Datasets
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-08-23 | Bimanual Hand Forecasting, 651k Windows, 111 Tasks, Plan Supervision | Institute of Computing Technology, CAS | EMPIRE: Explicit Manipulation Planning as a Learnable Intermediate Representation for Egocentric Hand-Motion Forecasting | arXiv | github |
| 2026-07-30 | Human HOI, Articulated Hands, Tactile, 75k Episodes, 150 Hours | Nanyang Technological University | ACE-Data-0: Human-Centric Ambient Capture as Embodied Data Engine | arXiv | project |
| 2026-07-28 | Robot-Free, Bimanual UMI, 2k Hours, Six-View, Replay-Validated | Simple AI | HiFi-UMI: Learning Deployable Manipulation Policies from High-Fidelity UMI Data Alone | arXiv | project / dataset |
| 2026-06-30 | Visual-Tactile-Action, Humanoid, 6k Trajectories | Authors | RoboTacDex: A Dexterous Visual-Tactile-Action Dataset for Humanoid Manipulation | arXiv | paper |
| 2026-06-08 | Bimanual UMI, 8,434 Hours, 1.20M Episodes, 119 Tasks | AI Robot Association | YUBI: Yielding Universal Bidigital Interface for Bimanual Dexterous Manipulation at Scale | ICRA 2026 Workshop | project / hardware / software |
| 2025-10-17 | Real+Synthetic Human HOI, 7k Hours, Contact+Force Annotations | University of Michigan | DexCanvas: Bridging Human Demonstrations and Robot Learning for Dexterous Manipulation | arXiv | paper |
| 2025-09-05 | Egocentric Video, 1,107 Hours, Hand Pose, Action Primitives | University of Texas at Dallas | OpenEgo: A Large-Scale Multimodal Egocentric Dataset for Dexterous Manipulation | arXiv | paper |
| 2024-03-28 | Bimanual, Hand-Object, Complex Tasks | Shanghai Jiao Tong University | OAKINK2: A Dataset of Bimanual Hands-Object Manipulation in Complex Task Completion | CVPR 2024 | project / github |
| 2024-02-21 | Human-Like Robot Grasps, Multi-View, Multimodal, Teleoperation | ShanghaiTech University | RealDex: Towards Human-like Grasping for Robotic Dexterous Hand | IJCAI 2024 | project |
| 2022-04-28 | Bimanual, Articulated Objects, Contact | ETH Zurich | ARCTIC: A Dataset for Dexterous Bimanual Hand-Object Manipulation | CVPR 2023 | project |
Teleoperation & Task Benchmarks
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-08-19 | Chemistry Lab, Real+Simulation, Hierarchical Skills, DexHand Benchmark | University of Science and Technology of China | LabDex: A Hierarchical Benchmark for Dexterous Manipulation in Laboratories | arXiv | project |
| 2026-08-12 | Synthetic-to-Real Challenge, Data Generation, Physical Evaluation | Shenzhen Loop Area Institute | RoboSynChallenge: Mastering Real-World Dexterity via Generalizing Synthesized Manipulation Skills | NeurIPS 2026 Competition Track | benchmark / github |
| 2026-08-12 | Human-to-Robot Hand Editing, 200M Instances, 26 URDFs | Shanghai Jiao Tong University | HandEdit: A Unified Benchmark for Egocentric Human-to-Robot Dexterous Hand Image Editing | Technical Report | project / github |
| 2026-07-15 | Industrial Assembly, Multimodal Imitation, Hardware+Software Benchmark | Analog Devices | Industrial Dexterity Benchmark: A Hardware-Software Benchmarking Platform for Industrial Dexterous Manipulation | arXiv | paper |
| 2026-07-10 | Tactile-Guided Transfer, Single+Bimanual, Benchmark | Authors | TactiDex: A Real-World Tactile-Guided Benchmark for Human-Like Dexterous Manipulation | arXiv | project |
| 2026-07-09 | 100 Tasks, 6 DexHands, 3,180 Demos, Multi-Embodiment | UNC Chapel Hill | DexVerse: A Modular Benchmark for Multi-Task, Multi-Embodiment Dexterous Manipulation | arXiv | project / github |
| 2026-06-30 | Humanoid DexHands, Chemistry Lab, Precision Benchmark | Authors | Labimus: A Simulation and Benchmark for Humanoid Dexterous Manipulation in Chemical Laboratory | arXiv | project |
| 2026-06-17 | Full-Hand Tactile, 10M RGB, 7.8M Tactile, 226 Tasks | Beihang University | HT-Bench: Benchmarking and Learning Dexterous Full-Hand Tactile Representations with Egocentric Vision | arXiv | paper |
| 2026-05-15 | MuJoCo, Task-Oriented Dexterity, Toolkit+Benchmark | Institute of Automation, CAS | DexJoCo: A Benchmark and Toolkit for Task-Oriented Dexterous Manipulation on MuJoCo | arXiv | project |
| 2026-04-10 | Anthropomorphic Hands, Taxonomy-Grounded Tasks, Real+Simulation | ETH Zurich | A Benchmark of Dexterity for Anthropomorphic Robotic Hands | arXiv | project / github |
| 2025-04-26 | Unified Platform, Simulation, Benchmark, 20+ Institutions | Cornell / 20+ institutions | RoboVerse: Towards a Unified Platform, Dataset and Benchmark for Scalable and Generalizable Robot Learning | RSS 2025 | project / github |
| 2025-02-11 | In-Grasp Manipulation, Benchmark, Dexterous Fingers | Tsinghua | Robotic In-Hand Manipulation for Large-Range Precise Object Movement: The RGMC Champion Solution | RA-L | project |
| 2024-03-19 | In-the-Wild, Large-Scale, Robot Data, 76k Trajectories, 350 Hours | Stanford / 10 institutions | DROID: A Large-Scale In-The-Wild Robot Manipulation Dataset | arXiv | project |
| 2020-04-15 | Dexterous Hand, Offline RL, Adroit | UC Berkeley | D4RL: Datasets for Deep Data-Driven Reinforcement Learning | arXiv | github |
| 2019-10-24 | Manipulation Benchmark, Meta-World, RL | Stanford | Meta-World: A Benchmark and Evaluation for Multi-Task and Meta Reinforcement Learning | CoRL 2019 | github |
4.3 Enabling Methods & System Utilities
Adjacent tasks that often determine whether a dexterous manipulation system can be initialized, transferred, sensed, calibrated, and evaluated reliably.
Grasp & Initialization
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-08-20 | Contact Topology, Functional Grasp Types, Object-Agnostic Training | CEA-List | CoToGrasp: Contact-Topology-Conditioned Dexterous Grasp Synthesis via Canonical Workspace Learning | ECCV 2026 | project / github |
| 2026-08-20 | Object-Agnostic Grasping, Generative Contacts, Multi-Gripper | CEA-List | GOAG: Generative and Object-Agnostic Grasp Planner for Dexterous Robotic Manipulation | IROS 2026 | project / github |
| 2026-08-06 | 3D Visuo-Tactile Fusion, Contact-Aware Grasping, Adaptive Refinement | Peking University | AdaDexGrasp: Adaptive Dexterous Grasping via 3D Visuo-Tactile Representation Fusion | ECCV 2026 | paper |
| 2026-07-22 | Language-Guided, Multi-Embodiment, Executable Grasp, Clutter | University of Toronto | SeededGrasp: Language-Guided Grasping in Complex Scenes with Multiple Embodiments | arXiv | project / github |
| 2026-07-13 | Flow Matching, URDF Graph, Cross-Hand, Executable Grasp | KAIST | GraspGraphNet: Graph-Structured Multi-Embodiment Dexterous Grasp Generation | arXiv | project |
| 2026-07-06 | Human Grasp Prior, Multi-Mode, Cross-Scale, 3.2M Synthetic Grasps | Tsinghua University | HUGS: Guiding Unified Dexterous Grasp Synthesis Across Modes and Scales via Learned Human Priors | arXiv | project |
| 2026-07-03 | Tactile MPC, Contact Coordination, Uncertainty, 15k Simulated Grasps | Tsinghua University | CoorGrasp: Coordinated Contact Control for Adaptive Dexterous Grasping Under Uncertainty | ICRA 2026 | project |
| 2026-03-01 | Differentiable Digital Twin, Mass Identification, Force-Aware Grasping | University of Southern California | D-REX: Differentiable Real-to-Sim-to-Real Engine for Learning Dexterous Grasping | ICLR 2026 | paper |
| 2025-08-20 | Force Closure, Differentiable Optimization, Grasp Synthesis | ETH Zurich | GraspQP: Differentiable Optimization of Force Closure for Diverse and Robust Dexterous Grasping | IROS 2025 | paper |
| 2025-06-17 | Clutter, Sim-to-Real, Dexterous Grasping | Tsinghua | ClutterDexGrasp: A Sim-to-Real System for General Dexterous Grasping in Cluttered Scenes | CoRL 2025 | project |
| 2025-04-26 | Grasp Taxonomy, Type-Conditional, 10.7k Objects, 9.5M Grasps, 31 Grasp Types | Shanghai AI Lab / Peking | Dexonomy: Synthesizing All Dexterous Grasp Types in a Grasp Taxonomy | RSS 2025 | paper |
| 2025-04-07 | Robust Grasping, Single-View, Adaptive | Seoul National University | RobustDexGrasp: Robust Dexterous Grasping of General Objects from Single-view Perception | CoRL 2025 | paper |
| 2025-03-06 | Geometric Algebra, SE(3) Equivariant, Diffusion | Georgia Tech | GAGrasp: Geometric Algebra Diffusion for Dexterous Grasping | ICRA 2025 | paper |
| 2024-10-02 | Cross-Embodiment, Unified Representation, D(R,O) | Tsinghua | (R,O) Grasp: A Unified Representation of Robot and Object Interaction for Cross-Embodiment Dexterous Grasping | ICRA 2025 | paper |
| 2023-10-24 | Multi-Object, DexHand, Synthetic Dataset | Peking University | Grasp Multiple Objects with One Hand | RA-L 2024 | project |
| 2022-10-06 | Large-Scale, DexHand, Grasp Synthesis | Peking University | DexGraspNet: A Large-Scale Robotic Dexterous Grasp Dataset for General Objects Based on Simulation | ICRA 2023 | project / github |
| 2022-10-03 | Hand-Agnostic, MultiDex, Grasp Synthesis | BIGAI | GenDexGrasp: Generalizable Dexterous Grasping | ICRA 2023 | project / github |
| 2021-01-08 | Initial Grasp, Motion Planning, TriFinger | TTIC | Grasp and Motion Planning for Dexterous Manipulation for the Real Robot Challenge | arXiv | challenge |
Retargeting
Perception & Tracking
Evaluation & Robustness
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-08-21 | Tactile Security, Contactless EMI, 15 Sensors, Two DexHands | Zhejiang University | GhostTac: Manipulating Tactile Sensors without Physical Contact | ACM CCS 2026 | project |
| 2026-01-06 | Zero-Shot Sim2Real, Force-Based Grasping, Tactile | CMU | Closing the Reality Gap: Zero-Shot Sim-to-Real Deployment for Dexterous Force-Based Grasping and Manipulation | arXiv | paper |
| 2024-12-13 | Force Safety, Implicit Tactile, Vision-Guided | CUHK | SafeDiff: Ensuring Force Safety in Vision-Guided Robotic Manipulation via Implicit Tactile Calibration | CoRL 2025 | paper |
| 2022-10-10 | Adaptation, Domain Randomization, Disturbance | UC Berkeley | HORA: In-Hand Object Rotation via Rapid Motor Adaptation | arXiv | paper |
| 2020-04-15 | Offline RL, Adroit, Benchmark | UC Berkeley | D4RL: Datasets for Deep Data-Driven Reinforcement Learning | arXiv | github |
| 2020-01-09 | Benchmark, YCB Objects, In-Hand Pose | KTH | Benchmarking In-Hand Manipulation | RA-L 2020 | paper |
| 2019-10-16 | Rubik's Cube, Vision, Domain Randomization | OpenAI | Solving Rubik's Cube with a Robot Hand | arXiv | blog |
| 2018-08-01 | In-Hand Manipulation, Domain Randomization | OpenAI | Learning Dexterous In-Hand Manipulation | IJRR 2020 | blog |
📚 5. Surveys & Reviews
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-05-13 | Dexterous Hand Intelligence, Hardware+Sensing+Control+Data, Survey | University of Liverpool | Towards Robotic Dexterous Hand Intelligence: A Survey | arXiv | paper |
| 2025-11-30 | Tactile Robotics History, 150 Reviews, Future Directions | University of Bristol | Tactile Robotics: Past and Future | IJRR 2026 | journal |
| 2025-07-16 | Embodied Dexterity, Data Collection, Skill Learning, Survey | Zhejiang University | The Developments and Challenges towards Dexterous and Embodied Robotic Manipulation: A Survey | arXiv | paper |
| 2025-04-04 | Imitation Learning, Teleoperation, Survey | Tianjin University | Dexterous Manipulation through Imitation Learning: A Survey | arXiv | html |
| 2021-05-18 | Tactile Sensing, Review, Robots | University of Bristol | A Review of Tactile Sensors for Robotic Applications | Sensors 2021 | paper |
| 2019-05-03 | Robotic Hands, Actuation, Softness, Century-Scale Review | University of Pisa | A Century of Robotic Hands | Annual Review of Control, Robotics, and Autonomous Systems 2019 | publication |
| 2018-12-01 | Dexterous Manipulation, Hand-Centric Taxonomy | Stanford | A Hand-Centric Classification of Human and Robot Dexterous Manipulation | IEEE ToH 2018 | paper |
| 2015-12 | Tactile Hand Sensing, Feedback Control, Review | Sorbonne University | Tactile sensing in dexterous robot hands — Review | Robotics and Autonomous Systems 2015 | publication |
Acknowledgement
This list follows the single-file, compact-table style of Awesome-UMI and cross-checks scope against related public resources:
- Dexterous-Manipulation
- awesome-humanoid-manipulation
- Awesome-Robotics-Manipulation
- Awesome-Touch
- awesome-robot-descriptions
Citation
If this repository helps your work, please cite or link it as:
@misc{awesome_dexterous_manipulation,
  title        = {Awesome-Dexterous-Manipulation},
  author       = {Xinhai Chang},
  year         = {2026},
  howpublished = {\url{https://github.com/chang-xinhai/Awesome-Dexterous-Manipulation}},
}
Similar repos


A curated awesome list for dexterous robot manipulation, tactile sensing, dexterous hands, robot learning, datasets, benchmarks, and simulators.
See the codeREADME
Awesome-Dexterous-Manipulation
A curated map of papers, hardware, sensors, methods, datasets, benchmarks, and infrastructure for dexterous robot manipulation.
About
Awesome-Dexterous-Manipulation is a curated list for the ecosystem around dexterous robot manipulation: dexterous hands, tactile sensing, hand-centric tasks, robot learning, optimal control, teleoperation, benchmarks, datasets, and simulators.
This list is intentionally dexterity-first. It includes strong adjacent manipulation work only when it materially helps understand, build, evaluate, or deploy dexterous manipulation systems.
Source: Fig. 1 from Dexterous Manipulation through Imitation Learning: A Survey.
Must Read
Start here if you want the shortest path through the field.
| Goal | Start with |
|---|---|
| Understand classic dexterous manipulation | A Mathematical Introduction to Robotic Manipulation, A framework for planning dexterous manipulation |
| Learn modern in-hand RL | Learning Dexterous In-Hand Manipulation, Learning Complex Dexterous Manipulation with Deep RL and Demonstrations, HORA: In-Hand Object Rotation via Rapid Motor Adaptation |
| Study dexterous hands | LEAP Hand, Shadow Dexterous Hand, Allegro Hand |
| Study tactile sensing | TacThru, GelSight, DIGIT, ReSkin, Awesome Touch |
| Find benchmarks and datasets | DexYCB, DexGraspNet, Adroit, Shadow Hand environments |
| Build with simulators | Isaac Lab, MuJoCo, SAPIEN, PyBullet |
| Explore data collection | Pre-training Visual Dexterity in Simulation, YUBI, AutoDex, DexDirect, DexCap, DexUMI, DexWild |
News
- 2026-06-24: Realigned the README navigation to the canonical five-section taxonomy and folded enabling-system material into Infrastructure.
Contents
- Awesome-Dexterous-Manipulation
🦾 1. Hardware & Sensor Systems
Physical systems and sensing layers for dexterous manipulation.
1.1 Dexterous Hands
Anthropomorphic Hands
Non-Anthropomorphic & Multi-Finger Grippers
1.2 Tactile Sensors
Vision-Based Tactile
Capacitive & Piezoresistive
1.3 Multi-Modal Fusion Setups
Visuo-Tactile Integration
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-09-08 | Contact-Aware Tactile VLA, Latent Co-Imagination, Bimanual DexHands | Peking University | DeCAL: Towards Physically-Grounded Dexterous Vision-Language-Action Models via Contact-Aware Latent Co-Imagination | CoRL 2026 | project / github |
| 2026-09-07 | Human Video, Simulated Touch Completion, Zero-Shot Sim-to-Real | Tsinghua University | Dex-X: Learning Visual-Tactile Dexterous Manipulation From Human Videos with Simulated Interaction | arXiv | project |
| 2026-09-04 | Tactile World-Action Model, Execution-Time Correction, 20.7x Cheaper | Fudan University | TacPAC: Tactile Prediction and Real-Time Action Correction in World-Action Models for Contact-Rich Manipulation | arXiv | github |
| 2026-08-26 | Streaming Actions, Execution-Time Touch, Tactile VLA | Shanghai Jiao Tong University | TacForcing: Streaming Action Generation with Execution-Time Tactile Feedback | arXiv | project |
| 2026-08-21 | Physical Properties, Human Visuo-Tactile Data, Adaptive Grasping | Xiaomi Robotics | ViTacPhys: Physical Property-Aware Grasping from Human Visual-Tactile Demonstrations | arXiv | project |
| 2026-08-21 | Sequential Visuo-Tactile Pretraining, Temporal Alignment, Policy Learning | Shanghai Jiao Tong University | VT-MUSE: Multimodal Unified Sequential Visuotactile Representation Learning for Manipulation | arXiv | data |
| 2026-08-20 | Tactile World Action Model, Contact+Deformation+Slip Forecast | Institute of Automation, CAS | HiTac-WAM: A Hierarchical Tactile World Action Model for Contact-Rich Robot Manipulation | arXiv | paper |
| 2026-08-03 | Tactile VLA, Online Prediction, XHand, 900 Demonstrations | Authors | ReTouch: Empowering Contact-Rich Dexterous Manipulation with Online-Refined Tactile Prediction | arXiv | paper |
| 2026-07-30 | Tactile World Action Model, Force/Deformation Futures, In-Hand Manipulation | Tsinghua University | TacWAM: Anchor-Guided World Action Model with Mechanics-Aware Tactile Prediction | arXiv | paper |
| 2026-07-27 | Visuo-Tactile World Model, Contact Prediction, Planning | Institute of Automation, CAS | FeelWorld: Visuo-Tactile World Model for Hierarchical Contact Prediction and Planning | arXiv | paper |
| 2026-07-24 | Action-Conditioned World Model, Visuo-Tactile Rollouts, Policy Evaluation | ShanghaiTech University | ViTacWorld: Scaling Visuo-Tactile World Models for Contact-Rich Robot Manipulation | arXiv | project |
| 2026-07-22 | Tactile Generation, RGB-to-Touch, Data Augmentation, Imitation Learning | USC | FELT: Generating Tactile Signals from Vision for Visuo-Tactile Manipulation | arXiv | project |
| 2026-07-16 | Tactile-Grounded VLA, Future Touch Prediction, Latent Alignment | Fudan University | Representation-Aligned Tactile Grounding for Contact-Rich Robotic Manipulation | arXiv | paper |
| 2026-07-10 | Whole-Hand Tactile, Human-to-Robot Transfer, Benchmark | Authors | TactiDex: A Real-World Tactile-Guided Benchmark for Human-Like Dexterous Manipulation | arXiv | project |
| 2026-07-08 | Tactile Foundation Model, Predictive+Reactive, DexHand | Harbin Institute of Technology | TouchWorld: A Predictive and Reactive Tactile Foundation Model for Dexterous Manipulation | arXiv | paper |
| 2026-07-01 | Tactile Pretraining, 160 Hours, 135k Episodes, Human-to-Robot | Peking University | Human-Centric Transferable Tactile Pre-Training for Dexterous Robotic Manipulation | arXiv | paper |
| 2026-06-25 | Vibro-Tactile, Contact/Slip, Reactive Dexterity | CMU | VibeAct: Vibration to Actions for Contact-Rich Reactive Robot Dexterity | arXiv | project |
| 2026-06-15 | Tactile-Reactive VLA, Variable-Rate MoT, 100-Hour Dataset | Authors | T-Rex: Tactile-Reactive Dexterous Manipulation | arXiv | project |
| 2026-04-26 | Diffusion Policy, Visual-Tactile, Contact-Rich, Reactive, Tube | CMU / Stevens | Tube Diffusion Policy: Reactive Visual-Tactile Policy Learning for Contact-rich Manipulation | arXiv | paper |
| 2026-03-05 | Generative Contact Grounding, Compliance Control, Allegro+DG-5F | Purdue University | Contact-Grounded Policy: Dexterous Visuotactile Policy with Generative Contact Grounding | RSS 2026 | project |
| 2026-03-04 | Privileged Tactile Latent, No Tactile Simulation, In-Hand Reorientation | Carnegie Mellon University | PTLD: Sim-to-Real Privileged Tactile Latent Distillation for Dexterous Manipulation | arXiv | project |
| 2026-02-10 | Normalizing Flow, Action-Chunked Critics, Real-World Fine-Tuning | ETH Zurich | SERNF: Sample-Efficient Real-World Dexterous Policy Fine-Tuning via Action-Chunked Critics and Normalizing Flows | arXiv | paper |
| 2026-02-01 | Unified Force, Zero-Shot Transfer, Multi-Sensor | University of Liverpool | UniForce: A Unified Latent Force Model for Robot Manipulation with Diverse Tactile Sensors | arXiv | paper |
| 2026-01-21 | Tactile, Force/Torque, Contact-Rich | TU Munich | TacUMI: A Multi-Modal Universal Manipulation Interface for Contact-Rich Tasks | arXiv | github |
| 2025-12-24 | Cross-Embodiment Transfer, MANO Hand Model, Zero-Shot, Spatio-Tactile | Peking University | UniTacHand: Unified Spatio-Tactile Representation for Human to Robotic Hand Skill Transfer | arXiv | paper |
| 2025-12-10 | See-Through-Skin, TacThru-UMI, Diffusion Policy | Peking University | Simultaneous Tactile-Visual Perception for Learning Multimodal Robot Manipulation | RA-L 2026 | project / github |
| 2025-11-08 | Vision+Tactile, Fine Manipulation, Bimanual | Tsinghua | ViTaMIn-B | arXiv | project / paper |
| 2025-10-16 | Kinematic-Frame-Anchored, Sub-mm Precision, Geometric Reasoning | Shanghai Jiao Tong | SaTA: Spatially Anchored Tactile Awareness for Robust Dexterous Manipulation | arXiv | paper |
| 2025-09-23 | Conformable Skin, Contact-Rich, RL | UC Berkeley | DexSkin: High-Coverage Conformable Robotic Skin for Learning Contact-Rich Manipulation | CoRL 2025 | paper |
| 2025-08-20 | Visuotactile, Flow Dynamics, FBI, In-Hand Manipulation | Shanghai Jiao Tong | FBI: Learning Dexterous In-hand Manipulation with Dynamic Visuotactile Shortcut Policy | arXiv | paper |
| 2025-08-12 | Vision-Tactile-Language-Action, Semantic-Aligned, Dual-Encoder | Zhejiang University | OmniVTLA: Vision-Tactile-Language-Action Model with Semantic-Aligned Tactile Sensing | arXiv | paper |
| 2025-08-04 | Tactile Control, Articulated Objects, Proactive | Peking University | TacMan-Turbo: Proactive Tactile Control for Robust and Efficient Articulated Object Manipulation | T-ASE 2026 | paper |
| 2025-06-19 | Cross-Modal Fusion, Autoregressive Prediction, Long-Horizon Manipulation | Cornell University | ViTacFormer: Learning Cross-Modal Representation for Visuo-Tactile Dexterous Manipulation | arXiv | paper |
| 2025-06-13 | Diffusion Recipe, 16-DoF, Tendon-Driven, Teleoperation | ETH Zurich / Cornell | mimic-one: A Scalable Model Recipe for General Purpose Robot Dexterity | arXiv | paper |
| 2025-06-13 | Visuo-Tactile, Implicit Representation, Pose Estimation | UConn | ViTaSCOPE: Visuo-tactile Implicit Representation for In-hand Pose and Extrinsic Contact Estimation | RSS 2025 | paper |
| 2025-06-02 | Tactile Glove, Human-to-Robot Force Transfer, Contact-Driven Learning | Cornell University | Feel the Force: Contact-Driven Learning from Humans | arXiv | paper |
| 2025-05-16 | Egocentric Video, Apple Vision Pro, Large-Scale, Dexterous | MIT | EgoDex: Learning Dexterous Manipulation from Large-Scale Egocentric Video | arXiv | paper |
| 2025-05-16 | Self-Supervised, Magnetic Skin, PercepSkin | Intel Labs | Sparsh-skin: Self-supervised Perception for Tactile Skin Covered Dexterous Hands | CoRL 2025 | paper |
| 2025-04-23 | Paper Picking, Tactile Feedback, Diffusion Policy, Slip Detection | Tsinghua | PP-Tac: Paper Picking Using Tactile Feedback in Dexterous Robotic Hands | RSS 2025 | paper |
| 2025-04-08 | Robot-Free, Visuo-Tactile, Contact-Rich | Tsinghua | ViTaMIn: Learning Contact-Rich Tasks Through Robot-Free Visuo-Tactile Manipulation Interface | arXiv | project |
| 2025-03-02 | Force Sensing Transfer, Multi-Sensor Alignment, Shared Representation | King's College London | GenForce: Training Tactile Sensors to Learn Force Sensing from Each Other | arXiv | paper |
| 2025-02-12 | Correspondence, Visuomotor, Diffusion Policy | Peking University | CordViP: Correspondence-based Visuomotor Policy for Dexterous Manipulation in Real-World | RSS 2025 | project |
| 2024-03-04 | Tactile, Articulated Objects, Prior-Free | Peking University | Tac-Man: Tactile-Informed Prior-Free Manipulation of Articulated Objects | T-RO 2024 | project |
| 2023-09-18 | Vision+Touch, In-Hand Rotation, Sim2Real | UC Berkeley | RotateIt: General In-Hand Object Rotation with Vision and Touch | CoRL 2023 | project |
| 2023-03-25 | Visuo-Tactile, In-Hand Reconstruction, DIGIT | Shanghai Jiao Tong University | Visual-Tactile Sensing for In-Hand Object Reconstruction | CVPR 2023 | cvf |
| 2022-09-30 | Multimodal, Contact-Rich, Learning | MIT | Visuo-Tactile Transformers for Manipulation | CoRL 2022 | paper |
| 2018-05-28 | Vision+GelSight, Closed-Loop Regrasping, 6,450 Trials | UC Berkeley | More Than a Feeling: Learning to Grasp and Regrasp Using Vision and Touch | RA-L 2018 | publication |
Proprioception & Force-Torque
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-07-20 | Force Memory, Non-Markovian VLA, Contact Events | Tsinghua University | FM-VLA: Force-based Memory for Vision-Language-Action Models in Contact-Rich Manipulation | arXiv | project / github |
| 2026-07-19 | Vision+Force, Asynchronous Fusion, Reactive Diffusion Policy | Shanghai Jiao Tong | Asynchronous Multimodal Diffusion Policy Composition via Latency-Aware Guidance Fusion | arXiv | project |
| 2026-07-03 | Motor Current, Contact Feedback, Compliant Dexterity | UNC Chapel Hill | Current as Touch: Proprioceptive Contact Feedback for Compliant Dexterous Manipulation | arXiv | project |
| 2026-06-23 | Vision+Proprioception, Contact Estimation, In-Hand | IIIT Hyderabad | NoContactNoWorries: Estimating Contact through Vision and Proprioception for In-Hand Dexterous Manipulation | IROS 2026 | project |
| 2026-05-20 | Joint-Only, Proprioceptive Transformer, Tendon-Driven Hand | ETH Zurich | Learning Robust Dexterous In-Hand Manipulation from Joint Sensors with Proprioceptive Transformer | arXiv | paper |
| 2026-01-15 | Force, Compliance, Contact-Rich | Stanford | In-the-Wild Compliant Manipulation with UMI-FT | ICRA 2026 | github |
| 2025-09-23 | Force-Guided, Wrist F/T, Contact-Rich | GIST | ManipForce | ICRA 2026 | project / github |
| 2022-10-10 | Proprioception, Adaptation, Sim2Real | UC Berkeley | HORA: In-Hand Object Rotation via Rapid Motor Adaptation | arXiv | paper |
| 2019-10-16 | Proprioception, Vision, Rubik's Cube | OpenAI | Solving Rubik's Cube with a Robot Hand | arXiv | blog |
🖐️ 2. Dexterity Capabilities & Tasks
Hand-centric capabilities, organized by manipulation taxonomy rather than by only individual benchmark names.
2.1 Prehensile Manipulation
In-Hand Reorientation / Rotation
Finger Gaiting / Regrasping
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2025-09-22 | Tactile RL, Contact-Aware, Finger Gaiting | University of Southern Denmark | Tac2Motion: Contact-Aware Reinforcement Learning with Tactile Feedback for Robotic Hand Manipulation | arXiv | video |
| 2024-09-13 | Teleoperation, Finger Gaiting, Residual Learning | UIUC | ResPilot: Teleoperated Finger Gaiting via Gaussian Process Residual Learning | CoRL 2024 | project |
| 2021-09-26 | Finger Gaiting, Intrinsic Sensing, Tactile | Columbia | On the Feasibility of Learning Finger-gaiting In-hand Manipulation with Intrinsic Sensing | arXiv | project / pdf |
| 1991-04-01 | Contact Planning, Classic, ICRA | Rensselaer Polytechnic Institute | A framework for planning dexterous manipulation | ICRA 1991 | author-bib |
Tool Use & Extrinsic Dexterity
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-07-20 | Underactuated Hand, Grasp Compliance, Forceful Tool Use, AMINN | Stevens Institute of Technology | Predicting Grasping Compliance in Robotic Hands through Analytical-Model-Informed Neural Networks | arXiv | paper |
| 2026-06-30 | Functional Tool Use, VLM Constraints, Zero-Demo, Sim-to-Real | UT Austin | CoDex: Learning Compositional Dexterous Functional Manipulation without Demonstrations | ICRA 2026 | project |
| 2026-06-29 | Grasp Pretraining, Articulated Tools, DexCraft | CMU | From Grasps to Dexterity: Large-Scale Grasp Pretraining for Dexterous Manipulation | arXiv | project |
| 2026-06-11 | Articulated Tools, Functional Retargeting, RL | Stanford University | Mana: Dexterous Manipulation of Articulated Tools | arXiv | project |
| 2026-02-18 | Zero-Shot Tool Manipulation, Object-Centric, Sim2Real | Stanford | SimToolReal: An Object-Centric Policy for Zero-Shot Dexterous Tool Manipulation | arXiv | project |
| 2025-09-27 | Articulated Tools, Cross-Attention, Sim2Real | UC San Diego | In-Hand Manipulation of Articulated Tools with Dexterous Robot Hands with Sim-to-Real Transfer | IROS 2025 | paper |
| 2014-05-31 | Extrinsic Dexterity, External Forces, Robot Hand | Carnegie Mellon | Extrinsic Dexterity: In-Hand Manipulation with External Forces | ICRA 2014 | paper |
2.2 Non-Prehensile Manipulation
Pushing, Sliding & Flipping
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2016-09-28 | Pushing, Planar Manipulation, Learning | MIT | Learning to Push by Grasping: Using Multiple Tasks for Effective Learning | ICRA 2017 | paper |
Rolling & Pivoting
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 1998-05-20 | Rolling, Finger Gaiting, Contact Planning | Texas A&M | Dextrous Manipulation by Rolling and Finger Gaiting | ICRA 1998 |
2.3 Dynamic & Agile Manipulation
Catching, Throwing & Juggling
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-08-27 | Bimanual Juggling, Multi-Finger Hands, Online Adaptation, Five Patterns | Robotics and AI Institute | Rapid On-Robot Learning for Dynamic Manipulation Skills: Robot Juggling | arXiv | paper |
| 2026-05-10 | Reactive Catching, Zero-Shot Sim-to-Real, Instance-Set Randomization | Rice University | Zero-Shot Sim-to-Real Robot Learning: A Dexterous Manipulation Study on Reactive Catching | arXiv | paper |
| 2019-10-16 | Rubik's Cube, Disturbance, Dynamic Recovery | OpenAI | Solving Rubik's Cube with a Robot Hand | arXiv | blog |
Pen Spinning / Twirling / Fine Motor Skills
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-09-10 | In-Hand Pen Writing, Online Jacobian, 18s Initialization, 0.6mm Error | ETH Zurich | Rapid Learning of Dexterous In-Hand Pen Writing through Real-Time Jacobian Estimation | arXiv | project |
| 2026-03-23 | Robot Drumming, In-Hand Control, Contact-Rich, Long-Horizon | Stanford University | DexDrummer: In-Hand, Contact-Rich, and Long-Horizon Dexterous Robot Drumming | arXiv | paper |
| 2024-07-26 | Pen Spinning, Sim2Real, Real Fine-Tuning | UC San Diego | Lessons from Learning to Spin "Pens" | arXiv | project |
| 2023-04-09 | Piano Playing, Fine Motor Control, RL | Google Research | RoboPianist: Dexterous Piano Playing with Deep Reinforcement Learning | CoRL 2023 | project / openreview |
2.4 Complex & Specialized Tasks
Bimanual Dexterous Manipulation
Deformable Object Manipulation
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-08-19 | Deformable Objects, Visuo-Tactile, 4k Demonstrations, Deformation-Aware Evaluation | Tuojing Intelligence | SoftVTBench: A Deformation-Aware Visuo-Tactile Dataset and Benchmark for Deformable-Object Manipulation | arXiv | project / github |
| 2026-07-22 | Deformable Dynamics, Material Identification, Differentiable MPM, World Model | Georgia Tech | PhysCoRe: Physics-Corrected Residual World Models for Material-Aware Deformable Dynamics | arXiv | paper |
| 2020-11-14 | Cloth, Benchmark, Deformable | UC Berkeley | SoftGym: Benchmarking Deep Reinforcement Learning for Deformable Object Manipulation | CoRL 2020 | project / github |
🧠 3. Methodology
Learning, planning, control, and data-pipeline methods for dexterous manipulation.
3.1 Reinforcement Learning
Sim-to-Real Transfer
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-09-09 | Generated HOI Video, Simulation Grounding, 1.5k+ Trajectories, Unified Controller | UC Berkeley | Grounding Generated Video Plans in Simulation Towards Versatile Dexterous Controllers | arXiv | project / github |
| 2026-09-07 | Human Video, Simulated Tactile Supervision, Zero-Shot Sim-to-Real | Tsinghua University | Dex-X: Learning Visual-Tactile Dexterous Manipulation From Human Videos with Simulated Interaction | arXiv | project |
| 2026-09-07 | Visuo-Tactile World Model, 49 Objects, Multi-Axis Rotation, Sim-to-Real | Sharpa Robotics | WM-Craftnet: World Synesthesia Model for Generalizable and Robust Dexterous In-Hand Manipulation | CoRL 2026 | project |
| 2026-09-05 | Intervention-Aware World Model, Real-World RL, LEAP Hand, Safety | HKUST (Guangzhou) | How to Learn from What a Human Would Avoid? Intervention-Aware World Models with Real-World RL for Dexterous Manipulation | CoRL 2026 | project |
| 2026-09-01 | Single Demo, Contact-Centric Reward, Cross-Object Generalization | Stanford University | One Demonstration, Many Objects: Generalizing Manipulation via Local Contact Geometry | arXiv | project |
| 2026-08-19 | Dexterity Pretraining, RL Post-Training, Visuo-Tactile, Multi-Embodiment | NVIDIA | ADEPT: Accelerating Dexterity via Pre-Training and Post-Training using Reinforcement Learning | arXiv | project |
| 2026-08-16 | Tactile Sim-to-Real, Sensor-Agnostic Oracle, GelSight+DIGIT, Zero-Shot | University of Michigan | Tactile Sim2Real without Tactile Simulation via Bottlenecked Latent Reconstruction | arXiv | paper |
| 2026-07-13 | Physics Priors, Grasp Quality, Fingertip Geometry, In-Hand Rotation | Northwestern University | Robust In-Hand Manipulation via Priors in Reinforcement Learning and Mechanical Design | arXiv | paper |
| 2026-07-13 | Retargeting-Guided RL, Single Demo, Tool Use | Cornell University | A Minimalist Retargeting-Guided Reinforcement Learning Recipe for Dexterous Manipulation | arXiv | project |
| 2026-07-07 | Latent Motion Prior, Real-World Learning, DexHand | Authors | LAMP: Latent Motion Prior-Guided Real-World Learning for Dexterous Hand Manipulation | arXiv | paper |
| 2026-07-05 | Segmentation Masks, Sim-to-Real, Dexterous World Models | ETH Zurich | Mask2Real-WM: Segmentation Masks as a Sim-to-Real Bridge for Controllable Dexterous World Models | arXiv | project |
| 2026-06-24 | Dexterous Play, Precise Assembly, RL Pretraining, Sim-to-Real | Stanford | Play2Perfect: What Matters in Dexterous Play Pretraining for Precise Assembly? | arXiv | project / github |
| 2026-06-08 | Real-World Post-Training, HIL, DAgger, Diffusion Policy | Hunan University | DexPIE: Stable Dexterous Policy Improvement from Real-World Experience | arXiv | project |
| 2026-04-13 | Monocular RGB, 3DGS, Visual Sim2Real | ETH Zurich | ViserDex | arXiv | project |
| 2026-03-11 | Few-Shot Augmentation, Adaptive Residual Policy, Arm-Hand Coordination | Institute of Automation, CAS | FAR-Dex: Few-shot Data Augmentation and Adaptive Residual Policy Refinement for Dexterous Manipulation | arXiv | paper |
| 2026-03-11 | Contact Coverage, Exploration, General-Purpose | Shanghai AI Lab | ContactExplorer: Contact Coverage-Guided Exploration for General-Purpose Dexterous Manipulation | arXiv | paper |
| 2026-03-04 | Privileged Tactile Distillation, No Tactile Simulation, Allegro | Carnegie Mellon University | PTLD: Sim-to-Real Privileged Tactile Latent Distillation for Dexterous Manipulation | arXiv | project |
| 2026-03-01 | Differentiable Real-to-Sim, Mass Identification, Force-Aware Grasping | University of Southern California | D-REX: Differentiable Real-to-Sim-to-Real Engine for Learning Dexterous Grasping | ICLR 2026 | paper |
| 2026-02-09 | Cross-Embodiment, Transformer, LEAP Hand | HKUST(GZ) | DexFormer | arXiv | project |
| 2026-02-02 | Residual Flow Steering, Generative Policies, Fine-Tuning | University of Washington | RFS: Reinforcement Learning with Residual Flow Steering for Dexterous Manipulation | arXiv | project |
| 2026-01-06 | Zero-Shot Sim2Real, Force-Based Grasping, Tactile | CMU | Closing the Reality Gap: Zero-Shot Sim-to-Real Deployment | arXiv | paper |
| 2025-11-10 | Tactile Equivariance, Residual Rotation, SO(2) | CMU / Boston University | EquiTac: Residual Rotation Correction using Tactile Equivariance | arXiv | paper |
| 2025-10-09 | Neural Dynamics, In-Hand Rotation, Sim2Real | Tsinghua | DexNDM | ICLR 2026 | project |
| 2025-09-28 | Self-Improving Data Generation, Sim-to-Real, Grasp Curriculum | Harbin Institute of Technology | DexFlyWheel: A Scalable and Self-improving Data Generation Framework for Dexterous Manipulation | NeurIPS 2025 Spotlight | project |
| 2025-08-03 | Mixture-of-Experts, Object Generalization, RL | HUST | DexReMoE | arXiv | project |
| 2025-07-15 | Vision-to-Force Policy, Contact-Rich, SE(3) Equivariance | University of Washington | EquiContact: A Hierarchical SE(3) Vision-to-Force Equivariant Policy for Spatially Generalizable Contact-rich Tasks | arXiv (rev. Jan 2026) | paper |
| 2025-07-09 | Hierarchical RL, Articulated Tools, Multifingered Hand | Shanghai Jiao Tong | Hierarchical Reinforcement Learning for Articulated Tool Manipulation with Multifingered Hand | IROS 2025 | paper |
| 2025-07-06 | Model-Based Simulation, Sim2Real, Visual RL | Tsinghua | SimLauncher: Launching Dexterous Hand Manipulation Policies with Model-Based Simulation | IROS 2025 | paper |
| 2025-05-30 | Functional Retargeting, Bimanual, Sim2Real | NVIDIA | DexMachina: Functional Retargeting for Bimanual Dexterous Manipulation | arXiv | project |
| 2025-03-06 | Geometric Algebra, SE(3) Equivariant, Diffusion | Georgia Tech | GAGrasp: Geometric Algebra Diffusion for Dexterous Grasping | ICRA 2025 | paper |
| 2025-03-04 | Variable Friction, Sim2Real, Imitation Learning | CMU | Variable-Friction In-Hand Manipulation for Arbitrary Objects via Diffusion-Based Imitation Learning | ICRA 2025 | paper |
| 2025-03-04 | Visuomotor Diffusion, In-Hand Manipulation, Multifingered | KTH | Learning Dexterous In-Hand Manipulation with Multifingered Hands via Visuomotor Diffusion Policies | IROS 2025 | paper |
| 2025-02-27 | Humanoid, DexHand, Sim2Real | NVIDIA | Sim-to-Real Reinforcement Learning for Vision-Based Dexterous Manipulation on Humanoids | arXiv | project |
| 2025-02-06 | Foundation Controller, Motion Primitives, RL Pretraining | Physical Intelligence | DexterityGen | arXiv | project |
| 2025-01-09 | Hierarchical Skills, Any-Axis, Sim2Real | UC Berkeley | From Simple to Complex Skills: The Case of In-Hand Object Reorientation | arXiv | project |
| 2024-11-27 | Interaction-Aware, Diffusion, Adaptive | Tsinghua | DexHandDiff: Interaction-aware Diffusion Planning for Adaptive Dexterous Manipulation | CVPR 2025 | paper |
| 2024-11-20 | Bimanual Dexterity, RL, Sim2Real | Georgia Tech | AsymDex | arXiv | project |
| 2024-10-02 | Cross-Embodiment, Unified Representation, D(R,O) | Tsinghua | (R,O) Grasp: A Unified Representation of Robot and Object Interaction for Cross-Embodiment Dexterous Grasping | ICRA 2025 | paper |
| 2024-09-22 | Online Planning, Sampling, Dexterous Reorientation | CMU | DROP: Dexterous Reorientation via Online Planning | ICRA 2025 | paper |
| 2024-07-26 | Pen Spinning, Real Fine-Tuning, Sim2Real | UC San Diego | Lessons from Learning to Spin "Pens" | arXiv | project |
| 2023-09-02 | Long-Horizon, Chaining Policies, RL | Stanford | Sequential Dexterity: Chaining Dexterous Policies for Long-Horizon Manipulation | CoRL 2023 | paper |
| 2022-11-17 | Point Cloud, Generalizable, Sim2Real | UC San Diego | DexPoint: Generalizable Point Cloud RL for Sim-to-Real Dexterous Manipulation | CoRL 2022 | paper |
| 2022-10-10 | Adaptation, Domain Randomization, Shadow Hand | UC Berkeley | HORA: In-Hand Object Rotation via Rapid Motor Adaptation | arXiv | paper |
| 2021-11-04 | General Reorientation, Zero-Shot, Distillation | MIT | A System for General In-Hand Object Re-Orientation | CoRL 2021 Oral | project |
| 2019-10-16 | Rubik's Cube, Automatic Domain Randomization | OpenAI | Solving Rubik's Cube with a Robot Hand | arXiv | blog |
| 2018-08-01 | In-Hand Manipulation, Domain Randomization | OpenAI | Learning Dexterous In-Hand Manipulation | IJRR 2020 | dblp / blog |
| 2018-02-26 | Multi-Goal RL, Shadow Hand, Sparse Rewards | OpenAI | Multi-Goal Reinforcement Learning: Challenging Robotics Environments and Request for Research | arXiv | github |
Reward Design & State Estimation
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-03-11 | Adaptive Force Control, Contact-Rich, Cartesian Impedance, RL | University of Southern California | Learning Adaptive Force Control for Contact-Rich Sample Scraping with Heterogeneous Materials | IROS 2026 | paper |
| 2025-10-09 | Human Video, Contact Rewards, Humanoid | Shanghai AI Lab | DexMan | arXiv | paper |
| 2025-09-22 | Tactile Feedback, Reward Shaping, Finger Gaiting | University of Southern Denmark | Tac2Motion | arXiv | video |
| 2025-09-09 | LLM Reward, Tactile, In-Hand Rotation | University of Bristol | Text2Touch: Tactile In-Hand Manipulation with LLM-Designed Reward Functions | CoRL 2025 | project / proceedings |
| 2025-03-06 | Real-World RL, Dexterous Grasping, Online | Beihang University | Dexterous Grasping with Real-World Robotic Reinforcement Learning | arXiv | paper |
| 2024-07-10 | Tactile Skin, Shear/Normal Force, Translation | Meta FAIR | Learning In-Hand Translation Using Tactile Skin With Shear and Normal Force Sensing | arXiv | project |
| 2023-09-18 | Vision+Touch, State Estimation, Rotation | UC Berkeley | RotateIt: General In-Hand Object Rotation with Vision and Touch | CoRL 2023 | project |
| 2017-09-28 | Demonstrations, Sparse Rewards, Adroit | University of Washington | Learning Complex Dexterous Manipulation with Deep RL and Demonstrations | RSS 2018 | github |
3.2 Imitation Learning
Behavior Cloning & Action Chunking
Diffusion Policies
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-07-30 | Frequency-Adaptive, Visual-Force, Reactive Diffusion, Contact-Rich | Shanghai Jiao Tong University | FA-RDP: A Frequency-Adaptive Reactive Diffusion Policy for Contact-Rich Manipulation | arXiv | project |
| 2026-07-28 | Reactive, Flow Matching, Proprioception, XHand, Real-Time | Carnegie Mellon University | $\pi\mathbf{R}^2$: Reactive Real-time Flow Policies | arXiv | project |
| 2026-07-19 | Asynchronous Fusion, Vision+Force, Reactive Diffusion Policy | Shanghai Jiao Tong | Asynchronous Multimodal Diffusion Policy Composition via Latency-Aware Guidance Fusion | arXiv | project |
| 2025-08-24 | Long-Horizon, Synthetic Data, Skill Routing | HKU | LodeStar: Long-horizon Dexterity via Synthetic Data Augmentation from Human Demonstrations | arXiv | paper |
| 2025-08-20 | Force Closure, Differentiable Optimization, Grasp Synthesis | ETH Zurich | GraspQP: Differentiable Optimization of Force Closure for Diverse and Robust Dexterous Grasping | IROS 2025 | paper |
| 2025-06-17 | Sim-to-Real, Clutter, Diffusion Policy | Tsinghua | ClutterDexGrasp: A Sim-to-Real System for General Dexterous Grasping in Cluttered Scenes | CoRL 2025 | project |
| 2025-03-03 | Soft Hands, Diffusion Policy, Proprioceptive | University of Michigan | KineSoft: Learning Proprioceptive Manipulation Policies with Soft Robot Hands | ICRA 2025 | paper |
| 2024-12-19 | Dexterous Fine-Tuning, Real-World Hands | UC Berkeley | DEFT: Dexterous Fine-Tuning for Real-World Hand Policies | Website | project |
| 2024-10-25 | Diffusion Policy, Compliant Manipulation, Contact-Rich, Stiffness Control | University of Tokyo | DIPCOM: Learning Diffusion Policies from Demonstrations For Compliant Contact-rich Manipulation | arXiv | paper |
| 2024-10-10 | Bimanual, Diffusion Foundation, Manipulation | Tsinghua | RDT-1B: a Diffusion Foundation Model for Bimanual Manipulation | arXiv | project / github |
| 2024-07-21 | Flow Matching, Uncertainty-Aware, Dexterous Grasping | TUM | FFHFlow: Diverse and Uncertainty-Aware Dexterous Grasp Generation via Flow Variational Inference | ICRA 2025 | paper |
| 2024-03-06 | 3D Diffusion, Point Cloud, Dexterous | Zhejiang University | DP3: 3D Diffusion Policy for Generalizable Visuomotor Policy Learning | ICRA 2025 | project |
| 2023-03-07 | Diffusion Policy, Visuomotor, Robot Learning | Columbia | Diffusion Policy: Visuomotor Policy Learning via Action Diffusion | RSS 2023 | project / github |
3.3 Vision-Language-Action (VLA) & Foundation Models
Dexterous VLA Models
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-09-08 | Contact-Aware Tactile VLA, Latent Co-Imagination, Factorized Flow | Peking University | DeCAL: Towards Physically-Grounded Dexterous Vision-Language-Action Models via Contact-Aware Latent Co-Imagination | CoRL 2026 | project / github |
| 2026-08-31 | General World Model, Dual DexHands, 130K h Human Data, Tactile Control | GensPI | Motus2: A Self-Evolving General World Model for Dexterous Manipulation | arXiv | project |
| 2026-08-16 | Frozen VLA, Tactile Residual Adaptation, UniVTAC, Physical Robot | Beijing Institute of Technology | ViTaR: Visuo-Tactile Residual Adaptation for Foundation VLA Manipulation | arXiv | project |
| 2026-08-14 | Human+Robot Demonstrations, Joint-Aligned Actions, Cross-Embodiment, Tactile VLA | Zhejiang University | AdvDex: Learning Dexterous Manipulation from Human Demonstrations via Joint-Aligned Actions and Adversarial Learning | arXiv | paper |
| 2026-07-30 | Tactile World Action Model, Mechanics-Aware, Contact-Rich, In-Hand | Tsinghua University | TacWAM: Anchor-Guided World Action Model with Mechanics-Aware Tactile Prediction | arXiv | paper |
| 2026-07-26 | Tactile-Native World Action Model, Contact-Rich, Multi-Embodiment | Authors | $N_0$-TWAM: Scaling Tactile-Native World-Action Model for Contact-Rich Manipulation | arXiv | paper |
| 2026-07-24 | Visuo-Tactile World Model, Rollout Generation, Policy Improvement | ShanghaiTech University | ViTacWorld: Scaling Visuo-Tactile World Models for Contact-Rich Robot Manipulation | arXiv | project |
| 2026-07-20 | Force Memory, Non-Markovian VLA, Contact-Rich | Tsinghua University | FM-VLA: Force-based Memory for Vision-Language-Action Models in Contact-Rich Manipulation | arXiv | project / github |
| 2026-07-16 | Tactile-Grounded VLA, Future Touch Prediction, Latent Alignment | Fudan University | Representation-Aligned Tactile Grounding for Contact-Rich Robotic Manipulation | arXiv | paper |
| 2026-07-07 | LingBot-VLA 2.0, Cross-Embodiment, DexHands | Robbyant | From Foundation to Application: Improving VLA Models in Practice | Tech Report | github / model / paper |
| 2026-07-03 | Tactile World Model, Failure Recovery, VLA Post-Training | Peking University | TACO: TActile World Model as a Self-COrrector for Scalable VLA Post-Training | arXiv | project |
| 2026-07-01 | Tactile Pretraining, Dexterous VLA, Human-to-Robot, Contact Dynamics | Peking University | Human-Centric Transferable Tactile Pre-Training for Dexterous Robotic Manipulation | arXiv | paper |
| 2026-06-30 | Tactile VLA, Contact Prediction, Tactile-Action Control | Harbin Institute of Technology | UniTacVLA: Unified Tactile Understanding and Prediction in Vision Language Action Models | arXiv | paper |
| 2026-06-17 | Zero-Shot Long-Horizon, Multi-View 3D Grounding, VLM Planning | Seoul National University | ZeroDex: Zero-Shot Long-Horizon Dexterous Manipulation via Multi-View 3D-Grounded VLM Reasoning | arXiv | project |
| 2026-06-10 | Dexterous VLA, Morphology Gap, Intent Conditioning, Fine-Tuning | Beihang University | Bridging the Morphology Gap: Adapting VLA Models to Dexterous Manipulation via Intent-Conditioned Fine-Tuning | arXiv | paper |
| 2026-05-14 | Dexterous VLA, Human-in-the-Loop, Bimanual, Policy Refinement | Shanghai Jiao Tong | Hand-in-the-Loop: Improving VLA Policies for Dexterous Manipulation via Seamless Hand-Arm Intervention | arXiv | project |
| 2026-05-07 | World Action Model, Object-Addressable, Slot-Based Attention | Southeast University | OA-WAM: Object-Addressable World Action Model for Robust Robot Manipulation | arXiv | paper |
| 2026-05-07 | Triadic Relational Structure, VLA, Object-Hand-Task | NUS | TriRelVLA: Triadic Relational Structure for Generalizable Embodied Manipulation | arXiv | paper |
| 2026-05-06 | Contact-Free, ToF Sensors, Grasp Stability, 86% Accuracy | Cornell | Contact-Free Grasp Stability Prediction with In-Hand Time-of-Flight Sensors | arXiv | paper |
| 2026-05-03 | Foundation Model, VLM Critic, Tactile-Visual, Sim-to-Real Gap 8.3% | Zhejiang University | DexSim2Real: Foundation Model-Guided Sim-to-Real Transfer for Generalizable Dexterous Manipulation | arXiv | paper |
| 2026-03-23 | Egocentric Video, Foundation Suite, Universal Dexterous, Cross-Hand | Shanghai AI Lab | UniDex: A Robot Foundation Suite for Universal Dexterous Hand Control from Egocentric Human Videos | CVPR 2026 | paper |
| 2026-03-12 | Humanoid, Reproducible Demonstrations, DexHand | Physical Intelligence Lab | HumDex: Humanoid Dexterous Manipulation Made Easy | arXiv | github |
| 2026-02-28 | DexHand, VLM, Unified Dexterous, Language-Guided, Physics-Refinement | Tsinghua | UniHM: Unified Dexterous Hand Manipulation with Vision Language Model | ICLR 2026 | project |
| 2025-02-28 | Dexterous Grasping, VLA, Open-Vocabulary | Shanghai AI Lab | DexGraspVLA: A Vision-Language-Action Framework Towards General Dexterous Grasping | AAAI 2026 | paper |
Zero-shot / Few-shot Dexterity
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-07-03 | Unified Hand Action Space, Zero-Shot Cross-Hand Transfer | Authors | Cross-Embodiment Robot Manipulation via a Unified Hand Action Space | arXiv | paper |
| 2026-02-18 | Canonical Hand, Cross-Embodiment, LEAP Hand | UNC Chapel Hill | One Hand to Rule Them All: Canonical Representations for Unified Dexterous Manipulation | arXiv | project |
| 2025-08-09 | Gaussian Splatting, Fruit Inspection, Dexterous Manipulation | Stanford | DexFruit: Dexterous Manipulation and Gaussian Splatting Inspection of Fruit | RA-L 2026 | paper |
| 2025-07-05 | Human Hand, Few-Shot, Robot-Free | Peking University | RwoR: Generating Robot Demonstrations from Human Hand Collection for Policy Learning without Robot | IROS 2025 | project |
| 2024-10-31 | Egocentric Video, Imitation, Scaling | Georgia Tech | EgoMimic: Scaling Imitation Learning via Egocentric Video | arXiv | project / github |
3.4 Trajectory Optimization & Optimal Control
Trajectory Optimization
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2025-02-11 | In-Grasp Movement, Trajectory Optimization, RGMC | Tsinghua | Robotic In-Hand Manipulation for Large-Range Precise Object Movement: The RGMC Champion Solution | RA-L | project |
| 2022-09-28 | Trajectory Optimization, RL, Dexterous | University of Washington | Solving Complex Dexterous Manipulation Tasks With Trajectory Optimisation and Reinforcement Learning | CoRL 2022 | project |
Kinematics & Motion Planning
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-02-09 | Human Videos, 3D Reconstruction, Dexterous Policies | Carnegie Mellon | Dexterous Manipulation Policies from RGB Human Videos via 3D Hand-Object Trajectory Reconstruction | arXiv | project |
| 2025-11-12 | Physics-Informed, Retargeting, Scalable | Columbia University | SPIDER: Scalable Physics-Informed Dexterous Retargeting | arXiv | paper |
| 2024-05-29 | Teleoperation, DeltaHand, In-Hand | CMU | Tilde: Teleoperation for Dexterous In-Hand Manipulation Learning with a DeltaHand | RSS 2024 | paper |
| 2024-04-24 | Human Videos, Visuomotor, Sim2Real | UC San Diego | ViViDex: Learning Vision-based Dexterous Manipulation from Human Videos | ICRA 2025 | project |
| 2024-03-12 | Mocap, Retargeting, DexHand | Stanford | DexCap: Scalable and Portable Mocap Data Collection System for Dexterous Manipulation | arXiv | github |
| 1994-01-01 | Kinematics, Grasping, Classic Textbook | Caltech | A Mathematical Introduction to Robotic Manipulation | Book |
3.5 Data Collection Paradigms
Source: teleoperation framework figure from Dexterous Manipulation through Imitation Learning: A Survey.
Vision-based Teleoperation
Exoskeleton & Glove-based
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-09-10 | Shared Human/Robot Exoskeleton, 20-DoF Encoders, Paired Contact Retargeting | Peking University | SEED-UMI: Sharing the Exoskeleton between human and robot for onE-to-one Dexterous demonstration | arXiv | project |
| 2026-08-25 | Fiber-Optic Glove, 60Hz Full-Hand Pose, 4.9mm Error, Bimanual | Meta | Fiber Optic Sensing Glove for High Performance Dexterous Manipulation Capture | arXiv | paper |
| 2026-06-15 | 22-DoF, 2048-Taxel, 120Hz, Interaction Capture | Carnegie Mellon | ART-Glove: Articulated Tactile Glove for Contact-Grounded Dexterous Interaction Capture | arXiv | project |
| 2026-03-30 | Tactile Feedback Array, Magnetic MoCap, Glove Teleop | Shanghai AI Lab | Feel Robot Feels: Tactile Feedback Array Glove for Dexterous Manipulation | arXiv | project / github |
| 2025-09-04 | Passive Hand Exoskeleton, Perioperation, Robot-Transferable Data | MIT | DEXOP: A Device for Robotic Transfer of Dexterous Human Manipulation | arXiv | paper |
| 2025-02-11 | Haptic Glove, Force Feedback, Teleoperation | University of Bristol | DOGlove: Dexterous Manipulation with a Low-Cost Open-Source Haptic Force Feedback Glove | RSS 2025 | project |
| 2024-08-21 | Visual-Exoskeleton, Retargeting, Teleop | UC San Diego | ACE | CoRL 2024 | project |
| 2019-06-06 | Tactile Glove, Human Demonstrations, Grasp | MIT | Learning the Signatures of the Human Grasp Using a Scalable Tactile Glove | Nature 2019 | paper |
Passive Video & Internet Data Extraction
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-09-09 | Generated HOI Video, 2k References, Simulation Grounding | UC Berkeley | Grounding Generated Video Plans in Simulation Towards Versatile Dexterous Controllers | arXiv | project / github |
| 2026-09-07 | Monocular Human Video, Tactile Completion in Simulation, No Robot Data | Tsinghua University | Dex-X: Learning Visual-Tactile Dexterous Manipulation From Human Videos with Simulated Interaction | arXiv | project |
| 2026-09-02 | Internet Video Retrieval, Actor-Centric 3D Hand Trajectories, Dexterous Policies | Rice University | RoboTok: An Internet-Scale Data Engine for Human Demonstration Retrieval and Dexterous Manipulation Learning | arXiv | project / models+evaluation data |
| 2026-09-01 | One Human Demo, Contact-Centric Sim-to-Real, Cross-Object Transfer | Stanford University | One Demonstration, Many Objects: Generalizing Manipulation via Local Contact Geometry | arXiv | project |
| 2026-08-23 | Egocentric Forecasting, Explicit Manipulation Plans, 651k Windows, 111 Tasks | Institute of Computing Technology, CAS | EMPIRE: Explicit Manipulation Planning as a Learnable Intermediate Representation for Egocentric Hand-Motion Forecasting | arXiv | github |
| 2026-08-15 | Egocentric Video, Vision-to-Touch, 5.7M Image-Tactile Pairs | Shanghai Qi Zhi Institute | EgoTac: In-the-wild Tactile Prediction from Egocentric Vision | arXiv | paper |
| 2026-08-07 | Monocular Video, Contact-Consistent, Retargeting, Sim-to-Real | Nanjing University | C2Dex: Contact-Consistent Reconstruction and Retargeting for Dexterous Manipulation from Monocular Video | arXiv | project |
| 2026-08-04 | Egocentric Video Retrieval, Cross-Embodiment, Similarity Mining | University of Tokyo | SiMDex: Mining Similar Egocentric Videos for Cross-Embodiment Dexterous Manipulation | arXiv | paper |
| 2026-07-30 | Ambient Capture, Hand-Object Interaction, Full-Body, Tactile, 150 Hours | Nanyang Technological University | ACE-Data-0: Human-Centric Ambient Capture as Embodied Data Engine | arXiv | project |
| 2026-06-20 | Generative World Model, Egocentric Hand Data, Scalable Synthesis | Shanghai Innovation Institute | Wh0: Generative World Models as Scalable Sources of Egocentric Human Hand Manipulation Data | arXiv | paper |
| 2026-06-17 | Human Video, 4D Reconstruction, Retargeting, DexHand Data | UC Berkeley | Do as I Do: Dexterous Manipulation Data from Everyday Human Videos | arXiv | project / github |
| 2026-06-15 | Monocular Human Video, 4D Reconstruction, Sim-to-Real | Zhejiang University | V2P-Manip: Learning Dexterous Manipulation from Monocular Human Videos | arXiv | paper |
| 2026-06-10 | Internet Video, Intent Model, Embodiment-Agnostic, Sim-to-Real | UIUC | LUCID: Learning Embodiment-Agnostic Intent Models from Unstructured Human Videos for Scalable Dexterous Robot Skill Acquisition | arXiv | project |
| 2026-06-10 | Egocentric Video, High-Fidelity Robot Demonstrations, Residual RL | Georgia Institute of Technology | EgoEngine: From Egocentric Human Videos to High-Fidelity Dexterous Robot Demonstrations | arXiv | paper |
| 2026-06-07 | Single Human Video, Digital Twin, Residual RL, Sim-to-Real | Georgia Tech | Video2Sim2Real: Full-Stack Autonomous Dexterous Skill Acquisition from a Single Human Video | arXiv | project |
| 2026-02-09 | RGB Video, Dexterous Policies, Human Video | Carnegie Mellon | Dexterous Manipulation Policies from RGB Human Videos via 3D Hand-Object Trajectory Reconstruction | arXiv | project |
| 2026-01-04 | Single RGB-D Demo, Bimanual DexHands, Residual RL, Assembly | ByteDance Seed | DemoBot: Efficient Learning of Bimanual Manipulation with Dexterous Hands From Third-Person Human Videos | arXiv | project |
| 2025-10-09 | Human Videos, Bimanual, Generated Videos | Shanghai AI Lab | DexMan | arXiv | paper |
| 2025-09-11 | Scalable Exploration, Reference-Scoped, Neural Control | Georgia Tech | Dexplore: Scalable Neural Control for Dexterous Manipulation from Reference-Scoped Exploration | CoRL 2025 | paper |
| 2025-07-02 | Manipulation Types, Teleoperation, Dexterity | Tsinghua | TypeTele: Releasing Dexterity in Teleoperation by Dexterous Manipulation Types | IROS 2025 | paper |
| 2025-04-08 | Egocentric Video, Manipulation Priors, Affordance | ETH Zurich | MAPLE: Encoding Dexterous Robotic Manipulation Priors Learned From Egocentric Videos | arXiv | paper |
| 2025-03-10 | GeoRT, Neural Retargeting, 1kHz | UC Berkeley | Geometric Retargeting: A Principled, Ultrafast Neural Hand Retargeting Algorithm | arXiv | project / github |
| 2024-10-31 | Egocentric Video, Imitation, Scaling | Georgia Tech | EgoMimic | arXiv | project |
| 2024-04-24 | Human Videos, Visuomotor, Sim2Real | UC San Diego | ViViDex: Learning Vision-based Dexterous Manipulation from Human Videos | ICRA 2025 | project |
| 2023-12-05 | Functional Grasping, Affordance, Zero-Shot | UC Berkeley | Dexterous Functional Grasping | CoRL 2023 | paper |
| 2023-09-06 | Data Reuse, Bootstrapping, Real-World RL | Google DeepMind | REBOOT: Reuse Data for Bootstrapping Efficient Real-World Dexterous Manipulation | CoRL 2023 | paper |
| 2022-02-21 | Human Video, Telekinesis, Dexterous Hand | Stanford | Robotic Telekinesis: Learning a Robotic Hand Imitator by Watching Humans on YouTube | RSS 2022 | project |
| 2021-08-12 | Human Video, Retargeting, DexHand | UC San Diego | DexMV: Imitation Learning for Dexterous Manipulation from Human Videos | ECCV 2022 | project |
🛠️ 4. Infrastructure
Reusable simulators, benchmark suites, datasets, robot descriptions, and training resources.
4.1 Simulators
GPU-Accelerated
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-06-21 | GPU Tactile Simulation, Multi-Sensor, 20k Envs, XHand1 | Carnegie Mellon | Tactile Genesis: Exploring Tactile Sensors at Scale for Learning Dexterous Tasks | arXiv | project / github |
| 2026-06-17 | Tactile Simulation, Shared Latent, Zero-Shot Sim-to-Real, Isaac Lab | ETH Zurich | TactSpace: Learning a Physics-enriched Shared Latent Space for Tactile Sim-to-Real Transfer | IROS 2026 | project |
| 2026-05-23 | Real-Time Video Simulation, Causal Diffusion, Hand-Object Interaction | UC Berkeley | DexSIM: Real-time Dexterous Simulation with Unified Causal Video Diffusion | arXiv | paper |
| 2026-04-22 | Tactile Simulation, Lightweight Rendering, Dexterous Policy Learning | ShanghaiTech University | ETac: A Lightweight and Efficient Tactile Simulation Framework for Learning Dexterous Manipulation | arXiv | project |
| 2025-11-03 | Generative Simulation, Cross-Hand Morphologies, Scalable Training | University of Hong Kong | GenDexHand: Generative Simulation for Dexterous Hands | arXiv | paper |
| 2025-04-17 | Tactile Simulation, GPU, Vision-Based Touch | Peking University | Taccel: Scaling Up Vision-based Tactile Robotics via High-performance GPU Simulation | NeurIPS 2025 Spotlight | project / github |
| 2024-06-14 | Isaac Lab, GPU Sim, RL Environments | NVIDIA | Isaac Lab | GitHub | github / docs |
| 2021-08-24 | GPU Physics, Massive RL, Dexterous Tasks | NVIDIA | Isaac Gym: High Performance GPU-Based Physics Simulation for Robot Learning | NeurIPS 2021 | paper |
| 2021-08-01 | Isaac Sim, Omniverse, Robotics Simulation | NVIDIA | Isaac Sim | Website | docs |
CPU-based & High-Fidelity Physics
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-05-15 | MuJoCo Toolkit, Task-Oriented Dexterity, Multi-Hand Benchmark | Institute of Automation, CAS | DexJoCo: A Benchmark and Toolkit for Task-Oriented Dexterous Manipulation on MuJoCo | arXiv | project |
| 2020-03-19 | SAPIEN, Manipulation, Simulation | UC San Diego | SAPIEN: A SimulAted Part-Based Interactive ENvironment | CVPR 2020 | project / github |
| 2016-10-27 | PyBullet, Robotics Simulation, Open Source | Erwin Coumans | PyBullet | GitHub | docs / pypi |
| 2012-12-11 | MuJoCo, Contact Dynamics, Model-Based Control | University of Washington | MuJoCo: A Physics Engine for Model-Based Control | IROS 2012 | website / github |
4.2 Benchmarks & Datasets
Dexterous Grasping Datasets
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-07-22 | Language-Guided, Multi-Embodiment, 2.5M Grasps, Clutter | University of Toronto | SeededGrasp: Language-Guided Grasping in Complex Scenes with Multiple Embodiments | arXiv | project / github |
| 2026-06-22 | Autonomous Real-World Collection, 3,593 Trials, Success+Failure Labels | Seoul National University | AutoDex: An Automated Real-World System for Dexterous Grasping Data Collection | arXiv | project |
| 2026-04-16 | Paired Human+Robot Grasps, 100 Objects, 2.1K Sequences, Tactile | Seoul National University | HRDexDB: A Paired Human-Robot Dataset for Cross-Embodiment Dexterous Grasping | arXiv | project / github / dataset |
| 2025-04-26 | Grasp Taxonomy, Type-Conditional, 10.7k Objects, 9.5M Grasps, 31 Grasp Types | Shanghai AI Lab / Peking | Dexonomy: Synthesizing All Dexterous Grasp Types in a Grasp Taxonomy | RSS 2025 | paper |
| 2023-10-24 | Multi-Object, DexHand, Synthetic Dataset | Peking University | Grasp Multiple Objects with One Hand | RA-L 2024 | project |
| 2022-10-06 | Large-Scale, DexHand, Grasp Synthesis | Peking University | DexGraspNet: A Large-Scale Robotic Dexterous Grasp Dataset for General Objects Based on Simulation | ICRA 2023 | project / github |
| 2022-10-03 | Hand-Agnostic, MultiDex, Grasp Synthesis | BIGAI | GenDexGrasp: Generalizable Dexterous Grasping | ICRA 2023 | project / github |
| 2021-04-09 | Hand-Object, RGB-D, Pose, YCB | NVIDIA | DexYCB: A Benchmark for Capturing Hand Grasping of Objects | CVPR 2021 | project |
| 2020-08-25 | Human Grasp, Object Pose, Contact | University of Tuebingen | GRAB: A Dataset of Whole-Body Human Grasping of Objects | ECCV 2020 | project |
| 2019-07-02 | Hand-Object, 3D Reconstruction, HO-3D | IIT Delhi | HOnnotate: A Method for 3D Annotation of Hand and Object Poses | CVPR 2020 | project |
Hand-Object & Bimanual Datasets
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-08-23 | Bimanual Hand Forecasting, 651k Windows, 111 Tasks, Plan Supervision | Institute of Computing Technology, CAS | EMPIRE: Explicit Manipulation Planning as a Learnable Intermediate Representation for Egocentric Hand-Motion Forecasting | arXiv | github |
| 2026-07-30 | Human HOI, Articulated Hands, Tactile, 75k Episodes, 150 Hours | Nanyang Technological University | ACE-Data-0: Human-Centric Ambient Capture as Embodied Data Engine | arXiv | project |
| 2026-07-28 | Robot-Free, Bimanual UMI, 2k Hours, Six-View, Replay-Validated | Simple AI | HiFi-UMI: Learning Deployable Manipulation Policies from High-Fidelity UMI Data Alone | arXiv | project / dataset |
| 2026-06-30 | Visual-Tactile-Action, Humanoid, 6k Trajectories | Authors | RoboTacDex: A Dexterous Visual-Tactile-Action Dataset for Humanoid Manipulation | arXiv | paper |
| 2026-06-08 | Bimanual UMI, 8,434 Hours, 1.20M Episodes, 119 Tasks | AI Robot Association | YUBI: Yielding Universal Bidigital Interface for Bimanual Dexterous Manipulation at Scale | ICRA 2026 Workshop | project / hardware / software |
| 2025-10-17 | Real+Synthetic Human HOI, 7k Hours, Contact+Force Annotations | University of Michigan | DexCanvas: Bridging Human Demonstrations and Robot Learning for Dexterous Manipulation | arXiv | paper |
| 2025-09-05 | Egocentric Video, 1,107 Hours, Hand Pose, Action Primitives | University of Texas at Dallas | OpenEgo: A Large-Scale Multimodal Egocentric Dataset for Dexterous Manipulation | arXiv | paper |
| 2024-03-28 | Bimanual, Hand-Object, Complex Tasks | Shanghai Jiao Tong University | OAKINK2: A Dataset of Bimanual Hands-Object Manipulation in Complex Task Completion | CVPR 2024 | project / github |
| 2024-02-21 | Human-Like Robot Grasps, Multi-View, Multimodal, Teleoperation | ShanghaiTech University | RealDex: Towards Human-like Grasping for Robotic Dexterous Hand | IJCAI 2024 | project |
| 2022-04-28 | Bimanual, Articulated Objects, Contact | ETH Zurich | ARCTIC: A Dataset for Dexterous Bimanual Hand-Object Manipulation | CVPR 2023 | project |
Teleoperation & Task Benchmarks
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-08-19 | Chemistry Lab, Real+Simulation, Hierarchical Skills, DexHand Benchmark | University of Science and Technology of China | LabDex: A Hierarchical Benchmark for Dexterous Manipulation in Laboratories | arXiv | project |
| 2026-08-12 | Synthetic-to-Real Challenge, Data Generation, Physical Evaluation | Shenzhen Loop Area Institute | RoboSynChallenge: Mastering Real-World Dexterity via Generalizing Synthesized Manipulation Skills | NeurIPS 2026 Competition Track | benchmark / github |
| 2026-08-12 | Human-to-Robot Hand Editing, 200M Instances, 26 URDFs | Shanghai Jiao Tong University | HandEdit: A Unified Benchmark for Egocentric Human-to-Robot Dexterous Hand Image Editing | Technical Report | project / github |
| 2026-07-15 | Industrial Assembly, Multimodal Imitation, Hardware+Software Benchmark | Analog Devices | Industrial Dexterity Benchmark: A Hardware-Software Benchmarking Platform for Industrial Dexterous Manipulation | arXiv | paper |
| 2026-07-10 | Tactile-Guided Transfer, Single+Bimanual, Benchmark | Authors | TactiDex: A Real-World Tactile-Guided Benchmark for Human-Like Dexterous Manipulation | arXiv | project |
| 2026-07-09 | 100 Tasks, 6 DexHands, 3,180 Demos, Multi-Embodiment | UNC Chapel Hill | DexVerse: A Modular Benchmark for Multi-Task, Multi-Embodiment Dexterous Manipulation | arXiv | project / github |
| 2026-06-30 | Humanoid DexHands, Chemistry Lab, Precision Benchmark | Authors | Labimus: A Simulation and Benchmark for Humanoid Dexterous Manipulation in Chemical Laboratory | arXiv | project |
| 2026-06-17 | Full-Hand Tactile, 10M RGB, 7.8M Tactile, 226 Tasks | Beihang University | HT-Bench: Benchmarking and Learning Dexterous Full-Hand Tactile Representations with Egocentric Vision | arXiv | paper |
| 2026-05-15 | MuJoCo, Task-Oriented Dexterity, Toolkit+Benchmark | Institute of Automation, CAS | DexJoCo: A Benchmark and Toolkit for Task-Oriented Dexterous Manipulation on MuJoCo | arXiv | project |
| 2026-04-10 | Anthropomorphic Hands, Taxonomy-Grounded Tasks, Real+Simulation | ETH Zurich | A Benchmark of Dexterity for Anthropomorphic Robotic Hands | arXiv | project / github |
| 2025-04-26 | Unified Platform, Simulation, Benchmark, 20+ Institutions | Cornell / 20+ institutions | RoboVerse: Towards a Unified Platform, Dataset and Benchmark for Scalable and Generalizable Robot Learning | RSS 2025 | project / github |
| 2025-02-11 | In-Grasp Manipulation, Benchmark, Dexterous Fingers | Tsinghua | Robotic In-Hand Manipulation for Large-Range Precise Object Movement: The RGMC Champion Solution | RA-L | project |
| 2024-03-19 | In-the-Wild, Large-Scale, Robot Data, 76k Trajectories, 350 Hours | Stanford / 10 institutions | DROID: A Large-Scale In-The-Wild Robot Manipulation Dataset | arXiv | project |
| 2020-04-15 | Dexterous Hand, Offline RL, Adroit | UC Berkeley | D4RL: Datasets for Deep Data-Driven Reinforcement Learning | arXiv | github |
| 2019-10-24 | Manipulation Benchmark, Meta-World, RL | Stanford | Meta-World: A Benchmark and Evaluation for Multi-Task and Meta Reinforcement Learning | CoRL 2019 | github |
4.3 Enabling Methods & System Utilities
Adjacent tasks that often determine whether a dexterous manipulation system can be initialized, transferred, sensed, calibrated, and evaluated reliably.
Grasp & Initialization
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-08-20 | Contact Topology, Functional Grasp Types, Object-Agnostic Training | CEA-List | CoToGrasp: Contact-Topology-Conditioned Dexterous Grasp Synthesis via Canonical Workspace Learning | ECCV 2026 | project / github |
| 2026-08-20 | Object-Agnostic Grasping, Generative Contacts, Multi-Gripper | CEA-List | GOAG: Generative and Object-Agnostic Grasp Planner for Dexterous Robotic Manipulation | IROS 2026 | project / github |
| 2026-08-06 | 3D Visuo-Tactile Fusion, Contact-Aware Grasping, Adaptive Refinement | Peking University | AdaDexGrasp: Adaptive Dexterous Grasping via 3D Visuo-Tactile Representation Fusion | ECCV 2026 | paper |
| 2026-07-22 | Language-Guided, Multi-Embodiment, Executable Grasp, Clutter | University of Toronto | SeededGrasp: Language-Guided Grasping in Complex Scenes with Multiple Embodiments | arXiv | project / github |
| 2026-07-13 | Flow Matching, URDF Graph, Cross-Hand, Executable Grasp | KAIST | GraspGraphNet: Graph-Structured Multi-Embodiment Dexterous Grasp Generation | arXiv | project |
| 2026-07-06 | Human Grasp Prior, Multi-Mode, Cross-Scale, 3.2M Synthetic Grasps | Tsinghua University | HUGS: Guiding Unified Dexterous Grasp Synthesis Across Modes and Scales via Learned Human Priors | arXiv | project |
| 2026-07-03 | Tactile MPC, Contact Coordination, Uncertainty, 15k Simulated Grasps | Tsinghua University | CoorGrasp: Coordinated Contact Control for Adaptive Dexterous Grasping Under Uncertainty | ICRA 2026 | project |
| 2026-03-01 | Differentiable Digital Twin, Mass Identification, Force-Aware Grasping | University of Southern California | D-REX: Differentiable Real-to-Sim-to-Real Engine for Learning Dexterous Grasping | ICLR 2026 | paper |
| 2025-08-20 | Force Closure, Differentiable Optimization, Grasp Synthesis | ETH Zurich | GraspQP: Differentiable Optimization of Force Closure for Diverse and Robust Dexterous Grasping | IROS 2025 | paper |
| 2025-06-17 | Clutter, Sim-to-Real, Dexterous Grasping | Tsinghua | ClutterDexGrasp: A Sim-to-Real System for General Dexterous Grasping in Cluttered Scenes | CoRL 2025 | project |
| 2025-04-26 | Grasp Taxonomy, Type-Conditional, 10.7k Objects, 9.5M Grasps, 31 Grasp Types | Shanghai AI Lab / Peking | Dexonomy: Synthesizing All Dexterous Grasp Types in a Grasp Taxonomy | RSS 2025 | paper |
| 2025-04-07 | Robust Grasping, Single-View, Adaptive | Seoul National University | RobustDexGrasp: Robust Dexterous Grasping of General Objects from Single-view Perception | CoRL 2025 | paper |
| 2025-03-06 | Geometric Algebra, SE(3) Equivariant, Diffusion | Georgia Tech | GAGrasp: Geometric Algebra Diffusion for Dexterous Grasping | ICRA 2025 | paper |
| 2024-10-02 | Cross-Embodiment, Unified Representation, D(R,O) | Tsinghua | (R,O) Grasp: A Unified Representation of Robot and Object Interaction for Cross-Embodiment Dexterous Grasping | ICRA 2025 | paper |
| 2023-10-24 | Multi-Object, DexHand, Synthetic Dataset | Peking University | Grasp Multiple Objects with One Hand | RA-L 2024 | project |
| 2022-10-06 | Large-Scale, DexHand, Grasp Synthesis | Peking University | DexGraspNet: A Large-Scale Robotic Dexterous Grasp Dataset for General Objects Based on Simulation | ICRA 2023 | project / github |
| 2022-10-03 | Hand-Agnostic, MultiDex, Grasp Synthesis | BIGAI | GenDexGrasp: Generalizable Dexterous Grasping | ICRA 2023 | project / github |
| 2021-01-08 | Initial Grasp, Motion Planning, TriFinger | TTIC | Grasp and Motion Planning for Dexterous Manipulation for the Real Robot Challenge | arXiv | challenge |
Retargeting
Perception & Tracking
Evaluation & Robustness
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-08-21 | Tactile Security, Contactless EMI, 15 Sensors, Two DexHands | Zhejiang University | GhostTac: Manipulating Tactile Sensors without Physical Contact | ACM CCS 2026 | project |
| 2026-01-06 | Zero-Shot Sim2Real, Force-Based Grasping, Tactile | CMU | Closing the Reality Gap: Zero-Shot Sim-to-Real Deployment for Dexterous Force-Based Grasping and Manipulation | arXiv | paper |
| 2024-12-13 | Force Safety, Implicit Tactile, Vision-Guided | CUHK | SafeDiff: Ensuring Force Safety in Vision-Guided Robotic Manipulation via Implicit Tactile Calibration | CoRL 2025 | paper |
| 2022-10-10 | Adaptation, Domain Randomization, Disturbance | UC Berkeley | HORA: In-Hand Object Rotation via Rapid Motor Adaptation | arXiv | paper |
| 2020-04-15 | Offline RL, Adroit, Benchmark | UC Berkeley | D4RL: Datasets for Deep Data-Driven Reinforcement Learning | arXiv | github |
| 2020-01-09 | Benchmark, YCB Objects, In-Hand Pose | KTH | Benchmarking In-Hand Manipulation | RA-L 2020 | paper |
| 2019-10-16 | Rubik's Cube, Vision, Domain Randomization | OpenAI | Solving Rubik's Cube with a Robot Hand | arXiv | blog |
| 2018-08-01 | In-Hand Manipulation, Domain Randomization | OpenAI | Learning Dexterous In-Hand Manipulation | IJRR 2020 | blog |
📚 5. Surveys & Reviews
| Date | Keywords | Institute (first) | Paper / Resource | Publication | Others |
|---|---|---|---|---|---|
| 2026-05-13 | Dexterous Hand Intelligence, Hardware+Sensing+Control+Data, Survey | University of Liverpool | Towards Robotic Dexterous Hand Intelligence: A Survey | arXiv | paper |
| 2025-11-30 | Tactile Robotics History, 150 Reviews, Future Directions | University of Bristol | Tactile Robotics: Past and Future | IJRR 2026 | journal |
| 2025-07-16 | Embodied Dexterity, Data Collection, Skill Learning, Survey | Zhejiang University | The Developments and Challenges towards Dexterous and Embodied Robotic Manipulation: A Survey | arXiv | paper |
| 2025-04-04 | Imitation Learning, Teleoperation, Survey | Tianjin University | Dexterous Manipulation through Imitation Learning: A Survey | arXiv | html |
| 2021-05-18 | Tactile Sensing, Review, Robots | University of Bristol | A Review of Tactile Sensors for Robotic Applications | Sensors 2021 | paper |
| 2019-05-03 | Robotic Hands, Actuation, Softness, Century-Scale Review | University of Pisa | A Century of Robotic Hands | Annual Review of Control, Robotics, and Autonomous Systems 2019 | publication |
| 2018-12-01 | Dexterous Manipulation, Hand-Centric Taxonomy | Stanford | A Hand-Centric Classification of Human and Robot Dexterous Manipulation | IEEE ToH 2018 | paper |
| 2015-12 | Tactile Hand Sensing, Feedback Control, Review | Sorbonne University | Tactile sensing in dexterous robot hands — Review | Robotics and Autonomous Systems 2015 | publication |
Acknowledgement
This list follows the single-file, compact-table style of Awesome-UMI and cross-checks scope against related public resources:
- Dexterous-Manipulation
- awesome-humanoid-manipulation
- Awesome-Robotics-Manipulation
- Awesome-Touch
- awesome-robot-descriptions
Citation
If this repository helps your work, please cite or link it as:
@misc{awesome_dexterous_manipulation,
  title        = {Awesome-Dexterous-Manipulation},
  author       = {Xinhai Chang},
  year         = {2026},
  howpublished = {\url{https://github.com/chang-xinhai/Awesome-Dexterous-Manipulation}},
}