Official repo of Towards Embodied AI with MuscleMimic: Unlocking full-body musculoskeletal motor learning at scale
See the code


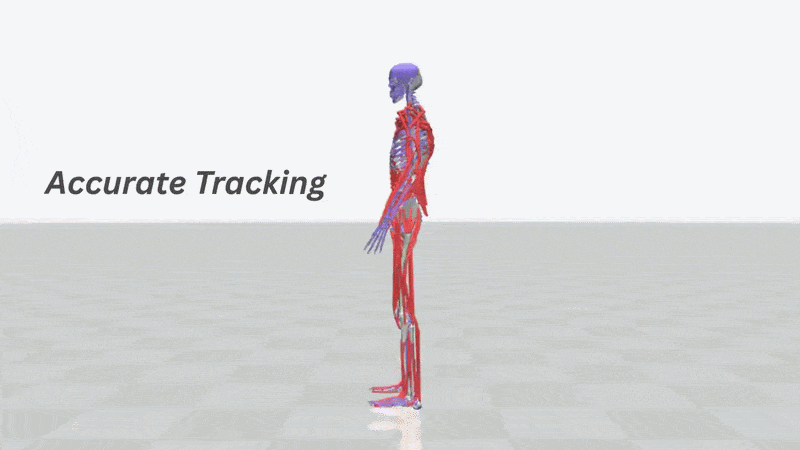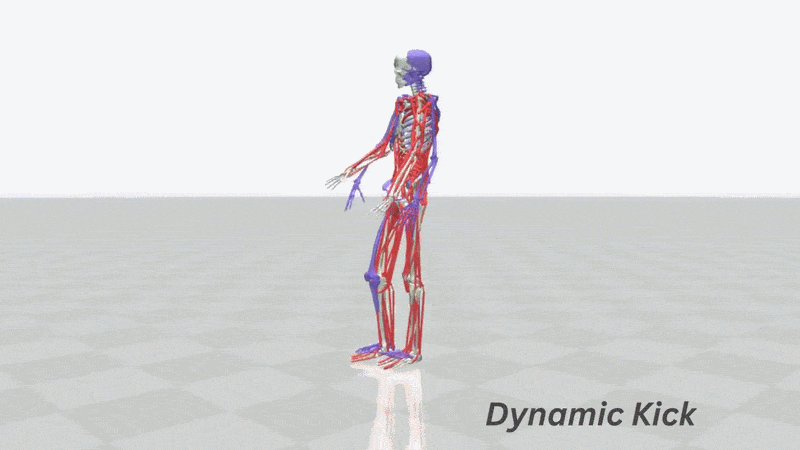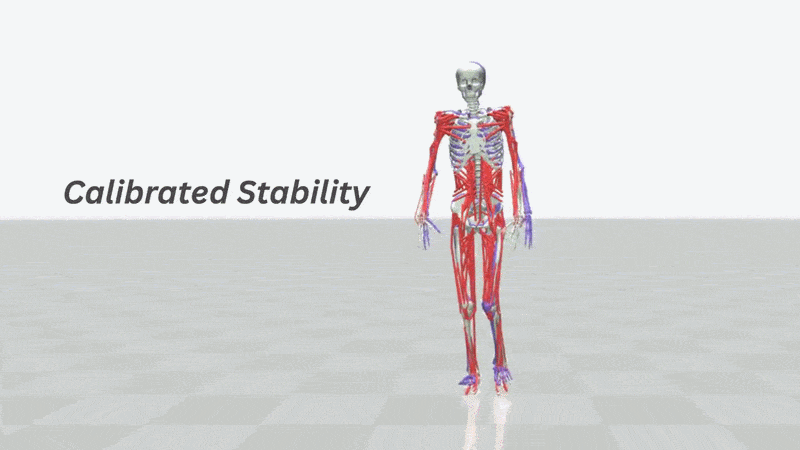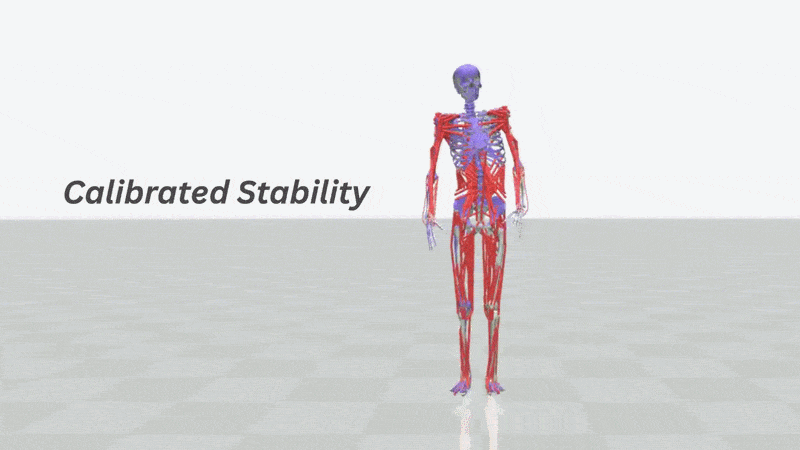
MuscleMimic is a JAX-based motion imitation learning benchmark for biomechanically accurate, muscle-actuated models. It targets full-body locomotion and manipulation with GPU-parallel training, MuJoCo/MJWarp dynamics, and retargeted motion datasets.
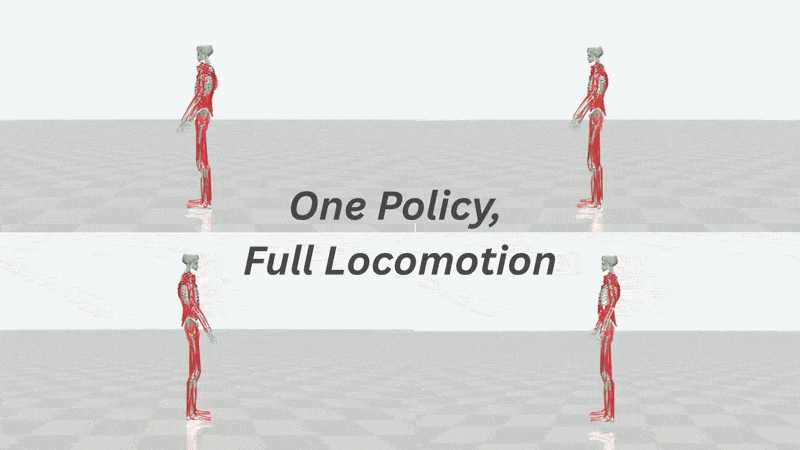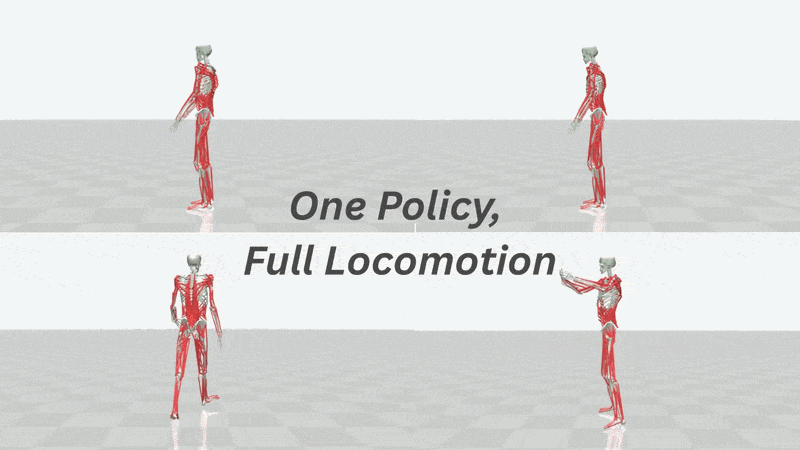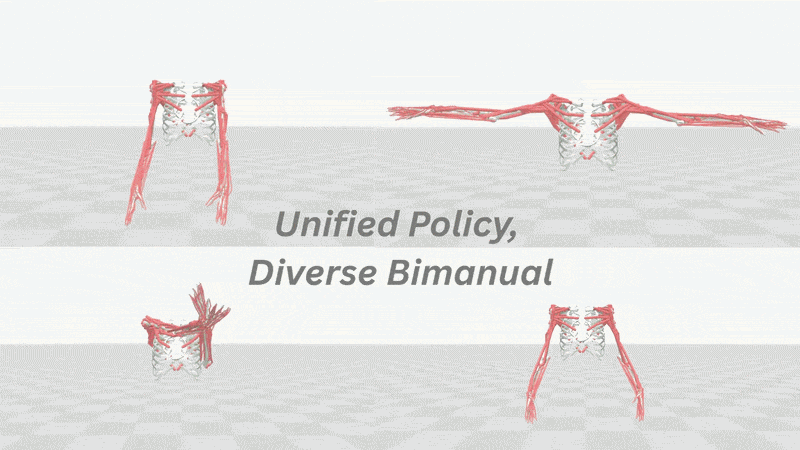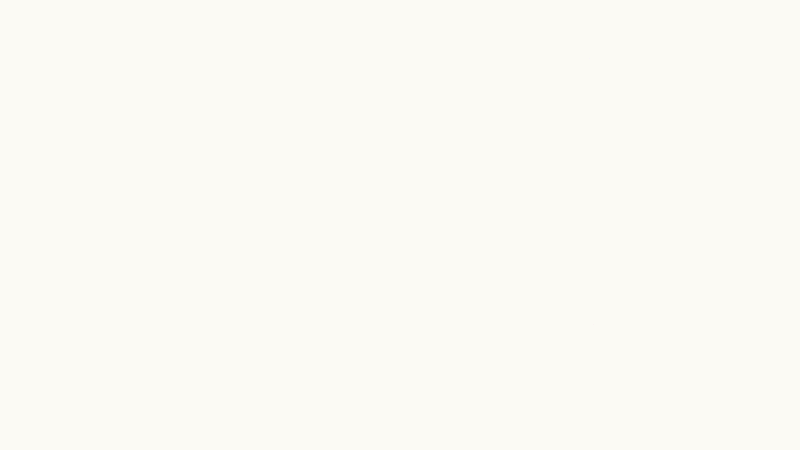
| Model | Type | Joints | Muscles | DoFs | Focus |
|---|---|---|---|---|---|
| MyoBimanualArm | Fixed-base | 76 (36*) | 126 (64*) | 54 (14*) | Upper-body manipulation |
| MyoFullBody | Free-root | 123 (83*) | 416 (354*) | 72 (32*) | Locomotion and manipulation |
*Configurations with finger muscles disabled.
Training requires Linux with an NVIDIA GPU. Inference and evaluation are supported on Linux and macOS.
curl -LsSf https://astral.sh/uv/install.sh | sh
git clone https://github.com/amathislab/musclemimic
cd musclemimic
uv sync --extra cuda
The first-time path uses pre-retargeted demo motions, so no AMASS download is needed. The demo dataset is gated on Hugging Face: amathislab/demo_dataset.
uv run hf auth login
uv run python -c "from musclemimic.utils.demo_cache import setup_demo_for_bimanual; setup_demo_for_bimanual()"
uv run python -c "from musclemimic.utils.demo_cache import setup_demo_for_myo_fullbody; setup_demo_for_myo_fullbody()"
Evaluate a released MyoFullBody checkpoint with the MuJoCo viewer:
uv run mjpython fullbody/eval.py \
  --path hf://amathislab/mm-10m-2 \
  --motion_path KIT/314/walking_medium09_poses \
  --use_mujoco \
  --stochastic \
  --eval_seed 0 \
  --n_steps 1000 \
  --mujoco_viewer
Start a short demo training run. These configs log to Weights & Biases with
wandb.mode=online by default:
uv run bimanual/experiment.py --config-name=conf_bimanual_demo
uv run fullbody/experiment.py --config-name=conf_fullbody_demo
On Linux, a regular python entrypoint is sufficient for viewer-based MuJoCo
commands. On macOS, use mjpython.
| Model | Checkpoints | Retargeted dataset |
|---|---|---|
| MyoBimanualArm | amathislab/mm-bimanual-v0 | amathislab/musclemimic-bimanual-retargeted |
| MyoFullBody | amathislab/mm-fullbody-base | amathislab/musclemimic-retargeted |
Pre-retargeted GMR caches can be downloaded directly:
uv run musclemimic-download-gmr-caches --dataset-group KIT_KINESIS_TRAINING_MOTIONS
uv run musclemimic-download-gmr-caches --dataset-group AMASS_BIMANUAL_TRAIN_MOTIONS --env-name MyoBimanualArm
For full AMASS setup, C3D conversion, finetuning from checkpoints, and viewer workflows, see Detailed Workflows.
make install-dev
make precommit-install
make ci
pre-commit currently targets a curated subset of files while the repository is
being migrated toward broader coverage. make lint and make format follow
that same scoped set rather than reformatting the whole repository.
If you use this code in your research, please cite:
@article{Li2026MuscleMimic,
  title={Towards Embodied AI with MuscleMimic: Unlocking full-body musculoskeletal motor learning at scale},
  author={Li, Chengkun and Wang, Cheryl and Ziliotto, Bianca and Simos, Merkourios and Kovecses, Jozsef and Durandau, Guillaume and Mathis, Alexander},
  journal={arXiv preprint arXiv:2603.25544},
  year={2026}
}
This project is licensed under the Apache License. Model checkpoints, datasets, SMPL-family assets, and other third-party software may be licensed separately; review each provider's terms before use.
Inspired by and built on MyoSuite, MuJoCo Warp, Kinesis, LocoMuJoCo, SMPL-X, PureJaxRL, and MuJoCo Playground.
Official repo of Towards Embodied AI with MuscleMimic: Unlocking full-body musculoskeletal motor learning at scale
See the code
MuscleMimic is a JAX-based motion imitation learning benchmark for biomechanically accurate, muscle-actuated models. It targets full-body locomotion and manipulation with GPU-parallel training, MuJoCo/MJWarp dynamics, and retargeted motion datasets.
| Model | Type | Joints | Muscles | DoFs | Focus |
|---|---|---|---|---|---|
| MyoBimanualArm | Fixed-base | 76 (36*) | 126 (64*) | 54 (14*) | Upper-body manipulation |
| MyoFullBody | Free-root | 123 (83*) | 416 (354*) | 72 (32*) | Locomotion and manipulation |
*Configurations with finger muscles disabled.
Training requires Linux with an NVIDIA GPU. Inference and evaluation are supported on Linux and macOS.
curl -LsSf https://astral.sh/uv/install.sh | sh
git clone https://github.com/amathislab/musclemimic
cd musclemimic
uv sync --extra cuda
The first-time path uses pre-retargeted demo motions, so no AMASS download is needed. The demo dataset is gated on Hugging Face: amathislab/demo_dataset.
uv run hf auth login
uv run python -c "from musclemimic.utils.demo_cache import setup_demo_for_bimanual; setup_demo_for_bimanual()"
uv run python -c "from musclemimic.utils.demo_cache import setup_demo_for_myo_fullbody; setup_demo_for_myo_fullbody()"
Evaluate a released MyoFullBody checkpoint with the MuJoCo viewer:
uv run mjpython fullbody/eval.py \
  --path hf://amathislab/mm-10m-2 \
  --motion_path KIT/314/walking_medium09_poses \
  --use_mujoco \
  --stochastic \
  --eval_seed 0 \
  --n_steps 1000 \
  --mujoco_viewer
Start a short demo training run. These configs log to Weights & Biases with
wandb.mode=online by default:
uv run bimanual/experiment.py --config-name=conf_bimanual_demo
uv run fullbody/experiment.py --config-name=conf_fullbody_demo
On Linux, a regular python entrypoint is sufficient for viewer-based MuJoCo
commands. On macOS, use mjpython.
| Model | Checkpoints | Retargeted dataset |
|---|---|---|
| MyoBimanualArm | amathislab/mm-bimanual-v0 | amathislab/musclemimic-bimanual-retargeted |
| MyoFullBody | amathislab/mm-fullbody-base | amathislab/musclemimic-retargeted |
Pre-retargeted GMR caches can be downloaded directly:
uv run musclemimic-download-gmr-caches --dataset-group KIT_KINESIS_TRAINING_MOTIONS
uv run musclemimic-download-gmr-caches --dataset-group AMASS_BIMANUAL_TRAIN_MOTIONS --env-name MyoBimanualArm
For full AMASS setup, C3D conversion, finetuning from checkpoints, and viewer workflows, see Detailed Workflows.
make install-dev
make precommit-install
make ci
pre-commit currently targets a curated subset of files while the repository is
being migrated toward broader coverage. make lint and make format follow
that same scoped set rather than reformatting the whole repository.
If you use this code in your research, please cite:
@article{Li2026MuscleMimic,
  title={Towards Embodied AI with MuscleMimic: Unlocking full-body musculoskeletal motor learning at scale},
  author={Li, Chengkun and Wang, Cheryl and Ziliotto, Bianca and Simos, Merkourios and Kovecses, Jozsef and Durandau, Guillaume and Mathis, Alexander},
  journal={arXiv preprint arXiv:2603.25544},
  year={2026}
}
This project is licensed under the Apache License. Model checkpoints, datasets, SMPL-family assets, and other third-party software may be licensed separately; review each provider's terms before use.
Inspired by and built on MyoSuite, MuJoCo Warp, Kinesis, LocoMuJoCo, SMPL-X, PureJaxRL, and MuJoCo Playground.
109 followers · starred Jul 2026






