
Mirror of the Basalt repository. All pull requests and issues should be sent to https://gitlab.com/VladyslavUsenko/basalt
C++
993
453 commits
updated Mar 22, 2026
README

Basalt
For more information see https://vision.in.tum.de/research/vslam/basalt
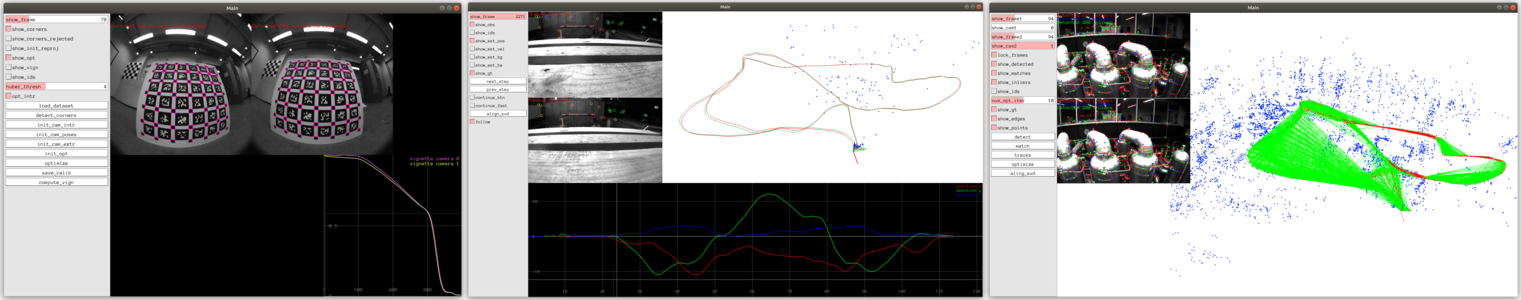
This project contains tools for:
- Camera, IMU and motion capture calibration.
- Visual-inertial odometry and mapping.
- Simulated environment to test different components of the system.
Some reusable components of the system are available as a separate header-only library (Documentation).
There is also a Github mirror of this project to enable easy forking.
Related Publications
Visual-Inertial Odometry and Mapping:
- Visual-Inertial Mapping with Non-Linear Factor Recovery, V. Usenko, N. Demmel, D. Schubert, J. Stückler, D. Cremers, In IEEE Robotics and Automation Letters (RA-L) [DOI:10.1109/LRA.2019.2961227] [arXiv:1904.06504].
Calibration (explains implemented camera models):
- The Double Sphere Camera Model, V. Usenko and N. Demmel and D. Cremers, In 2018 International Conference on 3D Vision (3DV), [DOI:10.1109/3DV.2018.00069], [arXiv:1807.08957].
Calibration (demonstrates how these tools can be used for dataset calibration):
- The TUM VI Benchmark for Evaluating Visual-Inertial Odometry, D. Schubert, T. Goll, N. Demmel, V. Usenko, J. Stückler, D. Cremers, In 2018 International Conference on Intelligent Robots and Systems (IROS), [DOI:10.1109/IROS.2018.8593419], [arXiv:1804.06120].
Calibration (describes B-spline trajectory representation used in camera-IMU calibration):
- Efficient Derivative Computation for Cumulative B-Splines on Lie Groups, C. Sommer, V. Usenko, D. Schubert, N. Demmel, D. Cremers, In 2020 Conference on Computer Vision and Pattern Recognition (CVPR), [DOI:10.1109/CVPR42600.2020.01116], [arXiv:1911.08860].
Optimization (describes square-root optimization and marginalization used in VIO/VO):
- Square Root Marginalization for Sliding-Window Bundle Adjustment, N. Demmel, D. Schubert, C. Sommer, D. Cremers, V. Usenko, In 2021 International Conference on Computer Vision (ICCV), [arXiv:2109.02182]
Installation
Binary installation from GitLab releases (Ubuntu 22.04+ amd64, MacOS 26+ arm64)
Install the latest published release into ~/.local:
curl -LsSf https://gitlab.com/VladyslavUsenko/basalt/-/raw/master/scripts/install.sh | sh
The installer places binaries in ~/.local/bin, libraries in ~/.local/lib, and data files in ~/.local/etc/basalt.
Source installation (CMake presets + vcpkg)
Clone the source code with the thirdparty/vcpkg submodule, then build with CMake presets. Install CMake (>= 3.24), Ninja, and a C++ compiler first.
git clone --recursive https://gitlab.com/VladyslavUsenko/basalt.git
cd basalt
# If you cloned without --recursive, fetch the vcpkg submodule:
# git submodule update --init thirdparty/vcpkg

# Bootstrap vcpkg once if needed:
# ./thirdparty/vcpkg/bootstrap-vcpkg.sh -disableMetrics

cmake --preset relwithdebinfo
cmake --build --preset relwithdebinfo -j8
ctest --preset relwithdebinfo
By default presets use:
thirdparty/vcpkg/scripts/buildsystems/vcpkg.cmake
On macOS, build the release preset and then package the release artifact:
cmake --preset release
cmake --build --preset release -j8
./scripts/package_macos_release.sh <tag>
Usage
- Camera, IMU and Mocap calibration. (TUM-VI, Euroc, UZH-FPV and Kalibr datasets)
- Visual-inertial odometry and mapping. (TUM-VI and Euroc datasets)
- Visual odometry (no IMU). (KITTI dataset)
- Simulation tools to test different components of the system.
- Batch evaluation tutorial (ICCV'21 experiments)
Device support
Licence
The code is provided under a BSD 3-clause license. See the LICENSE file for details. Note also the different licenses of thirdparty code.
Some improvements are ported back from the fork granite (MIT license).
Contributors


Similar repos


Languages
C++
81.0%
Python
9.1%
Shell
4.9%
CMake
4.5%
Mirror of the Basalt repository. All pull requests and issues should be sent to https://gitlab.com/VladyslavUsenko/basalt
C++
993
453 commits
updated Mar 22, 2026
README
Basalt
For more information see https://vision.in.tum.de/research/vslam/basalt
This project contains tools for:
- Camera, IMU and motion capture calibration.
- Visual-inertial odometry and mapping.
- Simulated environment to test different components of the system.
Some reusable components of the system are available as a separate header-only library (Documentation).
There is also a Github mirror of this project to enable easy forking.
Related Publications
Visual-Inertial Odometry and Mapping:
- Visual-Inertial Mapping with Non-Linear Factor Recovery, V. Usenko, N. Demmel, D. Schubert, J. Stückler, D. Cremers, In IEEE Robotics and Automation Letters (RA-L) [DOI:10.1109/LRA.2019.2961227] [arXiv:1904.06504].
Calibration (explains implemented camera models):
- The Double Sphere Camera Model, V. Usenko and N. Demmel and D. Cremers, In 2018 International Conference on 3D Vision (3DV), [DOI:10.1109/3DV.2018.00069], [arXiv:1807.08957].
Calibration (demonstrates how these tools can be used for dataset calibration):
- The TUM VI Benchmark for Evaluating Visual-Inertial Odometry, D. Schubert, T. Goll, N. Demmel, V. Usenko, J. Stückler, D. Cremers, In 2018 International Conference on Intelligent Robots and Systems (IROS), [DOI:10.1109/IROS.2018.8593419], [arXiv:1804.06120].
Calibration (describes B-spline trajectory representation used in camera-IMU calibration):
- Efficient Derivative Computation for Cumulative B-Splines on Lie Groups, C. Sommer, V. Usenko, D. Schubert, N. Demmel, D. Cremers, In 2020 Conference on Computer Vision and Pattern Recognition (CVPR), [DOI:10.1109/CVPR42600.2020.01116], [arXiv:1911.08860].
Optimization (describes square-root optimization and marginalization used in VIO/VO):
- Square Root Marginalization for Sliding-Window Bundle Adjustment, N. Demmel, D. Schubert, C. Sommer, D. Cremers, V. Usenko, In 2021 International Conference on Computer Vision (ICCV), [arXiv:2109.02182]
Installation
Binary installation from GitLab releases (Ubuntu 22.04+ amd64, MacOS 26+ arm64)
Install the latest published release into ~/.local:
curl -LsSf https://gitlab.com/VladyslavUsenko/basalt/-/raw/master/scripts/install.sh | sh
The installer places binaries in ~/.local/bin, libraries in ~/.local/lib, and data files in ~/.local/etc/basalt.
Source installation (CMake presets + vcpkg)
Clone the source code with the thirdparty/vcpkg submodule, then build with CMake presets. Install CMake (>= 3.24), Ninja, and a C++ compiler first.
git clone --recursive https://gitlab.com/VladyslavUsenko/basalt.git
cd basalt
# If you cloned without --recursive, fetch the vcpkg submodule:
# git submodule update --init thirdparty/vcpkg

# Bootstrap vcpkg once if needed:
# ./thirdparty/vcpkg/bootstrap-vcpkg.sh -disableMetrics

cmake --preset relwithdebinfo
cmake --build --preset relwithdebinfo -j8
ctest --preset relwithdebinfo
By default presets use:
thirdparty/vcpkg/scripts/buildsystems/vcpkg.cmake
On macOS, build the release preset and then package the release artifact:
cmake --preset release
cmake --build --preset release -j8
./scripts/package_macos_release.sh <tag>
Usage
- Camera, IMU and Mocap calibration. (TUM-VI, Euroc, UZH-FPV and Kalibr datasets)
- Visual-inertial odometry and mapping. (TUM-VI and Euroc datasets)
- Visual odometry (no IMU). (KITTI dataset)
- Simulation tools to test different components of the system.
- Batch evaluation tutorial (ICCV'21 experiments)
Device support
Licence
The code is provided under a BSD 3-clause license. See the LICENSE file for details. Note also the different licenses of thirdparty code.
Some improvements are ported back from the fork granite (MIT license).
Similar repos
Contributors
Languages
C++
81.0%
Python
9.1%
Shell
4.9%
CMake
4.5%