
TNY - 360 Robot source code and 3d models
See the codeSee what people are saying
README
🚀 TNY-360 V2 Kits are available in preorders, shipping early december. Get your kit here.
The repository will be updated with the V2 files in a couple of days.
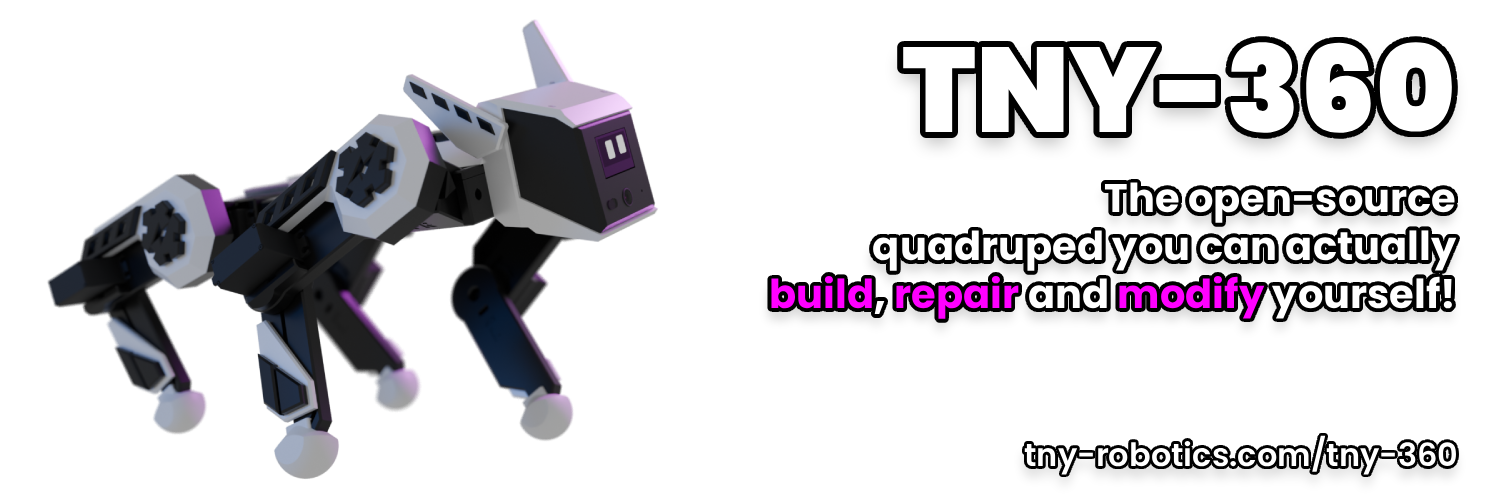
TNY-360 - Open-Source Robot Dog



The open-source quadruped you can actually build, repair and modify yourself.
🛠️ Want to build one?
👉 START HERE: The Official Step-by-Step Guide 👈
From ordering the first screw to assembling the last part, this guide covers it all.
🗂️ Quick Links (For Advanced Makers)
If you know what you are doing and just want the raw files, here is your toolkit:
- 🛒 Bill of Materials (BOM) - What to buy, tools needed, and where to find them.
- 📐 CAD & 3D Files - Grab the
.STLand.3MFfiles for your 3D printer. - ⚡ PCB Designs (Gerbers) - Files to order the custom PCBs used in the robot.
- 🧠 ESP32 Firmware - The ESP-IDF C++ firmware & drivers powering the robot.
- 🛠️ Servo Modding Tutorial - Learn the Op-Amp trick to get position-feedback on MG996R servos.
✨ Features
- 🧬 Dual-Core Architecture:
A segregated system using the ESP32-S3. Core 0 ("Reflex") runs a strict 200Hz kinematics/control loop, while Core 1 ("Brain") handles WebSockets, UI, and orchestration. - 🔄 Closed-Loop at 200Hz:
We ditched blind PWM. The TNY-360 uses digital MG996R servos modified with a custom Op-Amp buffer PCB for noise-free, high-speed position feedback. - ⚡ Zero Cable Spaghetti:
A fully modular hardware ecosystem. Dedicated PCBs (Control, Sensor, Brain, Power, etc.) communicate cleanly via standardized JST-PH cables. - 🛠️ Smart Auto-Calibration:
Features mechanical endstops for assembly validation and runtime algorithms that compensate for backlash and actuator latency. - 🧩 STEM & Expansion Ready:
Program the robot using TNY-Coder (our block-based web app) or build custom hardware modules using the dorsal I2C/Power expansion port. - 🔋 Industrial Power:
A custom 3S 18650 battery pack capable of 15A continuous discharge, featuring an integrated BMS and Fuse, for 1h+ of runtime.
⚙️ Hardware Specs
🧠 Core & Power
- MCU: ESP32-S3 N16R8 Module
- Power: 3S LiPo Battery (6x Samsung INR18650-25R)
- Monitoring: INA219 (Voltage/Current sensor)
🦵 Actuators
- Legs: 12x MG996R Servos (Must be modified for analog feedback)
- Head: 2x SG-90 Micro Servos (Ears)
- Driver: PCA9685 (16-Channel PWM)
📡 Sensors & I/O
- Vision: OV2640 Camera Module
- Distance: VL53L0X Time-of-Flight (Lidar)
- Orientation: MPU6050 6-axis IMU
- Display: SH1106 OLED (128x64)
- Audio: I2S MEMS Microphone + Speaker
📂 Repository Structure
BOM/— Bill of Materials. Detailed lists of all components, PCBs, screws, and cables, with links.CAD/— Hardware Source. FreeCAD project files and ready-to-print STLs.Electronics/PCBs/— PCB Designs. Gerber files, BOMs, and Pick'n'Place for all PCBs.Firmware/— Codebase. PlatformIO project (C++/ESP-IDF).Firmware/components/— Drivers. Custom libraries for sensors/actuators.
☕ Support the Project
TNY-360 is, and will always be, 100% free and open-source.
If you love the project, learned something new, or just want to help us build the next generation of affordable robots, consider supporting our R&D! Your tips help us buy prototyping materials (filament, PCBs, burned servos 😅) and keep the servers running.
(Even if you can't donate, simply starring this repository or sharing it with a friend is already a massive support!)
🤝 Contributing
We love contributions!
- Code: Please follow the ESP-IDF coding style.
- Hardware: Submit PRs with updated FreeCAD files or improvements.
- Found a bug? Open an Issue.
📄 License & Authors
TNY-360 is maintained by the TNY Robotics Team.
Licensed under CC BY-NC-SA 4.0.
You are free to share and adapt this material for non-commercial purposes, as long as you provide attribution and share alike.

Significant stargazers

57 followers · starred Jun 2026
Similar repos


Languages
C++
97.9%
C
1.1%
TNY - 360 Robot source code and 3d models
See the codeSee what people are saying
README
🚀 TNY-360 V2 Kits are available in preorders, shipping early december. Get your kit here.
The repository will be updated with the V2 files in a couple of days.
TNY-360 - Open-Source Robot Dog
The open-source quadruped you can actually build, repair and modify yourself.
🛠️ Want to build one?
👉 START HERE: The Official Step-by-Step Guide 👈
From ordering the first screw to assembling the last part, this guide covers it all.
🗂️ Quick Links (For Advanced Makers)
If you know what you are doing and just want the raw files, here is your toolkit:
- 🛒 Bill of Materials (BOM) - What to buy, tools needed, and where to find them.
- 📐 CAD & 3D Files - Grab the
.STLand.3MFfiles for your 3D printer. - ⚡ PCB Designs (Gerbers) - Files to order the custom PCBs used in the robot.
- 🧠 ESP32 Firmware - The ESP-IDF C++ firmware & drivers powering the robot.
- 🛠️ Servo Modding Tutorial - Learn the Op-Amp trick to get position-feedback on MG996R servos.
✨ Features
- 🧬 Dual-Core Architecture:
A segregated system using the ESP32-S3. Core 0 ("Reflex") runs a strict 200Hz kinematics/control loop, while Core 1 ("Brain") handles WebSockets, UI, and orchestration. - 🔄 Closed-Loop at 200Hz:
We ditched blind PWM. The TNY-360 uses digital MG996R servos modified with a custom Op-Amp buffer PCB for noise-free, high-speed position feedback. - ⚡ Zero Cable Spaghetti:
A fully modular hardware ecosystem. Dedicated PCBs (Control, Sensor, Brain, Power, etc.) communicate cleanly via standardized JST-PH cables. - 🛠️ Smart Auto-Calibration:
Features mechanical endstops for assembly validation and runtime algorithms that compensate for backlash and actuator latency. - 🧩 STEM & Expansion Ready:
Program the robot using TNY-Coder (our block-based web app) or build custom hardware modules using the dorsal I2C/Power expansion port. - 🔋 Industrial Power:
A custom 3S 18650 battery pack capable of 15A continuous discharge, featuring an integrated BMS and Fuse, for 1h+ of runtime.
⚙️ Hardware Specs
🧠 Core & Power
- MCU: ESP32-S3 N16R8 Module
- Power: 3S LiPo Battery (6x Samsung INR18650-25R)
- Monitoring: INA219 (Voltage/Current sensor)
🦵 Actuators
- Legs: 12x MG996R Servos (Must be modified for analog feedback)
- Head: 2x SG-90 Micro Servos (Ears)
- Driver: PCA9685 (16-Channel PWM)
📡 Sensors & I/O
- Vision: OV2640 Camera Module
- Distance: VL53L0X Time-of-Flight (Lidar)
- Orientation: MPU6050 6-axis IMU
- Display: SH1106 OLED (128x64)
- Audio: I2S MEMS Microphone + Speaker
📂 Repository Structure
BOM/— Bill of Materials. Detailed lists of all components, PCBs, screws, and cables, with links.CAD/— Hardware Source. FreeCAD project files and ready-to-print STLs.Electronics/PCBs/— PCB Designs. Gerber files, BOMs, and Pick'n'Place for all PCBs.Firmware/— Codebase. PlatformIO project (C++/ESP-IDF).Firmware/components/— Drivers. Custom libraries for sensors/actuators.
☕ Support the Project
TNY-360 is, and will always be, 100% free and open-source.
If you love the project, learned something new, or just want to help us build the next generation of affordable robots, consider supporting our R&D! Your tips help us buy prototyping materials (filament, PCBs, burned servos 😅) and keep the servers running.
(Even if you can't donate, simply starring this repository or sharing it with a friend is already a massive support!)
🤝 Contributing
We love contributions!
- Code: Please follow the ESP-IDF coding style.
- Hardware: Submit PRs with updated FreeCAD files or improvements.
- Found a bug? Open an Issue.
📄 License & Authors
TNY-360 is maintained by the TNY Robotics Team.
Licensed under CC BY-NC-SA 4.0.
You are free to share and adapt this material for non-commercial purposes, as long as you provide attribution and share alike.
Similar repos
Significant stargazers
57 followers · starred Jun 2026
Languages
C++
97.9%
C
1.1%