Official PyTorch implementation of FB-BEV & FB-OCC - Forward-backward view transformation for vision-centric autonomous driving perception
Python
797
9 commits
updated Mar 17, 2025
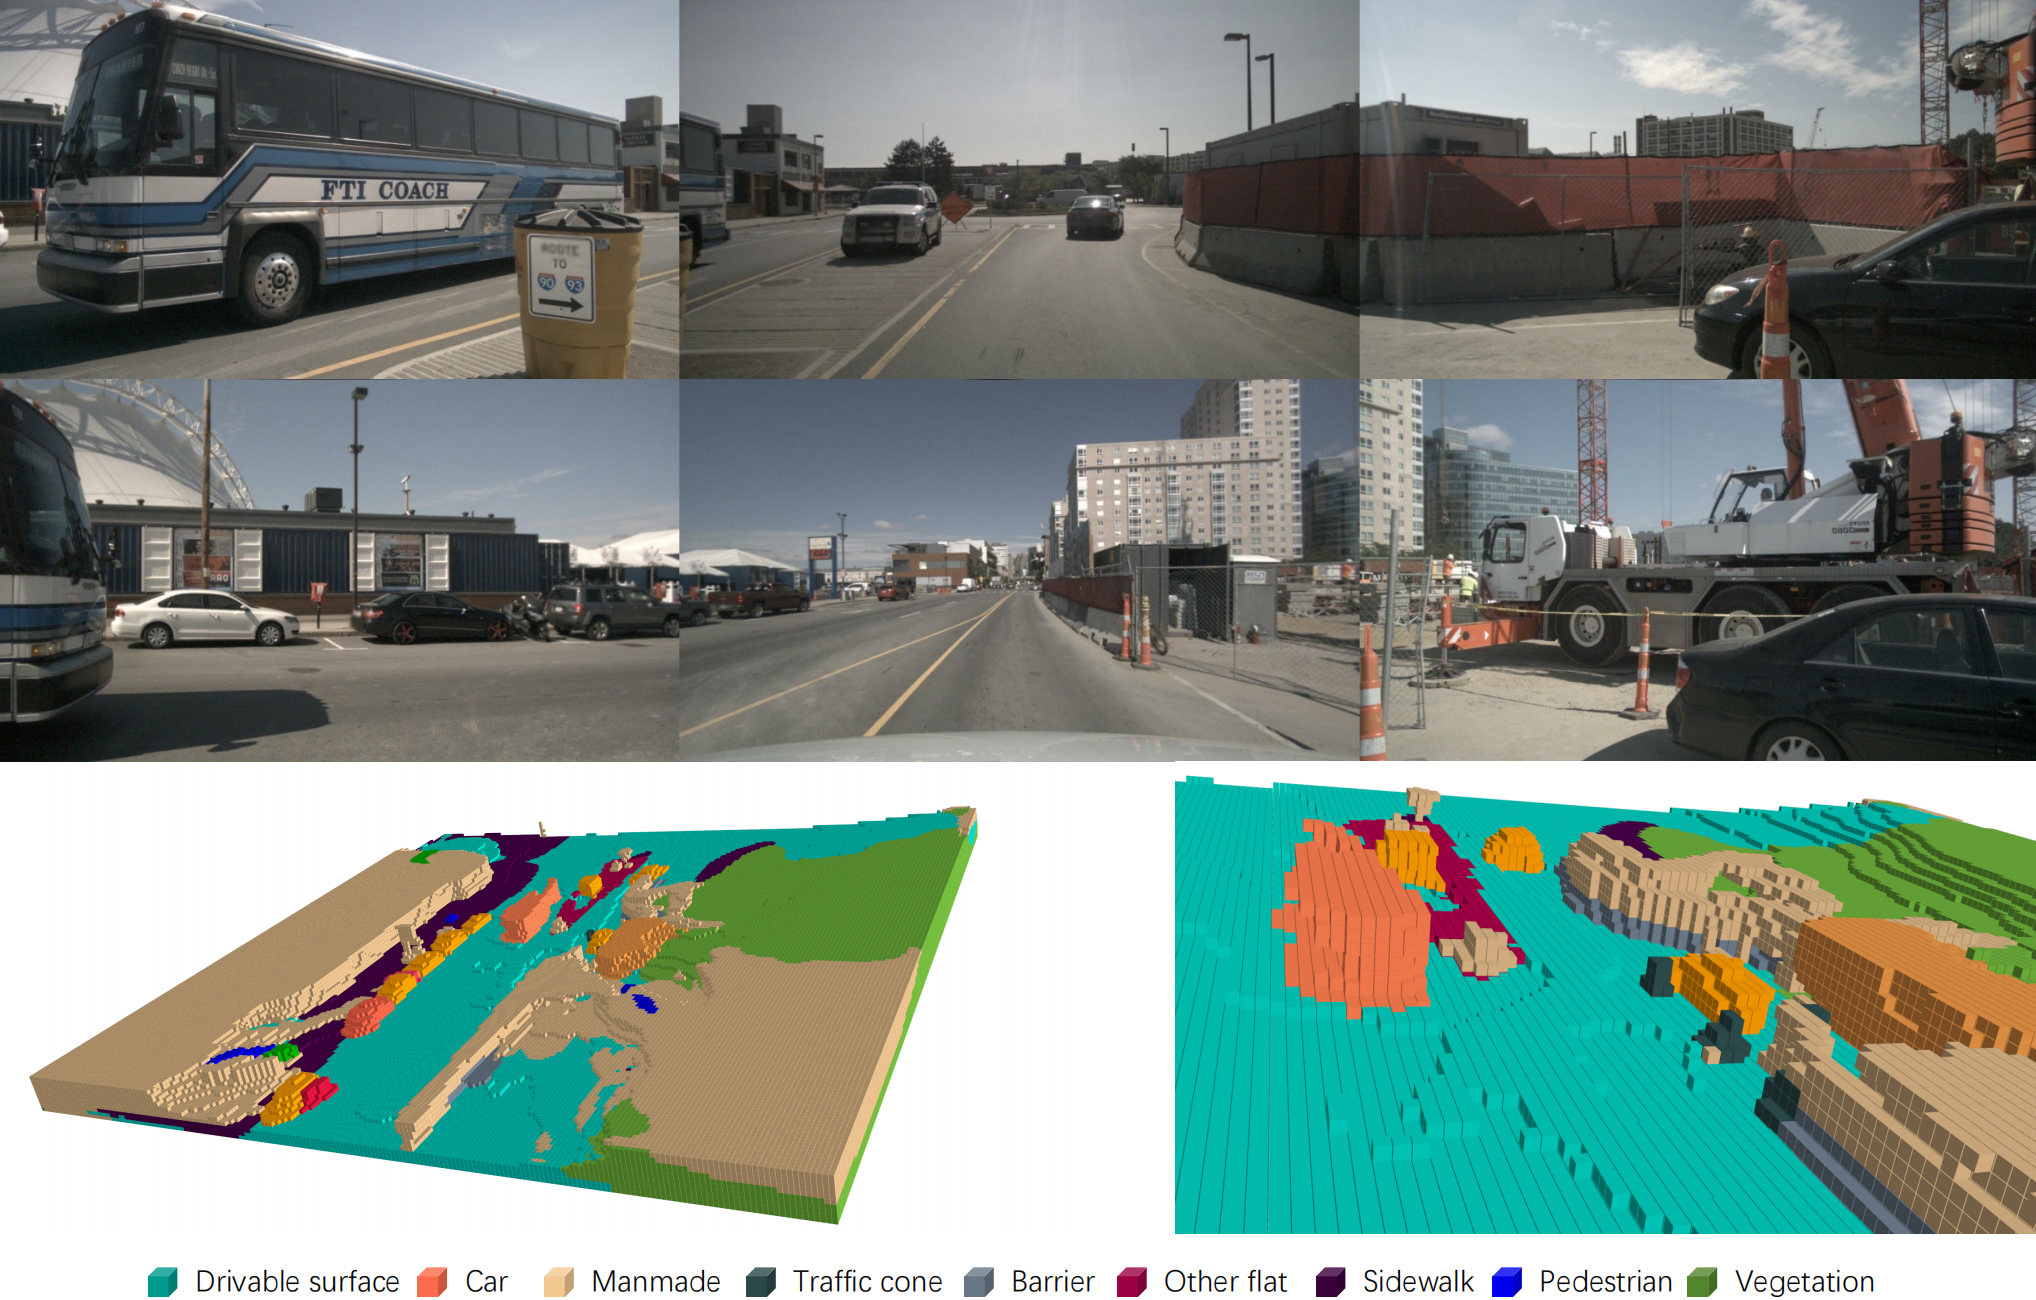
FB-BEV and FB-OCC are a family of vision-centric 3D object detection and occupancy prediction methods based on forward-backward view transformation.
[2023/8/01] FB-BEV was accepted to ICCV 2023.[2023/6/16] FB-OCC wins both Outstanding Champion and Innovation Award in Autonomous Driving Challenge in conjunction with CVPR 2023 End-to-End Autonomous Driving Workshop and Vision-Centric Autonomous Driving Workshop.Copyright © 2022 - 2023, NVIDIA Corporation. All rights reserved.
This work is made available under the Nvidia Source Code License-NC. Click here to view a copy of this license.
The pre-trained models are shared under CC-BY-NC-SA-4.0. If you remix, transform, or build upon the material, you must distribute your contributions under the same license as the original.
For business inquiries, please visit our website and submit the form: NVIDIA Research Licensing.
If this work is helpful for your research, please consider citing:
@inproceedings{li2023fbbev,
  title={{FB-BEV}: {BEV} Representation from Forward-Backward View Transformations},
  author={Li, Zhiqi and Yu, Zhiding and Wang, Wenhai and Anandkumar, Anima and Lu, Tong and Alvarez, Jose M},
  booktitle={IEEE/CVF International Conference on Computer Vision (ICCV)},
  year={2023}
}
@article{li2023fbocc,
  title={{FB-OCC}: {3D} Occupancy Prediction based on Forward-Backward View Transformation},
  author={Li, Zhiqi and Yu, Zhiding and Austin, David and Fang, Mingsheng and Lan, Shiyi and Kautz, Jan and Alvarez, Jose M},
  journal={arXiv:2307.01492},
  year={2023}
}
Many thanks to these excellent open source projects:
384 followers · starred Jun 2023
770 followers · starred Oct 2023
Official PyTorch implementation of FB-BEV & FB-OCC - Forward-backward view transformation for vision-centric autonomous driving perception
Python
797
9 commits
updated Mar 17, 2025
FB-BEV and FB-OCC are a family of vision-centric 3D object detection and occupancy prediction methods based on forward-backward view transformation.
[2023/8/01] FB-BEV was accepted to ICCV 2023.[2023/6/16] FB-OCC wins both Outstanding Champion and Innovation Award in Autonomous Driving Challenge in conjunction with CVPR 2023 End-to-End Autonomous Driving Workshop and Vision-Centric Autonomous Driving Workshop.Copyright © 2022 - 2023, NVIDIA Corporation. All rights reserved.
This work is made available under the Nvidia Source Code License-NC. Click here to view a copy of this license.
The pre-trained models are shared under CC-BY-NC-SA-4.0. If you remix, transform, or build upon the material, you must distribute your contributions under the same license as the original.
For business inquiries, please visit our website and submit the form: NVIDIA Research Licensing.
If this work is helpful for your research, please consider citing:
@inproceedings{li2023fbbev,
  title={{FB-BEV}: {BEV} Representation from Forward-Backward View Transformations},
  author={Li, Zhiqi and Yu, Zhiding and Wang, Wenhai and Anandkumar, Anima and Lu, Tong and Alvarez, Jose M},
  booktitle={IEEE/CVF International Conference on Computer Vision (ICCV)},
  year={2023}
}
@article{li2023fbocc,
  title={{FB-OCC}: {3D} Occupancy Prediction based on Forward-Backward View Transformation},
  author={Li, Zhiqi and Yu, Zhiding and Austin, David and Fang, Mingsheng and Lan, Shiyi and Kautz, Jan and Alvarez, Jose M},
  journal={arXiv:2307.01492},
  year={2023}
}
Many thanks to these excellent open source projects:
384 followers · starred Jun 2023
770 followers · starred Oct 2023



