Official Code for "Continuous Locomotive Crowd Behavior Generation (CVPR 2025)"
See the code
Inhwan Bae
·
Junoh Lee
·
Hae-Gon Jeon
CVPR 2025
Project Page
CVPR Paper
Source Code
3D Toolkit
Related Works
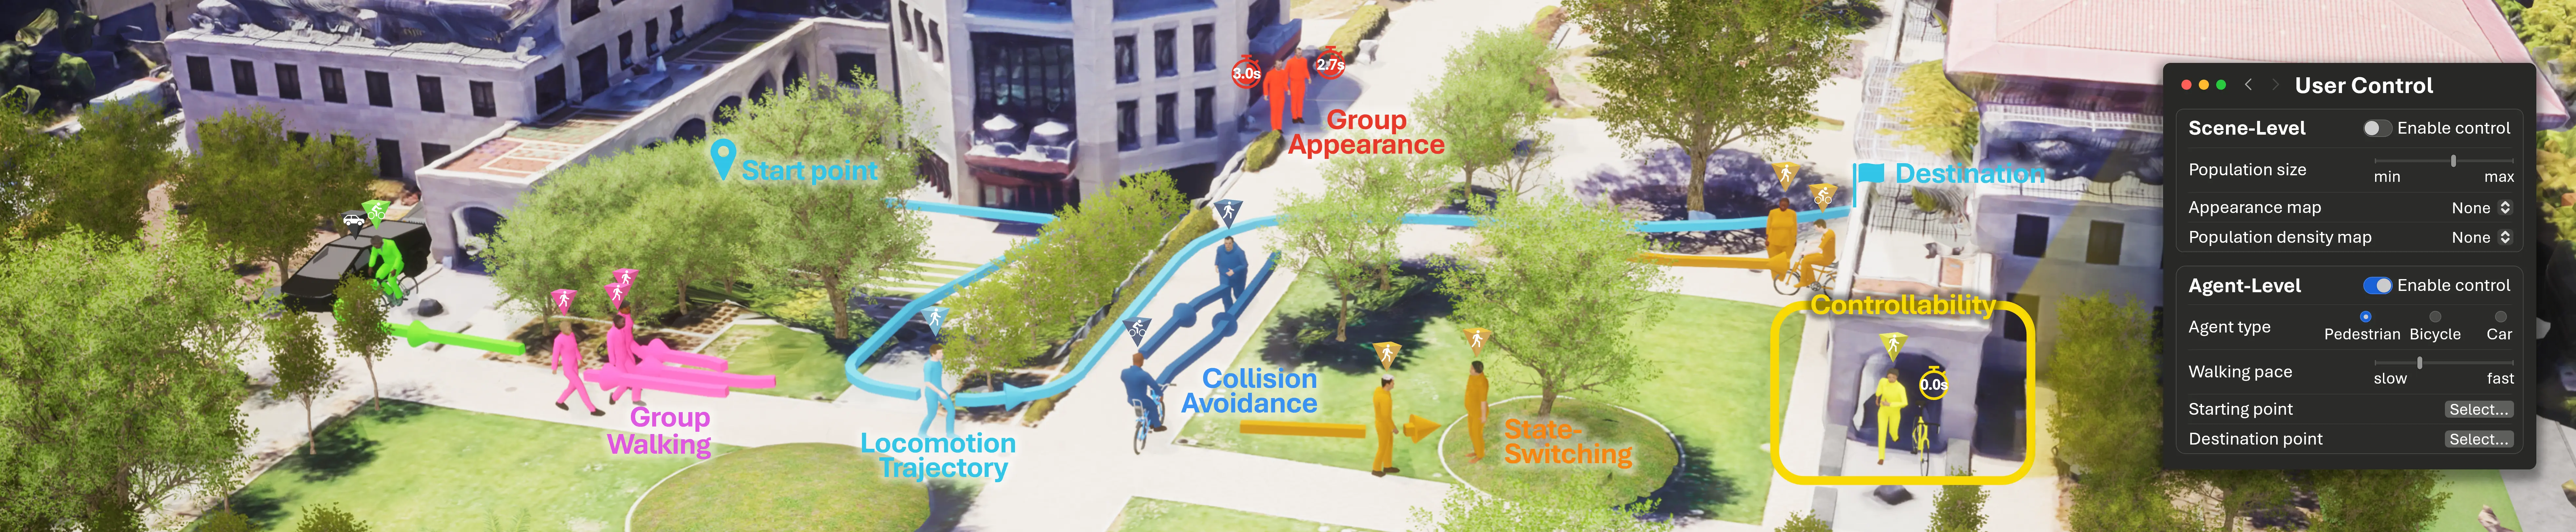
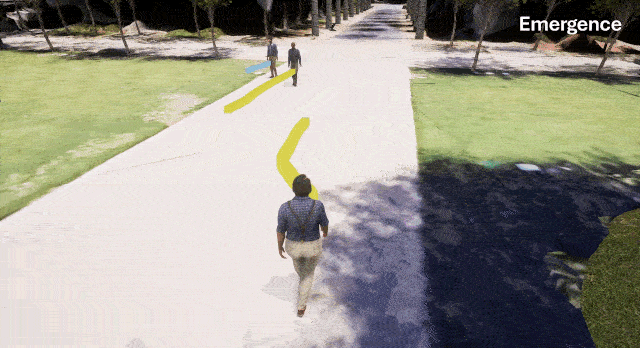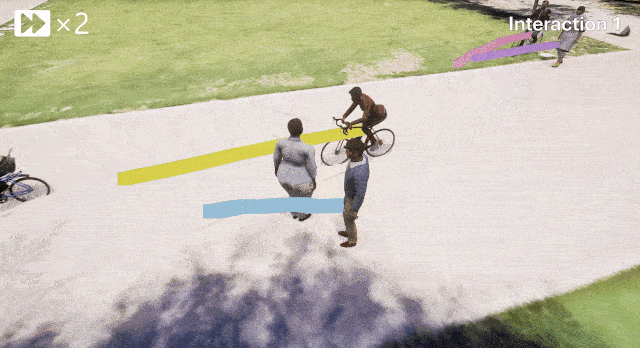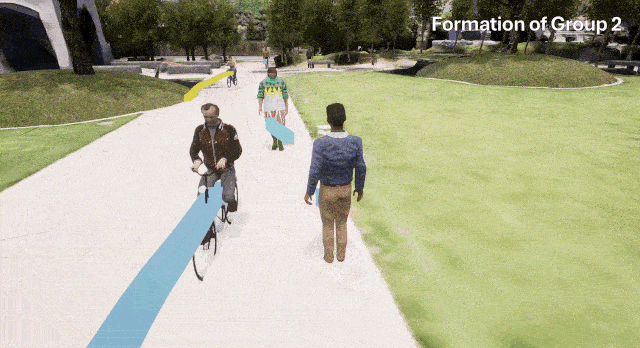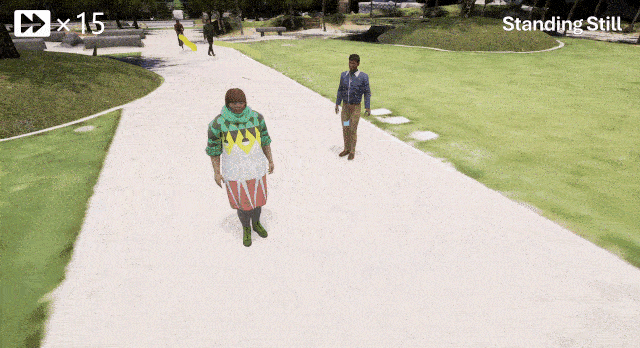
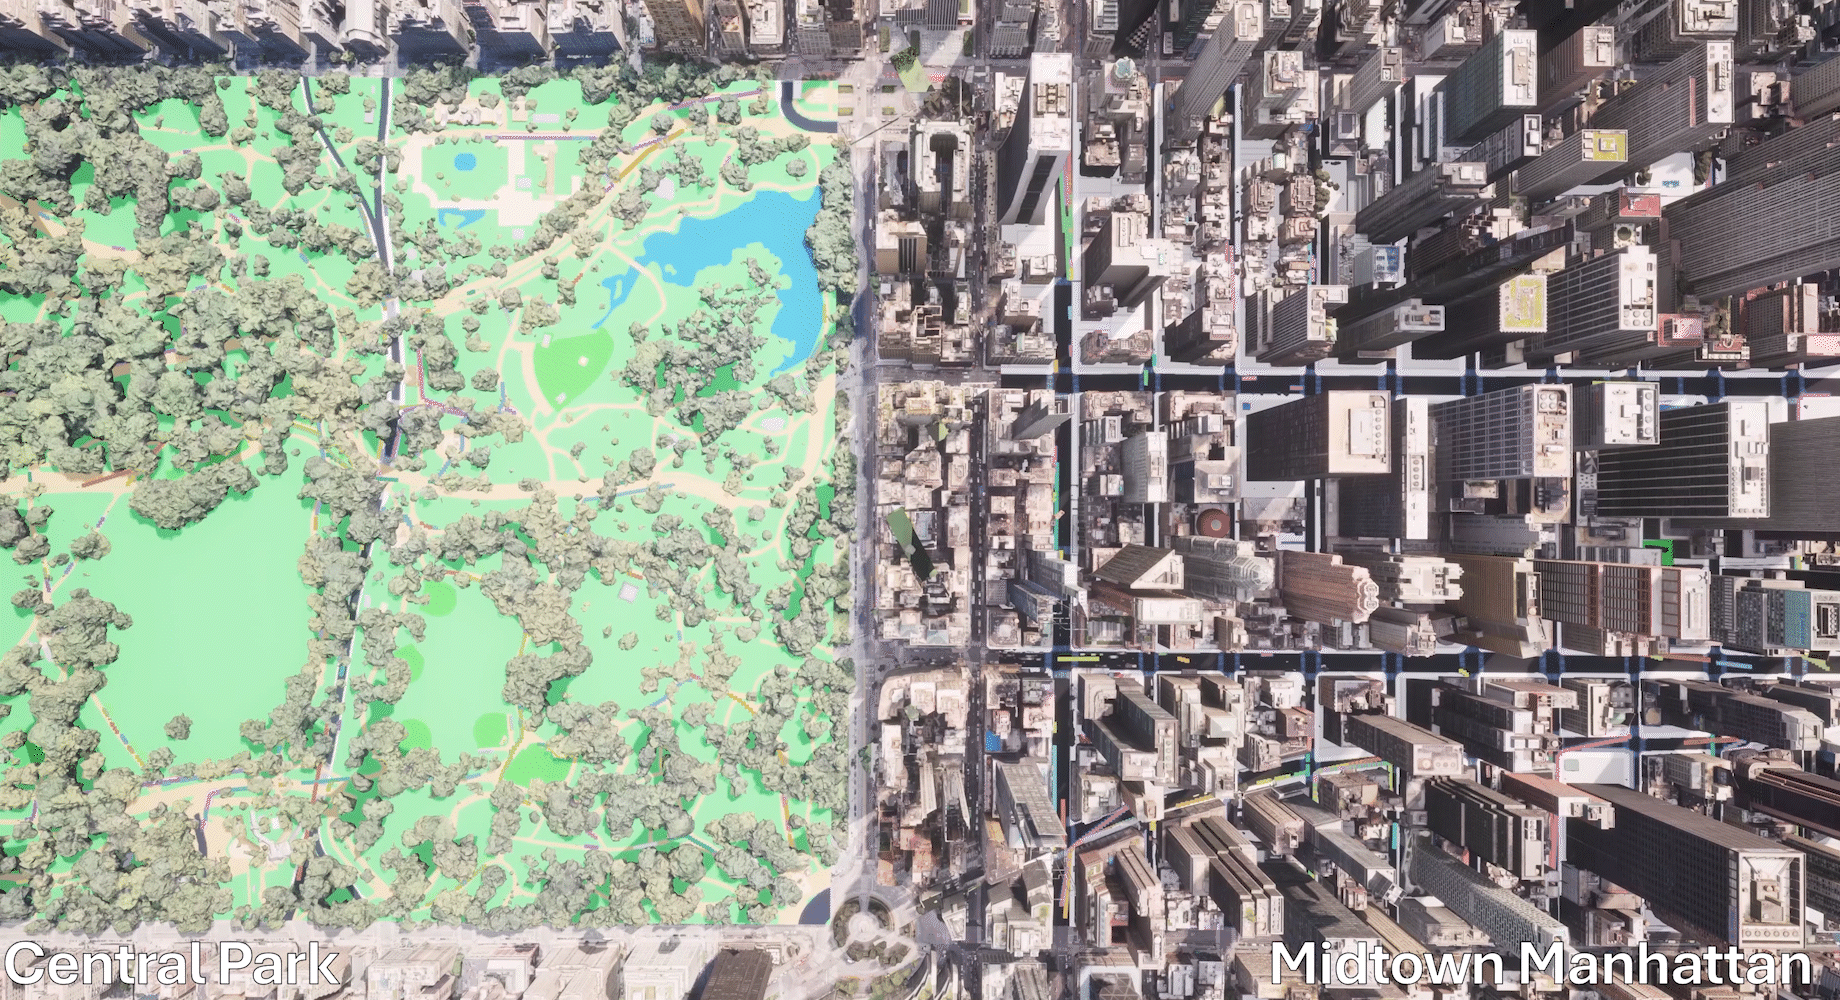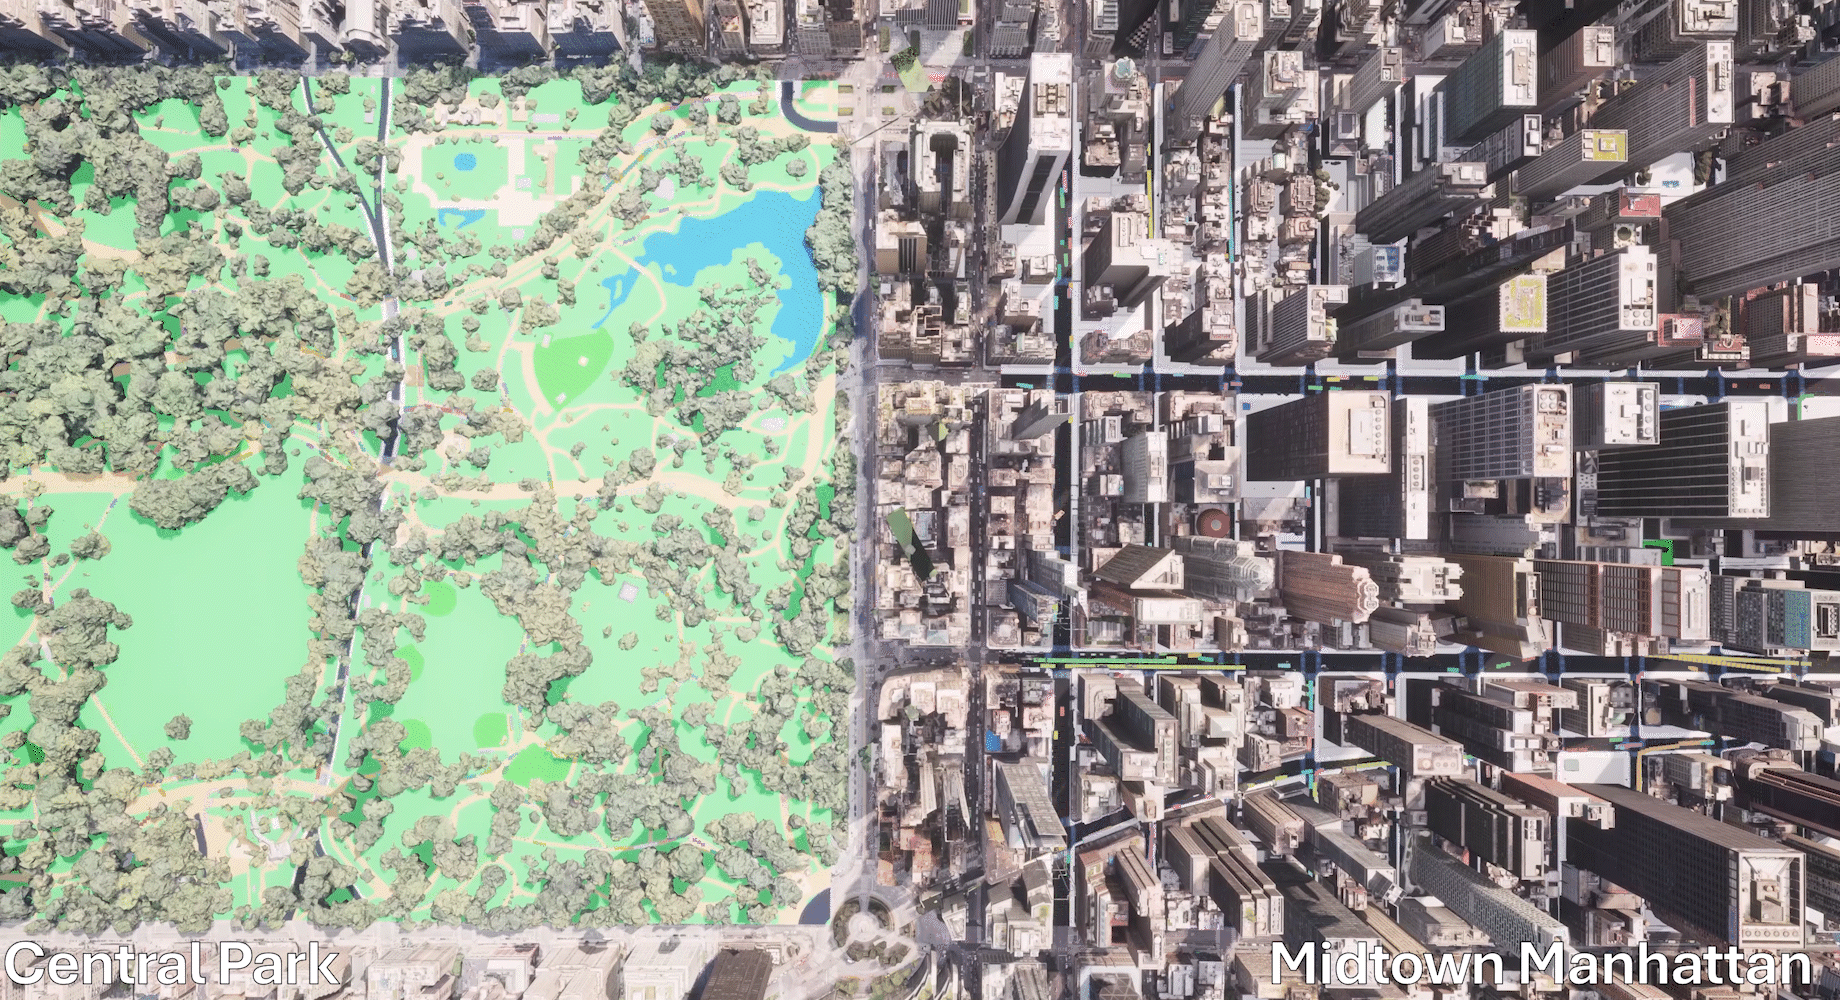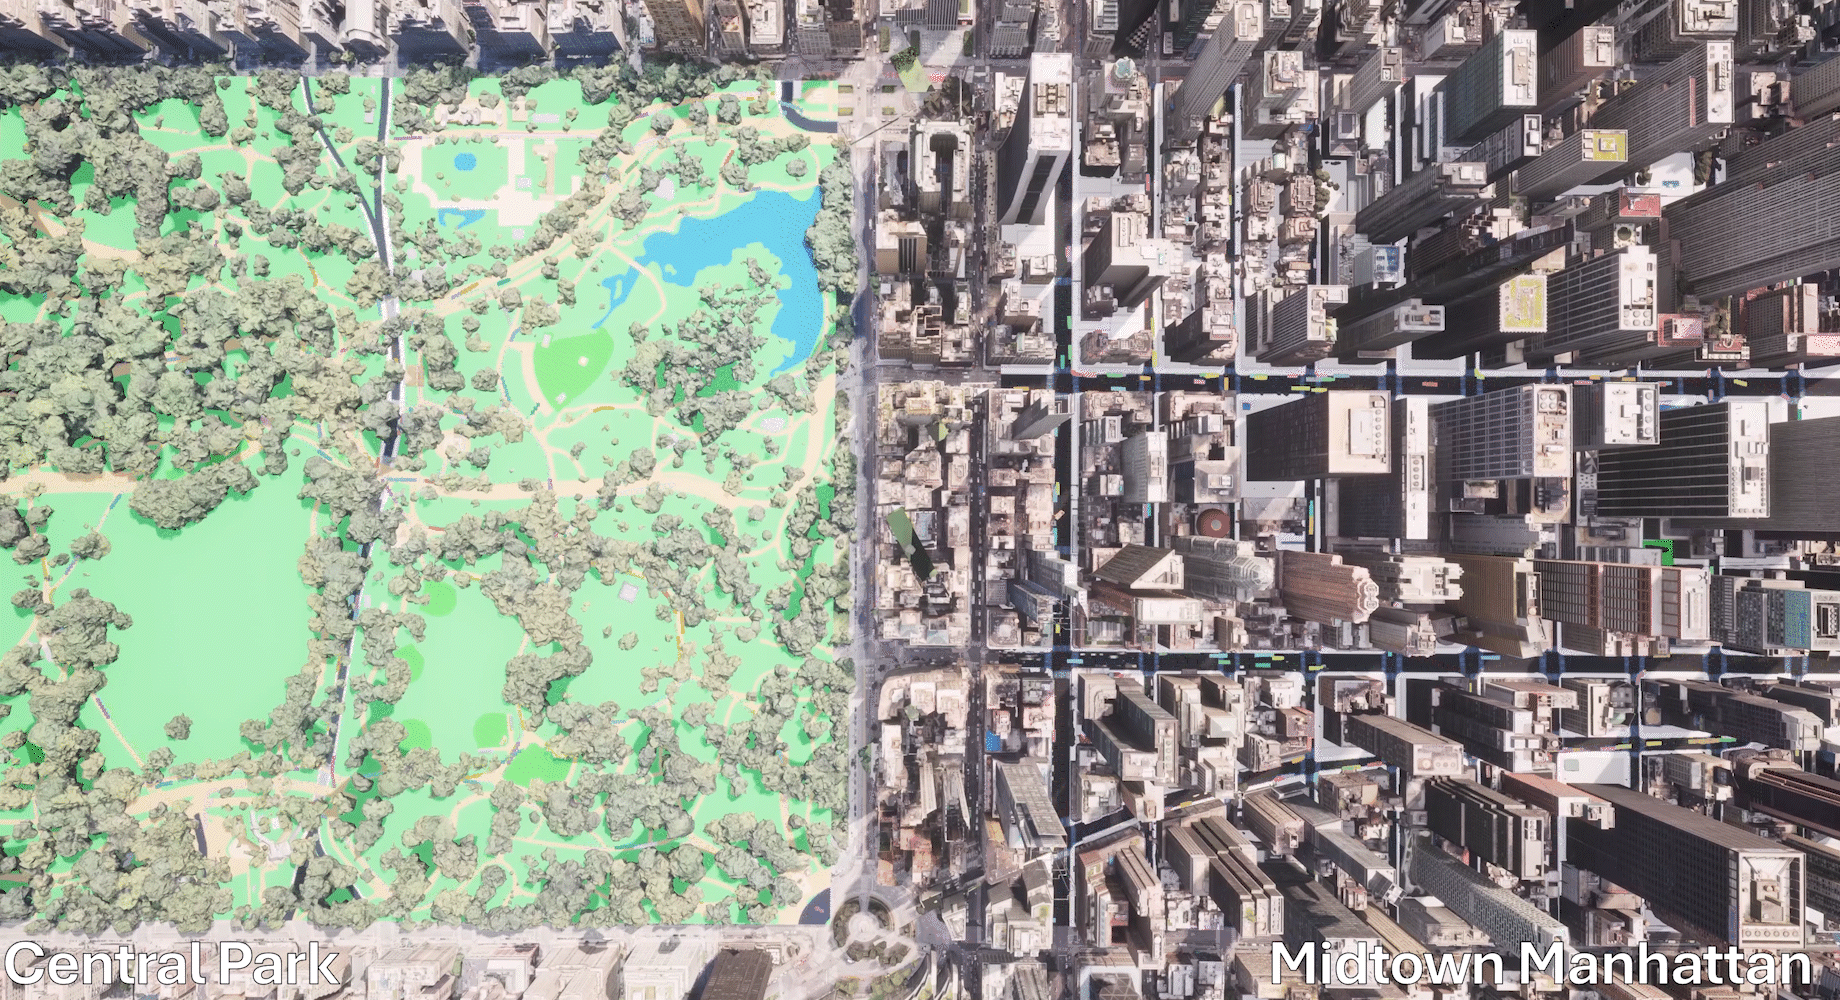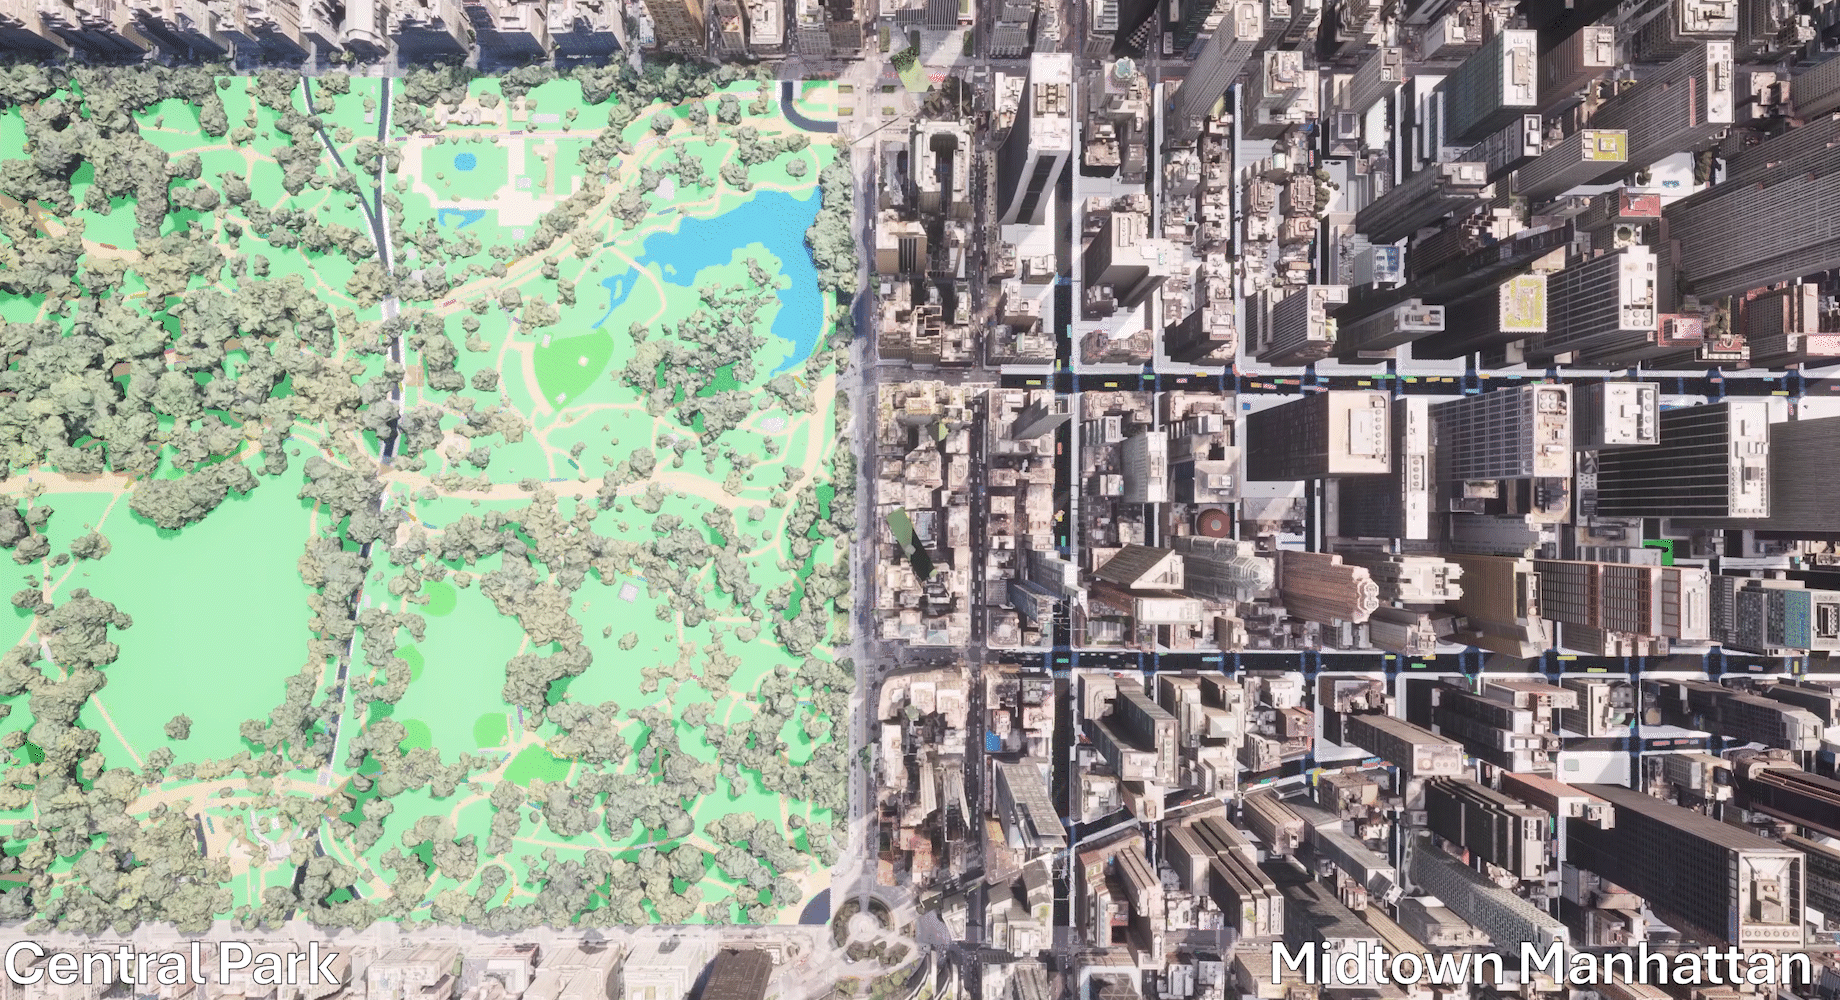
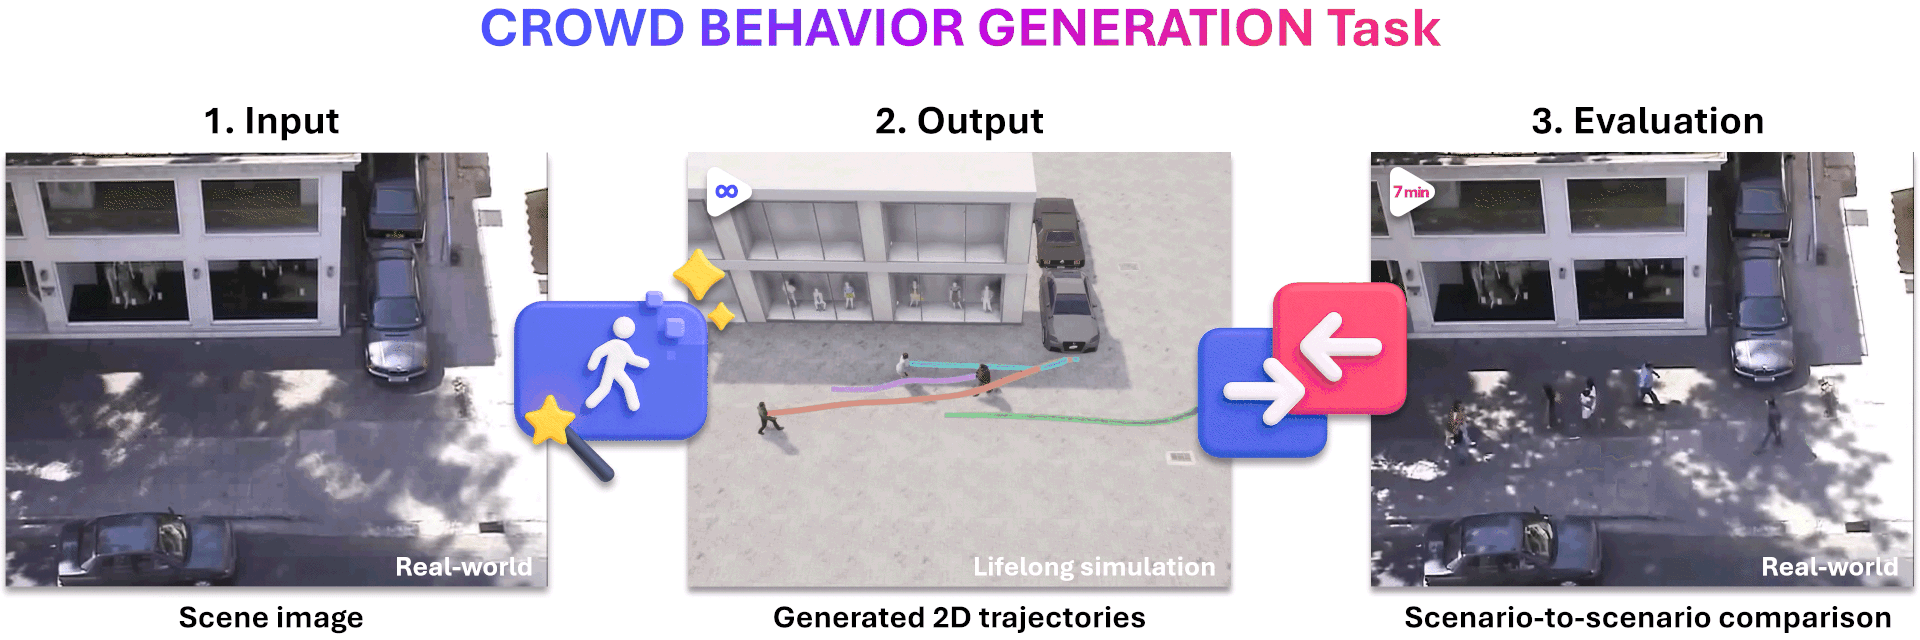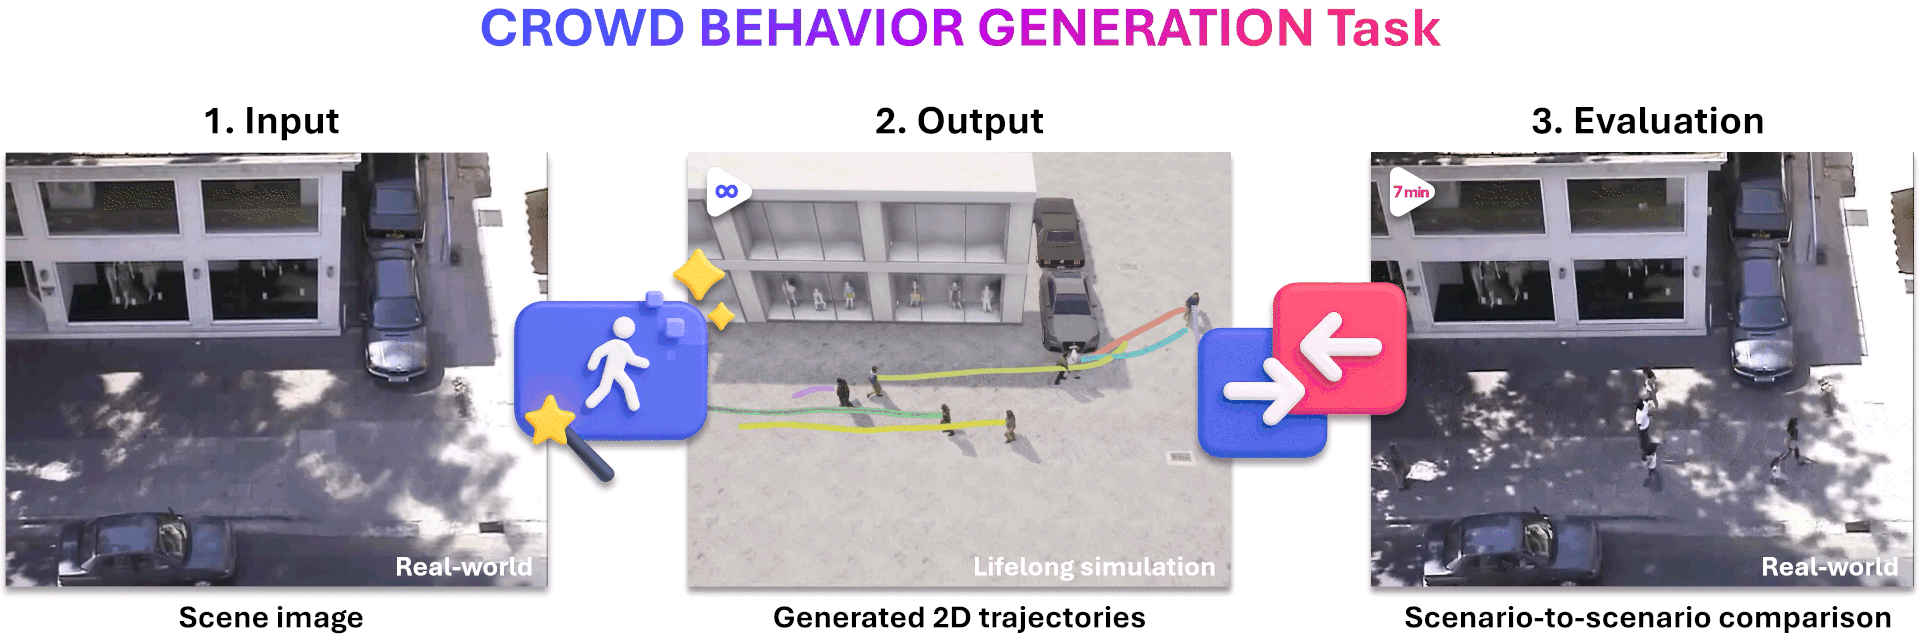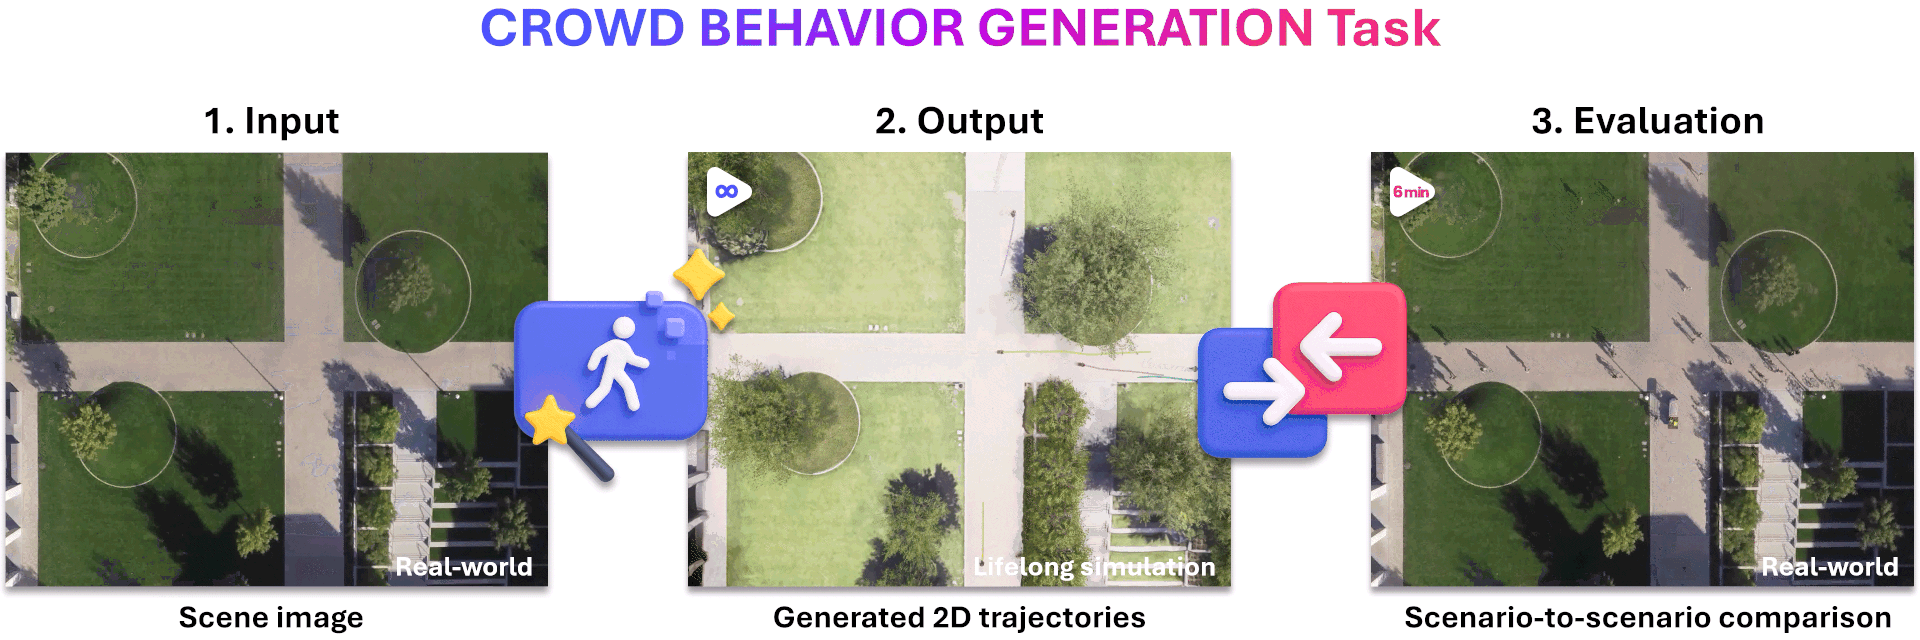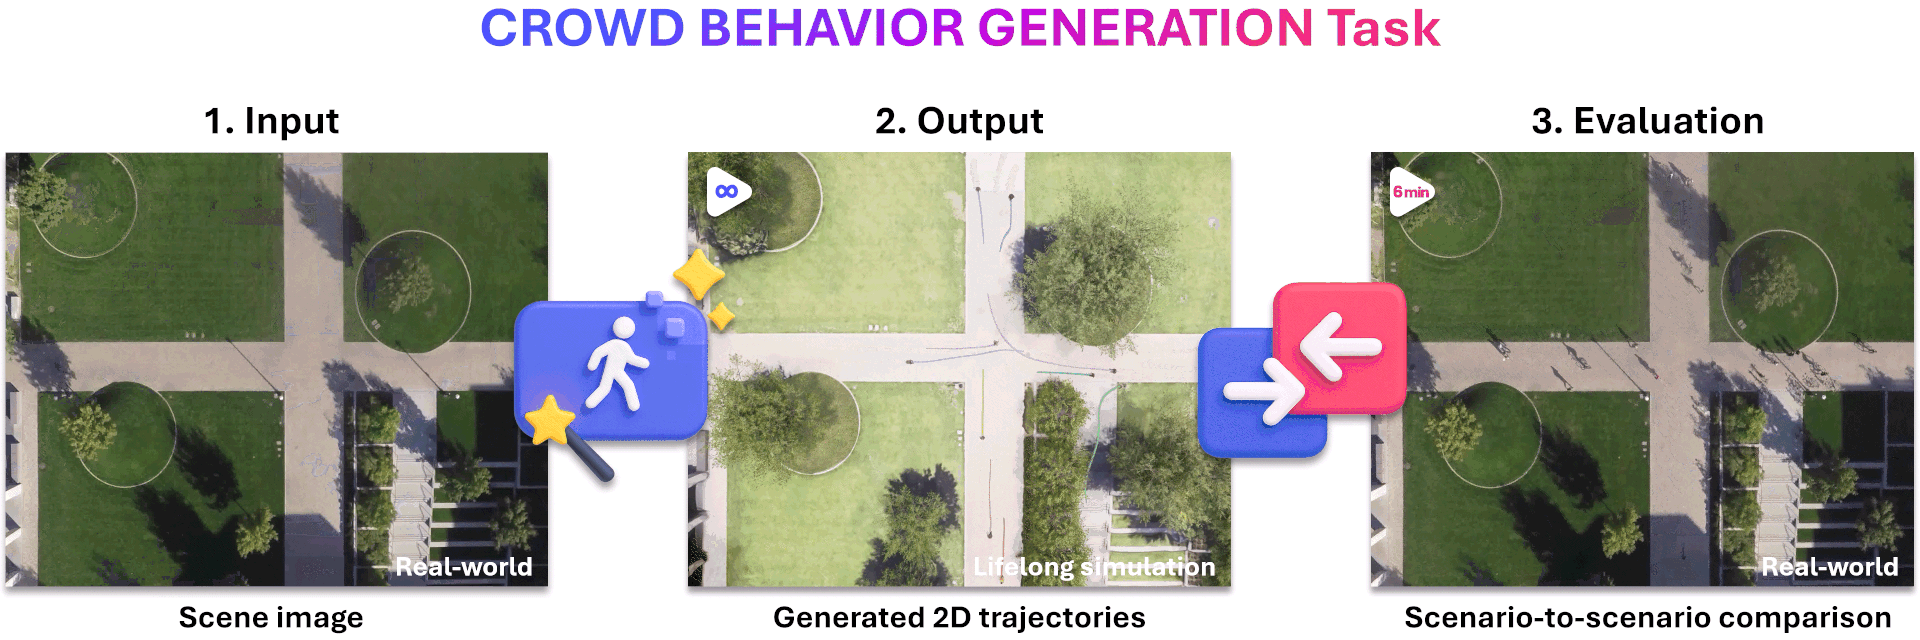
Summary: A crowd emitter diffusion model and a state-switching crowd simulator for populating input scene images and generating lifelong crowd trajectories.
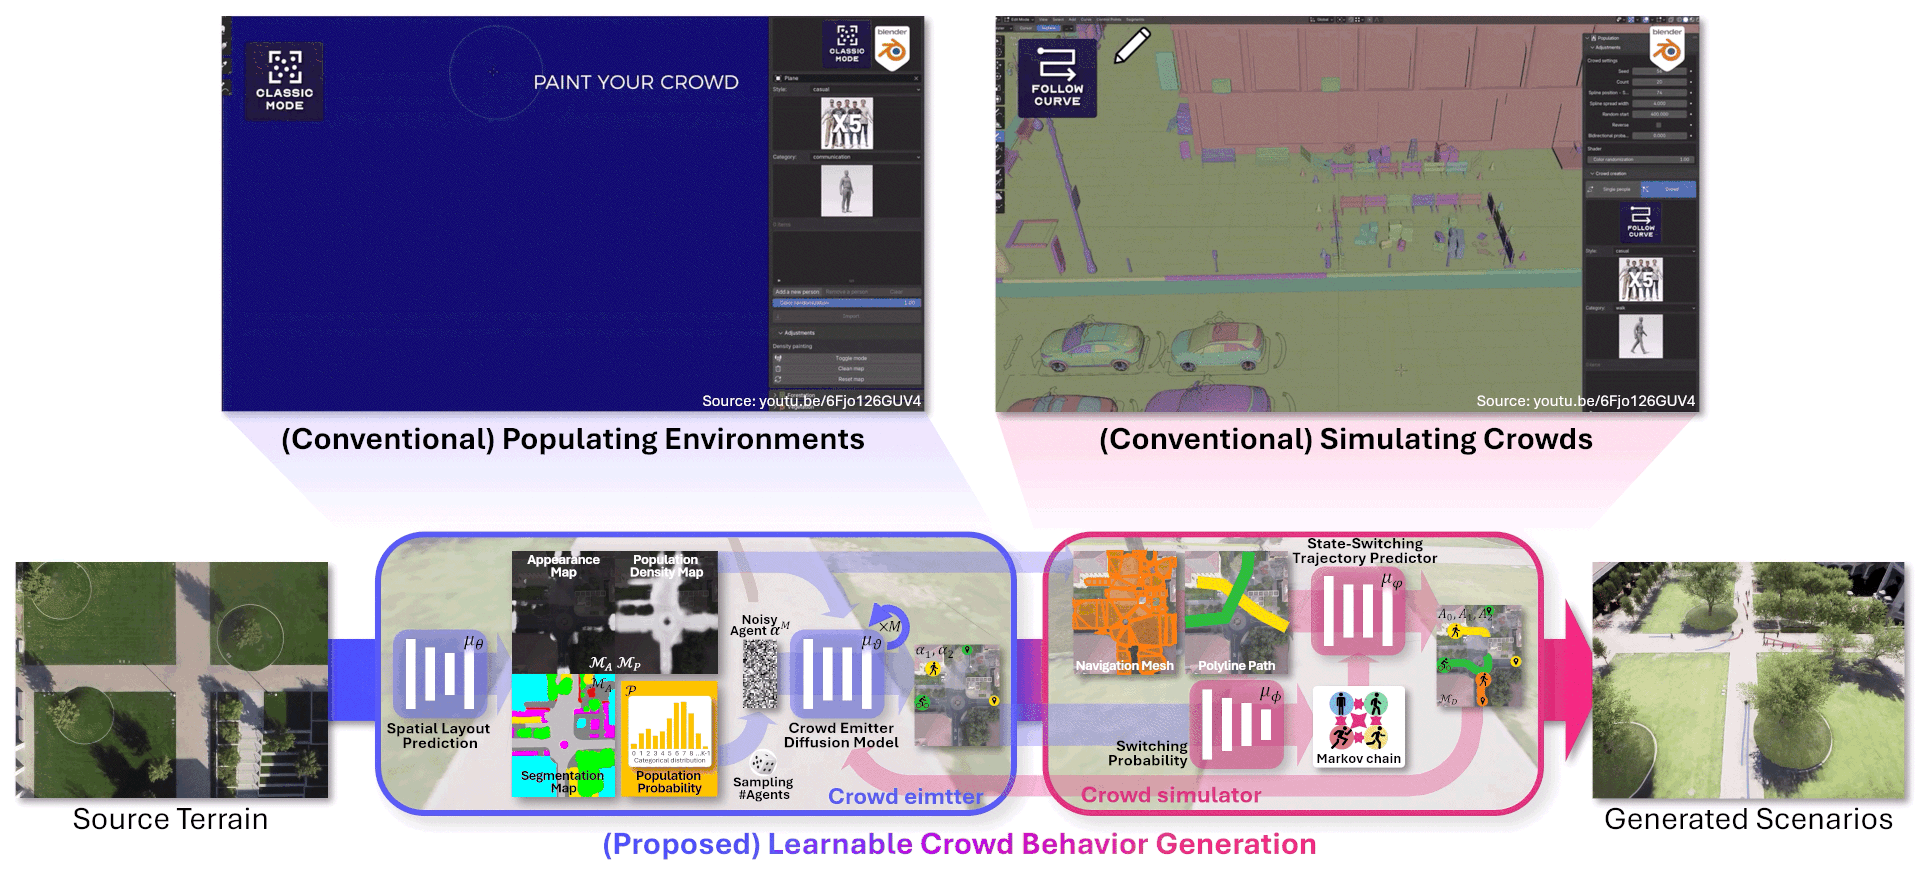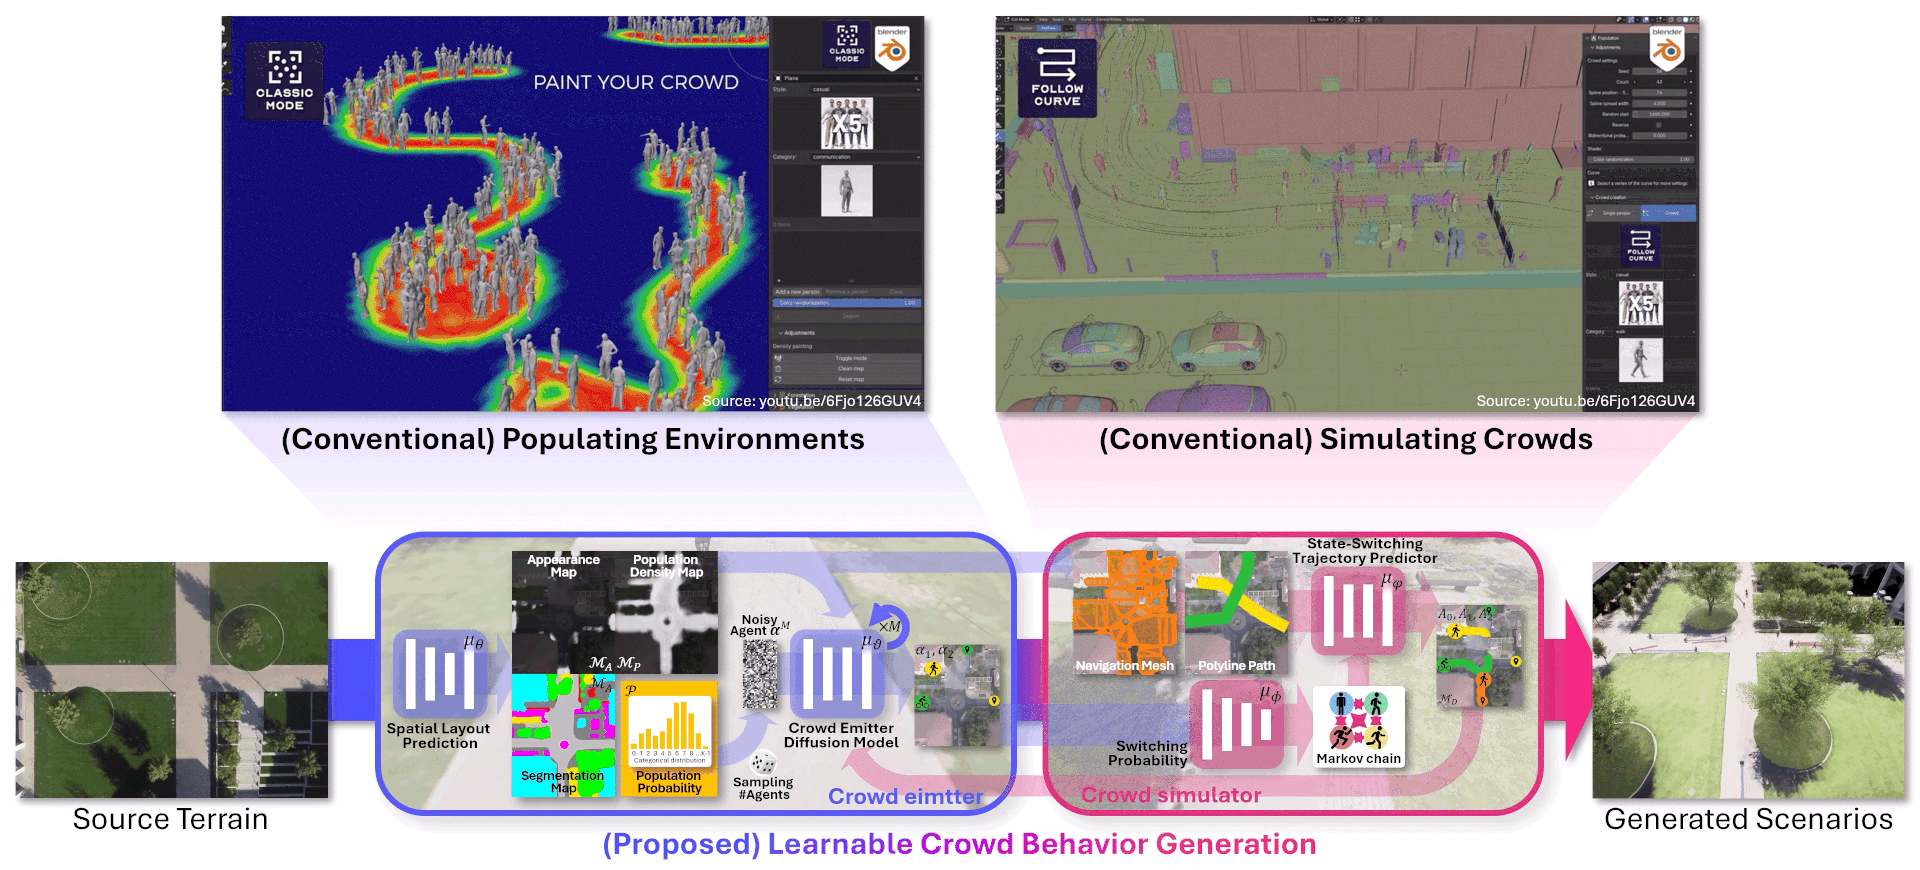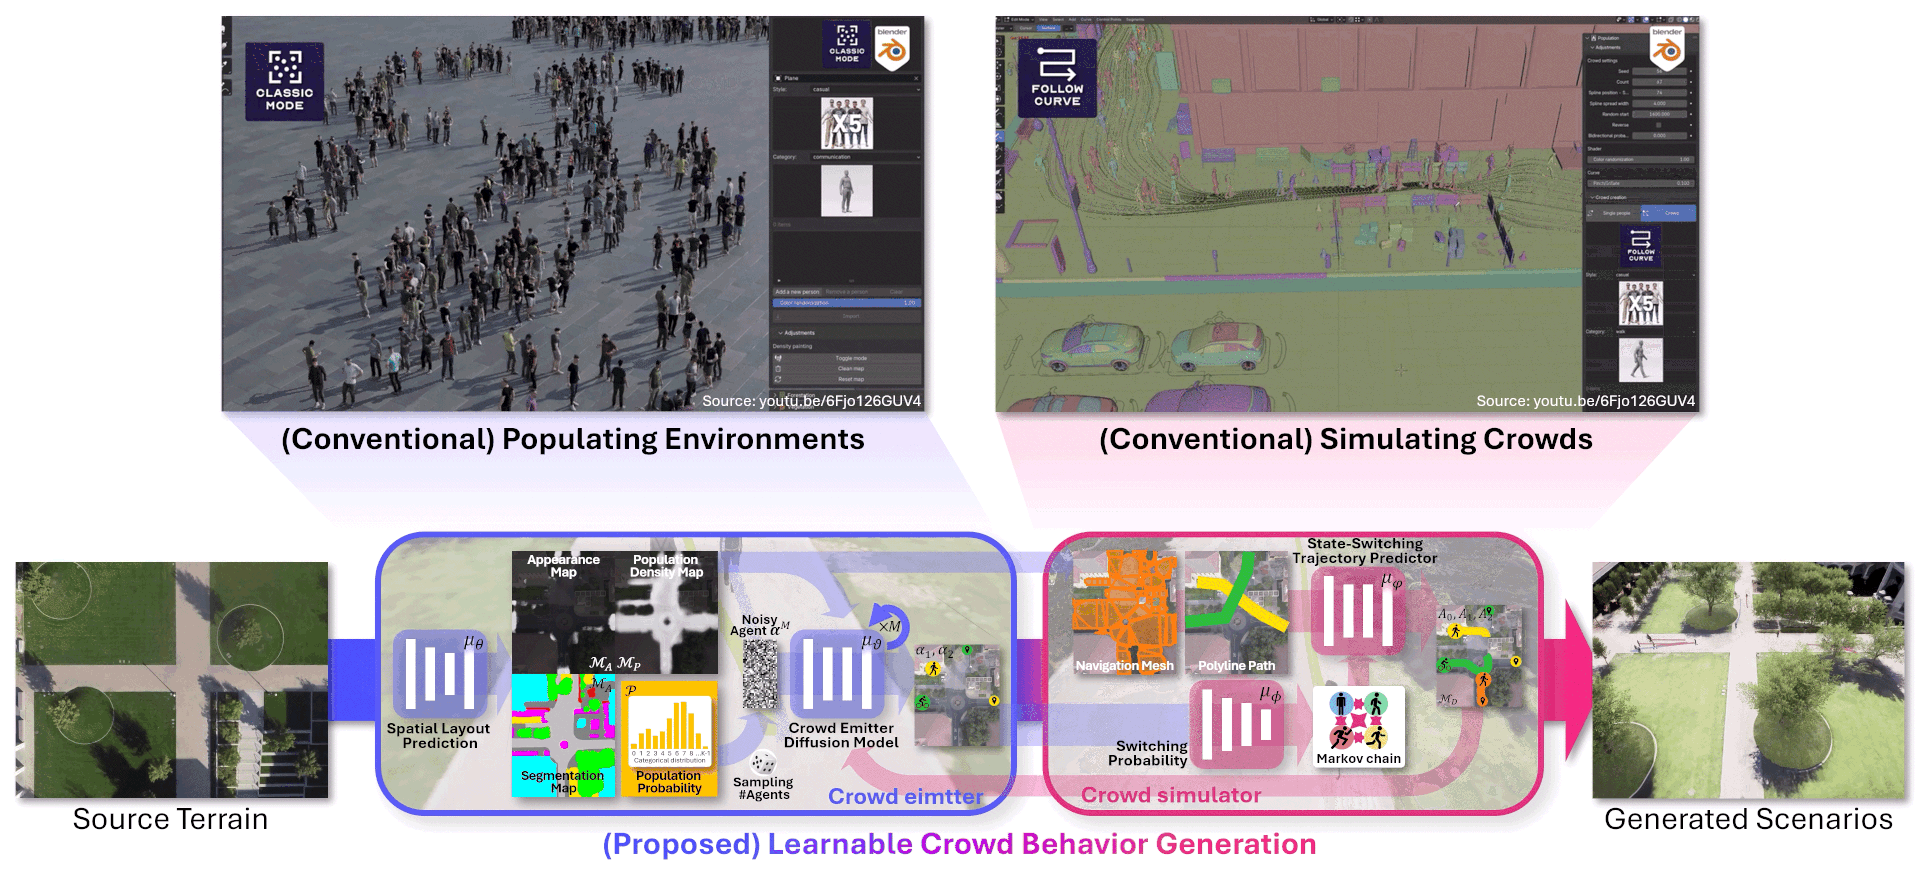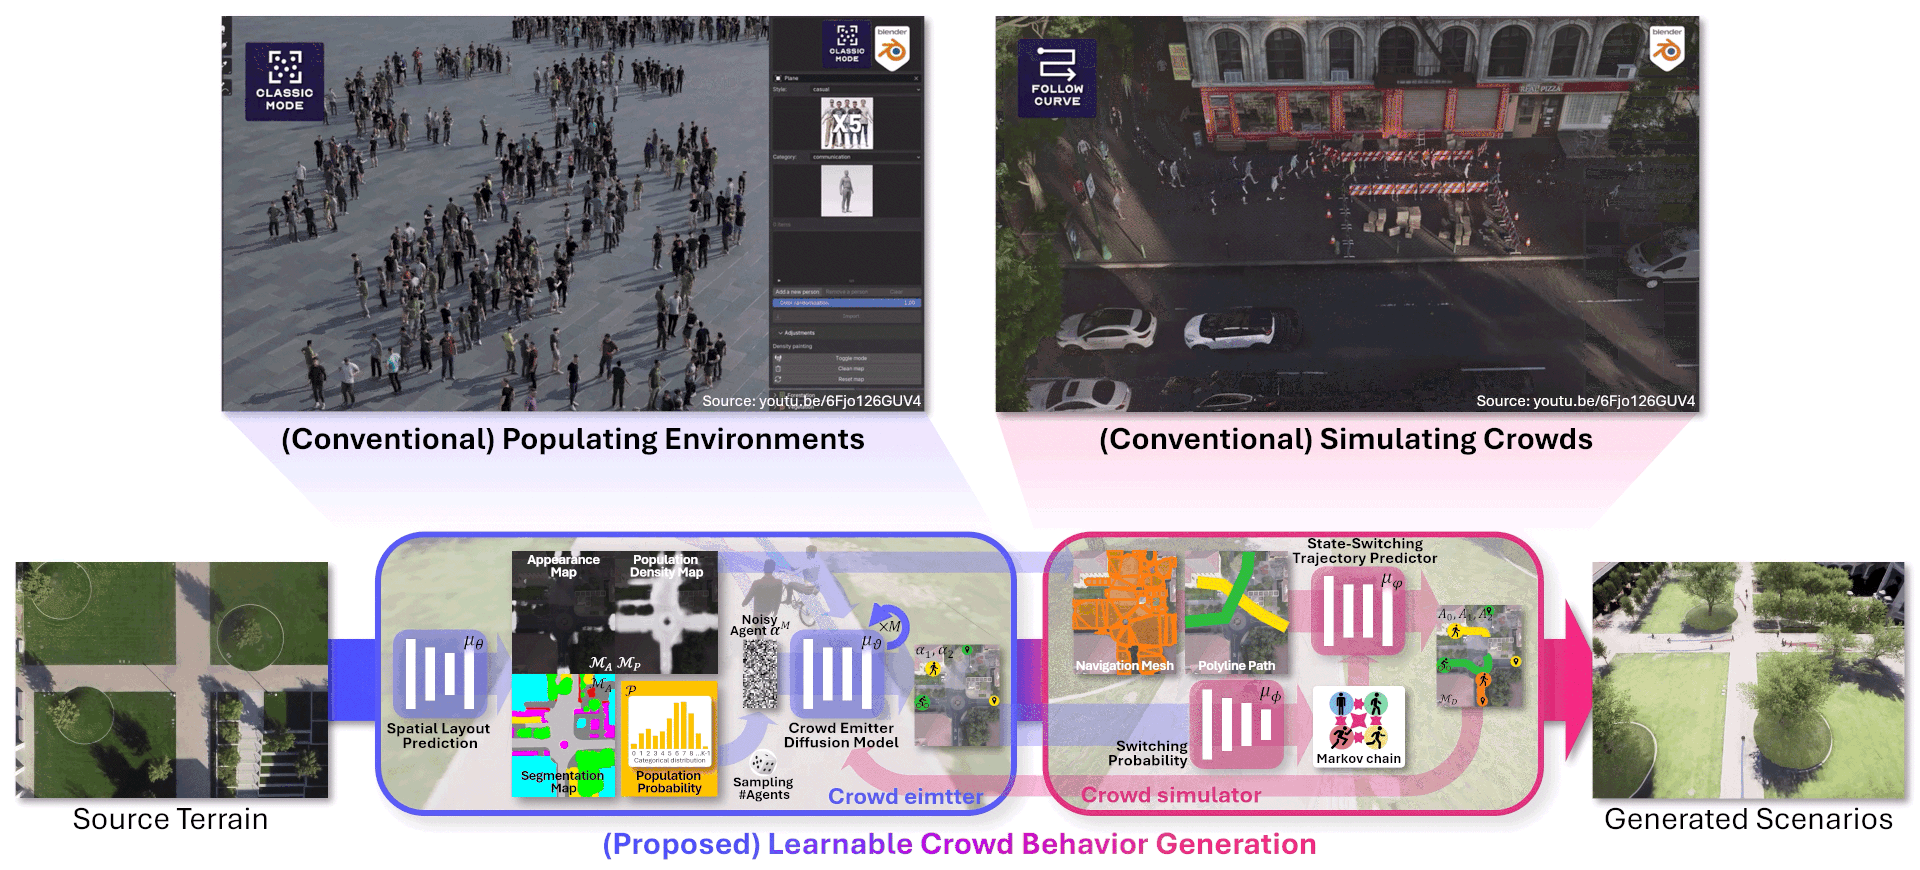
Environment
All models were trained and tested on Ubuntu 20.04 with Python 3.10 and PyTorch 2.2.2 with CUDA 12.1. You can install all dependencies via following command:
pip install -r requirements.txt
Dataset
Preprocessed ETH, UCY, SDD and EDIN datasets are released in this repository.
[!NOTE]
If you want to preprocess the datasets by yourself, please download the raw datasets and run the following command:
python utils/preprocess_dataset.py --model_config <path_to_model_config>

# Example
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_eth.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_hotel.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_univ.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_zara1.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_zara2.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_sdd.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_gcs.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_edin.yaml
To train the CrowdES crowd emitter model, you can use the following command:
python trainval.py --model_train emitter_pre --model_config <path_to_model_config>
python trainval.py --model_train emitter --model_config <path_to_model_config>

# Example
python trainval.py --model_train emitter_pre --model_config ./configs/model/CrowdES_eth.yaml
python trainval.py --model_train emitter --model_config ./configs/model/CrowdES_eth.yaml
To train the CrowdES crowd simulator model, you can use the following command:
python trainval.py --model_train simulator --model_config <path_to_model_config>

# Example
python trainval.py --model_train simulator --model_config ./configs/model/CrowdES_eth.yaml
We provide pretrained models in the release section.
To evaluate the CrowdES model, you can use the following command:
python trainval.py --test --model_config <path_to_model_config>

# Example
python trainval.py --test --model_config ./configs/model/CrowdES_eth.yaml
To export the generated trajectories from the CrowdES model, you can use the following command:
python trainval.py --export --model_config <path_to_model_config>

# Example
python trainval.py --export --model_config ./configs/model/CrowdES_eth.yaml
[!TIP] You can also customize the hyperparameters for exporting the generated trajectories by modifying the
CrowdES/evaluate_export_generated_traj.pyfile. Here are the default settings:
To evaluate the CrowdES model with a custom input image, you can use the following command:
python trainval.py --synthetic --model_config <path_to_model_config>

# Example
python trainval.py --synthetic --model_config ./configs/model/CrowdES_eth.yaml
[!TIP] You can also customize the hyperparameters by modifying the
CrowdES/evaluate_synthetic.pyfile. Here are the default settings:
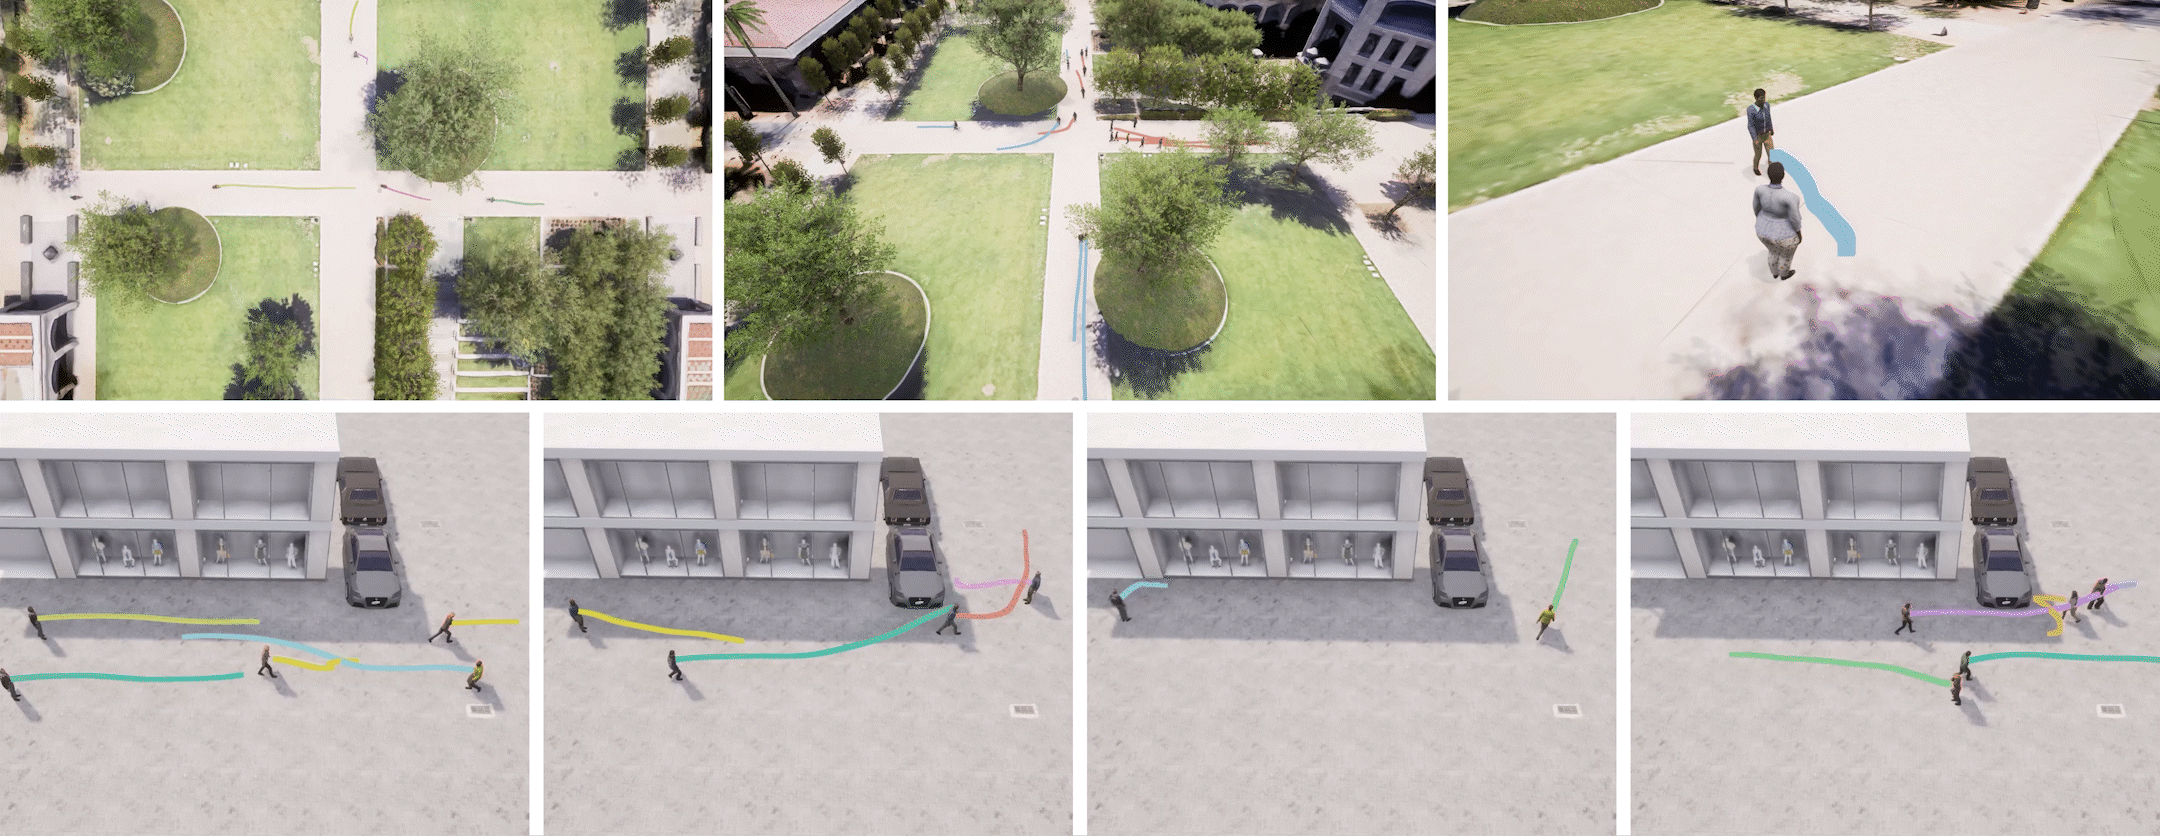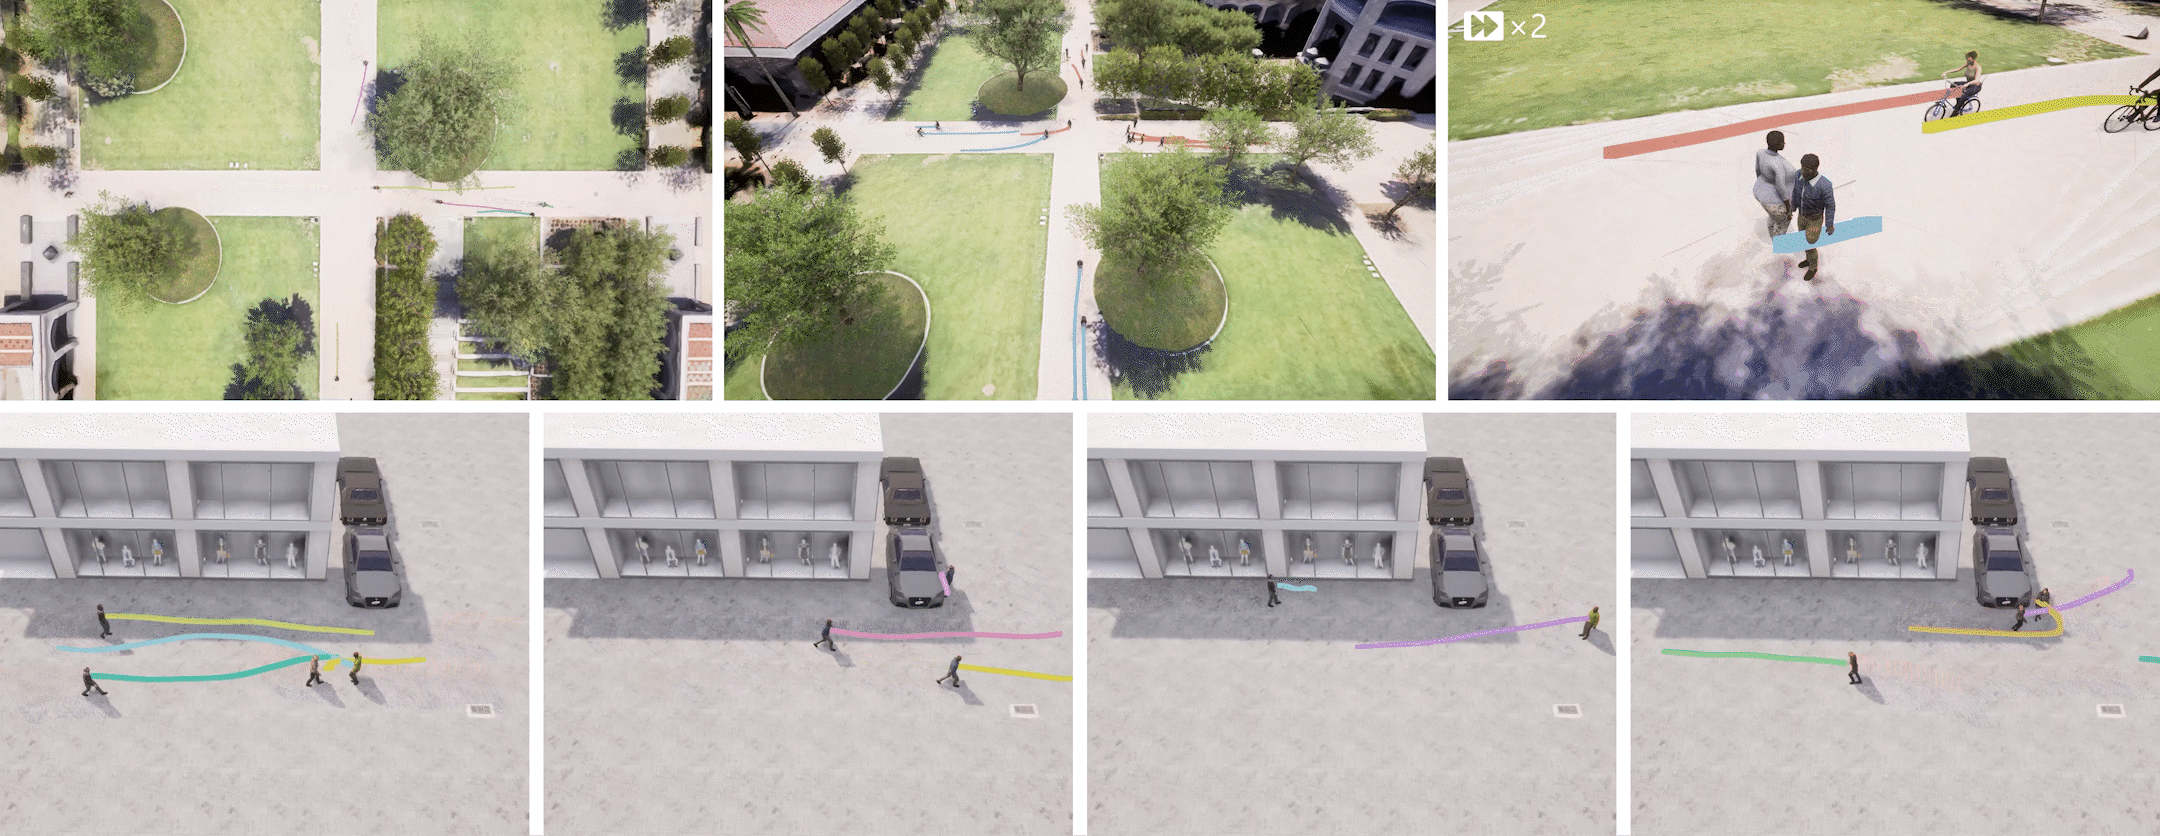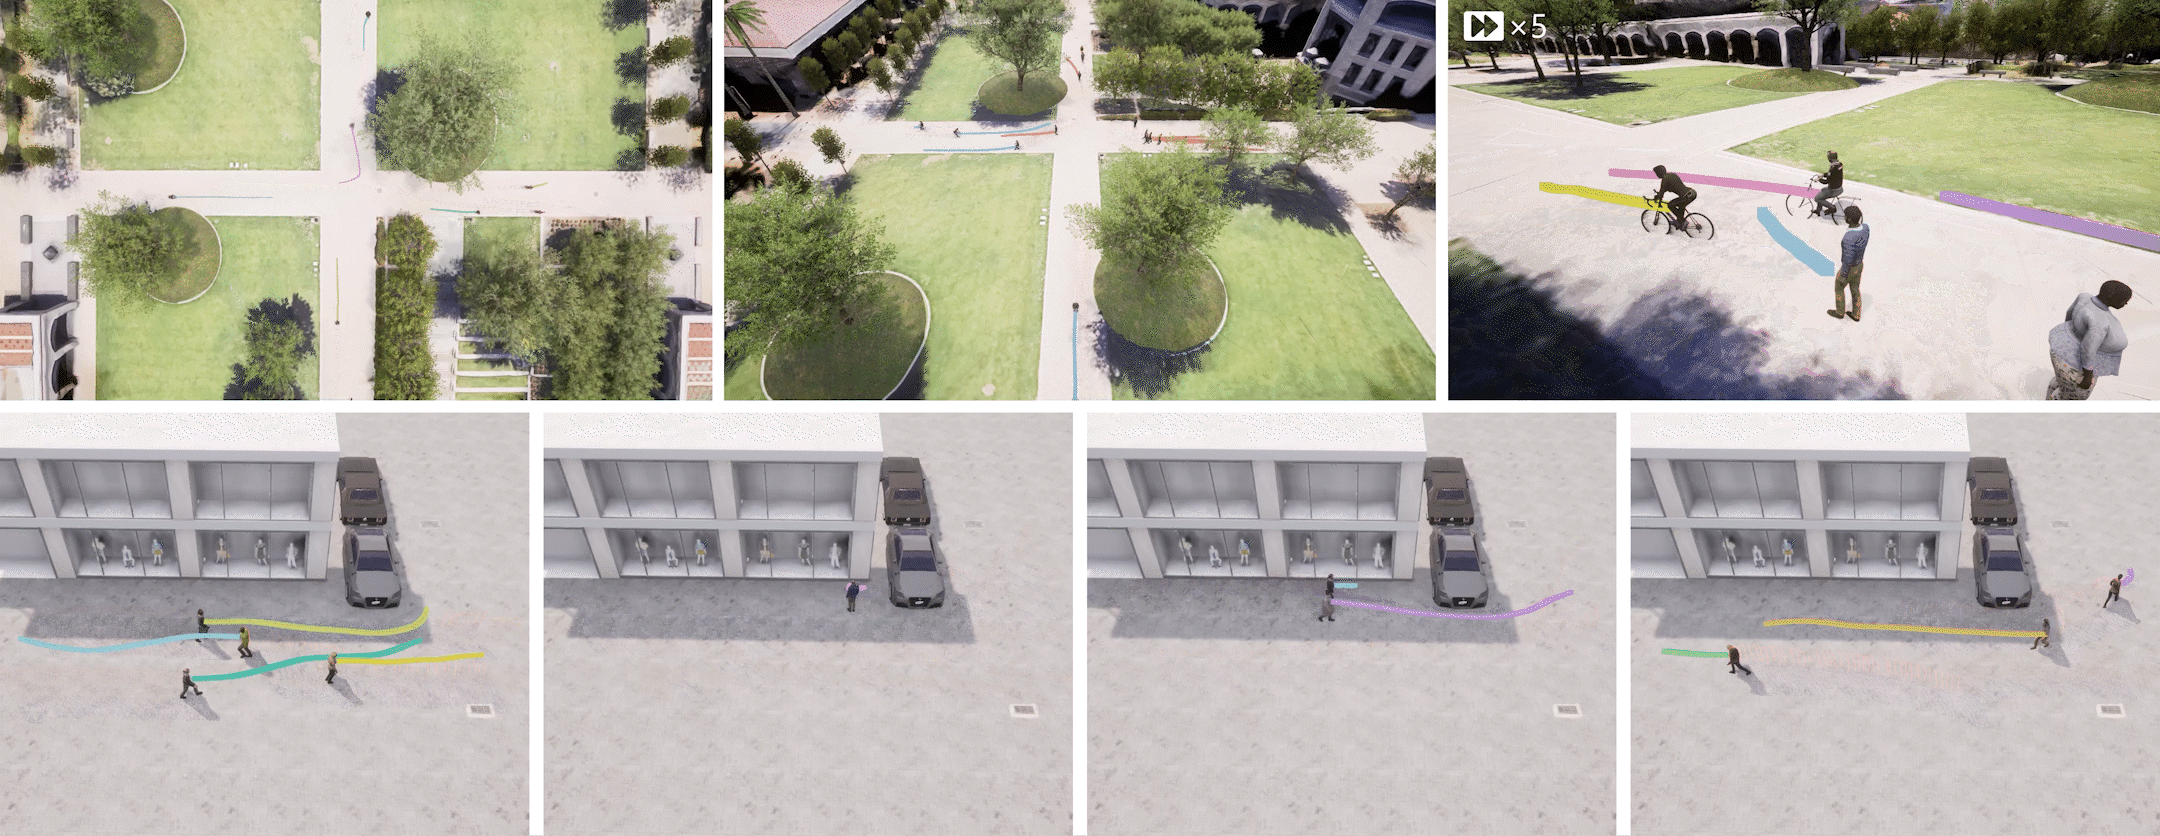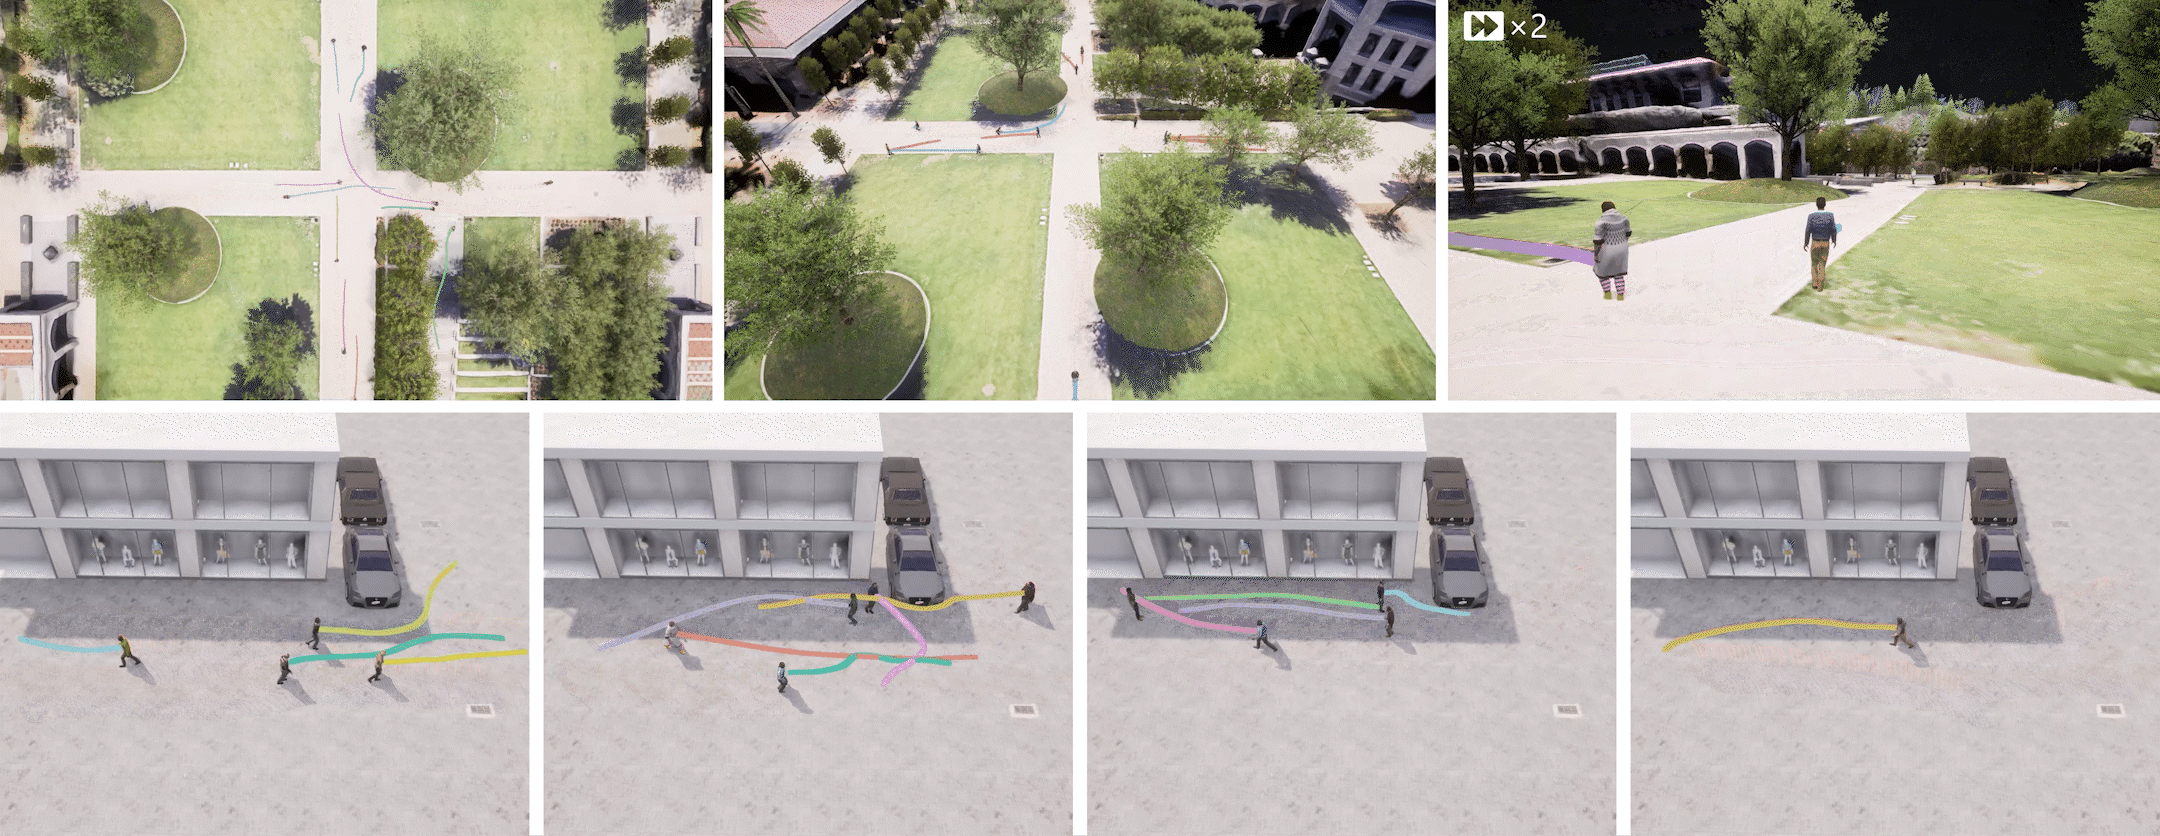
To visualize the generated crowd behaviors in 3D, we provide a visualization toolkit based on the CARLA simulator. Please follow the instructions in the 3D_Visualization_Toolkit/README file to set up the environment and visualize the results.
If you find this code useful for your research, please cite our trajectory prediction papers :)
🏢🚶♂️ CrowdES (CVPR'25) 🏃♀️🏠 |
💭 VLMTrajectory (TPAMI) 💭 |
💬 LMTrajectory (CVPR'24) 🗨️ |
1️⃣ SingularTrajectory (CVPR'24) 1️⃣ |
🌌 EigenTrajectory (ICCV'23) 🌌 |
🚩 Graph‑TERN (AAAI'23) 🚩 |
🧑🤝🧑 GP‑Graph (ECCV'22) 🧑🤝🧑 |
🎲 NPSN (CVPR'22) 🎲 |
🧶 DMRGCN (AAAI'21) 🧶
@inproceedings{bae2025crowdes,
  title={Continuous Locomotive Crowd Behavior Generation},
  author={Bae, Inhwan and Lee, Junoh and Jeon, Hae-Gon},
  booktitle={Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition},
  year={2025}
}
@article{bae2025vlmtrajectory,
  title={Social Reasoning-Aware Trajectory Prediction via Multimodal Language Model},
  author={Bae, Inhwan and Lee, Junoh and Jeon, Hae-Gon},
  journal={IEEE Transactions on Pattern Analysis and Machine Intelligence},
  year={2025}
}

@inproceedings{bae2024lmtrajectory,
  title={Can Language Beat Numerical Regression? Language-Based Multimodal Trajectory Prediction},
  author={Bae, Inhwan and Lee, Junoh and Jeon, Hae-Gon},
  booktitle={Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition},
  year={2024}
}

@inproceedings{bae2024singulartrajectory,
  title={SingularTrajectory: Universal Trajectory Predictor Using Diffusion Model},
  author={Bae, Inhwan and Park, Young-Jae and Jeon, Hae-Gon},
  booktitle={Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition},
  year={2024}
}

@inproceedings{bae2023eigentrajectory,
  title={EigenTrajectory: Low-Rank Descriptors for Multi-Modal Trajectory Forecasting},
  author={Bae, Inhwan and Oh, Jean and Jeon, Hae-Gon},
  booktitle={Proceedings of the IEEE/CVF International Conference on Computer Vision},
  year={2023}
}

@article{bae2023graphtern,
  title={A Set of Control Points Conditioned Pedestrian Trajectory Prediction},
  author={Bae, Inhwan and Jeon, Hae-Gon},
  journal={Proceedings of the AAAI Conference on Artificial Intelligence},
  year={2023}
}

@inproceedings{bae2022gpgraph,
  title={Learning Pedestrian Group Representations for Multi-modal Trajectory Prediction},
  author={Bae, Inhwan and Park, Jin-Hwi and Jeon, Hae-Gon},
  booktitle={Proceedings of the European Conference on Computer Vision},
  year={2022}
}

@inproceedings{bae2022npsn,
  title={Non-Probability Sampling Network for Stochastic Human Trajectory Prediction},
  author={Bae, Inhwan and Park, Jin-Hwi and Jeon, Hae-Gon},
  booktitle={Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition},
  year={2022}
}

@article{bae2021dmrgcn,
  title={Disentangled Multi-Relational Graph Convolutional Network for Pedestrian Trajectory Prediction},
  author={Bae, Inhwan and Jeon, Hae-Gon},
  journal={Proceedings of the AAAI Conference on Artificial Intelligence},
  year={2021}
}
Official Code for "Continuous Locomotive Crowd Behavior Generation (CVPR 2025)"
See the code
Inhwan Bae
·
Junoh Lee
·
Hae-Gon Jeon
CVPR 2025
Project Page
CVPR Paper
Source Code
3D Toolkit
Related Works
Summary: A crowd emitter diffusion model and a state-switching crowd simulator for populating input scene images and generating lifelong crowd trajectories.
Environment
All models were trained and tested on Ubuntu 20.04 with Python 3.10 and PyTorch 2.2.2 with CUDA 12.1. You can install all dependencies via following command:
pip install -r requirements.txt
Dataset
Preprocessed ETH, UCY, SDD and EDIN datasets are released in this repository.
[!NOTE]
If you want to preprocess the datasets by yourself, please download the raw datasets and run the following command:
python utils/preprocess_dataset.py --model_config <path_to_model_config>

# Example
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_eth.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_hotel.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_univ.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_zara1.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_zara2.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_sdd.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_gcs.yaml
python utils/preprocess_dataset.py --model_config ./configs/model/CrowdES_edin.yaml
To train the CrowdES crowd emitter model, you can use the following command:
python trainval.py --model_train emitter_pre --model_config <path_to_model_config>
python trainval.py --model_train emitter --model_config <path_to_model_config>

# Example
python trainval.py --model_train emitter_pre --model_config ./configs/model/CrowdES_eth.yaml
python trainval.py --model_train emitter --model_config ./configs/model/CrowdES_eth.yaml
To train the CrowdES crowd simulator model, you can use the following command:
python trainval.py --model_train simulator --model_config <path_to_model_config>

# Example
python trainval.py --model_train simulator --model_config ./configs/model/CrowdES_eth.yaml
We provide pretrained models in the release section.
To evaluate the CrowdES model, you can use the following command:
python trainval.py --test --model_config <path_to_model_config>

# Example
python trainval.py --test --model_config ./configs/model/CrowdES_eth.yaml
To export the generated trajectories from the CrowdES model, you can use the following command:
python trainval.py --export --model_config <path_to_model_config>

# Example
python trainval.py --export --model_config ./configs/model/CrowdES_eth.yaml
[!TIP] You can also customize the hyperparameters for exporting the generated trajectories by modifying the
CrowdES/evaluate_export_generated_traj.pyfile. Here are the default settings:
To evaluate the CrowdES model with a custom input image, you can use the following command:
python trainval.py --synthetic --model_config <path_to_model_config>

# Example
python trainval.py --synthetic --model_config ./configs/model/CrowdES_eth.yaml
[!TIP] You can also customize the hyperparameters by modifying the
CrowdES/evaluate_synthetic.pyfile. Here are the default settings:
To visualize the generated crowd behaviors in 3D, we provide a visualization toolkit based on the CARLA simulator. Please follow the instructions in the 3D_Visualization_Toolkit/README file to set up the environment and visualize the results.
If you find this code useful for your research, please cite our trajectory prediction papers :)
🏢🚶♂️ CrowdES (CVPR'25) 🏃♀️🏠 |
💭 VLMTrajectory (TPAMI) 💭 |
💬 LMTrajectory (CVPR'24) 🗨️ |
1️⃣ SingularTrajectory (CVPR'24) 1️⃣ |
🌌 EigenTrajectory (ICCV'23) 🌌 |
🚩 Graph‑TERN (AAAI'23) 🚩 |
🧑🤝🧑 GP‑Graph (ECCV'22) 🧑🤝🧑 |
🎲 NPSN (CVPR'22) 🎲 |
🧶 DMRGCN (AAAI'21) 🧶
@inproceedings{bae2025crowdes,
  title={Continuous Locomotive Crowd Behavior Generation},
  author={Bae, Inhwan and Lee, Junoh and Jeon, Hae-Gon},
  booktitle={Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition},
  year={2025}
}
@article{bae2025vlmtrajectory,
  title={Social Reasoning-Aware Trajectory Prediction via Multimodal Language Model},
  author={Bae, Inhwan and Lee, Junoh and Jeon, Hae-Gon},
  journal={IEEE Transactions on Pattern Analysis and Machine Intelligence},
  year={2025}
}

@inproceedings{bae2024lmtrajectory,
  title={Can Language Beat Numerical Regression? Language-Based Multimodal Trajectory Prediction},
  author={Bae, Inhwan and Lee, Junoh and Jeon, Hae-Gon},
  booktitle={Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition},
  year={2024}
}

@inproceedings{bae2024singulartrajectory,
  title={SingularTrajectory: Universal Trajectory Predictor Using Diffusion Model},
  author={Bae, Inhwan and Park, Young-Jae and Jeon, Hae-Gon},
  booktitle={Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition},
  year={2024}
}

@inproceedings{bae2023eigentrajectory,
  title={EigenTrajectory: Low-Rank Descriptors for Multi-Modal Trajectory Forecasting},
  author={Bae, Inhwan and Oh, Jean and Jeon, Hae-Gon},
  booktitle={Proceedings of the IEEE/CVF International Conference on Computer Vision},
  year={2023}
}

@article{bae2023graphtern,
  title={A Set of Control Points Conditioned Pedestrian Trajectory Prediction},
  author={Bae, Inhwan and Jeon, Hae-Gon},
  journal={Proceedings of the AAAI Conference on Artificial Intelligence},
  year={2023}
}

@inproceedings{bae2022gpgraph,
  title={Learning Pedestrian Group Representations for Multi-modal Trajectory Prediction},
  author={Bae, Inhwan and Park, Jin-Hwi and Jeon, Hae-Gon},
  booktitle={Proceedings of the European Conference on Computer Vision},
  year={2022}
}

@inproceedings{bae2022npsn,
  title={Non-Probability Sampling Network for Stochastic Human Trajectory Prediction},
  author={Bae, Inhwan and Park, Jin-Hwi and Jeon, Hae-Gon},
  booktitle={Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition},
  year={2022}
}

@article{bae2021dmrgcn,
  title={Disentangled Multi-Relational Graph Convolutional Network for Pedestrian Trajectory Prediction},
  author={Bae, Inhwan and Jeon, Hae-Gon},
  journal={Proceedings of the AAAI Conference on Artificial Intelligence},
  year={2021}
}



