[3DV'25 Award Candidate] 3D Reconstruction with Spatial Memory
See the code3D Reconstruction with Spatial Memory
Hengyi Wang, Lourdes Agapito
arXiv 2024
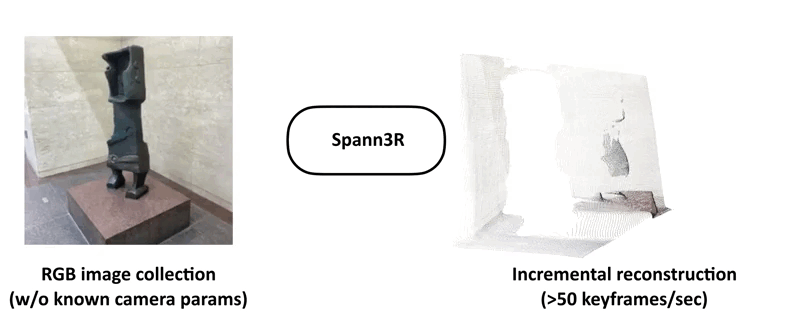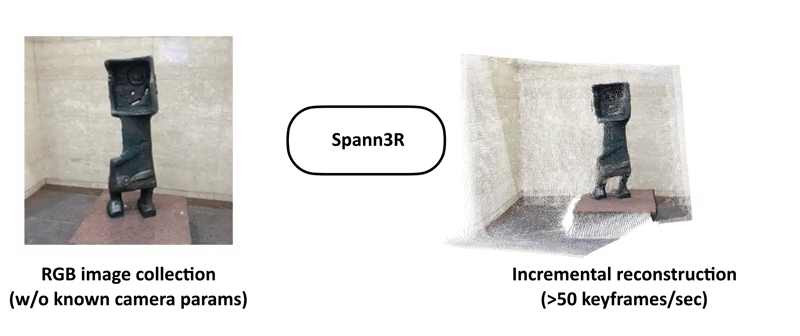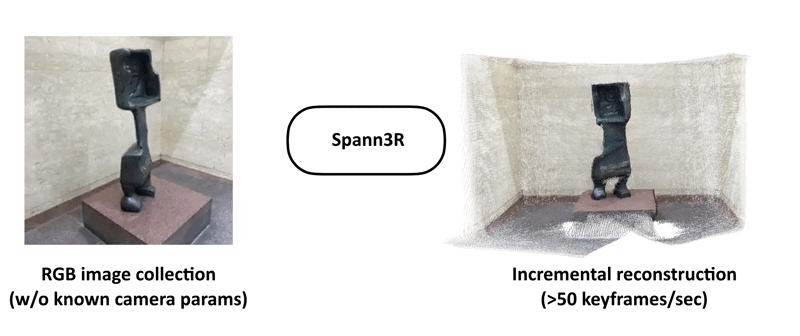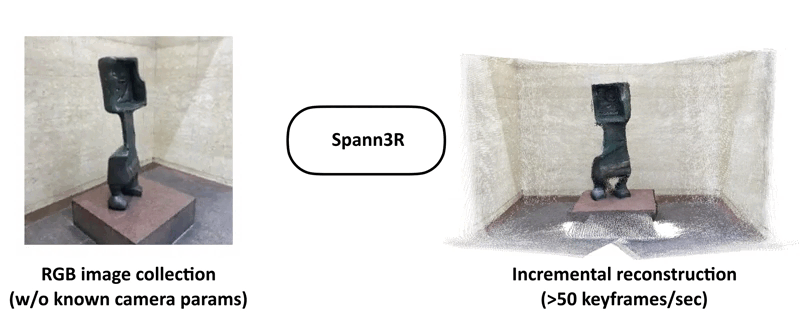
[2025-02-25] Spann3R v1.01 checkpoint released
[2024-10-25] Add support for Nerfstudio
[2024-10-18] Add camera param estimation
[2024-09-30] @hugoycj adds a gradio demo
[2024-09-20] Instructions for datasets data_preprocess.md
[2024-09-11] Code for Spann3R
Spann3R v1.01: We further train Spann3R with 10-frame sequence on a mixture of 15 datasets, including ScanNet, ScanNetpp, WildRGBD, Co3D, Aria, ArkitScene, BlendMVS, Waymo, Tartanair, OminiObject3d, Megadepth, Vkitti2, Unreal, Spring, Pointodyssey. (NOTE: We have removed Habitat from training, as we found that using our rendered Habitat sequences led to failure on synthetic data) We report the updated chamfer distance (mean) here:
| 7 Scenes | NRGBD | Replica | DTU | |
|---|---|---|---|---|
| Spann3R | 0.0291 | 0.0491 | N/A | 3.764 |
| Spann3R v1.01 | 0.0255 | 0.0437 | 0.0480 | 2.955 |
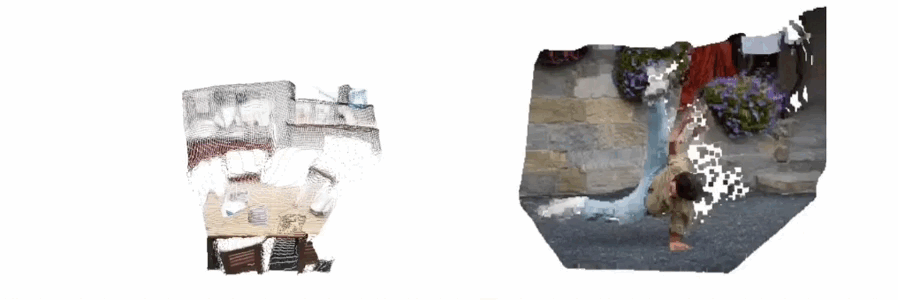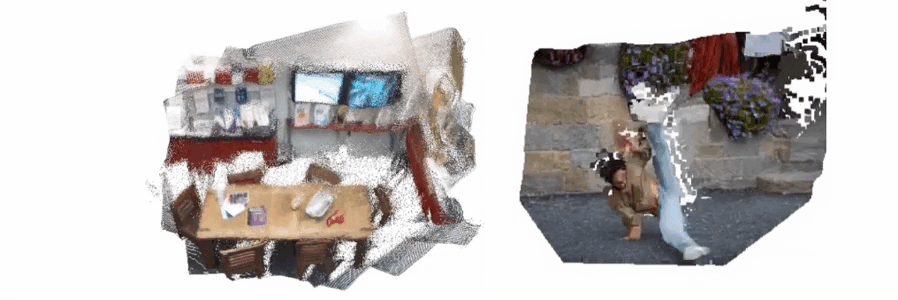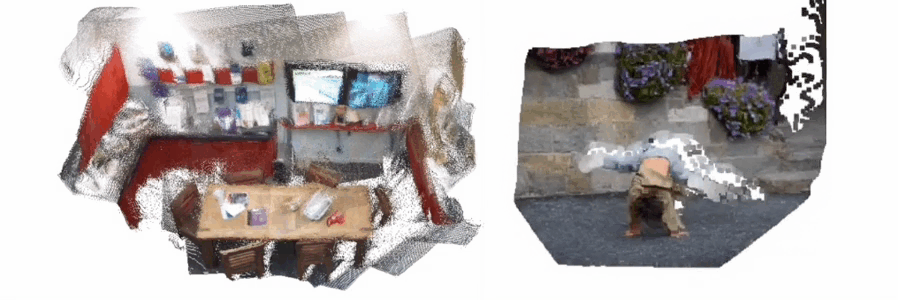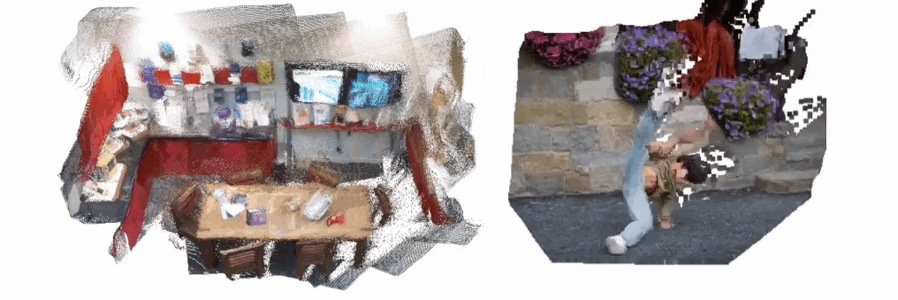
Also, since we include some dynamic scenes, Spann3R v1.01 now supports static/dynamic scene reconstruction. Here are some qualitative examples:
We acknowledge the support of the UKRI/EPSRC AI Hub in Generative Models [grant number EP/Y028805/1] for computing resources.
Clone Spann3R
git clone https://github.com/HengyiWang/spann3r.git
cd spann3r
Create conda environment
conda create -n spann3r python=3.9 cmake=3.14.0
conda install pytorch==2.3.0 torchvision==0.18.0 torchaudio==2.3.0 pytorch-cuda=11.8 -c pytorch -c nvidia  # use the correct version of cuda for your system

pip install -r requirements.txt

# Open3D has a bug from 0.16.0, please use dev version
pip install -U -f https://www.open3d.org/docs/latest/getting_started.html open3d
Compile cuda kernels for RoPE
cd croco/models/curope/
python setup.py build_ext --inplace
cd ../../../
Download the DUSt3R checkpoint
mkdir checkpoints
cd checkpoints
# Download DUSt3R checkpoints
wget https://download.europe.naverlabs.com/ComputerVision/DUSt3R/DUSt3R_ViTLarge_BaseDecoder_512_dpt.pth
Download our checkpoint and place it under ./checkpoints
Download the example data (2 scenes from map-free-reloc) and unzip it as ./examples
Run demo:
python demo.py --demo_path ./examples/s00567 --kf_every 10 --vis --vis_cam # --dynamic
For visualization --vis, it will give you a window to adjust the rendering view. Once you find the view to render, please click space key and close the window. The code will then do the rendering of the incremental reconstruction. --dynamic will give you a dynamic visualization that is suitable for dynamic scene reconstruction.
Nerfstudio:
# Run demo use --save_ori to save scaled intrinsics for original images
python demo.py --demo_path ./examples/s00567 --kf_every 10 --vis --vis_cam --save_ori

# Run splatfacto
ns-train splatfacto --data ./output/demo/s00567 --pipeline.model.camera-optimizer.mode SO3xR3

# Render your results
ns-render interpolate --load-config [path-to-your-config]/config.yml
Note that here you can use --save_ori to save the scaled intrinsics into transform.json to train NeRF/3D Gaussians with original images.'
We also provide a Gradio interface for a better experience, just run by:
# For Linux and Windows users (and macOS with Intel??)
python app.py
You can specify the --server_port, --share, --server_name arguments to satisfy your needs!
We use Habitat, ScanNet++, ScanNet, ArkitScenes, Co3D, and BlendedMVS to train our model. Please refer to data_preprocess.md.
Please use the following command to train our model:
torchrun --nproc_per_node 8 train.py --batch_size 4
Please use the following command to evaluate our model:
python eval.py
Our code, data preprocessing pipeline, and evaluation scripts are based on several awesome repositories:
We thank the authors for releasing their code!
The research presented here has been supported by a sponsored research award from Cisco Research and the UCL Centre for Doctoral Training in Foundational AI under UKRI grant number EP/S021566/1. This project made use of time on Tier 2 HPC facility JADE2, funded by EPSRC (EP/T022205/1).
If you find our code or paper useful for your research, please consider citing:
@article{wang20243d,
  title={3D Reconstruction with Spatial Memory},
  author={Wang, Hengyi and Agapito, Lourdes},
  journal={arXiv preprint arXiv:2408.16061},
  year={2024}
}
121 followers · starred Jan 2025
271 followers · starred Sep 2024
653 followers · starred Sep 2024
46 followers · starred Sep 2024
[3DV'25 Award Candidate] 3D Reconstruction with Spatial Memory
See the code3D Reconstruction with Spatial Memory
Hengyi Wang, Lourdes Agapito
arXiv 2024
[2025-02-25] Spann3R v1.01 checkpoint released
[2024-10-25] Add support for Nerfstudio
[2024-10-18] Add camera param estimation
[2024-09-30] @hugoycj adds a gradio demo
[2024-09-20] Instructions for datasets data_preprocess.md
[2024-09-11] Code for Spann3R
Spann3R v1.01: We further train Spann3R with 10-frame sequence on a mixture of 15 datasets, including ScanNet, ScanNetpp, WildRGBD, Co3D, Aria, ArkitScene, BlendMVS, Waymo, Tartanair, OminiObject3d, Megadepth, Vkitti2, Unreal, Spring, Pointodyssey. (NOTE: We have removed Habitat from training, as we found that using our rendered Habitat sequences led to failure on synthetic data) We report the updated chamfer distance (mean) here:
| 7 Scenes | NRGBD | Replica | DTU | |
|---|---|---|---|---|
| Spann3R | 0.0291 | 0.0491 | N/A | 3.764 |
| Spann3R v1.01 | 0.0255 | 0.0437 | 0.0480 | 2.955 |
Also, since we include some dynamic scenes, Spann3R v1.01 now supports static/dynamic scene reconstruction. Here are some qualitative examples:
We acknowledge the support of the UKRI/EPSRC AI Hub in Generative Models [grant number EP/Y028805/1] for computing resources.
Clone Spann3R
git clone https://github.com/HengyiWang/spann3r.git
cd spann3r
Create conda environment
conda create -n spann3r python=3.9 cmake=3.14.0
conda install pytorch==2.3.0 torchvision==0.18.0 torchaudio==2.3.0 pytorch-cuda=11.8 -c pytorch -c nvidia  # use the correct version of cuda for your system

pip install -r requirements.txt

# Open3D has a bug from 0.16.0, please use dev version
pip install -U -f https://www.open3d.org/docs/latest/getting_started.html open3d
Compile cuda kernels for RoPE
cd croco/models/curope/
python setup.py build_ext --inplace
cd ../../../
Download the DUSt3R checkpoint
mkdir checkpoints
cd checkpoints
# Download DUSt3R checkpoints
wget https://download.europe.naverlabs.com/ComputerVision/DUSt3R/DUSt3R_ViTLarge_BaseDecoder_512_dpt.pth
Download our checkpoint and place it under ./checkpoints
Download the example data (2 scenes from map-free-reloc) and unzip it as ./examples
Run demo:
python demo.py --demo_path ./examples/s00567 --kf_every 10 --vis --vis_cam # --dynamic
For visualization --vis, it will give you a window to adjust the rendering view. Once you find the view to render, please click space key and close the window. The code will then do the rendering of the incremental reconstruction. --dynamic will give you a dynamic visualization that is suitable for dynamic scene reconstruction.
Nerfstudio:
# Run demo use --save_ori to save scaled intrinsics for original images
python demo.py --demo_path ./examples/s00567 --kf_every 10 --vis --vis_cam --save_ori

# Run splatfacto
ns-train splatfacto --data ./output/demo/s00567 --pipeline.model.camera-optimizer.mode SO3xR3

# Render your results
ns-render interpolate --load-config [path-to-your-config]/config.yml
Note that here you can use --save_ori to save the scaled intrinsics into transform.json to train NeRF/3D Gaussians with original images.'
We also provide a Gradio interface for a better experience, just run by:
# For Linux and Windows users (and macOS with Intel??)
python app.py
You can specify the --server_port, --share, --server_name arguments to satisfy your needs!
We use Habitat, ScanNet++, ScanNet, ArkitScenes, Co3D, and BlendedMVS to train our model. Please refer to data_preprocess.md.
Please use the following command to train our model:
torchrun --nproc_per_node 8 train.py --batch_size 4
Please use the following command to evaluate our model:
python eval.py
Our code, data preprocessing pipeline, and evaluation scripts are based on several awesome repositories:
We thank the authors for releasing their code!
The research presented here has been supported by a sponsored research award from Cisco Research and the UCL Centre for Doctoral Training in Foundational AI under UKRI grant number EP/S021566/1. This project made use of time on Tier 2 HPC facility JADE2, funded by EPSRC (EP/T022205/1).
If you find our code or paper useful for your research, please consider citing:
@article{wang20243d,
  title={3D Reconstruction with Spatial Memory},
  author={Wang, Hengyi and Agapito, Lourdes},
  journal={arXiv preprint arXiv:2408.16061},
  year={2024}
}
121 followers · starred Jan 2025
271 followers · starred Sep 2024
653 followers · starred Sep 2024
46 followers · starred Sep 2024



