
README
Awesome-Memory-for-Robotics
🤖 Memory is a fundamental capability to store, retrieve, and utilize past experiences for improved perception, planning, and decision-making. This mechanism enables robots to learn from experience, adapt to new situations, and operate effectively in complex, dynamic environments.
Here we organized a list of resources on memory for robotics, including papers, code, datasets, and benchmarks.
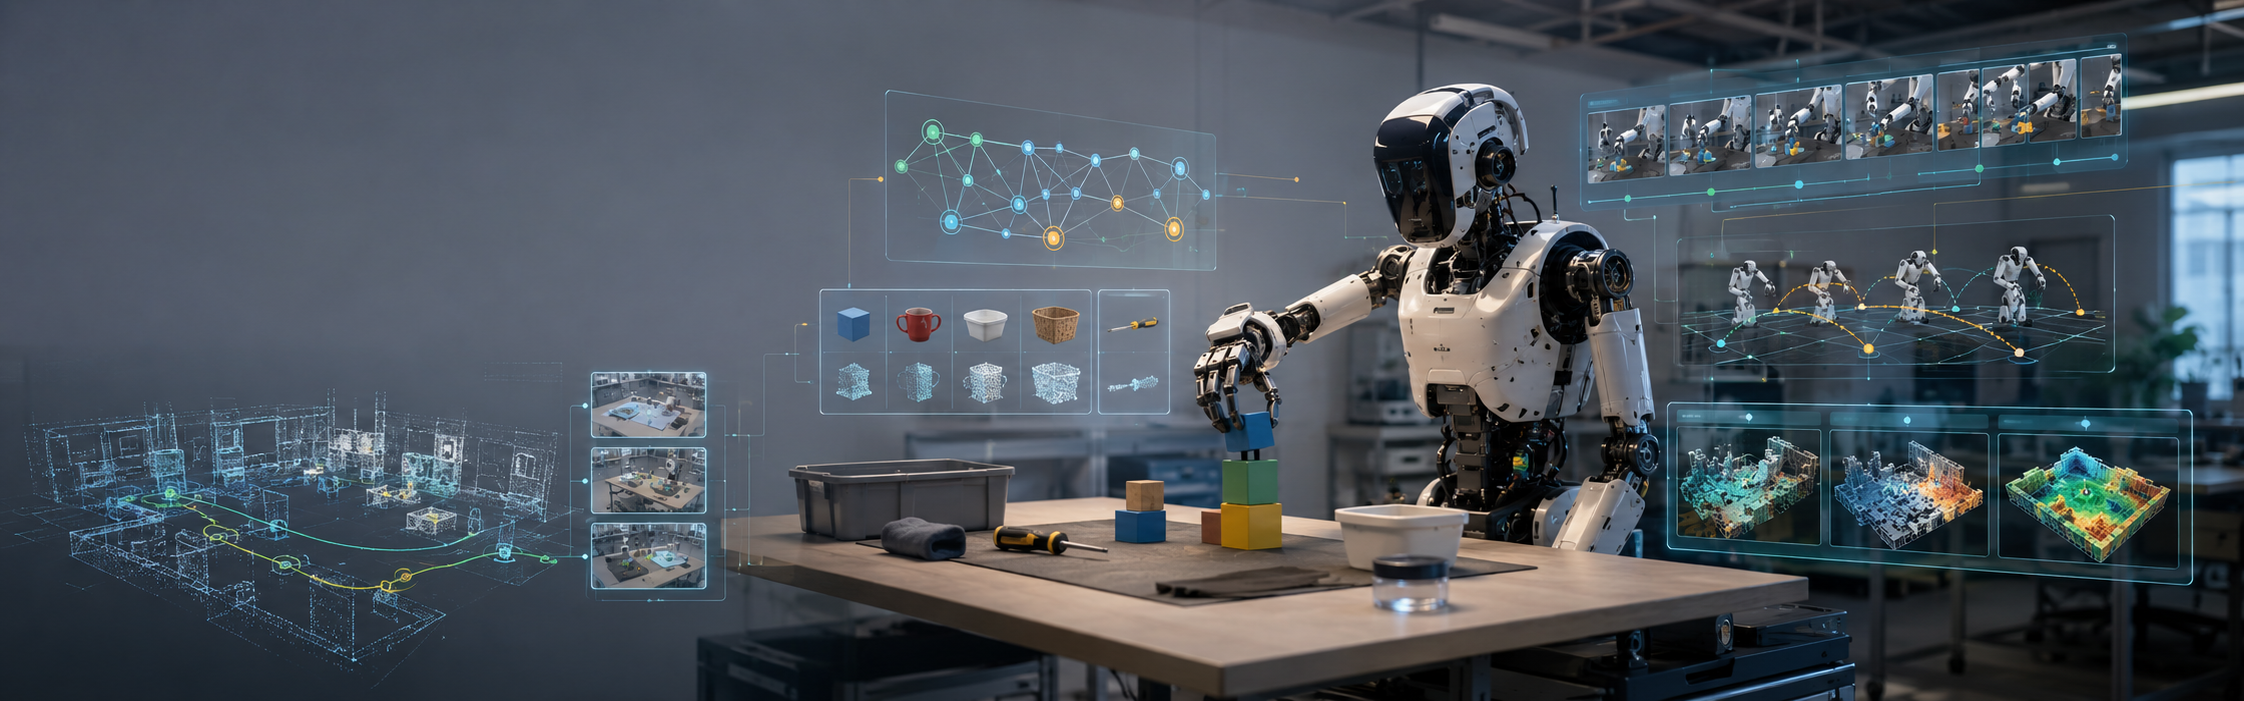
Scope: Robotics + Memory , not generic LLM memory.
📋 Table of Contents
- Surveys & Overviews
- Memory Systems & Cognitive Architecture
- Memory for Manipulation
- Memory for Navigation
- Memory for Locomotion
- Spatial & Scene Memory
- World Models & Memory
- Lifelong Learning & Continual Learning
- Benchmarks & Evaluation
- Datasets
- Contributing
Taxonomy
Memory in robotics often mixes multiple axes:
- Timescale
- Contextual memory (within-episode, short-term working memory)
- Episodic memory (experience replay / trajectories / videos)
- Semantic memory (facts, object affordances, task graphs)
- Long-term memory (stable knowledge across tasks)
- Representation
- key-value / slot memory, RNN / LSTM / Transformer state
- retrieval over embeddings (RAG / vector DB)
- 3D maps / NeRF / Gaussian splats / voxel grids
- symbolic graphs (scene graphs / task graphs)
- Usage
- policy conditioning (retrieve then act)
- planning (search over remembered states)
- perception (temporal integration / object permanence)
- safety & failure recovery (remember mistakes)
Read more: docs/taxonomy.md
Surveys & Overviews
There hasn't been a comprehensive survey on memory for robotics, we hope this list can help.
| Paper | Venue | Year | Links |
|---|---|---|---|
| MemoryArena: Benchmarking Agent Memory in Interdependent Multi-Session Agentic Tasks | arXiv | 2026 | [Paper] |
| World Model for Robot Learning: A Comprehensive Survey | arXiv | 2026 | [Paper] |
| From Human Memory to AI Memory: A Survey on Memory Mechanisms in the Era of LLMs | arXiv | 2025 | [Paper] |
| Foundation Models in Robotics: Applications, Challenges, and the Future | IJRR | 2025 | [Paper] |
| Foundation Model Driven Robotics: A Comprehensive Review | arXiv | 2025 | [Paper] |
| Partially Observable Markov Decision Processes in Robotics: A Survey | IEEE T-RO | 2022 | [Paper] |
| Skill Transfer Learning for Autonomous Robots and Human-Robot Cooperation: A Survey | RAS | 2020 | [Paper] |
Memory Systems & Cognitive Architecture
People built memory for robots from our cognitive science. Here are some classical papers:
| Paper | Venue | Year | Links |
|---|---|---|---|
| RoboMemory: A Brain-inspired Multi-memory Agentic Framework for Interactive Environmental Learning in Physical Embodied Systems | arXiv | 2025 | [Paper] |
| A Memory System of a Robot Cognitive Architecture and its Implementation in ArmarX | RAS | 2023 | [Paper] |
| A Memory System for a Conscious Robot | Frontiers | 2018 | [Paper] |
| Memory as the Substrate of Cognition: A Developmental Cognitive Robotics Perspective | ResearchGate | 2015 | [Paper] |
| Dynamic Learning in Cognitive Robotics through a Procedural Long Term Memory | EAAI | 2013 | [Paper] |
| The Development of Embodied Cognition: Six Lessons from Babies | Artificial Life | 2005 | [Paper] |
Further, I divide memory into four categories: Contextual memory, episodic memory, semantic memory, and long-horizon memory.
Contextual Memory
Working memory maintains task-relevant information during execution. It enables robots to track object states, maintain spatial awareness, and hold intermediate computation results. It is usually implemented by keyframe, history and context-window.
| Paper | Venue | Year | Links |
|---|---|---|---|
| MEM: Multi-Scale Embodied Memory for Vision Language Action Models | Physical Intelligence | 2026 | [Paper] [Project] |
| ReMem-VLA: Empowering Vision-Language-Action Model with Memory via Dual-Level Recurrent Queries | arXiv | 2026 | [Paper] |
| Beyond Short-Horizon: VQ-Memory for Robust Long-Horizon Manipulation in Non-Markovian Simulation Benchmarks | arXiv | 2026 | [Paper] [Project] |
| Causal Video Models Are Data-Efficient Robot Policy Learners (DVA) | Rhoda AI | 2026 | [Project] |
| DreamZero: World Action Models are Zero-shot Policies | arXiv | 2026 | [Paper] [Project] [Code] |
| MemER: Scaling Up Memory for Robot Control via Experience Retrieval | arXiv | 2025 | [Paper] [Project] |
| Beyond Sliding Windows: Learning to Manage Memory in Non-Markovian Environments | arXiv | 2025 | [Paper] |
| Scaling Short-Term Memory of Visuomotor Policies for Long-Horizon Tasks (PRISM) | Under Review | 2025 | [Project] |
| Learning Long-Context Diffusion Policies via Past-Token Prediction | CoRL | 2025 | [Paper] [Project] |
| SAM2Act: Integrating Visual Foundation Model with A Memory Architecture for Robotic Manipulation | ICML | 2025 | [Paper] |
| A Working Memory Model Improves Cognitive Control in Agents and Robots | COGSYS | 2018 | [Paper] |
| Short-term Memory Mechanisms in Neural Network Learning of Robot Navigation Tasks | IEEE | 2010 | [Paper] |
Episodic Memory
Episodic memory stores specific events and experiences from the robot's past, enabling recall of particular situations, trajectories, and outcomes. It is usually implemented by memory banks, replay buffers, or latent tokens.
| Paper | Venue | Year | Links |
|---|---|---|---|
| Chameleon: Episodic Memory for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| HELM: Harness-Enhanced Long-horizon Memory for Vision-Language-Action Manipulation | arXiv | 2026 | [Paper] |
| MemoryVLA: Perceptual-Cognitive Memory in Vision-Language-Action Models for Robotic Manipulation | arXiv | 2025 | [Paper] |
| Forgetting in Robotic Episodic Long-Term Memory | ECAI | 2024 | [Paper] |
| Long Horizon Episodic Decision Making for Cognitively Inspired Robots | COGSYS | 2024 | [Paper] |
| Episodic Memory Model for Learning Robotic Manipulation | arXiv | 2021 | [Paper] |
| ART Neural Network-based Integration of Episodic Memory and Semantic Memory for Task Planning | AURO | 2019 | [Paper] |
| Deep Episodic Memory: Encoding, Recalling, and Predicting Episodic Experiences for Robot Action Execution | IEEE RAL | 2018 | [Paper] |
| Storing and Retrieving Perceptual Episodic Memories for Long-term Manipulation Tasks | ICAR | 2017 | [Paper] |
| Towards an Episodic Memory for Cognitive Robots | ECAI Workshop | 2008 | [Paper] |
Semantic Memory
Language provides robots with structured knowledge about concepts, objects, and their relationships. It is usually implemented by Neural Symbolic Model, Chain of Thought Reasoning, or Scene Graphs.
| Paper | Venue | Year | Links |
|---|---|---|---|
| EchoVLA: Synergistic Declarative Memory for VLA-Driven Mobile Manipulation | arXiv | 2026 | [Paper] |
| GraSP-VLA: Graph-based Symbolic Action Representation for Long-Horizon Planning with VLA Policies | arXiv | 2025 | [Paper] |
| Enter the Mind Palace: Reasoning and Planning for Long-term Active Embodied Question Answering | arXiv | 2025 | [Paper] |
| Memory-Centric Embodied Question Answering | arXiv | 2025 | [Paper] |
| CRESTA: A Cognitivist Framework for Semantic-driven Task Awareness | RAS | 2025 | [Paper] |
| A Semantic Memory System for Task Planning under Uncertainties | IROS | 2010 | [Paper] |
| KnowRob: Knowledge processing for autonomous robots | IROS | 2009 | [Paper] |
| Robot Task Planning using Semantic Maps | RAS | 2008 | [Paper] |
Long-term Memory
Long-term memory enables continuous accumulation of knowledge across tasks and sessions, supporting lifelong learning and adaptation without catastrophic forgetting. It is usually implemented by experience replay, skill transfer, or continual learning.
| Paper | Venue | Year | Links |
|---|---|---|---|
| MEM: Multi-Scale Embodied Memory for Vision Language Action Models | Physical Intelligence | 2026 | [Paper] [Project] |
| ReMem-VLA: Empowering Vision-Language-Action Model with Memory via Dual-Level Recurrent Queries | arXiv | 2026 | [Paper] |
| Chameleon: Episodic Memory for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| HELM: Harness-Enhanced Long-horizon Memory for Vision-Language-Action Manipulation | arXiv | 2026 | [Paper] |
| EchoVLA: Synergistic Declarative Memory for VLA-Driven Mobile Manipulation | arXiv | 2026 | [Paper] |
| RoboMemory: A Brain-inspired Multi-memory Agentic Framework for Interactive Environmental Learning in Physical Embodied Systems | arXiv | 2025 | [Paper] |
| Preserving and Combining Knowledge in Robotic Lifelong Reinforcement Learning | Nature Machine Intelligence | 2025 | [Paper] |
| LIBERO: Benchmarking Knowledge Transfer for Lifelong Robot Learning | NeurIPS | 2023 | [Paper] |
| Online Active Continual Learning for Robotic Lifelong Object Recognition | IEEE T-NNLS | 2023 | [Paper] |
| Lifelong Robotic Reinforcement Learning by Retaining Experiences | CoLLAs | 2022 | [Paper] |
| A lifelong learning approach to mobile robot navigation | ICRA | 2021 | [Paper] |
| Learning an Embedding Space for Transferable Robot Skills | ICLR | 2018 | [Paper] |
| RoboEarth: A World Wide Web for Robots | IEEE RA Mag | 2011 | [Paper] |
| RatSLAM: A hippocampal model for simultaneous localization and mapping | ICRA | 2004 | [Paper] |
| Lifelong robot learning | RAS | 1995 | [Paper] [Project] |
Memory for Manipulation
Robotics Foundation Models (RFMs)
Because non-markovian property makes RFMs like VLAs prone to overfit, it's a huge challenge for RFMs to learn memory. We need to design spatial-temporal memory mechanisms carefully.
| Paper | Venue | Year | Links |
|---|---|---|---|
| π0.7: A Steerable Model with Emergent Capabilities | Physical Intelligence | 2026 | [Paper] [Project] |
| Causal Video Models Are Data-Efficient Robot Policy Learners (DVA) | Rhoda AI | 2026 | [Project] |
| DreamZero: World Action Models are Zero-shot Policies | arXiv | 2026 | [Paper] [Project] [Code] |
| MEM: Multi-Scale Embodied Memory for Vision Language Action Models | Physical Intelligence | 2026 | [Paper] [Project] |
| ReMem-VLA: Empowering Vision-Language-Action Model with Memory via Dual-Level Recurrent Queries | arXiv | 2026 | [Paper] |
| HELM: Harness-Enhanced Long-horizon Memory for Vision-Language-Action Manipulation | arXiv | 2026 | [Paper] |
| EchoVLA: Synergistic Declarative Memory for VLA-Driven Mobile Manipulation | arXiv | 2026 | [Paper] |
| Beyond Short-Horizon: VQ-Memory for Robust Long-Horizon Manipulation in Non-Markovian Simulation Benchmarks | arXiv | 2026 | [Paper] [Project] |
| OptimusVLA: Global Prior Meets Local Consistency: Dual-Memory Augmented Vision-Language-Action Model for Efficient Robotic Manipulation | CVPR | 2026 | [Paper] |
| MemER: Scaling Up Memory for Robot Control via Experience Retrieval | arXiv | 2025 | [Paper] [Project] |
| HAMLET: Switch your Vision-Language-Action Model into a History-Aware Policy | arXiv | 2025 | [Paper] [Project] |
| HiF-VLA: Hindsight, Insight and Foresight through Motion Representation for Vision-Language-Action Models | arXiv | 2025 | [Paper] |
| CronusVLA: Towards Efficient and Robust Manipulation via Multi-Frame Vision-Language-Action Modeling | ArKiv | 2025 | [Paper] [Project] |
| GraSP-VLA: Graph-based Symbolic Action Representation for Long-Horizon Planning with VLA Policies | arXiv | 2025 | [Paper] |
| MemoryVLA: Perceptual-Cognitive Memory in Vision-Language-Action Models for Robotic Manipulation | arXiv | 2025 | [Paper] |
Mobile Manipulation
| Paper | Venue | Year | Links |
|---|---|---|---|
| EchoVLA: Synergistic Declarative Memory for VLA-Driven Mobile Manipulation | arXiv | 2026 | [Paper] |
| Searching in Space and Time: Unified Memory-Action Loops for Open-World Object Retrieval | arXiv | 2025 | [Paper] [Project] |
| DynaMem: Online Dynamic Spatio-Semantic Memory for Open World Mobile Manipulation | arXiv | 2024 | [Paper] |
| CLIP-Fields: Weakly Supervised Semantic Fields for Robotic Memory | RSS | 2023 | [Paper] [Project] |
General Manipulation
| Paper | Venue | Year | Links |
|---|---|---|---|
| Chameleon: Episodic Memory for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| HELM: Harness-Enhanced Long-horizon Memory for Vision-Language-Action Manipulation | arXiv | 2026 | [Paper] |
| Beyond Short-Horizon: VQ-Memory for Robust Long-Horizon Manipulation in Non-Markovian Simulation Benchmarks | arXiv | 2026 | [Paper] [Project] |
| RMBench: Memory-Dependent Robotic Manipulation Benchmark with Insights into Policy Design | arXiv | 2026 | [Paper] [Project] [Code] |
| Rethinking Progression of Memory State in Robotic Manipulation: An Object-Centric Perspective | AAAI | 2026 | [Paper] |
| Gated Memory Policy | arXiv | 2026 | [Paper] [Project] |
| OptimusVLA: Global Prior Meets Local Consistency: Dual-Memory Augmented Vision-Language-Action Model for Efficient Robotic Manipulation | CVPR | 2026 | [Paper] |
| Learning Long-Context Diffusion Policies via Past-Token Prediction | CoRL | 2025 | [Paper] [Project] |
| SAM2Act: Integrating Visual Foundation Model with A Memory Architecture for Robotic Manipulation | ICML | 2025 | [Paper] |
| Out of Sight, Still in Mind: Reasoning and Planning about Unobserved Objects with Video Tracking Enabled Memory Models | ICRA | 2024 | [Paper] |
| RoboEXP: Action-Conditioned Scene Graph via Interactive Exploration for Robotic Manipulation | CoRL | 2024 | [Paper] [Project] |
Memory for Navigation
Memory is of great importance for navigation, there has been rich research on it.
| Paper | Venue | Year | Links |
|---|---|---|---|
| Remember to be Curious: Episodic Context and Persistent Worlds for 3D Exploration | arXiv | 2026 | [Paper] [Project] [Code] |
| Spatially-Enhanced Recurrent Memory for Long-Range Mapless Navigation via End-to-End Reinforcement Learning | arXiv | 2025 | [Paper] |
| MemoNav: Working Memory Model for Visual Navigation | CVPR | 2024 | [Paper] |
| Memory-Maze: Scenario Driven Benchmark and Visual Language Navigation Model for Guiding Blind People | arXiv | 2024 | [Paper] |
| Visual Language Maps for Robot Navigation (VLMaps) | ICRA | 2023 | [Paper] [Project] |
| Emergence of Maps in the Memories of Blind Navigation Agents | ICLR | 2023 | [Paper] [Project] |
| Memory-Augmented Reinforcement Learning for Image-Goal Navigation | IROS | 2022 | [Paper] |
| Structured Scene Memory for Vision-Language Navigation | CVPR | 2021 | [Paper] |
| Visual Graph Memory with Unsupervised Representation for Visual Navigation | ICCV | 2021 | [Paper] |
| Deep Visual Odometry With Adaptive Memory | TPAMI | 2020 | [Paper] |
| MultiON: Benchmarking Semantic Map Memory using Multi-Object Navigation | NeurIPS | 2020 | [Paper] |
| Scene Memory Transformer for Embodied Agents in Long-Horizon Tasks | CVPR | 2019 | [Paper] |
| Visual Memory for Robust Path Following | NeurIPS | 2018 | [Paper] |
| Cognitive Memory and Mapping in a Brain-like System for Robotic Navigation | Neural Networks | 2017 | [Paper] |
| Learning Indoor Robot Navigation using Visual and Sensorimotor Map | PMC | 2013 | [Paper] |
| Image-based Robot Navigation from an Image Memory | RAS | 2007 | [Paper] |
| 3D Navigation based on a Visual Memory | ICRA | 2006 | [Paper] |
Memory for Locomotion
| Paper | Venue | Year | Links |
|---|---|---|---|
| LocoFormer: Generalist Locomotion via Long-context Adaptation | CoRL | 2025 | [Paper] [Project] |
| Sim-to-Real Transfer for Quadrupedal Locomotion via Terrain Transformer (TERT) | RA-L | 2023 | [Paper] |
| Learning Vision-Guided Quadrupedal Locomotion End-to-End with Cross-Modal Transformers (LocoTransformer) | ICLR | 2022 | [Paper] [Project] |
| RMA: Rapid Motor Adaptation for Legged Robots | RSS | 2021 | [Paper] [Project] |
| Rapidly Adaptable Legged Robots via Evolutionary Meta-Learning | IROS | 2020 | [Paper] [Blog] |
Spatial & Scene Memory
3D Scene Memory
Representing and reasoning about 3D environments.
| Paper | Venue | Year | Links |
|---|---|---|---|
| Remember to be Curious: Episodic Context and Persistent Worlds for 3D Exploration | arXiv | 2026 | [Paper] [Project] [Code] |
| 3D-Mem: 3D Scene Memory for Embodied Exploration and Reasoning | CVPR | 2025 | [Paper] [Project] [Code] |
| What Is The Best 3D Scene Representation for Robotics? | arXiv | 2025 | [Paper] |
| SnapMem: 3D Scene Memory for Embodied Exploration | OpenReview | 2024 | [Paper] |
| Embodied-RAG: General Non-parametric Embodied Memory for Retrieval and Generation | arXiv | 2024 | [Paper] |
| Searching in Space and Time: Unified Memory-Action Loops for Open-World Object Retrieval | arXiv | 2025 | [Paper] [Project] |
| ConceptFusion: Open-set Multimodal 3D Mapping | RSS | 2023 | [Paper] [Project] |
| Hierarchical Representations and Explicit Memory: Learning Effective Navigation Policies on 3D Scene Graphs | ICRA | 2022 | [Paper] |
Spatial Memory & SLAM
Simultaneous Localization and Mapping(SLAM) is the most fundamental explicit type of memory.
| Paper | Venue | Year | Links |
|---|---|---|---|
| Unsupervised Online Learning for Robotic Interestingness with Visual Memory | IEEE T-RO | 2021 | [Paper] [Code] |
| Probabilistic Data Association for Semantic SLAM | ICRA | 2017 | [Paper] |
| SLAM-Based Spatial Memory for Behavior-Based Robots | IFAC | 2015 | [Paper] |
| RGB-D Mapping: Using Kinect-Style Depth Cameras for Dense 3D Modeling of Indoor Environments | IJRR | 2012 | [Paper] |
World Models & Memory
World models that incorporate memory for prediction and planning.
| Paper | Venue | Year | Links |
|---|---|---|---|
| Causal Video Models Are Data-Efficient Robot Policy Learners (DVA) | Rhoda AI | 2026 | [Project] |
| MosaicMem: Persistent Geometry + Dynamic Content for Long-Horizon World Models | arXiv | 2026 | [Paper] [Project] |
| World Model for Robot Learning: A Comprehensive Survey | arXiv | 2026 | [Paper] |
| DreamZero: World Action Models are Zero-shot Policies | arXiv | 2026 | [Paper] [Project] [Code] |
| Mastering Diverse Control Tasks through World Models | Nature | 2025 | [Paper] |
| Ctrl-World: A Controllable Generative World Model for Robot Manipulation | arXiv | 2025 | [Paper] |
| Genie 3: A New Frontier for World Models | Google DeepMind | 2025 | [Blog] |
| ManiGaussian: Dynamic Gaussian Splatting for Multi-task Robotic Manipulation | ECCV | 2024 | [Paper] [Project] |
| Mastering Memory Tasks with World Models (R2I) | ICLR | 2024 | [Paper] |
Lifelong Learning & Continual Learning
Experience Replay
| Paper | Venue | Year | Links |
|---|---|---|---|
| Lifelong Robotic Reinforcement Learning by Retaining Experiences | CoLLAs | 2022 | [Paper] |
| Selective Experience Replay for Lifelong Learning | AAAI | 2018 | [Paper] |
Lifelong Learning Frameworks
| Paper | Venue | Year | Links |
|---|---|---|---|
| Preserving and Combining Knowledge in Robotic Lifelong Learning | Nature MI | 2025 | [Paper] |
| Towards General Purpose Robots at Scale: Memory and Lifelong Learning | arXiv | 2024 | [Paper] |
| A Lifelong Learning Approach to Mobile Robot Navigation | IEEE RAL | 2021 | [Paper] |
Skill Transfer & Memory
| Paper | Venue | Year | Links |
|---|---|---|---|
| Efficient Policy Learning by Extracting Transferable Robot Skills | CoRL | 2024 | [Paper] |
| Unsupervised Skill Transfer Learning for Autonomous Robots | RAS | 2021 | [Paper] |
| Skill Transfer Learning for Autonomous Robots and Human-Robot Cooperation: A Survey | RAS | 2020 | [Paper] |
| Learning an Embedding Space for Transferable Robot Skills | ICLR | 2018 | [Paper] |
Benchmarks & Evaluation
We treasure these features that actually pose challenges to memory:
- Partial observability: occlusions, hidden states, deferred rewards
- Long-horizon: requires recalling earlier observations/instructions
- Distribution shift: new scenes, objects, layouts
- Recovery: can the robots use memory to diagnose and retry?
| Benchmark | Year | Focus | Links |
|---|---|---|---|
| RoboMemArena | 2026 | 26 long-horizon memory tasks with multimodal memory annotations and paired real-world tasks | [Paper] [Project] |
| MIKASA-Robo-VLA | 2026 | 90 memory tasks across 10 memory types for VLA evaluation on tabletop manipulation | [Paper] [Project] [Code] |
| RoboMME | 2026 | 16 manipulation tasks for temporal, spatial, object, and procedural memory in robotic generalist policies | [Paper] [Project] |
| RMBench | 2026 | 9 memory-dependent manipulation tasks over multiple memory-complexity levels | [Paper] [Project] [Code] |
| LIBERO-Mem | 2026 | Object-centric non-Markovian manipulation under object-level partial observability | [Paper] |
| MemMimic | 2026 | Non-Markovian imitation tasks with in-trial and cross-trial memory regimes | [Paper] [Project] |
| AbstainEQA | 2025 | Benchmarks abstention in embodied QA — when agents should say "I don't know" — across 5 categories with 1,636 ambiguous question variants; frontier models reach only 42.79% abstention recall vs. 91.17% for humans | [Paper] [Project] [Code] |
Read more: docs/evaluation.md
Datasets
See: docs/datasets.md
Citation
If you find this repository useful, please consider citing:
@misc{awesome-memory-for-robotics,
  author = {Jie Wang},
  title = {Awesome Memory for Robotics},
  year = {2025},
  publisher = {GitHub},
  howpublished = {\url{https://github.com/Everloom-129/Awesome-Memory-for-Robotics}}
}
Contributing
PRs welcome! Please read the contribution guidelines.
To add a new paper or resource:
- Fork this repository
- Add your entry in the appropriate section
- Submit a pull request
Please ensure your PR follows the existing format and includes:
- Paper title
- Venue and year
- Links to paper, code, and project page (if available)
Related Awesome Lists
License

This work is licensed under CC0 1.0 Universal.
⭐ Star this repository if you find it useful! ⭐


README
Awesome-Memory-for-Robotics
🤖 Memory is a fundamental capability to store, retrieve, and utilize past experiences for improved perception, planning, and decision-making. This mechanism enables robots to learn from experience, adapt to new situations, and operate effectively in complex, dynamic environments.
Here we organized a list of resources on memory for robotics, including papers, code, datasets, and benchmarks.
Scope: Robotics + Memory , not generic LLM memory.
📋 Table of Contents
- Surveys & Overviews
- Memory Systems & Cognitive Architecture
- Memory for Manipulation
- Memory for Navigation
- Memory for Locomotion
- Spatial & Scene Memory
- World Models & Memory
- Lifelong Learning & Continual Learning
- Benchmarks & Evaluation
- Datasets
- Contributing
Taxonomy
Memory in robotics often mixes multiple axes:
- Timescale
- Contextual memory (within-episode, short-term working memory)
- Episodic memory (experience replay / trajectories / videos)
- Semantic memory (facts, object affordances, task graphs)
- Long-term memory (stable knowledge across tasks)
- Representation
- key-value / slot memory, RNN / LSTM / Transformer state
- retrieval over embeddings (RAG / vector DB)
- 3D maps / NeRF / Gaussian splats / voxel grids
- symbolic graphs (scene graphs / task graphs)
- Usage
- policy conditioning (retrieve then act)
- planning (search over remembered states)
- perception (temporal integration / object permanence)
- safety & failure recovery (remember mistakes)
Read more: docs/taxonomy.md
Surveys & Overviews
There hasn't been a comprehensive survey on memory for robotics, we hope this list can help.
| Paper | Venue | Year | Links |
|---|---|---|---|
| MemoryArena: Benchmarking Agent Memory in Interdependent Multi-Session Agentic Tasks | arXiv | 2026 | [Paper] |
| World Model for Robot Learning: A Comprehensive Survey | arXiv | 2026 | [Paper] |
| From Human Memory to AI Memory: A Survey on Memory Mechanisms in the Era of LLMs | arXiv | 2025 | [Paper] |
| Foundation Models in Robotics: Applications, Challenges, and the Future | IJRR | 2025 | [Paper] |
| Foundation Model Driven Robotics: A Comprehensive Review | arXiv | 2025 | [Paper] |
| Partially Observable Markov Decision Processes in Robotics: A Survey | IEEE T-RO | 2022 | [Paper] |
| Skill Transfer Learning for Autonomous Robots and Human-Robot Cooperation: A Survey | RAS | 2020 | [Paper] |
Memory Systems & Cognitive Architecture
People built memory for robots from our cognitive science. Here are some classical papers:
| Paper | Venue | Year | Links |
|---|---|---|---|
| RoboMemory: A Brain-inspired Multi-memory Agentic Framework for Interactive Environmental Learning in Physical Embodied Systems | arXiv | 2025 | [Paper] |
| A Memory System of a Robot Cognitive Architecture and its Implementation in ArmarX | RAS | 2023 | [Paper] |
| A Memory System for a Conscious Robot | Frontiers | 2018 | [Paper] |
| Memory as the Substrate of Cognition: A Developmental Cognitive Robotics Perspective | ResearchGate | 2015 | [Paper] |
| Dynamic Learning in Cognitive Robotics through a Procedural Long Term Memory | EAAI | 2013 | [Paper] |
| The Development of Embodied Cognition: Six Lessons from Babies | Artificial Life | 2005 | [Paper] |
Further, I divide memory into four categories: Contextual memory, episodic memory, semantic memory, and long-horizon memory.
Contextual Memory
Working memory maintains task-relevant information during execution. It enables robots to track object states, maintain spatial awareness, and hold intermediate computation results. It is usually implemented by keyframe, history and context-window.
| Paper | Venue | Year | Links |
|---|---|---|---|
| MEM: Multi-Scale Embodied Memory for Vision Language Action Models | Physical Intelligence | 2026 | [Paper] [Project] |
| ReMem-VLA: Empowering Vision-Language-Action Model with Memory via Dual-Level Recurrent Queries | arXiv | 2026 | [Paper] |
| Beyond Short-Horizon: VQ-Memory for Robust Long-Horizon Manipulation in Non-Markovian Simulation Benchmarks | arXiv | 2026 | [Paper] [Project] |
| Causal Video Models Are Data-Efficient Robot Policy Learners (DVA) | Rhoda AI | 2026 | [Project] |
| DreamZero: World Action Models are Zero-shot Policies | arXiv | 2026 | [Paper] [Project] [Code] |
| MemER: Scaling Up Memory for Robot Control via Experience Retrieval | arXiv | 2025 | [Paper] [Project] |
| Beyond Sliding Windows: Learning to Manage Memory in Non-Markovian Environments | arXiv | 2025 | [Paper] |
| Scaling Short-Term Memory of Visuomotor Policies for Long-Horizon Tasks (PRISM) | Under Review | 2025 | [Project] |
| Learning Long-Context Diffusion Policies via Past-Token Prediction | CoRL | 2025 | [Paper] [Project] |
| SAM2Act: Integrating Visual Foundation Model with A Memory Architecture for Robotic Manipulation | ICML | 2025 | [Paper] |
| A Working Memory Model Improves Cognitive Control in Agents and Robots | COGSYS | 2018 | [Paper] |
| Short-term Memory Mechanisms in Neural Network Learning of Robot Navigation Tasks | IEEE | 2010 | [Paper] |
Episodic Memory
Episodic memory stores specific events and experiences from the robot's past, enabling recall of particular situations, trajectories, and outcomes. It is usually implemented by memory banks, replay buffers, or latent tokens.
| Paper | Venue | Year | Links |
|---|---|---|---|
| Chameleon: Episodic Memory for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| HELM: Harness-Enhanced Long-horizon Memory for Vision-Language-Action Manipulation | arXiv | 2026 | [Paper] |
| MemoryVLA: Perceptual-Cognitive Memory in Vision-Language-Action Models for Robotic Manipulation | arXiv | 2025 | [Paper] |
| Forgetting in Robotic Episodic Long-Term Memory | ECAI | 2024 | [Paper] |
| Long Horizon Episodic Decision Making for Cognitively Inspired Robots | COGSYS | 2024 | [Paper] |
| Episodic Memory Model for Learning Robotic Manipulation | arXiv | 2021 | [Paper] |
| ART Neural Network-based Integration of Episodic Memory and Semantic Memory for Task Planning | AURO | 2019 | [Paper] |
| Deep Episodic Memory: Encoding, Recalling, and Predicting Episodic Experiences for Robot Action Execution | IEEE RAL | 2018 | [Paper] |
| Storing and Retrieving Perceptual Episodic Memories for Long-term Manipulation Tasks | ICAR | 2017 | [Paper] |
| Towards an Episodic Memory for Cognitive Robots | ECAI Workshop | 2008 | [Paper] |
Semantic Memory
Language provides robots with structured knowledge about concepts, objects, and their relationships. It is usually implemented by Neural Symbolic Model, Chain of Thought Reasoning, or Scene Graphs.
| Paper | Venue | Year | Links |
|---|---|---|---|
| EchoVLA: Synergistic Declarative Memory for VLA-Driven Mobile Manipulation | arXiv | 2026 | [Paper] |
| GraSP-VLA: Graph-based Symbolic Action Representation for Long-Horizon Planning with VLA Policies | arXiv | 2025 | [Paper] |
| Enter the Mind Palace: Reasoning and Planning for Long-term Active Embodied Question Answering | arXiv | 2025 | [Paper] |
| Memory-Centric Embodied Question Answering | arXiv | 2025 | [Paper] |
| CRESTA: A Cognitivist Framework for Semantic-driven Task Awareness | RAS | 2025 | [Paper] |
| A Semantic Memory System for Task Planning under Uncertainties | IROS | 2010 | [Paper] |
| KnowRob: Knowledge processing for autonomous robots | IROS | 2009 | [Paper] |
| Robot Task Planning using Semantic Maps | RAS | 2008 | [Paper] |
Long-term Memory
Long-term memory enables continuous accumulation of knowledge across tasks and sessions, supporting lifelong learning and adaptation without catastrophic forgetting. It is usually implemented by experience replay, skill transfer, or continual learning.
| Paper | Venue | Year | Links |
|---|---|---|---|
| MEM: Multi-Scale Embodied Memory for Vision Language Action Models | Physical Intelligence | 2026 | [Paper] [Project] |
| ReMem-VLA: Empowering Vision-Language-Action Model with Memory via Dual-Level Recurrent Queries | arXiv | 2026 | [Paper] |
| Chameleon: Episodic Memory for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| HELM: Harness-Enhanced Long-horizon Memory for Vision-Language-Action Manipulation | arXiv | 2026 | [Paper] |
| EchoVLA: Synergistic Declarative Memory for VLA-Driven Mobile Manipulation | arXiv | 2026 | [Paper] |
| RoboMemory: A Brain-inspired Multi-memory Agentic Framework for Interactive Environmental Learning in Physical Embodied Systems | arXiv | 2025 | [Paper] |
| Preserving and Combining Knowledge in Robotic Lifelong Reinforcement Learning | Nature Machine Intelligence | 2025 | [Paper] |
| LIBERO: Benchmarking Knowledge Transfer for Lifelong Robot Learning | NeurIPS | 2023 | [Paper] |
| Online Active Continual Learning for Robotic Lifelong Object Recognition | IEEE T-NNLS | 2023 | [Paper] |
| Lifelong Robotic Reinforcement Learning by Retaining Experiences | CoLLAs | 2022 | [Paper] |
| A lifelong learning approach to mobile robot navigation | ICRA | 2021 | [Paper] |
| Learning an Embedding Space for Transferable Robot Skills | ICLR | 2018 | [Paper] |
| RoboEarth: A World Wide Web for Robots | IEEE RA Mag | 2011 | [Paper] |
| RatSLAM: A hippocampal model for simultaneous localization and mapping | ICRA | 2004 | [Paper] |
| Lifelong robot learning | RAS | 1995 | [Paper] [Project] |
Memory for Manipulation
Robotics Foundation Models (RFMs)
Because non-markovian property makes RFMs like VLAs prone to overfit, it's a huge challenge for RFMs to learn memory. We need to design spatial-temporal memory mechanisms carefully.
| Paper | Venue | Year | Links |
|---|---|---|---|
| π0.7: A Steerable Model with Emergent Capabilities | Physical Intelligence | 2026 | [Paper] [Project] |
| Causal Video Models Are Data-Efficient Robot Policy Learners (DVA) | Rhoda AI | 2026 | [Project] |
| DreamZero: World Action Models are Zero-shot Policies | arXiv | 2026 | [Paper] [Project] [Code] |
| MEM: Multi-Scale Embodied Memory for Vision Language Action Models | Physical Intelligence | 2026 | [Paper] [Project] |
| ReMem-VLA: Empowering Vision-Language-Action Model with Memory via Dual-Level Recurrent Queries | arXiv | 2026 | [Paper] |
| HELM: Harness-Enhanced Long-horizon Memory for Vision-Language-Action Manipulation | arXiv | 2026 | [Paper] |
| EchoVLA: Synergistic Declarative Memory for VLA-Driven Mobile Manipulation | arXiv | 2026 | [Paper] |
| Beyond Short-Horizon: VQ-Memory for Robust Long-Horizon Manipulation in Non-Markovian Simulation Benchmarks | arXiv | 2026 | [Paper] [Project] |
| OptimusVLA: Global Prior Meets Local Consistency: Dual-Memory Augmented Vision-Language-Action Model for Efficient Robotic Manipulation | CVPR | 2026 | [Paper] |
| MemER: Scaling Up Memory for Robot Control via Experience Retrieval | arXiv | 2025 | [Paper] [Project] |
| HAMLET: Switch your Vision-Language-Action Model into a History-Aware Policy | arXiv | 2025 | [Paper] [Project] |
| HiF-VLA: Hindsight, Insight and Foresight through Motion Representation for Vision-Language-Action Models | arXiv | 2025 | [Paper] |
| CronusVLA: Towards Efficient and Robust Manipulation via Multi-Frame Vision-Language-Action Modeling | ArKiv | 2025 | [Paper] [Project] |
| GraSP-VLA: Graph-based Symbolic Action Representation for Long-Horizon Planning with VLA Policies | arXiv | 2025 | [Paper] |
| MemoryVLA: Perceptual-Cognitive Memory in Vision-Language-Action Models for Robotic Manipulation | arXiv | 2025 | [Paper] |
Mobile Manipulation
| Paper | Venue | Year | Links |
|---|---|---|---|
| EchoVLA: Synergistic Declarative Memory for VLA-Driven Mobile Manipulation | arXiv | 2026 | [Paper] |
| Searching in Space and Time: Unified Memory-Action Loops for Open-World Object Retrieval | arXiv | 2025 | [Paper] [Project] |
| DynaMem: Online Dynamic Spatio-Semantic Memory for Open World Mobile Manipulation | arXiv | 2024 | [Paper] |
| CLIP-Fields: Weakly Supervised Semantic Fields for Robotic Memory | RSS | 2023 | [Paper] [Project] |
General Manipulation
| Paper | Venue | Year | Links |
|---|---|---|---|
| Chameleon: Episodic Memory for Long-Horizon Robotic Manipulation | arXiv | 2026 | [Paper] |
| HELM: Harness-Enhanced Long-horizon Memory for Vision-Language-Action Manipulation | arXiv | 2026 | [Paper] |
| Beyond Short-Horizon: VQ-Memory for Robust Long-Horizon Manipulation in Non-Markovian Simulation Benchmarks | arXiv | 2026 | [Paper] [Project] |
| RMBench: Memory-Dependent Robotic Manipulation Benchmark with Insights into Policy Design | arXiv | 2026 | [Paper] [Project] [Code] |
| Rethinking Progression of Memory State in Robotic Manipulation: An Object-Centric Perspective | AAAI | 2026 | [Paper] |
| Gated Memory Policy | arXiv | 2026 | [Paper] [Project] |
| OptimusVLA: Global Prior Meets Local Consistency: Dual-Memory Augmented Vision-Language-Action Model for Efficient Robotic Manipulation | CVPR | 2026 | [Paper] |
| Learning Long-Context Diffusion Policies via Past-Token Prediction | CoRL | 2025 | [Paper] [Project] |
| SAM2Act: Integrating Visual Foundation Model with A Memory Architecture for Robotic Manipulation | ICML | 2025 | [Paper] |
| Out of Sight, Still in Mind: Reasoning and Planning about Unobserved Objects with Video Tracking Enabled Memory Models | ICRA | 2024 | [Paper] |
| RoboEXP: Action-Conditioned Scene Graph via Interactive Exploration for Robotic Manipulation | CoRL | 2024 | [Paper] [Project] |
Memory for Navigation
Memory is of great importance for navigation, there has been rich research on it.
| Paper | Venue | Year | Links |
|---|---|---|---|
| Remember to be Curious: Episodic Context and Persistent Worlds for 3D Exploration | arXiv | 2026 | [Paper] [Project] [Code] |
| Spatially-Enhanced Recurrent Memory for Long-Range Mapless Navigation via End-to-End Reinforcement Learning | arXiv | 2025 | [Paper] |
| MemoNav: Working Memory Model for Visual Navigation | CVPR | 2024 | [Paper] |
| Memory-Maze: Scenario Driven Benchmark and Visual Language Navigation Model for Guiding Blind People | arXiv | 2024 | [Paper] |
| Visual Language Maps for Robot Navigation (VLMaps) | ICRA | 2023 | [Paper] [Project] |
| Emergence of Maps in the Memories of Blind Navigation Agents | ICLR | 2023 | [Paper] [Project] |
| Memory-Augmented Reinforcement Learning for Image-Goal Navigation | IROS | 2022 | [Paper] |
| Structured Scene Memory for Vision-Language Navigation | CVPR | 2021 | [Paper] |
| Visual Graph Memory with Unsupervised Representation for Visual Navigation | ICCV | 2021 | [Paper] |
| Deep Visual Odometry With Adaptive Memory | TPAMI | 2020 | [Paper] |
| MultiON: Benchmarking Semantic Map Memory using Multi-Object Navigation | NeurIPS | 2020 | [Paper] |
| Scene Memory Transformer for Embodied Agents in Long-Horizon Tasks | CVPR | 2019 | [Paper] |
| Visual Memory for Robust Path Following | NeurIPS | 2018 | [Paper] |
| Cognitive Memory and Mapping in a Brain-like System for Robotic Navigation | Neural Networks | 2017 | [Paper] |
| Learning Indoor Robot Navigation using Visual and Sensorimotor Map | PMC | 2013 | [Paper] |
| Image-based Robot Navigation from an Image Memory | RAS | 2007 | [Paper] |
| 3D Navigation based on a Visual Memory | ICRA | 2006 | [Paper] |
Memory for Locomotion
| Paper | Venue | Year | Links |
|---|---|---|---|
| LocoFormer: Generalist Locomotion via Long-context Adaptation | CoRL | 2025 | [Paper] [Project] |
| Sim-to-Real Transfer for Quadrupedal Locomotion via Terrain Transformer (TERT) | RA-L | 2023 | [Paper] |
| Learning Vision-Guided Quadrupedal Locomotion End-to-End with Cross-Modal Transformers (LocoTransformer) | ICLR | 2022 | [Paper] [Project] |
| RMA: Rapid Motor Adaptation for Legged Robots | RSS | 2021 | [Paper] [Project] |
| Rapidly Adaptable Legged Robots via Evolutionary Meta-Learning | IROS | 2020 | [Paper] [Blog] |
Spatial & Scene Memory
3D Scene Memory
Representing and reasoning about 3D environments.
| Paper | Venue | Year | Links |
|---|---|---|---|
| Remember to be Curious: Episodic Context and Persistent Worlds for 3D Exploration | arXiv | 2026 | [Paper] [Project] [Code] |
| 3D-Mem: 3D Scene Memory for Embodied Exploration and Reasoning | CVPR | 2025 | [Paper] [Project] [Code] |
| What Is The Best 3D Scene Representation for Robotics? | arXiv | 2025 | [Paper] |
| SnapMem: 3D Scene Memory for Embodied Exploration | OpenReview | 2024 | [Paper] |
| Embodied-RAG: General Non-parametric Embodied Memory for Retrieval and Generation | arXiv | 2024 | [Paper] |
| Searching in Space and Time: Unified Memory-Action Loops for Open-World Object Retrieval | arXiv | 2025 | [Paper] [Project] |
| ConceptFusion: Open-set Multimodal 3D Mapping | RSS | 2023 | [Paper] [Project] |
| Hierarchical Representations and Explicit Memory: Learning Effective Navigation Policies on 3D Scene Graphs | ICRA | 2022 | [Paper] |
Spatial Memory & SLAM
Simultaneous Localization and Mapping(SLAM) is the most fundamental explicit type of memory.
| Paper | Venue | Year | Links |
|---|---|---|---|
| Unsupervised Online Learning for Robotic Interestingness with Visual Memory | IEEE T-RO | 2021 | [Paper] [Code] |
| Probabilistic Data Association for Semantic SLAM | ICRA | 2017 | [Paper] |
| SLAM-Based Spatial Memory for Behavior-Based Robots | IFAC | 2015 | [Paper] |
| RGB-D Mapping: Using Kinect-Style Depth Cameras for Dense 3D Modeling of Indoor Environments | IJRR | 2012 | [Paper] |
World Models & Memory
World models that incorporate memory for prediction and planning.
| Paper | Venue | Year | Links |
|---|---|---|---|
| Causal Video Models Are Data-Efficient Robot Policy Learners (DVA) | Rhoda AI | 2026 | [Project] |
| MosaicMem: Persistent Geometry + Dynamic Content for Long-Horizon World Models | arXiv | 2026 | [Paper] [Project] |
| World Model for Robot Learning: A Comprehensive Survey | arXiv | 2026 | [Paper] |
| DreamZero: World Action Models are Zero-shot Policies | arXiv | 2026 | [Paper] [Project] [Code] |
| Mastering Diverse Control Tasks through World Models | Nature | 2025 | [Paper] |
| Ctrl-World: A Controllable Generative World Model for Robot Manipulation | arXiv | 2025 | [Paper] |
| Genie 3: A New Frontier for World Models | Google DeepMind | 2025 | [Blog] |
| ManiGaussian: Dynamic Gaussian Splatting for Multi-task Robotic Manipulation | ECCV | 2024 | [Paper] [Project] |
| Mastering Memory Tasks with World Models (R2I) | ICLR | 2024 | [Paper] |
Lifelong Learning & Continual Learning
Experience Replay
| Paper | Venue | Year | Links |
|---|---|---|---|
| Lifelong Robotic Reinforcement Learning by Retaining Experiences | CoLLAs | 2022 | [Paper] |
| Selective Experience Replay for Lifelong Learning | AAAI | 2018 | [Paper] |
Lifelong Learning Frameworks
| Paper | Venue | Year | Links |
|---|---|---|---|
| Preserving and Combining Knowledge in Robotic Lifelong Learning | Nature MI | 2025 | [Paper] |
| Towards General Purpose Robots at Scale: Memory and Lifelong Learning | arXiv | 2024 | [Paper] |
| A Lifelong Learning Approach to Mobile Robot Navigation | IEEE RAL | 2021 | [Paper] |
Skill Transfer & Memory
| Paper | Venue | Year | Links |
|---|---|---|---|
| Efficient Policy Learning by Extracting Transferable Robot Skills | CoRL | 2024 | [Paper] |
| Unsupervised Skill Transfer Learning for Autonomous Robots | RAS | 2021 | [Paper] |
| Skill Transfer Learning for Autonomous Robots and Human-Robot Cooperation: A Survey | RAS | 2020 | [Paper] |
| Learning an Embedding Space for Transferable Robot Skills | ICLR | 2018 | [Paper] |
Benchmarks & Evaluation
We treasure these features that actually pose challenges to memory:
- Partial observability: occlusions, hidden states, deferred rewards
- Long-horizon: requires recalling earlier observations/instructions
- Distribution shift: new scenes, objects, layouts
- Recovery: can the robots use memory to diagnose and retry?
| Benchmark | Year | Focus | Links |
|---|---|---|---|
| RoboMemArena | 2026 | 26 long-horizon memory tasks with multimodal memory annotations and paired real-world tasks | [Paper] [Project] |
| MIKASA-Robo-VLA | 2026 | 90 memory tasks across 10 memory types for VLA evaluation on tabletop manipulation | [Paper] [Project] [Code] |
| RoboMME | 2026 | 16 manipulation tasks for temporal, spatial, object, and procedural memory in robotic generalist policies | [Paper] [Project] |
| RMBench | 2026 | 9 memory-dependent manipulation tasks over multiple memory-complexity levels | [Paper] [Project] [Code] |
| LIBERO-Mem | 2026 | Object-centric non-Markovian manipulation under object-level partial observability | [Paper] |
| MemMimic | 2026 | Non-Markovian imitation tasks with in-trial and cross-trial memory regimes | [Paper] [Project] |
| AbstainEQA | 2025 | Benchmarks abstention in embodied QA — when agents should say "I don't know" — across 5 categories with 1,636 ambiguous question variants; frontier models reach only 42.79% abstention recall vs. 91.17% for humans | [Paper] [Project] [Code] |
Read more: docs/evaluation.md
Datasets
See: docs/datasets.md
Citation
If you find this repository useful, please consider citing:
@misc{awesome-memory-for-robotics,
  author = {Jie Wang},
  title = {Awesome Memory for Robotics},
  year = {2025},
  publisher = {GitHub},
  howpublished = {\url{https://github.com/Everloom-129/Awesome-Memory-for-Robotics}}
}
Contributing
PRs welcome! Please read the contribution guidelines.
To add a new paper or resource:
- Fork this repository
- Add your entry in the appropriate section
- Submit a pull request
Please ensure your PR follows the existing format and includes:
- Paper title
- Venue and year
- Links to paper, code, and project page (if available)
Related Awesome Lists
License
This work is licensed under CC0 1.0 Universal.
⭐ Star this repository if you find it useful! ⭐